DRIVER MODEL ANALYSIS USING CUSTOMISED DRIVE CYCLE AND PERFORMING WOT ANALYSIS ON GMEV1 CAR.
DRIVER MODEL ANALYSIS USING CUSTOMISED DRIVE CYCLE AND PERFORMING WOT ANALYSIS ON GMEV1 CAR
OBJECTIVE:
- To find the ratio of hill-climbing power required by fully loaded tata ultra truck to the half-loaded one.
- To find how much can be the minimum length of the flyover, considering the minimum height at the summit should be 5.5 meters.
- To prepare a new drive cycle excel file representing hill climbing angle corresponding to speed and time.Revise the model file "driver_glider.slx" such that it can calculate gradient force from drive cycle.
- Model the WOT (wide open throttle ) of GM EV1 car.Compare it with the official figures of the performance of a real vehicle. prepare a table showing variation in acceleration time with 5% change in vehicles parameters.
STUDY_1:
- Ratio of hill climbing power required by fully loaded TATA truck to the half loaded one.
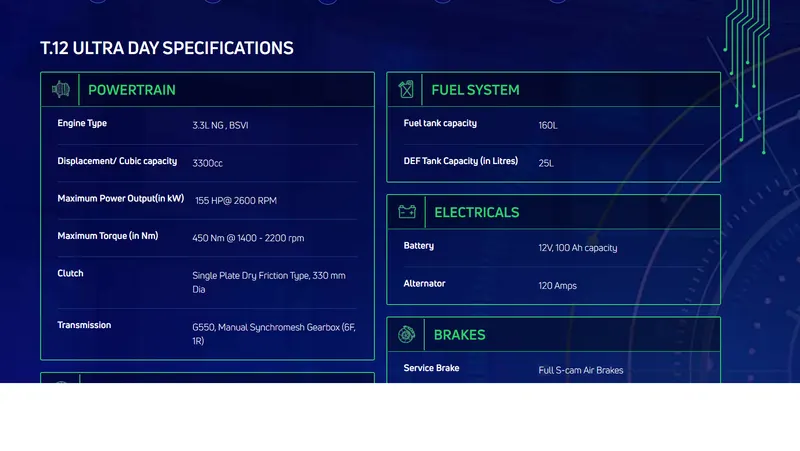
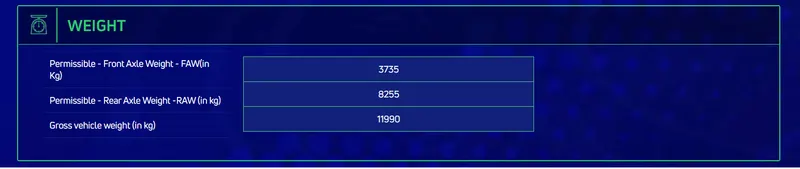
VEHICLE AT FULL LOAD
Gross vehicle weight= kerb weight +payload
=3735+8255
=11990kg
Gradeability=25.6% Therefore angle = 15 degrees
Hill climbing force=mass *gravity*sin(`theta`)
=11990*9.81*sin(15)
=76448.1N
Considering velocity of the vehicle= 25 kmph or 7 m862.5/s
Calculating the hill climbing power = hill climbing force * velocity of the vehicle
=76448.1*7
power at full load=535136.7W
VEHICLE AT HALF LOAD
Gross vehicle weight= kerb weight +payload/2
=3735+8255/2
=7862.5 kg
Hill climbing force= mass*gravity*sin(`theta`)
=7862.5*9.81 *sin(15)
=50157.45N
Considering velocity of the vehicle = 7m/s
Hill climbing power= hill climbing force *velocity of the vehicle
=50157.45*7
power at half load =351102W
Ratio of powers= power at full load /power at half load
535136.7/50157.45 = 1.524
STUDY_2:
MINIMUM LENGTH OF FLYOVER, SUMMIT MINIMUM HEIGHT 5.5M
Given, rise =5.5m
angle=15 degrees
since it is a right angle triangle
sin(theta)=5.5/ length
sin(15) =5.5/length
minimum length of flyover= 21.25meters
Applying pythagoras theorem
=length^2=rise^2+run^2
minimum run of flyover = 20.5meters
STUDY-3:
Prepare a new drive cycle excel file for the model and also include a hill climbing angle to it.
Input for driver_glider.slx file is made in excel.
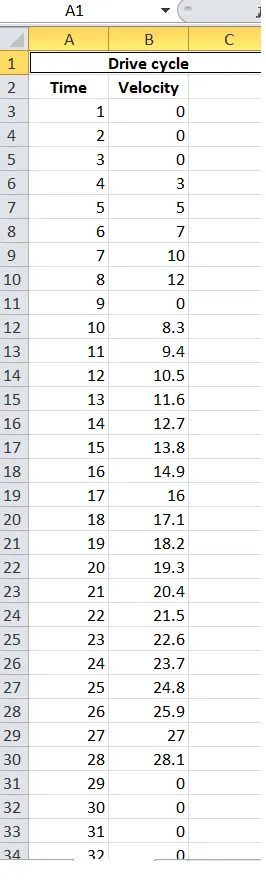
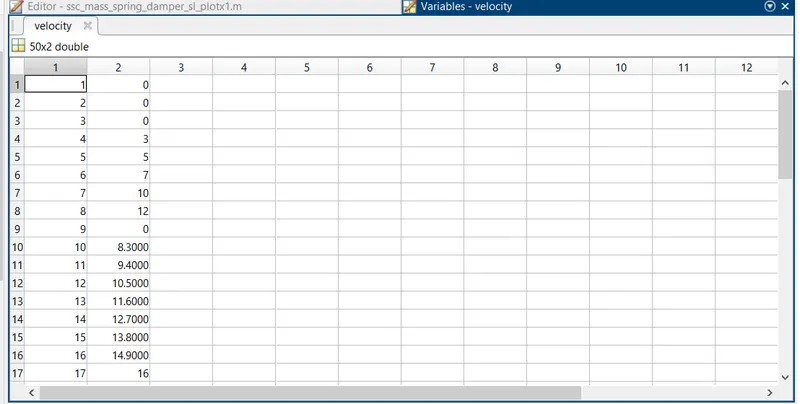
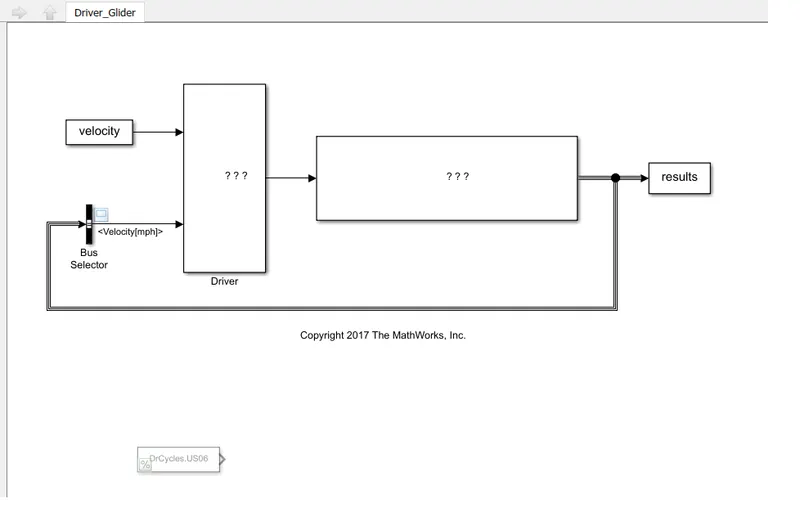
Giving this drive cycle as input for the existing driver_glider.slx model. we need to import this excel data to MATLAB workspace by using import data option .so this file is imported by using the name "velocity",
and is shown in workspace in matlab'.
The instructions given in help section article was followed.After importing and replacing the new drive cycle through workspace , the simulink model looks ike this:
MODEL:
DRIVE CYCLE GOOGLE SHEET LINK AS INPUT:https://drive.google.com/file/d/13VyTrmMwR5k0TPbeUjlv7lTd8imMjPv0/view?usp=sharing
OUTPUT:
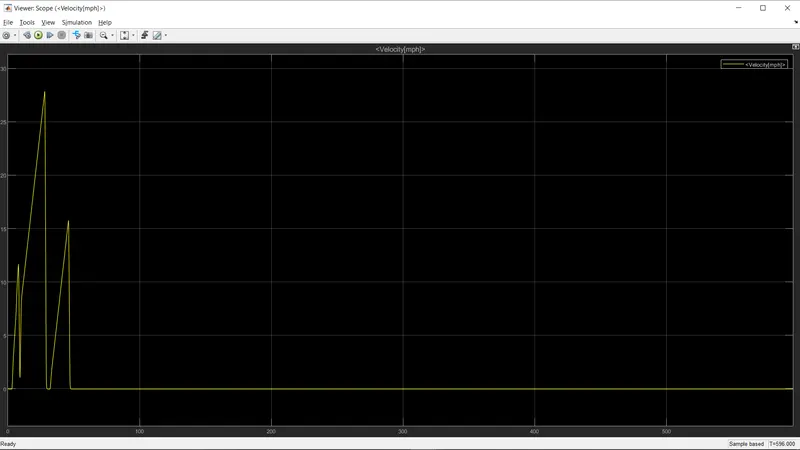
STUDY_3:
Modelling the WOT (Wide Open Throttle) response of GM EV1 car and Comparing it with the official figures of the performance of a real vehicle. Prepare a table showing variation in acceleration time with a 5% change in vehicle parameters.
Theory:
Wide open throttle(WOT) refers to an engine maximum intake of air and fuel that occurs when the throttle plates inside the carbuerettoror throttle body are "wide open".Providing the least resistance to the incoming air. In the case of an automobile. WOT is when the accelerator is depressed fully. In the case of a diesel engine which does not have a throttle value ,WOT is the point t whivh the maximum amount of fuel is being injected relative to the amount pumped by the engine, generally in order to bring the fuel-air mixture upto the stoichiometric point.
Given GMEV1 data:
Mass of vehicle=1540kg
Drag coefficient Cd =0.19
Angular velocity=733rad/sec
coefficient(rolling resistance)=0.0048
Gear ratio=11
Efficiency of drive =0.95
Tyre radius=0.3m
Critical velocity= 19.8 m/s
Motor torque =140 nm
Motor speed=12000rpm
Constant power=102kW
Maximum velocity=35.8m/s
CASE 1= PARAMETERS OF GMEV1 VALUES:
A] Below critical velocity (19.8m/s) we use this below equation: Here torque is constant but power varies .
`dv=dT.(3.07901-0.00013698.v^2)`
B] Between critical velocity (19.8m/s) and cutoff velocity (35.8m/s). we use this below equation:
`dv=dT*((61.5227/v)-0.04648-(0.00013698*v^2))`
CASE 2= PARAMETERS OF GMEV1 VALUES WITH 5% INCREASE:
A] Below critical speed velocity (19.8m/s) we use this below equation: Here torque is constant but power varies.
`dv=dT*(2.92839-0.00013698*v^2)`
B] between critical velocity(19.8m/s) and cutoff velocity (35.8m/s). we use this below equation:
`dv=dT*((58.6083/v)-0.04880-(0.00013689*v^2))`
IMPLEMENTING FORMULAS IN EXCEL TO FIND OUT ACCELERATION TIME FOR GMEV1 VALUES AND FOR GMEV1 VALES WITH 5% INCREASE :
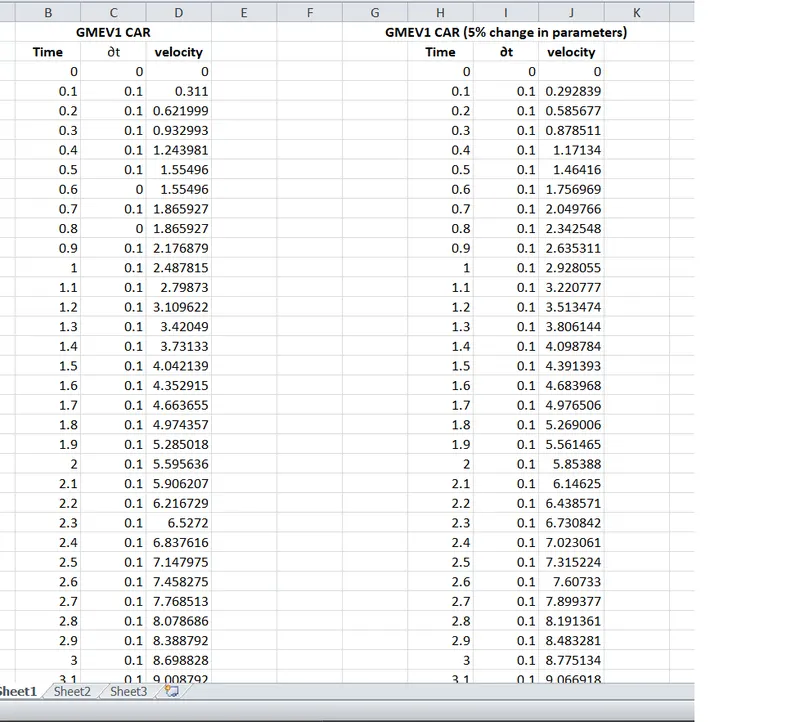
FORMULAS IN VEHICLE COLOUMN
Below critical speed-
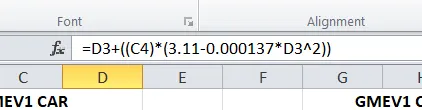
Between critical velocity and cutoff velocity-
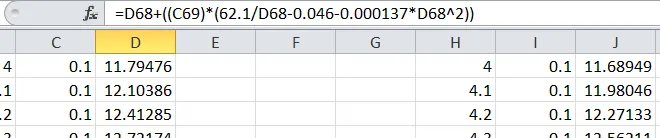
google sheet link :https://docs.google.com/spreadsheets/d/1D_U9m4YFY1JwsOlLZdjByk16XEYt9ggSvK9-9Iw7YFc/edit?usp=sharing
Similarly, this process is repeated with 5% change in vehicle parameters. and it is clearly evident from the data in excel sheet that the velocity of the vehicle remains constant after it reaches its maximum value thus we conclude that vehicle 1 reaches its top speed in 24 seconds whereas vehicle 2 with 5% increse in parametrs reaches its top speed in 15 secs.
CONCLUSION:
Thus we have successfully completed all the questions with proper output and matlab code .
Study1- Ratio of powers=1.524
Study2- Minimum length of flyover=20.5meters
Study3- Graphical representation
Study4- Googlesheet link.