Design of an Electric Vehicle
Electric Vehicle
Electric vehicles are also called Battery Electric Vehicles (BEV). These are fully-electric vehicles with rechargeable batteries and no gasoline engine. Battery electric vehicles store electricity onboard with high-capacity battery packs. Their battery power is used to run the electric motor and all onboard electronics. BEVs do not emit any harmful emissions and hazards caused by traditional gasoline-powered vehicles. BEVs are charged by electricity from an external source. Electric Vehicle (EV) chargers are classified according to the speed with which they recharge an EVs battery.
The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. Optionally include pitch and suspension dynamics. The vehicle does not move vertically relative to the ground.
The block has an option to include an externally-defined mass and externally-defined inertia. The mass, inertia, and center of gravity of the vehicle body can vary over the course of simulation in response to system changes.
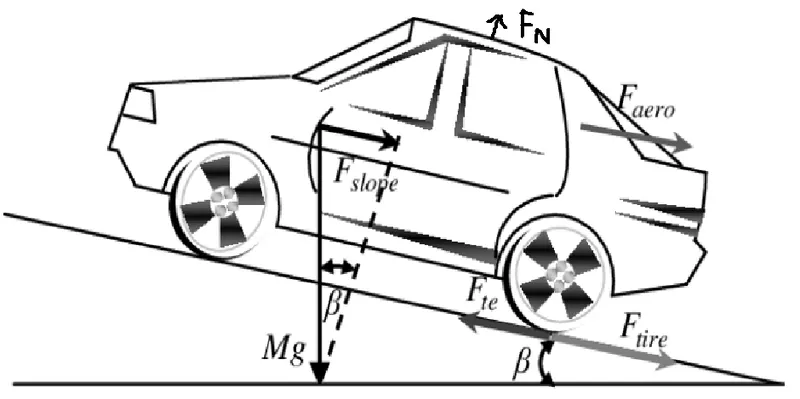
1. Rolling Resistance Force
Rolling resistance sometimes called rolling friction or rolling drag, is the force resisting the motion when a body (such as a ball, tire, or wheel) rolls on a surface.
Force due to rolling resistance is given by the equation
Frr=μrr⋅m⋅g">Frr=μrr⋅m⋅gFrr=μrr⋅m⋅g where
μ">μμ =coefficient of rolling resistance
m">mm = mass of the vehicle in kg
g">gg = acceleration due to gravity (9.81ms-2">ms−2ms-2)
2. Aero Dynamic Drag
Aerodynamic force is due to the friction of the vehicle body moving through the air. It is a function of the frontal area, shape, protrusions such as side mirrors, ducts and air passages, spoilers and many other factors.
Force due to aerodynamic drag is given by
Fad=12⋅ρ⋅A⋅Cd⋅v2">Fad=12⋅ρ⋅A⋅Cd⋅v2Fad=12⋅ρ⋅A⋅Cd⋅v2 where
ρ">ρρ is density of air
A">AA is frontal area of the vehicle
Cd">CdCd is drag coefficient
v">vv is velocity of vehicle
3. Force due to Gravity
The weight of the vehicle is defined as the force of gravity on the object and may be calculated as the mass times the acceleration of gravity. Force due to gravity is given by
FGravity=m⋅g">FGravity=m⋅gFGravity=m⋅g
m">mm is mass of the vehicle in kg
g">gg is the acceleration due to gravity (g">gg =9.81 ms-2">ms−2ms-2)
4. Normal Force
The force that surfaces exerts to prevent solid objects from passing through each other. The normal force is a contact force. It is the force that is perpendicular to the surface that an object contacts.
On a flat surface, the Normal Force= Force due to Gravity and on an inclined plane, it is equal in magnitude and opposite in direction to the vertical component of the force due to gravity that is perpendicular to the inclined surface.
5. Force due to Slope
It is an additional force needed to drive the vehicle up a slope. It is dependent on the slope angle and it is simply the component of the vehicle weight that acts along the slope. The force due to hill climb is given by
Fhc=mgsin(β)">Fhc=mgsin(β)Fhc=mgsin(β) where
m">mm is mass of the vehicle in kg
g">gg is the acceleration due to gravity (g">gg =9.81 ms-2">ms−2ms-2)
β">ββ is slope angle in radians
6. Traction Force
Traction or tractive force is the force used to generate motion between a body and a tangential surface. It is the force generated by the powertrain of the vehicle to overcome all the external and internal forces resisting the motion.
The Traction Force is given by
Fte=Frr+Fad+Fhc+Fla+Fwa">Fte=Frr+Fad+Fhc+Fla+FwaFte=Frr+Fad+Fhc+Fla+Fwa where
Frr">FrrFrr is the Rolling Resistance Force
F(ad)">F(ad)F(ad) is the Aero Dynamic Drag Force
Fhc">FhcFhc is Hill Climb Force
Fla">FlaFla is Force required for Linear Acceleration
Fwa">FwaFwa is force required to give Angular Acceleration to motor
Linear Acceleration Force
The force required to accelerate the vehicle from a state of motion to another is called the Linear Acceleration Force.
The Linear Acceleration Force is given by
Fla=m⋅a">Fla=m⋅aFla=m⋅a where
m">mm is the mass of the vehicle in kg
a">aa is the acceleration in ms-2">ms−2ms-2
Angular Acceleration Force
The force exerted by the moment of inertia of the motor is called Angular Acceleration Force. It is not because of its particularly high moment of inertia, but because of the higher angular speeds.
It will quite often turn out that the moment of inertia of the motor I will not be known. In such cases, a reasonable approximation is simply to increase the mass of the vehicle by 5% in the equation Fla=m⋅a">Fla=m⋅aFla=m⋅a and ignore the Fωa term.
The Force due to Angular Acceleration is given by
Fwa=I⋅G2ηg⋅r2⋅a">Fwa=I⋅G2ηg⋅r2⋅aFwa=I⋅G2ηg⋅r2⋅a where
I">II is the moment of Intertia in kgm2">kgm2kgm2
G">GG is the gear ratio
ηg">ηgηg is the efficiency of gear system
r">rr is the radius of tire
a">aa is the linear acceleration required.
Drive Cycle
A driving cycle is a series of data points representing the speed of a vehicle versus time. Driving cycles are produced by different countries and organizations to assess the performance of vehicles in various ways, as for instance fuel consumption, electric vehicle autonomy, and polluting emissions.
FTP Drive Cycle
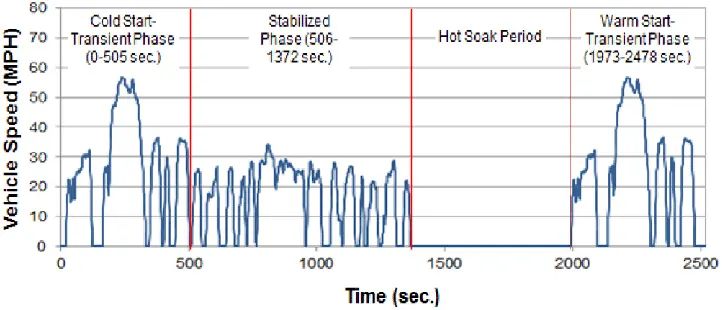
The FTP-75 (Federal Test Procedure) has been used for emission certification and fuel economy testing of light-duty vehicles in the United States. The test is often referred to as simply ‘FTP’ (this should not be confused with the FTP test for heavy-duty engines).
The FTP-75 and the FTP-72 are two variants of the EPA Urban Dynamometer Driving Schedule (UDDS). The FTP-75 cycle is derived from the FTP-72 by adding a third phase of 505 s, identical to the first phase of FTP-72 but with a hot start. The third phase starts after the engine is stopped for 10 minutes.
Thus, the entire FTP-75 cycle consists of the following segments:
- Cold start transient phase (ambient temperature 20-30°C), 0-505 s,
- Stabilized phase, 506-1372 s,
- Hot soak (min 540 s, max 660 s),
- Hot start transient phase, 0-505 s.
Braking in Electrical Vehicle
1. Mechanical braking system:
The mechanical braking system powers the hand brake or emergency brake. It is the type of braking system in which the brake force applied on the brake pedal is carried to the final brake drum or disc rotor by the various mechanical linkages like cylindrical rods, fulcrums, springs, etc. In order to stop the vehicle.
2.Electric braking
The conversion of the mechanical energy of a rotating shaft to electrical energy (electric generator) to decrease reduce the speed of the vehicle is called dynamic braking. The dynamic braking slows down a moving vehicle or object by converting its kinetic energy into a form that can be either used immediately or stored until needed. In this mechanism, the electric traction motor uses the vehicle's momentum to recover energy that would otherwise be lost to the brake discs as heat. The interactions of armature windings with a (relatively) moving external magnetic field, with the armature connected to an electrical circuit with either a power supply (motor) or power receptor (generator). Since the role of the electrical/mechanical energy converting device is determined by which interface (mechanical or electrical) provides or receives energy, the same device can fulfill the role of either a motor or a generator. In dynamic braking, the traction motor is switched into the role of a generator by switching from a supply circuit to a receptor circuit while applying electric current to the field coils that generate the magnetic field (excitation).
The amount of resistance applied to the rotating shaft (braking power) equals the rate of electrical power generation plus some efficiency loss. That is proportional to the strength of the magnetic field, controlled by the current in the field coils, and the rate at which the armature and magnetic field rotate against each other, determined by the rotation of the wheels and the ratio of a power shaft to wheel rotation. The amount of braking power is controlled by varying the strength of the magnetic field through the amount of current in the field coils. As the rate of electrical power generation, and conversely braking power, are proportional to the rate at which the power shaft is spinning, a stronger magnetic field is required to maintain braking power as speed decreases and there is a lower limit at which dynamic braking can be effective depending on the current available for application to the field coils.
The two main methods of managing the electricity generated during dynamic braking are rheostatic braking and regenerative braking, as described below.
For permanent magnet motors, dynamic braking is easily achieved by shorting the motor terminals, thus bringing the motor to a fast abrupt stop. This method, however, dissipates all the energy as heat in the motor itself, and so cannot be used in anything other than low-power intermittent applications due to cooling limitations. It is not suitable for traction applications.
PWM Duty Cycle Control
Pulse-width modulation (PWM), or pulse-duration modulation (PDM), is a method of reducing the average power delivered by an electrical signal, by effectively chopping it up into discrete parts. The average value of voltage (and current) fed to the load is controlled by turning the switch between supply and load on and off at a fast rate. The longer the switch is on compared to the off periods, the higher the total power supplied to the load. PWM is particularly suited for running inertial loads such as motors, which are not as easily affected by this discrete switching because their inertia causes them to react slowly. The PWM switching frequency has to be high enough not to affect the load, which is to say that the resultant waveform perceived by the load must be as smooth as possible.
Pulse-width modulation uses a rectangular pulse wave whose pulse width is modulated resulting in the variation of the average value of the waveform. If we consider a pulse waveform f(t), with period T, low-value ymin, a high value ymax, and a duty cycle D.
`bary = 1/T ∫ _0^T f(t)dt`
H- Bridge (Power Converter)
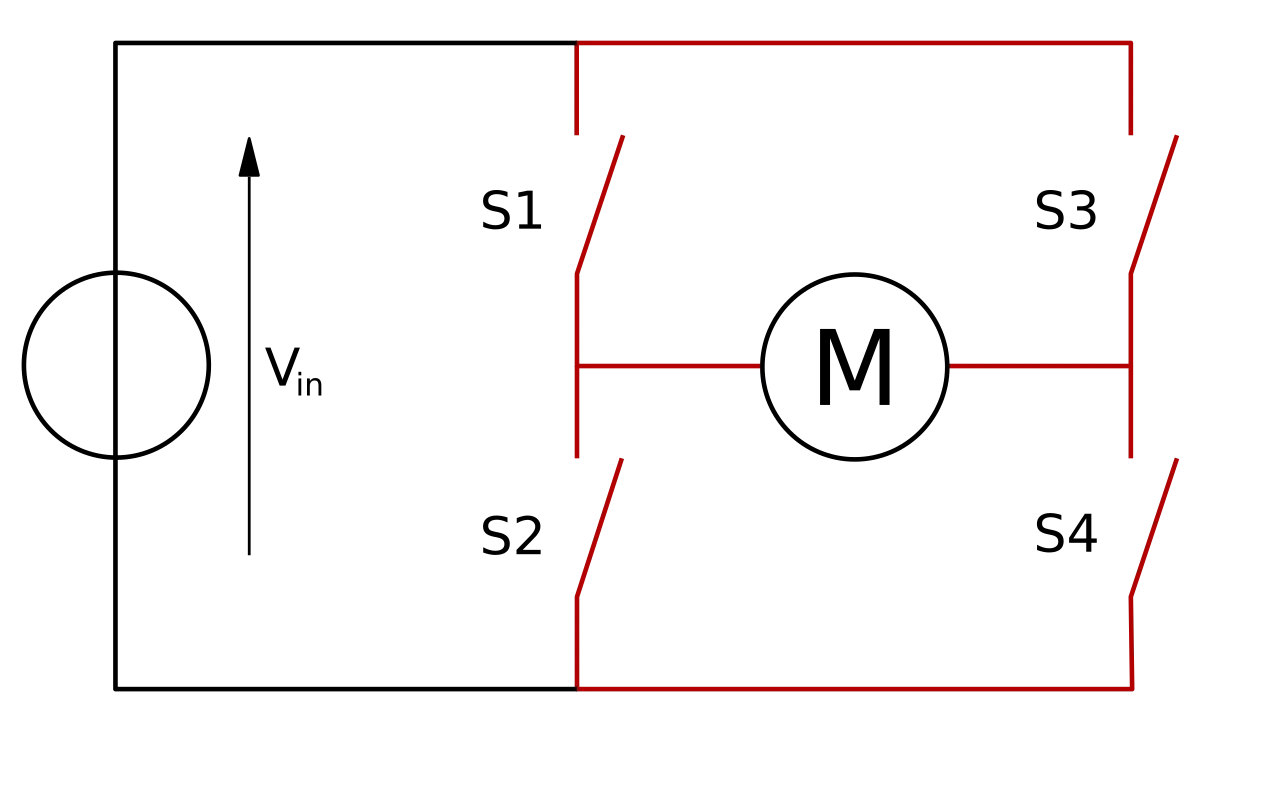
An H-bridge is an electronic circuit that switches the polarity of a voltage applied to a load. These circuits are often used in robotics and other applications to allow DC motors to run forwards or backward. Most DC-to-AC converters (power inverters), most AC/AC converters, the DC-to-DC push-pull converter, most motor controllers, and many other kinds of power electronics use H bridges.
The term H bridge is derived from the typical graphical representation of such a circuit. An H bridge is built with four switches (solid-state or mechanical). When the switches S1 and S4 (according to the first figure) are closed (and S2 and S3 are open) a positive voltage will be applied across the motor. By opening S1 and S4 switches and closing S2 and S3 switches, this voltage is reversed, allowing reverse operation of the motor.
Using the nomenclature above, the switches S1 and S2 should never be closed at the same time, as this would cause a short circuit on the input voltage source. The same applies to the switches S3 and S4. This condition is known as shoot-through.
PI Controller
A P.I Controller is a feedback control loop that calculates an error signal by taking the difference between the output of a system, which in this case is the power being drawn from the battery, and the set point.
The setpoint is the level at which we’d like to have our system running.
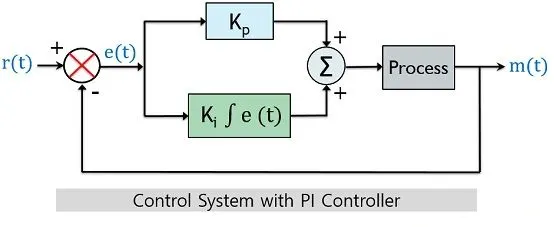
Battery State of Charge
State of Charge (SoC) is the level of charge of an electric battery relative to its capacity. The units of SoC are percentage points (0% = empty; 100% = full). An alternative form of the same measure is the depth of discharge (DoD), the inverse of SoC (100% = empty; 0% = full). SoC is normally used when discussing the current state of a battery in use, while DoD is most often seen when discussing the lifetime of the battery after repeated use.
This method, also known as "coulomb counting", calculates the SoC by measuring the battery current and integrating it in time. Since no measurement can be perfect, this method suffers from long-term drift and lack of a reference point: therefore, the SoC must be re-calibrated on a regular basis, such as by resetting the SoC to 100% when a charger determines that the battery is fully charged (using one of the other methods described here).
DC Motor
A DC motor is any of a class of rotary electrical motors that converts direct current electrical energy into mechanical energy. The most common types rely on the forces produced by magnetic fields. Nearly all types of DC motors have some internal mechanism, either electromechanical or electronic, to periodically change the direction of current in a part of the motor.
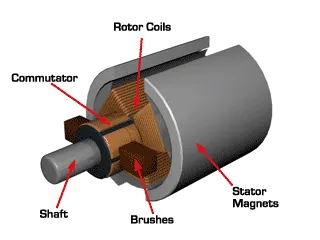
Equivalent Circuit of Permanent Magnet DC Motor or PMDC Motor
As in the PMDC motor, the field is produced by a permanent magnet, there is no need for drawing field coils in the equivalent circuit of a permanent magnet DC motor.
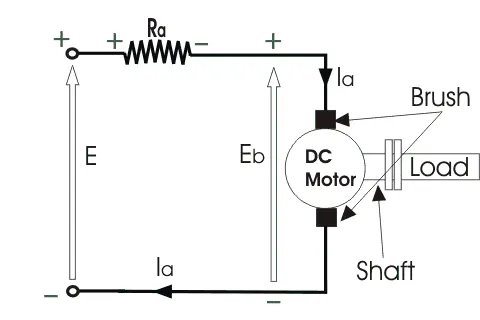
The supply voltage to the armature will have armature resistance drop and the rest of the supply voltage is countered by the back emf of the motor. Hence the voltage equation of the motor is given by,
`V=I_aR_a+V_(b)`
Where I is armature current and R is armature resistance of the motor.
Eb is the back emf and V is the supply voltage.
2. Model parameters
Matlab EV Model
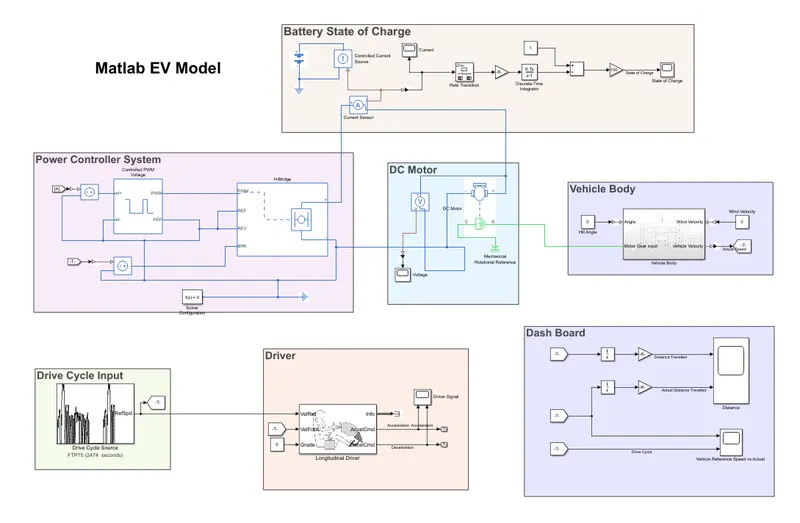
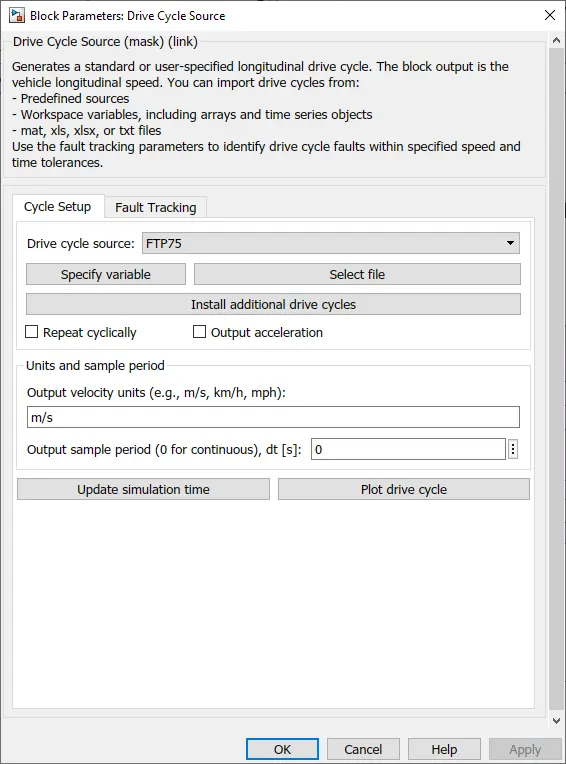
a. Drive Cycle
The Drive Cycle Source block generates a standard or user-specified longitudinal drive cycle. The block output is the specified vehicle longitudinal speed, which you can use to:-
- Predict the engine torque and fuel consumption that a vehicle requires to achieve the desired speed and acceleration for a given gear shift reference.
- Produce realistic velocity and shift references for closed-loop acceleration and braking commands for vehicle control and plant models.
- Study, tune, and optimize vehicle control, system performance, and system robustness over multiple drive cycles.
- Identify the faults within tolerances specified by standardized tests
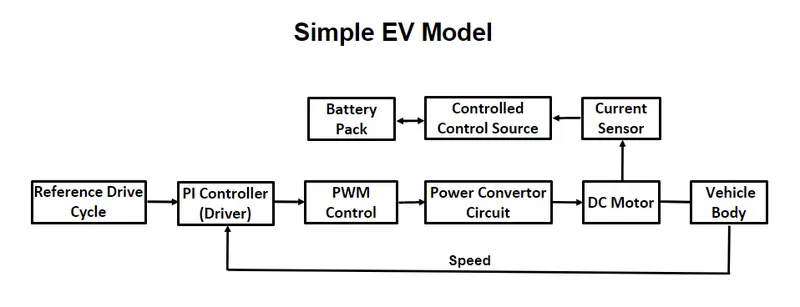
The FTP75 is given as the reference input to the Pi Controller Driver.
b. PI Controller
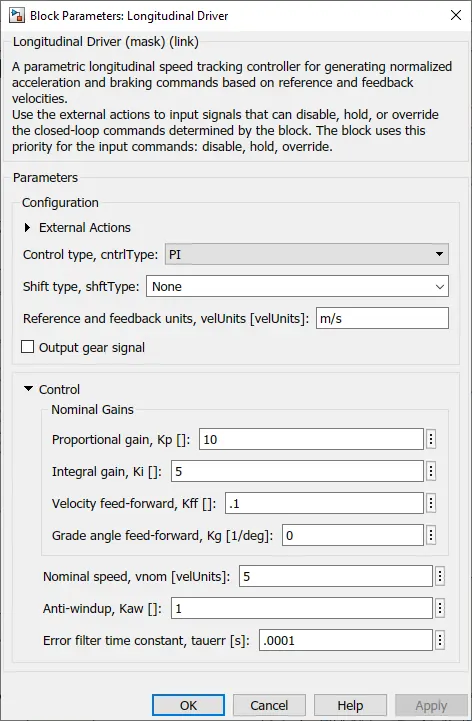
The Longitudinal Driver block implements a longitudinal speed-tracking controller. Based on reference and feedback velocities, the block generates normalized acceleration and braking commands that can vary from 0 through 1. You can use the block to model the dynamic response of a driver or to generate the commands necessary to track a longitudinal drive cycle.
c. PWM Duty Cycle Control
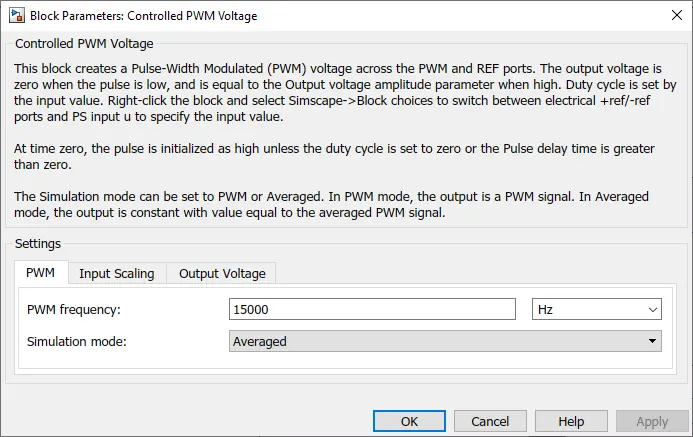
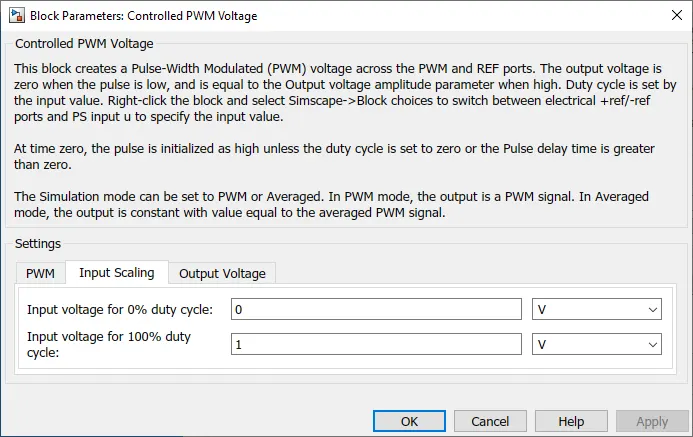
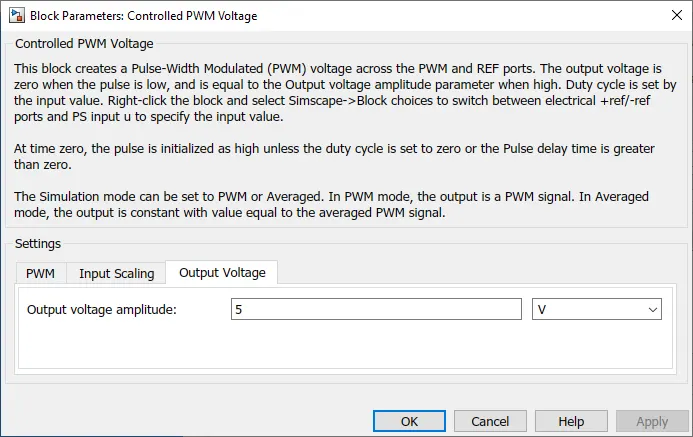
The Controlled PWM Voltage block represents a pulse-width modulated (PWM) voltage source. The signal from the PI Controller is fed into the PWM Generator. The input scaling must be adjusted as the max input by PI Controller will be 1V and the Output is scaled to a voltage of 5V. For example, the input of 1 will generate a 100% duty cycle and the signal voltage will be 5V from the PWM Source.
d. H-Bridge
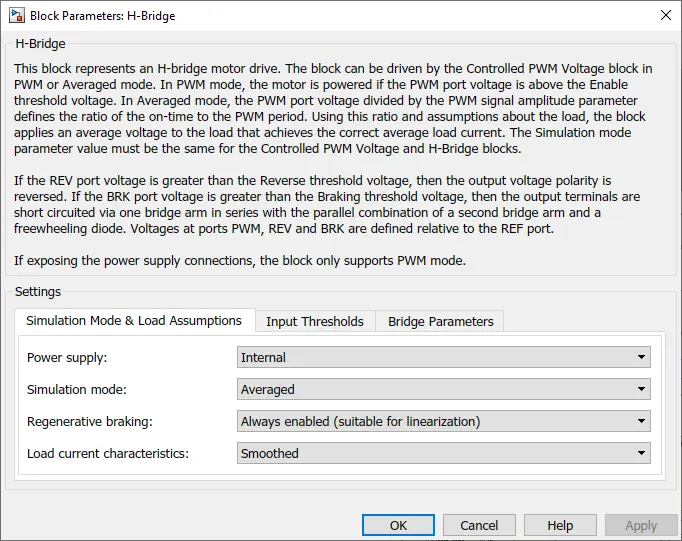
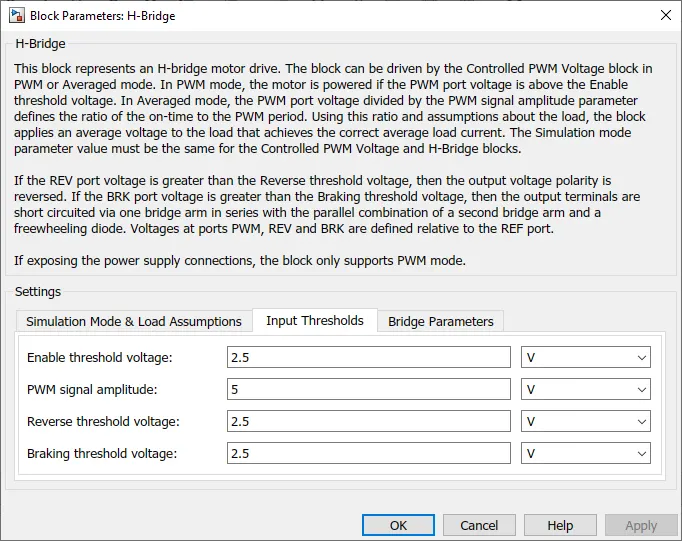
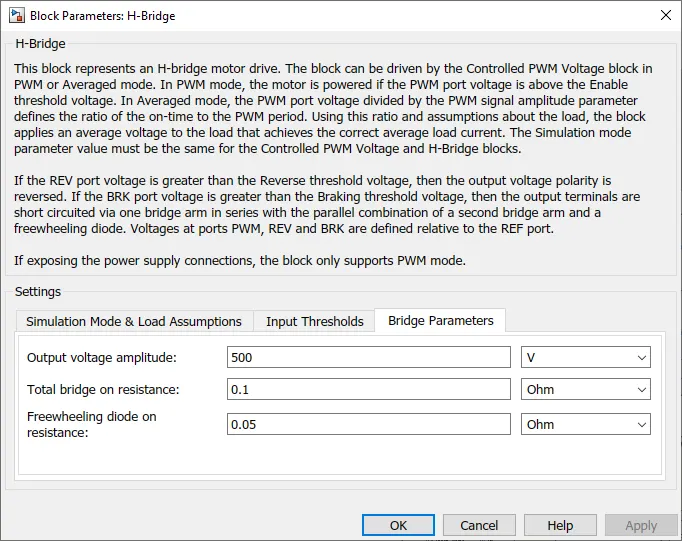
The H-Bridge block represents an H-bridge motor driver. Simulation mode parameter to Averaged in order to speed up simulations when driving the H-Bridge block with a Controlled PWM Voltage block. You must also set the Simulation mode parameter of the Controlled PWM Voltage block to Average mode. This applies the average of the demanded PWM voltage to the motor. The accuracy of the Averaged mode simulation results relies on the validity of your assumption about the load current. If you specify that the current is unsmoothed or discontinuous, then the accuracy also depends on the values you provide for load resistance and inductance being representative. This mode also makes some simplifying assumptions about the underlying equations for the case when the current is discontinuous.
e. DC Motor
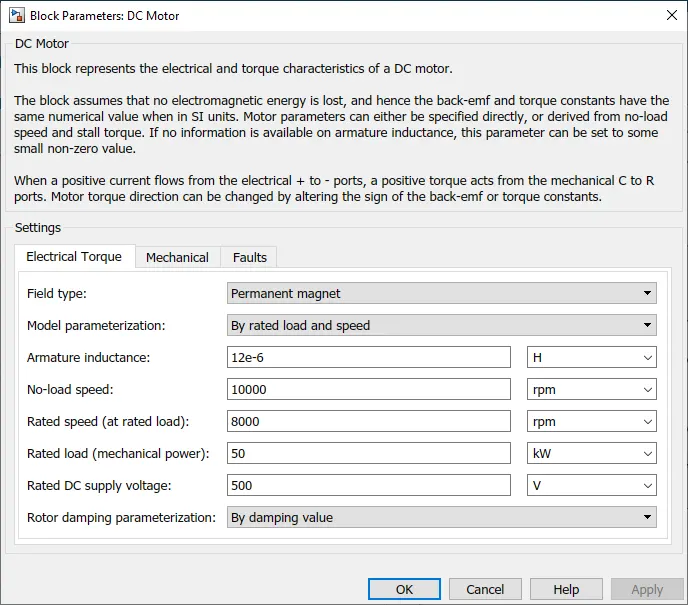
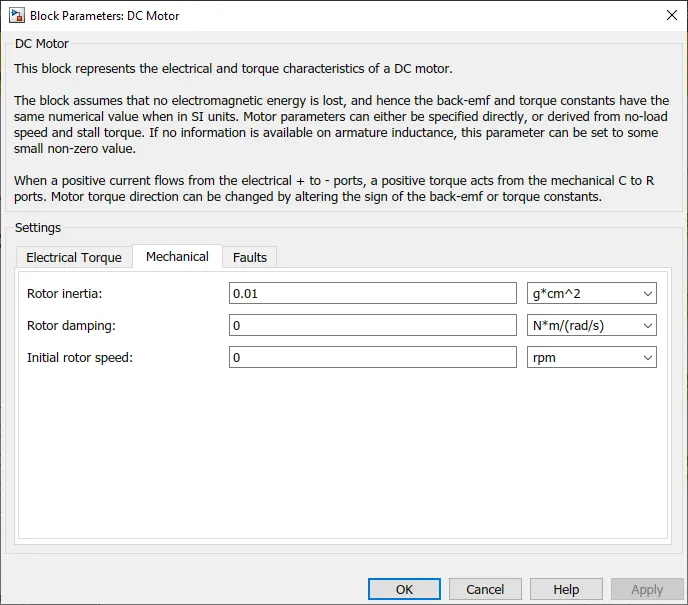
The DC Motor parameters are set based not the rated load and the speed(RPM) requirement by the vehicle design calculations explained above. Here we choose a 50kW motor with a max RPM of 10000 at no load. The input supply rating is set to 500V.
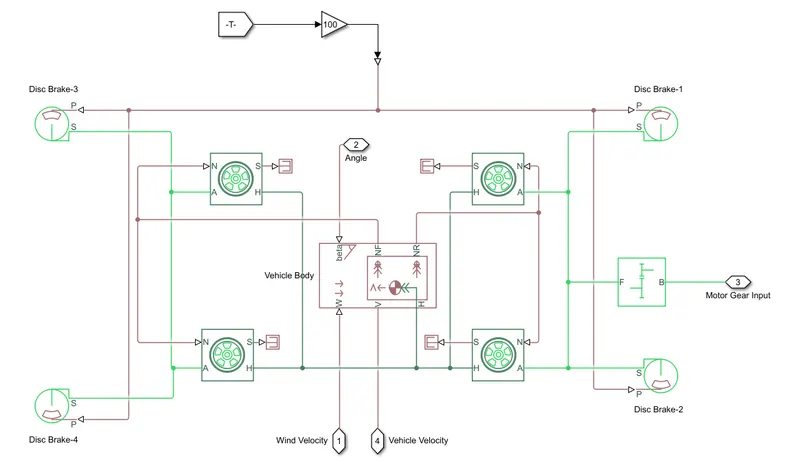
f. Vehicle Body
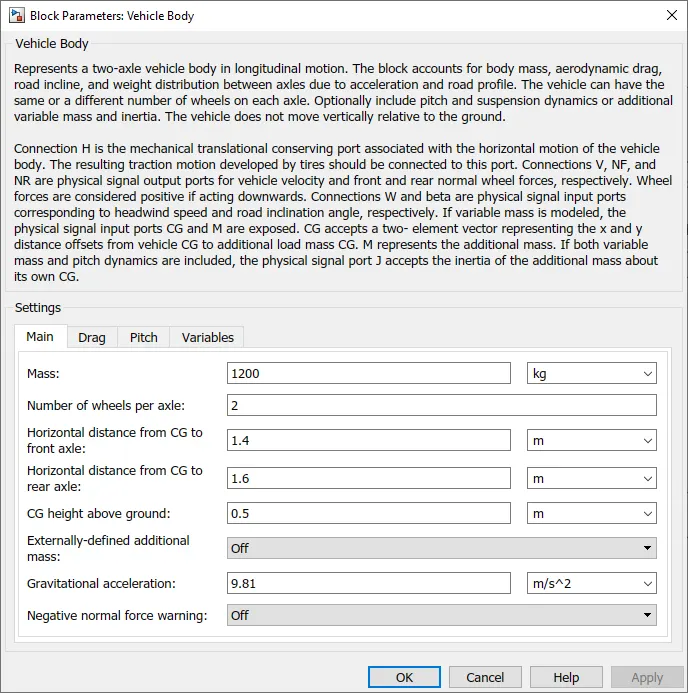
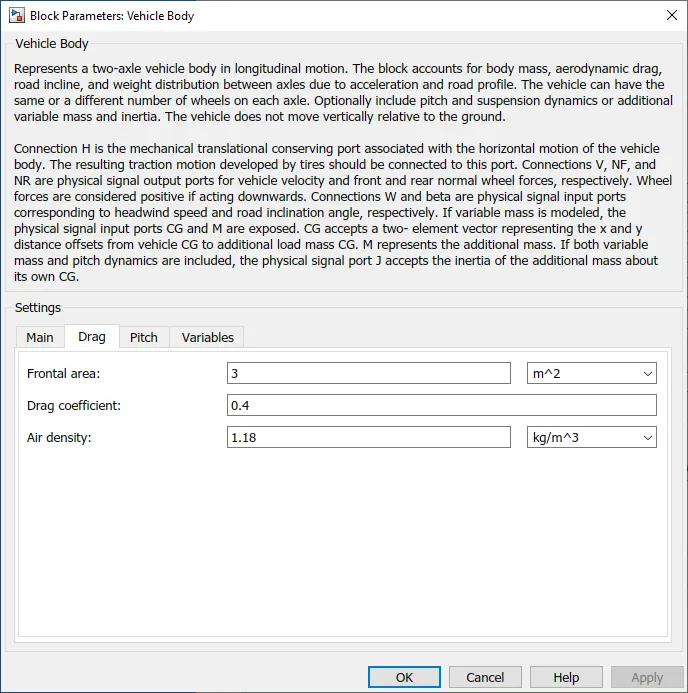
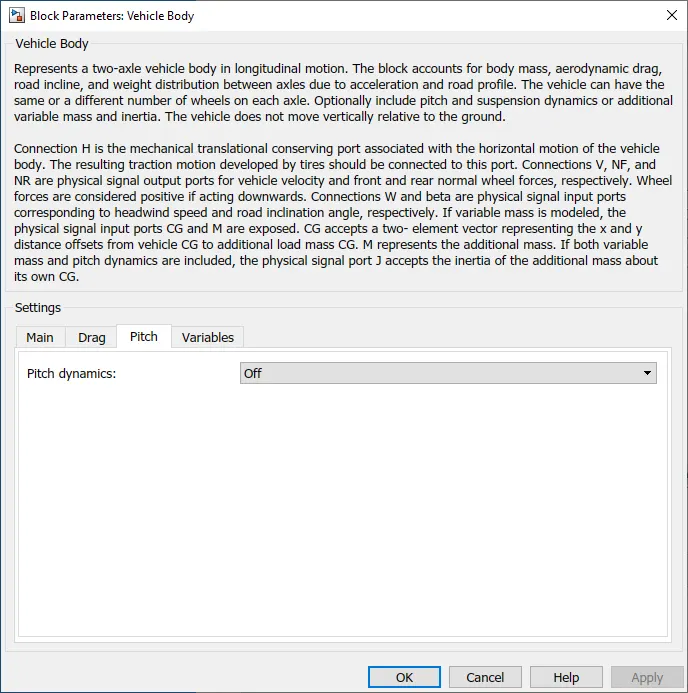
The Vehicle Body block represents a two-axle vehicle body in longitudinal motion. The vehicle can have the same or a different number of wheels on each axle. For example, two wheels on the front axle and one wheel on the rear axle. The vehicle wheels are assumed identical in size. The vehicle can also have a center of gravity (CG) that is at or below the plane of travel.
The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. Optionally include pitch and suspension dynamics. The vehicle does not move vertically relative to the ground.
The block has an option to include an externally-defined mass and externally-defined inertia. The mass, inertia, and center of gravity of the vehicle body can vary over the course of simulation in response to system changes.
g. Tire
The Tire (Magic Formula) block models the tire as a rigid wheel-tire combination in contact with the road and subject to slip. When torque is applied to the wheel axle, the tire pushes on the ground (while subject to contact friction) and transfers the resulting reaction as a force back on the wheel. This action pushes the wheel forward or backward. We can specify properties such as tire compliance, inertia, and rolling resistance, etc.
h. Gear
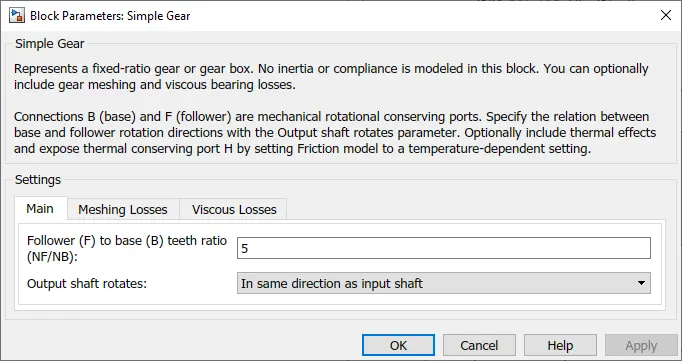
The Simple Gear block represents a gearbox that constrains the connected driveline axes of the base gear, B, and the follower gear, F, to corotate with a fixed ratio that you specify. You choose whether the follower axis rotates in the same or opposite direction as the base axis. If they rotate in the same direction, the angular velocity of the follower, ωF, and the angular velocity of the base, ωB, have the same sign. If they rotate in opposite directions, ωF and ωB have opposite signs.
i. Disc Brake
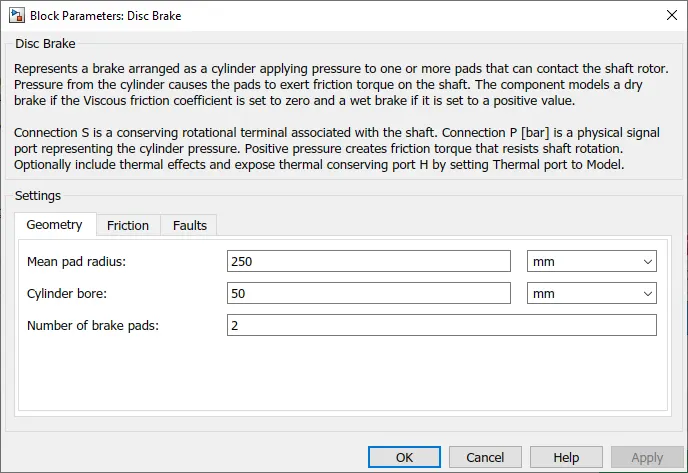
The Disc Brake block represents a brake arranged as a cylinder applying pressure to one or more pads that can contact the shaft rotor. Pressure from the cylinder causes the pads to exert friction torque on the shaft. The friction torque resists shaft rotation.
You can also enable faulting. When faulting occurs, the brake will exert a user-specified pressure. Faults can occur at a specified time or due to an external trigger
3. Results
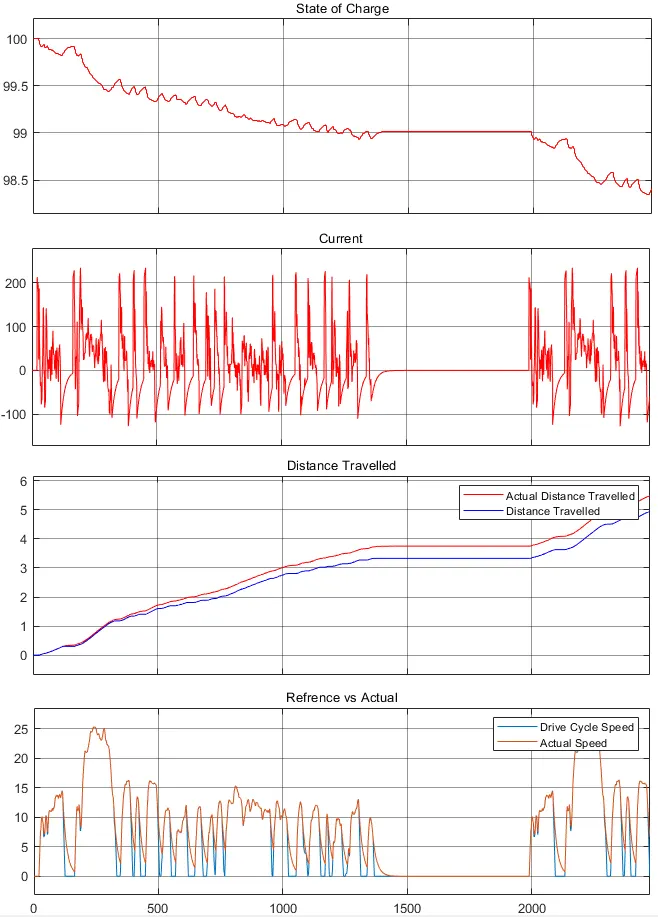
The EV Model follows about 85% of the input reference drive cycle FTP75. The power required for the acceleration is matched whereas the braking power is not sufficient to match the input drive cycle. The braking power at row rpm is less as the power developed by the motor as a generator depends upon the RPM thus at higher speed the braking power requirement is matched.
The peak current drawn by the motor is about 230A (ampere) and the peak current developed by the motor is -110A (ampere).
The battery state charge of charge after completing the FTP75 drive cycle is about 98.25 with only using regeneration braking in the vehicle.
The actual distance traveled by the vehicle is about 500m more than the FTP75 drive cycle as the braking was insufficient.
Improving the Model by adding Mechanical Braking
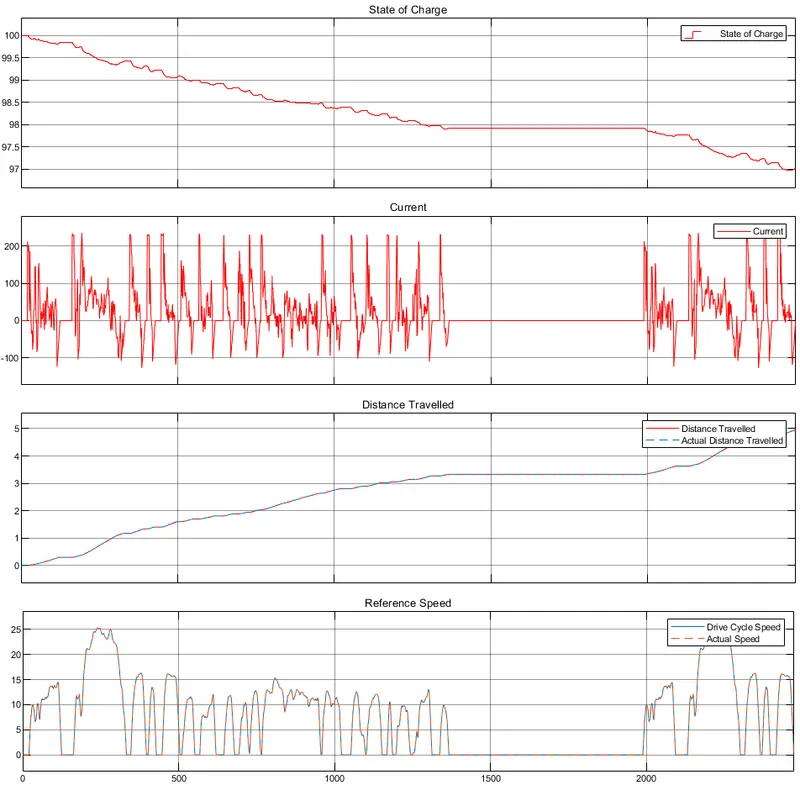
The EV Model follows about 99.99% of the input reference drive cycle FTP75. The power required for both the acceleration and deceleration is matched.
The peak current drawn by the motor is about 230A (ampere) and the peak current developed by the motor is -110A (ampere).
The battery state charge of charge after completing the FTP75 drive cycle is about 97 with only using both regeneration braking and mechanical brakes in the vehicle.
The actual distance traveled by the vehicle is about 500m more than the FTP75 drive cycle as the braking was insufficient.
Modified in Vehicle Body
Four-disc brakes are added, one each at four wheels. The brake signal from the PI controller(Driver) is given to the brakes which improves the vehicle response while braking.
4. Conclusion
A simple EV model is simulated using a permanent magnet DC motor with a PI controller and FTP75 drive cycle input. The vehicle speed is matched to the reference input.
The braking of the car was improved using the mechanical brakes as at lower speed the electrical regenerative braking is less efficient. This reduces the regeneration power the same is reflected in the battery state of charge.
References
1. https://muse.union.edu/seniorproject-menesese/implementation
2. https://www.electrical4u.com/permanent-magnet-dc-motor-or-pmdc-motor/