Assignment 5-RADIOSS Interfaces & Study of Effect of Notches Challenge
OBJECTIVE:Create the mesh for bumper assembly,mesh size should be 6mm.
- Run the crash tube model as it is.
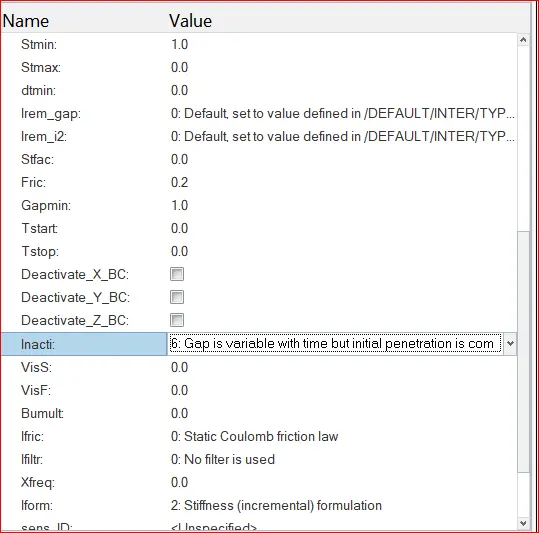
- Change the Inacti=6 and run.
- Create the type 11 contact and run.
- Remove both notches and remove boundary condition on rigid body node then run.
- Create a new notch in the middle ,select the whole section and run.
- Create a new notch with nodes only from opposing 2 faces and run.
SOFTWARE USED: Altair - Hypermesh.
ABOUT SOFTWARE: Radioss is a solver tool which is mainly used to solve the meshing problems. it is used to analyse how the energies will converted with the help of animation and hyper graph.
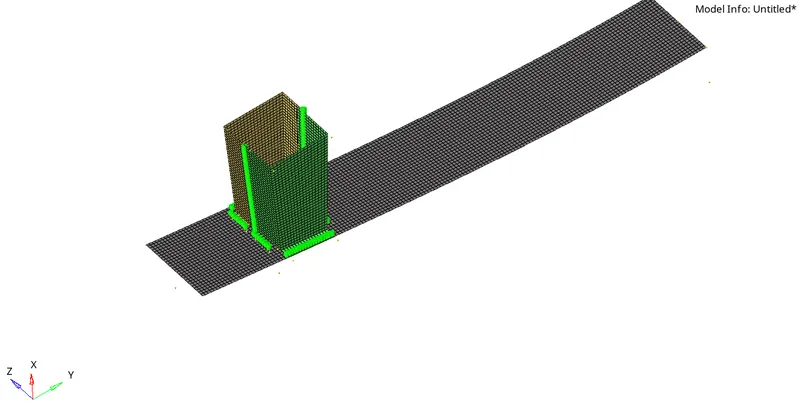
before going to run the cases there is another challenge given by the instructor is to provide the mesh to the bumper part.
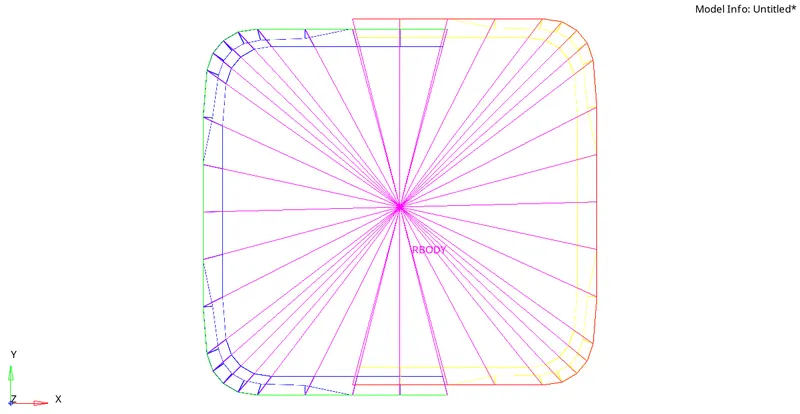
after that we have to turn off the wireframe mode in elements. below figure represensts the bumper.
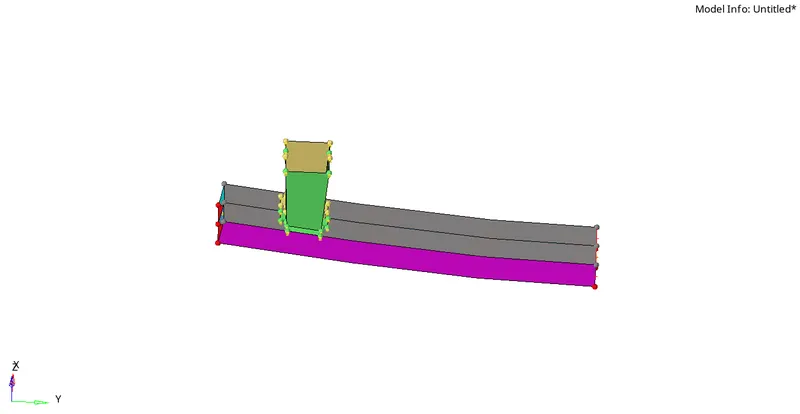
after importing the car bumper successfully we have to mesh the bumper perfectly.below figures represents mesh of a car bumper.
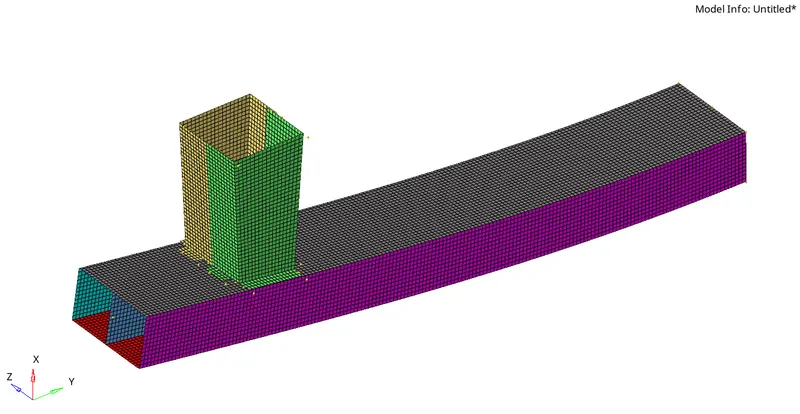
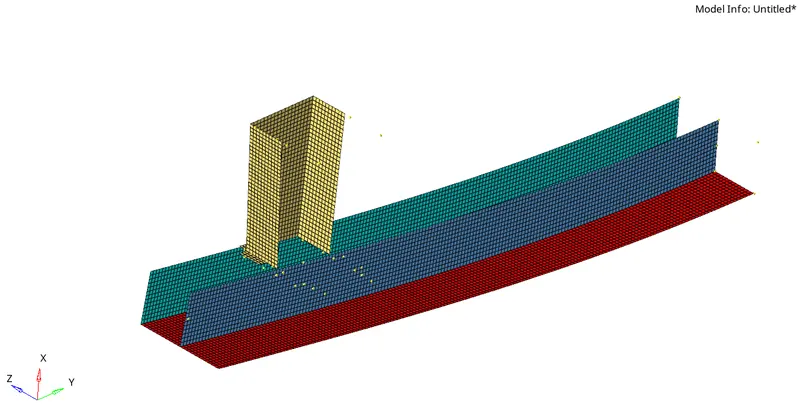
below figure represents the connections of a bumper part.
before going to start the cases we need to understand the concept of thses master and slave nodes.
INTERFACE OR CONTACT MODELLING:Interfaces are defined to model how parts interface when they come into contact with each other .
1) interface penalty mrthod
2) type 7 , variable stiffness, node to suface contact.
3) type-11 edge to edge contact
4) type - 24, linear stiffness node to surface , and surface to surface contact.
interface penalty method :
- The penalty method treats the behaviour between slave and master segments as spring that generates resistive force as a function of penetration.
- spring elements are created between the slave node and its projection the spring stiffness is automatically computed according to the material and property of both master segments and slave node.
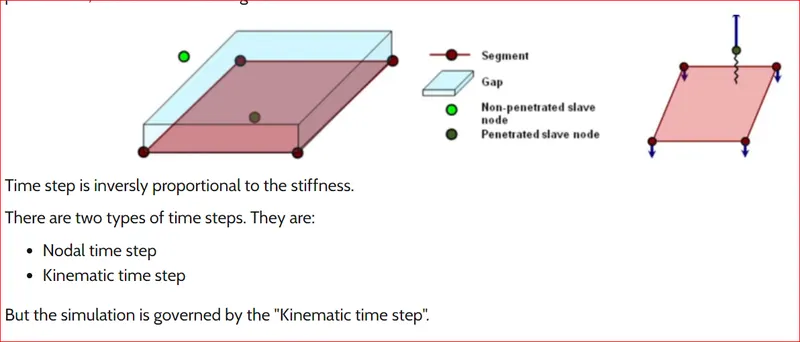
nodal time step δt <= √(2m/k)
kinematic time step δt <=0.5 (g-p/(dp/dt))
k=Kinterface+Kelements
δt <= 1mm/2(5000mmts)= 100μs
TYPE -7 :
- This contact is used for node to surface contact.
- It can simulate all types of impact between a set of nodes and a master surface.
- It is non-oriented & slave nodes can belong to the master surface. hence the auto-impact is possible (can also be a self contact).
- In this method penalty method with variable stiffness can also be used.
- resistive force are applied to keep the slave nodes out of the contact gap.
- stiffness is non linear.
- contact gap can be constant or variable.
Contact gap: Its a gap between the slave nodes & master segment, which indicates when a slave enters into the gap, which makes the resistive force come into picture.
the resistive force vs displacement curve which is non linear for the type 7 contact appears as shown in the following figure.
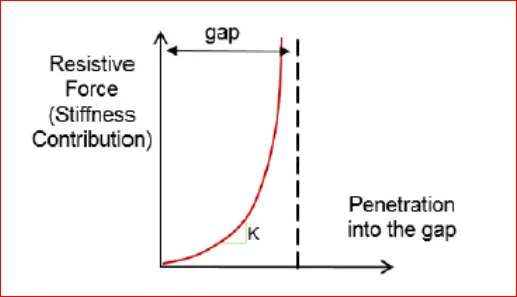
To have a stability maintain the penetration lower level, which makes the stiffness less.
important parameter in Type -7
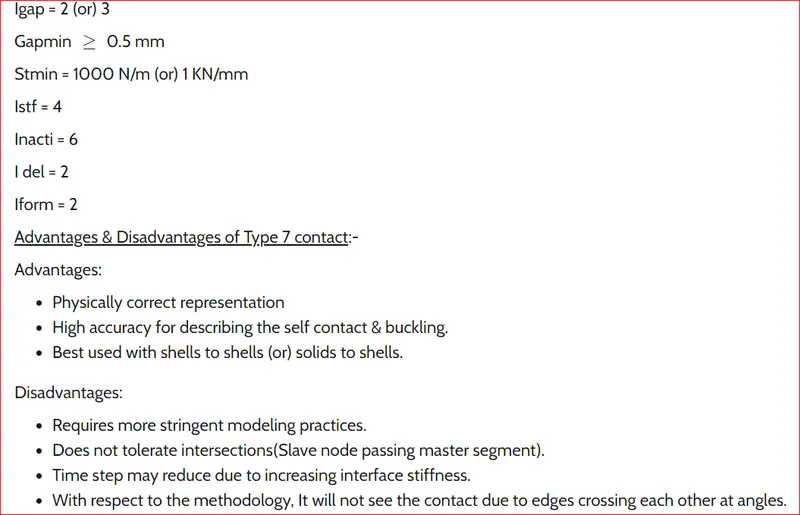
There are 7 parameters , which are important to be assigned at the time of creating the type -7 contact, they are.
Igap: Which determines the size of the gap is calculated.
Gapmin: To indicate the minimum gap for the activation of interface.
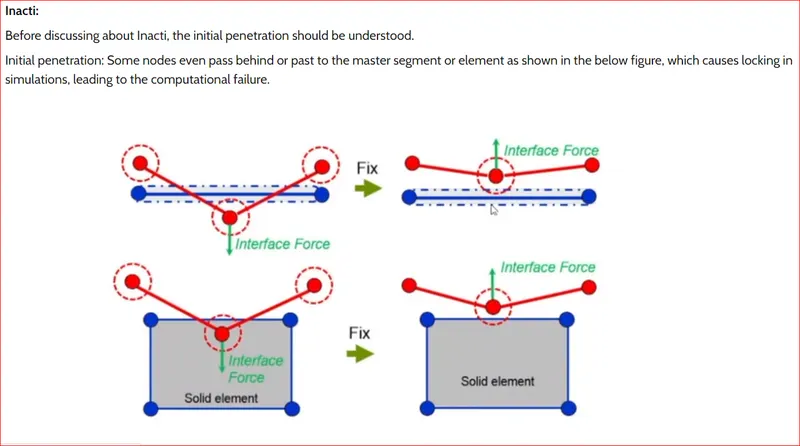
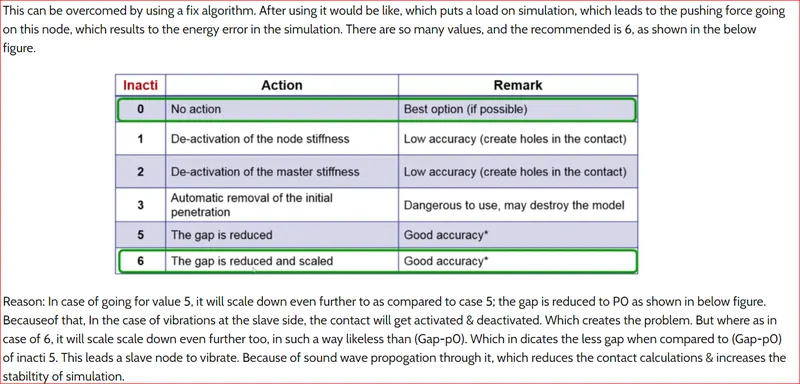
Inacti:Action to take, if initial penetration exists.
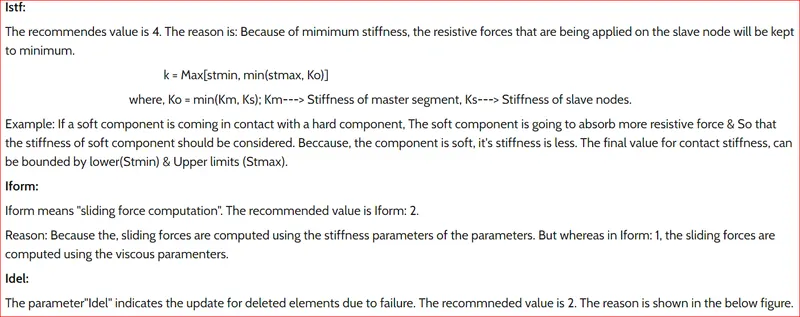
Istf:Affects how the stiffness is calculated.
Iform: To indicate the formulation of friction.
Stmin: To indicate how much minimum stiffness to be used in the interface.
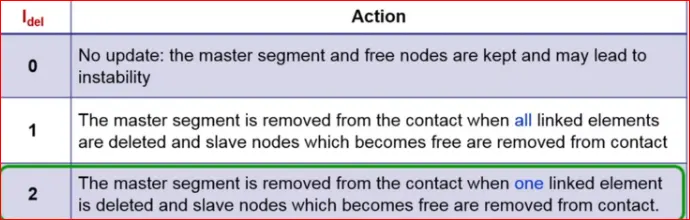
Idel: To indicate, what to do with the slave nodes & master segments if elements failed/deleted that they are attached to
Igap
Igap Gap type Description
0 constant gap The gap is defined by the Gapmin & is constant for all the contact.(default).
1 variable gap Gap varies according to the characteristics of the impacted master surface & impacting slave node.
3 variable gap varibale gap with gap scale factor & mesh size correction.
it depends on the Gapmin value (Recommended value for Gapmin is mm).
Recommended value : 2 or 3
Reason: Majorly, used is 3. because ,gap scale factor &mesh size correction is taken into account .because of adding gap scale factor,it puts a scale factor to the founded gap. in so many cases, there will be so many components with each other(ie, by default the component will rest on each other.) And if we dont want any reaction force to activate there. the Fscale gap is going to relax the interface contacts by a fit. which allows the slave node to reach upto the gap 0.8 which reduces some calculations for solver.
Mesh-size correction: if the mesh size is big, then the nodes will be far away from each other. it is very likely, instead of nodes comming into contact with the master segment.the edge of the slave node or element comes into contact with the master .Because, the contact is not well defined. if the mesh size correction factor,it can be overcomed.
limitation of type 7: it will consider only the nodes as a slave node.
recommended properties for type -7
Type -11 contact:
- It is also known edge to edge contact. In the case of edge crossing. type 11 interface can be added to capture the physics correctly.
- it is defined by identifying the master & slave lines in terms of edges.
- it works similar to type 7 contact interms of penalty formulation, gap definition, search method.
- slaves will receive stresses & forces. and the object which is to be analyzed is the "slave".
- coarser the mesh, stiffer the structure. hence the mater is typically meshed coarser. so that the slave doesnt penetrate into the master.
- thats why the less deformable or highly stiffer structure is taken as a master & less stiffer as slave.
note: type -19 contact is the combination of both type 7 and type 11 contacts.
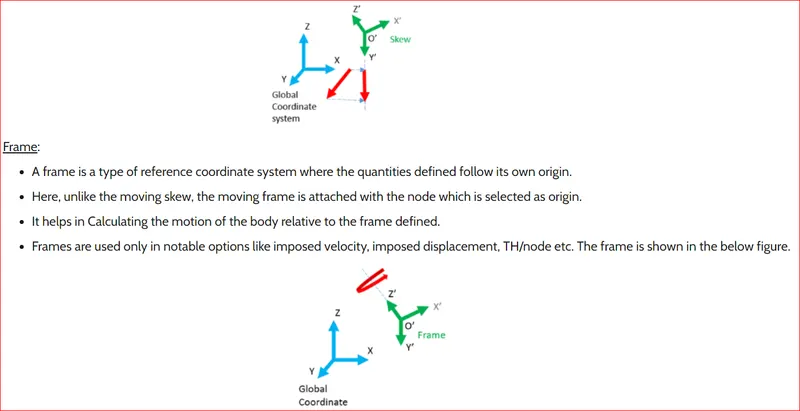
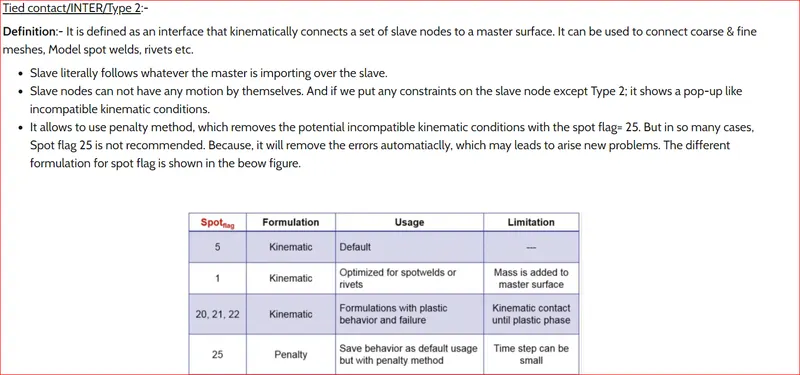
Skew: .
- skew is one type of referece coordinate system which helps in defining local quantities with respect to the global coordinate system.
- here the origin of the skew remains in a fixed position even if it is a fixed skew or moving skew.
- in a moving skew, the orinetation of the node of interest is recomputed everytime. with that of the origin coordinates of the skew.
Application: The example is the study of intrusions in the car through skews. 2 nodes are created and fixded skews are assigned to it. There the travel of the node is computed from the global coordinates and it is presented in the local coordinates . the overal travel of the node is obtained.
the skew is represented as shown in the below figure.
interface type available in radioss
crash structural applications
type 2 : tied node to surface
type 3 : surface to surface
type 5 : node to surface
type 6 : special rigid body to rigid body
type 7 : general node to surface
type 10 : tied node to surface after impact
type 11 : edge to edge
type -14 : madymo ellposidal to node
type 15 : madymo ellissoidal to surface
type 19 : type 7 + type 11
type 20 : general contact
type 23 : special self impact contact for airbay
type 24 : general node and surface to surface
manufacturing contacts:
type 8 : draw beads model
type 21 : node to rigid surface
fluid applications
type 1 : tied fluid to structure
type 9 : ale language with void opening and free surface contact.
type 12 : fluid to fluid contact
type 18: fluid structure contact
special crash structural applications
LAGMUL/type 16 : node to quadratic brick.
LAGMUL/type 17 : quadratic back to quadratic brick
inter/hertz/type 17: quadratic brick with hertz pressure contact.
The major difference is stiffness and type of interaction
out of many interface types listed above, the most used ones for impact simulations are interface
| interface type | slave | master | gap | stiffness | usage |
| 7 | node | surface | yes | non linear | general node to surface contact for any application |
| 11 | line | line | yes | non linear | edge to edge contact for any application |
| 24 | node or surface | surface | no for solid/ yes for shell | linear | new, general node or surface to surface contact. |
important interferance parameters
| Igap | determines how the size of the gap is calculated |
| Gap min | min gap for activation of interface |
| I nacti | Action to take if initial penetration exist |
| Istf | Affects how the stiffness of the interface is calculated |
| I form | Friction formulation |
| Stmin | Minimum siffness to use in the interface |
| Idel | What to do with slave nodes and master segments if elements fails (deleted) that they are attached to. |
case -1
- Run the crash tube model as it is.
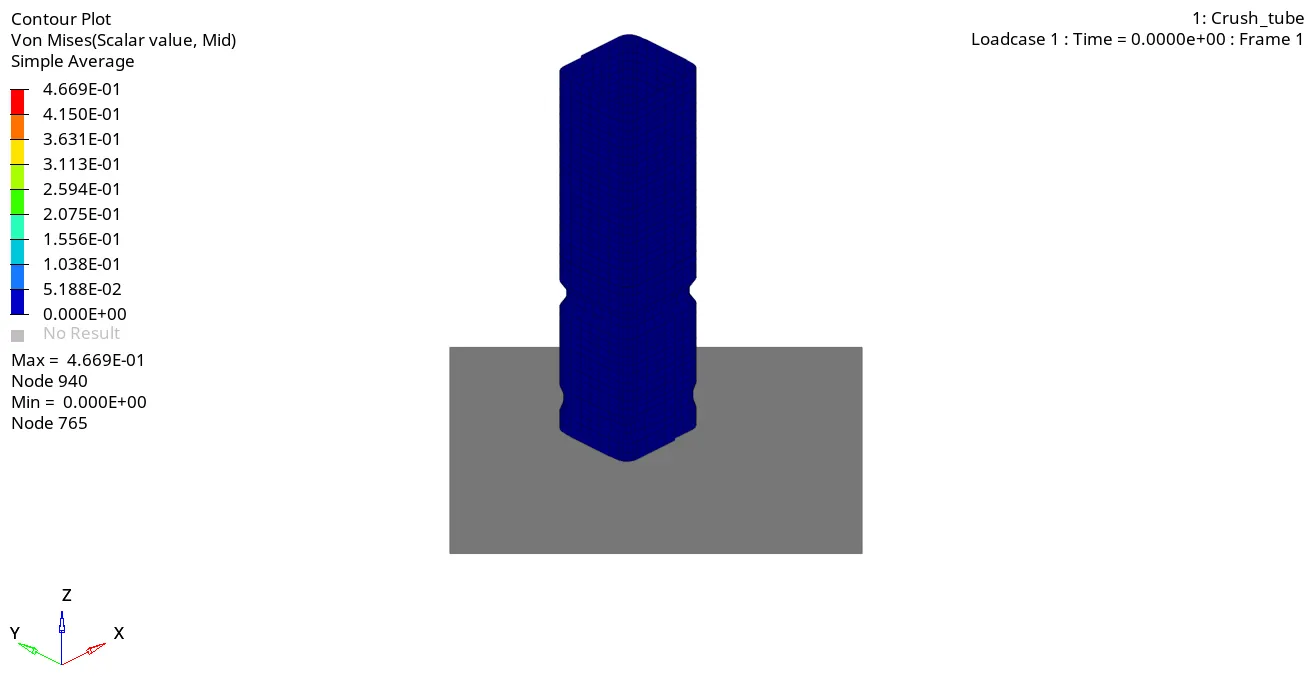
for this case we have to run the model as it is. firstly the model will look like the below figure.
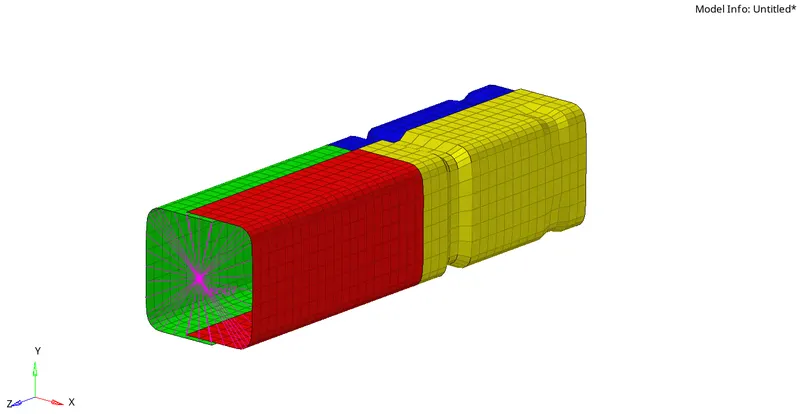
after that there is no need to change the material card and boundary condition card.
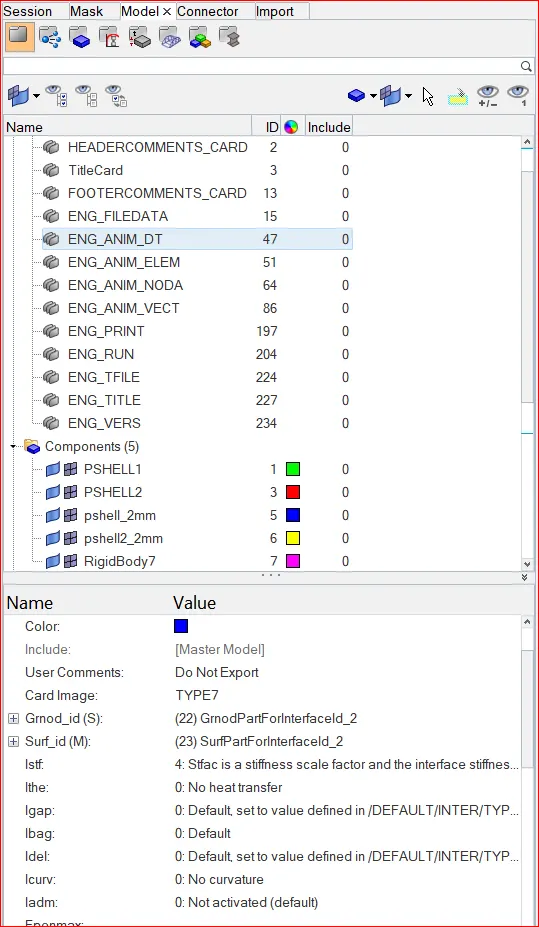
the material of type 7 will be general node to surface. all we put here is zero there is no igap, idel, icur and most all are in zero condition let us do an quick analysis and see what happend.
below figures represents the energy errros.
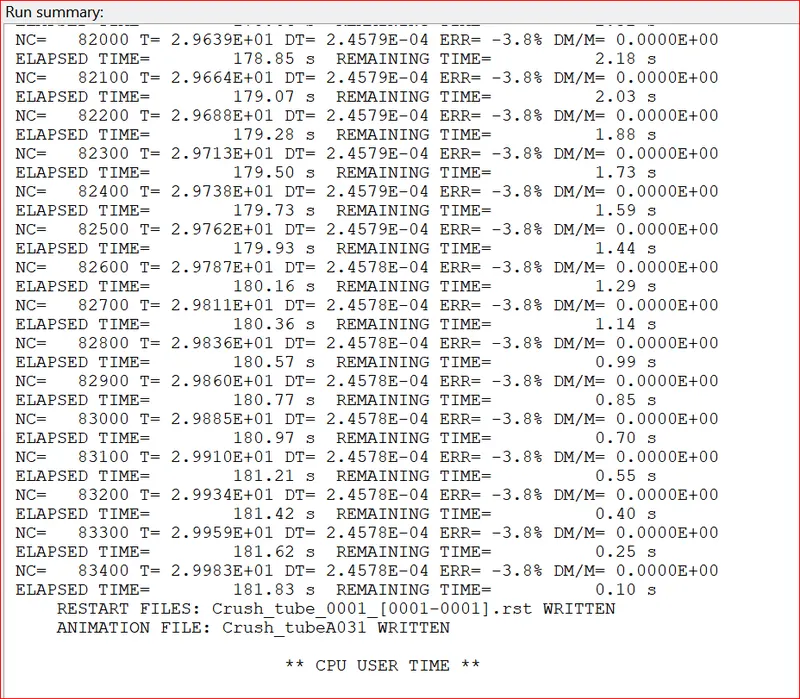
the energy errror is 3.8% so it satisfied the ideal condition of 15 % we can move on it.
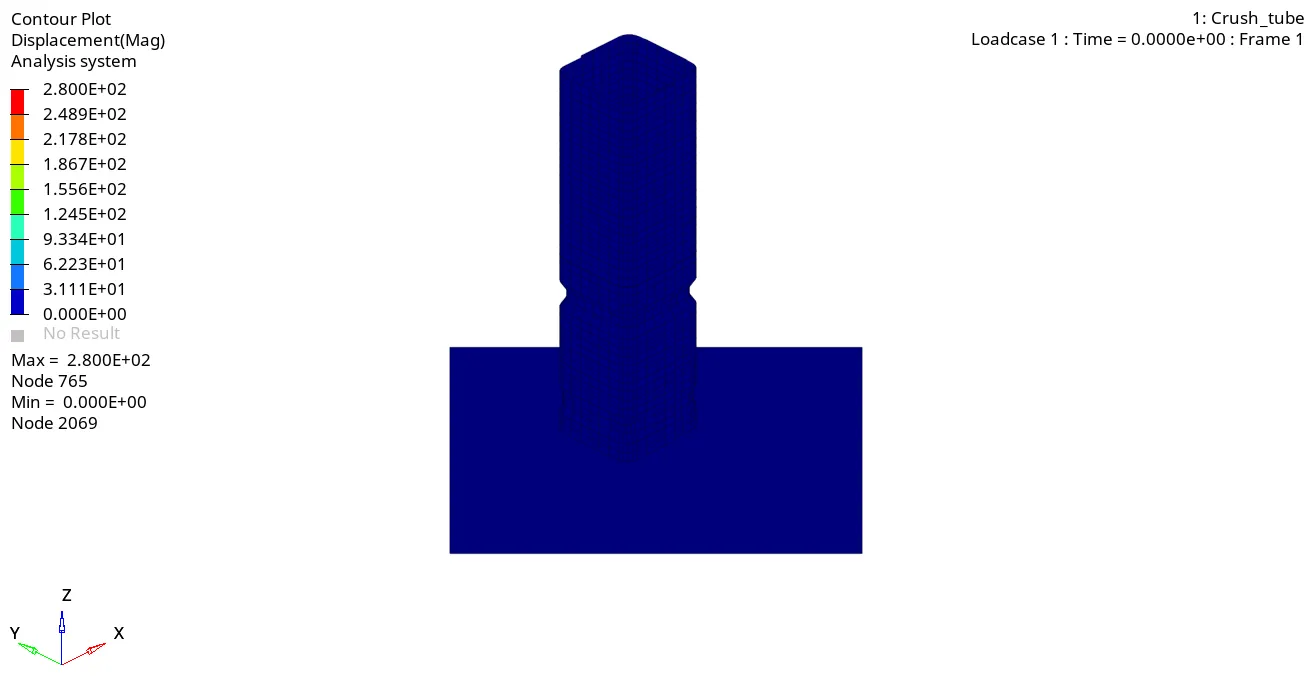
For case 1 DISPLACEMENT ANIMATION FILE
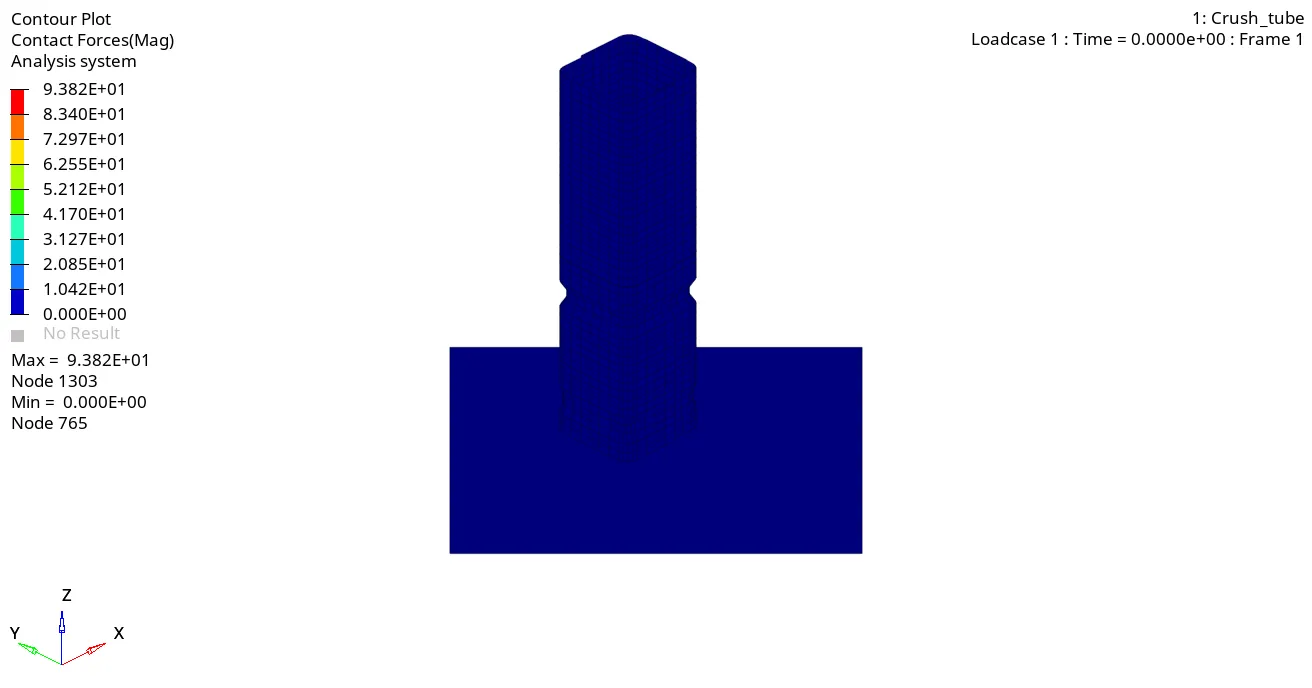
CONTACT FORCE ANIMATION FILE
VON MISES ANIMATION FILE
RIGID WALL FORCE
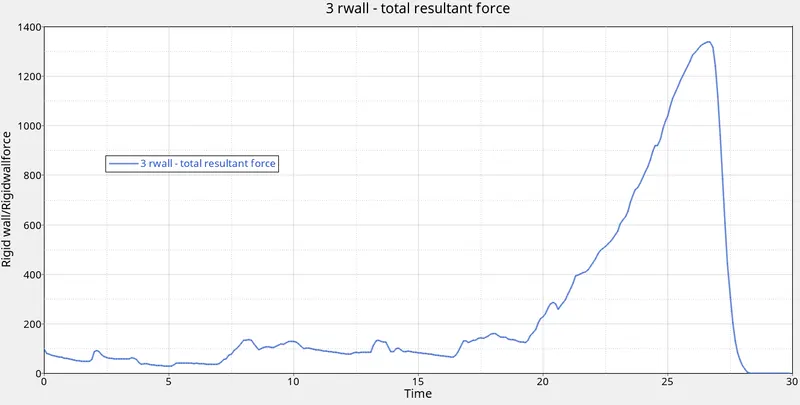
if we observe the rigid wall force it will increses with respect to time upto 20ms point of time and the rigid wall force range is in between the 200kn. after that there is sudden increase in its rigid wall force,due to the crush tube reaches last stage, so the crush tube force is changed to the rigid wall force so at that time the rigid wall force is more compared to previous.
if we observe the rigid wall force is suddenly increased due to the sudden change in contact force. before the crush take the energy/load after that force is transferred/contact force is transfered to the rigid wall.
at that time the rigid wall getting more force.
INTERNAL ENERGY
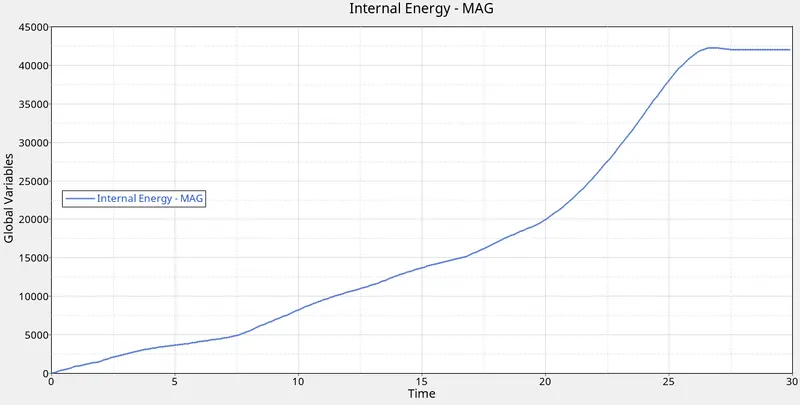
The kinetic energy is travelled alon the crush tube, it means while travelling the body it have kinetic energy but, it suddenly hit the wall or any other body/ surface that kinetic energy is converted into internal energy to stop the load condition.
- If we observe the graph the internal energy is less and with respect to time it increased gradually because there is a change in energy. firstly the kinetic energy will be higher but after that it will converted into internal energy.
- At the end of simulation total kinetic energy will be converted into internal energy.
- if we observe the graph between 20ms to 25ms there is a sudden increasing in internal energy. so the internal energy is increased after the crush tube contacting with the rigid wall, after 25ms to 30ms the internal energy is constant due to no energy is produced during the time .
SELF CONTACT FORCE
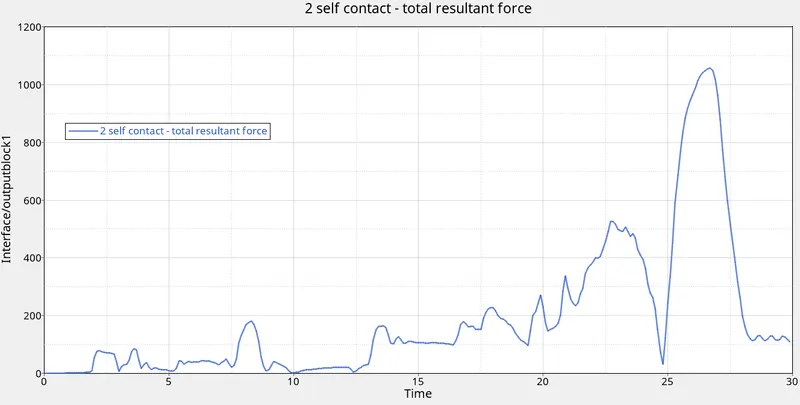
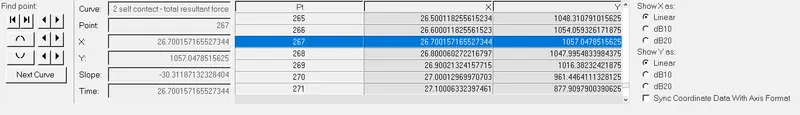
The self contact force is 1057.047851N. the maximum self contact force is occurs at the end of simulation. so the crush tube is completely deformed and the master and slave nodes contact successfully.
TOTAL ENERGY PLOT
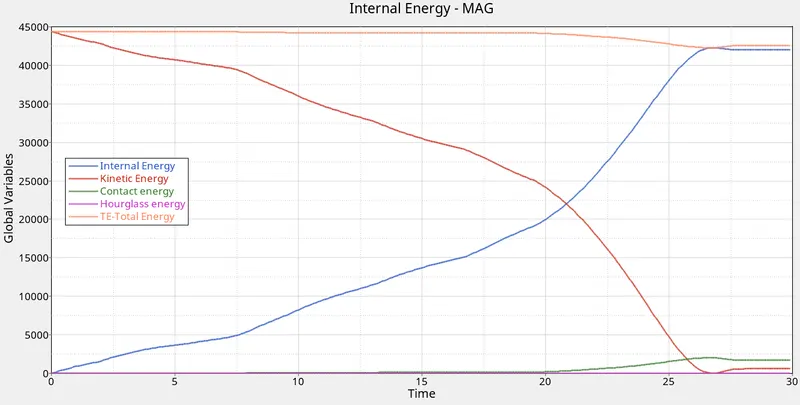
Here we observe that kinetic energy is more compared to internal energy because it is not collinding the rigid wall till 22ms of time after that it is converted to internal energy. comming to contact and total energy, the total energy is almost same but in the later it is decreased upto some extent due to increase im its contact energy.
here we can observe the hourglass energy ( artifical energy of radioss solver for balancing of energy is not developed it means it is correct and it is in balanced condition of all energies).
case -2 Change the Inacti=6 and run.
Inacti: Action to take if initial penetration exist.
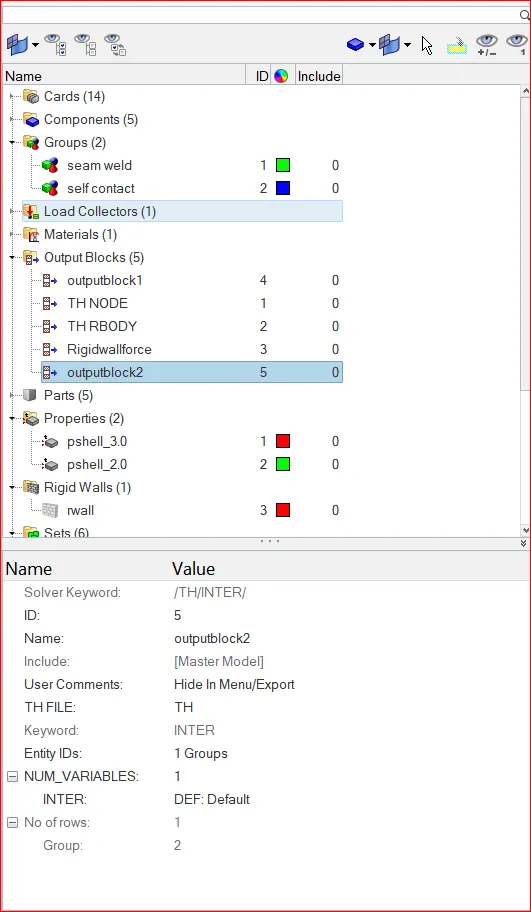
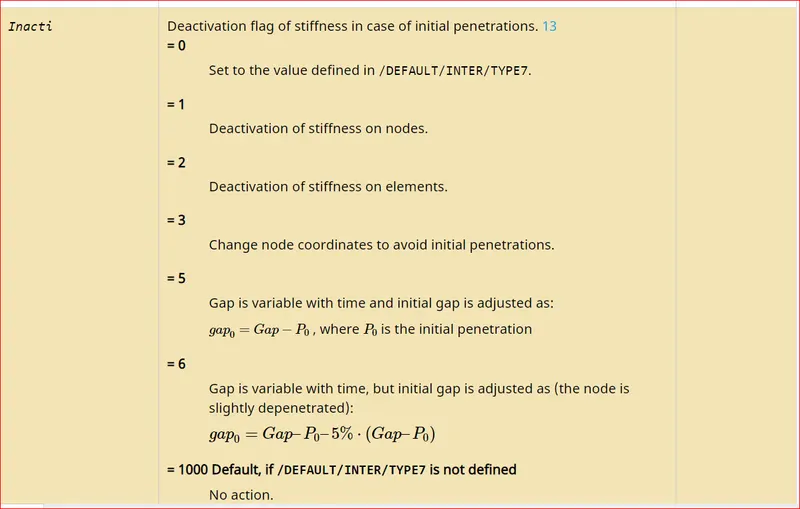
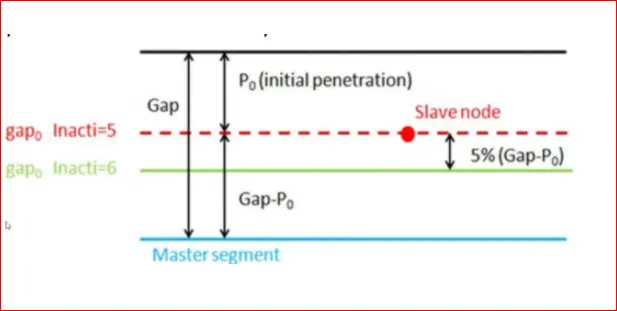
here i took inacti is equal to 6 : gap is variable with time, but initial gap is adjusted as (the node is slightly depenetrated).
GAP! = GAP - P!-5%.(GAP-P!).
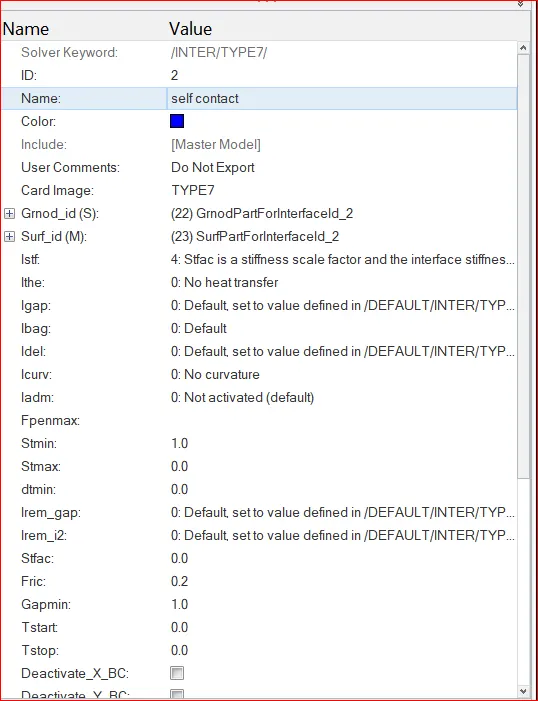
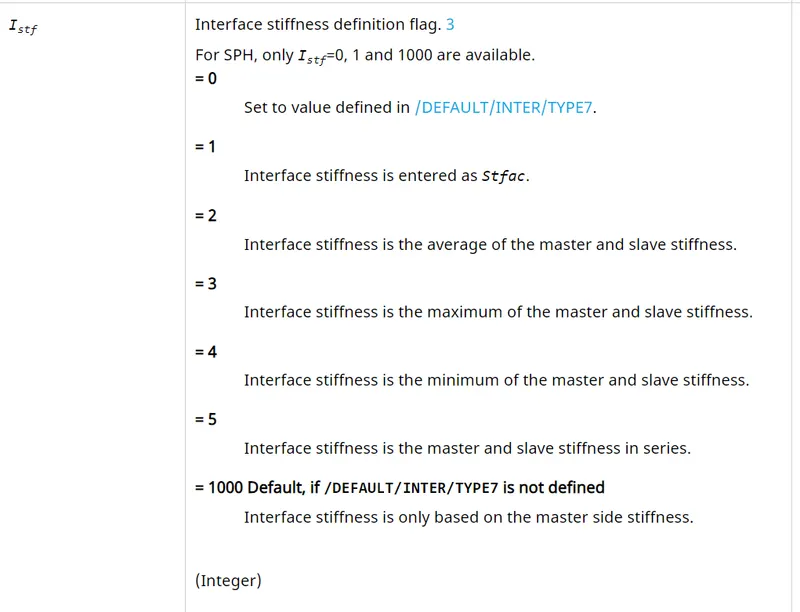
Here i took interface stiffness definition here we put istif in 4 because the master is the rigid wall so it has minimum stiffness if incase we have to put in 3, the slave nodes impacts greater stiffness it leads to breakage or it may give wrong solutions.
so here we put it in minimum stiffness of the master because it takes lesser load.
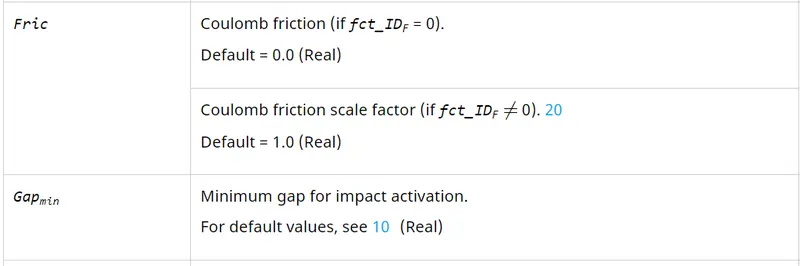
here i gave the value is to 0.2 it is in the range between 0-1. we can take 0.1,0.2,0.3,0.4.... etc.
below figure represents the energy error and mass error.
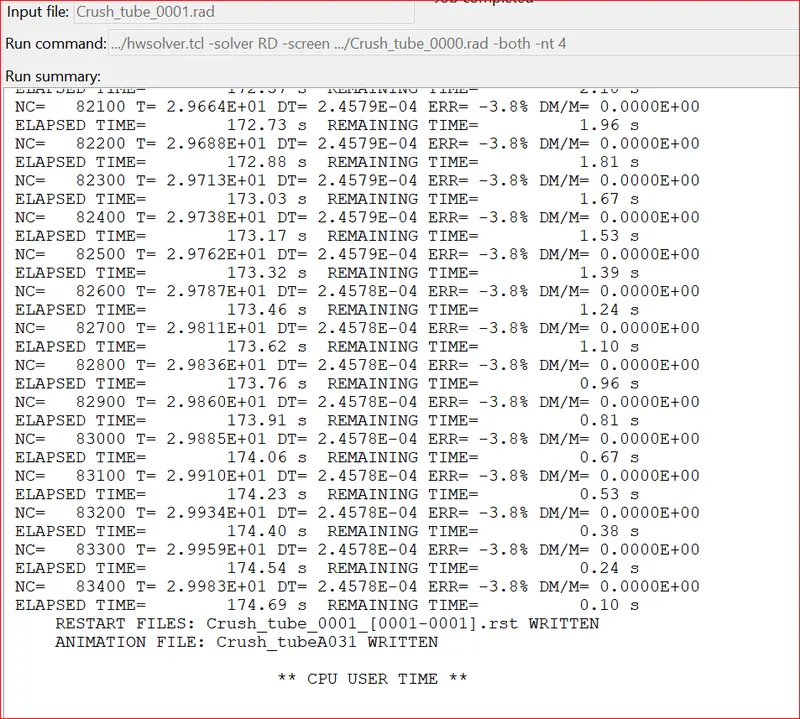
the error is 3.8 % out of 15. we can prceed the simulation why becuase it is less than the ideal error. and the mass errro is 0.00
DISPLACEMENT ANIMATION FILE
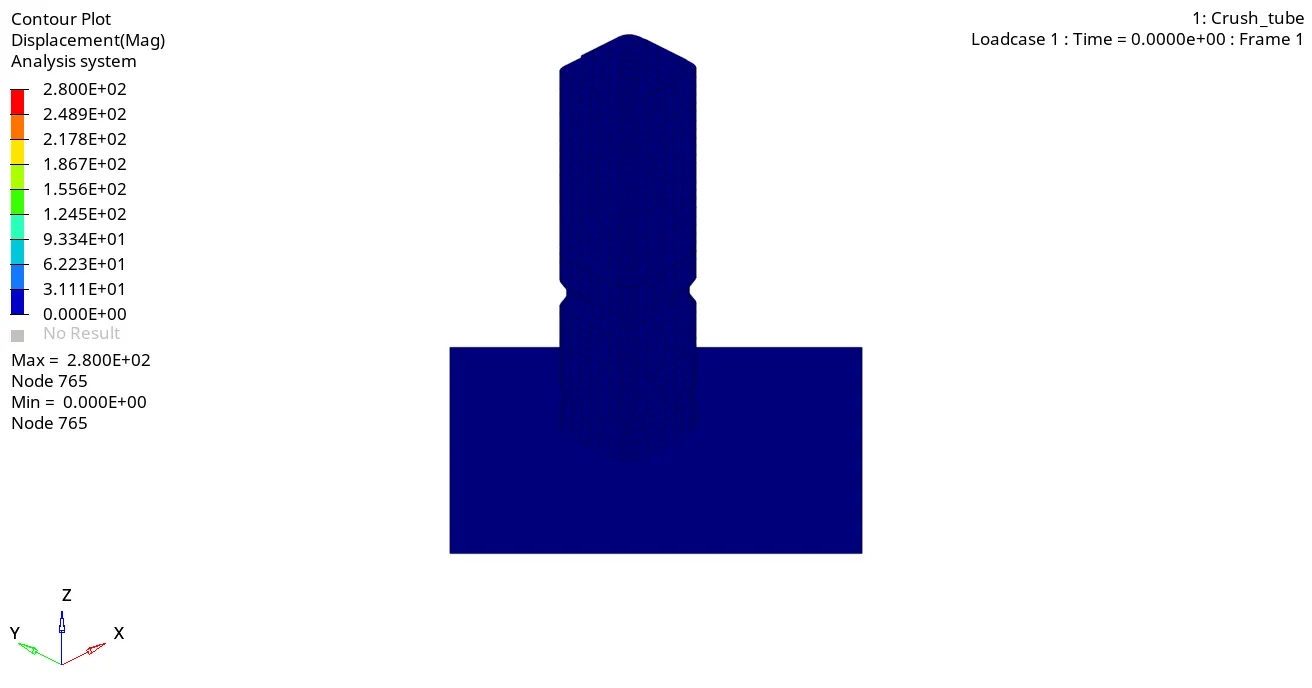
CONTACT FORCE ANIMATION FILE
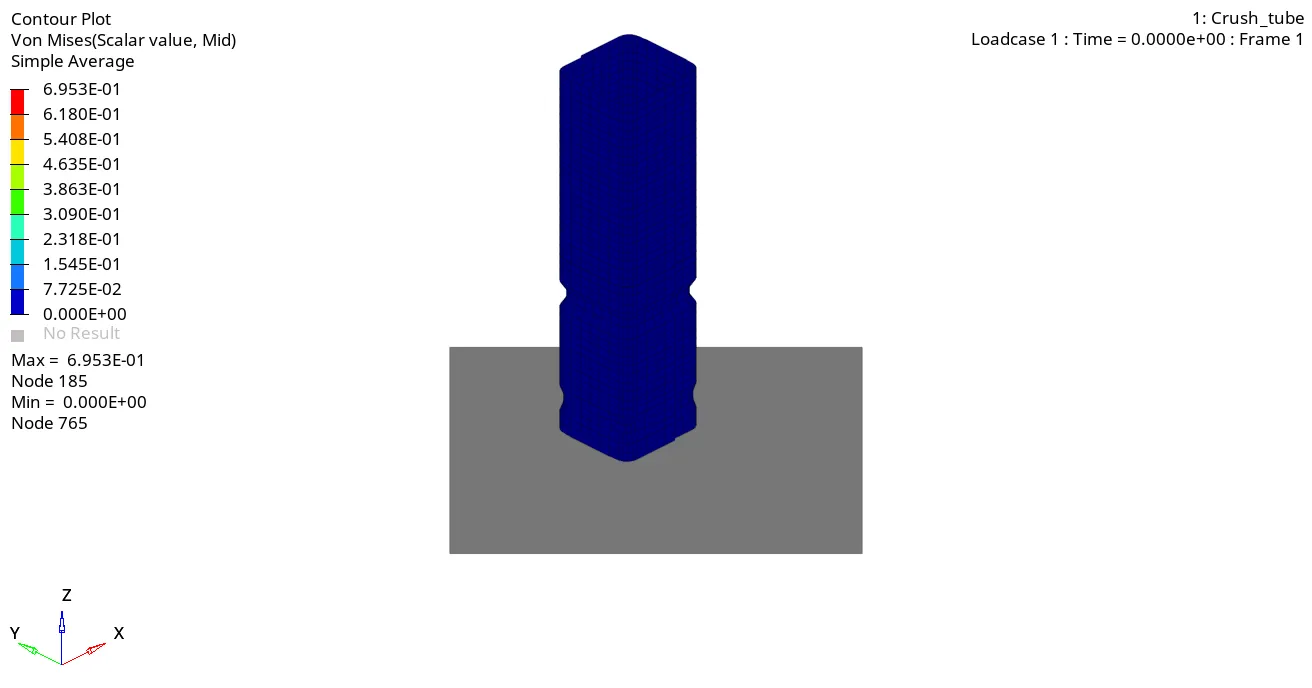
VON MISES ANIMATION FILE
RIGID WALL FORCE
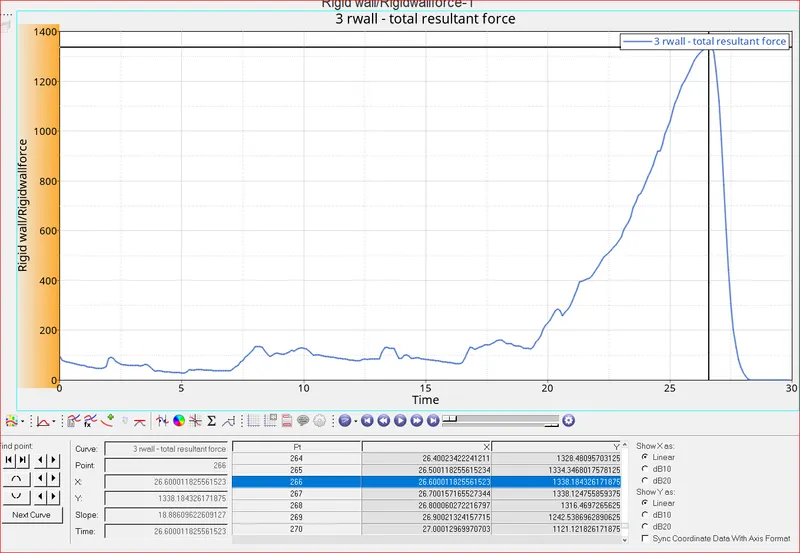
the maximum rigid wall force is noted 1338.18N with in the time of 26.6000ms. so the maximum force is acting at the end of the simulation, it means the crush tube contacts the rigid wall at the end of the simulation. so the crush tube energy is transferred to the rigid wall directly.the master and the slave node contact at the end of the simulation.
CONTACT FORCE
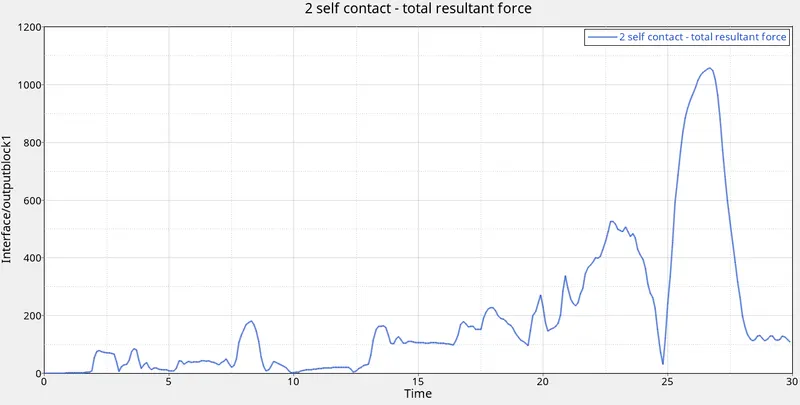
The maximum self contact force is noted at the end of the simulation due to the contact of the master and the slave node. the maximum self contact force is 1050N and the time taken by the contact force is 26ms. this is the contact force.
ALL FORCES
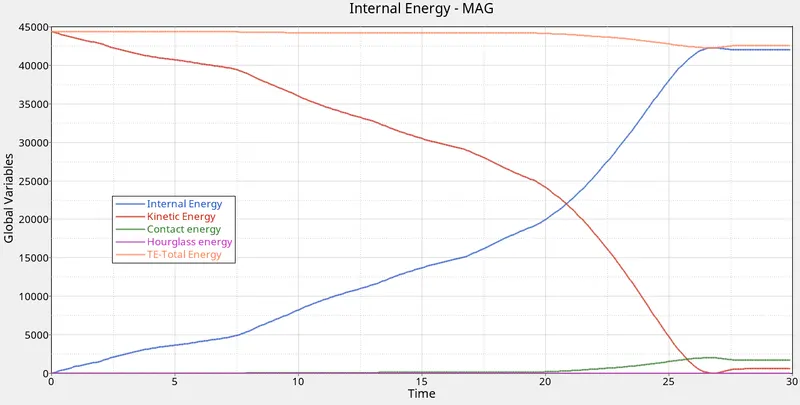
The kinetic energy is more primarily because when the body in motion due to the kinetic energy, after that it hits the rigid wall with so the kinetic energy is converted into internal energy.
we can observe here the kinetic energy is decreased in the middle of the plot because it reaches/ hits the rigid wall so the crush tube doesnt have any force acting at the end, so the kinetic energy is converted into internal energy due to the present of rigid wall.
if we observe here the hourglass energy is equal to zero we can say it is correct.
so we conclude that compared to case 1 with 2 there is not much change we observed in the plots, because of the only change is inacti to 6.
case -3:Create the type 11 contact and run.
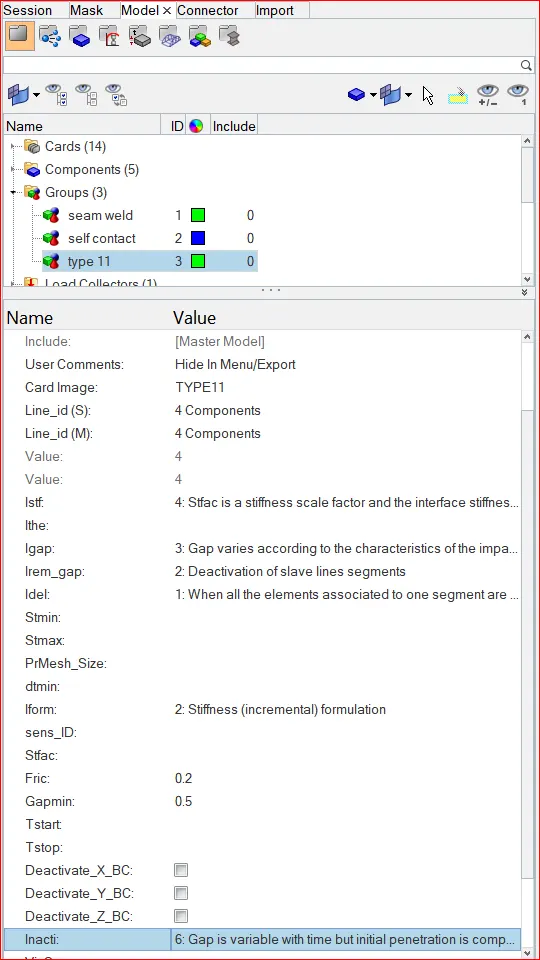
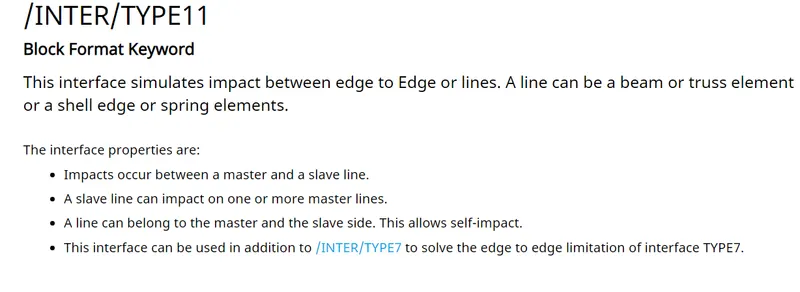
This interface is simulates the impact between the edge to edge or lines.
then we will check the energy error.
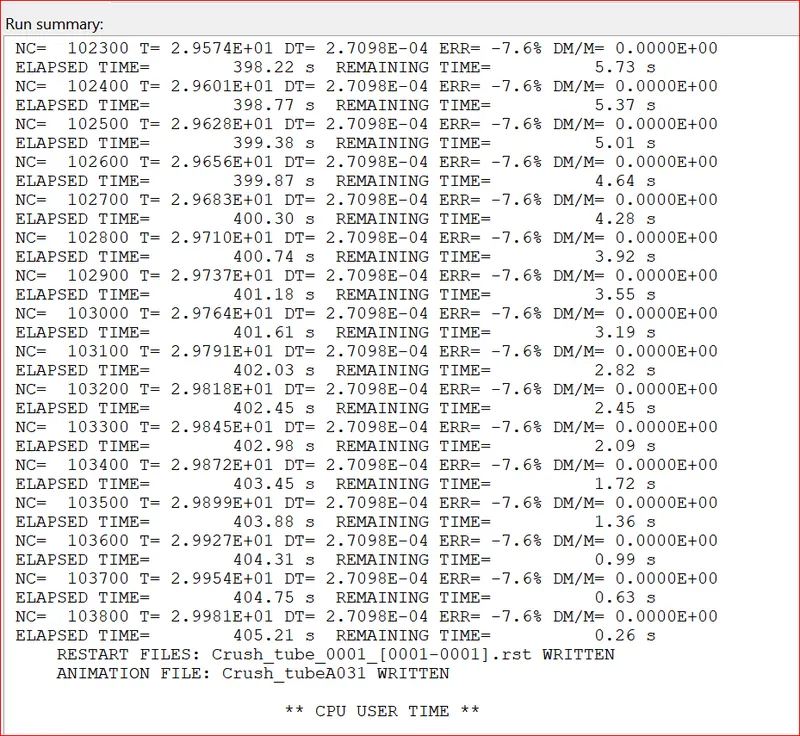
the energy error is 7.6% and the mass error is 0.000%.
DISPLACEMENT ANIMATION FILE
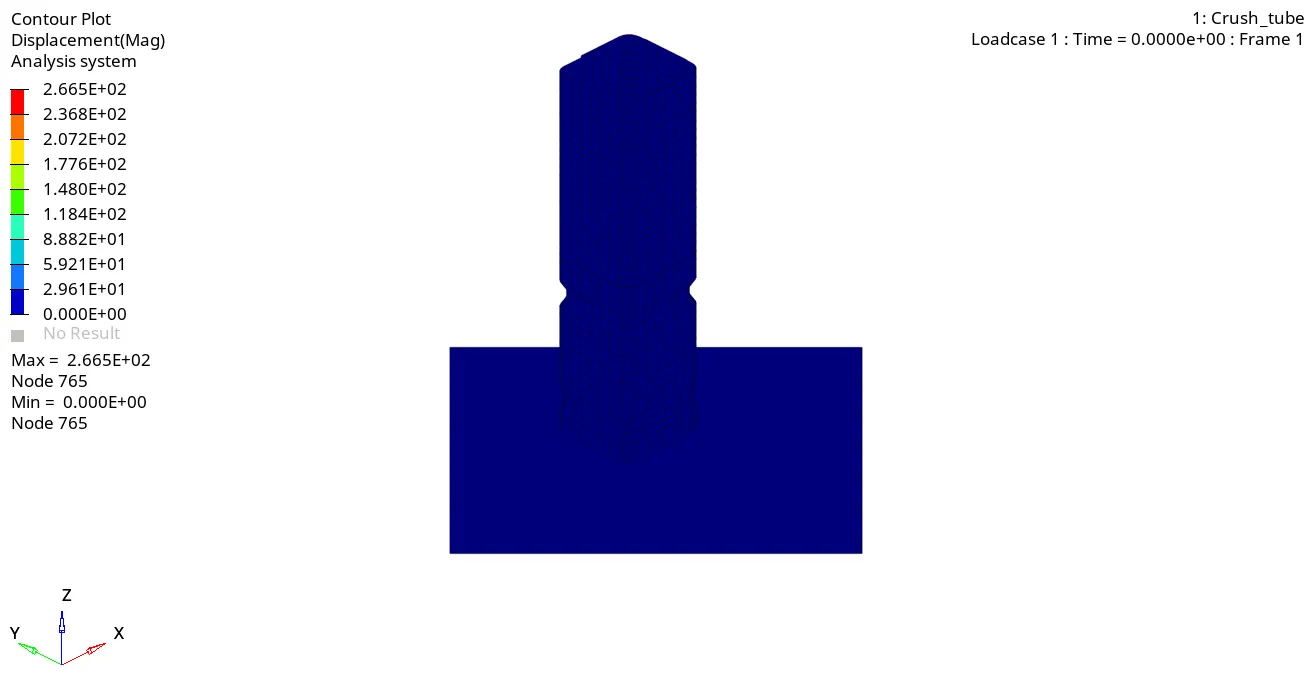
CONTACT FORCE
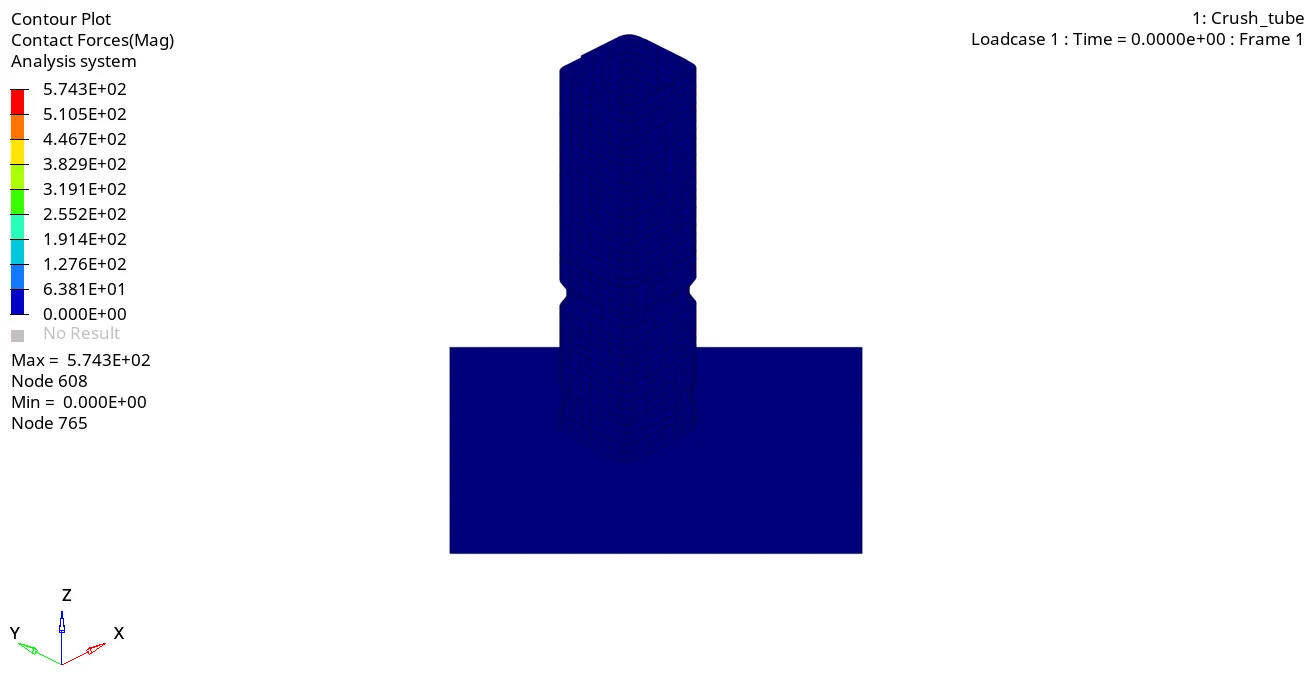
VON MISSES
RIGIDWALL FORCE
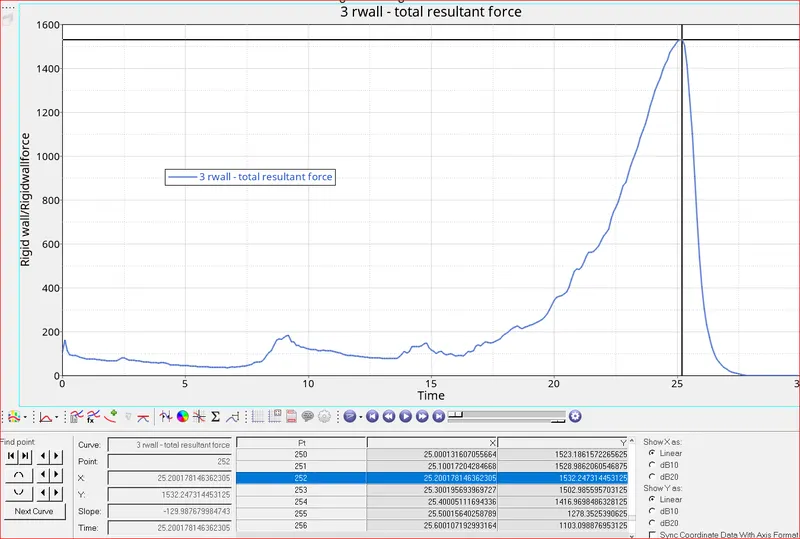
The maximum rigid wall force is noted at 1532.2473N with in a time range of 252msec. the maximum deformation occurs at the end of the simulation because the contact of the master and the slave node.
the crush tube hits the rigid wall with some velocity and load due to that load it increses at the end of the simulation. if we observe the graph we can say at the begining lower the rigid wall force due to the load is acting on the crush tube itself.
self contact force
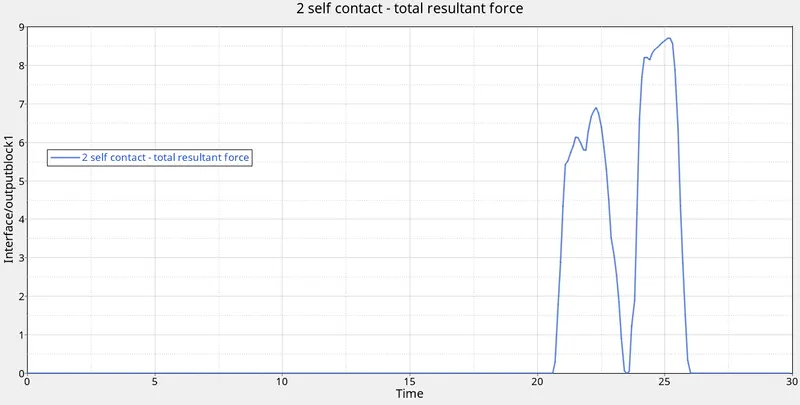
The contact force has lot of fluctuation due to type 11. it is a line to line contact or edge to edge contact. so here the contact force is fluctuated due to the line to line contact. the maximum contact is noted at 26ms with an self contact force of 8.5 N.
NOTE: if we create a rigid wall card there is no need to give contact energy or contact interface.
if we create a wall with elements we will create a contact moelling between the wall of the elements to the crush tube.
ALL ENERGIES
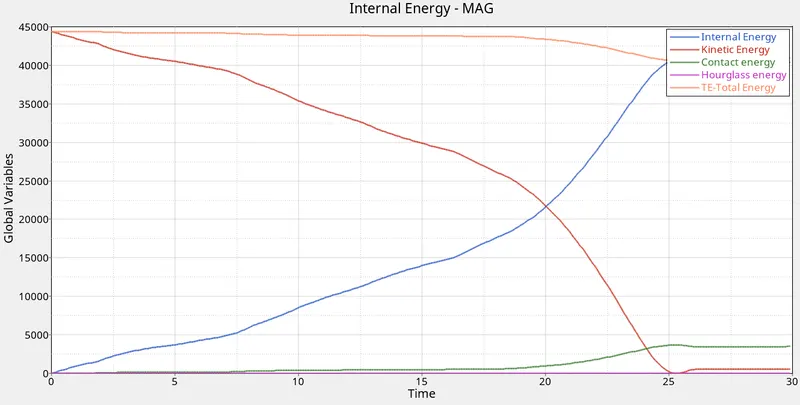
IF we noticed in this type 11 we got a kinetic energy conversion at the point of 20ms of time in x axis exactly. so, here we can say the energy conversion rate is faster in type 11 compared to type 7. the crush tube energy is contacted to the rigid wall.
case -4 : Remove both notches and remove boundary condition on rigid body node then run.
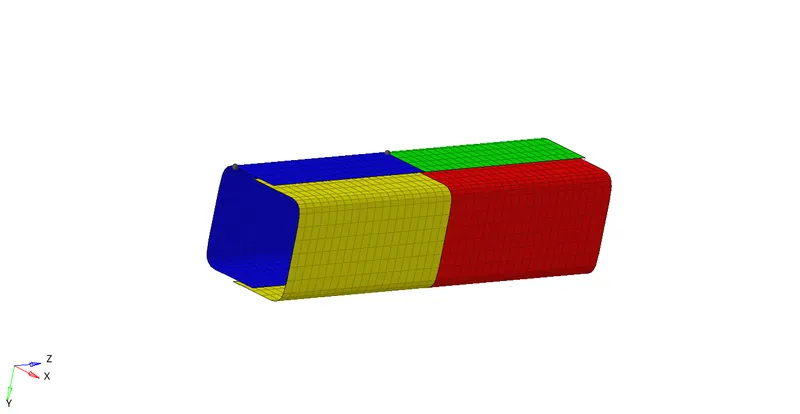
The notches are removed and we put it in same conditions like previous case of type 11. we need to observe the energy error and mass error.
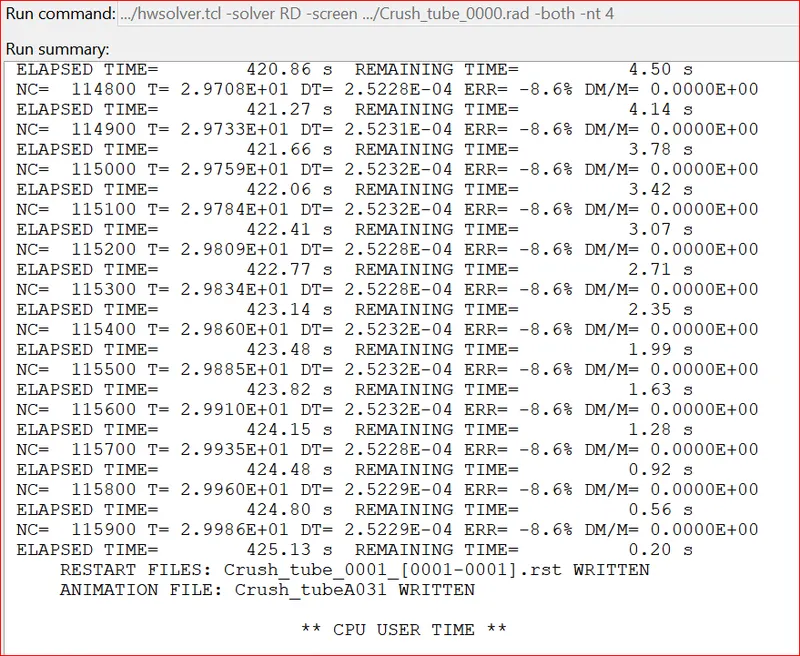
the energy errror is noted as 8.6 % and it satisfied the ideal condition of 15%. then we can proceed for analysis.
DISPLACEMENT ANIMATION FILE
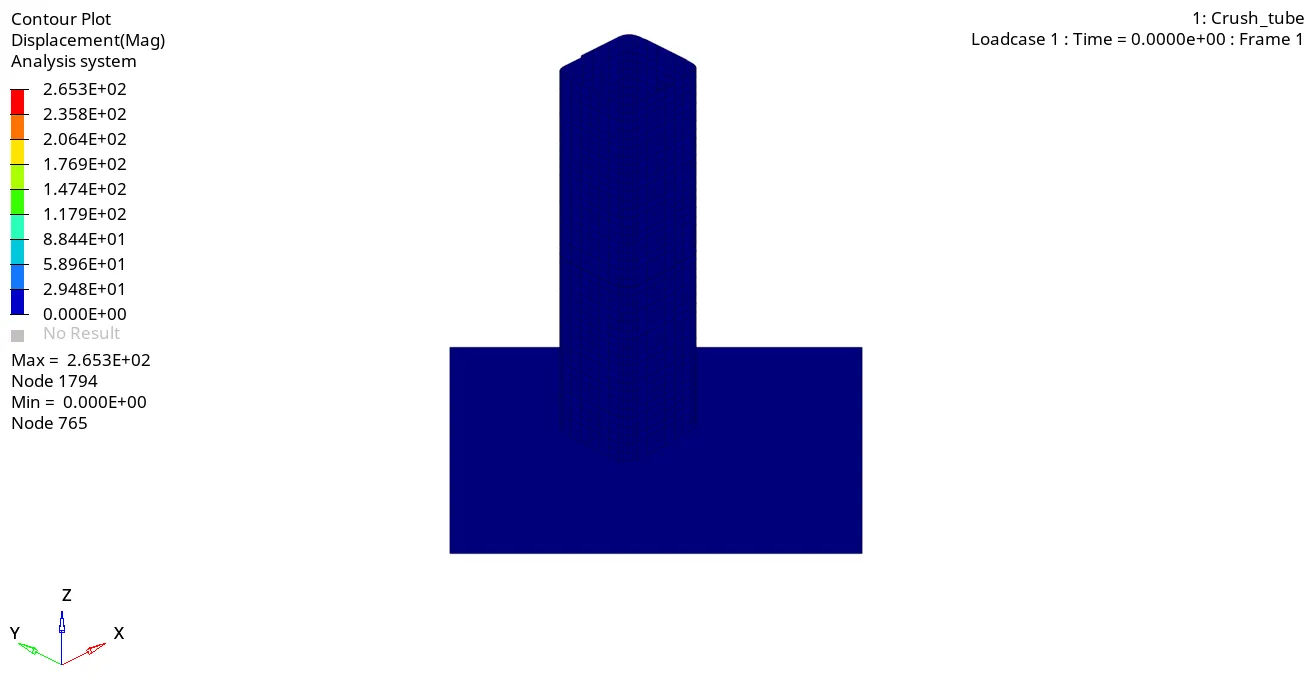
SELF CONTACT FORCE ANIMATION FILE
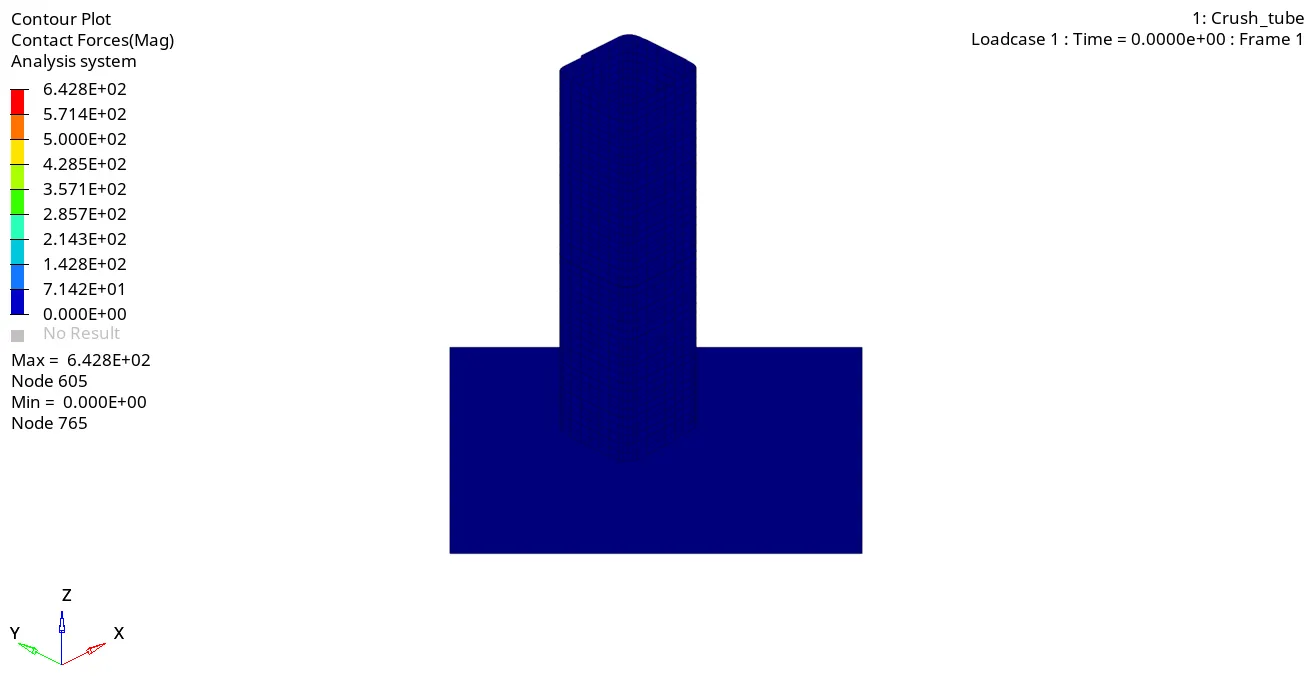
IF we can observe the cases upto 3rd case, due to the present of notches near to the middle of the crush tube. first the force impacts and deformed at that area and it moves downward. but in this case there is no notches so the deformation occurs at the end of the crush tube it means the rigidbody force is acting at the end of the crush tube due to no notches present in crush tube.
VONMISES ANIMATION FILE
RIGID WALL PLOT
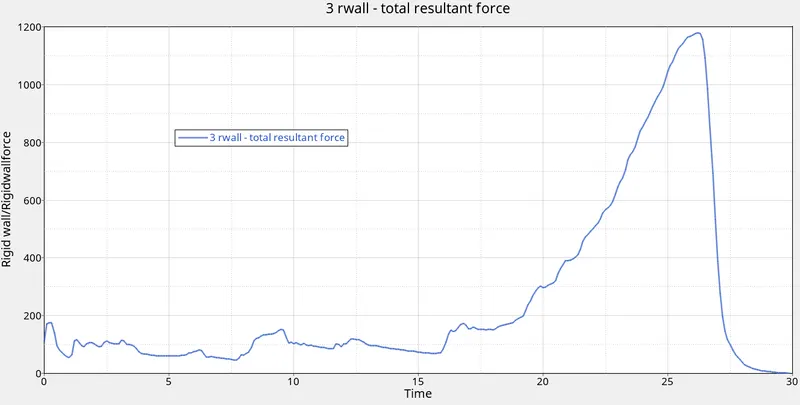
The max rigid wall force is noted 1180 N in the time of 27 ms. the rigid wall force is equal to case 1 and 2. in case 3 we obwerved that max rigid wall force due to the change it to type 11. and also we can noted there is no notches present in the crushtube the force is decreased little bit due to no nothces present in the model and there is a smooth impact we noticed.
SELF CONTACT PLOT
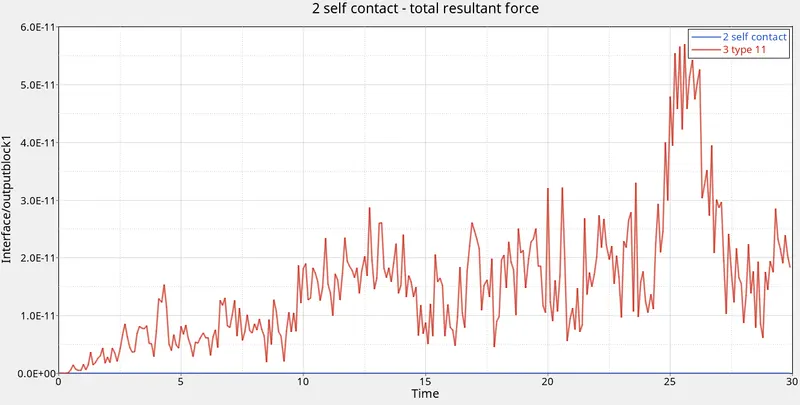
Due to the deletion of the boundry conditions of the rigidwall we noted there is a self contact between the master and the slave node.
ALL ENERGY PLOT
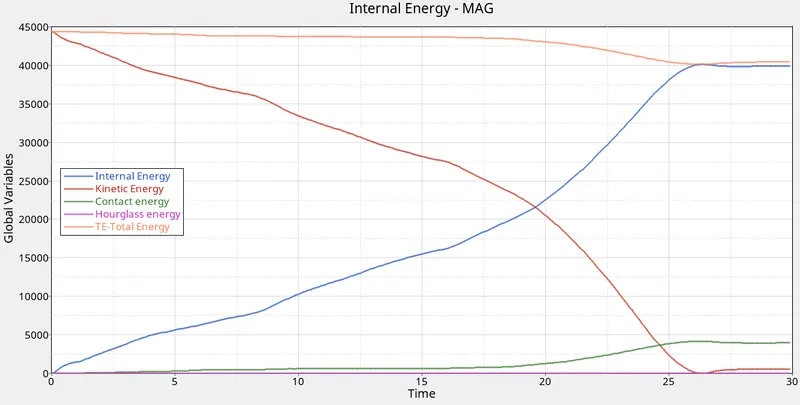
We can observed here the conversion of kinetic energy is dependent on the notches present in the crush tube. so we will observe we have more notches it will take time to convert into internal energy.
but if no notches present in the crush tube it will directly converted into internal energy due to no disturbances(notches ) present in the model.
here the ke conversion starts at before 20 milliseconds.there is no hourglass energy is produced it means our simulation is correct.
CASE-5 Create a new notch in the middle ,select the whole section and run.
WE can see the energy error in the below figure.
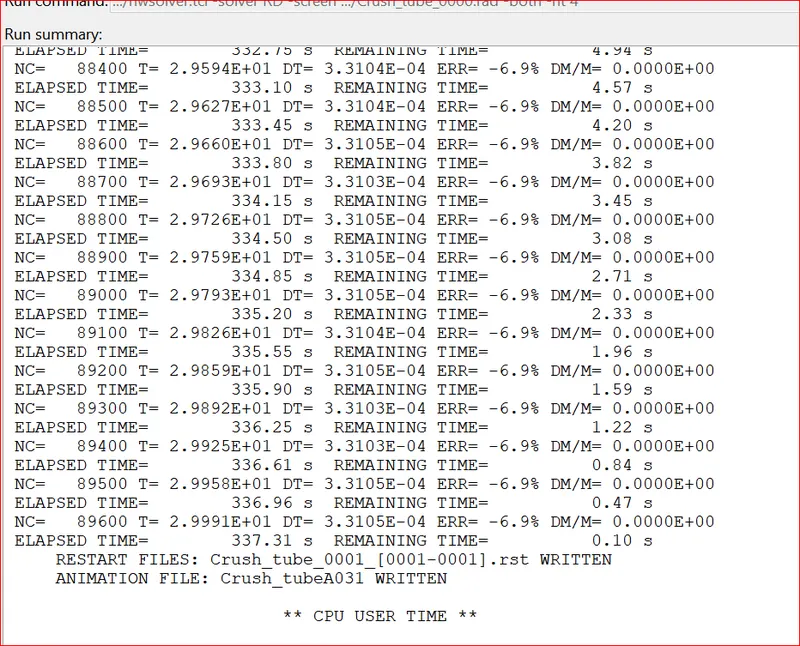
The energy error is noticed 6.9% and it is satisfied with the ideal condition of 15%.
the mass error is 0.000%.
RIGID WALL ANIMATION FILE
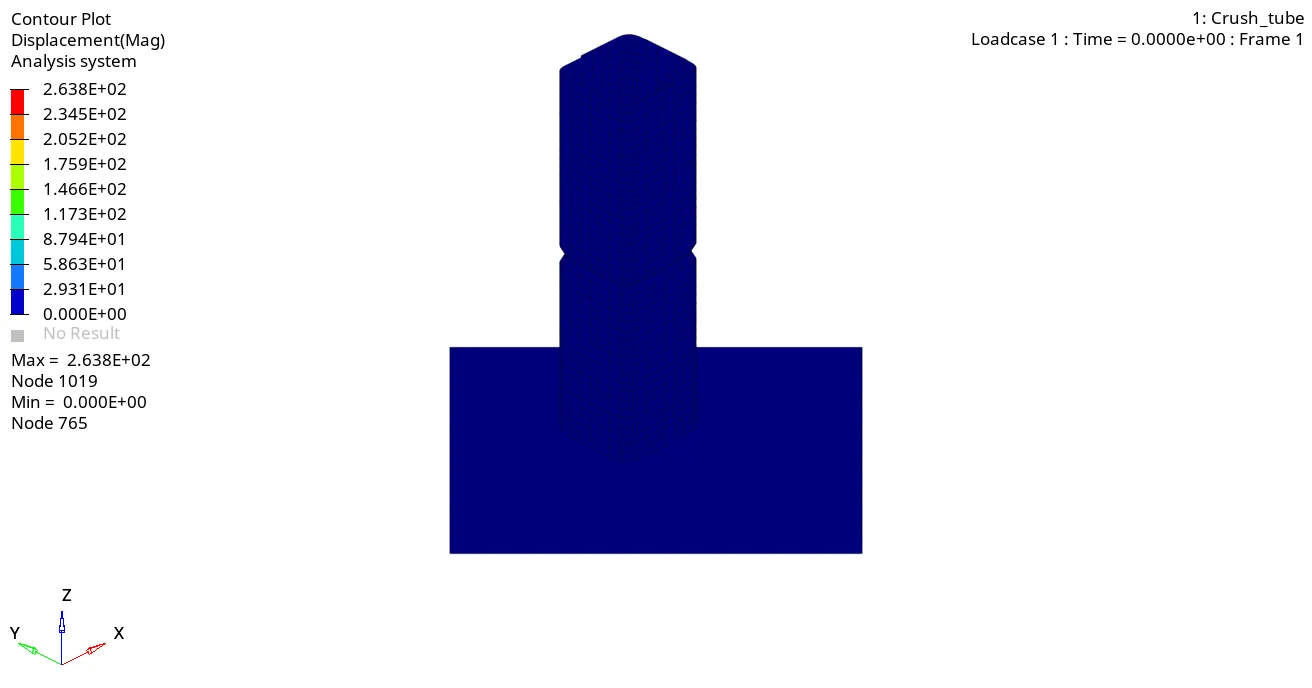
SELF CONTACT ANIMATION FILE
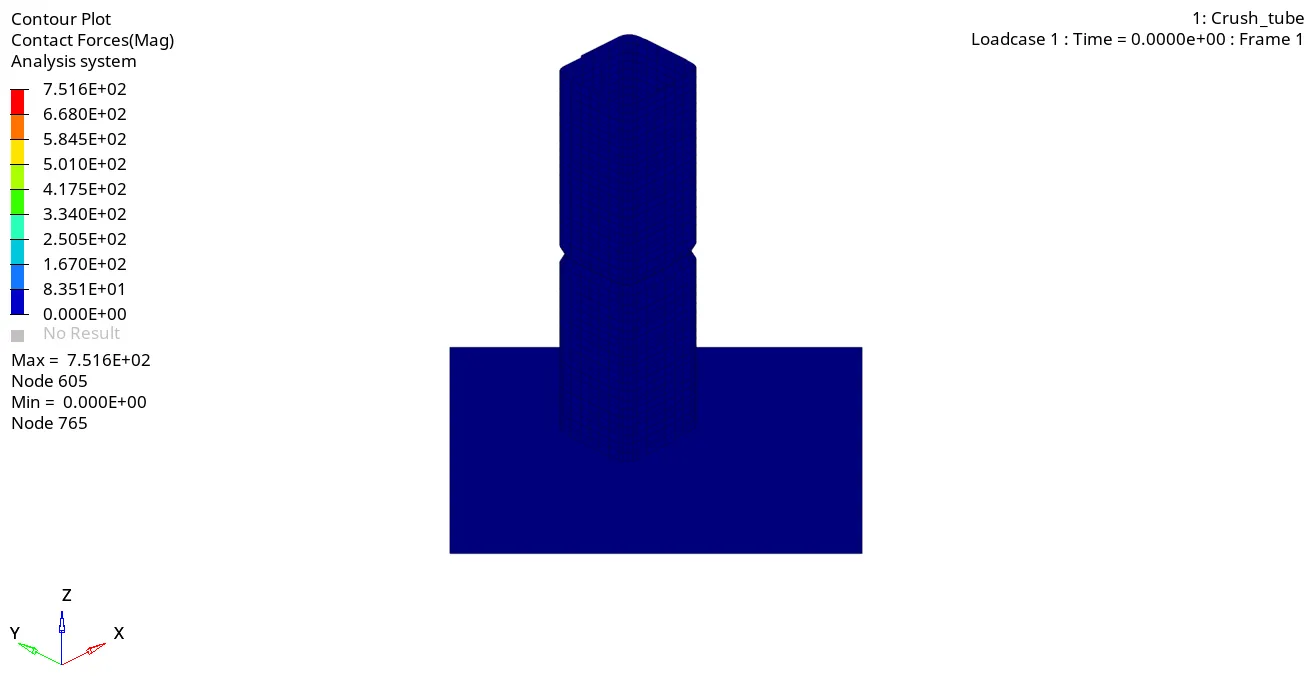
VON MISES ANIMATION FILE
RIGID WALL PLOT
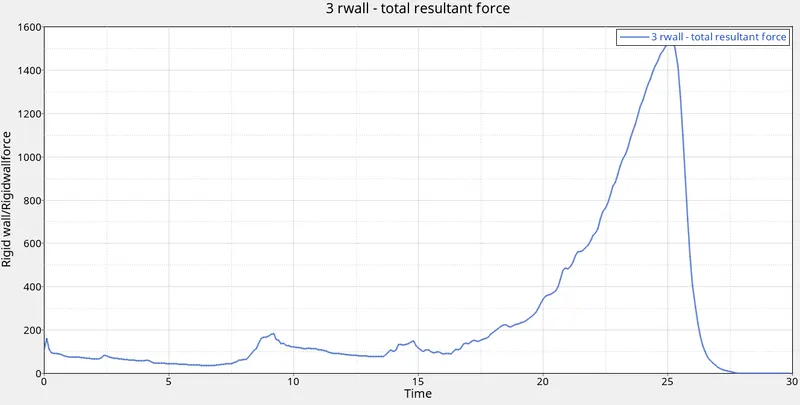
The Max rigid wall force is noted 1500N and in the time range of 26ms. this is equal to case 2 of crush tube.
SELF CONTACT PLOT
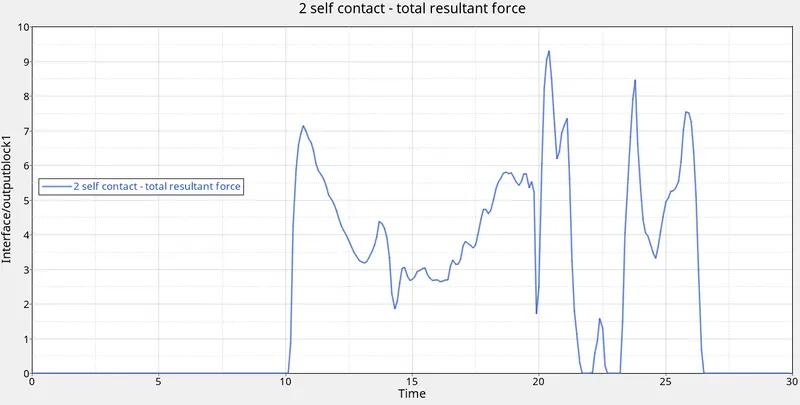
The self contact force is fluctuated due to the notch creation at the middle of the crush tube. so the rigid body of the master node force is acting in the middle of the crush tube and that force is directliny acting on the rigid body with contact force and also rigid body is not fixed. because we deleted the bounday conditions.
TOTAl ENERGY PLOT
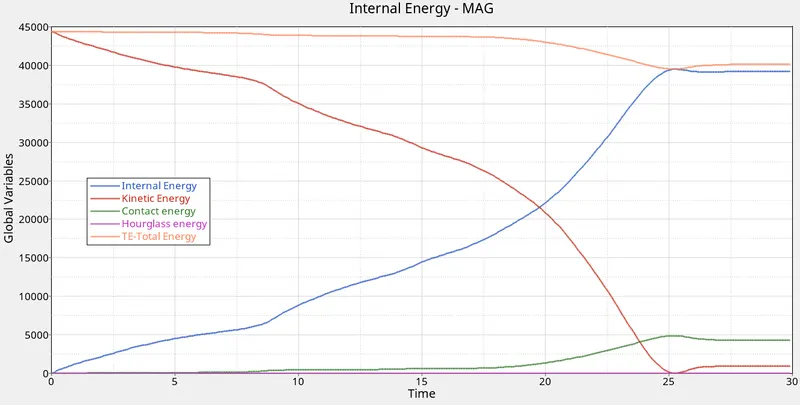
the kinetic energy is converted into internal energy at the point of 19 ms.
CASE -6 Create a new notch with nodes only from opposing 2 faces and run.
The energy error is shown in figure below.
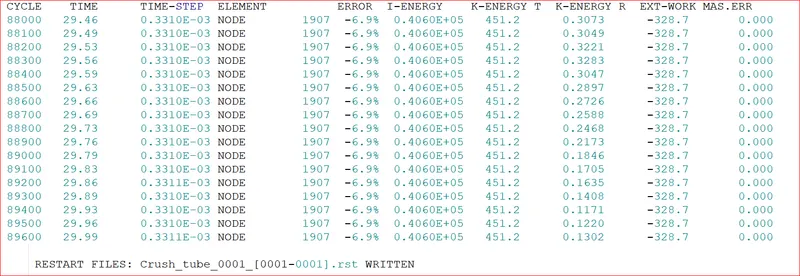
the energy error is 6.9% so it satisfied the ideal condition of 15%. the energy error is zero.
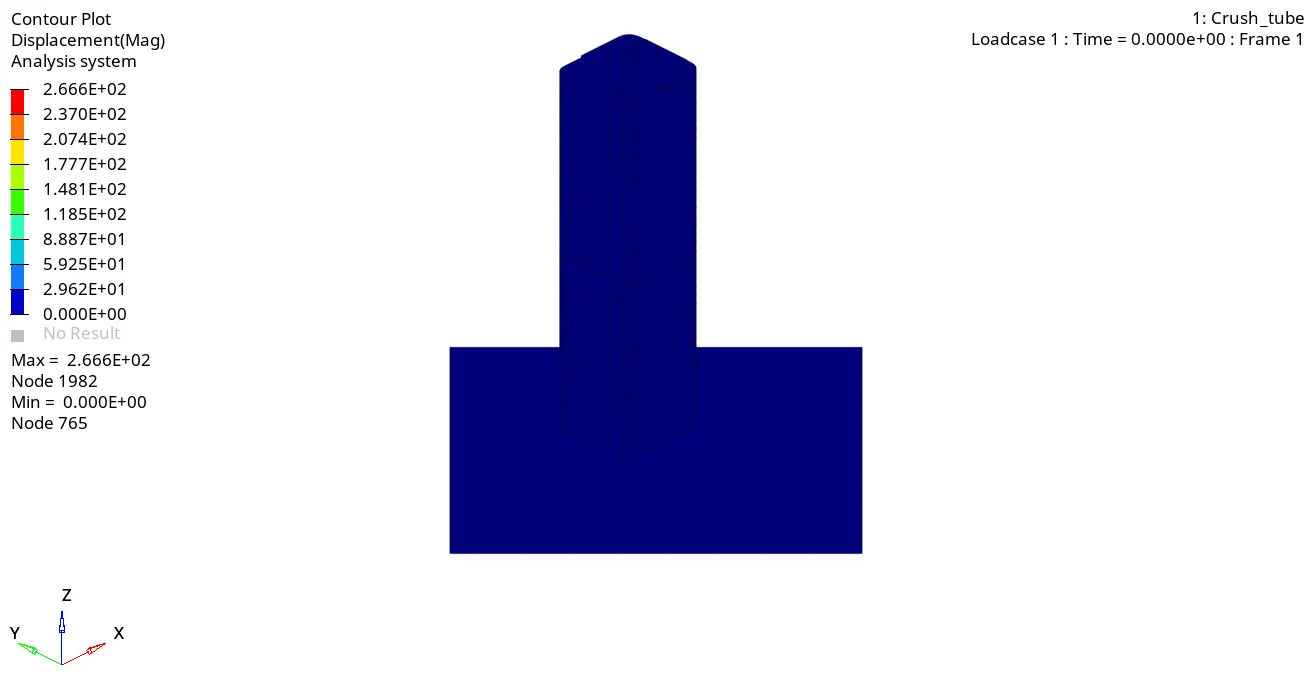
DISPLACEMENT ANIMATION FILE
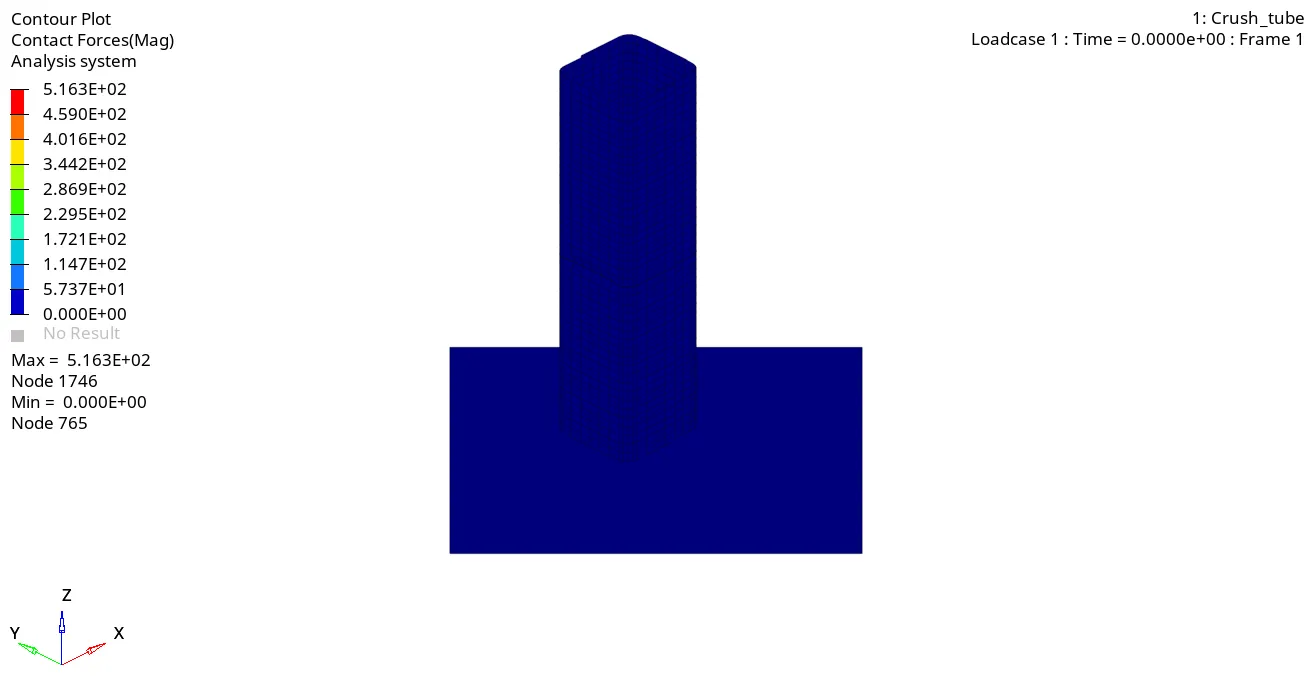
CONTACT FORCE ANIMATION FILE
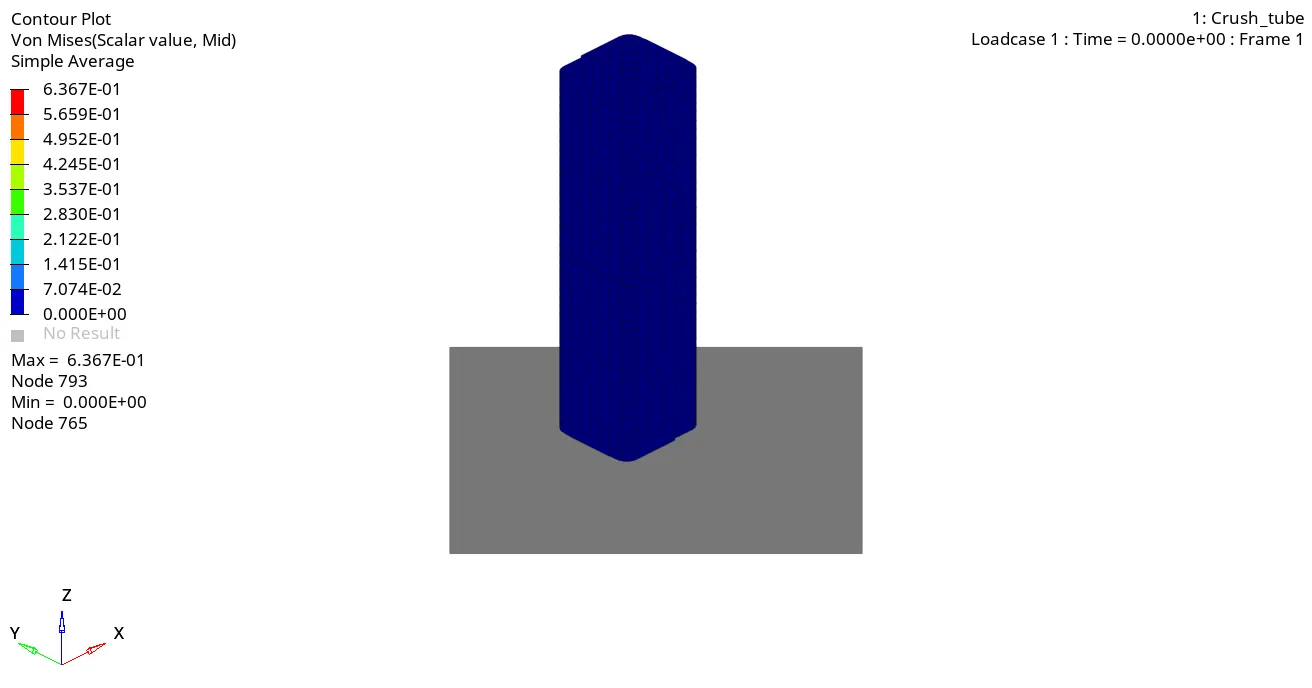
VON MISES ANIMATION FILE
RIGID WALL PLOT
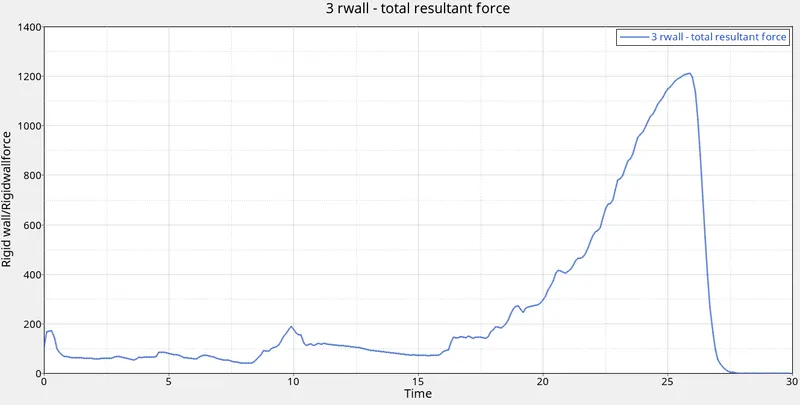
THE max rigid wall force is noted 1210 N. the crush tube deformed totally and that energy is impacted on the rigid wall.
SELFCONTACT PLOT
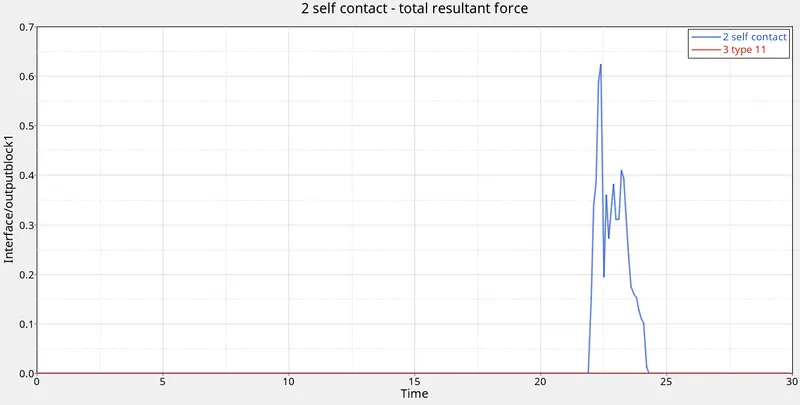
THE SELF CONTACT FORCE IS DEVELOPED AT STARTING OF TYPE 11 DUE TO THE NOTCH PRESENT IN THE MIDDLE.THE MAX SELF CONTACT FORCE IS 0.64N AND THE TIME IS 21ms.
ALL ENERGY PLOT
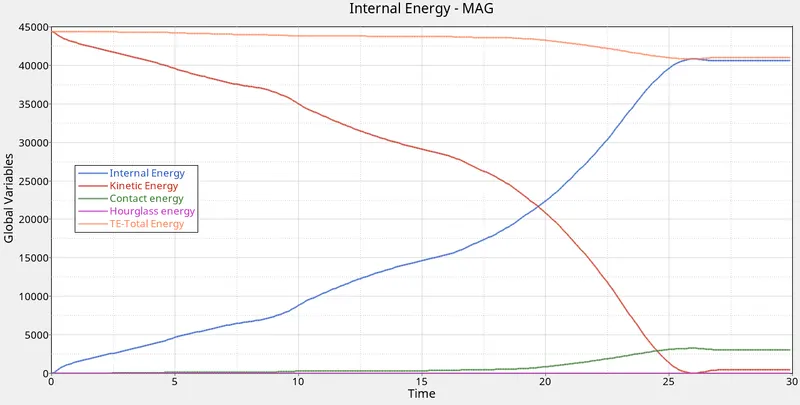
there is no hourglass energy developed so it is correct and conversion of all energies is correct.the kinetic energy is converted into internal energy.
and the summation of all energies is equal to total energy.
RESULT:
| RESULT OF COMPARISON | CASE 1 | CASE 2 | CASE 3 | CASE 4 | CASE 5 | CASE 6 |
| ENERGY ERROR | 3.8% | 3.8% | 7.6% | 8.6% | 6.9% | 6.9% |
| MASS ERROR | 0.00% | 0.00% | 0.00% | 0.00% | 0.00% | 0.00% |
| MAX DISPLACEMENT | 2.800E^2 | 2.800E^2 | 2.665E^2 | 2.653E^2 | 2.638E^2 | 2.666E^2 |
|
MAX CONTACT FORCE |
9.38E^1 | 9.38E^1 | 5.743E^1 | 6.428E^1 | 7.516E^1 | 5.263^1 |
| RIGID WALL | 200N | 1338.18N | 1532.247N | 1180N | 1500N | 1210N |
LEARNING OUTCOMES
- How to perform radioss execution/analysis.
- how to import a model
- how to prepare solver deck
- how many types of interfaces
- contact modelling
- types of contacts
- comparison of types
- how to take plot graphs
- what is rigid wall
- what is rigid body
- what is master and slave node