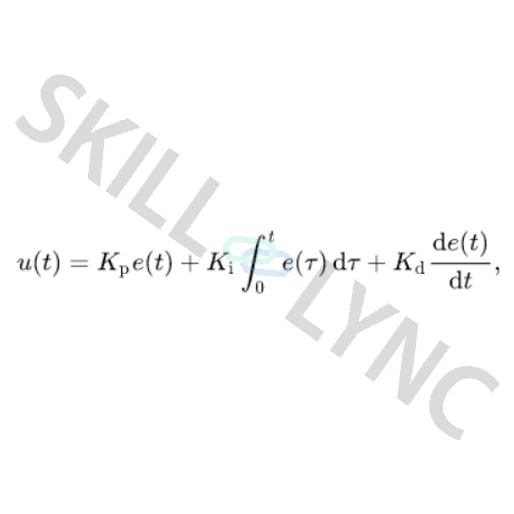How To Tune PID Controllers for Converter Feedback
In industrial control applications, a PID controller is a device that regulates temperature, flow, pressure, speed, and other process variables. PID (proportional integral derivative) controllers, which use a control loop feedback mechanism to control process variables, are the most accurate and trustworthy controllers.
 Navin Baskar·26 Aug 2022·2 min read
How To Tune PID Controllers for Converter Feedback
In industrial control applications, a PID controller is a device that regulates temperature, flow, pressure, speed, and other process variables. PID (proportional integral derivative) controllers, which use a control loop feedback mechanism to control process variables, are the most accurate and trustworthy controllers.
What Functions a PID Controller?
A proportional integral derivative (PID) controller can be used to control temperature, pressure, flow, and other process variables. In order to let the device automatically adjust for system changes, the PID controller, as its name suggests, combines proportional control with additional integral and derivative alterations.
Basics of PID Controller
A PID controller's function is to force feedback to correspond to a setpoint, like a thermostat that compels the heating and cooling system to operate based on a predetermined temperature. PID controllers work best in systems with a low mass and quick responses to changes in the amount of energy added to the process.
The Working of a PID controller
The most precise and reliable controllers are PID (proportional integral derivative) controllers, which use a control loop feedback mechanism to control process variables. In real life, it automatically corrects a control function with accuracy and responsiveness. A common example is the cruise control on a car, which would slow down if just constant engine power was used as it ascended a hill. By boosting the engine's power output, the controller's PID algorithm returns the measured speed to the target speed with little delay or overrun.
PID Controller regulation
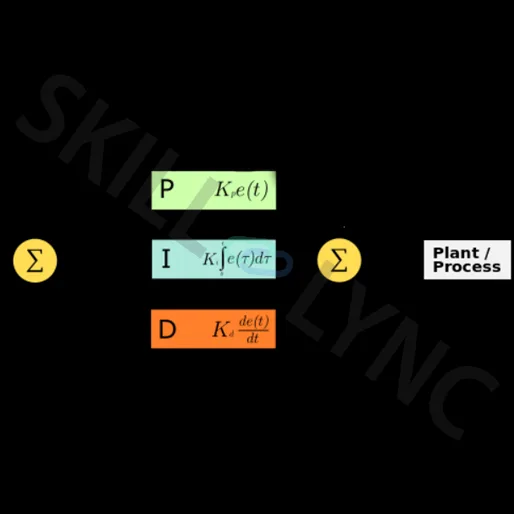
The fundamental idea underlying a PID controller is that every one of the terms—proportional, integral, and derivative—must be independently set. A correction factor is computed and applied to the input to support the difference between these two values.
The three steps are as follows:
- Correcting a target proportionally to the difference is understood as proportional tuning. As a result, the goal value is rarely reached because the applied correction decreases because the discrepancy gets closer to zero.
- Integral tuning makes an endeavour to handle this by efficiently accumulating the error produced by the "P" operation so as to lift the correction factor. as an example, "I" would act to extend the top provided if the oven remained below temperature. However, "I" tries to drive the cumulative error to zero, resulting in an overshoot, instead of stopping heating when the target is met.
- Derivative tuning aims to minimise this overshoot by delaying the correction factor used because the target is near. A derivative term instead considers the speed of change of error, attempting to cut back this rate to zero, instead of the error itself (which can't be dropped at zero.