Week-6 Challenge: EV Drivetrain
AIM
To understand EV Drivetrain.
OBJECTIVES
- To understand power converter circuits employed in EV and HEV.
- To understand the difference between power cable and signal cable.
- To understand the battery limits of the battery source in EV.
PROBLEM SPECIFICATION AND SOLVING:
PROBLEM STATEMENT I:
Which types of power converter circuits are employed in an electric (EV) and hybrid electric vehicle (HEV)?
EXPLANATION AND OBSERVATION:
[1] The voltage from all sources of electrical power varies with time, temperature, and many other factors, especially current. Battery voltage is actually quite well regulated, but frequently there will be a requirement for a change in the voltage to a lower or higher value, usually to control the speed of a motor. Most electronic and electrical equipment requires a fairly constant voltage. This can be achieved by dropping the voltage down to a fixed value below the operating range of the fuel cell or battery or boosting it up to a fixed value. In other cases, it would be desirable to produce a variable voltage (e.g., for a motor) from the more-or-less fixed voltage of a battery. Therefore, a change is required, and it is done using ‘switching’ or ‘chopping’ circuits, which are described below.
[2] Choppers are used for the control of DC motors because of a number of advantages such as high efficiency, flexibility in control, light weight, small size, quick response, and regeneration down to very low speeds. Presently, the separately excited DC motors are usually used in traction, due to the control flexibility of armature voltage and field. For a DC motor control in open-loop and closed-loop configurations, the chopper offers a number of advantages due to its high operation frequency. High operation frequency results in high-frequency output voltage ripple and, therefore, less ripples in the motor armature current and a smaller region of discontinuous conduction in the speed–torque plane. A reduction in the armature current ripple reduces the armature losses. A reduction or elimination of the discontinuous conduction region improves speed regulation and the transient response of the drive.
SINGLE-QUADRANT CHOPPER: The power electronic circuit and the steady-state waveform of a DC chopper drive are shown in Figure 1. A DC voltage source, V, supplies an inductive load through a self-commutated semiconductor switch S. The symbol of a self-commutated semiconductor switch has been used because a chopper can be built using any device among thyristors with a forced commutation circuit: GTO, power transistor, MOSFET, and IGBT. The diode shows the direction in which the device can carry current.
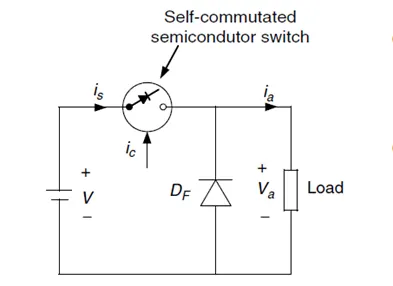
Figure 1. Principle of operation of a step down (or class A) basic chopper circuit.
The diode shows the direction in which the device can carry current. A diode DF is connected in parallel with the load. The semiconductor switch S is operated periodically over a period T and remains closed for a time ton = δT with 0 < δ < 1. The variable δ = ton/T is called the duty ratio or duty cycle of a chopper. Figure 2., also shows the waveform of control signal ic. Control signal ic will be the base current for a transistor chopper, and a gate current for the GTO of a GTO chopper or the main thyristor of a thyristor chopper. If a power MOSFET is used, it will be a gate to the source voltage. When the control signal is present, the semiconductor switch S will conduct, if forward biased. It is assumed that the circuit operation has been arranged such that the removal of ic will turn off the switch.
During the on interval of the switch (0`<=` t `<=` δT), the load is subjected to a voltage V and the load current increases from ia1 to ia2. The switch is opened at t = δT. During the off period of the switch (δT`<=` t `<=` 1), the load inductance maintains the flow of current through diode DF. The load terminal voltage remains zero (if the voltage drop on the diode is ignored in comparison to V) and the current decreases from ia2 to ia1. The internal 0`<=` t `<=` δT is called the duty interval and the interval δT`<=` t `<=` T is known as the free-wheeling interval. Diode DF provides a path for the load current to flow when switch S is off, and thus improves the load current waveform. Furthermore, by maintaining the continuity of the load current at turn off, it prevents transient voltage from appearing across switch S, due to the sudden change of the load current. The source current waveform is also shown in Figure 2(e). The source current flows only during the duty interval and is equal to the load current. The direct component or average value of the load voltage Va is given by:
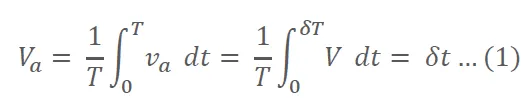
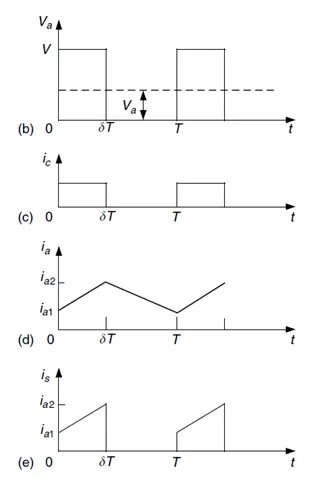
Figure 2. Waveforms from (b) to (e) for a step-down basic chopper (class A).
By controlling δ between 0 and 1, the load voltage can be varied from 0 to V; thus, a chopper allows a variable DC voltage to be obtained from a fixed voltage DC source. The switch S can be controlled in various ways for varying the duty ratio δ. The control technologies can be divided into the following categories:
- Time ratio control (TRC). [Constant frequency TRC: The chopper period T is kept fixed and the on period of the switch is varied to control the duty ratio δ. Varied frequency TRC: Here, δ is varied either by keeping ton constant and varying T or by varying both ton and T.]
- Current limit control (CLC).
The following important points can be noted from the waveform of Figure 2:
- The source current is not continuous but flows in pulses. The pulsed current makes the peak input power demand high and may cause fluctuation in the source voltage. The source current waveform can be resolved into DC and AC harmonics. The fundamental AC harmonic frequency is the same as the chopper frequency. The AC harmonics are undesirable because they interfere with other loads connected to the DC source and cause radio frequency interference through conduction and electromagnetic radiation. Therefore, an L-C filter is usually incorporated between the chopper and the DC source. At higher chopper frequencies, harmonics can be reduced to a tolerable level by a cheaper filter. From this point, a chopper should be operated at the highest possible frequency.
- The load terminal voltage is not a perfect direct voltage. In addition to a direct component, it has harmonics of the chopping frequency and its multiples. The load current also has an AC ripple.
The chopper of Figure 1 is called a class A chopper. It is one of a number of chopper circuits that are used for the control of DC motors. This chopper is capable of providing only a positive voltage and a positive current. It is therefore called a single-quadrant chopper, capable of providing DC separately excited motor control in the first quadrant, positive speed, and positive torque. Since it can vary the output voltage from V to 0, it is also a step-down chopper or a DC-to-DC buck converter. The basic principle involved can also be used to realize a step-up chopper or DC to DC boost converter.The circuit diagram and steady-state waveforms of a step-up chopper are shown in the Figure 3. This chopper is known as a class B chopper. The presence of control signal ic indicates the duration for which the switch can conduct if forward-biased.
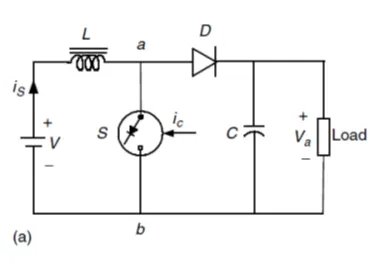
Figure 3. Principle of operation of a step up (or class B) basic chopper circuit.
During a chopping period, T, it remains closed for an interval 0 t δT and remains open for an interval δT t T. During the on period, iS increases from iS1 to iS2, thus increasing the magnitude of energy stored in inductance L. When the switch is opened, current flows through the parallel combination of the load and capacitor C. Since the current is forced against the higher voltage, the rate of change of the current is negative. It decreases from iS2 to iS1 in the switch’s off period. The energy stored in the inductance L and the energy supplied by the low-voltage source are given to the load. The capacitor C serves two purposes. At the instant of opening of switch S, the source current, iS, and load current, ia, are not the same. In the absence of C, the turn off of S will force the two currents to have the same values. This will cause high induced voltage in the inductance L and the load inductance. Another reason for using capacitor C is to reduce the load voltage ripple. The purpose of the diode D is to prevent any flow of current from the load into switch S or source V. For understanding the step-up operation, capacitor C is assumed to be large enough to maintain a constant voltage Va across the load. The average voltage across the terminal a, b is given as:
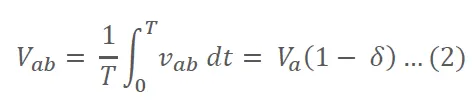
The average voltage across the inductance L is:
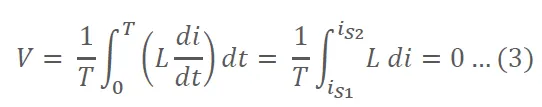
The source voltage is:
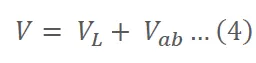
Substituting from equations (2) and (3) into (4) gives:
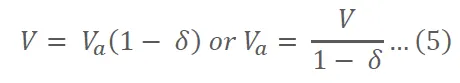
According to (5), theoretically the output voltage Va can be changed from V to ∞ by controlling δ from 0 to 1. In practice, Va can be controlled from V to a higher voltage, which depends on the capacitor C, and the parameters of the load and chopper.
The main advantage of a step-up chopper is the low ripple in the source current. While most applications require a step-down chopper, the step-up chopper finds application in low-power battery-driven vehicles. The principle of the step-up chopper is also used in the regenerative braking of DC motor drives.
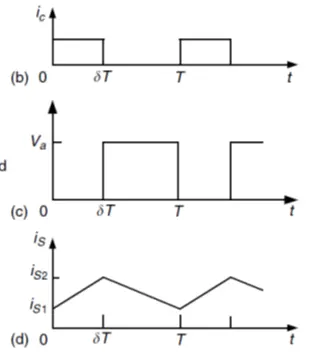
Figure 4. Waveforms from (b) to (d) for a step-up basic chopper (class B).
TWO-QUADRANT CONTROL OF FORWARD MOTORING AND REGENERATIVE BRAKING: A two-quadrant operation consisting of forward motoring and forward regenerative braking requires a chopper capable of giving a positive voltage and current in either direction. This two-quadrant operation can be realized in the following two schemes.
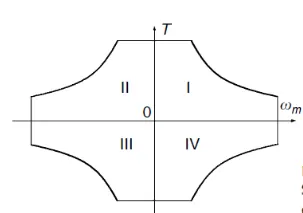
Figure 5. Speed–torque profiles of multi-quadrant operation.
SINGLE CHOPPER WITH A REVERSE SWITCH: The chopper circuit used for forward motoring and forward regenerative braking is shown in Figure 6.11, where S is a self-commutated semiconductor switch, operated periodically such that it remains closed for a duration of δT and remains open for a duration of (1 - δ)T. C is the manual switch. When C is closed and S is in operation, the circuit is similar to that of Figure 6.6, permitting the forward motoring operation. Under these conditions, terminal a is positive and terminal b is negative.
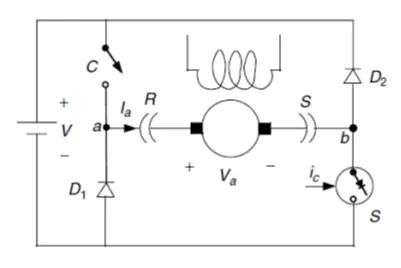
Figure 6. Forward motoring and regenerative braking control with a single chopper.
Regenerative braking in the forward direction is obtained when C is opened and the armature connection is reversed with the help of the reversing switch RS, making terminal b positive and terminal a negative. During the on-period of the switch S, the motor current flows through a path consisting of the motor armature, switch S, and diode D1, and increases the energy stored in the armature circuit inductance. When S is opened, the current flows through the armature diode D2, source V, diode D1 and back to the armature, thus feeding energy into the source. During motoring, the changeover to regeneration is done in the following steps. Switch S is deactivated, and switch C is opened. This forces the armature current to flow through diode D2, source V, and diode D1. The energy stored in the armature circuit is fed back to the source and the armature current falls to zero. After an adequate delay to ensure that the current has indeed become zero, the armature connection is reversed, and switch S is reactivated with a suitable value of d to start regeneration.
CLASS C TWO-QUADRANT CHOPPER: In some applications, a smooth transition from motoring to braking and vice versa is required. For such applications, the class C chopper is used as shown in Figure 7. The self-commutated semiconductor switch S1 and diode D1 constitute one chopper and the self-commutator switch S2 and diode D2 form another chopper. Both the choppers are controlled simultaneously, both for motoring and regenerative braking.
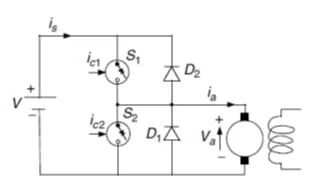
Figure 7. Forward motoring and regenerative braking control using class C two-quadrant chopper circuit.
The switches S1 and S2 are closed alternately. In the chopping period T, S1 is kept on for a duration δT, and S2 is kept on from δT to T. To avoid a direct, short-circuit across the source, care is taken to ensure that S1 and S2 do not conduct at the same time. This is generally achieved by providing some delay between the turn off of one switch and the turn on of another switch. The waveforms of the control signals va ia and is and the devices under conducting during different intervals of a chopping period are shown in Figure 8. In drawing these waveforms, the delay between the turn off of one switch and the turn on of another switch has been ignored because it is usually very small. The control signals for the switches S1 and S2 are denoted by ic1 and ic2, respectively. It is assumed that a switch conducts only when the control signal is present, and the switch is forward biased.
The following points are helpful in understanding the operation of this two-quadrant circuit:
- In this circuit, discontinuous conduction does not occur, irrespective of its frequency of operation. Discontinuous conduction occurs when the armature current falls to zero and remains zero for a finite interval of time. The current may become zero either during the freewheeling interval or in the energy transfer interval. In this circuit, freewheeling will occur when S1 is off, and the current is flowing through D1. This will happen in interval δT t T, which is also the interval for which S2 receives the control signal. If ia falls to zero in the freewheeling interval, the back EMF will immediately drive a current through S2 in the reverse direction, thus preventing the armature current from remaining zero for a finite interval of time. Similarly, energy transfer will be present when S2 is off and D2 is conducting — that is, during the interval 0 t δT. If the current falls to zero during this interval, S1 will conduct immediately because ic is present and V > E. The armature current will flow, preventing discontinuous conduction.
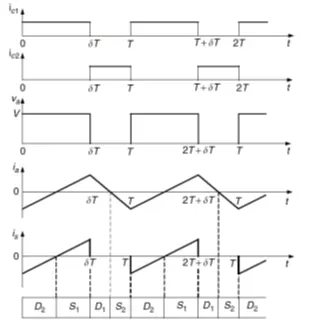
Figure 8. Forward motoring and regenerative braking control using class C two-quadrant chopper waveforms.
- Since discontinuous conditions are absent, the motor current will be flowing all the time. Thus, during the interval 0`<=` t `<=` δT, the motor armature will be connected either through S1 or D2. Consequently, the motor terminal voltage will be V and the rate of change of ia will be positive because V>E. Similarly, during the interval δT `<=` t `<=`T, the motor armature will be shorted either through D1 or S2. Consequently, the motor voltage will be zero and the rate of change of ia will be negative.
- During the interval 0 `<=` t `<=` δT, the positive armature current is carried by S1 and the negative armature current is carried by D2. The source current flows only during this interval and it is equal to ia. During the interval δT`<=`t `<=`T, the positive current is carried by D1 and the negative current is carried by S2.
- From the motor terminal voltage waveform of Figure 8, Va = δV. Hence,
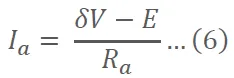
Equation (6) suggests that the motoring operation takes place when δ > E/V, and that regenerative braking occurs when δ < E/V. The no-load operation is obtained when δ = E/V.
FOUR-QUADRANT OPERATION: The four-quadrant operation can be obtained by combining two class C choppers (Figure 7) as shown in Figure 9, which is referred to as a class E chopper. In this chopper, if S2 is kept closed continuously and S1 and S4 are controlled, a two-quadrant chopper is obtained, which provides positive terminal voltage (positive speed) and the armature current in either direction (positive or negative torque), giving a motor control in quadrants I and IV. Now if S3 is kept closed continuously and S1 and S4 are controlled, one obtains a two-quadrant chopper, which can supply a variable negative terminal voltage (negative speed) and the armature current can be in either direction (positive or negative torque), giving a motor control in quadrants II and III.
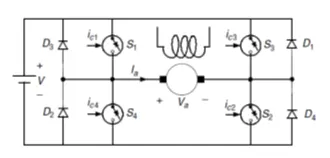
Figure 9. Class E four-quadrant chopper.
This control method has the following features: the utilization factor of the switches is low due to the asymmetry in the circuit operation. Switches S3 and S2 should remain on for a long period. This can create commutation problems when the switches use thyristors. The minimum output voltage depends directly on the minimum time for which the switch can be closed, since there is always a restriction on the minimum time for which the switch can be closed, particularly in thyristor choppers. The minimum available output voltage, and therefore the minimum available motor speed, is restricted. To ensure that switches S1 and S4, or S2 and S3 are not on at the same time, some fixed time interval must elapse between the turn off for one switch and the turn on of another switch. This restricts the maximum permissible frequency of operation. It also requires two switching operations during a cycle of the output voltage.
PROBLEM STATEMENT II:
An Electric Vehicle’s Drivetrain with 72V battery pack is shown in the diagram below.
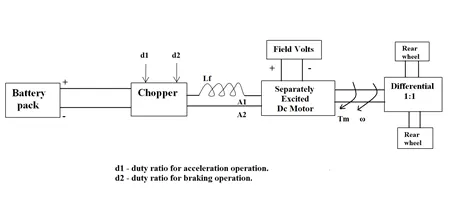
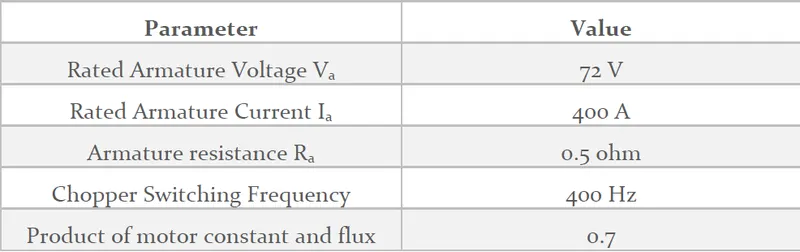
The duty ratio for acceleration operation is ‘d1’ and for the braking operation the duty ratio is ‘d2’. The other parameters of the electric vehicle are tabulated below:
Motor and Controlled parameters:
The vehicle characteristics are given by the following equation:
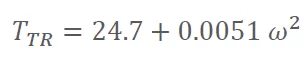
What is EV steady-state speed if the duty cycle is 70%?
EXPLANATION AND OBSERVATION:
At steady state condition, Torque of the motor and the vehicle are equal. Therefore, we have
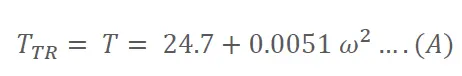
Given that the duty cycle ratio is 70%. Therefore, from the equation (5), we have:
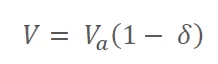
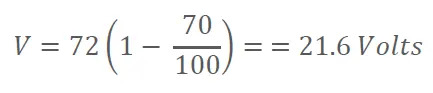
We know from the Torque Speed characteristics, the equation for the torque of any type of DC motor is given as follows:
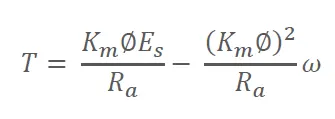
On substituting the values in the above formula, we have:
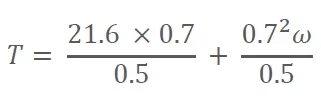
On equating equations (A) and (B), we get a quadratic equation as follows:
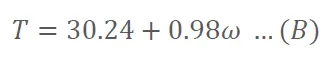
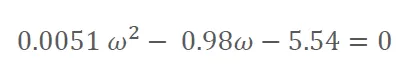
On solving the equation, we have:
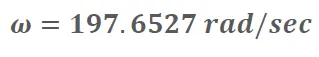
Therefore, the electric vehicle’s steady state speed when it works on the duty cycle of the ratio 70% is 197.65 rad/sec.
PROBLEM STATEMENT III:
Explain in brief about the author, Wally Ripple’s, Tesla, perspective of the topic mentioned in the blog on Induction motor versus Brushless DC motor given below:
https://www.tesla.com/blog/induction-versus-dc-brushless-motors
EXPLANATION AND OBSERVATION:
Wally Ripple, an engineer who also worked at Tesla, has a well-established knowledge of EV’s. In the article he mentions the competitive features of both Induction motor and a Brushless DC motor. He believes that these motors are to survive for a long time to come in the near future and also sheds a light on how the improvements in the machine affects their performance and cost analysis pertaining to the motors.
He starts of by describing the working principles of brushless DC motor and Induction motor as follows:
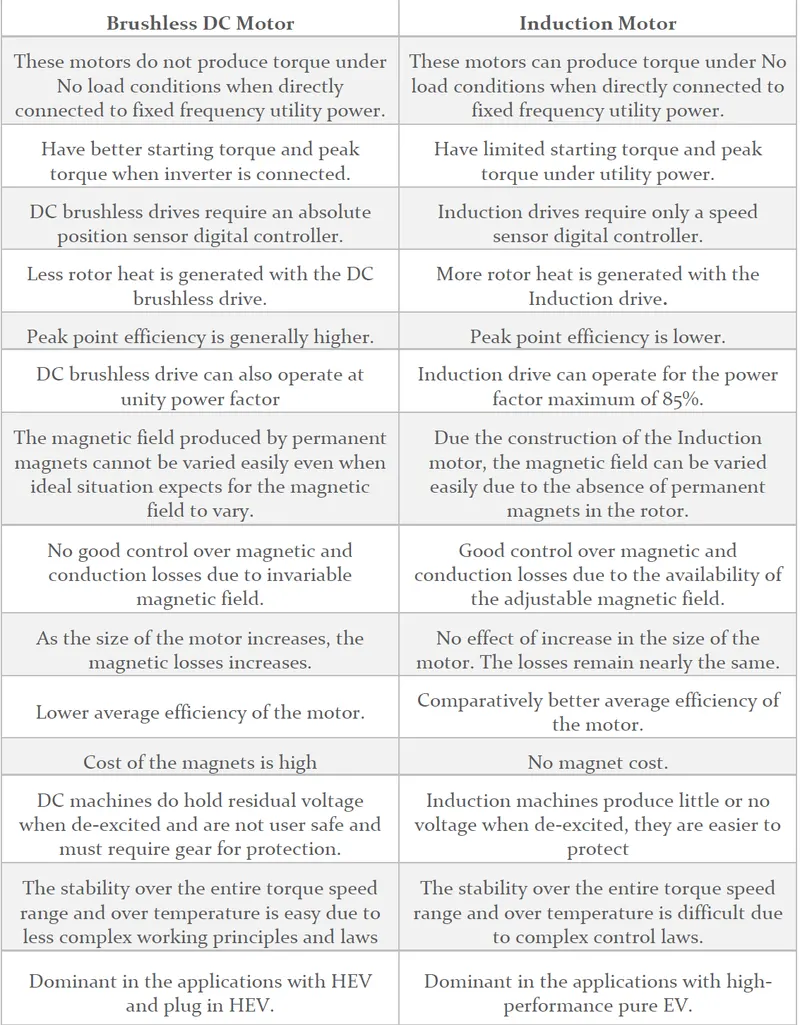
BRUSHLESS DC MOTOR: The brushless DC motor has a rotor that includes two or more permanent magnets which generate DC magnetic field. The permanent magnets are expensive which amount nearly $50/kilogram. This magnetic field interacts with the current flowing through the windings in the stator that establishes a torque interaction between rotor and the stator. For the produced torque to remain constant, the magnitude and the polarity of the stator current are continuously varied with the help of a current control device known as an Inverter. This results in the conversion of the electrical energy to mechanical energy in optimally efficient manner. The key component in the Brushless DC motor is the Inverter. To maintain the inverter and motor currents at their lowest possible values, magnetic field strength should be maximum under maximum torque requirements, especially at low speeds. This results in optimized efficiency by keeping (I2R) losses at bay. Under the converse requirements i.e., low torque condition, magnetic field should be reduced by reducing eddy and hysteresis losses caused due to magnetic field. As a results, to achieve best efficiency of brushless DC motor, it is required to minimize the eddy, hysteresis and I2 losses. As the size of the motor is increased the magnetic losses also increase proportionately and the part load efficiency also decreases.
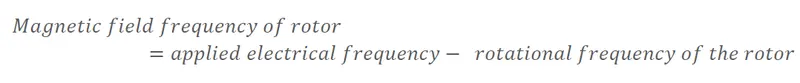
INDUCTION MOTORS: These motors do not have magnets in their rotors. The rotors consist of stacked steel laminations with buried peripheral conductors that form a shorted structure. The current in the stator windings produces a rotating magnetic field which influences the rotor. In terms of frequency, rotor frequency due to magnetic field is the result of applied electrical frequency and the loss developed due to rotation frequency i.e.,
The induced voltage produces currents that result in the voltage existing proportionate to the speed difference between the rotor and electrical frequency. These currents produce force and therefore torque, on interacting with the original magnetic field. The adjustable magnetic fields in Induction motor is obtained due to the fact that the magnetic field is proportional to the ratio of voltage and frequency. The smart inverter reduces the voltage under light loads in such a way that the magnetic losses are reduced thereby improving the efficiency. This acts as a great advantage over the brushless DC motors. For high-performance requirement, Induction motor is preferred. Although the peak efficiency is lower than the DC motor, the average efficiency may actually be better. On the other hand, under high-performance condition, inverter ratings and costs appear to be lower. Spinning induction machines produce little or no voltage when de-excited, they are easier to protect. The induction machines are difficult to control due to the complex control laws. Achieving stability over the entire torque speed range and over temperature is difficult as compared to DC motors. This points to additional development costs but cuts down the recurring costs to almost zero.
RESULTS
- The different types of power converter circuits in EV and HEV are explained in detail.
- The electric vehicle’s steady state speed when it works on the duty cycle of the ratio 70% is 197.65 rad/sec.
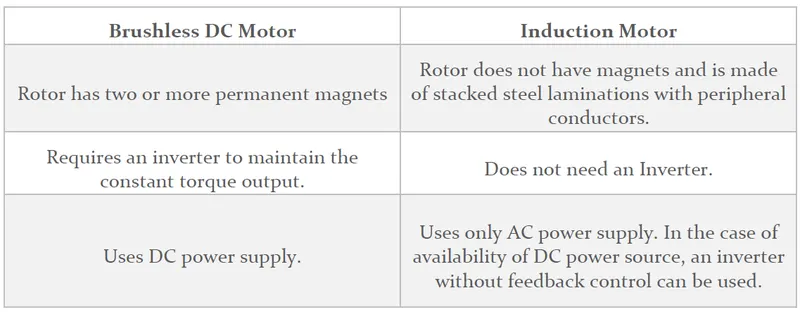
- The following are the differences observed in the author’s perspective:
CONCLUSION
The required problems have been solved and justified with appropriate results. Different types of power converter circuits are employed in an electric (EV) and hybrid electric vehicle (HEV) are thoroughly explained. The author’s take on the weighing the applications of Brushless DC motor and Induction motor is very eye opening.
BIBLIOGRAPHY
- “Electric Vehicle Technology Explained”, James Larminie, John Lowry, John Wiley & Sons Ltd, The Atrium, Southern Gate, Chichester, West Sussex PO19 8SQ, England. ISBN 0-470-85163-5.
- ‘Modern Electric, Hybrid Electric, and Fuel Cell Vehicles – Fundamentals, Theory, and Design”, Mehrdad Ehsani, Yimin Gao, Sebastian E.Gay, Ali Emadi, Power electronics and applications series, ISBN 0-8493-3154-4, CRC Press LLC, 2000 N.W. Corporate Blvd., Boca Raton, Florida.