Study on Wide Open Throttle (WOT) Condition using MATLAB-Simulink
Wide Open Throttle (WOT) Conditions
AIM:
(1) To differentiate between the mapped and dynamic models used in MATLAB/Simulink.
(2) To study and calculate the model for miles per gallon and also state the factors considered to model fuel flow.
(3) To simulate the HEV Reference Application with WOT cycle and comment on the results w.r.t to change in the grade and wind velocity in the environment block with the defaults value.
(4) To simulate and compare the results of hybrid and Pure EV powertrains with WOT drive cycle.
SOLUTION:
(1) What is the difference between the mapped and dynamic model of engine, motor and generator? How can you change the model type?
Answer:-
The below table shows the difference between the mapped and dynamic model of engine, motor and generator.
| ParameterModels | Mapped | Dynamic |
| Engine | It is the default settings in the powertrain blockset. It is used to measure the performance parameters of the vehicle by using standard lookup tables which are preferred to the system. This type of modelling is less accurate. The lookup tables value are based on the values of brake torque, commanded torque and engine speed. If any other parameter like Input engine temperature is selected then lookup table values are also a function of the temperature parameter. The data extracted from lookup tables are air mass flow, fuel flow, emission data, exhaust temperature and efficiency. This data is used to find out other parameters which are needed by the end-user. | This type of model uses real-time data fed by the user at run time for modelling. This model is more accurate than the mapped engine model. This type of model is used when the data of subsystems of a vehicle is required. We can calculate Brake torque, fuel flow, port gas mass flow, exhaust temperature, exhaust mass flow rate and exhaust emissions. |
| Motor | The mapped motor works in torque control mode. This type of motor is used when the user requires a faster simulation and doesn't have the knowledge of motor parameters. The output torque and reference torque is compared and changes are made. Input torque or speed can be specified, electrical losses and maximum motor power and torque can be defined. | It is a three-phase interior permanent magnet synchronous motor (PMSM) is used. The block uses three-phase input voltages to regulate the individual phase currents, allowing control of the motor torque or speed. This block is used when the user knows what parameters are to be used in that particular simulation. This motor is more accurate |
| Generator | This block is also similar to other blocks. Most of the data required are taken from the lookup tables corresponding to the given input parameters. Its simulation time is less. | It involves the user entering the parameters manually during the run time for their particular applications. The results take time and are more accurate. |
How can you change the model type:
(I) Go to the Modelling page. Under the design window, click on the dropdown arrow.
(II) Then click on the Variant Manager, a new window will pop up.
(III) After selecting the GenDynamic, do the right-click and select the Set as label Mode Active case.
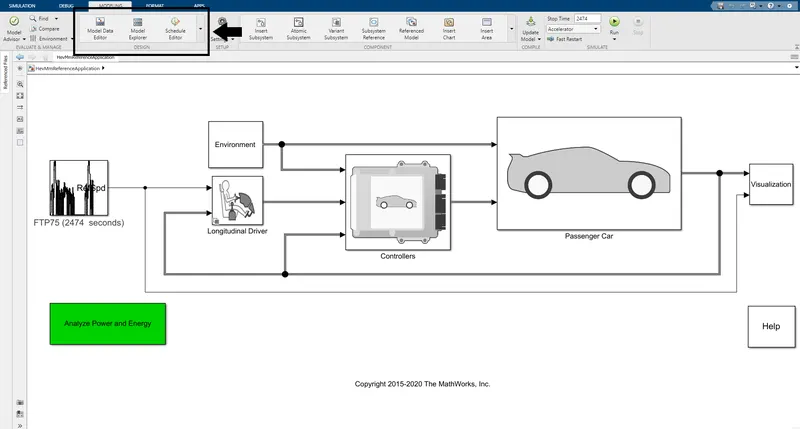
fig(i) The Simulink window showing the modelling command
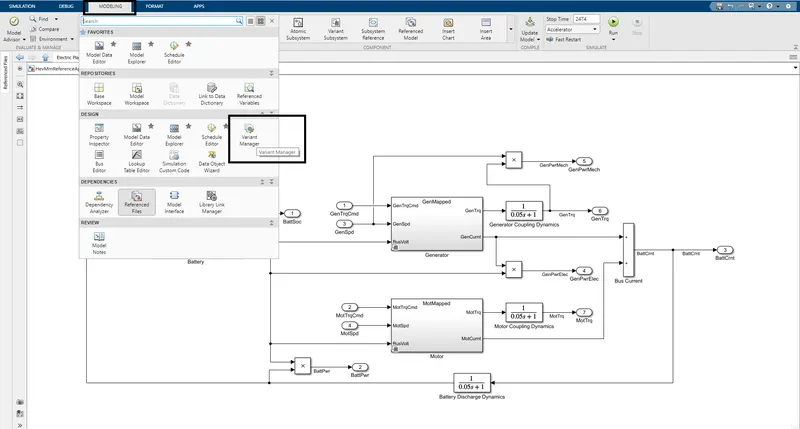
fig(ii) The variant manager command window inside the vehicle sub-block
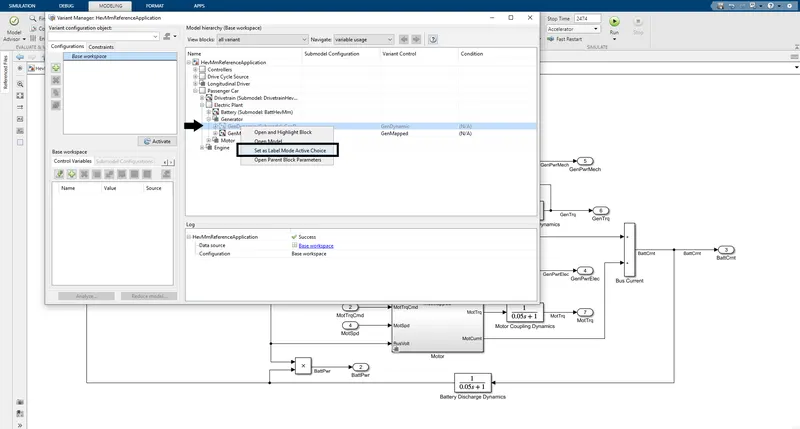
fig(iii) The selection window for changing the mapped to dynamic parameters
-----------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------
(2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Answer:-
Miles per gallon (MPG) is a fuel economy rating determined by how far a car can travel on a gallon of gasoline or diesel. Although the metric version would be kilometres per litre, MPG is adopted in many metric-system countries, like USA, Canada and other European Nations.
While it is both cheaper and better for the environment to achieve a higher MPG rating, there is a curve, that the EPA calls the "MPG Illusion" that shows the cost-benefits of increasing MPG decrease with the higher rating. For example, to travel 1,000 miles, a car that gets 10 MPG will require 100 gallons of fuel. Conversely, a car that gets 15 MPG will require 67 gallons of fuel. In this case, an increase of just 5 MPG cuts fuel consumption by 33%. When a car gets 30 MPG, however, increasing its mileage to 35 MPG will only save 5 gallons of fuel over 1,000 miles.
The below figure is the block used by Simulink to calculate the MPGe to display the performance of the vehicle.
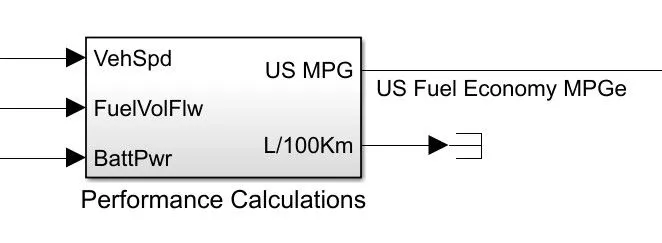
fig(iv) Simulink block for the Performance calculation
The sub-block of the Performance Calculation is shown by the below figure.
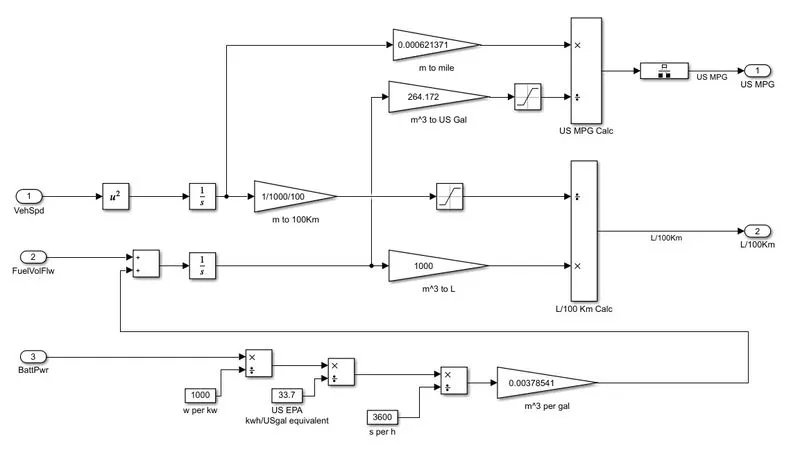
fig (v) Simulink sub-block of the Performance Calculation
The factors considered to model fuel flow:
- Vehicle speed
- Fuel volume flow
- Battery power
Steps to calculate the MPGe:-
- As we know, that 1 gallon of gas is equal to 33.7 kWh of electricity.
- So battery power is first converted into KW (W/1000) then its divides by 33.7 kWh.
- The fuel equivalent of battery is added to the fuel flow.
- Using vehicle speed and time the distance of travel is calculated.
- Then distance is converted into miles by conversions.
- Then as we have the fuel flow in `m^3` and distance in miles and we can calculate the fuel efficiency.
-----------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------
(3) Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
Answer:- The basic architecture of HEV is shown below.
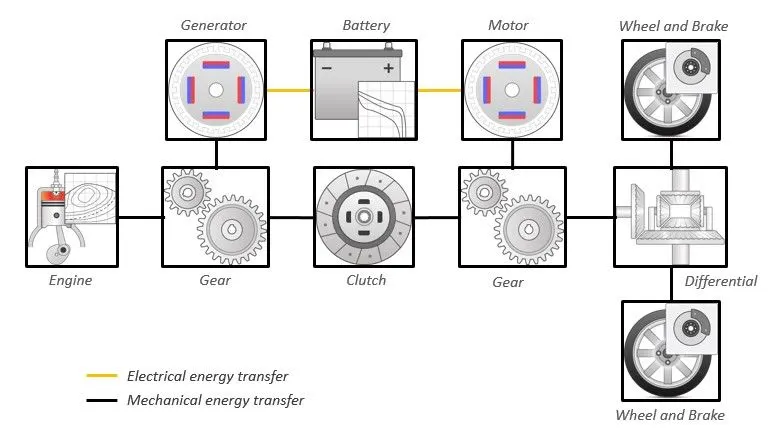
fig (vi) The basic architecture of HEV from Mathworks website
The Simulink block diagram for HEV is shown below with FTP75 drive cycle.
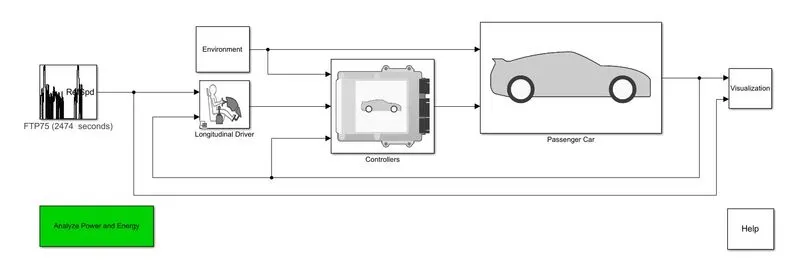
fig (vii) The Simulink block diagram of the HEV with FTP75 drive cycle
WOT conditions:
| Start time | t_wot1 | 5 |
| Initial reference speed | xdot_woto | 0 |
| Nominal reference speed | xdot_wot1 | 45 |
| Time to start deceleration | t_wot2 | 70 |
| Final reference speed | xdot_wot2 | 0 |
| WOT simulation time | t_wotend | 150 |
------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------------
(4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
Answer:- The basic architecture of pure EV is shown below and for HEV, it is shown in the previous question.
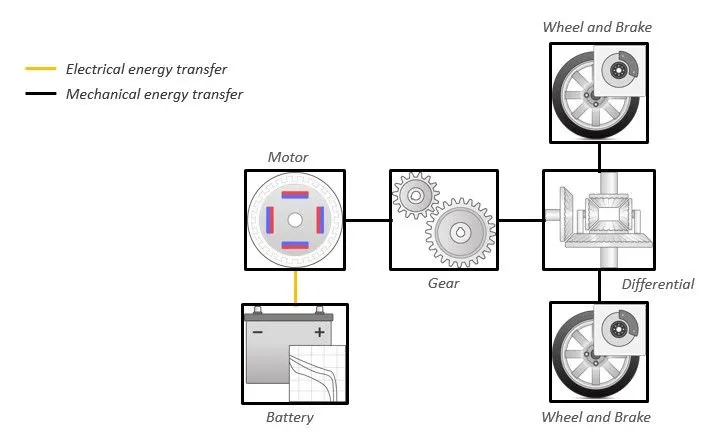
fig (viii) The basic architecture of pure EV from Mathworks website
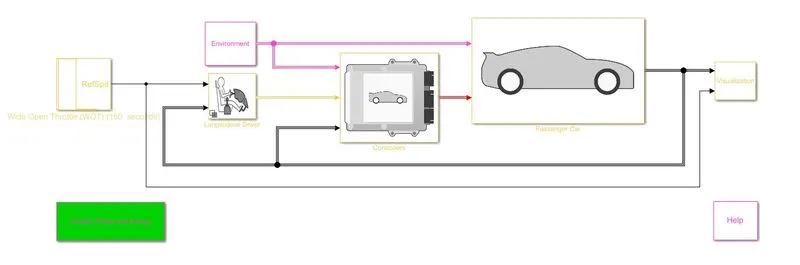
fig (ix) The Simulink block diagram of the EV with WOT drive cycle
TEST CASES:
The test results are carried out in 3 cases:-
(i) CASE 1: Performance of the HEV with the WOT drive cycle.
(ii) CASE 2: Performance of the HEV with the WOT drive cycle and with the changed of the grade & wind velocity.
(iii) CASE 3: Performance of the EV with the WOT drive cycle and with the changed of the grade & wind velocity.
fig (x) The sub-block of Environment block with the changed values of grade and wind velocity
Test results:
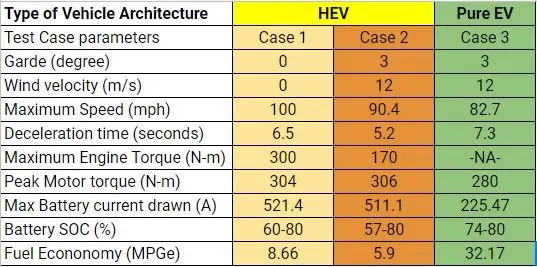
fig(xi) The test results output table
Graphs:
(i) CASE 1: Performance of HEV with WOT drive cycle.
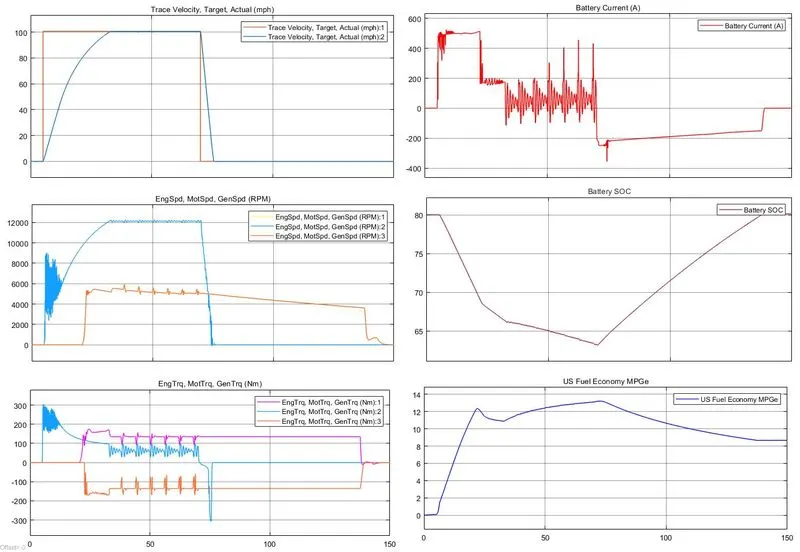
fig(xii) Performance graph results of HEV with WOT drive cycle
(ii) CASE 2: Performance of the HEV with the WOT drive cycle and with the changed of the grade & wind velocity.
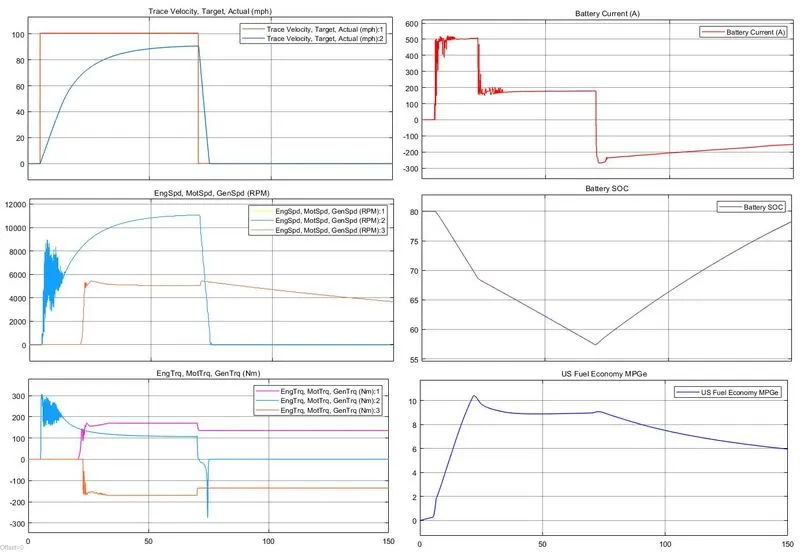
fig(xiii) Performance graph results of HEV with WOT drive cycle
(iii) CASE 3: Performance of the EV with the WOT drive cycle and with the changed of the grade & wind velocity.
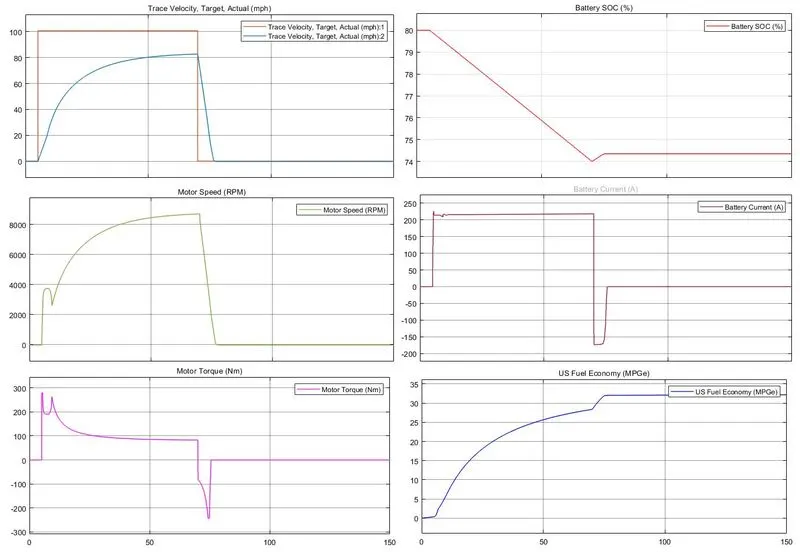
fig(xiv) Performance graph results of EV with WOT drive cycle
Observations:
(i) CASE 1
- The target speed and the actual speeds are the same w.r.t time and the WOT condition.
- The battery is gradually decreasing before the declaration starts and increases gradually w.r.t time.
- The engine speed & motor speed characteristics behave in the same fashion. The generator speed is 0 till engine & motor speed reaches to the maximum.
- The motor torque is high at the start of the drive cycle for instantaneous acceleration and reduces as per the engine torque reaches its peak value. The generator produces negative torque in this case.
(ii) CASE 2
- In this case, the grade value and the wind velocity is change as mentioned above.
- The actual speed is less than the target speed with the change in the grade and wind velocity.
- The engine is not fluctuating as compare to 0-degree grade value.
- The characteristics behave in the same manner but with the decrease in the values w.r.t the initial conditions.
- The maximum speed achieved is lower in case 2 because of the gradient slope considered and also the wind resistance.
- Since more power from the energy source is required to overcome these resistances, the battery SOC and the fuel economy is decreased.
(iii) CASE 3
- As this is the case of Pure EV, the vehicle completely relies on the motor power for its output.
- The battery SOC is reduced drastically in the time of acceleration.
- The electric powertrain achieves a lower top speed when compared to an HEV powertrain.
- Since the motor is the only propulsion source in an EV powertrain, the motor needs higher rated power and generate the instantaneous start-up torque to propel the vehicle.
CONCLUSION:
(1) Studied and explained the difference between the mapped and dynamic models of engine, motor and generators used in MATLAB/Simulink.
(2) Explained the calculation of the model for miles per gallon and also stated the factors considered to model fuel flow.
(3) Successfully simulated the HEV Reference Application model with assigned WOT cycle and commented on the results w.r.t to change in the grade and wind velocity in the environment block with the defaults value for hybrid and pure EV powertrains.
(4) By looking at the characteristics curves of HEV and Pure EV, we can conclude that the conventional HEV's use lead-acid battery whereas the EV's use lithium-ion cells which have more energy density. And also, EV has a superior fuel economy than a conventional HEV.