Challenge WOT Condition Part-2
AIM:
1) Find the difference between the mapped and dynamic model of engine, motor and generator. How can you change the model type?
2) Calculate miles per gallon for the model and the factors to be considered for the model fuel flow.
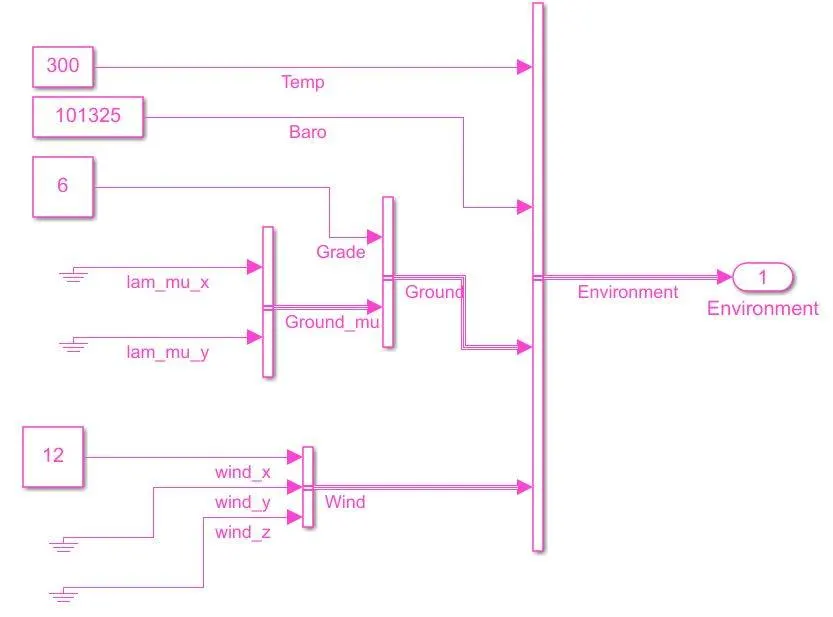
3) Run the HEV Reference application with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
DESCRIPTION:
1) DIFFERENCE BETWEEN THE MAPPED AND DYNAMIC MODEL OF ENGINE, MOTOR, GENERATOR & CHANGE THE MODEL TYPE:
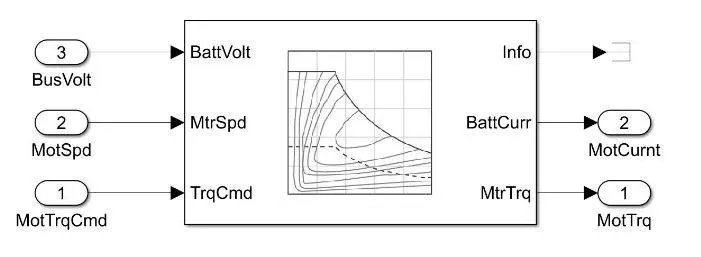
MAPPED ENGINE:
- It is used of steady state lookup tables to characterize the engine performance. The tables provide overall engine characteristics, including actual torque, fuel flow rate and engine out exhaust emissions.
- Most of components are modelled by staedy state maps and charts in backward facing modelling approach, therefore energy consumption and performance of different components during transient periods of drive are not calculated correctly. It is also known as backward facing approach.
- It is suitable for analysis & design activities that do not require engine subsystem dynamic characteristics. For e.g; engine and powertrain transmission analysis for fuel economy, emissions & performance tradeoffs.
BLOCK DIAGRAM:
DYNAMIC ENGINE:
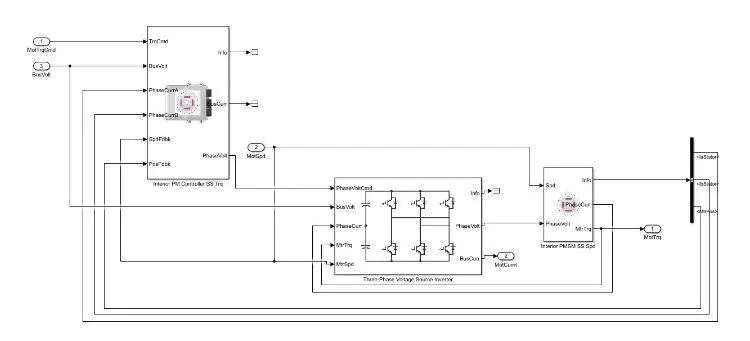
- It decomposes the engine behaviour into engine characteristics thst are seperated into lower level components. By combining the components the model may capture dynamic effects.
- This model are suitable for designing control,estimator & diagnostic alogorithms that depend on dynamic subsystem. For e.g; in closed loop AFR alogorithm development. It is also known as forward facing approach.
- It demands for torque, current & voltage which has been compared with actual variables of the system & with the help of controllers error may occured due to minimization of desirable performance.
BLOCK DIAGRAM:
2) CALCULATE MILES PER GALLON FOR THE MODEL & THE FACTORS TO BE CONSIDERED FOR THE MODEL FUEL FLOW:
Kilowatt-hours is the standard energy unit for electricity. In simplified terms, if an electric vehicle can travel 100 miles on 33.7 kWh of electricity, the EPA rates it at 100 MPGe. As you can see, this would be a very efficient vehicle, because a gas car would have to travel 100 miles per gallon to be equivalent. One gallon of fuel is 3.785 litres of gasoline.
BLOCK DIAGRAM:
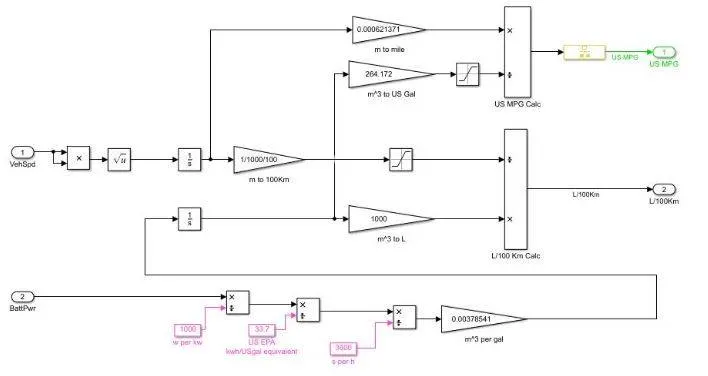
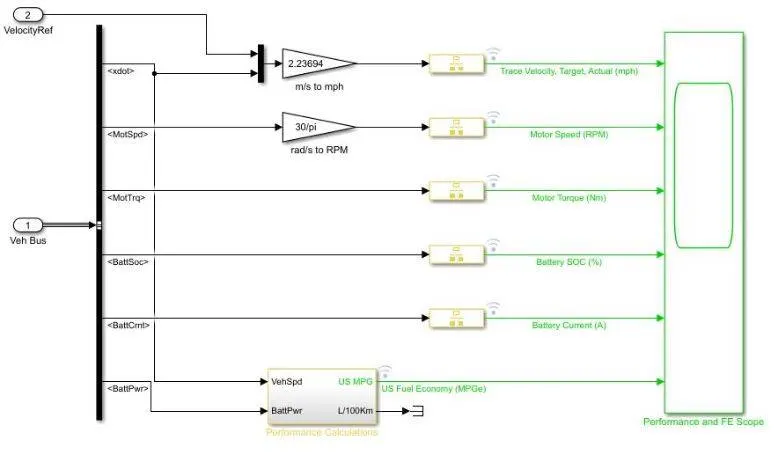
- The above block diagram represents the powertrain blockset of the EV vehicle to calculate the miles per gallon. Given input parameters are fuel flow, vehicle speed & battery power to find the fuel efficiency of the vehicle.
- Distance is calculated by integrating the vehicle speed with respect to time and converted into miles.
- Battery power is consumed by which the total distance is covered & converting from watt into kw.
- The volume flow rate of the fuel is expressed & converted into gallons & integrated with respect to time for calculating the volume of fuel.
Thus Miles per Gallon is calculated for the performance of the fuel economy of the car or commercial vehicle. In simple terms, if your car performs at 40mpg it means that, on average, you will be able to drive 40 miles on every gallon of petrol that you put in the tank.
Factors which are to be considered for the model fuel flow;
- the cost of acquiring and using the fuel for each specific situation.
- the energy content of the fuel type being considered.
- the availability of the type of fuel source wanted.
- how safe it will be to use the fuel under consideration.
3) RUN THE HEV REFERANCE APPLICATION WITH WOT DRIVE CYCLE & CHANGE THE GRADE & WIND VELOCITY IN THE ENVIRONMENT BLOCK:
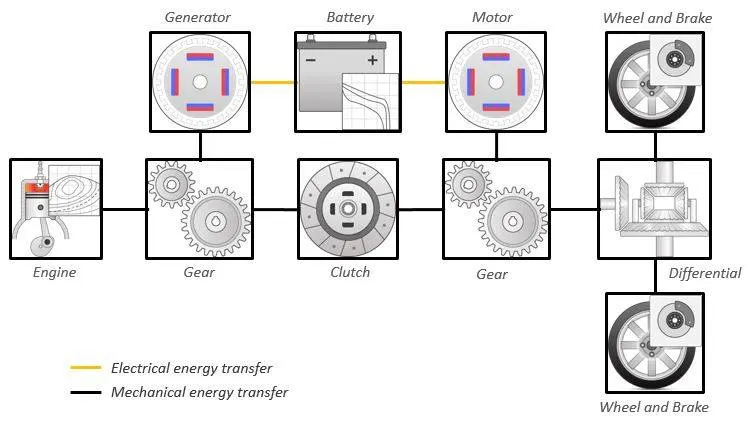
(HEVs) are powered by an internal combustion engine in combination with one or more electric motors that use energy stored in batteries. HEVs combine the benefits of high fuel economy and low tailpipe emissions with the power and range of conventional vehicles.
POWER TRAIN CONFIGURATION:
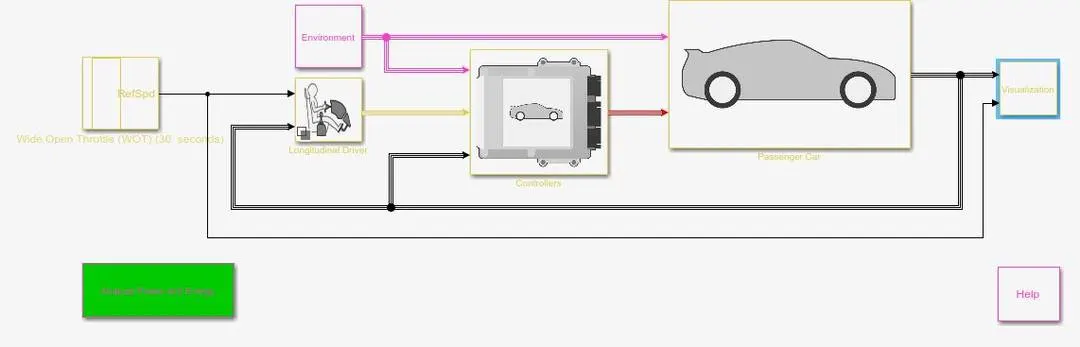
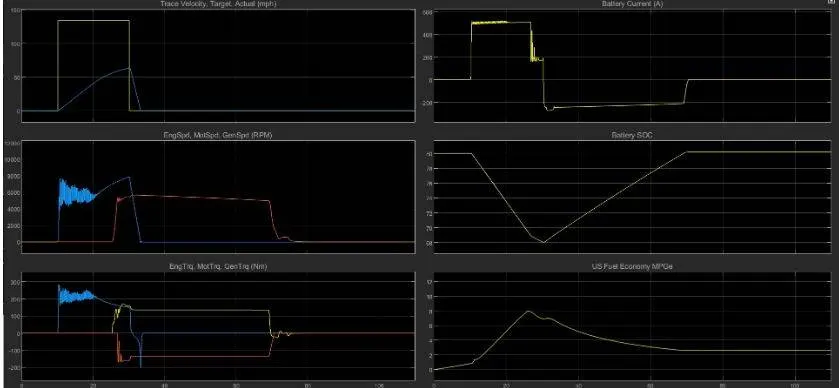
Once the model is selected with wide open throttle drive cycle, we run the simulation where the input parameters are feeded into the drive cycle.
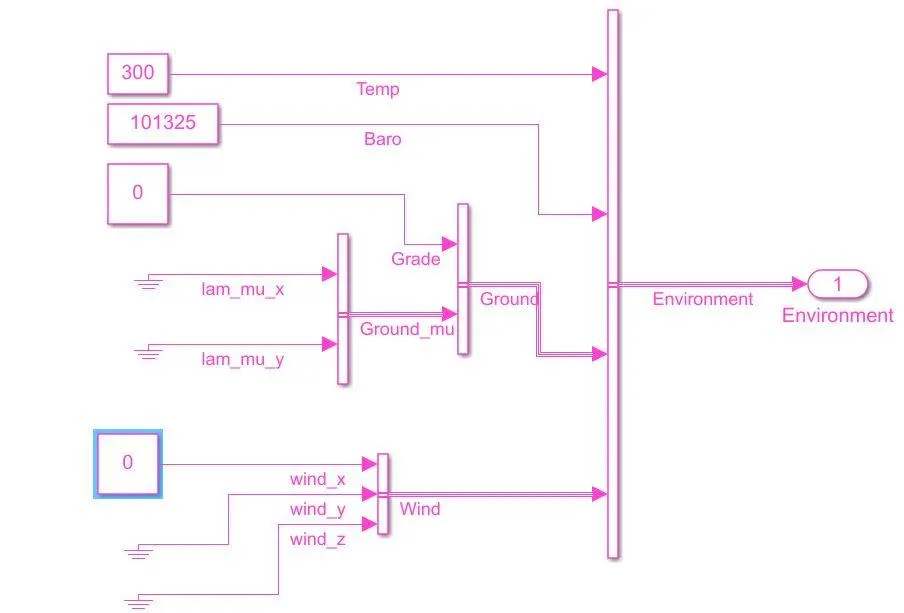
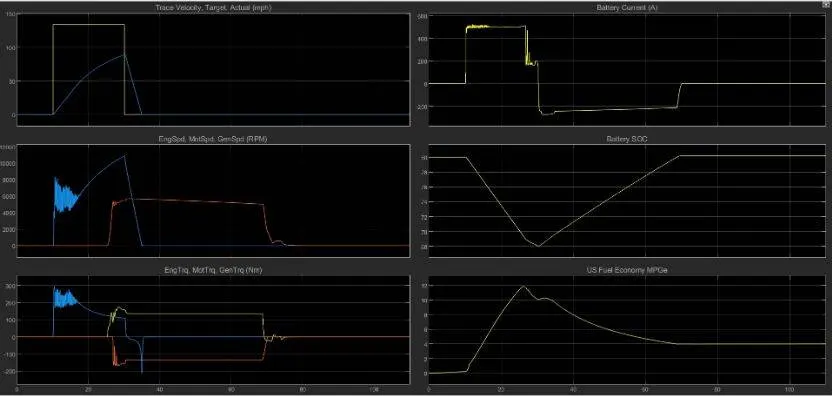
PLOTS:
Change the grade and wind velocity in the environment block
PLOTS:
4) BY KEEPING THE ALL PARAMATERS SAME COMPARE THE SIMULATED RESULTS OF HYBRID AND PURE ELECTRIC VEHICLE:
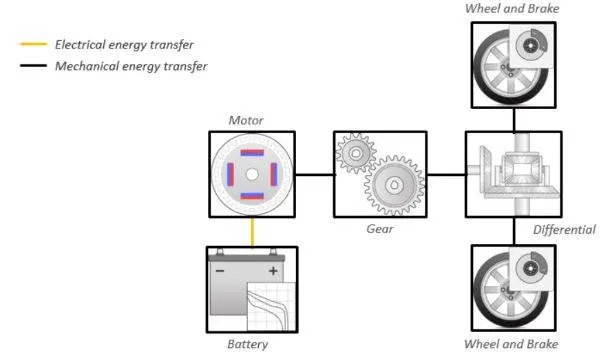
PURE ELECTRIC VEHICLE:
A battery electric vehicle (BEV), pure electric vehicle, only-electric vehicle or all-electric vehicle is a type of electric vehicle (EV) that exclusively uses chemical energy stored in rechargeable battery packs, with no secondary source of propulsion (e.g. hydrogen fuel cell, internal combustion engine, etc.)
POWER TRAIN CONFIGURATION:
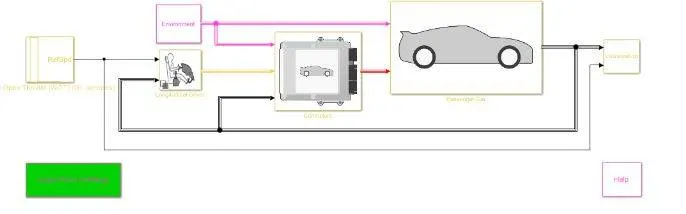
Once the model is selected with wide open throttle drive cycle, we run the simulation where the input parameters are feeded into the drive cycle.
PLOTS:
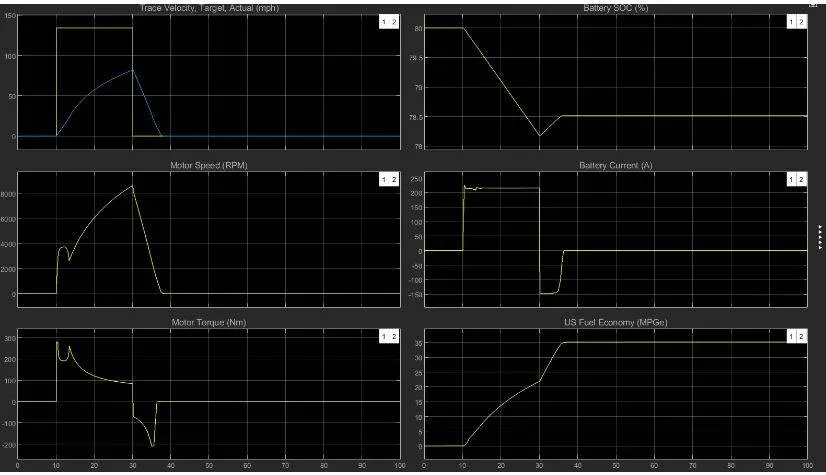
Change the grade and wind velocity in the environment block
PLOTS:
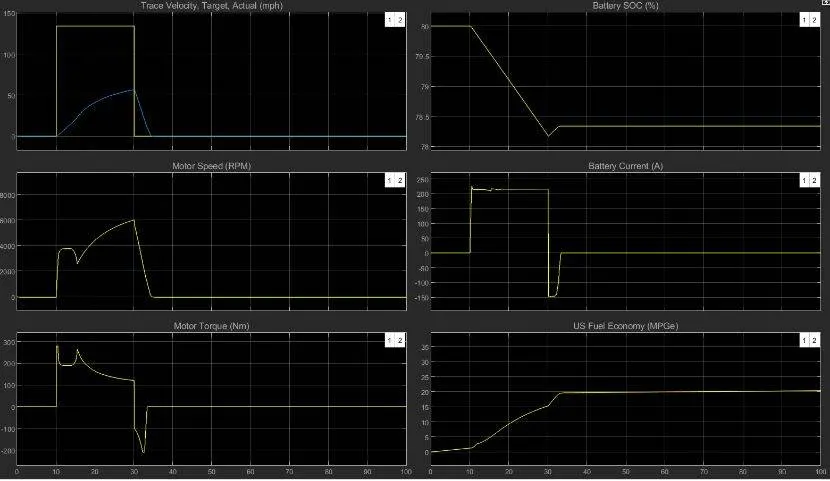
Difference between HEV's & EV's
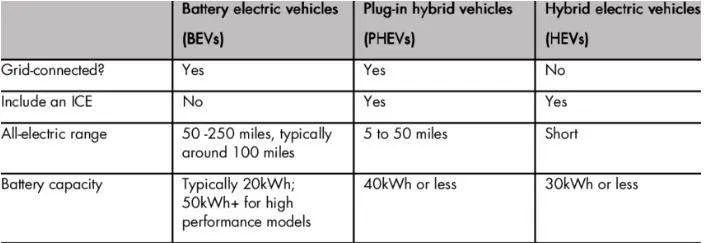
RESULTS:
1) The difference between the mapped and dynamic model engine is verified & model type is identified.
2) The model is calculated miles per gallon & factors are considered.
3) HEV model is simulated & values of wind velocity & grade has been changed.
4) By keeping the all parameters same model is simulated for pure Electric Vehicle.