Week-4 Challenge WOT Condition Part-2
Aim:- To study on Wide Open Throttle (WOT) Part-2.
Objective:-
- Compare between mapped and dynamic model of engine, motor and generator.How can you change model type
- How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
- Run the HEV model with WOT drive cycle and Change the grade and wind velocity in the environment block and Comment on the its results.
- To compare the simulated results of Hybrid Electric and Pure Electric powertrains. Keeping all parameters are same and observation on It results.
Quetion:- 1) What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Ans:-
There are two type of model Mapped and Dynamic.
Mapped Model:-
- In mapped model the data used forthe operation and simulation are to be entered in a form of Lookup table.
- If the detailed lookup table data is available with us the simulation becomes easier and it give the result on the basic of data interpreted.
- It is also called as Global Based Model.
- The calculation In mapped Model are very Fast.
Dynamic Model:-
- In Dynamic model it understand the behavior of the element and then it behaves accordingly.
- It is also called as Real-Time-Based Model.
- In this model use real time data for calculating every behavior of Vehicle characteristics like Velocity, Speed, and Vehicle braking etc.
- The calculation In this model are time Consuming.
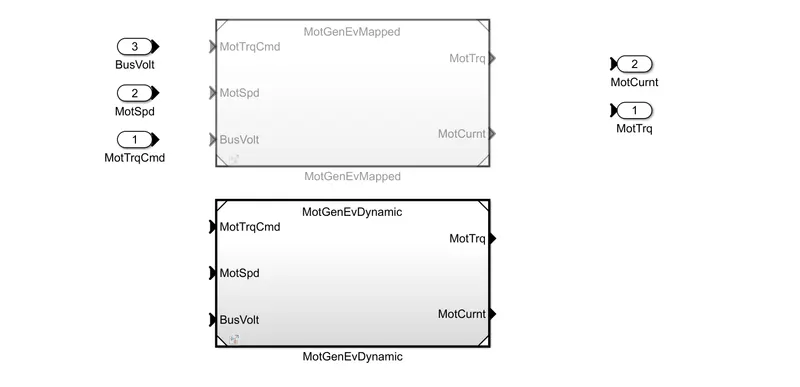
The Sub-system of Mapped and Dynamic Model as shown below:-
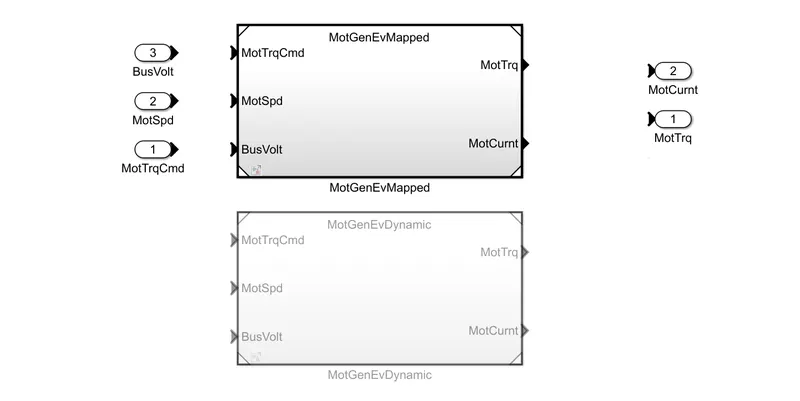
In the mapped model the data used for the operation and simulation are to be entered in a form of Lookup table. In this engine motor require torque.engine performance could be simulated with array of data interpreted in the system.in this engine block generated the required torque output. then the ouput stored in the corresponding given input values of engine,motor and Generator.
In Dynamic model decomposses the engine behavior into engine characteristics that are seperated into lower-value component by combining component in this way the models capture the dynamic effects.
How can you change model type:-
We have open Ev Reference application in powertrain blockset in matlab as shown in below model-
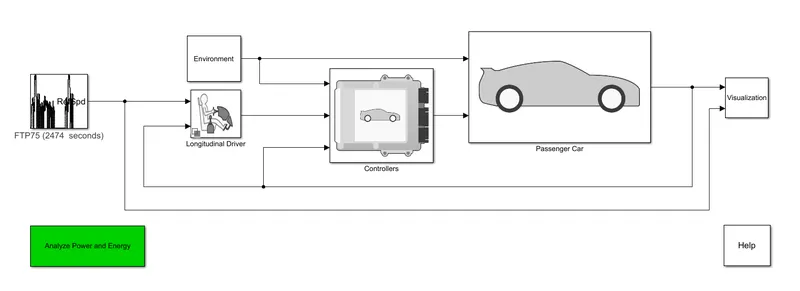
Now, we click on Passenger Car and open this block.Select the Electric plant block.Then we click on 'MotGenEvMapped' bock and open it block.
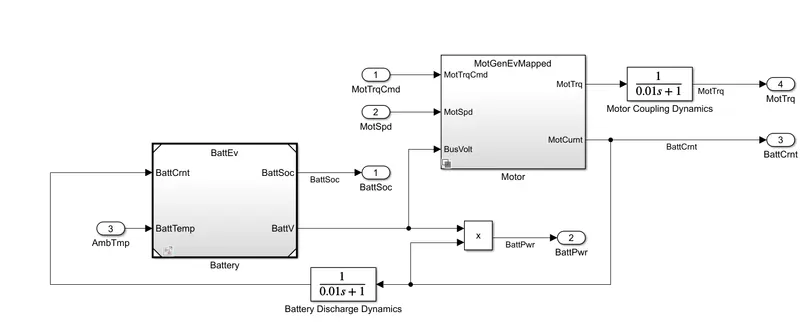
We can see open block MotGenEVMapped model and MotGenEvDynamic model as shown below.
Now, we have change MotGenEvmapped model to MotGenEvDyanamic model.click right button of mouse anywhere on black screen. Select the Variant option to Label Mode Active Choice to click on MotGenEvDynamic as shown below images.
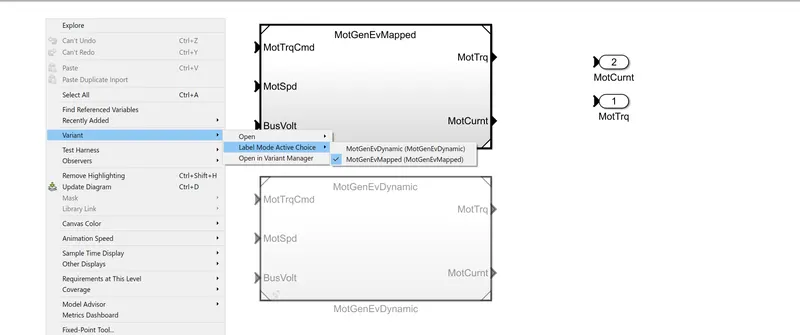
We can change model from mapped to dynamic model as shown below.
Question:- 2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Ans:-
The below shown model for calculate miles per gallon.It is fuel economy rating determined by how far a car travel on a gallon of petrol or diesel engine for powered car. The mileage of the vehicle in terms of miles per gallon. We can the distance measuring shown in Odometer. Fill the tank of fuel upto full and note down it reading.The vehicle travels to desired distance. We have measure the distance between the Initial and Final distance.The amount of fuel energy required to move a engine powered through a distance determine.
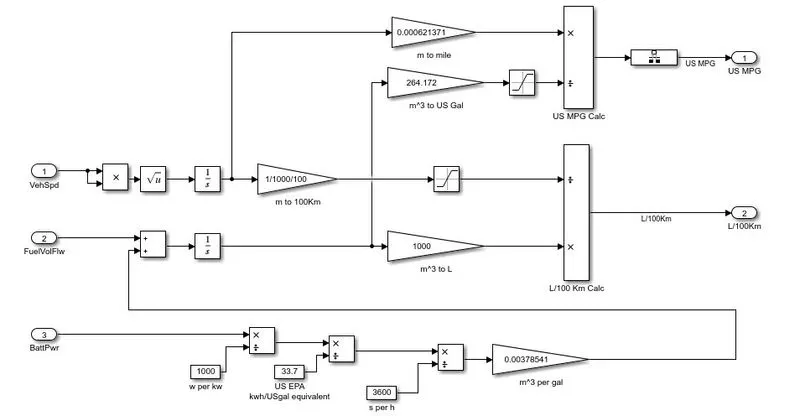
Fig:- The model for Calculation Miles Per Gallons.
Factors influencing the milege of the Vehicle:-
- Battery Power.
- Vehicle Speed.
- Fuel Volume.
Question:- 3) Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
Ans:-
The hybrid electric vehicle reference application represents a full multimode hybrid electric vehicle (HEV) model with an internal combustion engine, transmission, battery, motor, generator, and associated powertrain control algorithms. Use the reference application for powertrain matching analysis and component selection, control and diagnostic algorithm design, and hardware-in-the-loop (HIL) testing. To create and open a working copy of the hybrid electric vehicle reference application project, enter
autoblkHevStart
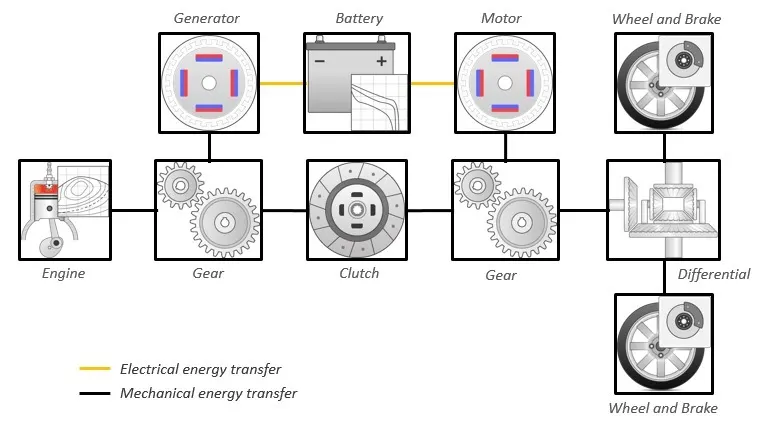
By default, the HEV multimode reference application is configured with:
Mapped motor and generator
1.5–L spark-ignition (SI) dynamic engine
This diagram shows the powertrain configuration.
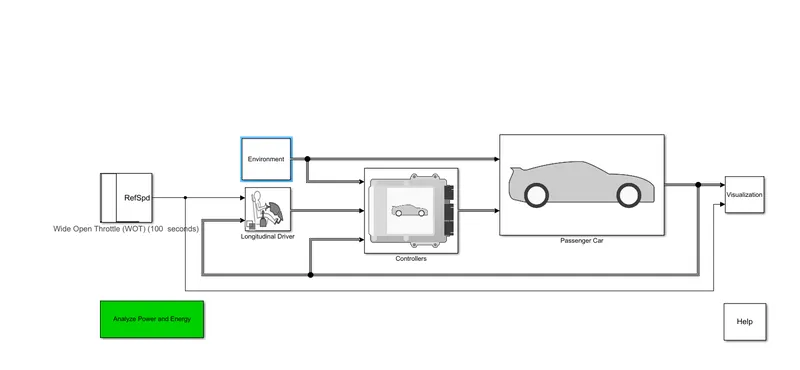
Below shown model For Hybrid Electric Vehicle (HEV):-
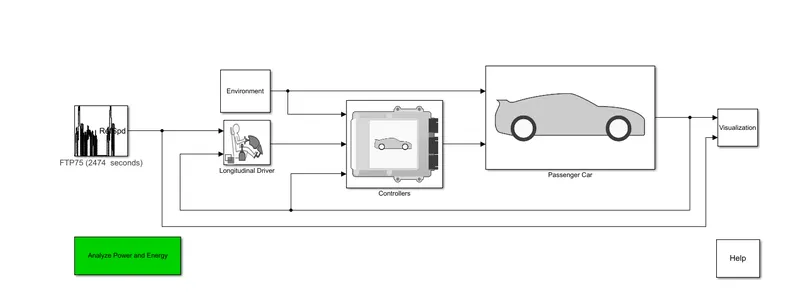
Fig:- The HEV Model and we have not change Drive Cycle Source.
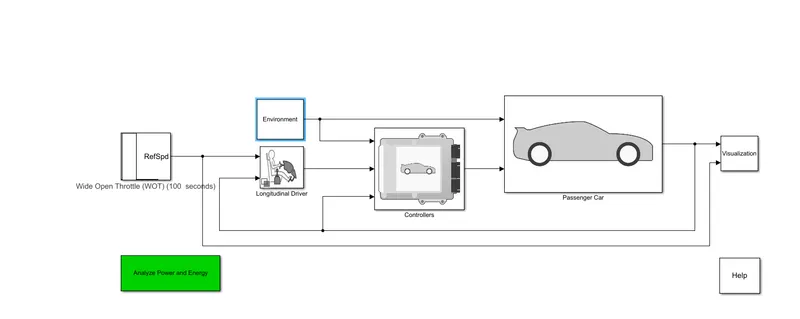
Fig:- The HEV Model and We have change Drive Cycle Source from FTP75 to WOT.
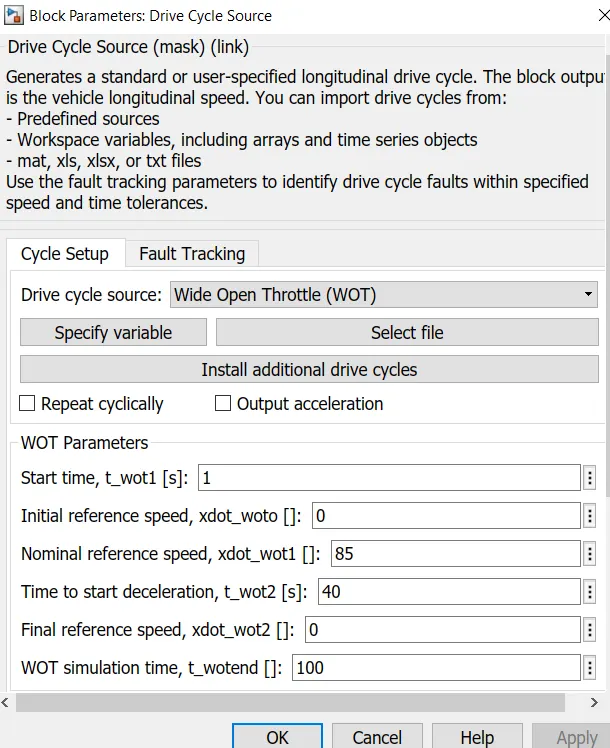
Case:-1] The above in model we have change speed (mph) and Deacceleration value and other parameter keeping same.The simulate above model using WOT. we have change the Drive Cycle Source from FTP75 to Wide Open Throttle (WOT).
Speed = 85 Mph.
Deceleration = 40 Sec.
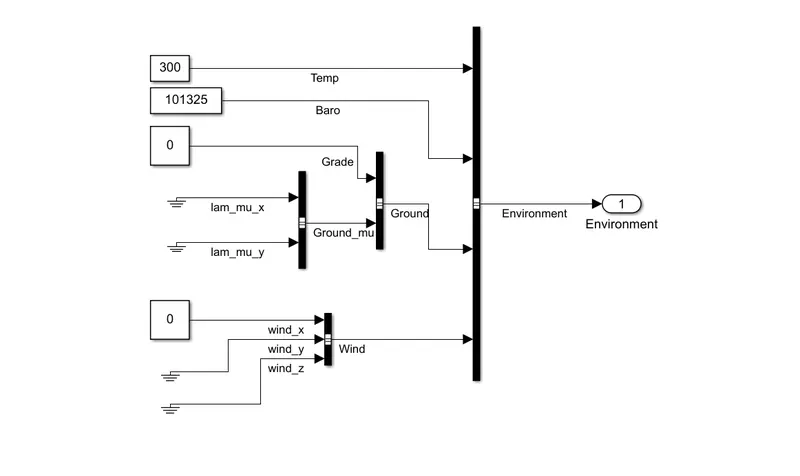
Gradability = 0 Deg.
Wind Velocity = 0 m/s.
The WOT drive cycle using with stop time(t)= 100 Sec.
Output Graph:-
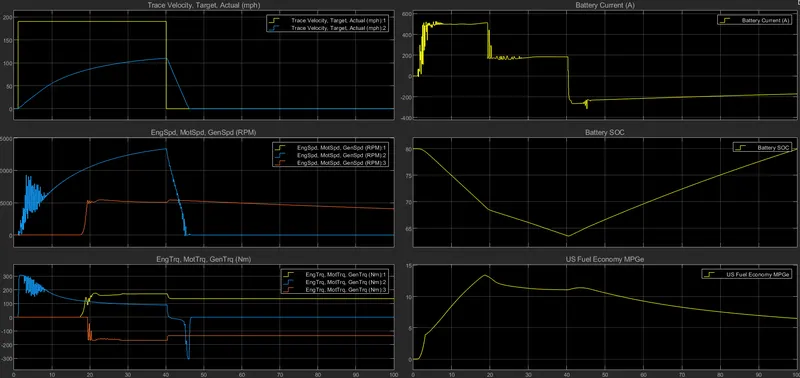
Obervation Result from above Graph:-
In the First plot:- It show the velocity vs drive cycle data Y- Axis on Velocity (mph) and X- Axis on Time (Second). The Vehicle Acceleration time to reach 85 m/h. it give time in 17.72 Sec and The Vehicle Deacceleration time to reach 85 m/h.it give time in 6.52 second.
In The Second plot:- It show the Engine Speed,Motor Speed, Generator Speed (Rpm) vs Time. The Maximum Engine Speed is 4680 rpm. The Maximum Motor Speed is 9992 rpm. The Maximum Engine Speed is 14122 rpm.
In the Third plot:- It show the Motor Torque (Nm) vs time (sec). We can see in this graph the number of ploted graph for Engine Torque,Motor Torque and Generator Torque (N-m). The Maximum Engine Torque is 140 N-m.The Maximum Motor Torque is 210 N-m.The Maximum Generator Torque is 44 N-m.
In the Forth plot:- It show the Battery current (A) Vs Time in Sec.We can see in this graph the firstly the Battery current (A) Fluctuation,The battery Current discharge =168.25 A and The battery Current Charging=-154.23 A.
In the Fift plot:-It show the State of charge (SOP) % vs Time (Sec). We can see in plot the battery State of Charge 80 %. It reducing to 62% in period 48.01 Second and then after increases SOP of Battery.
In the Six plot:- It show the Fuel economy as mile per gallon (MPGe) vs Time (Sec). The maximum mile that the run per gallon of fuel = 7.75 mile.
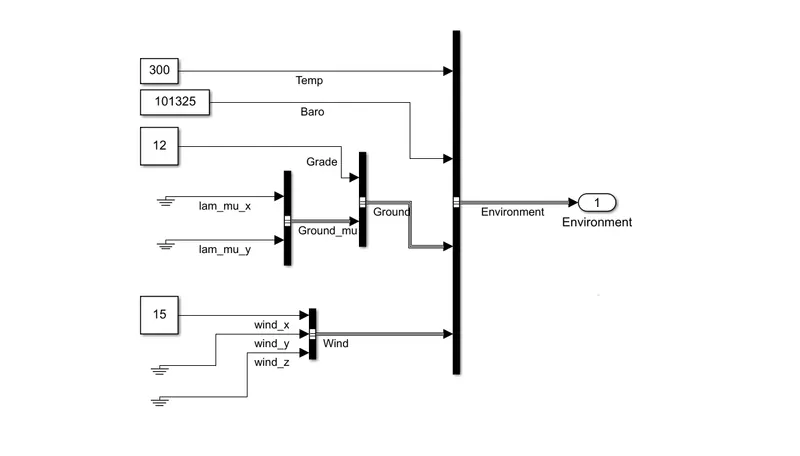
Case:- 2] In this case we have change value of only the grade and wind velocity in the environment block.
Speed = 85 Mph.
Deceleration = 40 Sec.
Gradability = 12 Deg.
Wind Velocity = 15 m/s.
The WOT drive cycle using with stop time(t)= 100 Sec.
The above model shown HEV model. we have click on Environment block and Change the Hill Clambing angle=12 Deg and Wind velocity also change = 15 M/s.
Output Graph:-
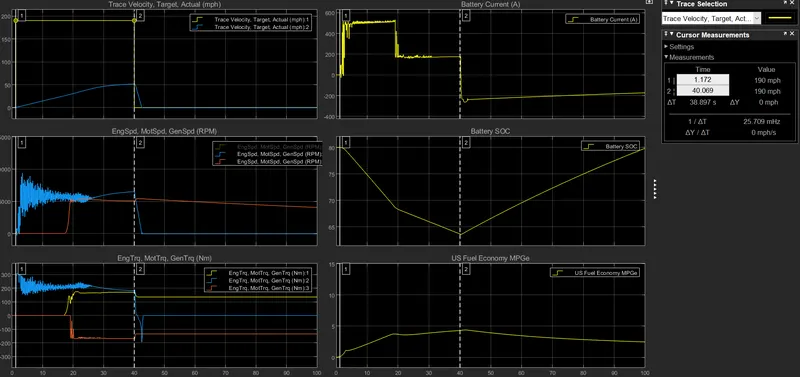
Observation:-
- Above shown in graph we have change Hill Climbing and wind velocity in the Case 2. We can see the in case 1 keeping Hill Climbing angle 0 and Wine velocity 0 m/s. It result is much more efficient comapred to Case 2.
- In the case 2 we can see in graph the fuel Ecomomy (MPGe) reduce in as compared to Case 1.
Question:- 4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
Ans:-
Electric Vehicle Reference Application:-
The Electric Vehicle reference application reprensents a full electric vehicle model with a motor with a motor-Generator,Battery,direct drive trnsmission and associated powertrain control algorithms.Use the electric vehicle reference application for powertrain matching analysis and component selection,control and diagnostic algorithm design and hardware in the loop (HL) testing.Open a working copy of the conventional vehicle reference application project, enter "autoblkEvStart"
The electric vehicle reference appliction is configured with a mapped motor and battery. This diagram showns the powertrain configuration.
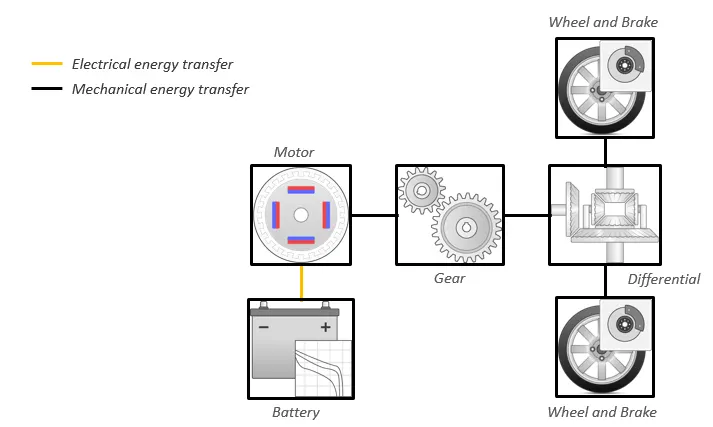
Below figure shown Model of Electric Vehicle:-
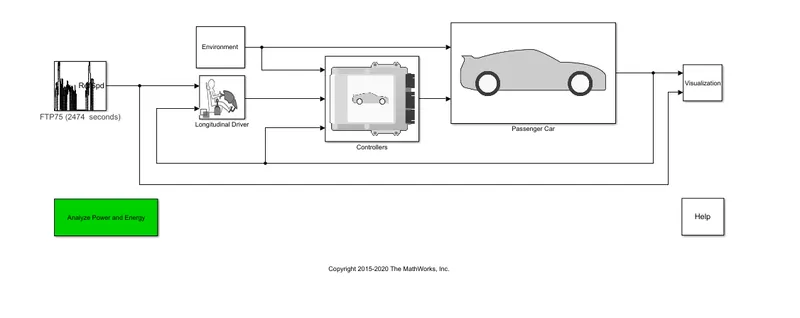
We have keep same data as in case 1 in Hybrid Electric Vehicle(HEV).
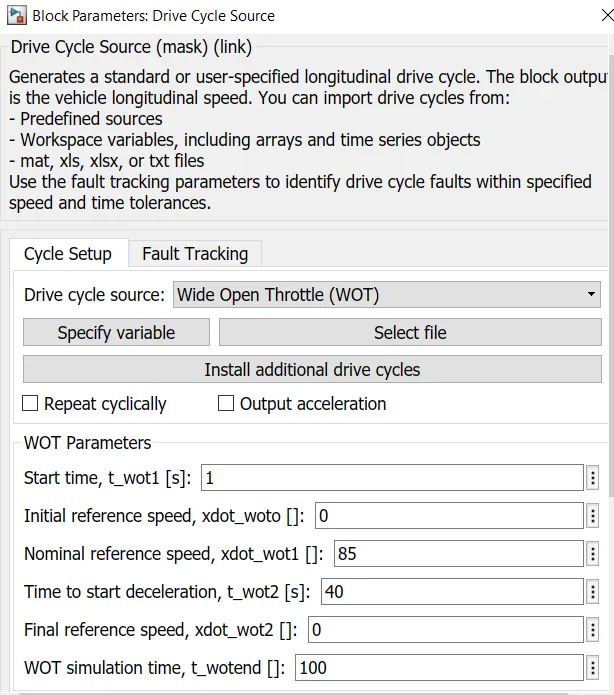
Speed = 85 Mph.
Deceleration = 40 Sec.
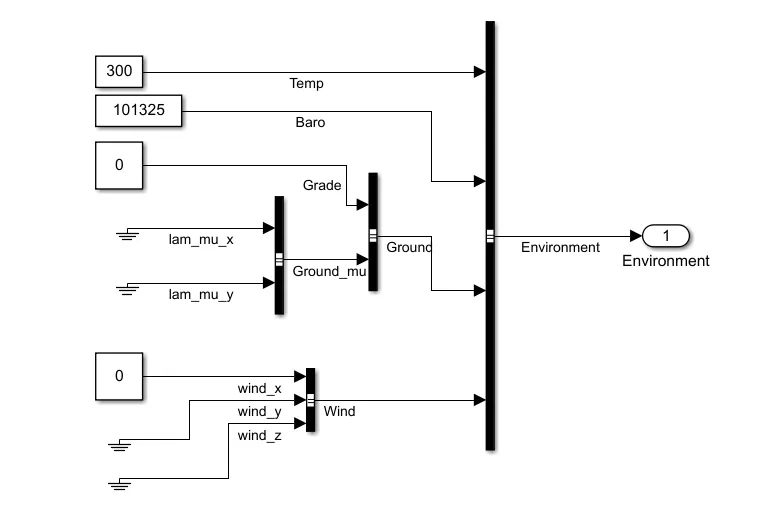
Gradability = 0 Deg.
Wind Velocity = 0 m/s.
The WOT drive cycle using with stop time(t)= 100 Sec.
Ouput Graph:-
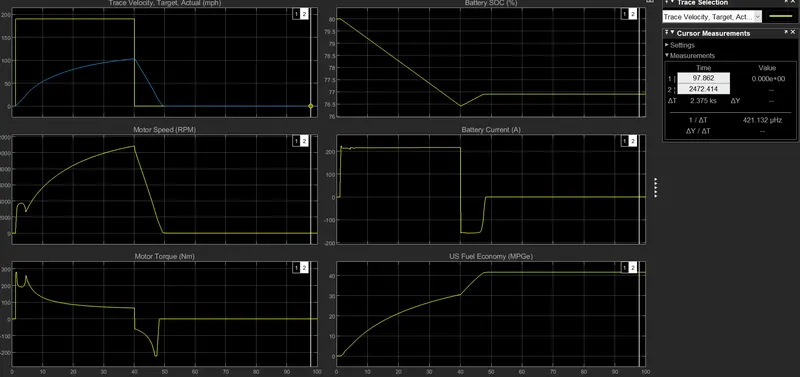
Observation From above Graph:-
In the First plot:- It show the velocity vs drive cycle data Y- Axis on Velocity (mph) and X- Axis on Time (Second). The Vehicle Acceleration time to reach 85 m/h. it give time in 19.146 Sec and The Vehicle Deacceleration time to reach 85 m/h.it give time in 9.931 second.
In The Second plot:- It show the Motor Speed (RPM) vs time Second. the Y-Axis on Speed of motor in Rpm and X-Axis on Time in second. The vehicle speed increases the maximum speed of motor 11250rpm and time to rech motor speed 40 Sec. after Vehicle deaccelectation the speed reducing motor speed to 0 rpm at time 50 second.
In the Third plot:- It show the Motor Torque (Nm) vs time (sec). The maximum motor torque=275 Nm and time to reach torqur for 275 Nm=2 second.
In the forth plot:- It show the State of charge (SOP) % vs Time (Sec).We can see in this graph the SOP decreases from 80% to 75.5 % At a time 40 Second and again Increases 77% and remaining constant.
In the Fift plot:- It show the Battery current (A) Vs Time in Sec. We can see in this plot the Maximum peak value of Battery Current 215 A . the battery current at 215 A the quickly decrease the the vehicle deacceleration the battery current go to Negative value. and again the vehicle accelerating the voltage go to positive value and remain constant.
In the Six plot:- It show the Fuel economy as mile per gallon (MPGe) vs Time (Sec). The maximum mile that the run per gallon of fuel = 22 mile and in for periode 71.25 Sec.
Oservation:-
- In the Hybrid Electric Vehicle have Engine, Motor , Generator and in Electric Vehicle (EV) Battery and Motor. The efficiency of the Electric Vehicle is Higher than compare to HEV.
- Electric produce Zero emission and it high initial cost.
- The Ev produce more value of Motor speed and Motor torque compared to HEV motor speed and motor torque alone the both higher than EV Torque.
- We have uses Battery in Electric Vehicle Litium iron battery comapare to the Nickel metal hybride vehicle battery the discharging capacity and rate of this battery is higher in EV Battery.