Week-4 Challenge WOT Condition Part-2
1) Difference between mapped and dynamic model
Static model is the model of the system not during runtime.They are at equilibrium of in a steady state.
Static or mapped model is basically based on available data of the respective entity. So simulation runs on the available data in form of look up table. It means the mapped simulation will run faster . The simulation results for a combination of data will remain the same all the time.
Dynamic model represnts actual model which runs on real run time data. Simulation time would be greater than the mapped model.
Dynamic model's simulation results will vary all time. In dynamic model each and every smallest component of the model's characterstic are subjected to change because of real time simulation.
The model type can be changed by following steps
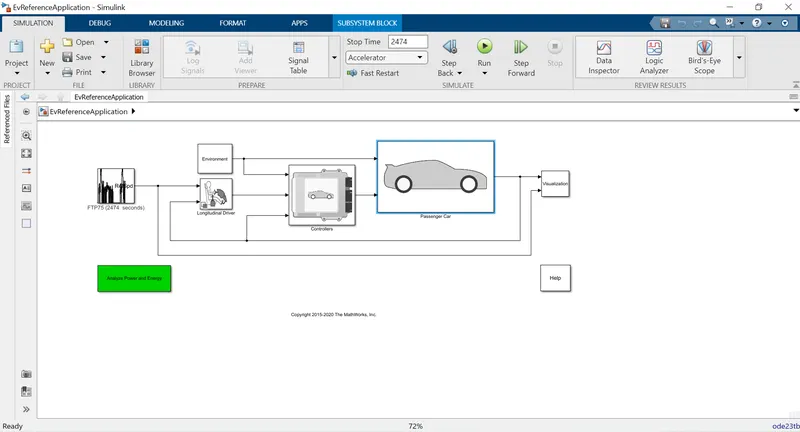
1) From the EV Reference Application select the Passenger Car blockset
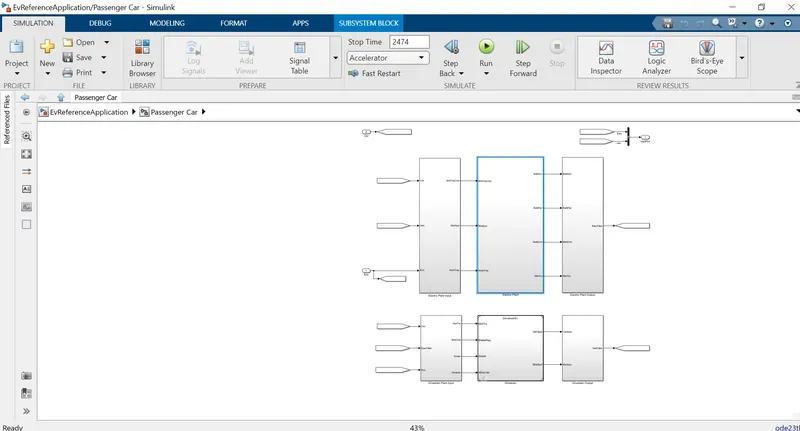
2) Then select the Electric plant blockset
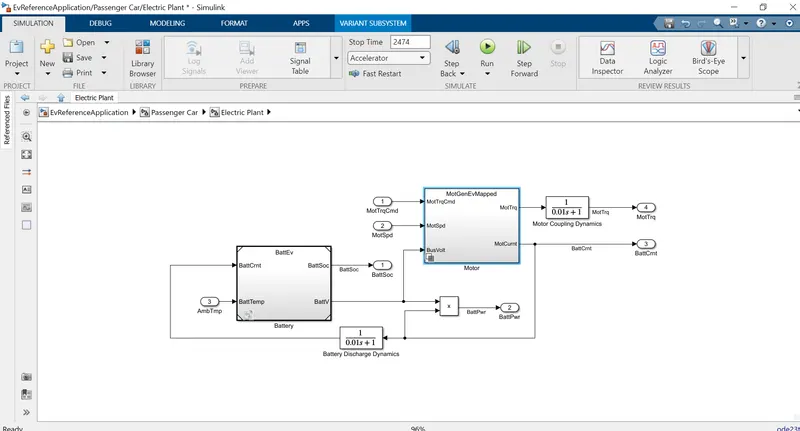
3) Double click thr plant and it will be expanded as shown below
4) Right click on the motor block and select the variant option then select the LabelModeActive Choice and select the dynamic model
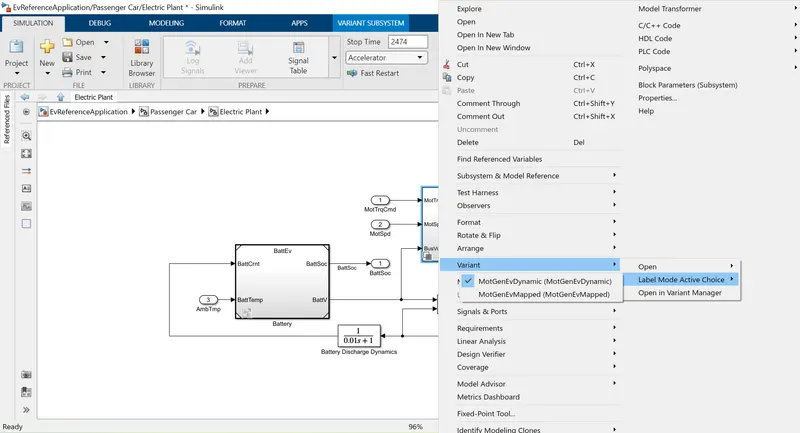
The motor will be a dynamic one
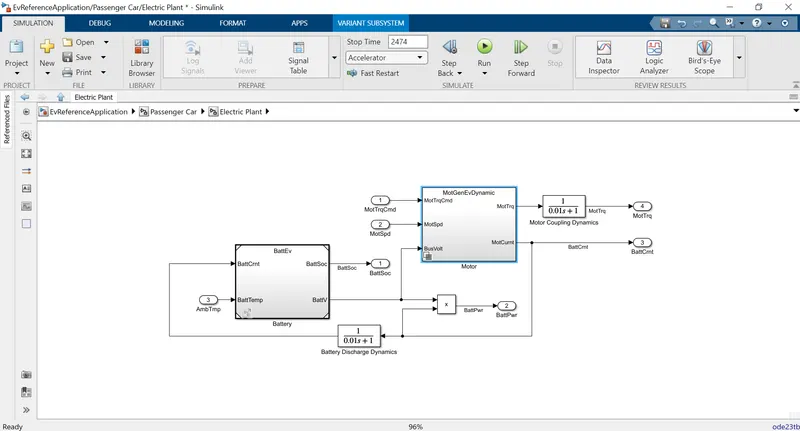
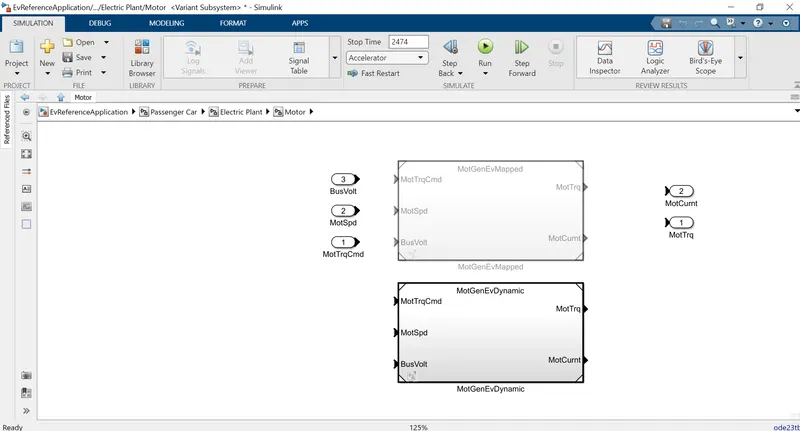
Same process can be applied for generator and engine.
---------------------------------------------------------------------------------------------------------------------------------------
2)
To the get the details of fuel consumption
goto visualisation then select the performance calculation block.
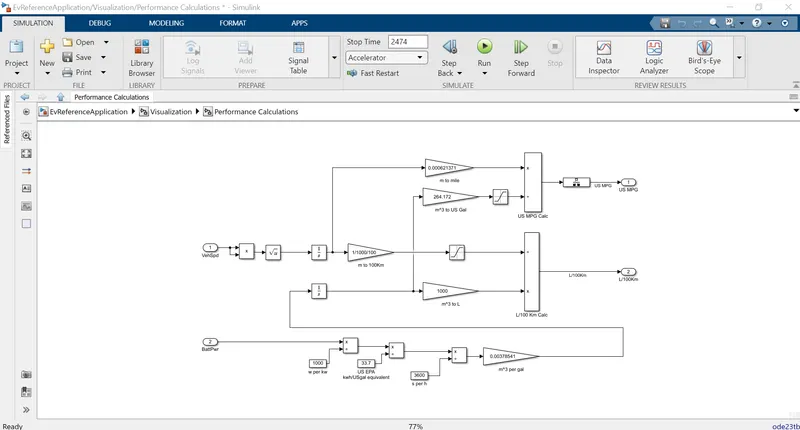
From the block we can see that the fuel calculation depends on
1) Vehicle speed - This input to the performance block is in m/sec^2 which is converted to the distance using an integrator block. This value is then passsed to various gain block for respective conversion to litre, miles and meter.
passed to gain of 0.000621371 for m to mile conversion
2) Battery Power -
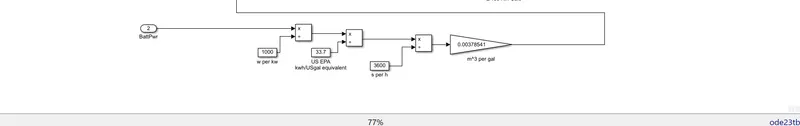
This value of battery power is then passed through various conversion from kWh to gallon m^3 , which is to emphasize the amount of battery power used for propulsion will be proportional to the equivalent amount of fuel used for same distance. This value is then passed to gain of 264.172 for m to US Gallon conversion.
These two values are combined to get the US MPG result.
-----------------------------------------------------------------------------------------------------------------------------
3) HEV ReferenceApplication with WOT drive cycle with hange grade and wind velocity in the environment block.
The demands for more efficient and faster car are always a priority for the marketing strategy. The importance of aerodynamics and grade to a Hybrid Electric Vehicle (HEV) is the determination of drag estimation to know the car’s performance on the road against air resistance and hill force. It can be used to improve stability, noise and fuel consumption.
More than half of the energy required to move a car traveling at highway speeds is spent on aerodynamic drag.
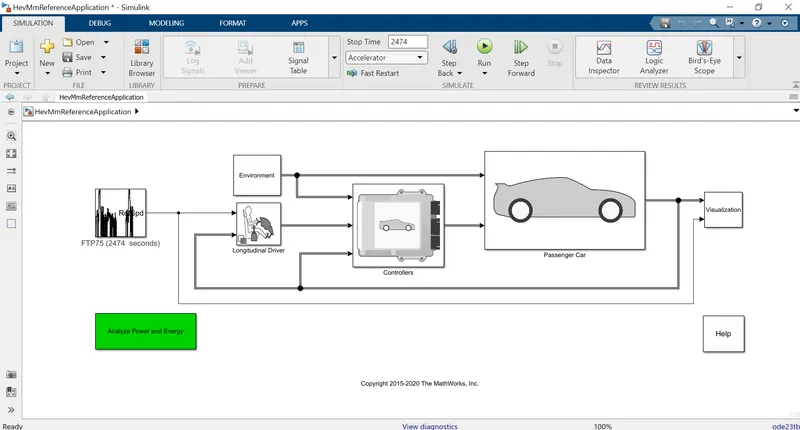
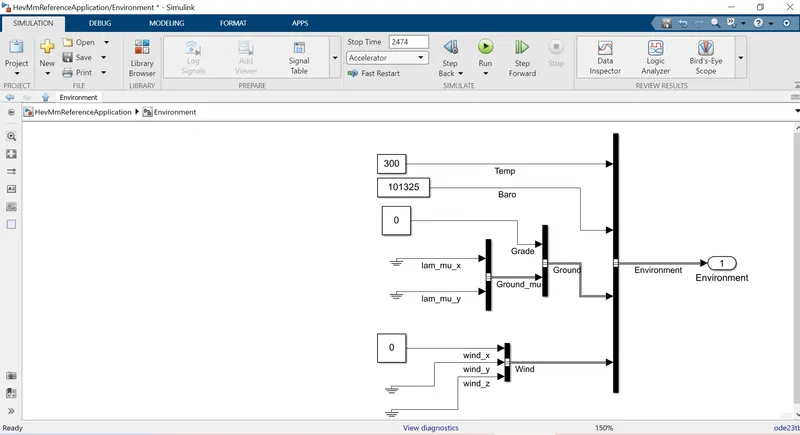
Here the values of grade and wind velocity is changed and the variations is observed
CASE 1) GRADE - 0 & WIND - 0
After runing the simulation the performance obtained is
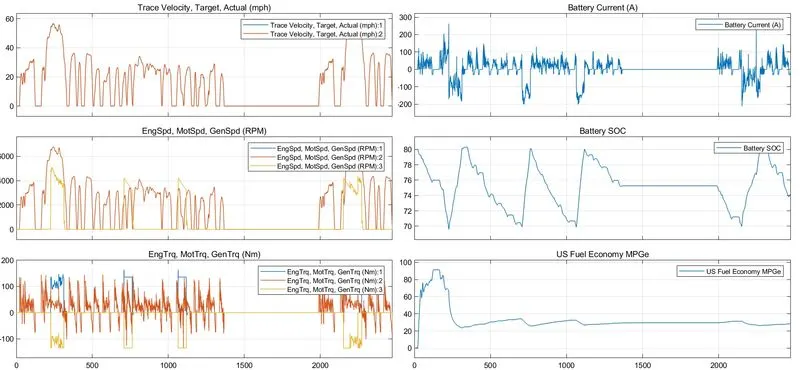
it can be deduced that with the above mentioned conditions
Fuel economy is having an average value of 30 - 35 MPGe
Battery SOC is oscillating between value of 80-70
CASE 2) GRADE - 5 & WIND -30
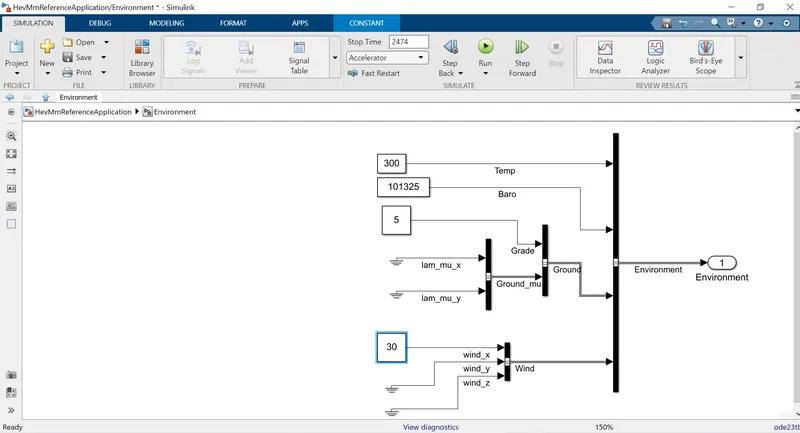
After runing the simulation the performance obtained is
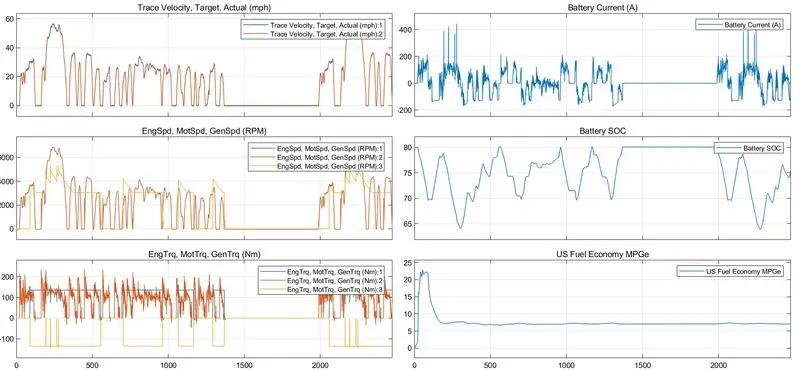
it can be deduced that with the above mentioned conditions
Fuel economy is having an average value of 8-6 MPGe which ghas also dropped from 30 -35
Battery SOC is oscillating between value of 80-65 .SO THE LOWER VALUE OF SOC HAS DROPPED TO 65 IN COMPARISON TO 70 IN THE PREVIOUS CASE.
CASE 3) - GRADE - 10 & WIND -70
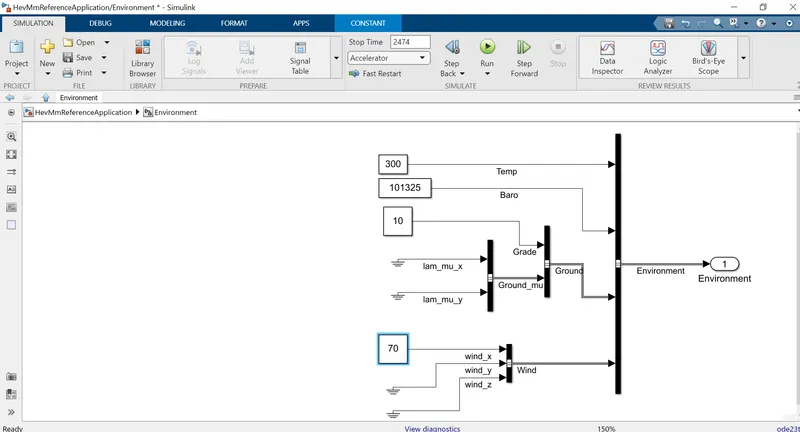
After runing the simulation the performance obtained is
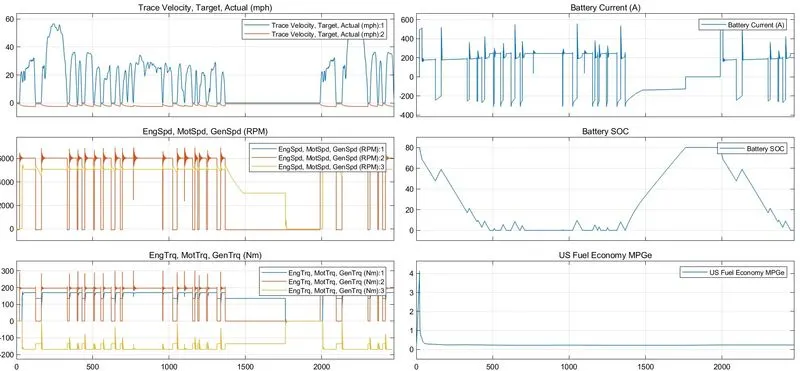
it can be deduced that with the above mentioned conditions
Fuel economy is having an average value BELOW 1 MPGe
Battery SOC is oscillating between value of 80-0 .
ALSO THE ENGINE,MOTOR,GENERATOR IN RPM IS AT 6000 RPM FOR MOST OF THE TIME.ALSO TE TORQUE PRODUCED IS AT 200Nm
SO IT CAN BE infered that with increase in wind speed the fuel consumption (both gasoline and battery ) is increasing.
------------------------------------------------------------------------------------------------------------------------------
4) comparing the simulated results of hybrid and pure electric powertrains.
SIMULATION MODEL FOR HEV
SIMULATION MODEL FOR EV
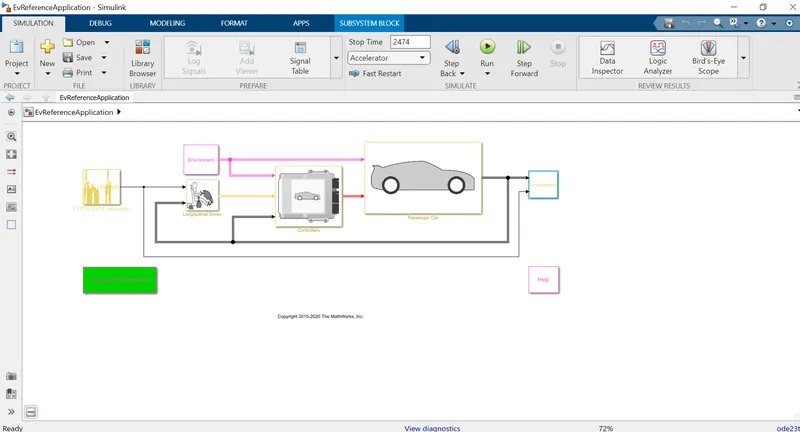
CASE 1) GRADE - 0 & WIND - 0
After runing the simulation the performance obtained is F
CASE 1A) FOR HYBRID VEHICLE
CASE 1B) FOR ELECTRIC VEHICLE
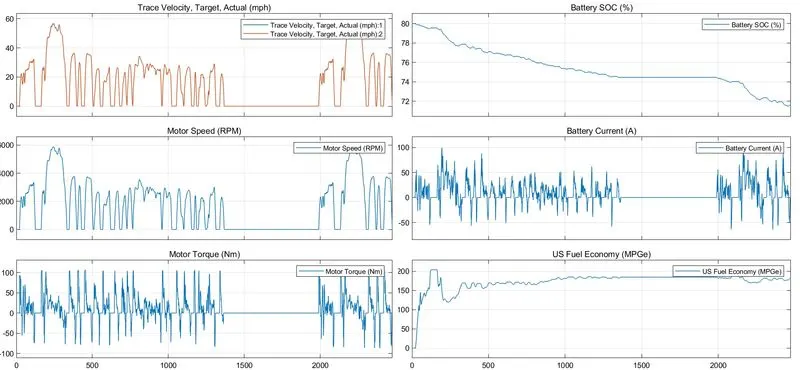
it can be deduced that with the above mentioned conditions
Fuel economy - A) HEV is having an average value of 30 - 35 MPGe
B) EV is having an average value of 150 - 200 MPGe
Battery SOC - A) HEV is oscillating between value of 80-70
B)IN case of EV its discharging from 80 to 70 during the same simulation time
CASE 2) GRADE - 5 & WIND -30
After runing the simulation the performance obtained is F
CASE 2A) FOR HYBRID VEHICLE
CASE 2B) FOR ELECTRIC VEHICLE
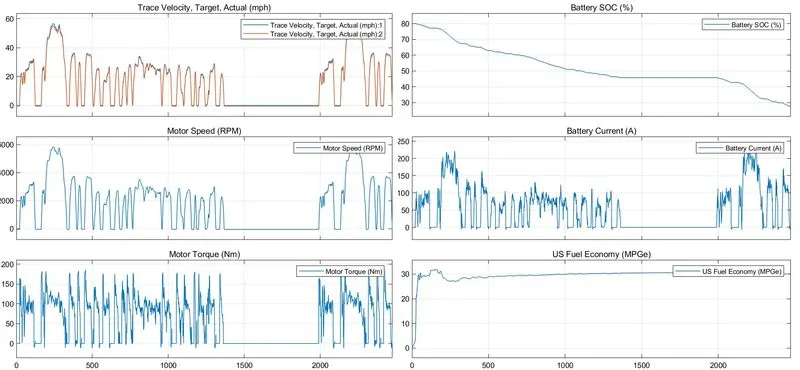
it can be deduced that with the above mentioned conditions
Fuel economy - A) HEV is having an average value of 8-6 MPGe MPGe
B) EV is having an average value of 31 - 30 MPGe
Battery SOC - A) HEV is oscillating between value of 80-65
B)IN case of EV its discharging from 80 to 25 during the same simulation time
CASE 3) - GRADE - 10 & WIND -70
After runing the simulation the performance obtained is F
CASE 3A) FOR HYBRID VEHICLE
CASE 3B) FOR EV
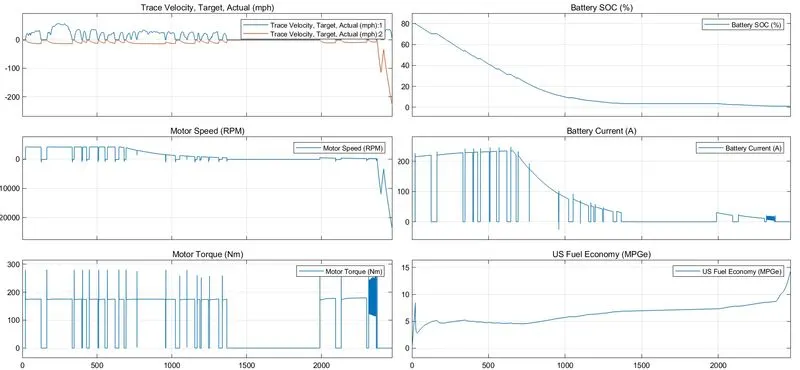
it can be deduced that with the above mentioned conditions
Fuel economy - A) HEV is having an average value BELOW 1 MPGe
B) EV is having an average value of 5-8 MPGe
Battery SOC - A) HEV is oscillating between value of 80-0
B)IN case of EV Battery has discharged close to a value of 0 by 1600 run time
SO IT CAN BE infered that with increase in wind speed the fuel consumption (both gasoline and battery ) is increasing.