Project - Position control of mass spring damper system
AIM: Obtain the transfer function of a mass spring damper system witha PID controller for following parameters;
mass=3.6kg; k=400N/m; c=100Ns/m
CODE:
%Parameters
k=400;%(given, in N/m)
%c=2*zeta*wn*m
c=100;%(given, in Ns/m)
m=3.6;%(Kg)
wn=10.54;
zeta=(c*0.5)/((m*k)^(1/2));
G=tf([400],[1,100,111.5]);
pzmap(G)
grid on
[p,z]=pzmap(G)
A=[0,1;111.11,27.77];
B=[0;0.278];
p1=-zeta*wn+wn*sqrt(zeta^2-1);
p2=-zeta*wn-wn*sqrt(zeta^2-1);
P=[p1;p2];
K=place(A,B,P);
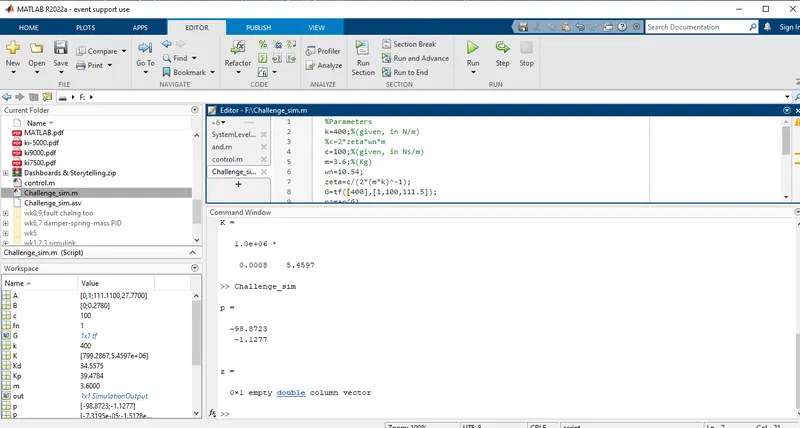
POLES & K:
Zeta value:
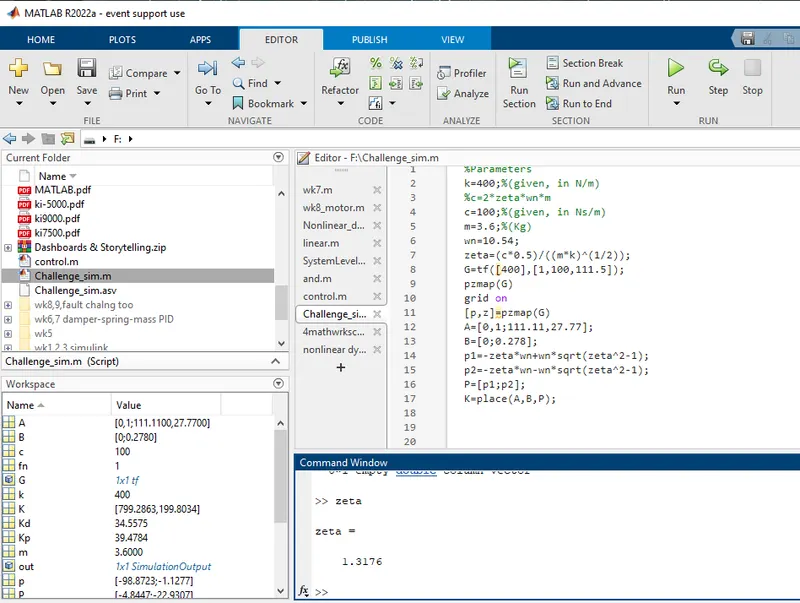
As zeta>1 that implies it is a critically damped condition.
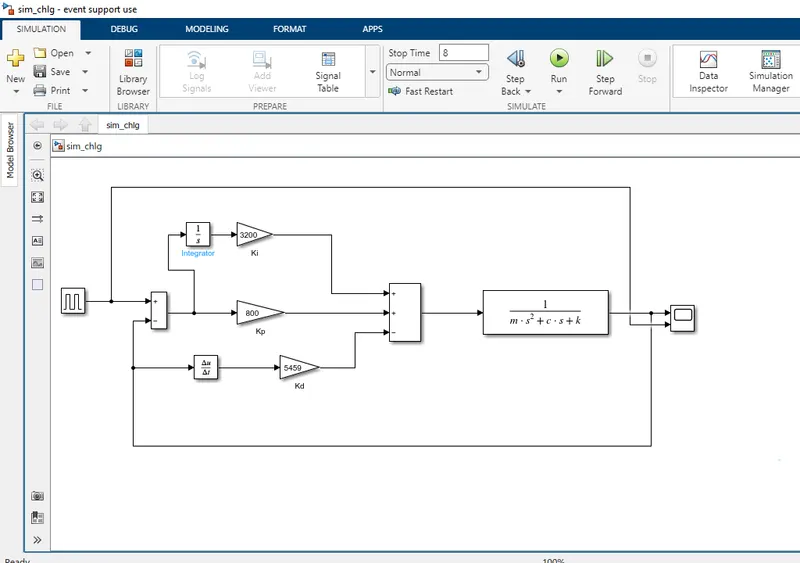
Model:
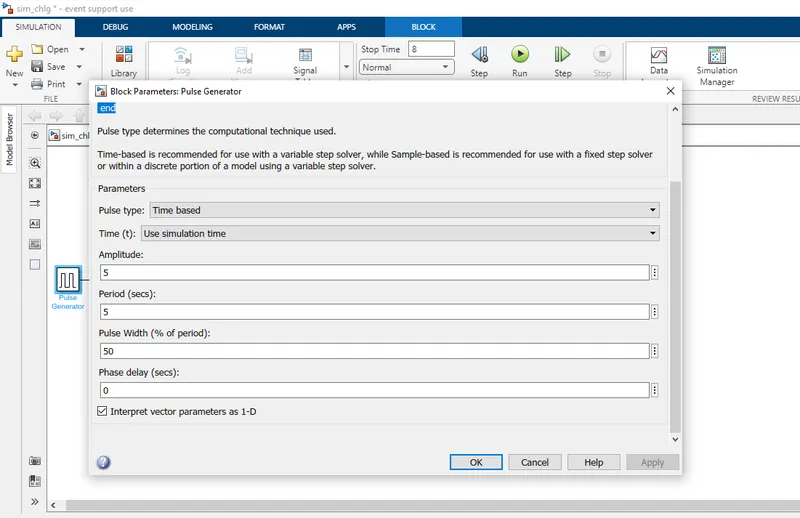
Input For Reference- A pulse generator withfollowing conditions:
Output w.r.t the reference signal:
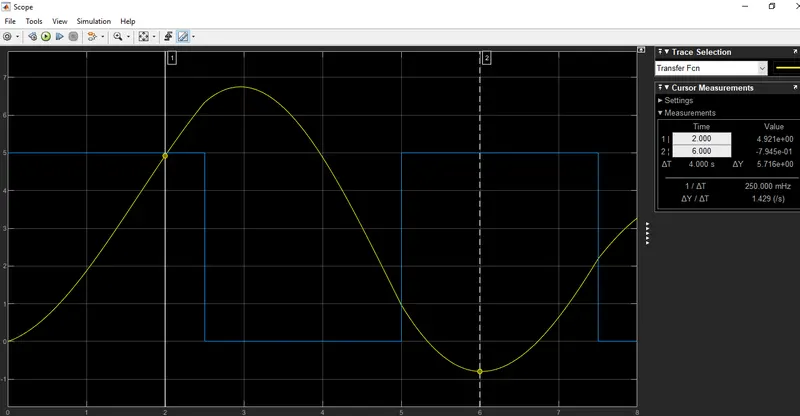
As we can see it is overdamped w.r.t the reference signal position.