Project 2 - Measuring distance of an object using ultrasonic sensor (HC-SR04)
PROJECT-2:
Aim: To write a program to measure the distance using ultasonic sensot
Schematic Diagram:
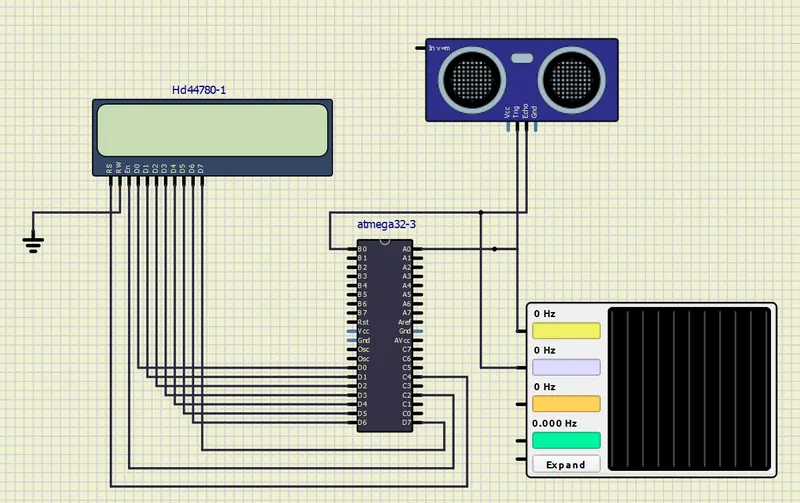
Steps of Programming
- ATmega16 microcontroller needs to transmit at least 10 us trigger pulse to the HC-SR04 Trig Pin.
- After getting a trigger pulse, HC-SR04 automatically sends eight 40 kHz sound waves and the microcontroller waits for rising edge output at the Echo pin.
- When the rising edge capture occurs at the Echo pin which is connected to an input of ATmega16, start Timer of ATmega16 and again wait for a falling edge on the Echo pin.
- As soon as the falling edge is captured at the Echo pin, the microcontroller reads the count of the Timer. This time count is used to calculate the distance to an object.
Calculation (distance in cm) (H1)
Sound velocity = 343.00 m/s = 34300 cm/s
The distance of Object (in cm) = Sound velocity *Timer/2
= 32300*Timer/2
= 17150*Timer
Now, here we have selected an internal 8 MHz oscillator frequency for ATmega16, with No-presale for timer frequency. Then time to execute 1 instruction is 0.125 us.
So, the timer gets incremented after 0.125 us time elapse.
= 17150 x (TIMER value) x 0.125 x 10^-6 cm
= 0.125 x (TIMER value)/58.30 cm
= (TIMER value) / 466.47 cm
Code:
/*
 * Project2_ultrasonic.c
 *
 * Created: 24-06-2023 08:13:41
 * Author : chand
 */

#include <avr/io.h>
#define F_CPU 16000000ul
#include <util/delay.h>
#include <avr/interrupt.h>
#include <string.h>
#include <stdlib.h>


#define lcd_data_dir DDRD
#define lcd_command_dir DDRC
#define lcd_data_port PORTD
#define lcd_command_port PORTC
#define EN PC2
#define RW PC3
#define RS PC4

void lcd_command(char);
void lcd_char(char);
void lcd_init(void);
void lcd_string(char*);
void lcd_string_xy (char,char,char*);

void lcd_command (char cmd)
{
	lcd_data_port = cmd;
	lcd_command_port&=~((1<<RS)|(1<<RW));
	lcd_command_port|= (1<<EN);
	_delay_ms(1);
	lcd_command_port&=~(1<<EN);
	_delay_ms(2);

}
void lcd_char(char char_data)
{
	lcd_data_port= char_data;
	lcd_command_port&=~(1<<RW);
	lcd_command_port|=((1<<EN)|(1<<RS));
	_delay_ms(1);
	lcd_command_port&=~(1<<EN);
	_delay_ms(1);
}
void lcd_init(void)
{
	lcd_command_dir|= (1<<RS)|(1<<RW)|(1<<EN);
	lcd_data_dir = 0xff;

	_delay_ms(20);
	lcd_command(0x38);
	lcd_command(0x0C);
	lcd_command(0x06);
	lcd_command(0x01);
	lcd_command(0x80);
}
void lcd_string(char *str)
{
int i;
for(i=0;str[i]!=0;i++)
{
	lcd_char (str[i]);
}

}
void lcd_string_xy(char row,char pos,char *str)
{
	if (row == 1)
	lcd_command((pos & 0x0f)|0x80);
	else if (row == 2)
	lcd_command((pos & 0x0f)|(0xC0));
	lcd_string(str);
}
#define trigger_pin PA0
int TimerOverFlow = 0;
ISR(TIMER1_OVF_vect)
{
	TimerOverFlow++;
}
int main (void)
{
	char string[10];
	long count;
	double distance;

	DDRA = 0x01;
	PORTB = 0xff;

	lcd_init();
	lcd_string_xy(1,0,"ultrasonic");

	sei();
	TIMSK = (1<< TOIE1);
	TCCR1A = 0;

	while(1)
	{
		PORTA |= (1<< trigger_pin);
		_delay_ms(10);
		PORTA &=(~(1<< trigger_pin));

		TCNT1 = 0;
		TCCR1B = 0x41;
		TIFR = 1<<ICF1;
		TIFR = 1<<TOV1;


		while ((TIFR & (1<<ICF1)) == 0);
		TCNT1 = 0;
		TCCR1B = 0x01;
		TIFR = 1<<ICF1;
		TIFR = 1<<TOV1;
		TimerOverFlow = 0;

		while ((TIFR & (1<< ICF1))== 0);
		count = ICR1 +(65535 * TimerOverFlow);
		distance = (double)count/466.47;

		dtostrf(distance,2,2,string);
		strcat(string,"cm");
		lcd_string_xy(2,0,"dist= ");
		lcd_string_xy(2,7,string);
		_delay_ms(200);
	}
}
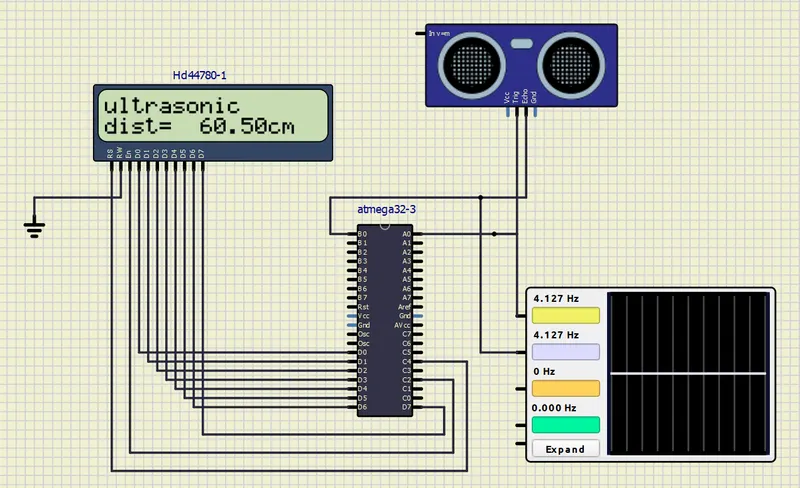
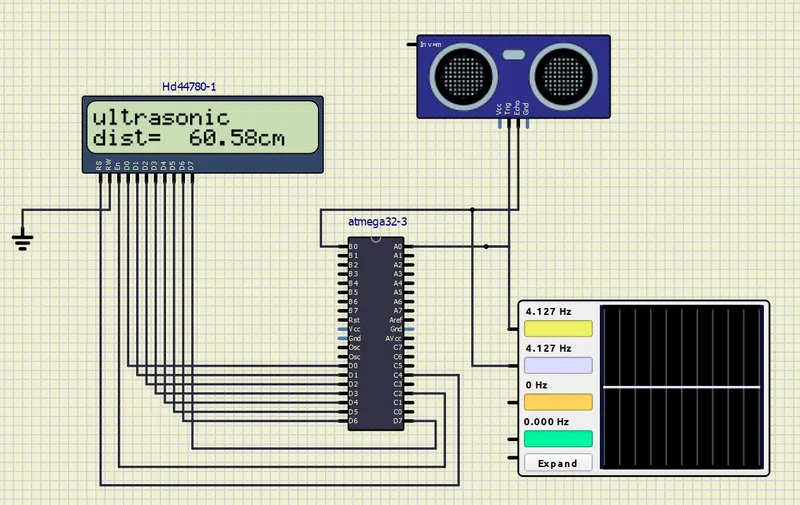
Output:
-----------------------------------------------********************-----------------------------------------------