Final Project: Design of an Electric Vehicle
AIM:
Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
Objectives:
1. System level configurations
2. Model parameters
3. Results
4. Conclusion
BLOCK DIAGRAM:
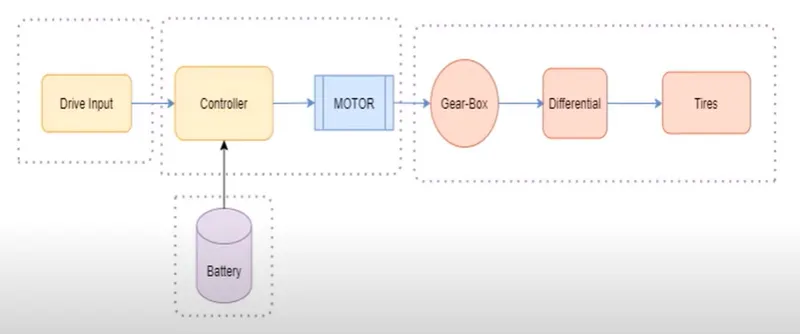
the model of electric vehicle is divided into four parts
1) vehicle body- in vehicle body we have gear box, tires, differential.
2) motor and controller part- we will use simple dc motor and H bridge controller.
3)drive input- we will create input by inbuilt drive cycle or by using signal builder block
4) battery
from the model we see that the drive input will provide driving cycle . the battery is connected to the motor through controller. if the battery is directly connected to motor , then controlling of speed is not possible.
the mechanical energy from dc motor is given to vehicle body so that the vehicle will perform accordingly.
MODEL:
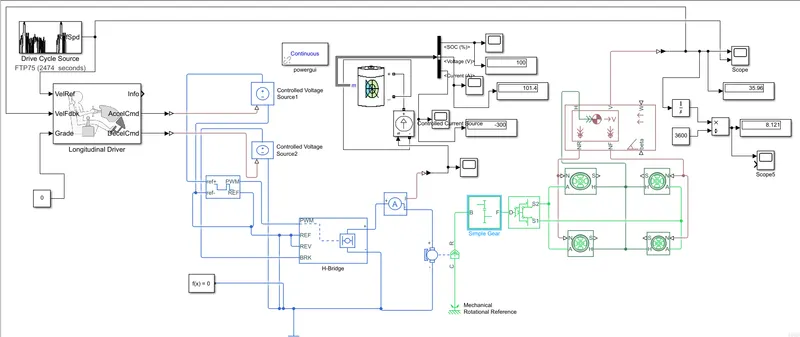
BLOCKS USED IN MODEL:
1) VEHICLE BODY
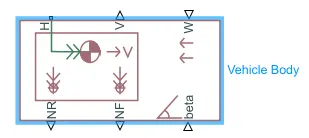
vehicle body have 6 ports.
V-actual sped of vehicle
w-wind velocity
beta- inclination of road
NF-normal force for front wheel
NR- normal force for rear wheel.
H-horizontal motion
2) TIRE:

The Tire (Friction Parameterized) block models a tire with friction parameterized in terms of static and kinetic coefficients. The static friction coefficient determines the applied torque at which the tire loses traction and begins to slip. The kinetic friction coefficient determines the amount of torque that the tire transmits to the pavement once it begins to slip. The tire regains traction once its relative velocity over the pavement falls below the traction velocity tolerance specified.
To increase the fidelity of the tire model, the block enables you to specify properties such as tire compliance, inertia, and rolling resistance
input ports is
N-normal force
output port is
S-slip
conserving port are
1)A-axle
2)H-hub
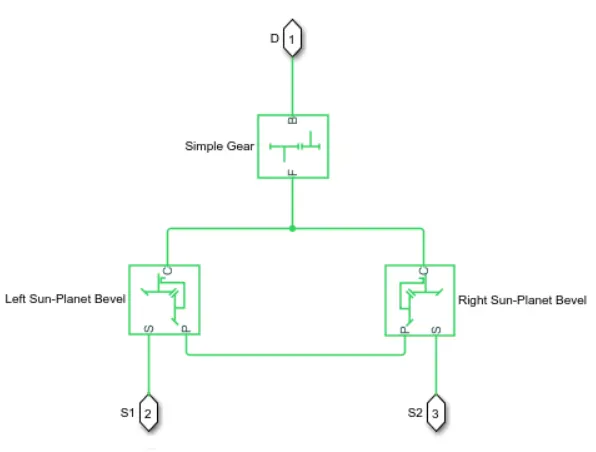
3) DIFFERENTIAL:
by diffrential block ,we can add inertia and losses of gear machine and viscous gear friction.

The Differential block represents a gear mechanism that allows the driven shafts to spin at different speeds. Differentials are common in automobiles, where they enable the various wheels to spin at different speeds while cornering. Ports D, S1, and S2 represent the longitudinal driving and the sun driven gear shafts of the differential.
the equivalent circuit for the block.


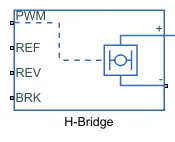
The H-Bridge block represents an H-bridge motor driver. The block has the following two Simulation mode options:
1)The H-Bridge block output is a controlled voltage that depends on the input signal at the PWM port. If the input signal has a value greater than the Enable threshold voltage parameter value, the H-Bridge block output is on and has a value equal to the value of the Output voltage amplitude parameter. If it has a value less than the Enable threshold voltage parameter value, the block maintains the load circuit using one of the following three Freewheeling mode options:
-
via one semiconductor switch and one freewheeling diode
-
via two freewheeling diode
- via two semiconductor switch and one freewheeling diode
The first and third options are sometimes referred to as synchronous operation.
2)The signal at the REV port determines the polarity of the output. If the value of the signal at the REV port is less than the value of the Reverse threshold voltage parameter, the output has positive polarity; otherwise, it has negative polarity.Electrical conserving port associated with the voltage that controls when to reverse the polarity of the H-Bridge block output. The voltage is defined relative to the REF port.
3)BRK PORT- Electrical conserving port associated with the voltage that controls when to short circuit the H-Bridge block output. The voltage is defined relative to the REF port.
by the help of h bridge we can perform accleration , braking and reverse mechanism.
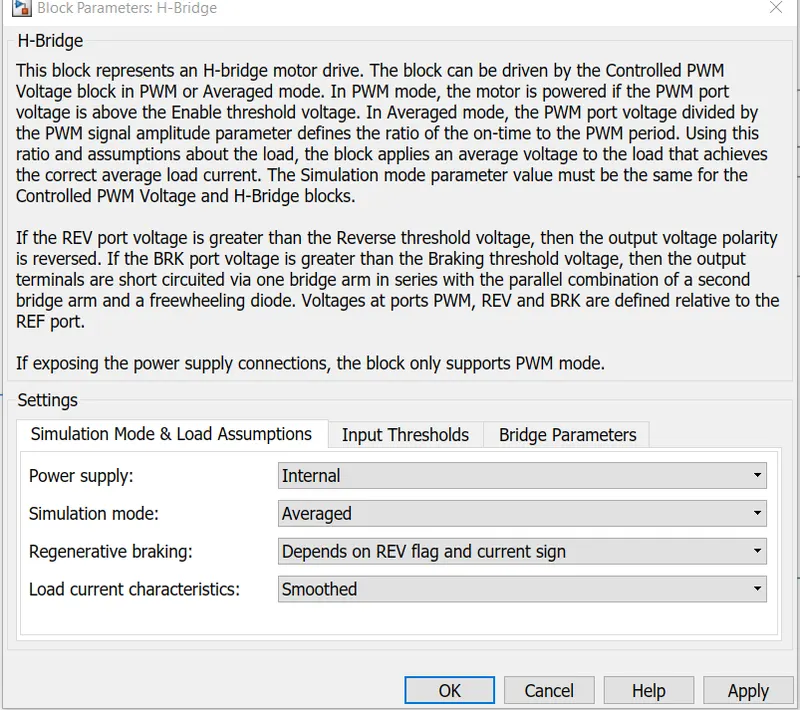
change simulation mode to average , this will reduce simulation time
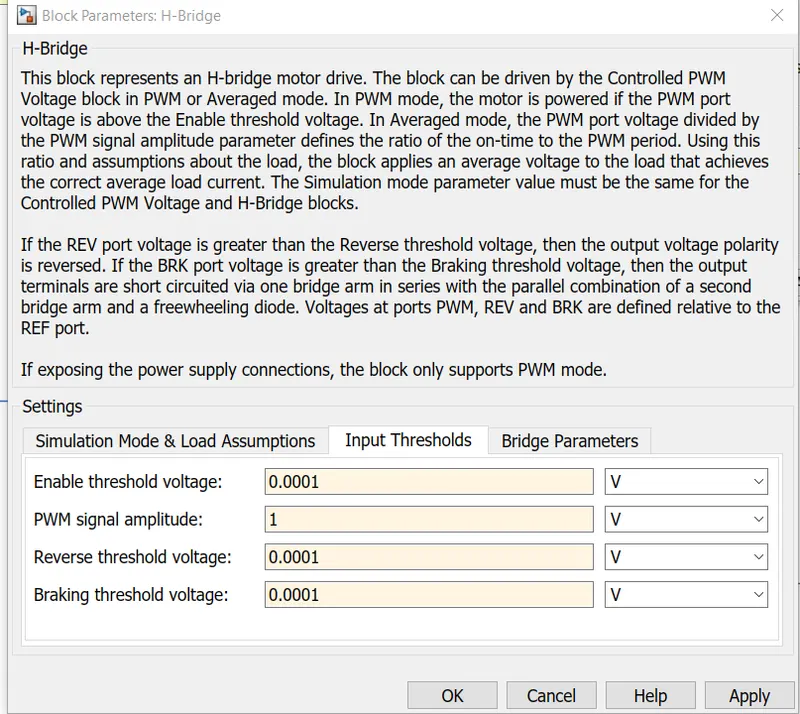
now change the input thresholds value as shown .
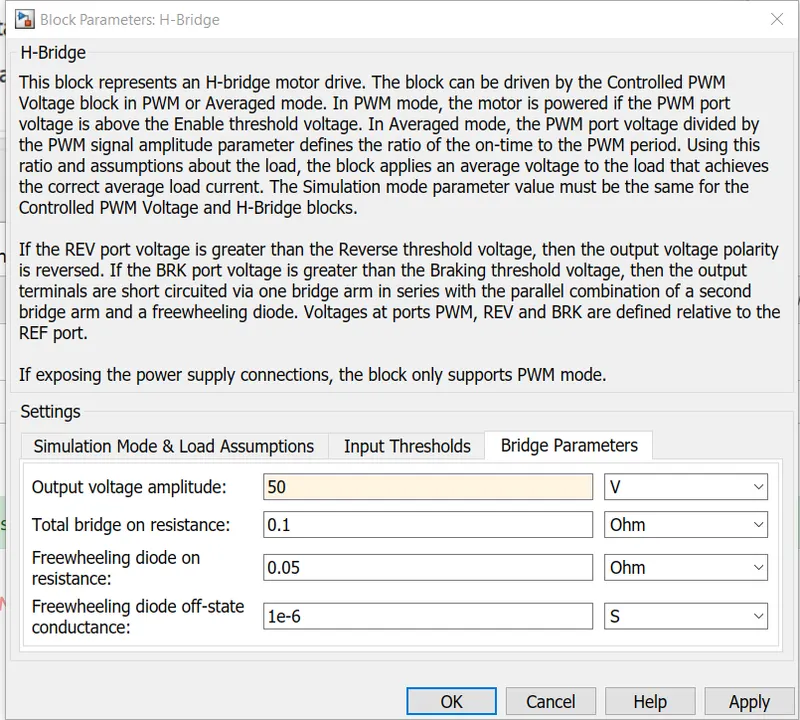
in bridge parameters , change the output voltage amplitude to 50 volts.
8) CONTROLLED PWM VOLTAGE:
to control PWm input we use controlled pwm voltage.
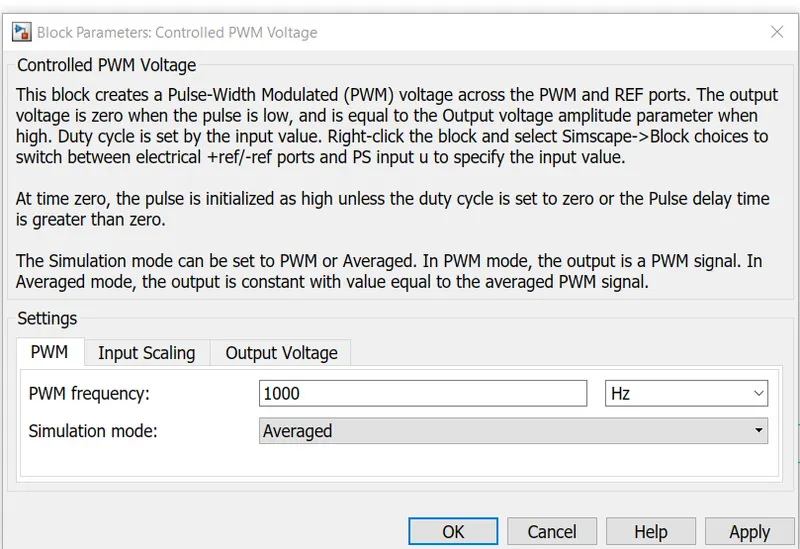
change simulation mode to averaged .
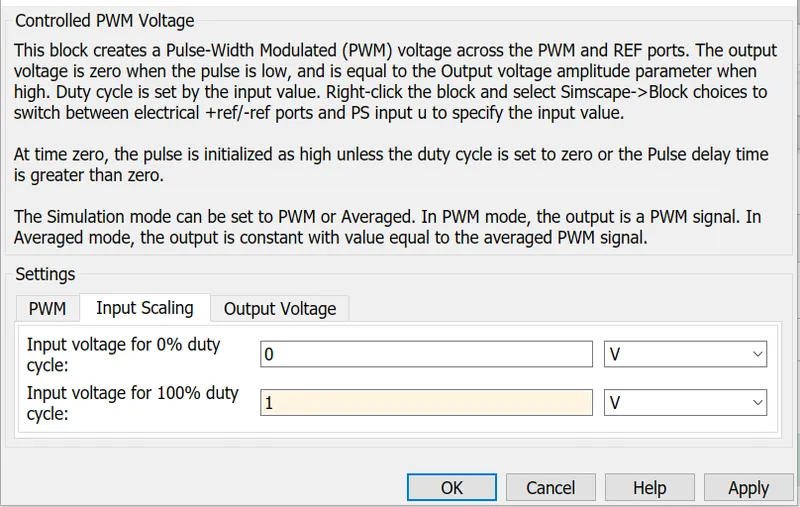
in input scaling , make lower value to zero and higher value to 1.
this done because driver will give signals in format of 0 and 1.
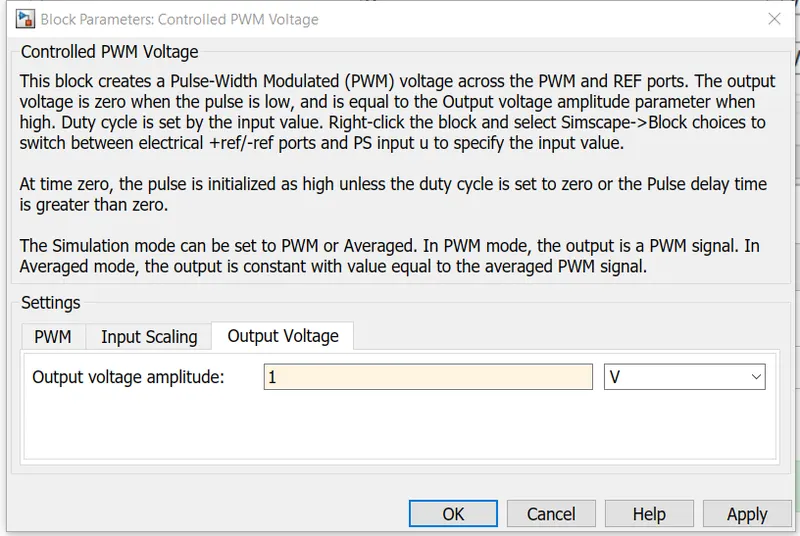
also make output voltage amplitude to 1.
the controlled pwm voltage block will get input from driver and driver will provide input in terms of 0 and 1 .thus we have choosen 0 and 1 as low and high value respectively.
9) ELECTRICAL REFERENCE:

all the references are connected to electrical reference .also connect solver confugration to ground.
10) LONGITUDINAL DRIVER:
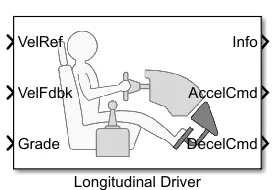
The Longitudinal Driver block implements a longitudinal speed-tracking controller. Based on reference and feedback velocities, the block generates normalized acceleration and braking commands that can vary from 0 through 1. You can use the block to model the dynamic response of a driver or to generate the commands necessary to track a longitudinal drive cycle.
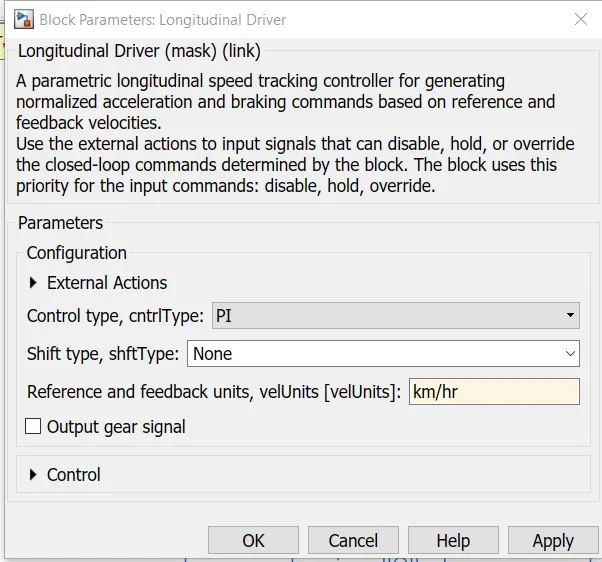
by double clicking on longitudinal driver block , change the reference and feedback units to km/hr.
here we will provide reference signal by inbuilt drive cycle or by creating our own signal by the help of signal builder block.
we will connect actual speed of vehicle to the port velocity feedback.
the grade port is connected to constant value let be 0.
we will get acceleration command from accel command
and deacceleration command from decel command.
11) SIMULINK TO PS CONVERTER:

this block is used to convert simulink signal to physical signal.
12) CONTROLLED VOLTAGE SOURCE
this block is used to provide constant voltage throughout the circuit.
13) BATTERY
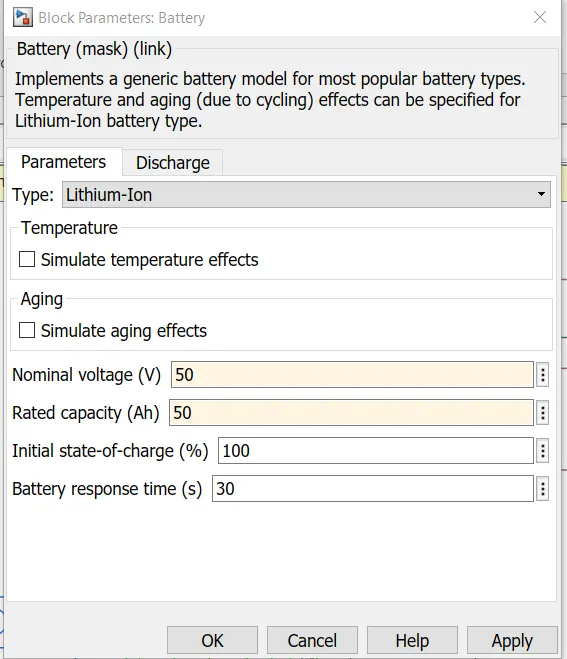
The lithum ion battery is taken in model. the nominal voltage selected is 50 volts .
14)BUS SELECTOR
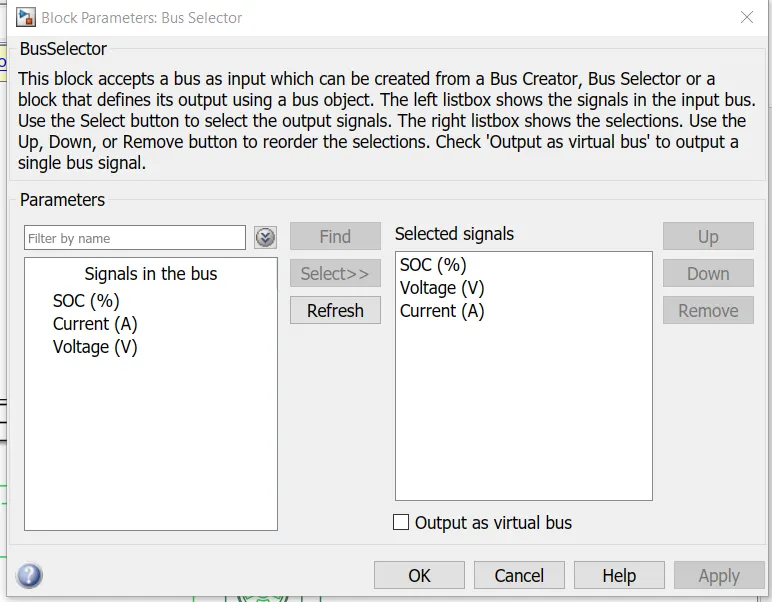
In bus selector, we have taken signal SOC , voltage and current.
15) CONTROLLED CURRENT SOURCE:

a controlled current source is connected to the lithium battery. this controlled current source will initiate the flow of current from battery to motor and during regenerative barking from motor to battery.
16) DRIVE CYCLE SOURCE:
a default FTP75 drive cycle source is connected in model.
17) TO MEASURE DISTANCE TRAVELLED BY ELECTRIC VEHICLE:
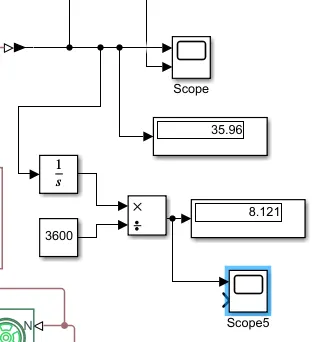
The scope will display velocity of vehicle in km/hr.
to measure the distance in km, an intergator block is used beacuse intergartion of velocity will give us distance.
and 3600 constant block is used because 1hr=3600 seconds.
thus scope 5 will give distance graph.
RESULTS OBTAINED:
1)
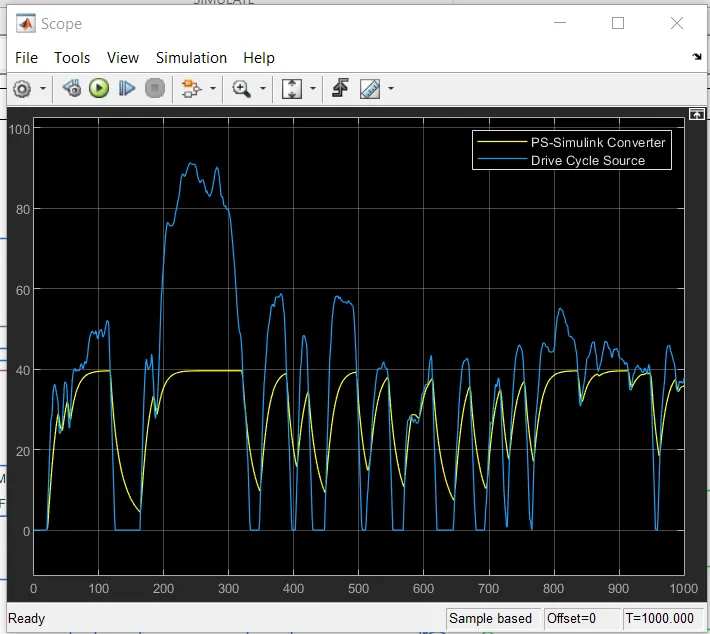
The blue line is graph of drive cycle source and yellow line shows the corresponding velocity graph.
2)
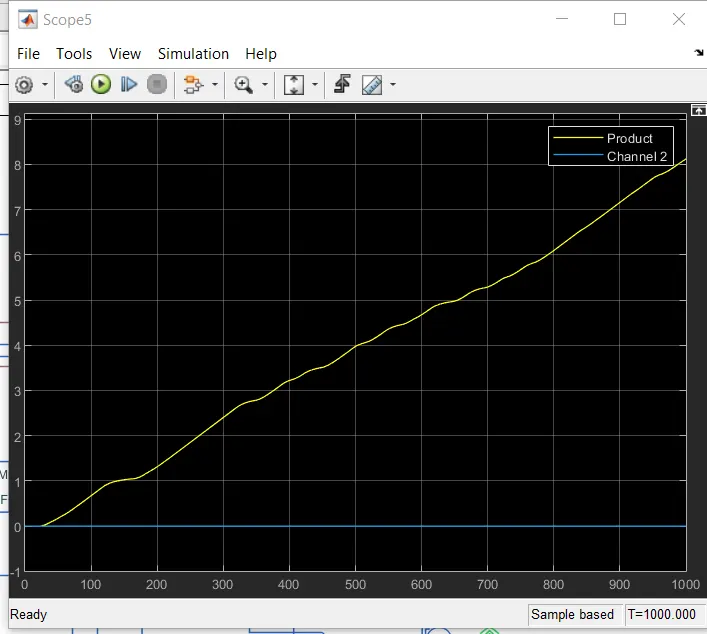
the yellow line shows the distance covered by an electric vehicle.
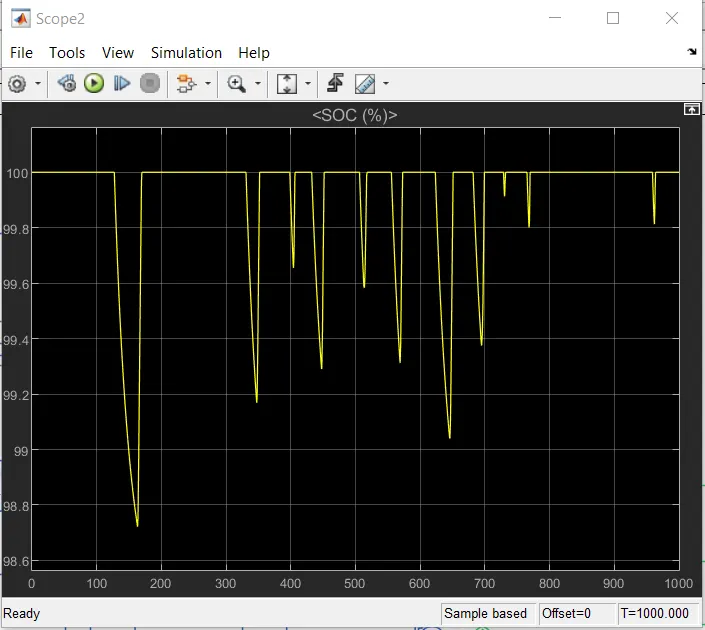
3) SOC calculation:
the variation of SOC is shown below.
the variation of battery voltage is shown below
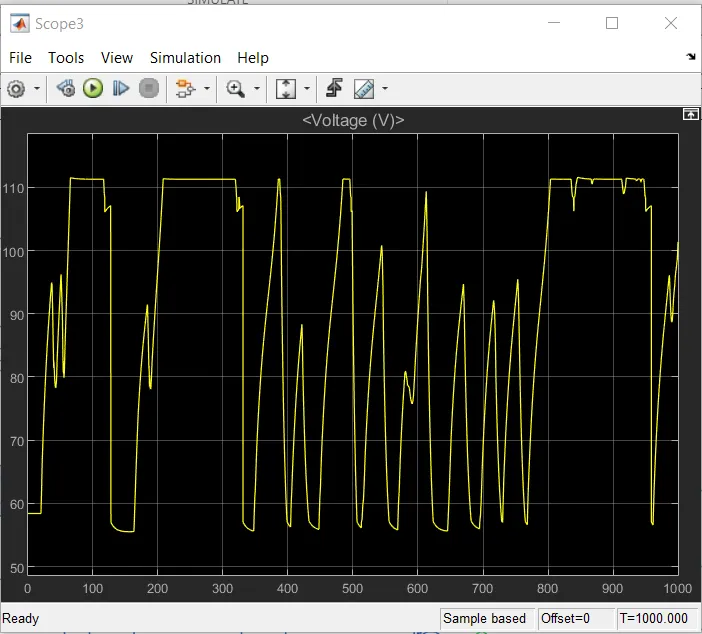
the variation of battery current is shown below
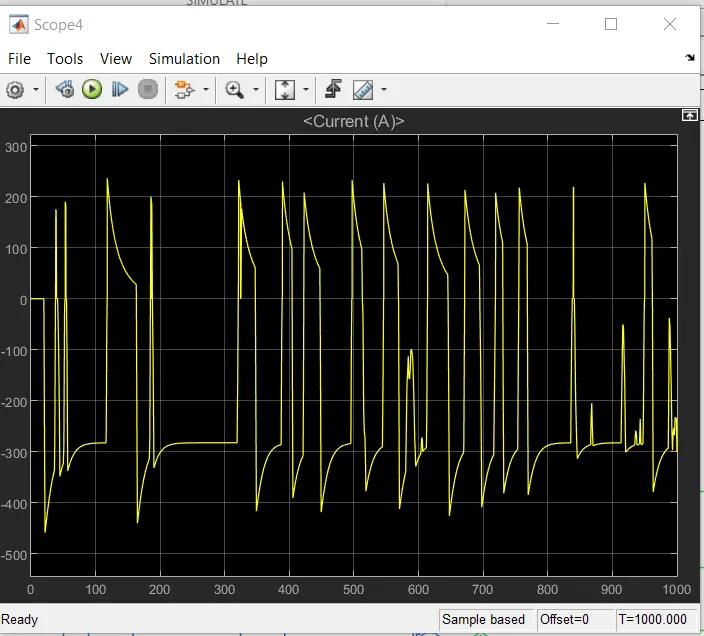
CONCLUSION:
from the above model and from the assume parameters we found that the velocity of electric vehicle is 35.96 km and the distance covered by the electric vehicle is 8.121 km. and also the variation of SOC and the battery current and battery voltage is also studied.