Compliant and Non-Compliant Simulations- An Overview
Before diving into compliant and non-compliant simulations, let us have a look at what kind of bodies can be made in a multi-body dynamics tool.
 Navin Baskar·10 Oct 2022·3 min read
Compliant and Non-Compliant Simulations- An Overview
Before diving into compliant and non-compliant simulations, let us have a look at what kind of bodies can be made in a multi-body dynamics tool. The two broad classifications of bodies/components in multibody dynamics are:
- Rigid Bodies
- Flex bodies
Rigid bodies are the ones which cannot be deformed even to the slightest extent on the application of any type of loading. In practice, none of the bodies is completely/perfectly rigid. The amount of rigidity can be determined by the amount of deformation on the application of a certain amount of load. This can be translated as the hardness of the particular body. Rigid bodies are considered to have significant mass and inertia properties along with negligible deformation.
Flexible bodies are the ones which can be subjected to a considerable amount of deformation on the application of load. The deformation amount depends on the type of load applied and the material's physical properties. In order to create a flexible body on software, it has to be meshed so that the deformation can be mapped properly while running a simulation. In conclusion, we can derive that rigid bodies can be used in kinematics and dynamic simulations, whereas flexible bodies can be used in compliant simulations.
Non-Compliant Simulations:
Non-compliant simulations are the ones where the deformation of the body is not considered, or rephrasing it, the effect of deformation can be negligible for these simulations. They can be broadly classified as Kinematic and dynamics simulations
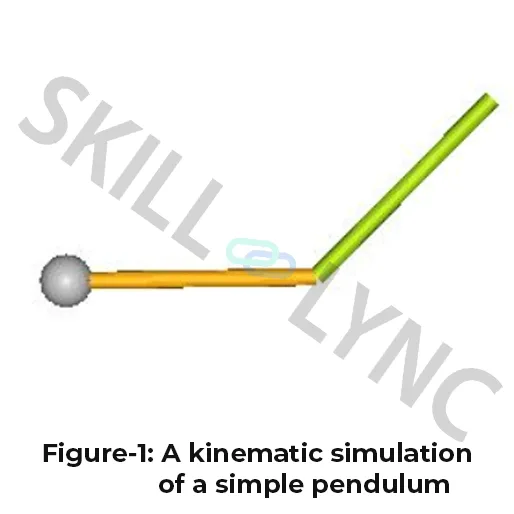
Kinematic Simulation:
Kinematic simulations show the physical positions of all the components/bodies in a body with respect to time as it goes through a cycle. This technology is useful for simulating steady-state motion (with no acceleration), as well as for evaluating a motion for interference purposes, such as assembly sequences of complex mechanical systems. Many basic kinematic packages, however, go a step further by providing “reaction forces,” forces that result from the motion.
Dynamic Simulation:
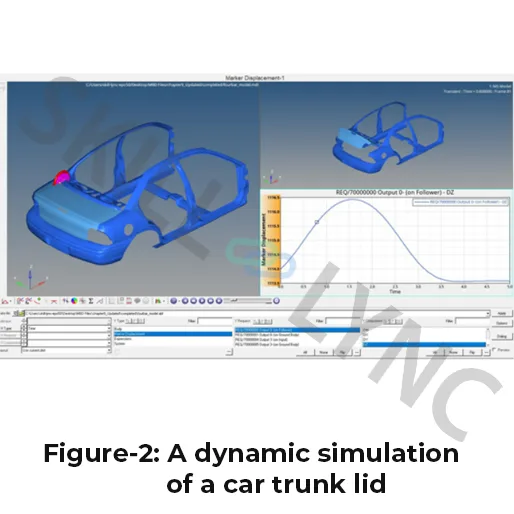
The dynamic simulation uses a computer program to model the time-varying behavior of a dynamical system. The systems are typically described by ordinary differential equations or partial differential equations. A simulation run solves the state-equation system to find the behavior of the state variables over a specified period of time. The equation is solved through numerical integration methods to produce the transient behavior of the state variables. Simulation of dynamic systems predicts the values of model-system state variables, as the past state values determine them. This relationship is found by creating a model of the system.
At present most of the simulation packages does this in a very interactive way so that all the solving process happens in the backend. Dynamic simulation is more complex because the problem needs to be further defined and more data is needed to account for the forces. But dynamics are often required to accurately simulate the actual motion of a mechanical system. Generally, kinematic simulations help evaluate form, while dynamic simulations assist in analyzing function.
Compliant Simulation:
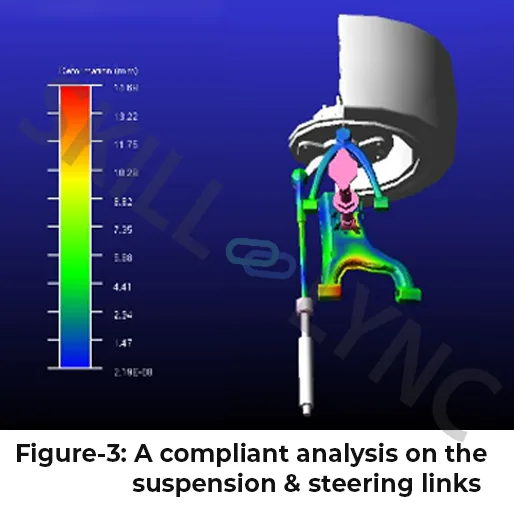
Compliant simulations are the ones where the deformation and the elastic properties of the body can be taken into account while solving/simulating the model. In general, compliance can be considered as the inverse of the stiffness of a particular component. Since the model is compliant in this case, a considerable amount of loading will be absorbed by the component itself and the rest is transferred. This results in the damping of the force and the deformation of the component. A classical example of a compliant simulation is with a suspension subsystem. The suspension links undergo a non-ignorable amount of deformation which damps the amount of force getting transferred to the centre of gravity of a vehicle.
Area of Applications:
Non-compliant simulations:
- IC engine dynamics, motion transmission mechanisms.
- Robot motion simulations. Power transmission areas
Compliant Simulations:
- Suspension Analysis
- Force transfer simulations
- Bending-related simulations/fundamental bar/beam simulation
Which one should be chosen for your application?
Compliant simulations are to be chosen:
- The model involves bending the individual components
- The model involves the absorption of loads by individual components
Otherwise non-compliant/rigid simulations can be done for your model.