Week 8 - Universal Joint
Transient Analysis of Double Universal joint using ANSYS Workbench:
AIM:
To study and perform transient analysis on the double universal joint with given material and compare the analytical results. Grid dependency test was also performed to optimize the element size for better accuracy.
Case 1: Spring (Structural Steel)
Case 2: Spring (Stainless Steel)
Case 3: Spring (Titanium Alloy)
TRANSIENT ANALYSIS SETUP FOR DOUBLE UNIVERSAL JOINT:
I. GEOMETRY:
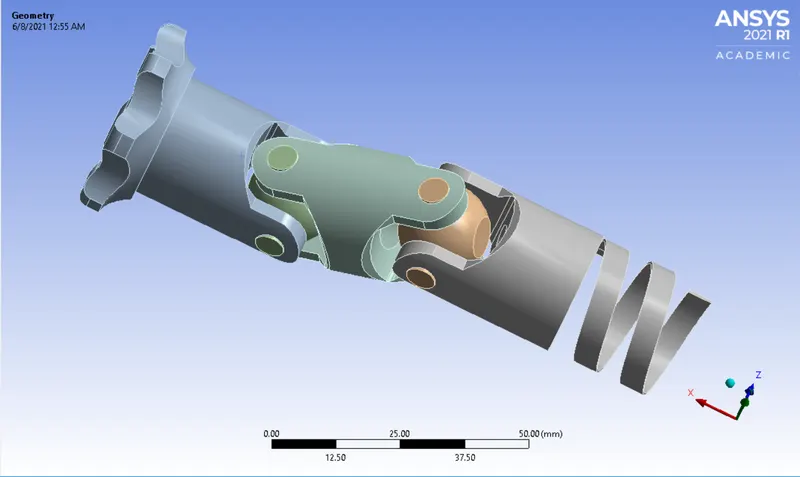
The CAD model of double universal joint is imported in Ansys static structural environment. It comprises of five different components named as spring and driven yoke, Driver yoke, Cross Trunnion 1, Cross Trunnion 2, Intermediate link. It is based on the principle that it is a joint or coupling connecting rigid rods whose axes are inclined to each other, and is commonly used in shafts that transmit rotary motion. It consists of a pair of hinges located close together, orientation at 90 deg to each other, connected by a cross shaft. The universal joint is not a constant-velocity joint.
II. MATERIALS:
Below are the materials which is used to perform analysis for double universal joint. The analysis is carried out for each material individually.
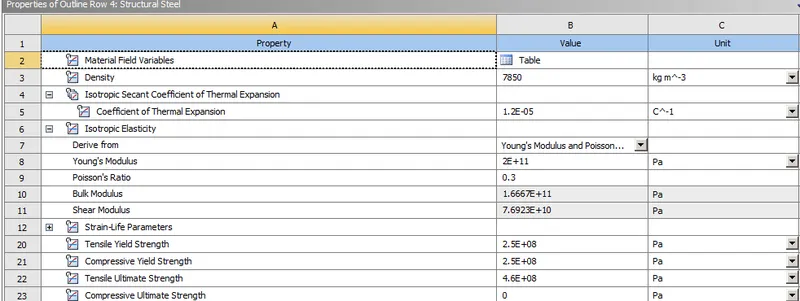
Case 1: Material for spring - Structural Steel
Spring and Driven Yoke: Structural Steel
Driver Yoke: Structural Steel
Cross Trunnion 1: Structural Steel
Cross Trunnion 2: Structural Steel
Intermediate Link: Structural Steel
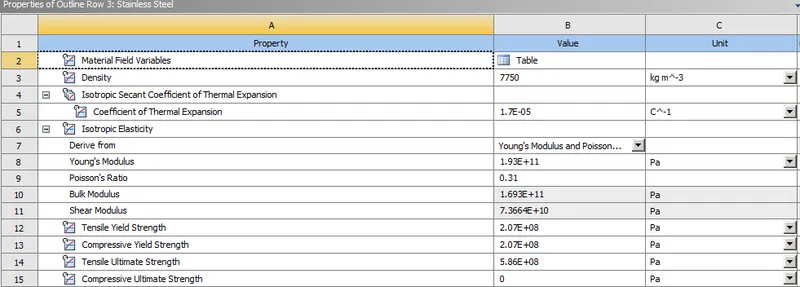
Case 2: Material for spring - Stainless Steel
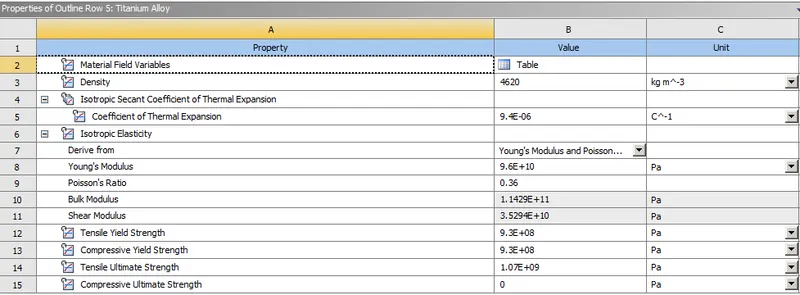
Case 3: Material for spring - Titanium Alloy
The details of each material has been carried out below as shown in the image:
III. CONNECTION DETAILS:
JOINT DETAILS:
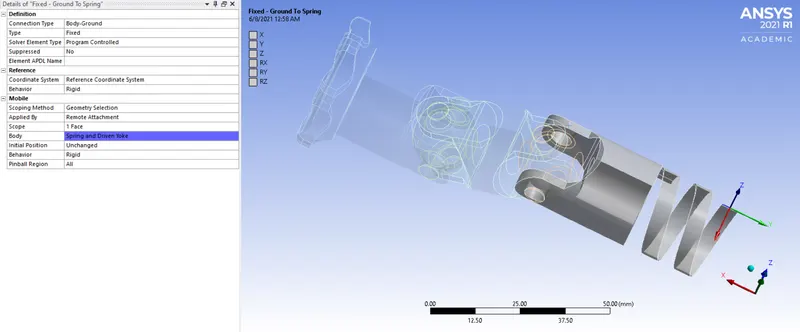
1. Fixed - Ground to spring:
In this joint, we have to select the spring and driven yoke as geometry selection part, as basically it holds relative to the ground so that it will not move while performing analysis. Then we have to change the connection type and connection as 'Body-ground' and 'Fixed'.
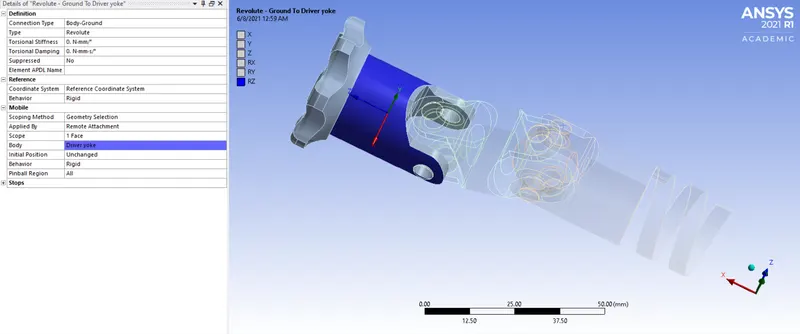
2. Revolute - Ground to Driver Yoke:
In this joint, we have to select the driver yoke as geometry selection part. Then we have to change the connection type and connection as 'Body-ground' and 'Revolute'. This joint is applicable to the cylindrical cam relative to the ground so that it will allow only axial rotation.
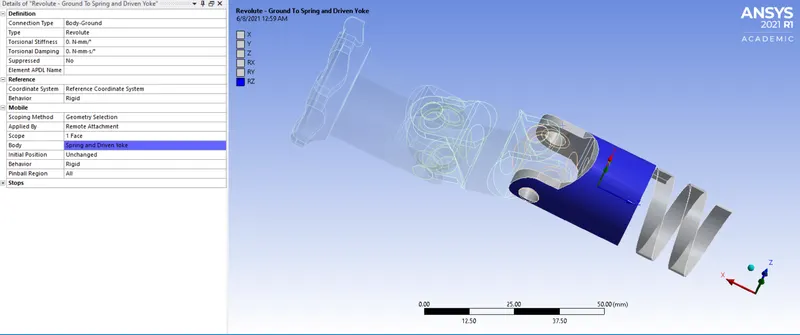
3. Revolute - Ground to Spring and Driven yoke:
In this joint, we have to select the spring and driven yoke as geometry selection part. Then we have to change the connection type and connection as 'Body-ground' and 'Revolute'. This joint is applicable to the cylindrical cam relative to the ground so that it will allow only axial rotation.
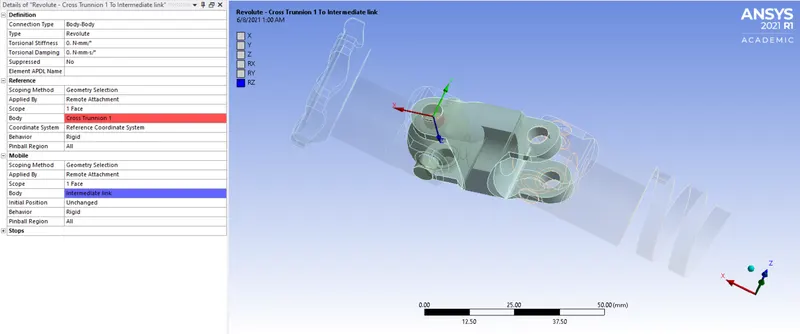
4. Revolute - Cross Trunnion 1 to Intermediate link:
In this joint, we have to select the connection type and connection as 'Body-Body' and 'Revolute.' Basically, we have selected reference body and mobile body type as 'Cross Trunnion 1' and 'Intermediate link' as its geometric selection part.
5. Revolute - Cross Trunnion 1 to Driver Yoke:
In this joint, we have to select the connection type and connection as 'Body-Body' and 'Revolute.' Basically, we have selected reference body and mobile body type as 'Cross Trunnion 1' and 'Driver Yoke' as its geometric selection part.
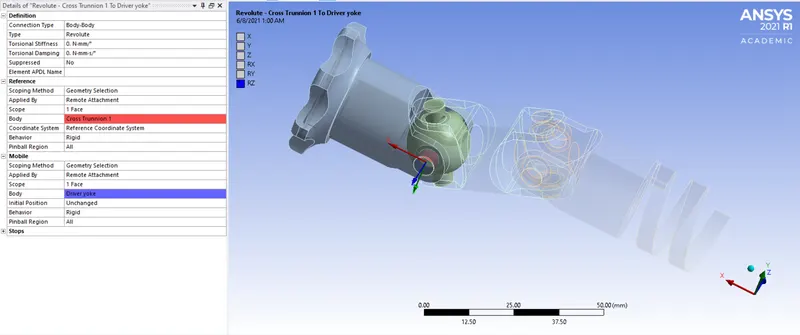
6. Revolute - Cross Trunnion 1 to Driver Yoke:
In this joint, we have to select the connection type and connection as 'Body-Body' and 'Revolute.' Basically, we have selected reference body and mobile body type as 'Cross Trunnion 1' and 'Driver Yoke' as its geometric selection part.
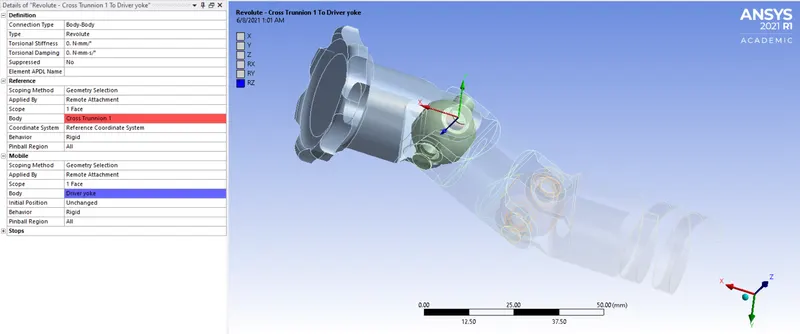
7. Revolute - Cross Trunnion 1 to Intermediate link:
In this joint, we have to select the connection type and connection as 'Body-Body' and 'Revolute.' Basically, we have selected reference body and mobile body type as 'Cross Trunnion 1' and 'Intermediate link' as its geometric selection part.
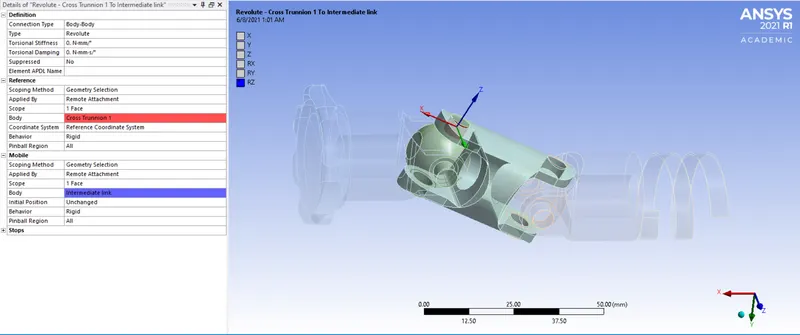
8. Revolute - Cross Trunnion 2 to Intermediate link:
In this joint, we have to select the connection type and connection as 'Body-Body' and 'Revolute.' Basically, we have selected reference body and mobile body type as 'Cross Trunnion 2' and 'Intermediate link' as its geometric selection part.
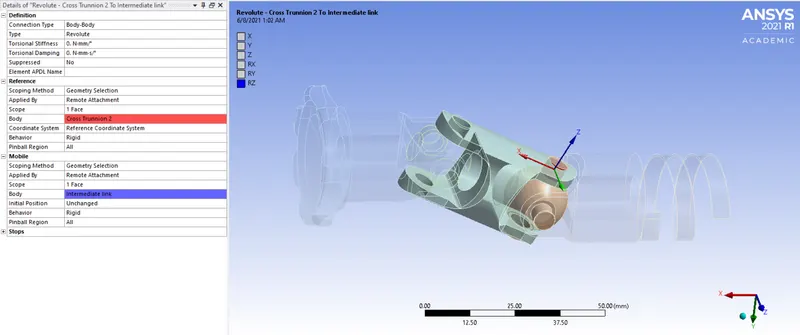
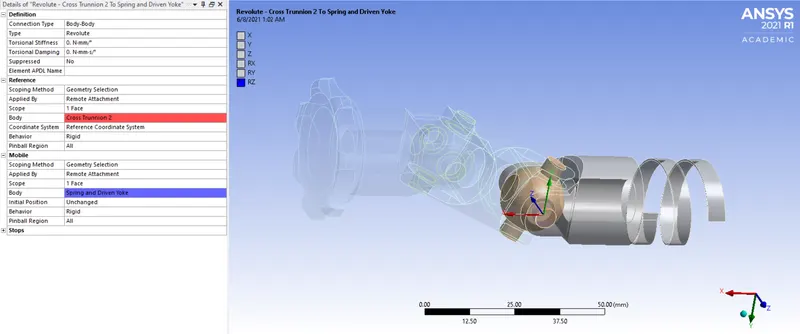
9. Revolute - Cross Trunnion 2 to Spring and Driven yoke:
In this joint, we have to select the connection type and connection as 'Body-Body' and 'Revolute.' Basically, we have selected reference body and mobile body type as 'Cross Trunnion 2' and 'Spring and Driven yoke' as its geometric selection part.
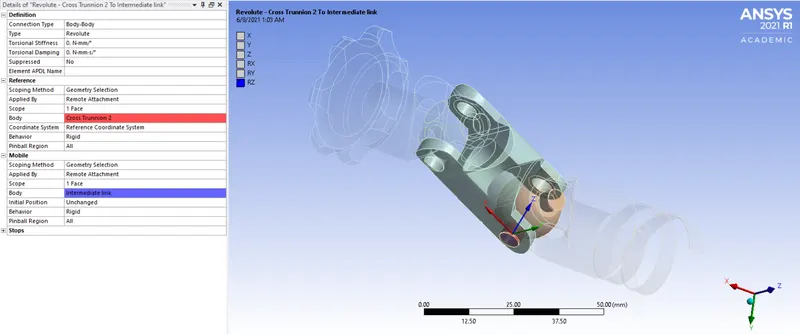
10. Revolute - Cross Trunnion 2 to Intermediate link:
In this joint, we have to select the connection type and connection as 'Body-Body' and 'Revolute.' Basically, we have selected reference body and mobile body type as 'Cross Trunnion 2' and 'Intermediate link' as its geometric selection part.
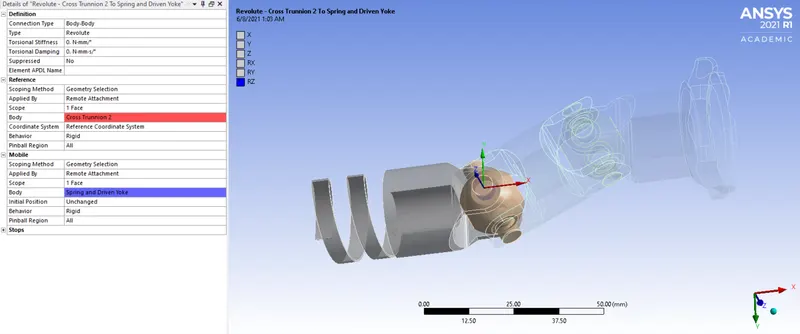
11. Revolute - Cross Trunnion 2 to Spring and Driven yoke:
In this joint, we have to select the connection type and connection as 'Body-Body' and 'Revolute.' Basically, we have selected reference body and mobile body type as 'Cross Trunnion 2' and 'Spring and Driven yoke' as its geometric selection part.
IV. MESH:
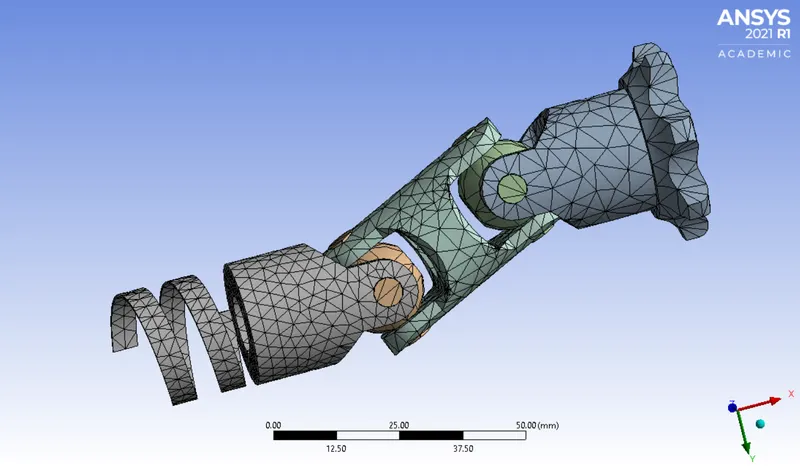
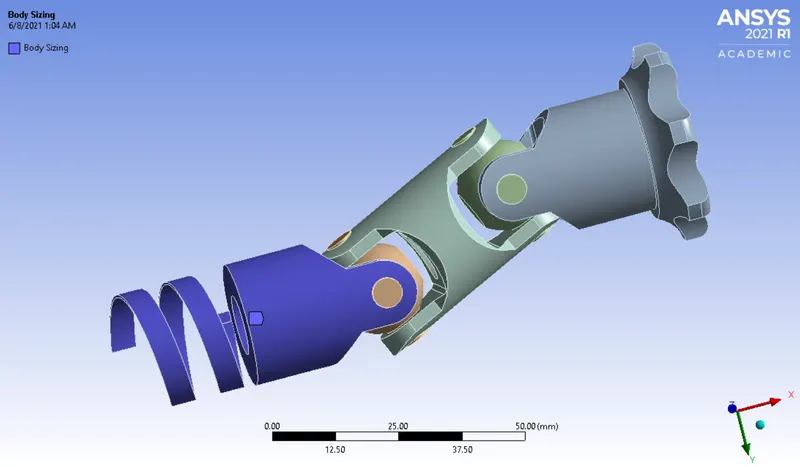
- Basically, we have preferred default mesh for whole setup.
- As, we have to do body sizing for the critical part, hence we have selected spring as critical part and given element size as 3 mm.
- Likethat, we have generated the fine mesh which is sufficient to carrry out simulation which gives desired results.
V. ANALYSIS SETTINGS AND BOUNDARY CONDITIONS:
A. ANALYSIS SETTINGS:
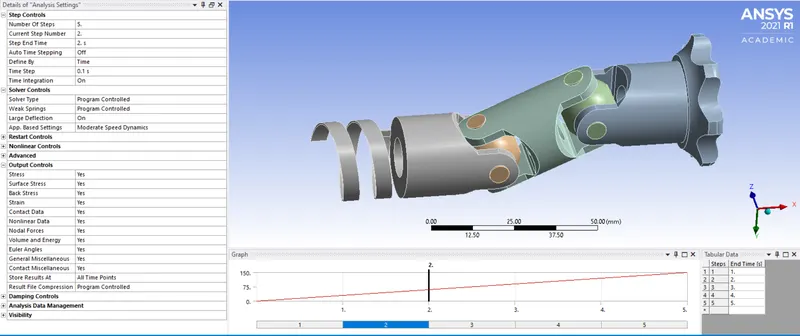
For this analysis the number of steps is set to 5 with Auto Time stepping is OFF and it is defined by time, hence time step would be 0.1 sec. After that, the solver type is to be Program controlled and then Large deflection is set to On, so as to account for change in stiffness due to change in shape of gears. When stabilizers are activated, it add dampers to all nodes. When the large displacement nodes try to move the force is added to balance them thus favoring convergence. Hence, the energy dissipiation is said to be Program Controlled. Lastly, we have to enable all output controls to be ON.
B. BOUNDARY CONDITIONS:
Joint-Rotation:
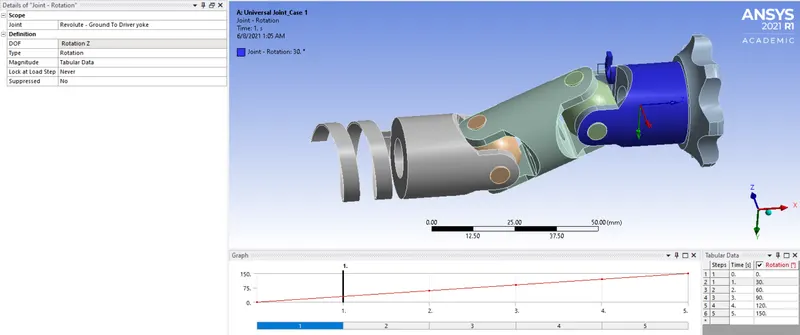
Basically, we have selected joint as Revolute-Ground to Driver Yoke. Then, we have taken DOF and its type as 'Z Rotation' and 'Rotation'. Likewise, we have given rotation in tabular form. The rotation is given in the form of angle 30 deg.
VI. POST-PROCESSING RESULTS:
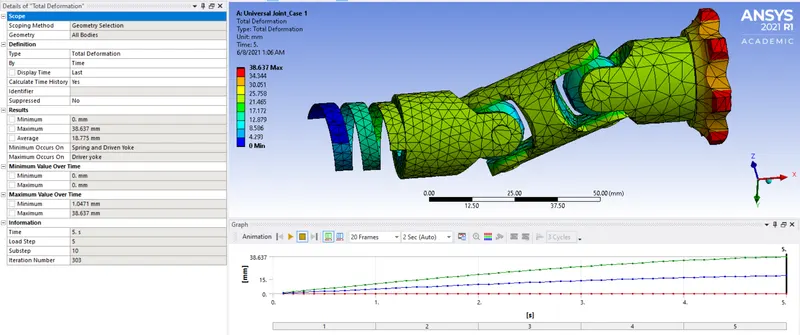
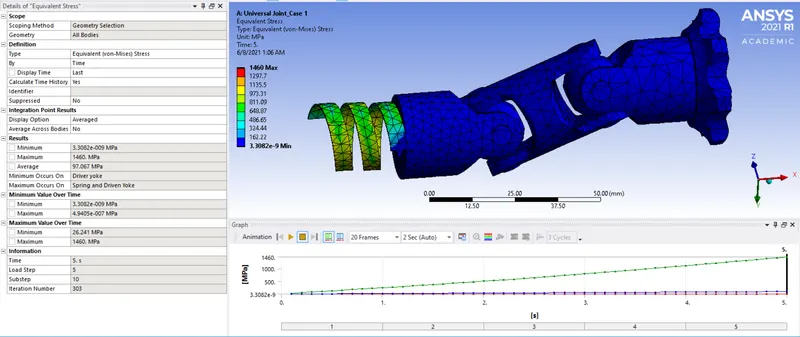
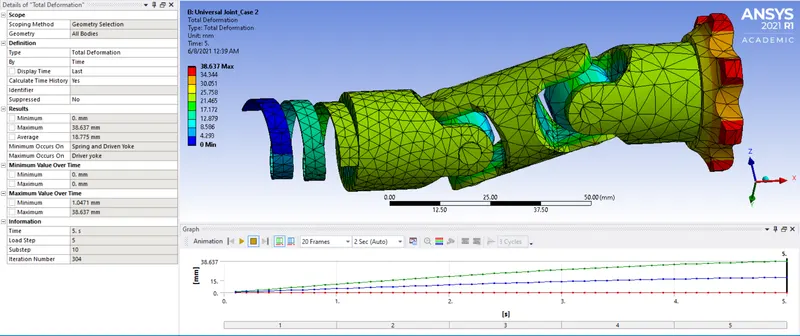
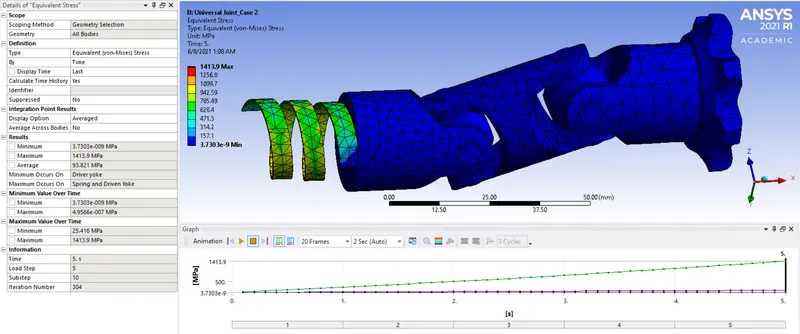
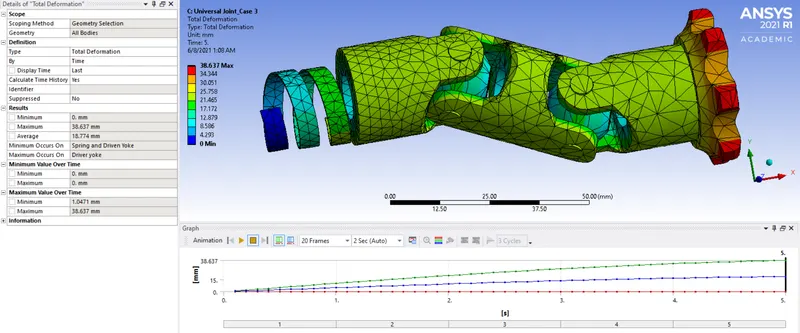
Now, we have to compare the deformation and stress on the basis of different materials. Then, we have to analyze the result for total deformation, equivalent stress and strain for double universal joint. The results are as shown below:
Case 1: Material for spring - Structural Seel
I. Total Deformation:
II. Equivalent stress:
Case 2: Material for spring - Stainless Seel
I. Total Deformation:
II. Equivalent stress:
Case 3: Material for spring - Titanium Alloy
I. Total Deformation:
II. Equivalent stress:
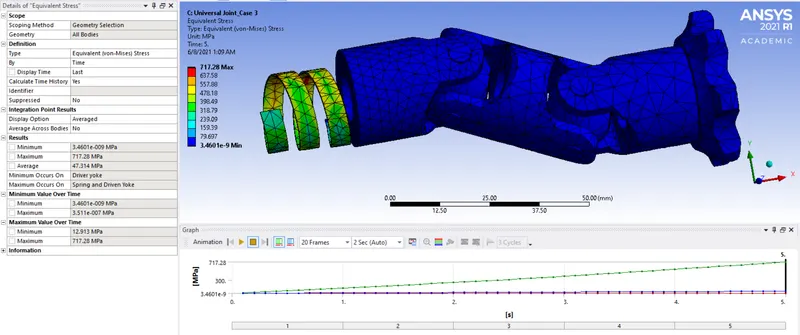
VII. POST-PROCESSING SUMMARY:
|
Parameters |
Case 1 |
Case 2 |
Case 3 |
|
Maximum Total Deformation |
38.637 mm |
38.637 mm |
38.637 mm |
|
Minimum Total Deformation |
0 |
0 |
0 |
|
Maximum Equivalent stress |
1460. MPa |
1413.9 MPa |
717.28 MPa |
|
Minimum Equivalent stress |
3.3082e-009 MPa |
3.7303e-009 MPa |
3.4601e-009 MPa |
CONCLUSION:
- From the results, we can observe that the structural steel gives higher stress than stainless steel and titanium alloy has the lower stress.
- As we know that Titanium alloy has the density nearly half of the structural steel, so it is light weight compared to structural steel and stainless steel, and so it is more flexible.
- Also, the tensile yeild strength and tensile ultimate strength of the titanium alloy are highest among all the materials. So it has more eleastic region and can regain the original shape easily and also can withstand to higher loads.
- Also, in case_1 and case_2, maximum stress is exceeding the value of the yeild strength, so there is plastic deformation, but in case_3, the maximum stress is well below the yeild strength.
- Also, the ultimate strength of the titanium alloy is very high, so the structure is safe compared to other materials.
- So, from the results and observation, we can conclude that the Titanium alloy is very safe and effective material, which can give high performance and the mechanism of the double universal joint, will be safe and can work longer.
- Thus, the alloy of titanium material can give good results for universal joint and it is the best suited material.