Week-7 Challenge: DC Motor Control
AIM:- To study on DC Motor Control.
Question:-1] A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H- bridge model.
Ans:-
A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
- Speed Control of DC Motor:- A DC motor is used to convert the direct current electric power into Mechanical power based on the force produced by magnetic field.
EMF equation of DC motors:-
`Eb=(PphiNZ)/(60A)`
Eb∝ϕN
Eb=KϕN
Where, K= Proportionality Constant
Eb= V- IaRa
KϕN= V-IaRa
The Relationship given below equation of the speed control of DC motor-
`N=(V-IaRa)/(Kphi)`
From above equation the speed of the DC motor depends on Supply voltage(V), Flux (ϕ) and Armature resistance(Ra).
There are three control method of a Speed of DC motor-
1. Applied voltage control methode(V).
2. External resistance with armature resistance (Ra).
3. Flux per pole(ϕ).
BJT:- BJT stand for bipolar junction transistor.
A Bipolar Junction Transistor (also known as a BJT Transistor) is a three-terminal semiconductor device consisting of two p-n junctions which are able to amplify or magnify a signal. It is a current controlled device. The three terminals of the BJT are the base, the collector and the emitter. A BJT is a type of transistor that uses both electrons and holes as charge carriers.A signal of small amplitude if applied to the base is available in the amplified form at the collector of the transistor. This is the amplification provided by the BJT.
There are two types of bipolar junction transistors – PNP transistors and NPN transistors. We can see below figure-
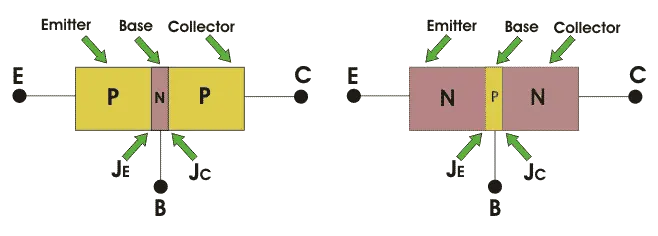
From the above figure, we can see that every BJT has three parts named Emitter, Base and Collector. JE and JC represent the junction of emitter and junction of collector respectively. Now initially it is sufficient for us to know that emitter based junction is forward biased and collector-base junctions are reverse biased.
Application of Bipolar Junction Transistor:-
BJT can be used in various kinds of applications such as logic circuits, amplification circuits, oscillation circuits,circuits of the timer, time delay circuits, switching circuits, etc.
H-Bridge:-
H - Bridge is a simple electronic circuit which enables us to apply voltage to load in either direction. By using H Bridge we can run DC Motor in clockwise or anticlockwise directions. This circuit is also used to produce alternating waveforms in inverters.
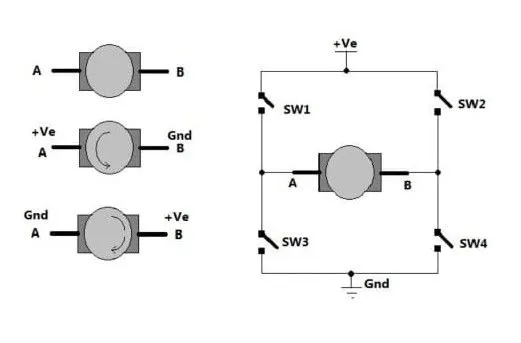
Fig:- Image showing H-Bridge circuit used for controlling direction of rotation of a DC Motor.
As shown in above figure there are two terminals ‘A’ and ‘B’ of DC motor. Now if we connect terminal A with +Ve supply and terminal B with –Ve supply or ground the current will flow from motor from A to B and motor will rotate in one direction – say clockwise (CW) or forward direction. Now as shown in second figure we change the supply terminals. Now B is connected with +Ve and A is connected to ground. The current will flow from motor from B to A and motor will rotate in other direction (counter clockwise – CCW or reverse).
We can see The arrangement is shown in right side of figure. Four switches are connected in between +Ve supply and ground and DC motor is connected in between two switches as shown. Such circuit arrangement is known as H-bridge because it looks like letter ‘H’ (H-bridge circuits are most widely used in DC motor drivers). Let us see how it gives reverse supply to motor.
If SW1 and SW4 are pressed simultaneously then current will flow from +Ve – SW1 – A – B – SW4 – Gnd. So motor will rotate in one direction. Open (release) SW1 and SW4 to stop motor. Now if SW2 and SW3 are pressed current will flow from +Ve – SW2 – B – A – SW3 – Gnd. So motor gets reverse supply and it will rotate in another direction.
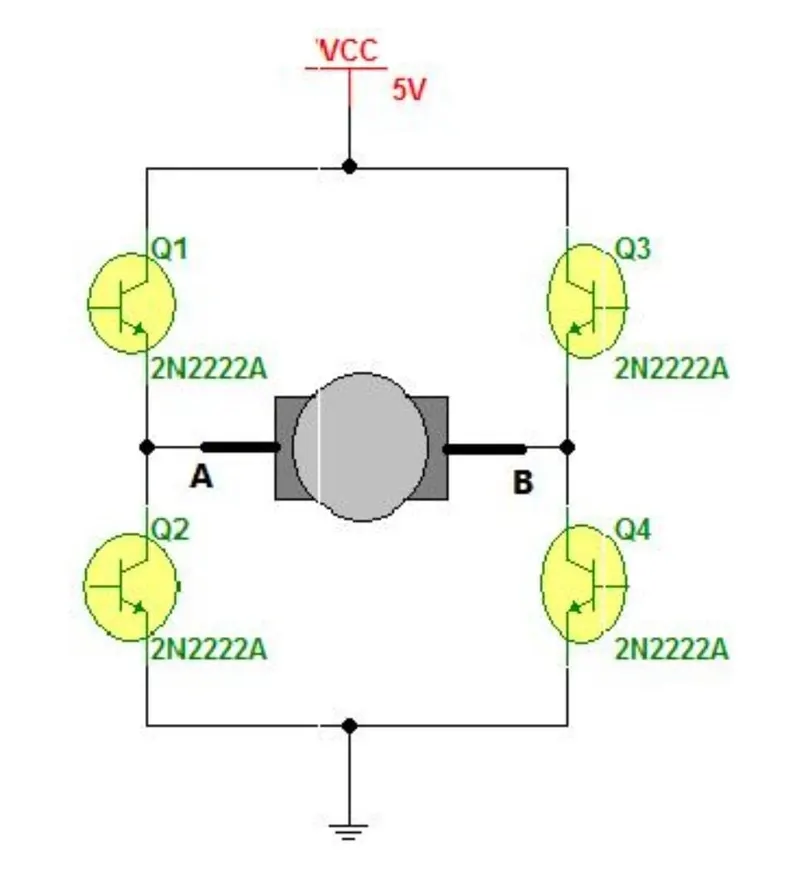
Fig:- Circuit Diagram of H-Bridge built by transistor for controlling DC motor speed and rotation.
The above circuit replaces the switches with NPN type transistors. We all know that transistor works as switch. For NPN transistor if we give +Ve input to base it will turn ON and if we give 0 input it will be turned OFF.So in this circuit if Q1 and Q4 are turned ON simultaneously the motor will rotate forward and if Q2 and Q3 are turned ON then motor will rotate reverse.The Motor can be rotated forward and reverse using 4 transistors only.
One of the very popular methods for generating variable DC voltage is pulse width modulation (PWM). It is explained in figure given below.
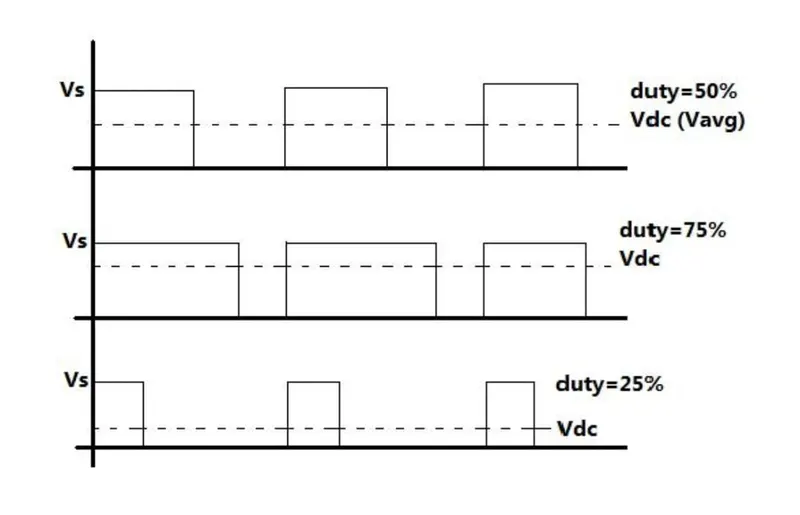
Fig:- Graph showing Pulse Width Modulation(PWM) for controlling speed of DC Motor.
Pulse width modulation means varying the width (duty) of pulse. Width means ON time Ton of pulse. The average output voltage (Vdc or Vavg) is given by equation
Vdc = [Ton / (Ton+Toff)] × Vs
It directly depends upon Ton. As shown in above figure if duty is 50% the average output voltage Vdc is exactly the half of Vs. If duty is increased to 75%, Vdc also increases to 3/4th of Vs and if duty is decreased to 25%, Vdc reduces to 1/4th of Vs.
Model for Speed control of a DC motor using BJT H-bridge:-
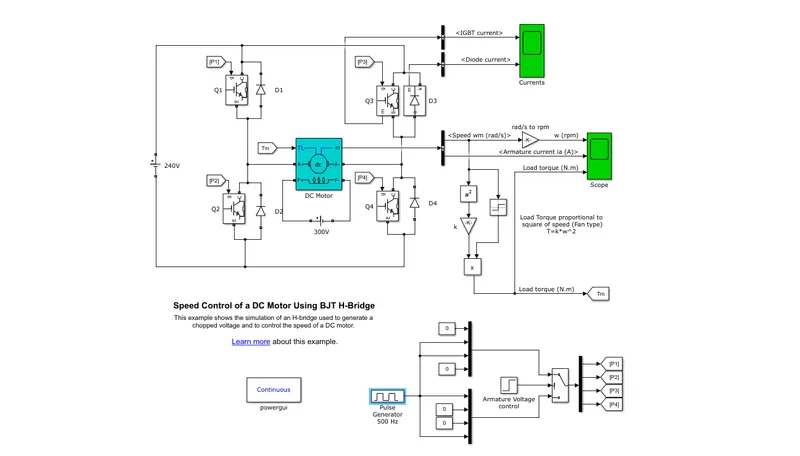
Fig:- Model for Speed control of a DC motor using BJT H-bridge.
In this model to control speed of a DC motor used BJT H-bridge.The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting , a forward voltage Vf is developed between collector and emitter. Therefore, the IGBT block can be used to model the BJT device.The IGBT block does not simulate the gate current controlling the BJT or IGBT. The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to square of speed). The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
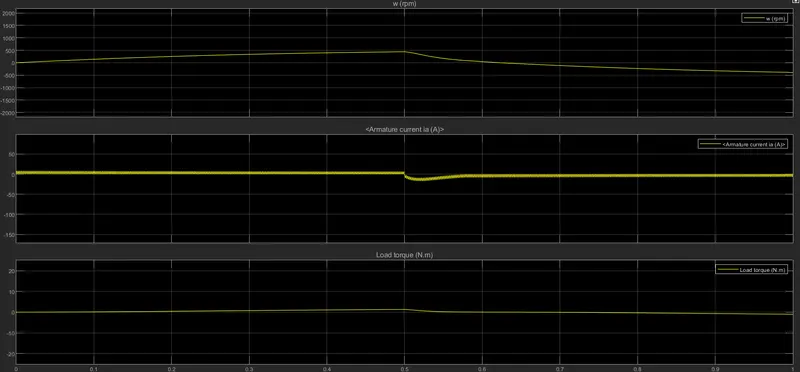
The motor starts in the positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t= 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction.'Scope' shows motor speed, armature current and load torque and 'Currents' shows currents flowing in BJT Q3 and diode D3.
BJT H- Bridge Voltage 230and DC Motor Voltage 300-We can see in pulse generator block 75% Duty Cycle and Simulink run for 1 sec.
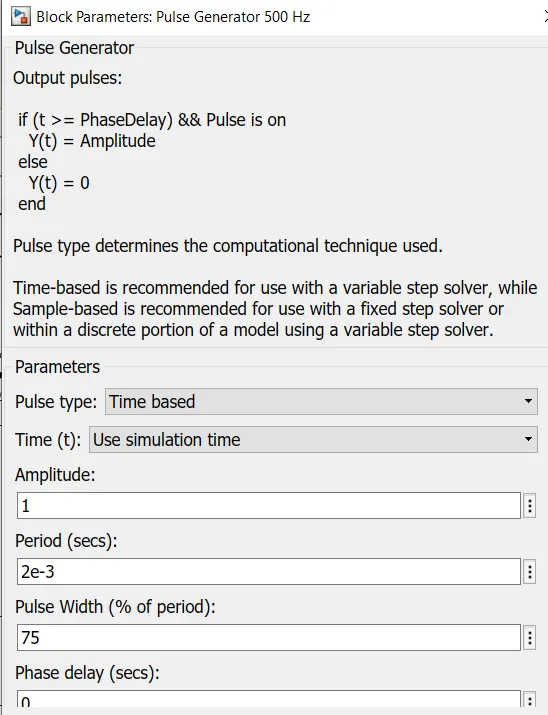
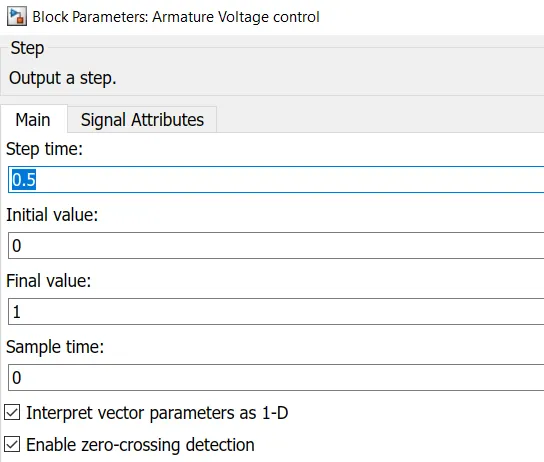
Output of Duty Cycle is 75%:-
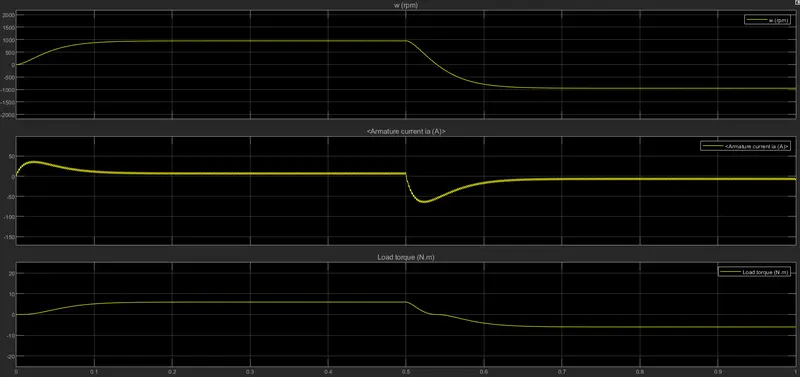
We can see in above graph the Armature current Vs time the current started from 0 quickly increasing and remaining constant and again goes to down negative direction and remains constant.We see in Curve Speed (rpm) Vs Time the the curve started from 0 the speed slowly increasing and remains constans at 0.5 sec maximum speed at 1000 rpm and after decresing speed and remains constant speed.
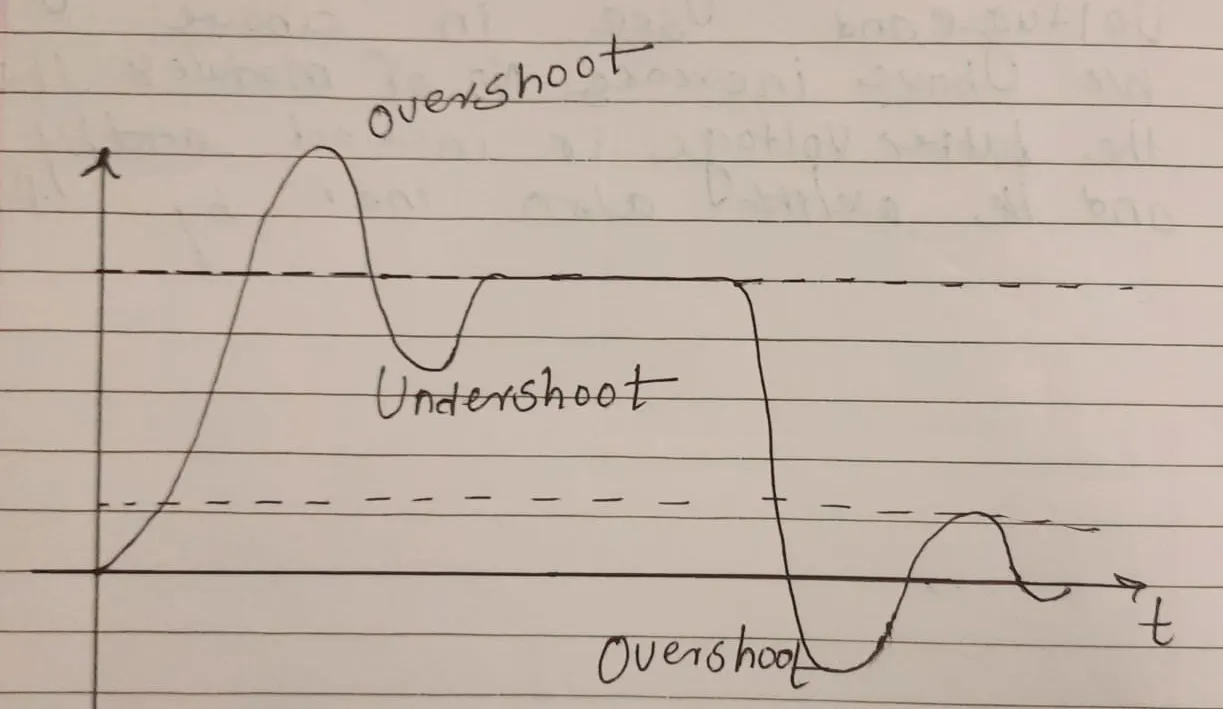
Overshoot:- The overshoot is a condition where signal is exceeding Final value.
Undershoot:- The Undershoot is a condition where signal is lower than the desired value.We Can Seen in below graph.
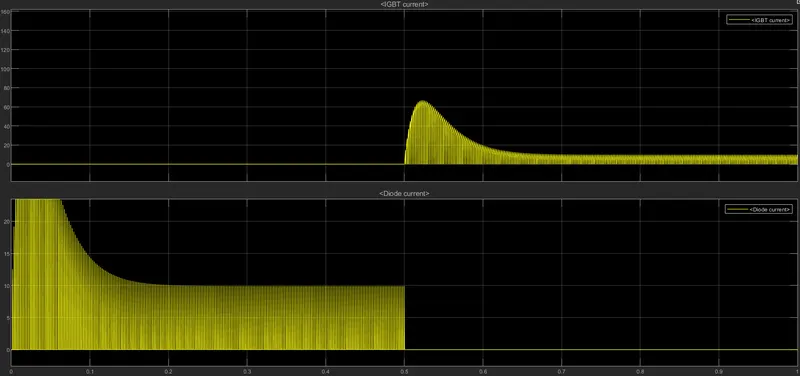
Output for IGBT Current and Diode Current Graph:-
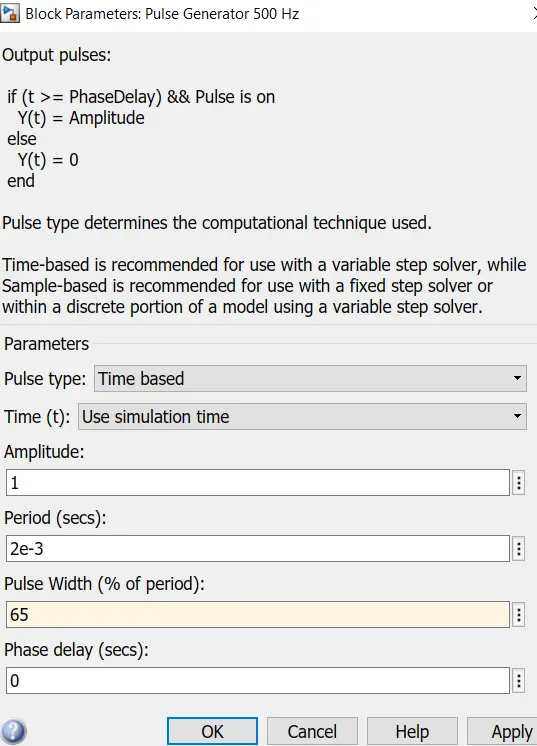
We can see in pulse generator block 65% Duty Cycle:-
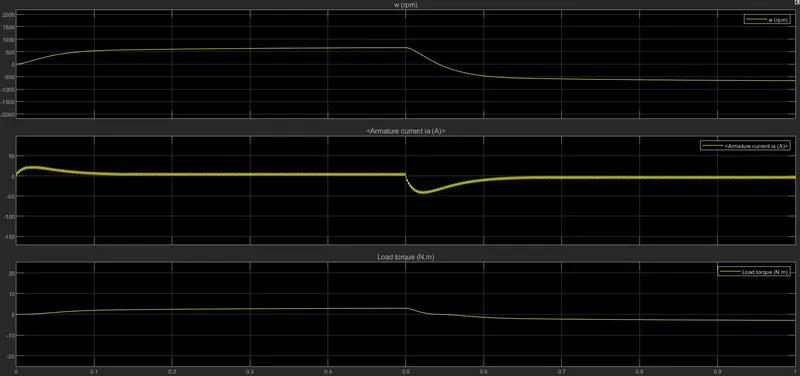
Output of Duty Cycle is 65%:-
We can see in pulse generator block 50% Duty Cycle:-
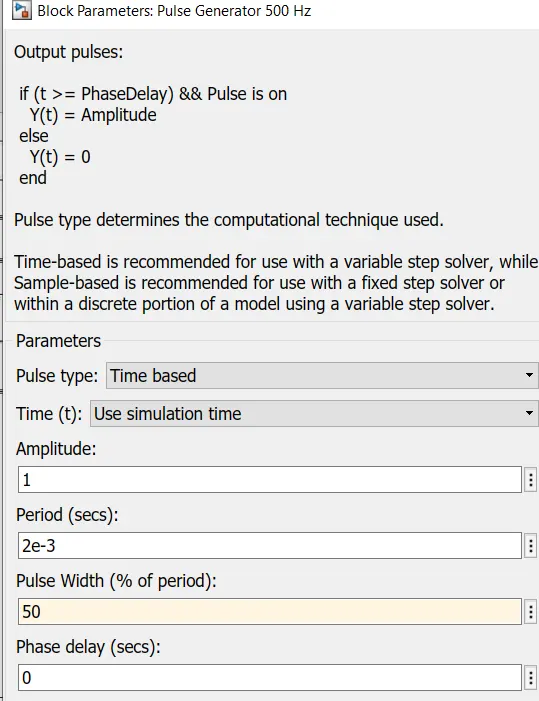
Output of Duty Cycle is 50%:-
Output for IGBT Current and Diode Current Graph:-
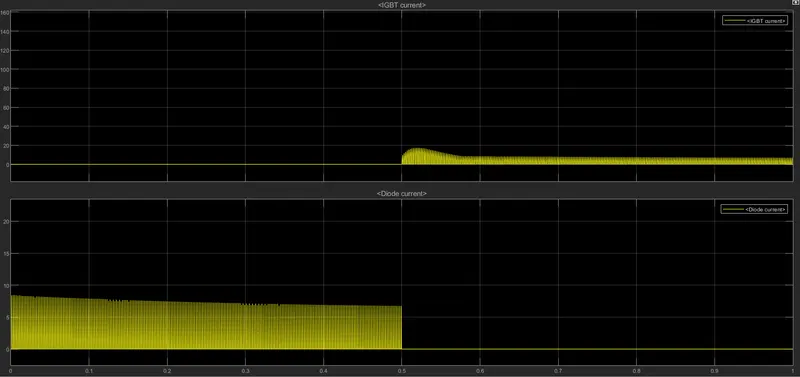
We Have Change duty for 50% result as shown in above graph- We can see in Armature current Vs Time graph the Duty cycle Decreasing speed(rpm), Torque and IGBT & Diode current aslo Decreasing.The Armature Current remains Constant From 0 at time for 1 sec. we can see in Armature Current Vs Time Graph there are not available overshoot.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H- bridge model.
- The Four Quadrant Chopper DC motor means that the machine operate in Four Quadrant Name as Forward motoring, Forward braking, Reverse motoring,Reverse braking. They are basically Two mode of Operation-In Motoring Mode, The electrical energy is converted into mechanical energy and Support the motion. In Braking Mode, The Mechanical energy is converted into electrical energy and the motor works as generator and opposit the motion.
The circuit of a four quadrant chopper basically consists of four Semiconductors switches CH1 to CH4 and four Diode D1 to D4. The four diodes are connected in anti-parallel. The circuit diagram of this type of chopper is shown below.The Chopper are numbered CH1 to CH4. For first quadrant operation CH1 is made ON, for second quadrant operation CH2 is made ON. We have Discuss in Detail in below.
Fig:- The circuit of a four quadrant chopper.
First quadrant operation:- In this region, CH4 is kept ON, CH3 is kept OFF and CH1 is operated. When both CH1 & CH4 are ON simultaneously, the load gets directly connected to the source and hence the output voltage becomes equal to the source voltage. This essentially means that vo = vs. It may be noted that the load current flows from source to load as shown by the direction of io.When CH1 is switched OFF, the load current free wheels through CH4 and D2. During this period, the load voltage and current remains positive.Thus, both the output voltage vs and load current io are positive and hence, the operation of chopper is in first quadrant.
Second quadrant operation:- In this region, CH2 is operated while keeping the CH1, CH3 & CH4 OFF. When CH2 is ON, the DC source in the load drives current through CH2, D4, E and L. Inductor L stores energy during the On period of CH2.When CH2 is turned OFF, current is fed back to the source through D1, D4. It should be noted at this point that (E+Ldi/dt) is more than the source voltage Vs. As load voltage Vo is positive and Io is negative, it is second quadrant operation of chopper. Since, the current is fed back to the source.For second quadrant operation load must contain emf E as shown in the circuit diagram.
Third quadrant operation:- In this region,When CH1 is kept off, CH2 is kept ON and CH3 is operated. When CH3 is ON, load gets connected to source and hence load voltage is equal to source voltage. But carefully observe that the polarity of load voltage vo is opposite to what shown in the circuit diagram. Hence, vo is assumed negative. Let us now see what is the status of load current io. It may be seen that io is flowing in the direction opposite to shown in the circuit diagram and hence negative.Now, when CH3 is turned OFF, the negative load current free wheels through the CH2 and D4. In this manner, vo and io both are negative. Hence, the chopper operates in third quadrant.
Fourth quadrant operation:- In this region, The CH4 is operated while keeping CH1, CH2 and CH3 OFF. The polarity of load emf E needs to be reversed in this case too like third quadrant operation.When CH4 is turned ON, positive current flows through CH4, D2, L and E. Induction (L) stores energy during the time CH4 is ON. When CH4 is made OFF, current is fed back to the source through diodes D2, D3. Here load voltage is negative but the load current is always positive.
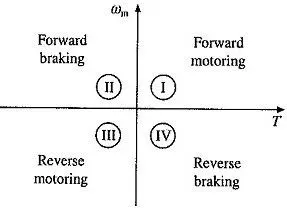
Fig:- Image shows the Torque and Speed Coordinate for both Forward and Reverse Motion.
Four Quadrant Chopper DC Motor Drive- If the power developed is positive then the operation is motoring and If the Power developed is Negative then the operation is Braking.
In The Quadrant (I)- Forward Motoring, The power and torque are both positive, so the power developed is positive and the machine work as a motor supplying Mechanical energy.
In The Quadrant (II)- Forward Braking, The speed is positive but torque is negative, so power developed is negative and the machine work under braking opposing the motion.
In The Quadrant(III)- Reverse Motoring, The speed and torque both are negative, so power developed is positive and so the machine work under reverse motoring mode.
In The Quadrant (IV)- Reverse Braking, The speed is negative and the torque is positive, so the power developed is negative, so the machine work as a braking mode in the reverse direction.
Compare The Four-Quadrant Chopper DC Drive with the H- bridge model.
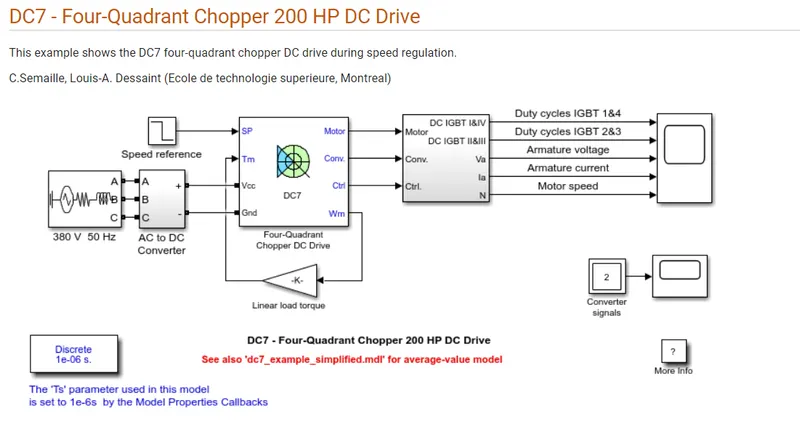
The Four-Quadrant Chopper DC Drive:-
- The DC7 drive operate in Four Quadrant name as Forward motoring and Braking, Reverse motoring and Braking.
- The armature voltage is provided by IGBT controller is the controlled by PI Regulation.
- In this model used Open Loop Chopper.
- This model contains Speed and Current regulation.
- The Chopper Convert the fixed DC Voltage to Variable DC Voltage.
- PID Controller used in DC7 model.
- The change in direction in BJT is done by changing the polarity.
H- bridge model:-
- It operate in 2 Quadrant name as Forward Motoring and Reverse Motoring.
- PID controller are not used in this model.
- In this model used Closed Loop Chopper.
- H- bridge model is Continuous.
- In this model The current changes the change in polarity in the Switches.
- The motor take the graph by load Torque and Output speed.
- This model used DC Motor as an Output.
Question:- 2] Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results.
Ans:-
Two quadrant chopper:-
It is basically a cpmbination of First and Second Quadrant choppers.In First case CH1 is on and D2 conducts where as CH2 is on and D1 conducts in second case.
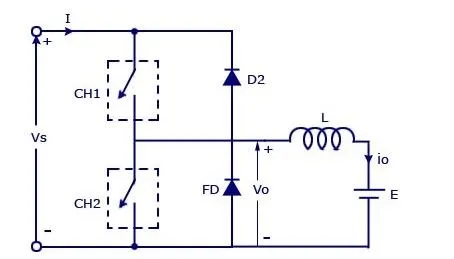
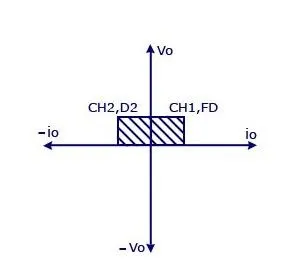
Fig:- Two Quadrant Chopper.
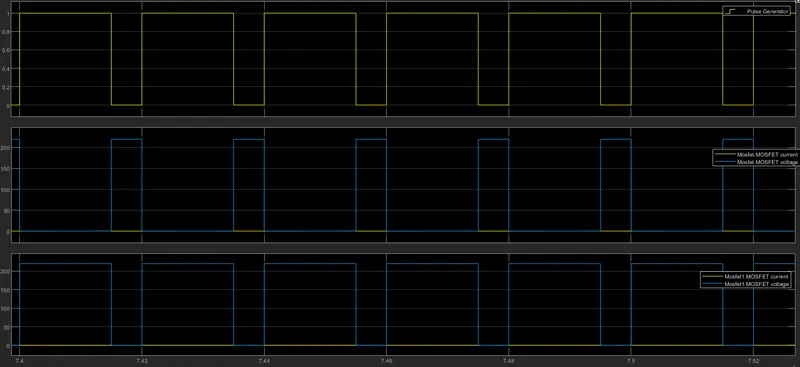
The above figure in shows the Two Quadrant chopper. Both the switch never turn on at the same time because this will cause a short circuit. At the output, there is a freewheeling diode so the voltage is always positive. When the chopper 2 (or switch 2) is turned on then the voltage is zero and when chopper 1 is turn on then the output voltage Vo=Vs.
2-quadrant chopper using simulink Model:-
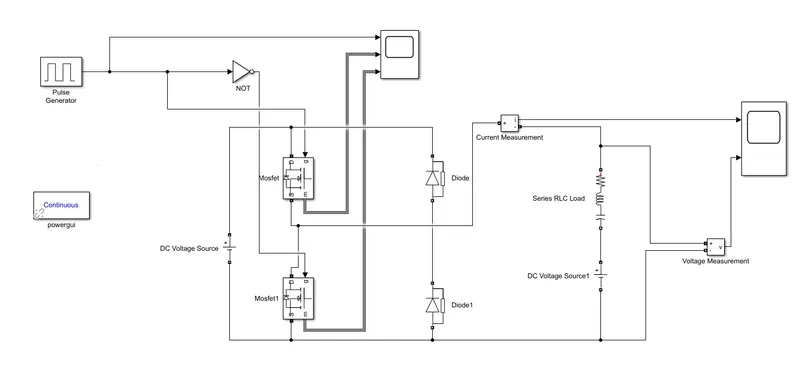
Fig:- Two-Quadrant Chopper Model
Above Shown in Model we have Two mosfet and Two Diode used. The DC voltage Source is connection as shown in above model. We have used Pulse Generation Block to create gate pulse.
We have give to Supply Voltage DC Source 220V.
The 100 V DC Voltage Source.
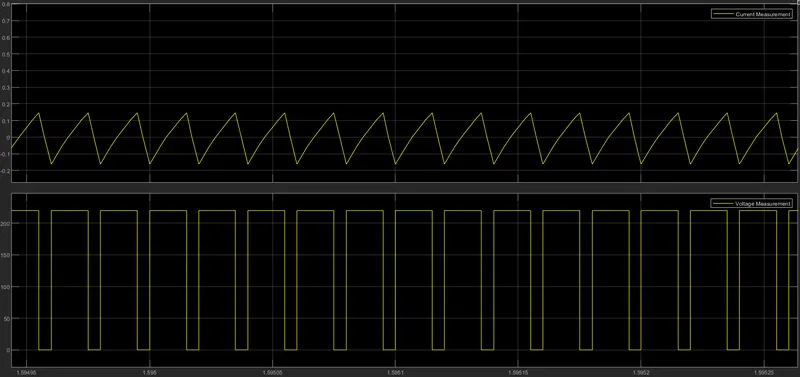
Result:-
Question:- 3] Explain in a brief about operation of BLDC motor.
Ans:-
What is the BLDC Motor:- Brushless DC motors do not use brushes. With brushed motors, the brushes deliver current through the commutator into the coils on the rotor. In simple words,a BLDC has no brushes and commutator for having unidirectional torque rather integrated inverter / switching circuit is used to achieve unidirectional torque.
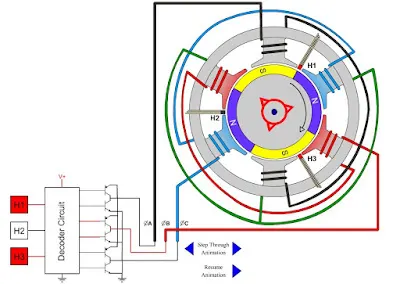
There are three types of the BLDC motor:
1) Single-phase
2)Two-phase
3) Three-phase.
The single-phase and three-phase motors are the most widely used. The simplified cross section of a single-phase and a three-phase BLDC motor is shown in figure below. The rotor has permanent magnets to form two magnetic pole pairs, and surrounds the stator, which has the windings.
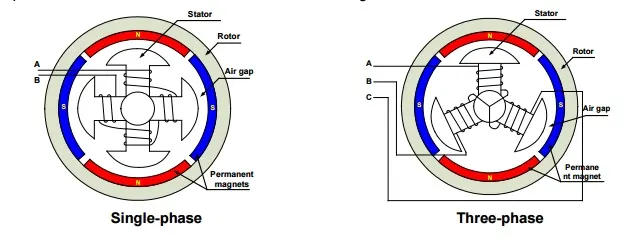
A single-phase motor has one stator winding wound either clockwise or counter-clockwise along each arm of the stator to produce four magnetic poles as shown in above figure.A three phase BLDC motor has three windings. Each phase turns on sequentially to make the rotor revolve.
Construction of Brushless DC Motor:-
It consists of in this motor Rotor, stator, Permanent magnet. the permant magnets attach to the rotor.The current conductor or Armature winding is located on the stator. They use electrical commutation to convert electrical energy into mechanical energy.the main design difference between a brushed and brushless motor is the replacement of mechanical commutator with an electric switch circuit.A Brushless DC motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.Brushless motor does not have any current carring commutators.
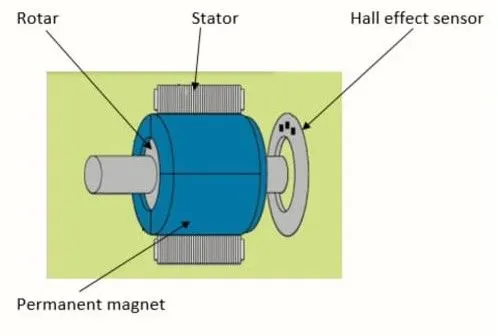
Brushless Motors are available in three configurations: single phase, two phase and three phase. Out of these, the three phase BLDC is the most common one.
The following image shows the cross-section of a BLDC Motor.
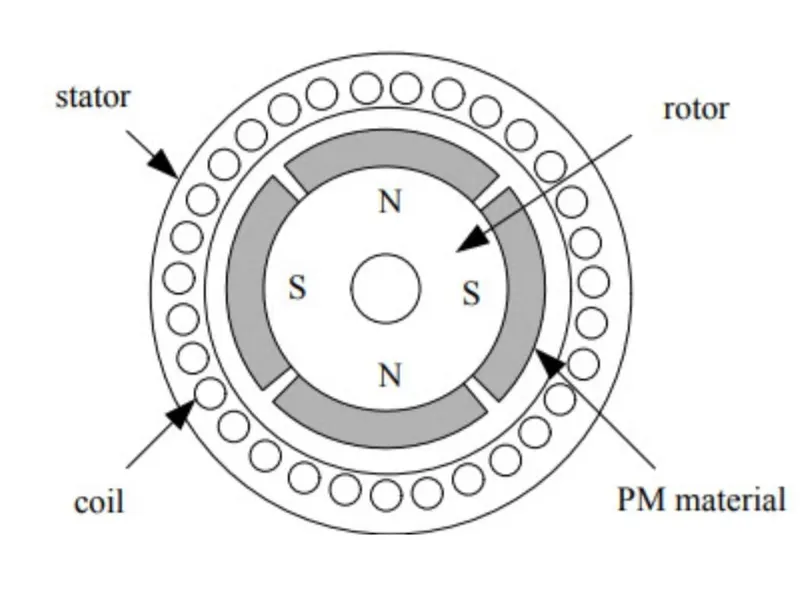
As you can see in the image, a BLDC Motor consists of two main parts: a stator and a rotor.
Stator
The structure of the stator of a BLDC Motor is similar to that of an induction motor. It is made up of stacked steel laminations with axially cut slots for winding. The winding in BLDC are slightly different than that of the traditional induction motor.
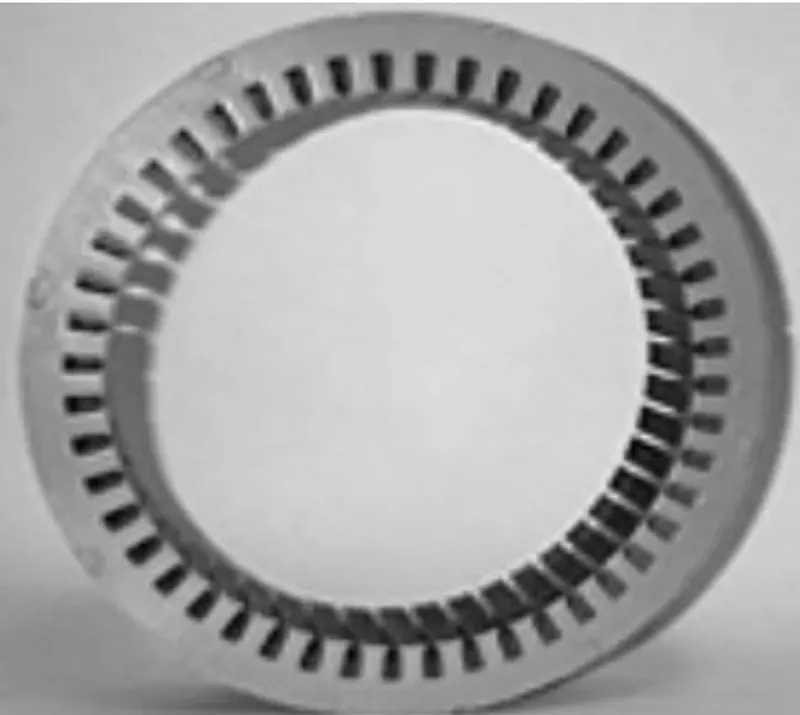
Generally, most BLDC motors consists of three stator windings that are connected in star or ‘Y’ fashion (without a neutral point). Additionally, based on the coil interconnections, the stator windings are further divided into Trapezoidal and Sinusoidal Motors.
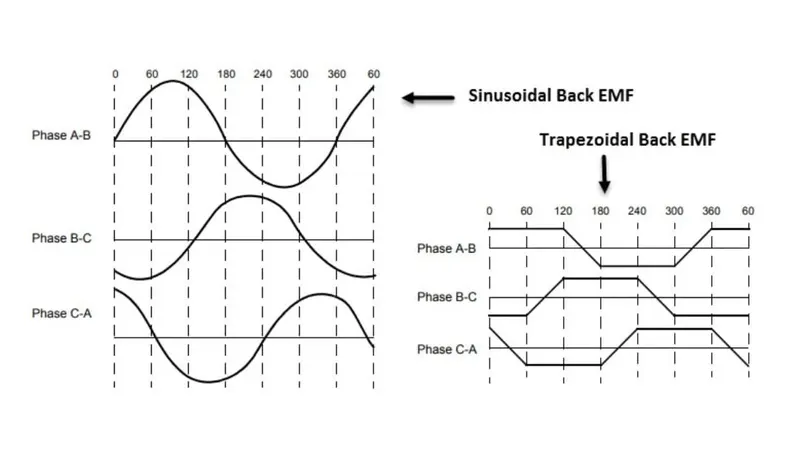
In a trapezoidal motor, both the drive current and the back EMF are in the shape of a trapezoid (sinusoidal shape in case of sinusoidal motors). Usually, 48 V (or less) rated motors are used in automotive and robotics (hybrid cars and robotic arms).
Rotor
The rotor part of the BLDC Motor is made up of permanent magnets (usually, rare earth alloy magnets like Neodymium (Nd), Samarium Cobalt (SmCo) and alloy of Neodymium, Ferrite and Boron (NdFeB)).
Based on the application, the number of poles can vary between two and eight with North (N) and South (S) poles placed alternately. The following image shows three different arrangements of the poles. In the first case, the magnets are placed on the outer periphery of the rotor.
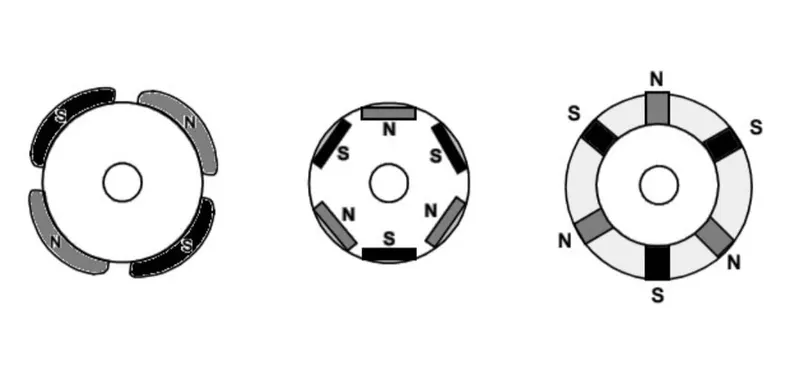
The second configuration is called magnetic-embedded rotor, where rectangular permanent magnets are embedded into the core of the rotor. In the third case, the magnets are inserted into the iron core of the rotor.
Position Sensors (Hall Sensors)
Since there are no brushes in a BLDC Motor, the commutation is controlled electronically. In order to rotate the motor, the windings of the stator must be energized in a sequence and the position of the rotor (i.e. the North and South poles of the rotor) must be known to precisely energize a particular set of stator windings.
A Position Sensor, which is usually a Hall Sensor (that works on the principle of Hall Effect) is generally used to detect the position of the rotor and transform it into an electrical signal. Most BLDC Motors use three Hall Sensors that are embedded into the stator to sense the rotor’s position.
The output of the Hall Sensor will be either HIGH or LOW depending on whether the North or South pole of the rotor passes near it. By combining the results from the three sensors, the exact sequence of energizing can be determined.
Working of Brushless DC motor(BLDC):-
Consider the following setup of three windings in the stator designated A, B and C. For the sake of understanding, let us replace the rotor with a single magnet.
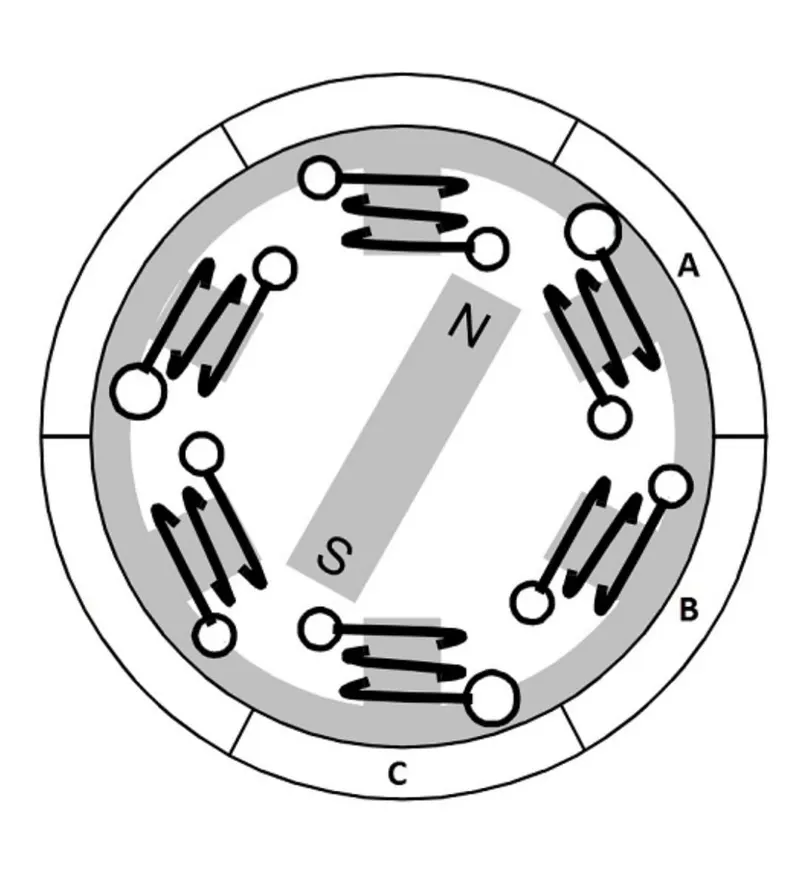
We know that when a current is applied through a coil, a magnetic field is generated and the orientation of the field lines i.e. the poles of the generated magnet will depend on the direction of the current flowing through the coil.
Using this principle, if we supply current to the coil A so that it will generate a magnetic field and attract the rotor magnet. The position of the rotor magnet will shift slightly clockwise and will align with A.
If we now pass current through coils B and C one after the other (in that order), the rotor magnet will rotate in clock wise direction.
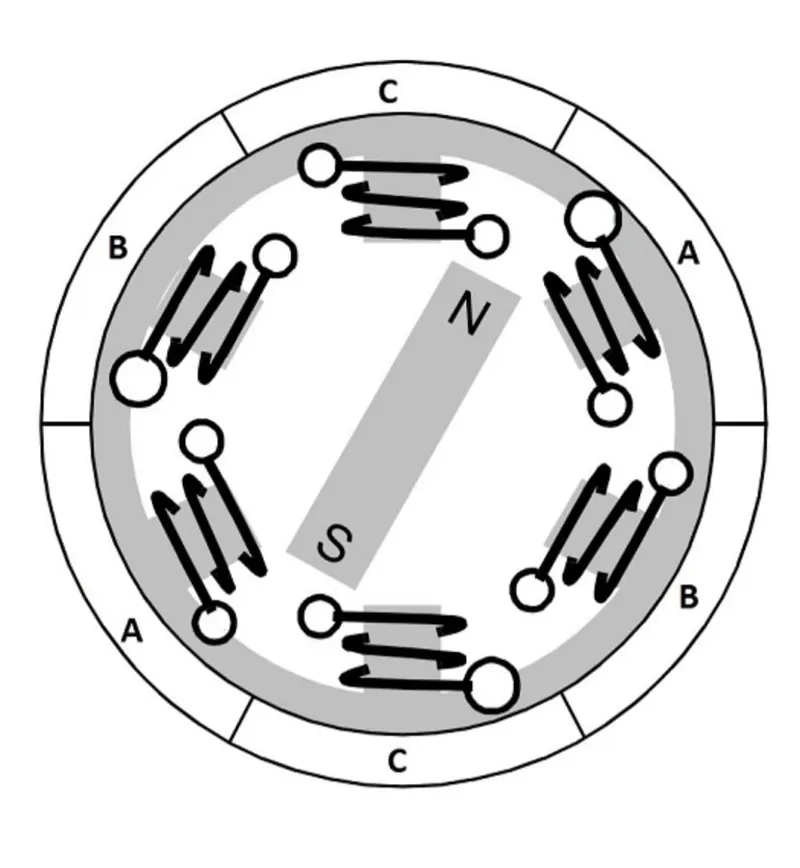
To increase efficiency, we can wind the opposite coils using a single coil so that we get double attraction. Further increasing the efficiency, we can energize two coils at the same time so that one coil will attract the magnet and the other coil will repel it. During this time, the third will be idle.
For a complete 360 deg rotation of the rotor magnet, six possible combinations of the coils A, B and C are applicable and are shown in the following timing diagram.
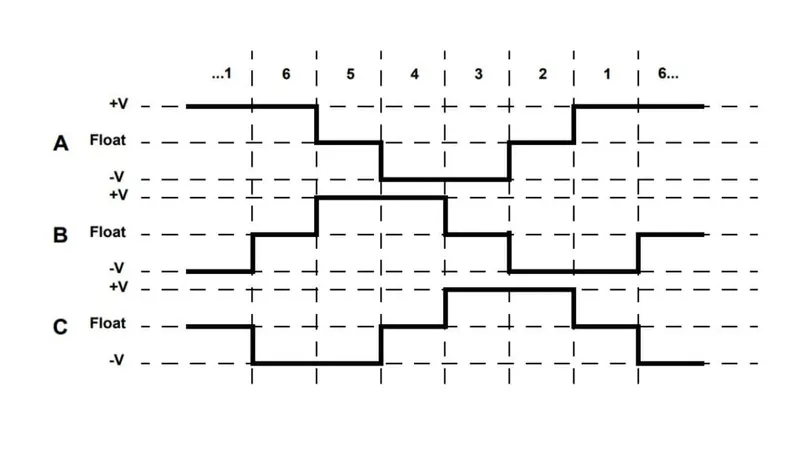
Base on the above diagram, we can confirm that at any time, one phase is positive, one phase is negative and the third phase is idle (or floating). So, based on the inputs from the Hall Sensors, we have two switch the phases as per the above diagram.
Driving Brushless DC Motors
If stator and rotor are essential parts of a BLDC Motor that are integral to it, then the driving electronics are equally essential. Block diagram of a typical Brushless DC Motor control or drive system is shown in the following image.
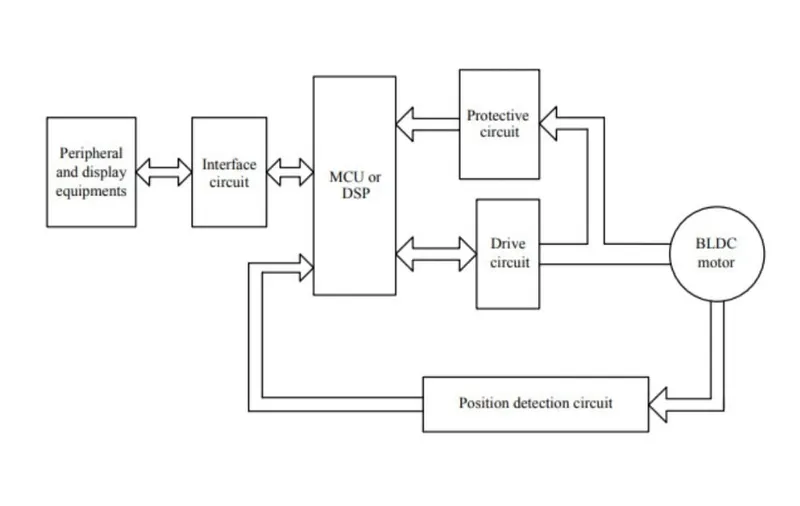
This drive circuitry is often known as Electronic Speed Controller System or simply an ESC. One common setup is called the Full Bridge Drive Circuit. It consists of an MCU with PWM outputs, six MOSFETS for the three phases of the stator windings, feedback from the Hall sensors and some power supply related components.
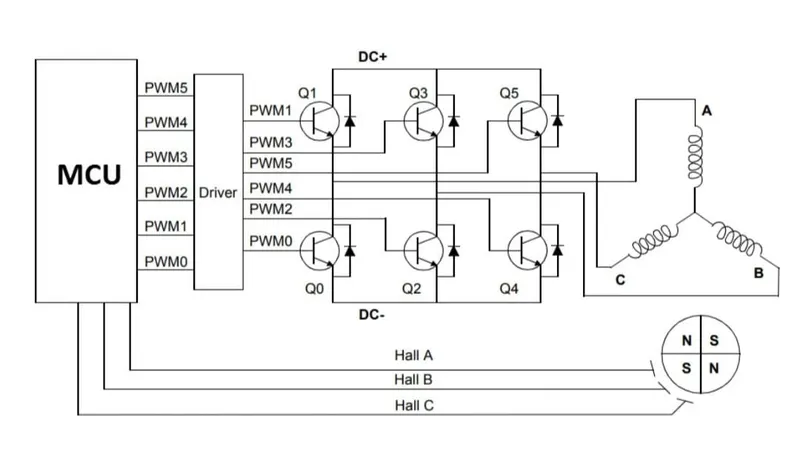
The MCU can be programmed to appropriately switch the MOSFETS based on the data from the Hall Sensors.
Benefits of Brushless DC motor(BLDC):-
1) Less overall maintenace due to absence of brushes.
2) This motor give Higher speed range and lower electric noise generation.
3) High efficiency because no losses in the brushes.
4) Low noise due to absence of brushes.
5) Smaller and lighter.
6) Long life.
Disadvantages of Brushless DC motor(BLDC):-
1) These motors are Costly, Because Electronic controller required control this motor is expensive.
2) Need of additional sensors.
3) Required complex drive circuitry.
Application of Brushless DC motor(BLDC):-
- Some of the areas of applications of BLDC Motors are mentioned below:
1. Single speed applications.
2. Adjustable speed applications.
3. Position control.
4. Low noise applications.
5. High speed applications.
6. Brushless DC motor(BLDC) use for a wide varity of use requirements such as varing loads. constant load and positining application in the field of industries control, automotive.automation system etc.
i. In Automotive Industries:-
This BLDC motor used in Electrical Vehicles, Hybrid Vehicles and Electric bicycles.
ii. In Automation System Industries:-
This BLDC motor used in Industries robots, CNC machine tool, and simple belt driven systems.