Week-6 Challenge: EV Drivetrain
1. Power Electronic Converters used in EVs and HEVs
In an ELectric Vehicle wheels are coupled with Electric Motor powered by a Battery Storage. In a Hybrid Electric Vehicle, wheels are powered by both IC engine and Electric Motor with battery storage. By the way of mechanical coupling of Motor and IC engines to the wheels, HEVs are classified into Series, Prallel and Series-Parallel HEVs.
According to the article "Induction Versus DC brushless motors by Wally Rippel, Tesla", Induction Motors will be mostly used by EVs and HEVs will mostly used DC Brushless Motors. Hence, DC-DC converter will be only used in HEVs to provide electrical power between battery and DC motor. In EVs AC-DC converter used to charge battery from external AC supply and charge batteries during regeneration by motor. DC- DC converter used to charge battery from external DC charger, regulate DC voltage. DC- AC converter used to power motor from battery.
- AC-DC converters/ Rectifiers: Converts AC power to DC power
- DC-DC Converters
- Buck Converter: Output DC voltage is equal to or less than input DC voltage
- Boost Converter: Output DC voltage is equal to or greater than input DC voltage
- Buck-Boost Converter: Output DC voltage is equal to or greater than or les than input DC voltage
- DC-AC converters/ Inverters: Converts DC power to AC power. Single phase and Three phase inverters
2. EV steady state speed
Given Torque, `T = 24.7 + (0.0051)omega^2`
Torque equation of a DC motor is `T = 1/R_a[V.K phi - omega(Kphi)^2]`
A step-up chopper function will be there for acceleration.
`V_m: Motor input voltage or Chopper output voltage
`V_(bat)`: Battery voltage
`D`: Duty Cycle
Thus, `V_m = V_(bat)/ D`
= 72/0.7
= 102.85 V
Therefore, `T = 1/0.5[102.85 * 0.7 - omega*0.7^2]`
`= 2*[72-0.49omega]`
`= 144 - 0.98omega`
`24.7 + (0.0051)omega^2 = 144 - 0.98omega`
`(0.0051)omega^2 + 0.98omega-119.3=0`
Value of `omega`can be obtained using quadratic equation `omega = (-0.98 +- sqrt(0.98^2-4*0.0051*(-119.3)))/(2*0.0051)`
`omega = (-0.98 +- sqrt(3.393))/(0.0102)`
`omega = (-0.98 + 1.84)/0.0102; omega = (-0.98 - 1.84)/0.0102`
`omega = 84; omega = -276.47`
We have considered acceleration and hence, `omega = 84 (rad)/(sec)`
3. Mathematical model of DC motor using MATLAB Simulink
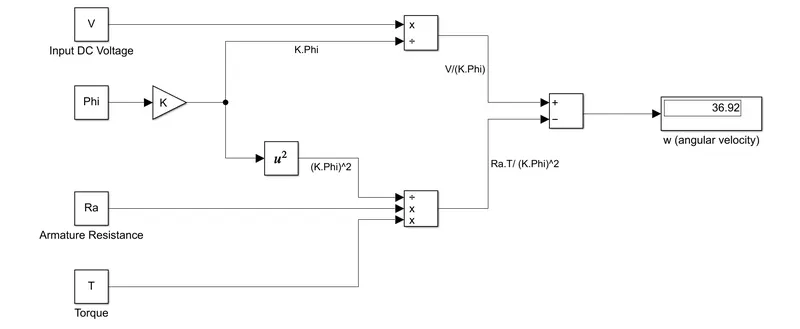
Constant, Square, Multiply and Add blocks used to create the mathematical model of DC Motor as shown below for the equation: `omega = V/(K.phi)-R_a/(K.Phi)^2 T`
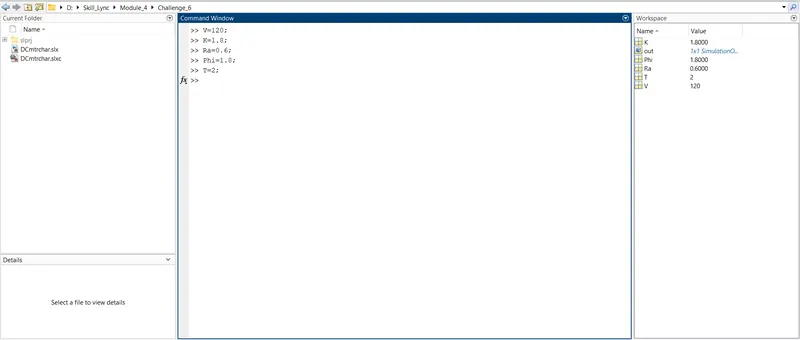
Values of constant variables given as shown below to display the result
4. Induction Motor Vs DC Brushless Motors
Wally Rippel has long been an advocate for electric vehicles. He starts his comparison between Induction Motor and DC Brushless motor by saying "one size doesn't fit all". In case of IC engines, different types of them were evolved. Among them there is an optimum and efficient one. Even then, the types of them used varied according to Size, Cost, Power etc. Similar to these there are good and bad for Induction Motor as well as DC Brushless Motors. But, their usage varies according to the application needed. Author says that in olden days Lead acid batteries and DC brush motors were there. Now they have been replaced with Li-ion batttery and DC brushless and Induction Motors. In future, these also can be replaced or not.
Windings of DC Brushless motor (DCBM) and Induction motors (IM) are almost similar having three sets of distributed windings. In DCBM, rotor is a permanent magnet and in IM there are stacked steel laminations formed like a short circuit. Speed of the IM will be according to the frequency of the supply provided. Hence the speed will be constant normally. For the speed below rated speed can be varied by varying voltage and speed aboce rated speed can be varied by varying frequency. The primary factor influencing the success of induction motors is that they are readily compatible with conventional utility power. When directly connected to utility electricity with a set frequency, a brushless DC motor doesn't generate any initial torque. They truly require the assistance of an inverter whose "phase" is kept in step with the rotor's angular position.
When directly connected to utility electricity with a set frequency, a brushless DC motor doesn't generate any initial torque. They truly require the assistance of an inverter whose "phase" is kept in step with the rotor's angular position. By using an inverter, IMs can be operated in DC and by varying frequency speed can be varied but still the torque performance is less compared to DCBM.
Both motors are driven by 3-phase modulating inverters. The inverter controls and the rotors are the only modifications. The only control variations with digital controllers are in the control code.
The DC brushless drive generates significantly less rotor heat and has a higher peak point efficiency. It can also operate at unity power factor, whereas the induction drive's best power factor is around 85%. This means that a DC brushless drive's peak point energy efficiency will typically be a few percentage points higher than an induction drive's.
As the size increases the magnetic field loss increases for DCBM as well as the cost of the motor is also higher for DCBM compared to IM. Overall comparison author says that we can't judge the better one. Both have good performance in their said application. The application will be like HEVs will be mostly with DCBMs and Pure EVs will be go with IMs.