Week-6 Challenge: EV Drivetrain
1.
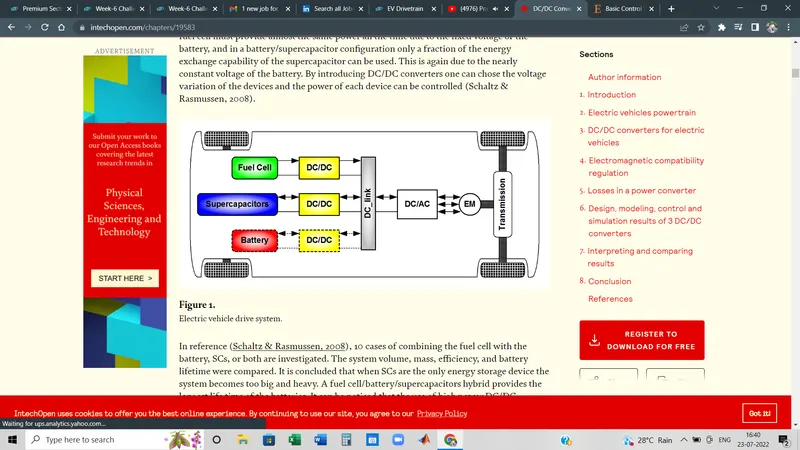
Basically there are 3 types of Power converters are used in Electric and Hybrid vehicles and those are folowing.
- AC to DC converter : Rectifier: It converts AC to unipolar (DC) current
- DC to DC converter : Chopper: It converts constant to variable DC or variable DC to constant DC
- DC to AC converter : Inverter: It converts DC to AC of desired frequency and voltage
AC to DC converter:
An AC to DC converter is also called a rectifier, which converts AC supply from main lines to DC supply for the load. The block diagram of an AC to DC converter is shown in figure below.
The essential components in this rectifier include transformer, switching unit, filter and a control block.
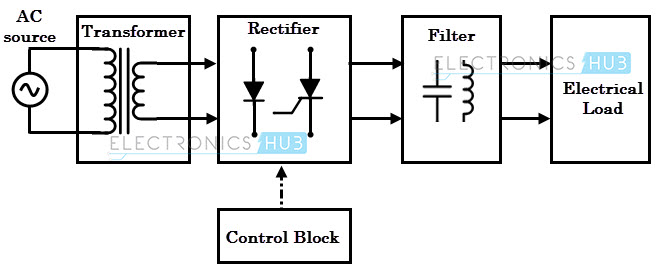
Here, the transformer adjusts the primary AC source supply to the input of rectifier stage. Usually it is a step-down transformer that reduces the supply voltage to a circuit operating range.
The rectifier converts the low voltage AC supply into DC supply.
It comprises diode and/or thyristors based on type of rectifier. The output of the rectifier is of pulsed DC and hence it is filtered using filter circuit, which is usually made with a capacitor or a choke.
The control block controls the firing angle of thyristors in case of phase controlled rectifiers. Since the diode is not a controllable device, control block is not needed in case of diode rectifiers.
Rectifiers are majorly classified into two types
- Uncontrolled diode rectifiers
- Controlled rectifiers
Uncontrolled Diode Rectifiers
This type of rectifier converts AC voltage from mains into a fixed DC voltage.
Since the diodes are uncontrollable components (which do not require any triggering), these converters are called as uncontrolled converters as they produce a fixed voltage. The input voltage can be either single phase or three-phase.
The diode rectifiers are classified into following types.
- Single phase half wave rectifier :
The half wave rectifier is a type of rectifier that rectifies only half cycle of the waveform. This article describes the half wave rectifier circuit working. The half rectifier consist a step down transformer, a diode connected to the transformer and a load resistance connected to the cathode end of the diode. The circuit diagram of half wave transformer is shown below:
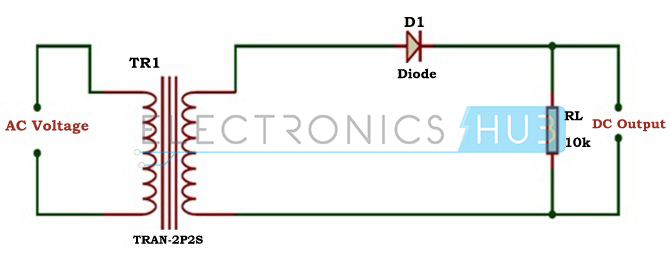
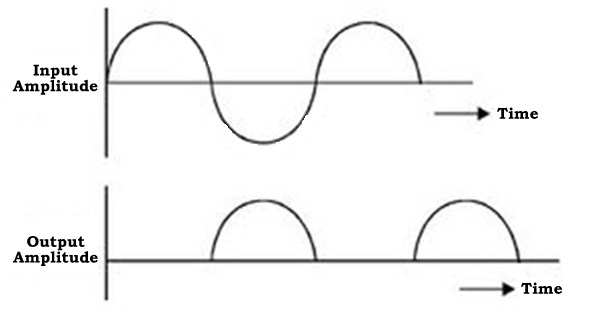
The main supply voltage is given to the transformer which will increase or decrease the voltage and give to the diode. In most of the cases we will decrease the supply voltage by using the step down transformer here also the output of the step down transformer will be in AC. This decreased AC voltage is given to the diode which is connected serial to the secondary winding of the transformer, diode is electronic component which will allow only the forward bias current and will not allow the reverse bias current. From the diode we will get the pulsating DC and give to the load resistance RL.
2. Single phase centre tapped full wave rectifier :
Center tap is the contact made at the middle of the winding of the transformer.
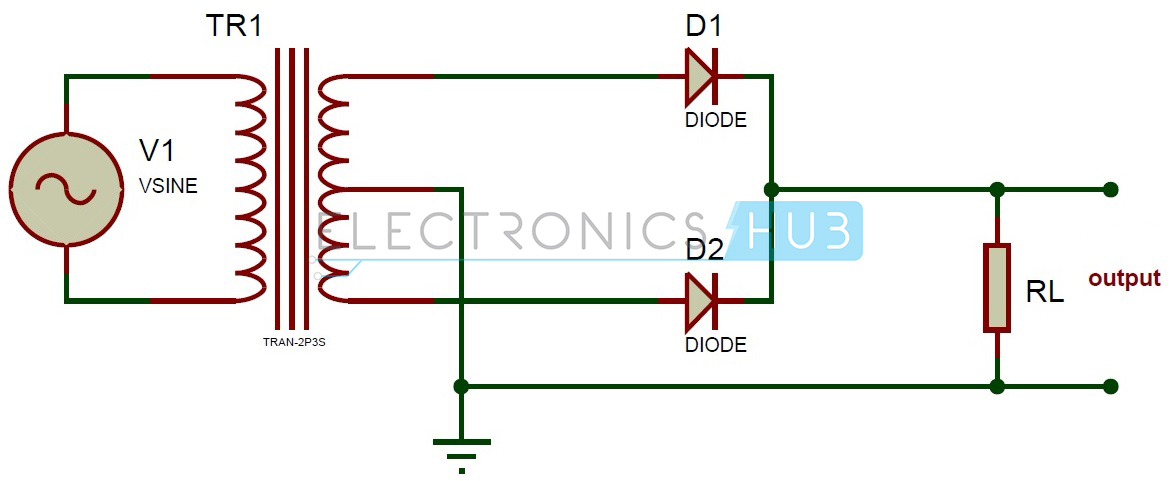
In the center tapped full wave rectifier two diodes were used. These are connected to the center tapped secondary winding of the transformer. Above circuit diagram shows the center tapped full wave rectifier. It has two diodes. The positive terminal of two diodes is connected to the two ends of the transformer. Center tap divides the total secondary voltage into equal parts.
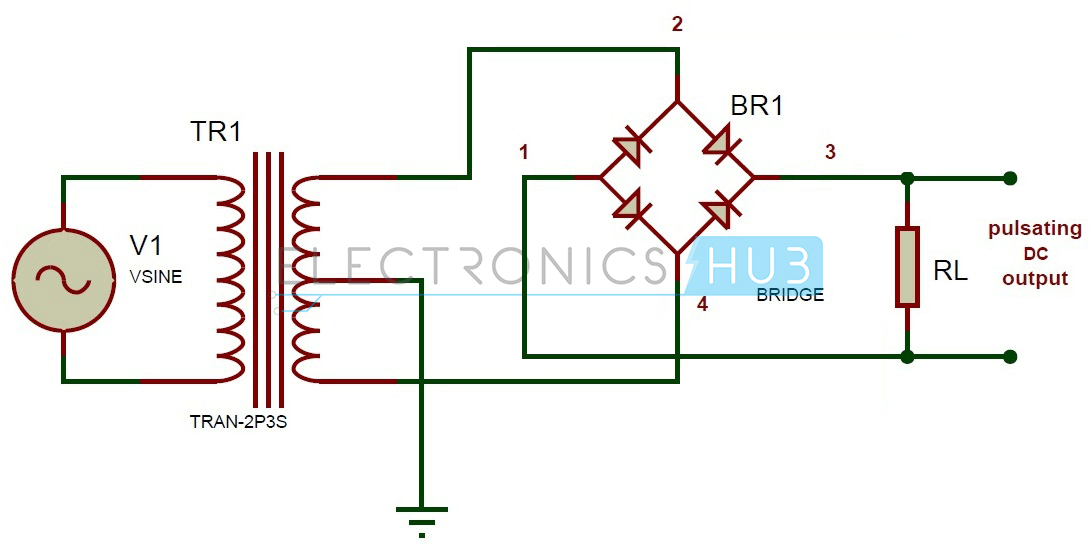
3. Single phase full wave bridge rectifier :
In bridge rectifier four diodes are used. These are connected as shown in the circuit diagram. The four diodes are connected in the form of a bridge to the transformer and the load as shown.
4. Three-phase Half-wave diode rectifier:
It employs three diodes and its anode terminals are connected to three phase source via transformer as shown in figure. The load is connected between the common cathode point and neutral terminal of star connected source.

When R-phase is at its peak value, maximum conduction occurs through diode D1 as it is forward biased and no conduction takes place through it during negative alteration of phase R. During Y-phase and B-phase maximum values, other two diodes conduct in a similar manner.
The main disadvantage of this rectifier is that the secondary winding consists of DC component of current which can cause the transformer core to go under saturation problem.
Therefore, it is not advisable to use three-phase half-wave rectifier for large power applications.
5. Three-phase full-wave diode bridge rectifier :
This type of rectifiers is suitable for high power applications, typically the power output higher than 15KW. The circuit of full-wave diode bridge rectifier is shown in figure below.
It requires six diodes for the operation of the circuit. This type of circuit doesn’t need any neutral connection from three phase source therefore, a star as well as delta-connected sources can be used.
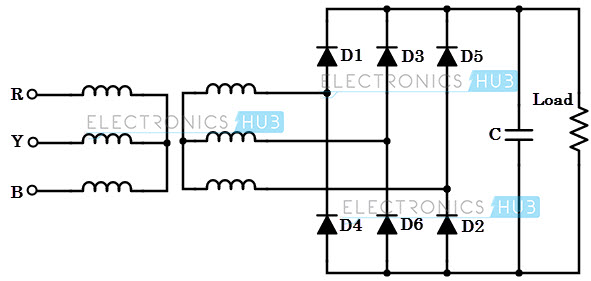
Here the output current flows through one diode of the upper group and one diode of lower group of diodes. If anode of a diode is at high potential, this upper group diode will conduct while other two diodes are reversed biased.
Similarly, the diode having the cathode at lower potential will conduct while other two diodes are off. The diode pair’s conduction for above circuit is given as D6 D1, D1 D2, D2 D3, D3 D4, D4 D5 and D6 D1.
Since, one diode from upper group and one diode from lower group are always conducting; negative members of three- phase voltages are rectified, so the output voltage consists of six segments of line voltage during one cycle.
For this reason, three phase bridge rectifiers are called as six pulse rectifiers.
These are efficient rectifier as compared to half-wave converters. Due to six pulse output, ripple content in the output is very low, typically about 4.5%.
This avoids the additional filter circuit in many high power applications. Even it a filter is required, a small sized filter is enough because of increase in ripple frequency to six times the input frequency.
Phase Controlled Rectifiers
These are similar to the uncontrolled rectifiers but the only difference is that the uncontrolled diodes are replaced by controlled thyristor family of devices such as SCRs.
These are also called as phase controlled rectifiers. Unlike diodes, thyristors can be controlled by triggering them at desired instants in order to vary the output voltage.
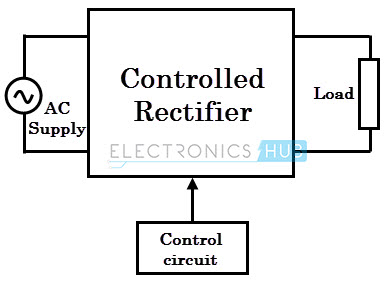
The block diagram of a controlled rectifier is shown in the above figure that transfers the DC power to the load in a control manner by varying triggering angle of thyristors (by the control circuit) using different technologies such as a microprocessor or microcontroller based techniques.
The start of thyristor conduction varies the average value of output voltage of the converter. Similar to the uncontrolled rectifier types, these thyristor based converters are also classified into following types.
6. Three-phase half-wave converter :
The output from single phase converter is small; when high power is required, three phase rectifiers are used. A three-phase half-wave rectifier with thyristors is shown in figure below.
The three-phase supply is given to this converter through a three-phase transformer with star connected secondary.
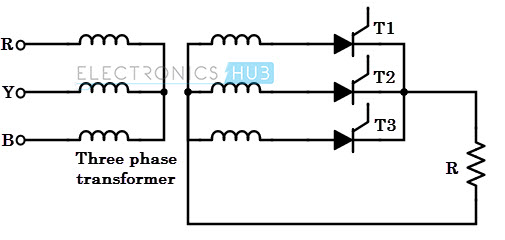
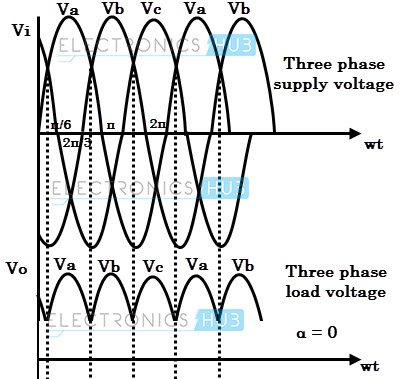
It works as similar to the three-phase diode bridge rectifier. In this, thyristor T1 is at highest positive anode voltage in the interval π/6 to 5π/6. During this interval, T1 can be made to conduct by giving a firing pulse to its gate.
This thyristor T1 continues to conduct till thyristor T2 is made to conduct in the interval 5π/6 < wt < 3π/2. Now the load current starts flowing through T2. Similarly, thyristor T3 is starts conducting once thyristor T2 is turned OFF.
In this, there are three pulses of output voltage during each complete cycle of supply voltage. Thus the ripple frequency is three times the supply frequency.
For this reason, this converter is also called as 3-pulse converter. This converter can be connected to different loads such as RL and RLE loads.
7. Three-phase full wave converter :
It is obtained by connecting a DC terminal of two three-pulse converters in series. It is also called as 6-pulse bridge converter. This type converter is used in industrial applications where two-quadrant operation is required.
Here the load is connected via a three-phase half wave connection to one of three supply lines. Thus, there is no need of transformer; however, for isolation purpose a transformer is connected as shown in figure.
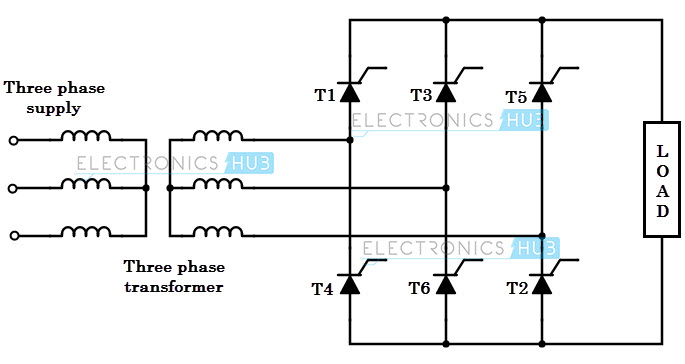
Here thyristors T1, T3 and T5 forms a positive group, whereas thyristors T4, T6 and T2 forms a negative group. And thus positive group SCRs are turned ON for positive supply voltage and negative group thyristors are turned ON for negative supply voltages.
In this, one of the thyristors from positive, whose anode voltage is maximum positive will conduct at any instant and simultaneously one of the thyristors from negative group, whose cathode voltage is maximum negative will conduct.
This converter can be connected to RL or RLE loads. By controlling the firing angle to respective thyristor, average power delivered to the load is changed.
The firing angle of particular thyristor in positive group measured from the instant when its anode becomes maximum positive.
Similarly, the firing angle for a thyristor in negative group is measured from the instant when its cathode terminal attains a maximum negative value.
DC to DC converter:
Many DC operated applications need different levels of DC voltage from a fixed DC source.
Some of these applications include subway cars, DC traction systems, control of large DC motors, battery operated vehicles, trolley buses, etc. They require variable DC to produce variable speed, so a power conversion device is needed.
A DC chopper is a static device that converts a fixed input DC voltage to variable DC output or a fixed DC output of different magnitude (which can be lower or higher) than input value. The block diagram of a DC chopper is shown in figure below.
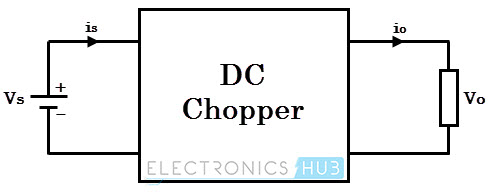
The chopper circuit is connected between DC input source and DC load. This chopper consists of power electronic switching devices such as thyristors which are connected in such a way that they produce required DC voltage to the load.
The output voltage is controlled by adjusting ON time of the thyristor (or switch) which turn changes the width of DC voltage pulse at the output. This method of switching is called as pulse width modulation (PWM) control.
The output of the chopper can be less or greater than the input and also it can be fixed or variable. These can be unidirectional or bidirectional devices based on the application it is intended for.
DC choppers are mainly used in DC drives, i.e., electric vehicles and hybrid electric vehicles.
DC choppers are classified into three basic types based on input and output voltage levels and are discussed below.
Step-down Chopper or Buck converter
A step-down chopper produces an average output voltage lower than the input DC voltage. The circuit for this converter is shown in figure below.
Here the switching component is a thyristor that switches the input voltage to the load when it is triggered at particular instants.
A diode acts as a free wheeling diode that allows the load current to flow through it when thyristor is turned OFF. If this diode is absent, a high induced EMF in inductance may cause damage to the switching device.
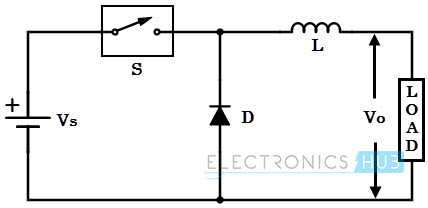
The average output voltage of the converter is varied by controlling turn ON/OFF periods of thyristor. When thyristor is turned ON, the output voltage is same as the input voltage and if it is turned OFF, the output voltage is zero.
The output voltage is equal to (TON / T) Vin. So, by controlling the duty ratio K = (TON / T), the output voltage will be increased.
Step-up Chopper or Boost converter
In this chopper, the output voltage is always greater than input voltage. The configuration of a boost converter is shown in figure below.
Here also a switch is used, which is connected in parallel with the load. This switch is a thyristor or an SCR.
As similar to the buck converter, a diode is placed in series with the load that allows the load current to flow when the thyristor is turned OFF.
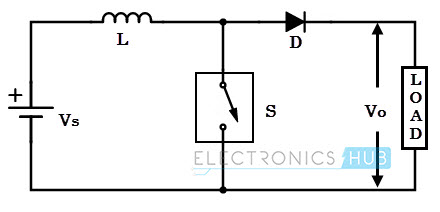
When the thyristor is turned ON, the diode is reverse-biased and hence it isolates the load circuit from the source. So the inductor charges to the maximum input voltage source.
When the thyristor is turned OFF, the load gets the voltage from input as well as from inductor. So the voltage appearing across the converter output will be more than the input.
Here the output voltage is equal to (1/ 1 – d) times the input voltage, where d is the duty ratio (TON / T). By varying this duty ratio, the output voltage will be varied till the load gets desired voltage.
Buck/Boost converter
This chopper can be used both in step-down and step-up modes by continuously adjusting its duty cycle. The configuration of buck-boost converter is shown in figure below that consists of only one switching device, i.e., one thyristor.
Along with an inductor and diode, additional capacitor is connected in parallel with this circuit.
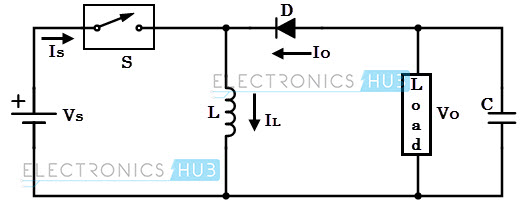
When the thyristor is turned ON, the supply current flows to the inductor through the thyristor and induces the voltage in inductor.
When the thyristor is OFF, the current in the inductor tends to decrease with the induced emf reversing polarity. The output voltage of this converter remains constant as capacitor is connected across the load.
By varying the value of duty ratio to a certain value, the output voltage is lower than the input voltage, typically in the range 0 ≥ k > 0.5, thus a buck converter.
And the output is higher than the input voltage if the duty ratio is in the range of 0.5 > K ≥ 1, thus acts as a boost converter.
DC to AC converter:
These converters are connected between DC source of fixed input, and variable AC load. Most commonly, these DC to AC converter are called as inverters. An inverter is a static device that converts fixed DC supply voltage to variable AC voltage.
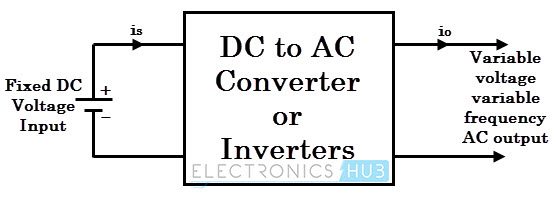
Here the fixed DC voltage is obtained from batteries or by DC link in most power electronic converter. The output of the inverter can be variable/ fixed AC voltage with variable/fixed frequency.
This conversion from DC to AC along with variable supply is produced by varying the triggering angle to the thyristors. Most of the thyristors used in inverters are employed with forced commutation technique.
These can be single phase or three phase inverter depending on the supply voltage. These converters are mainly divided into two groups. One is PWM based inverters and other multilevel inverters.
Further, these are classified voltage source inverter and current source inverter. Each type is subdivided into different types such as PWM, SVPWM, etc. Multilevel inverters are more popular in industrial applications.
The inverters overcome the drawbacks of PWM based inverters.
2.
Given,
Rated Armature voltage= 72 V
Rated armature current= 400 A
Armature Resistance(Ra)= 0.5Ω
Motor constant(KΦ)= 0.7 Volt second
Chopper Switching frequency= 400 Hz
Duty cycle=70%=0.7
Battery pack voltage(Supply voltage)= 72 volt.
So,
Vehicle voltage=72*d = 72*0.7 = 50.4 volt
Vehicle voltage = 50.4 volt.
We know,
Vehicle torque eqn : T = (V*kϕ/Ra) - (kϕ^2/Ra)*ω -----------(1)
where.
T= Torque
V= Vehicle voltage
ω= angular velocity
Ra= Armature Resistance
kϕ=Motor constant
by putting the values in (eqn-1)
T= (50.4*0.7/0.5) - ((0.7^2)/0.5)*ω
T= 70.56 - 0.98ω^2 -------------------(2)
In the question itself, given the vehicle speed-torque characteristics eqn
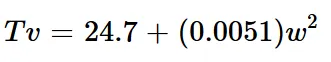 ---------------(3)
So, Eqn-2 = Eqn-3
or, 70.56 - 0.98ω^2 = 24.7 - 0.0051ω^2
`or, 0.0051ω^2+0.98ω^2-45.85=`0
By using the Quardic eqn formula, we get
ω = 38.92
So the steady state speed of the vehicle is = 38.92 rad/sec.
3.
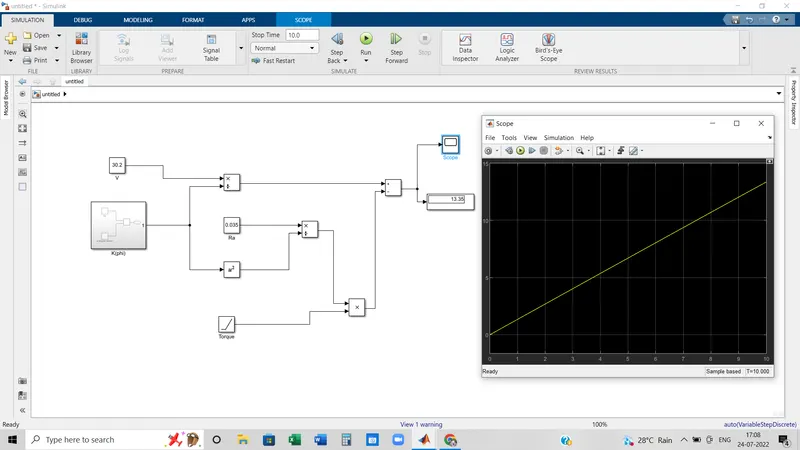
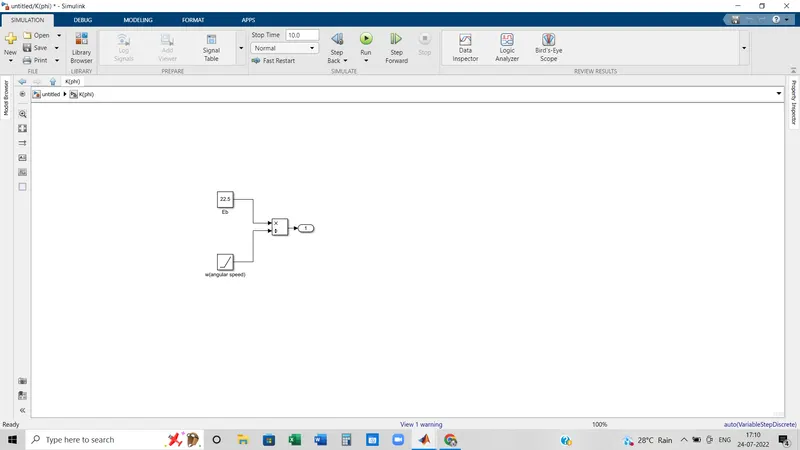
Kϕ sub-system:
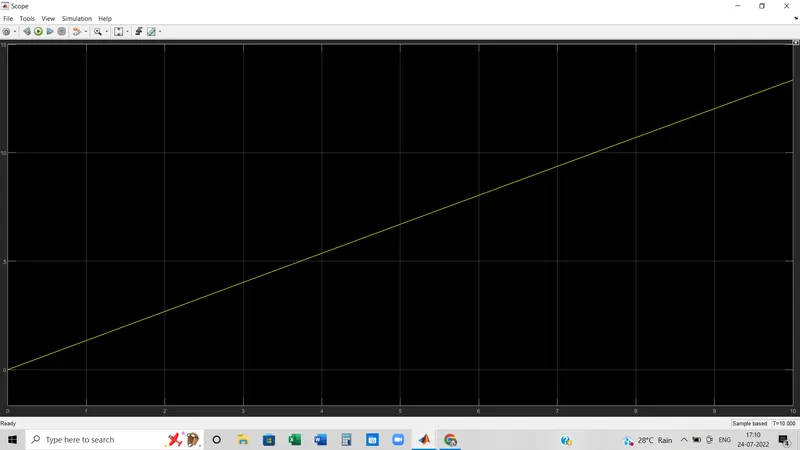
Scope:
4.
First of all the author describe a little history before the EV or hybrid or plug-in hybrid came into human thought. In his words I had hair on my head and carried a slide rule, there were lead acid batteries, DC brush motors, and contactor controllers. Today, none of these remain (including my hair). Lead has been replaced by Lithium and DC by either DC brushless or induction. Contactors, meanwhile, have given way to modulating inverters. So, will each of these elements also become obsolete in the near future or is it possible that some “stability” may be at hand? Without a good crystal ball, it is hard to predict the future. My guess, however, is that we will see both induction and brushless machines “duke it out” for many years to come. Each will have its loyal proponents and religious detractors.
DC Brushless Motor:
With Brushless machine, the rotor includes two or more permanent magnets that generate a DC magnetic field (as seen from the vantage point of the rotor). In turn, this magnetic field enters the stator core (a core made up of thin, stacked laminations) and interacts with currents flowing within the windings to produce a torque interaction between the rotor and stator. As the rotor rotates, it is necessary that the magnitude and polarity of the stator currents be continuously varied – and in just the right way - such that the torque remains constant and the conversion of electrical to mechanical energy is optimally efficient. The device that provides this current control is called an inverter. Without it, brushless motors are useless motors
Advantage:
- Much less rotor heat is generated with the DC brushless drive.
- Rotor cooling is easier and peak point efficiency is generally higher for this drive.
- The DC brushless drive can also operate at unity power factor, whereas the best power factor for the induction drive is about 85 percent. This means that the peak point energy efficiency for a DC brushless drive will typically be a few percentage points higher than for an induction drive.
Disadvantage:
- With DC brushless, as machine size grows, the magnetic losses increase proportionately and part load efficiency drops.
- Peak efficiency will be a little less than with DC brushless.
- Permanent magnets are expensive – something like $50 per kilogram. This means that induction motors will likely retain a cost advantage over PM machines.
- Permanent magnet (PM) rotors are also difficult to handle due to very large forces that come into play when anything ferromagnetic gets close to them.
Induction Motor:
3 phase Induction Motor was invented by Nikola Tesla sometime before 1889. Curiously, the stators for the 3-phase induction motor and the DC brushless motor are virtually identical. Both have three sets of “distributed windings” that are inserted within the stator core. The essential difference between the two machines is with the rotor.
Unlike the DC brushless rotor, the induction rotor has no magnets – just stacked steel laminations with buried peripheral conductors that form a “shorted structure.” Currents flowing in the stator windings produce a rotating magnetic field that enters the rotor. In turn, the frequency of this magnetic field as “seen” by the rotor is equal to the difference between the applied electrical frequency and the rotational “frequency” of the rotor itself. Accordingly, an induced voltage exists across the shorted structure that is proportionate to this speed difference between the rotor and electrical frequency. In response to this voltage, currents are produced within the rotor conductors that are approximately proportionate to the voltage, hence the speed difference. Finally, these currents interact with the original magnetic field to produce forces – a component of which is the desired rotor torque.
When a 3-phase induction motor is connected to utility type 3-phase power, torque is produced at the outset; the motor has the ability to start under load. No inverter is needed. (Were an inverter needed, Tesla’s invention would have been useless until sometime in the 1960s.) The fact that induction motors are directly compatible with conventional utility power is the main reason for their success.
Advantage:
- Induction machines have no magnets and B fields are “adjustable,” since B is proportionate to V/f (voltage to frequency). This means that at light loads the inverter can reduce voltage such that magnetic losses are reduced and efficiency is maximized. Thus, the induction machine when operated with a smart inverter has an advantage over a DC brushless machine – magnetic and conduction losses can be traded such that efficiency is optimized. This advantage becomes increasingly important as performance is increased.
- With DC brushless, as machine size grows, the magnetic losses increase proportionately and part load efficiency drops. With induction, as machine size grows, losses do not necessarily grow. Thus, induction drives may be the favored approach where high-performance is desired.
- Average efficiency is better than DC brushless machine.
Disadvantage:
- They cannot operate from DC; AC is a must.
- Shaft speed is proportionate to line frequency. Hence, when used with utility power, they are constant speed machines. Finally, when operated from utility power, they have limited starting torque and somewhat limited running peak torque capabilities, when compared to DC-type machines.
- Induction machines are more difficult to control. The control laws are more complex and difficult to understand. Achieving stability over the entire torque-speed range and over temperature is more difficult with induction than with DC brushless.
Inference:
The author wrote DC brushless drive will dominate in hybrid and plug-in hybrid but induction motor will dominate pure electric vehicle.