Week-6 Challenge: EV Drivetrain
Aim 1:
Which types of power converter circuits are employed in electric and hybrid electric vehicles?
Solution:
Introduction to Power Electronic Converters:- Power electronic technology deals with processing and
controlling the flow of electrical energy in order to supply voltages and currents in a form that
optimally suited for end user's requirements.
A power electronic converter uses power electronic components such as SCRs, TRIACs, IGBTs, etc.
to control and convert the electric power. The main aim of the converter is to produce conditoning
power with respect to a certain applications.
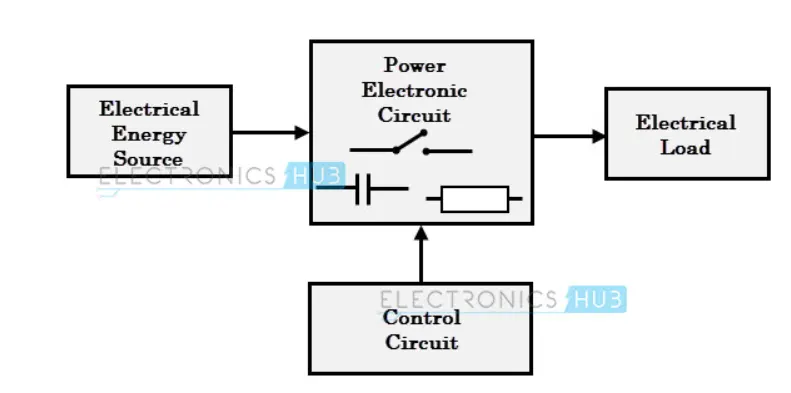
The block diagram of a power electronic converter is shown in figure above. It consists of electrical
energy source, power electronic circuit, a control circuit and an electric load. This converter changes
one form of electrical energy to other form of electrical energy.
Depending on the type of function performed, power electronic convrters are categorized into
following types:
1. AC to AC = cycloconverters , Matrix converter: It converts AC of desired frequency and/or desired
voltage magnitude from a line AC supply.
2. DC to DC = Chopper: It converts constant to variable DC or variable DC to constant DC.
3. DC to AC = Inverter: It converts DC to AC of desired frequency and voltage.
4. AC to DC = Rectifier: It converts AC to unipolar (DC) current.
1. AC to AC Converters
AC/AC converters connnects an AC source to AC loads by controlling amount of power supplied
to the load. This converters converts the AC voltage at one level to the other by varying its
magnitude as well as frequency of the supply voltage.
These are used in different types of applications including uninteruppted power supplies, high
power AC to AC transmission, adjustable speed drives, renewable energy conversions systems
and aircraft converters systems.
The types of AC to AC converters are discussed below:
A. AC/AC voltage converters:
These converters control the rms value of output voltage at a constant frequency. The common
application of these converters includes starting of AC motors and controlling power to heaters.
A single phase AC/AC voltage converters consists of a pair of anti-parallel thyristors along with
a control circuit as shown in figure below.
The other name of this controller are single phase full wave converters and AC voltage controller.
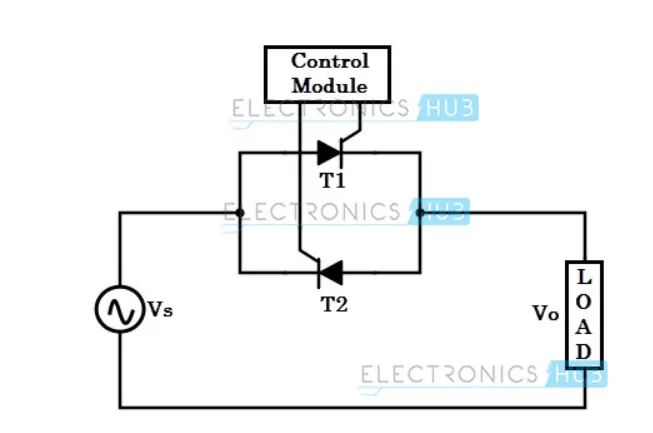
During +ve half cycle of the input signal, thyristor-1 is forward biased and it starts conducting, when
the triggering is applied. Thus the power flows from source to load.
In -ve half cycle of the input, thyristor-2 is forward biased and starts conducting when it is triggered,
while thyristor-1 is turned OFF by natural commutation.
By varying the triggering or conduction angel of each thyristor during each half cycle, the magnitude
of voltage appeared across the load is controlled.
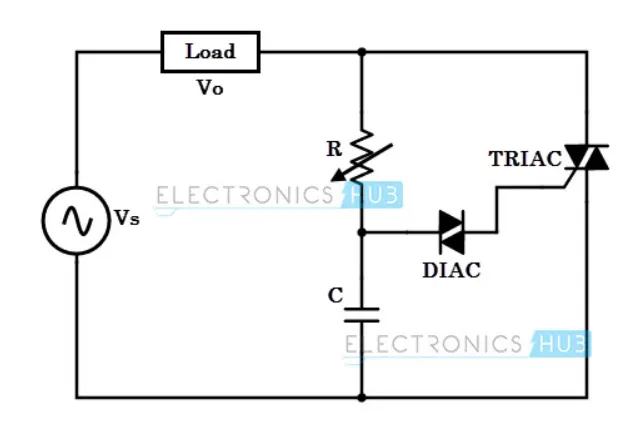
the other popular form of AC voltage controller is the use of TRIAC in place of two anti-parallel thyristor.
The figure below shows TRIAC based AC controller along with triggering control circuit.
Here diac controls the +ve nd -ve triggering to the TRIAC so that average output voltage to the load
is controlled.
B. AC/AC frequency conveters:
These converters are mainly used for varying the frequency of the input source to desird level
of the load. An AC/AC frequency converters changes the frequency of input voltage/current of
the load compared to the frequency of the source.
Some of the converters may control magnitude of voltage besides the frequency control. These
are mainly used for adjusting the speed of AC drives and also for induction heating.
The two major classes of these converters includes:
1. Cyclo converters
2. Matrix converters
Since the cyclo converters satisfactorily work only for a certain range of frequencies ,
matrix converters are invented that has unrestricted frequency conversion capability.
These are constructed using full-controlled static devices, mostly uses bidirectional
switches. With the use of these switches in 3 phase matrix converters, any phase of
the load can be connected to any phase of the input supply.
By using pulse width modulation techniques, the load frequency and voltages are controlled
from zero value to their maximum values.
2. DC to DC Converters
Many DC operated applications need different levels of DC voltage from a fixed DC source.
Some of these applicationa include subway cars, Dc traction systems, control of large DC
motors, battery operated vehicles, trolley buses, etc. They require variable DC to produce
variable speed, so a power conversion device is needed.
A DC chopper is a static device that converts a fixed input DC voltage to variable DC output
or a fixed DC output of different magnitude(which can be lower or higher) than input values.
The block diagram of a DC chopper is shown in figure below.
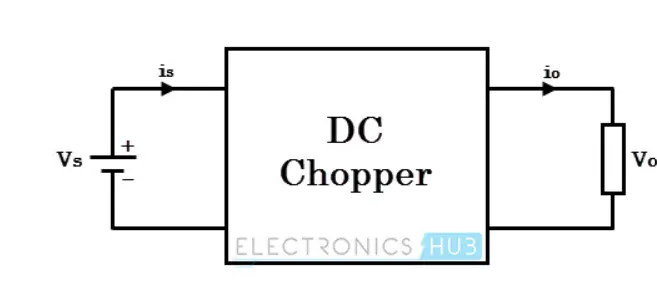
The chopper circuit is connected between DC input source and DC load. This chopper consists
of power electronic switching devices such as a thyristors which are connected in such a way that
they produce required DC voltage to the load.
The output voltage is controlled by adjusting ON time of a thyristor (or switch) which turn changes
the width of a DC voltage pulse at the output. This method of switching is called pulse width
modulation (PWM) control.
The output of the chopper can be less or greater than the input and also it can be fixed or variable.
These can be unidirectional or bidirectional devices based on the application it is intende for.
DC choppers are mainly used in DC drives, i.e., electric vehicles and hybrid electric vehicles.
DC choppers are classified into 3 basic types based on input and output voltage levels are
discussed below.
A. Step-down chopper or Buck converter
A step down chopper produces an average output voltage lower than the input DC voltage.
The circuit for this converter is shown in figure below.
Here switching components is a thyristor that switches the input voltage to the load when
it is triggered at particular instants.
A diode acts as a free wheeling diode that allows the load current to flow through it when
thyristor is turned OFF. If this diode is absent, a high induced EMF in inductance may cause
damage to the switching device.
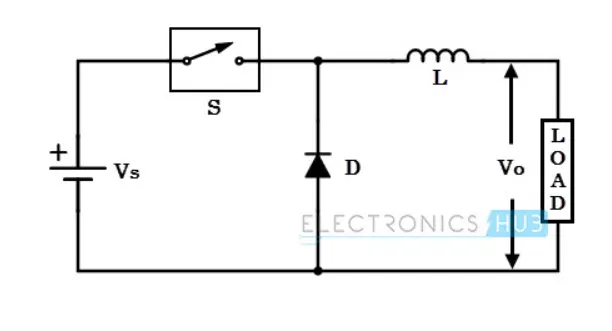
The average output voltage of the converter is varied by controlling turn ON/OFF periods of
a thyristor. When thyristor is turned ON, the output voltage is same as the input voltage
and if it is turned OFF , the output voltage is zero.
The output voltage is equal to ( TON/T) Vin. So by controlling the duty ratio k=(TON/T),the
output voltage will be increased.
B. Step-up chopper or Boost converter
In this chopper, the output voltage is always greater than input voltage. the configuration
of a boost converter is shown in figure below.
Here also a switch is used, which is connected in parallel with the load. This switch is a
thyristor or an SCR.
As similar to the buck converter, a diode is placed in series with the load that allows the
load current to flow when the thyristor is turned OFF.
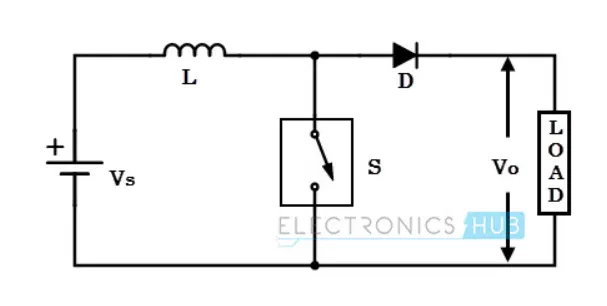
When the thyristor is turned ON, the diode is reverse-biased and hence it isolates the load circuit
from the source. So the inductor charges to the maximum input voltage source.
When the thyristor is turned OFF, the load gets the voltage from input as well as from inductor.
So the voltage appearing across the converter output will be more than the input.
Hence the output voltage is equal to (1/1 - d)times the input voltage, where d is the duty ratio(TON/T)
By varying this duty ratio, the output voltage will be varied till the load gets desired voltage.
C. Buck/Boost converter
This chopper can be used both in step-down and step-up modes by continuously adjusting duty
cycle. The configuration of buck-boost converter is shown in figure below that consists of only
one switching device. i.e., one thyristor.
Along with an inductor and diode, additional capacitor is connected in parallel with this circuit.
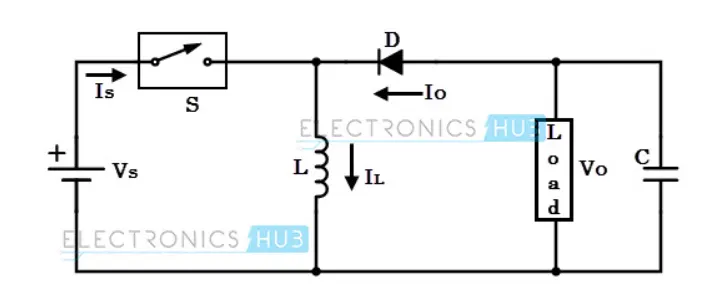
When the thyristor is turned ON, the supply current flows to the inductor through the thyristor
and induces the voltage in inductor.
When the thyristor is OFF, the current in the inductor tends to decrease with the induced emf
reversing polarity. The output voltage of this converter remains constant as capacitors is
connected across the load.
By varying the value of duty ratio to a certain value, the output voltage, typically in the range
0>=k>0.5 thus a buck converter.
And the output is higher than the input voltage if the duty ratio is in the range of 0.5>k>=1, thus
acts as a boost converter.
3. DC to AC Converters or Inverters
These converters are connected between DC source of fixed input, and variable AC load. Most
commonly these DC to AC converters are called as inverters. An inverters is a static device that
converts the fixed DC supply voltage to a variable AC voltage.
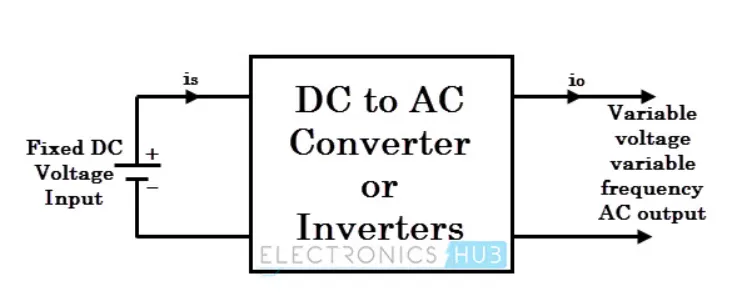
Here the fixed DC voltage is obtained from batteries or by DC link in most power electronic
converter. The output of the inverter can be variable/fixed AC voltage with variable/fixed
frequency.
This conversions from DC to AC along with variable supply is produced by varying the
triggering angle to the thyristors. Most of the thyristors used in inverters are employed
with forced commutation techniques.
These can be single phase or three phase inverter depending on the supply voltage.
These converters are mainly divided into two groups. One is PWM based inverters and
other multilevel inverters.
Further, these are classified voltage source inverter and current source inverter. Each
type is subdivided into different types such as PWM,SVPWM,etc. Multilevel inverters
are more popular in industrial applications.
The inverters overcomr the drawback of PWM based inverters.
4. AC to DC Converter or Rectifier
An AC to DC converter is also called a rectifier, which converts AC supply from main
lines to DC supply for the load. The block diagram of an AC to DC converter is shown
in figure below.
The essential components in this rectifier include transformer, switching unit, filter,
and a control block.
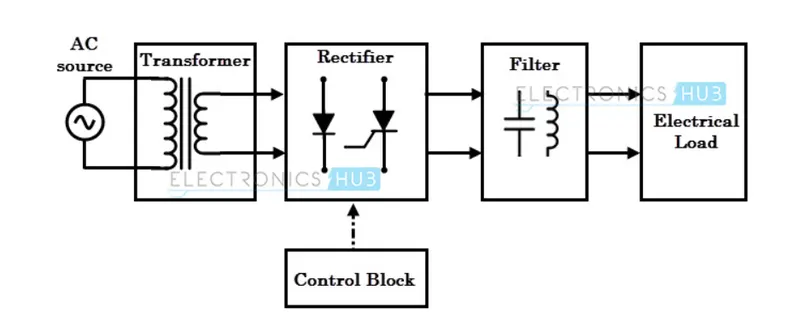
Here, the transformer adjusts the primary AC source supply to the input of rectifier stage. Usually
it is a step down transformer that reduces the supply voltage to a circuit operating range.
The rectifier converts the low voltage AC supply into DC supply.
It comprises diode and/or thyristor based on type of rectifier. The output of the rectifier
is of pulsed DC and hence it is filtered using filter circuit, which is usually made with a
capacitor or choke.
The control block controls the firing angle of thyristor in case of phase controlled
rectifiers. since the diode is not a controllable device, control block is not needed
in case of diode rectifier.
Rectifiers are majorly classified into two types:
1. Uncontrolled diode rectifier
2. controlled rectifier
Aim 2:
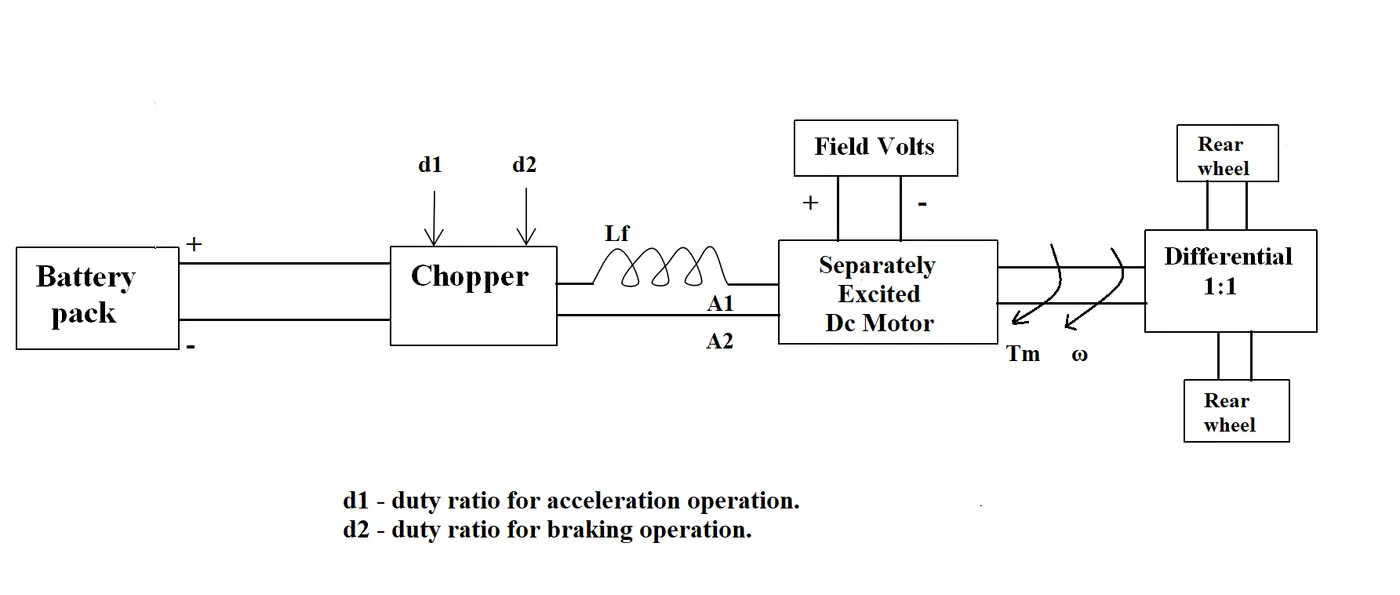
An Electric Vehicle's powertrain with 72V battery pack in shown in the diagram below.
The duty ratio for acceleration operation is 'd1' and for the braking operation the duty r
atio is 'd2'.
The other parameters of the electric vehicle is given below,
Motor and Controller Parameters:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5Ω, KΦ= 0.7 Volt second
Chopper Switching frequency= 400 Hz
The vehicle speed-torque characteristics are given by the below equation
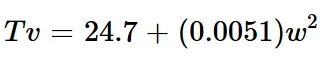
What is EV steady state speed if duty cycle is 70%?
Solution:
Given, supply rated voltage (Vs) = 72 volts
duty ratio (d) = 0.7
thus, motor voltage that come across the motor = Va = Vs*d
= 72*0.7
= 50.4 volts
The speed relationship is governed by equation,
w = V/KΦ - Ra/KΦ^2 . T
where, T=motor torque
V=Va=motor voltage
Ra= Armature resistance
w=Angular speed of a motor (rad/s)n
Thus,
w = 50.4/0.7 - (0.5/(0.7)^2) .T
we get
T = 70.58 - 0.98w
now, the vehicle speed-torque charecteristics are given by the equation,
Tv = 24.7 + (0.0051)w^2
equating above two equation , we get
70.58 - 0.98w = 24.7 + (0.0051)w^2
0.0051w^2 + 0.98w - 45.88 = 0
the solution for the quadratic equation
ax^2 + bx + c = 0
is given by
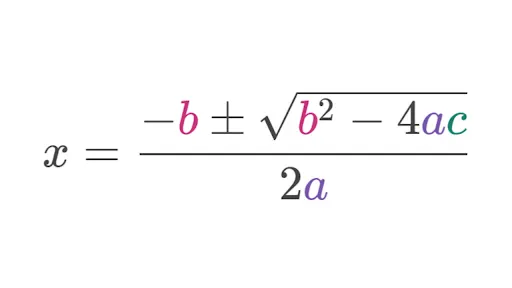
Hence, we get w=38.95rad/sec and w=-231.08rad/sec.
it shows that EV steady state speed is 38.95 rad/sec.
Aim 3:
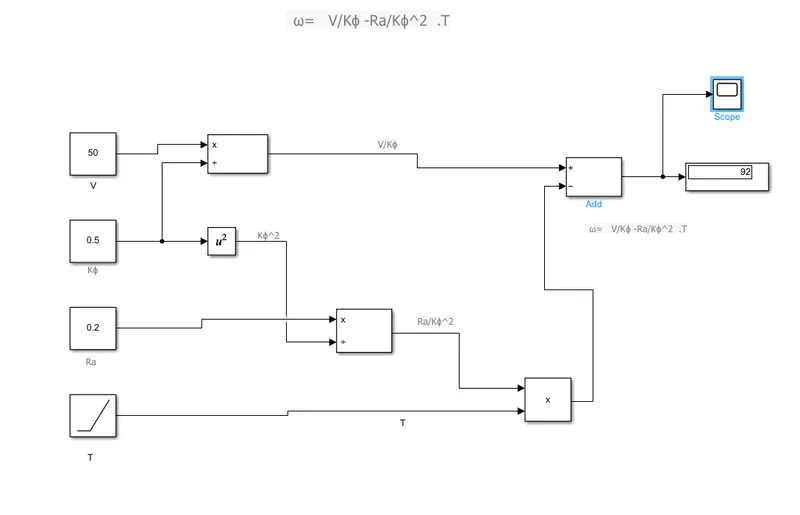
Develop a mathematical model of a DC Motor for the below equation using Simulink.
ω= V/Kϕ -Ra/Kϕ^2 .T
Solution: Let us draw the model for the above equation as shown below.
let V= 50 volts
Kϕ= 0.5
Ra= 0.2
consider that torque as linearly increasing signal, Ramp signal is considered.
The scope of speed of a motor is shown below.
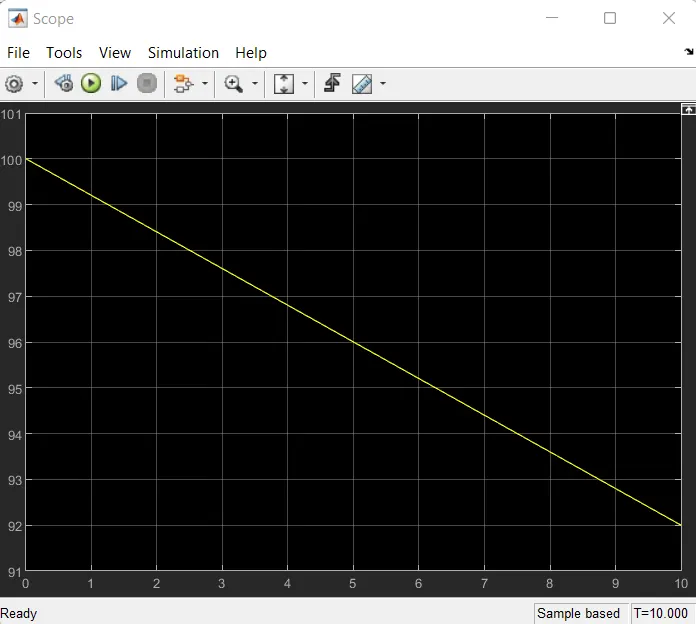
From the scope it can be concluded that for the fixed voltage , the motor speed is inversely
proportional to the load. This means that increase in load torque will result in decrease in
speed.
https://drive.google.com/file/d/1HP5aPYR33rksEACfXKuH-A0XZZx5PVdg/view?usp=sharing
Aim 4:
Refer to the blog on below topic:
Induction Versus DC brushless motors by Wally Rippel, Tesla
Explain in brief about author’s perspective.
Solution: Technique 1- About DC brushless motors:
With brushless machine, the rotor includes two or more permanent magnets that generates
a DC magnetic field ( as seen from the vantage point of rotor ). In turns, this magnetic
field enters the stator core ( a core made up of thin, stacked laminations ) and interacts
with current flowing within the winding to produce a torque interactions between the rotor
and stator. As the rotor rotates, it is necessary that the magnitude and polarity of the
stator current be continuously varied-and in just the right way-such that the torque remains
constant and the conversion of electrical to mechanical energy is optimally efficient. The
device that provide this current control is called an inverter. Without it, brushless motor
are useless motors.
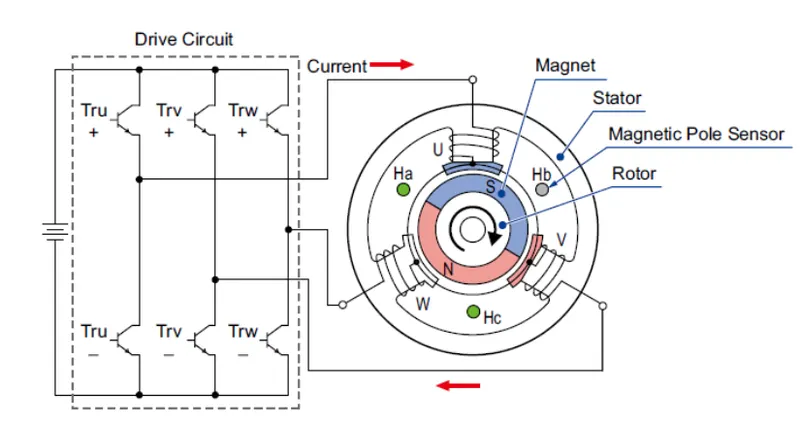
Fig. Simpified representation of DC brushless motor
Technique 2- About induction motor:
Unlike the DC brushless rotor, the induction rotor has no magnets-just stacked steel
laminations with buried peripheral conductors that form a "shorted structure".
Currents flowing in the stator winding produces a rotating magnetic field that enters
the rotor. In turn, the frequency of this magnetic field as "seen" by the rotor is equal
to the difference between the applied electrical frequency and the rotational "frequency"
of the rotor itself. Accordingly, an induced voltage exists across the shorted structure
that is proportionate to this speed difference between the rotor and electrical frequency.
In response to this voltage, currents are produced within the rotor conductors that are
approximately proportionate to the voltage, hence the speed difference. Finally, these
currents interacts with the original magnetic field to produce forces - a component of
which is the desired rotor torque.
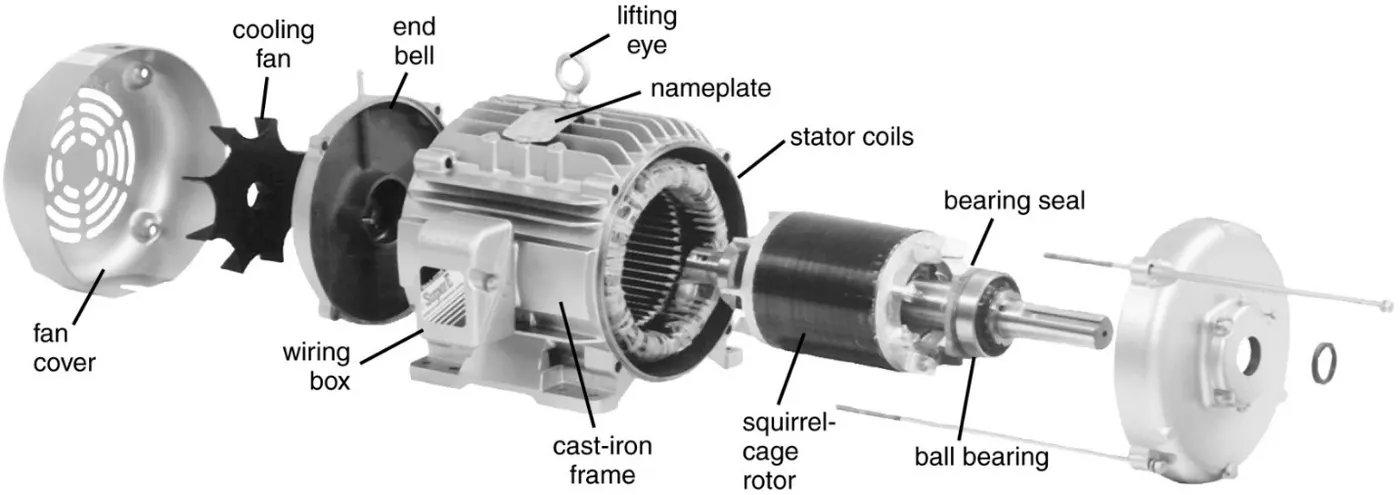
Fig. 3-Phase Induction motor
While 3-phase induction motors have great utility, they also have some severe limitationns.
They cannot operate from DC; AC is must. Shaft speed is proportionate to line frequency.
Hence, when used with utility power, they are constant speed machines. Finally, when
operated from utility power, they have limited starting torque and somewhat limited
running peak torque capabilities, when compared to DC type machines.
Which is more significant: Brushless or Induction?
Both DC brushless and induction drives use motors having similar stators.
Both drives use 3-phase modulating inverters. The only differences are the
rotors and the inverters controls. And with digital controllers, the only
control differences are with control code.( DC brushless drives require an
absolute position sensor, while induction drives requires only a speed
sensor; these difference are relatively small.)
In an ideal brushless drive, the strenghth of the magnetic field produced
by the permanent magnet would be adjustable. When maximum torque
is required, especially at low speeds, the magnetic field strenght (B)
should be maximum - so that inverter and motor currents are maintained
at their lowest possible values. The minimizes the I^2R (current^2 resistance)
losses and thereby optimizes efficiency. Likewise, when torque levels are
low, the B field should be reduced such that eddy and hysteresis losses due
to B are also reduced. Ideally, B should be adjusted such that the sum of the
eddy, hysteresis, current losses is minimized. Unfortunately, there is no easy way
of changing B with permanent magnets.
One of the main difference is that much less rotor heat is generated with the DC
brushless drive. Rotor cooling is easier and peak point efficiency is generally
higher for this drive. The DC brushless drive can also operate at unity power factor
whereas the best power factor for the induction drives is about 85%. This means
that the peak point energy efficiency for a DC brushless drive will typically be a few
percentage points higher than for an induction drives.
Conclusions:
1. Various power converter circuits used in EV and hybrid EV are studied.
2. The EV steady state speed for the data given is calculated.
3. Simulink model for equation ω= V/Kϕ -Ra/Kϕ^2 .T is developed.
4. Difference between DC brushless motor and Induction motor is studied.