Week-6 Challenge: EV Drivetrain
1. Which types of power converter circuits are employed in electric and hybrid electric vehicle?
Answer:
We know generally there are three types of Electrical vehicles.
1. Hybrid Electric vehicle
2. Plugin Hybrid Electric vehicle
3. Battery Electric vehicle
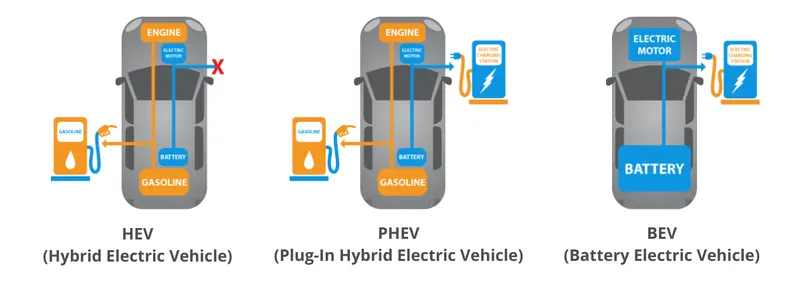
Hybrid Electric vehicle:
- Hybrid Electric Vehicles, or HEVs, have both a gas-powered engine and an electric motor to drive the car.
- All energy for the battery is gained through regenerative braking, which recoups otherwise lost energy in braking to assist the gasoline engine during acceleration.
- In a traditional internal combustion engine vehicle, this braking energy is normally lost as heat in the brake pads and rotors.
- Regular hybrids cannot plug into the grid to recharge and cannot charge with EVgo.
Plug-in Hybrid Electric vehicle:
- Plug-in Hybrid Electric Vehicles, or PHEVs, have both an engine and electric motor to drive the car.
- Like regular hybrids, they can recharge their battery through regenerative braking.
- They differ from regular hybrids by having a much larger battery, and being able to plug into the grid to recharge.
- While regular hybrids can (at low speed) travel 1-2 miles before the gasoline engine turns on, PHEVs can go anywhere from 10-40 miles before their gas engines provide assistance.
- Once the all-electric range is depleted, PHEVs act as regular hybrids, and can travel several hundred miles on a tank of gasoline.
- All PHEVs can charge at an EVgo L2 charger, but most PHEVs are not capable of supporting fast charging.
Battery Electric vehicle:
- Battery Electric Vehicles, also called BEVs and more frequently called EVs, are fully electric vehicles with rechargeable batteries and no gasoline engine.
- All energy to run the vehicle comes from the battery pack which is recharged from the grid.
- BEVs are zero emissions vehicles, as they do not generate any harmful tailpipe emissions or air pollution hazards caused by traditional gasoline-powered vehicles.
- Some popular EV models are pictured here and a full list of available fast charging EV models is available in the chart above.
But in all these types of vehicles, we use basically 3 types of power converters.
They are 1. AC-DC converter
2. DC-DC converter
3. DC-AC converter
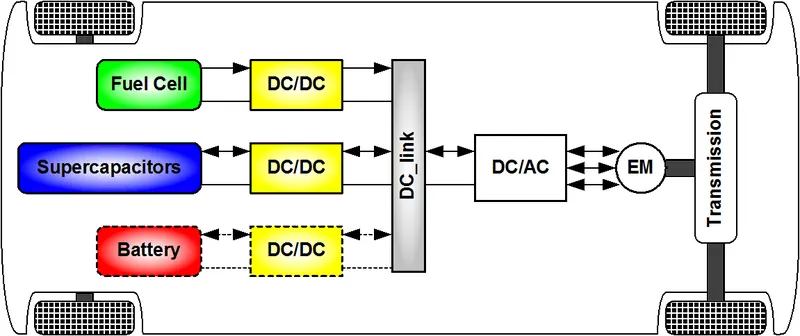
Basic block diagram of EV
1. AC-DC Converter:
- AC-DC converter (Onboard charger) is used for charging the vehicle.
- As battery stores energy in the form of DC, so AC-DC power converter is required.
- They are generally used in PHEV and PEV type vehicles.
2. DC-DC Converter(Chopper):
- We know lights, indicators and other signal generators requires only low voltage (12V or 24 V).
- So the battery energy (DC type high range) will converted into Low voltage DC by DC to DC converter (Chopper).
3. DC-AC Converter (Inverter):
- DC-AC converter is used to convert the battery energy (DC type) to AC to supply the motor (AC motor used).
- Therefore, the converted energy (AC) is used for motor operation.
Conclusion:
The different types power converters used in EV and HEV are discussed.
2. An Electric Vehicle's powertrain with 72V battery pack in shown in the diagram below. The duty ratio for acceleration operation is 'd1' and for the braking operation the duty ratio is 'd2'.
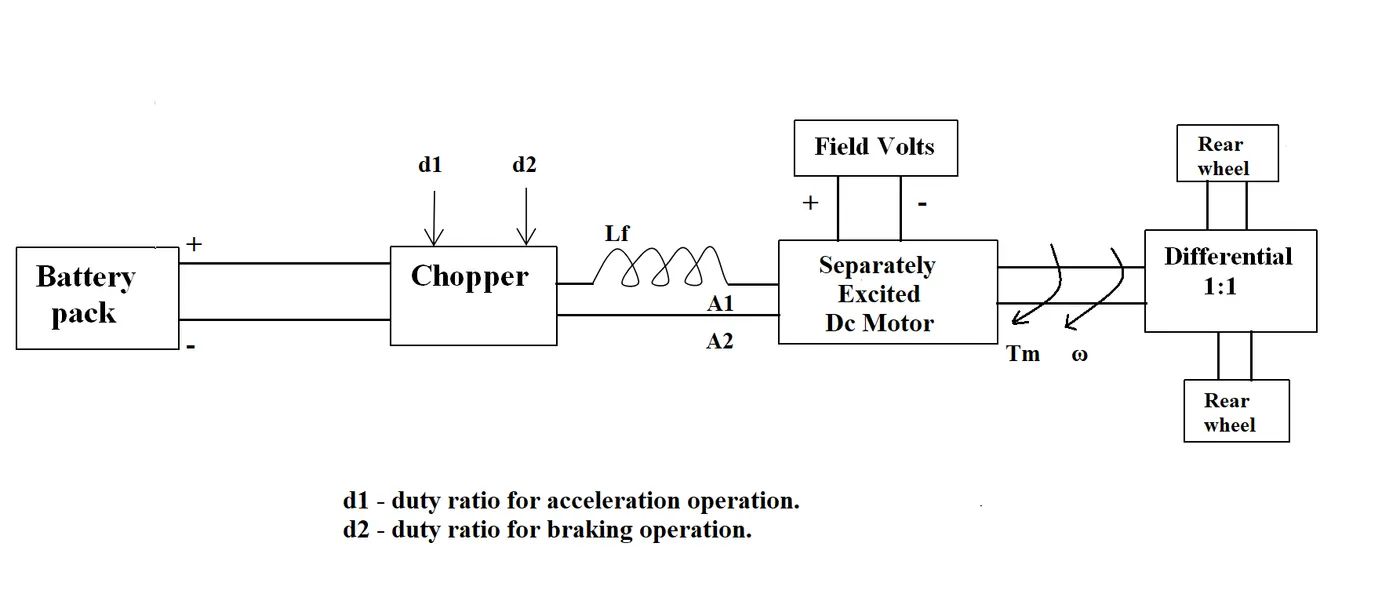
The other parameters of the electric vehicle is given below,
Motor and Controller Parameters:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5Ω, KΦ= 0.7 Volt second
Chopper Switching frequency= 400 Hz
The vehicle speed-torque characteristics are given by the below equation
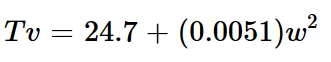
What is EV steady state speed if duty cycle is 70%?
Answer:
Given vehicle, motor and controller parameters:
Battery voltage = 72V
Armature Voltage = 72V
Rated armature current = 400A
Armature resistance = 0.5Ω
Speed Constant (Kϕ) = 0.7 V-sec
Chopper switching frequency = 400 Hz
Given dutycycle (%) = 70%
Given Torque-speed characteristics
Tv = 24.7 + (0.0051)*W^2----------------------(1)
We know relation between speed and torque charactercharacteristics is
W = ((Vt*d1)/Kϕ) - ((Ra*T)/(Kϕ^2))-----------(2)
by substituting given values in (2), we get
T = 70.56 - (0.98)*W ------------------(3)
So by equating equation (1) and (3),
=> 24.7 + (0.0051)*W^2 = 70.56 - (0.98)*W
=> (0.0051)*W^2 + (0.98)*W - 45.86 = 0
So to solve the above qudratic equation, we can use matlab code.
Matlab code:
clc
a=input('enter the value of a:\n');
b=input('enter the value of b:\n');
c=input('enter the value of c:\n');
D= b.^2-4*a.*c;
if D>0
    fprintf('The eqution has two real and distinct roots \n')
    root1=(-b+sqrt(D))/(2*a);
    root2=(-b-sqrt(D))/(2*a);
    fprintf('%6.24f and %6.24f\n',root1,root2);
elseif D==0
    fprintf('The equation has real and equal roots \n')
    root1=b/(2*a);
    root2=root1;
    printf(root1,root2);
elseif D<0
    fprintf('The equation has complex roots \n')
    root1=(-b+(1i*sqrt(D)))/(2*a);
    root2=(-b-(1i*sqrt(D)))/(2*a);
    printf(root1,root2);
end
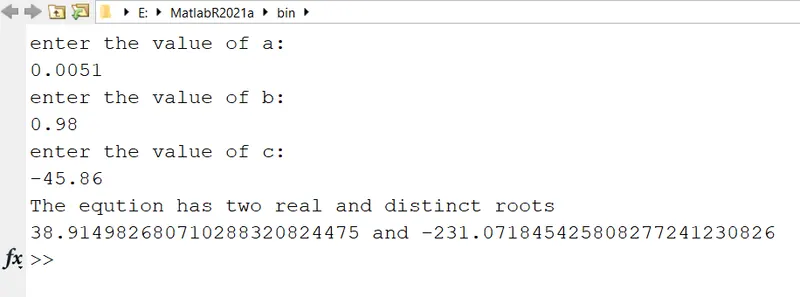
Output:
Conclusion:
The steady state speed of EV for given speed-torque characteristics is 38.915 rad/sec (Negative speed is neglected).
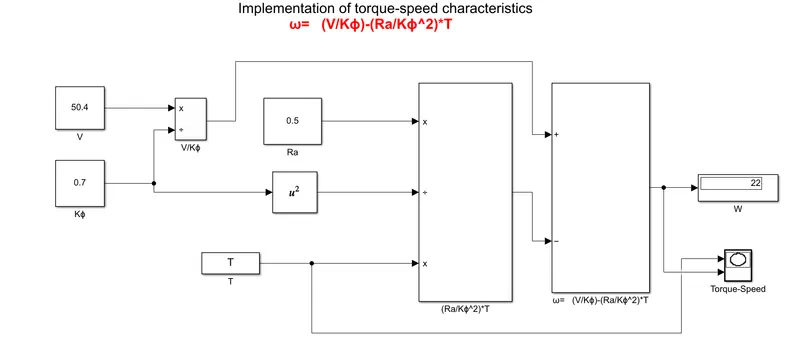
3. Develop a mathematical model of a DC Motor for the below equation using Simulink.
ω = (V/Kϕ) - (Ra/(Kϕ^2))*T
Answer:
We know for a DC motor, governing equation for speed-torque characteristics is
ω = (V/Kϕ) - (Ra/(Kϕ^2))*T
Mainmodel:
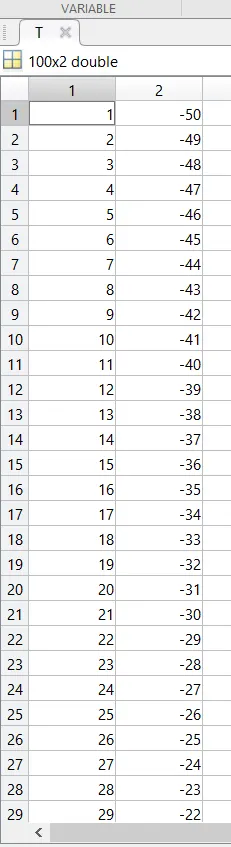
Torque input (Workspace):
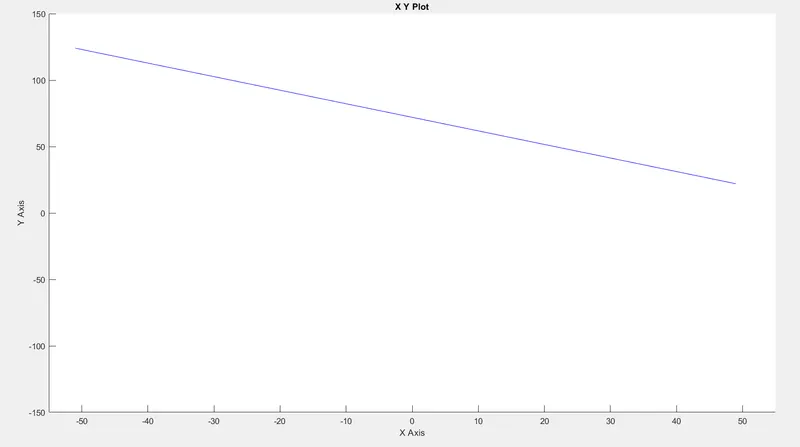
Output:
Conclusion:
Therefore, mathematical model of DC motor for the given torque-speed characteristics is modelled.
4.Refer to the blog on below topic: Induction Versus DC brushless motors by Wally Rippel, Tesla
Explain in brief about author’s perspective.
Answer:
The author Wally Rippel actually discussing about major differences between Induction motors versus DC brushless motors.
- In early days, we use lead cid batteries, DC brush motors and contactor controllers.
- But now, lead acid batteries replaced by lithium batteries, DC brush motor replaced by DC brushless or induction motors.
- Contact contollers replaced by modulated inverters.
Brushless DC machine:
- Incase of brushless machines, the rotor includes two or more permanent magnets that generate a DC magnetic field (with respect to rotor).
- Then, this magnetic field enters the stator core (a core made up of thin, stacked laminations) and interacts with currents flowing within the windings to produce a torque interaction between the rotor and stator.
- As the rotor rotates, it is necessary that the magnitude and polarity of the stator currents be continuously varied such that the torque remains constant.
- The conversion of electrical to mechanical energy is optimally efficient.
- The device that provides this current control is called an inverter. Without it, brushless motors are useless motors.
Induction motor:
- Unlike the DC brushless rotor, the induction rotor has no magnets and stacked steel laminations with buried peripheral conductors that form a “shorted structure.”
- Currents flowing in the stator windings produce a rotating magnetic field that enters the rotor.
- In turn, the frequency of this magnetic field with respect to the difference between the applied electrical frequency and the rotational “frequency” of the rotor itself.
- Accordingly, an induced voltage exists across the shorted structure that is proportional to this speed difference between the rotor and electrical frequency.
- In response to this voltage, currents are produced within the rotor conductors that are approximately proportionate to the voltage, hence the speed difference.
- Finally, these currents interact with the original magnetic field to produce forces – a component of which is the desired rotor torque.
| Brushless DC machine | Induction motor |
| It has three sets of distributed winding that are inserted within the stator core. | It also has three sets of distributed winding that are inserted within the stator core. |
| Rotating magentic field (RMF) is produced by using Permanent magnets (Attraction and Repulsion). | Rotating magnetic field (RMF) is produced by the stator winding in the air gap between stator and the rotor. |
| They cannot operate from DC. | They are operated from DC. |
| No feedback required for its better performance. | Feedback is required for its better performance. |
| Its drive require an absolute position sensor. | Its drive require only a speed sensor. |
| Very low rotor heat is generated with its drive. | Significant heat is generated. |
| Easy rotor cooling | Compared to BLDC, rotor cooling is complex, |
| High peak point efficiency. | Some what less peak point effciency. |
| Its drive can operated at unity power factor. | Its drive can operated at around 85 percent. |
Conclusion:
- DC brushless drives will likely continue to dominate in the hybrid and coming plug-in hybrid markets.
- The induction drives will likely maintain dominance for the high-performance pure electrics.