Week-6 Challenge: EV Drivetrain
1. Types of power converter circuits are employed in electric and hybrid electric vehicle.
- AC to DC converters are most commonly used in Plug-in Hybrid Electric Vehicles (PHEV) & Plug-in Electric Vehicles (PEV). ...
- DC-DC converters can be used to interface the elements in the electric power train by boosting or chopping the voltage levels.
Due to the automotive constraints, the power converter structure has to be reliable, lightweight, small volume, with high efficiency, low electromagnetic interference and low current/voltage ripple.
Different types of power converters:
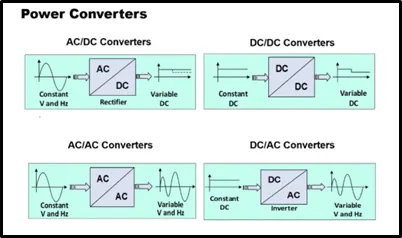
AC to DC Converters:
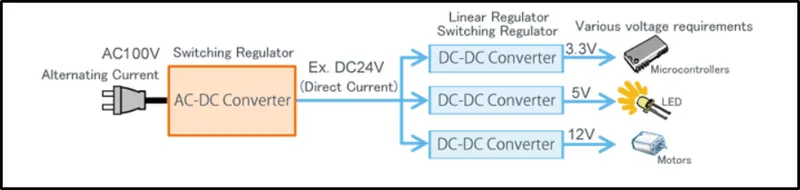
In EV/HEV vehicle some motors and lamps can be driven with AC voltage, but for motors that include control circuitry (i.e. MCUs) and lamps that have switched to energy-saving LEDs, AC-DC conversion is required.
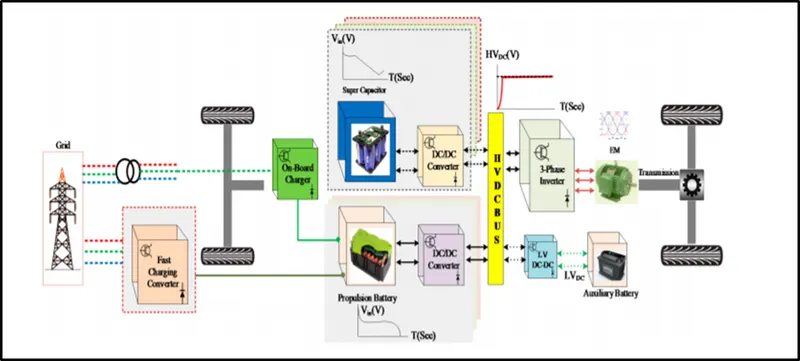
Electric Vehicle powertrain:
- An Electric Vehicle is a vehicle that uses a combination of different energy sources, Fuel Cells (FCs), Batteries and Supercapacitors (SCs) to power an electric drive system as shown below.
- In EV the main energy source is assisted by one or more energy storage devices. Thereby the system cost, mass, and volume can be decreased, and a significant better performance can be obtained.
- Two often used energy storage devices are batteries and SCS.(Supercapacitors)
- They can be connected to the fuel cell stack in many ways.
- A configuration is to directly connect two devices in parallel, (FC/battery, FC/SC, or battery/SC).
Below figure shows a typical arrangement of Electric Vehicle powertrain:
DC-DC converters
DC-DC converters can be used to interface the elements in the electric power train by boosting or chopping the voltage levels.
Three DC/DC converters topologies
- Conventional step-up or Boost DC-DC converters .
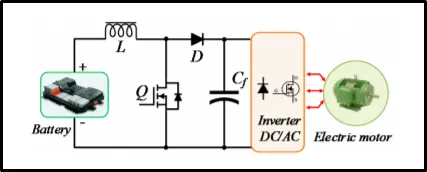
The Conventional step-up dc-dc converter is a power converter that steps-up the input voltage while stepping down the input current. It is a class of switched-mode power supply (SMPS) having at least one energy storage element (a capacitor, an inductor, or the two in combination) and at least two semiconductors (a diode and a switch) as shown in Figure.
In BC, a series connected inductor with the input DC source helps to reduce input current ripples and a capacitor-based filter is used at the output side to eliminate the output voltage ripples.
Boost DC-DC converters -advantages.
A moderate output voltage gain can be obtained (<4%), the switch can be easily driven concerning ground, the input current is continuous and filtering and meeting EMI requirements are simple for this converter.
Boost DC-DC converter - drawbacks.
As the requirement of a large capacitor to reduce the ripple at the output voltage, which makes the volume quite large and weight moderately heavy, high voltage gain (>4%) is not suitable for this converter, parallel arrangement of the power-switching devices are required to handle high-power and it requires extra stages to make it short-circuit proof.
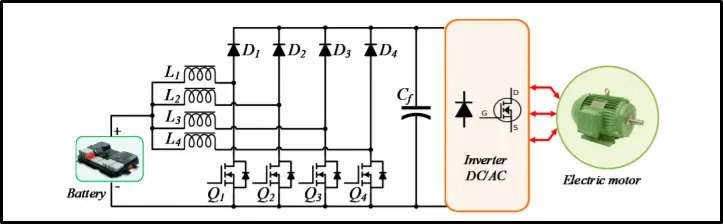
- Interleaved 4-channels step-up dc-dc converter with independent inductors
The Interleaved 4-Phase boost DC-DC converter (IBC) topology allows minimizing the input current ripples and output voltage ripples; it steps up voltage ratio approximately above four times .
In this converter, four identical levels are introduced with four inductances (L1, L2, L3, and L4); all these inductors have a separate magnetic core as shown in Figure.
- Successive phase shifting of the power switching devices is fixed by the ratio of switching period (T) and the number of Phases (N).
IBC has an efficiency of 92% at 30 kW load. Around an 8% drop in the efficiency is caused by alternating from discontinuous current mode (DCM) to continuous current mode (CCM). - This converter is sensitive to duty cycle ratio change.
- Moreover, magnetic core influence due to load change is notable and the component count is also high .
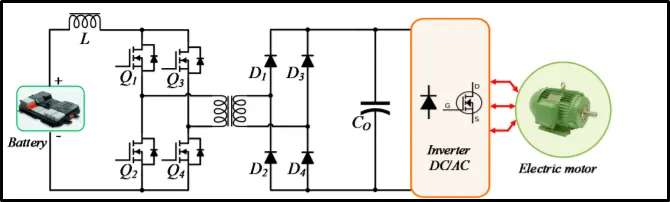
- Full-Bridge step-up dc-dc converter.
This converter has three functional stages, namely the inverter (conversion from DC to AC), followed by a high-frequency transformer (HFT) (step up the AC voltage), and followed by a rectifier (conversion the AC back to DC).
Utilization of the negative portion of the hysteresis loop reduces the core saturation as the current flows in the opposite direction during alternate half cycles, thus making the flux in the core swing from negative to positive.
The duty cycle of the PWM signal can be increased or decreased promptly so that the output voltage is held constant even with a varying input source voltage. However, the duty ratio needs to be kept above 50% to protect semiconductorswitches.
Hence, identical control signals are used in two legs, which alternate with half period duration. As an HFT is used, a high step-up voltage is possible. Moreover, it provides galvanic isolation between the input side and the load side.
At 30 kW load, the efficiency of the converter is approximately 91.5%.
Although this converter has moderately high efficiency, the effect of the HFT leakage inductance is crucial because of the high electrical stress in the switching circuit. Thus, a clamping circuit is used to resolve peak voltage issue.
2. An Electric Vehicle's powertrain with 72V battery pack in shown in the diagram below. The duty ratio for acceleration operation is 'd1' and for the braking operation the duty ratio is 'd2'.
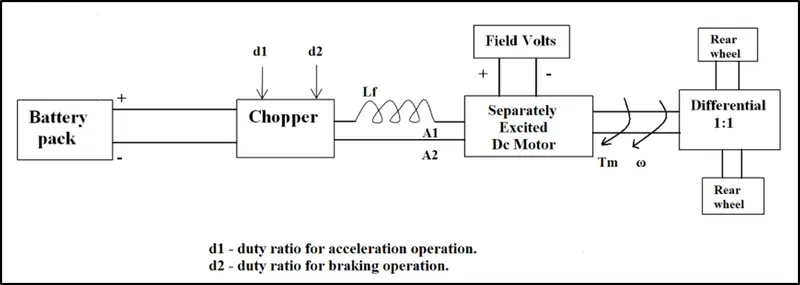
The other parameters of the electric vehicle is given below,
Motor and Controller Parameters:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5Ω, KΦ= 0.7 Volt second
Chopper Switching frequency= 400 Hz
What is EV steady state speed if duty cycle is 70%?
The vehicle speed-torque characteristics are given by the below equation:
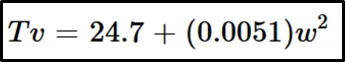
Solution: -
Vehicle Output Voltage (Vv) is given by: -
Vv= Battery Voltage (V) * Duty Cycle
Vv=72* 0.70
Thus, Vehicle voltage = 50.4V
Now, Equation for Vehicle torque is given by: -
T = (Vv — ω.KΦ).KΦ
________________
Ra
Where;
T= Vehicle Torque (N-m)
Vv = Vehicle voltage (Volts)
ω=steady state speed of vehicle (rps)
KΦ = Motor constant
Ra= Armature Resistance
Substituting all these values in equation, we get:
((50.04 — 0.7 . ω). 0.7)/0.5
Tv = 70.56 — 0.98. ω
Tv = 24.7 + 0.0051 . ω^2
Solving these two equations,
70.56 — 0.98. ω = 24.7 + 0.0051. ω^2
We get a quadratic equation:
0.0051. ω^2+0.98. ω-46.94=0
By solving above equation:
ω1=38.85rad/s
ω2=-230.95 rad/s
Note:For solving above equation:
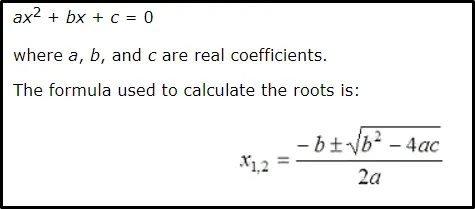
Since EV steady state speed cannot be negative we take ω=38.85rad/s.
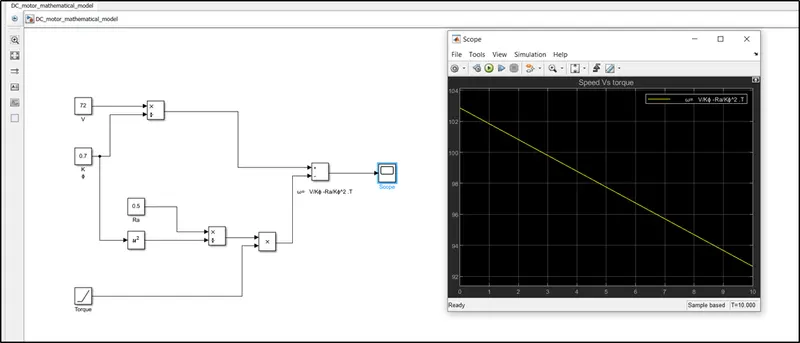
3. Develop a mathematical model of a DC Motor for the below equation using Simulink.
ω= V/Kϕ -Ra/Kϕ^2 .T
Solution:
Motor and Controller Parameters:
Rated Armature voltage= 72 V
Ra= 0.5Ω, KΦ= 0.7 Volt second
Torque is taken as Rampsignal-increases linearly.
Mathematical modeling using MATLAB:
Simulation output:
Speed VS torque
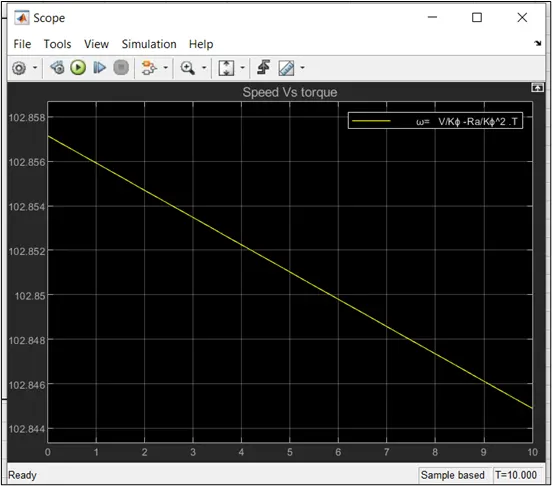
Inference:
Torque increases linearly and Speed of motor decreases.
4. Refer to the blog on below topic:
Induction Versus DC brushless motors by Wally Rippel, Tesla
Explain in brief about author’s perspective.
In the blog titled "Induction Versus DC Brushless Motors"the author Wally Rippel makes the readers understand about these two technologies, How do they work? What differentiates them? And what do they have in common?
He describes the " induction motor drives" as follows:
- In brushless machines, the rotor includes two or more permanent magnets that generate a DC magnetic field (as seen from the vantage point of the rotor).
- In turn, this magnetic field enters the stator core (a core made up of thin, stacked laminations) and interacts with currents flowing within the windings to produce a torque interaction between the rotor and stator.
- As the rotor rotates, it is necessary that the magnitude and polarity of the stator currents be continuously varied – and in just the right way - such that the torque remains constant and the conversion of electrical to mechanical energy is optimally efficient.
- The device that provides this current control is called an inverter. Without it, brushless motors are useless motors.
Advantages of DC brushless motor :
- One of the main differences is that much less rotor heat is generated with the DC brushless drive.
Rotor cooling is easier and peak point efficiency is generally higher for this drive. - The DC brushless drive can also operate at unity power factor, whereas the best power factor for the induction drive is about 85 percent.
This means that the peak point energy efficiency for a DC brushless drive will typically be a few percentage points higher than for an induction drive. - In an ideal brushless drive, the strength of the magnetic field produced by the permanent magnets would be adjustable.When maximum torque is required, especially at low speeds, the magnetic field strength (B) should be maximum – so that inverter and motor currents are maintained at their lowest possible values. This minimizes the I² R (current² resistance) losses and thereby optimizes efficiency. Likewise, when torque levels are low, the B field should be reduced such that eddy and hysteresis losses due to B are also reduced. Ideally, B should be adjusted such that the sum of the eddy, hysteresis, and I² losses is minimized. Unfortunately, there is no easy way of changing B with permanent magnets.
Disadvantages of DC brushless motor :
With DC brushless, as machine size grows, the magnetic losses increase proportionately and part load efficiency drops.
He describes the " induction motor drives" as follows:
Curiously, the stators for the 3-phase induction motor and the DC brushless motor are virtually identical.
Both have three sets of “distributed windings” that are inserted within the stator core.
The essential difference between the two machines is with the rotor.
Unlike the DC brushless rotor, the induction rotor has no magnets – just stacked steel laminations with buried peripheral conductors that form a “shorted structure.”
Currents flowing in the stator windings produce a rotating magnetic field that enters the rotor.
In turn, the frequency of this magnetic field as “seen” by the rotor is equal to the difference between the applied electrical frequency and the rotational “frequency” of the rotor itself.
Accordingly, an induced voltage exists across the shorted structure that is proportionate to this speed difference between the rotor and electrical frequency.
In response to this voltage, currents are produced within the rotor conductors that are approximately proportionate to the voltage, hence the speed difference.
Finally, these currents interact with the original magnetic field to produce forces – a component of which is the desired rotor torque.
When a 3-phase induction motor is connected to utility type 3-phase power, torque is produced at the outset; the motor has the ability to start under load. No inverter is needed.
(Were an inverter needed, Tesla’s invention would have been useless until sometime in the 1960s.) The fact that induction motors are directly compatible with conventional utility power is the main reason for their success. In contrast, a brushless DC motor produces no starting torque when directly connected to fixed frequency utility power. They really need the aid of an inverter whose “phase” is maintained in step with the angular position of the rotor.
Advantages of Induction motor:
- Permanent magnets are expensive – something like $50 per kilogram.Permanent magnet (PM) rotors are also difficult to handle due to very large forces that come into play when anything ferromagnetic gets close to them.
- This means that induction motors will likely retain a cost advantage over PM machines.
- Also, due to the field weakening capabilities of induction machines, inverter ratings and costs appear to be lower, especially for high performance drives.
- Since spinning induction machines produce little or no voltage when de-excited, they are easier to protect.
- Induction machines have no magnets and B fields are “adjustable,” since B is proportionate to V/f (voltage to frequency).
This means that at light loads the inverter can reduce voltage such that magnetic losses are reduced and efficiency is maximized. - Thus, the induction machine when operated with a smart inverter has an advantage over a DC brushless machine – magnetic and conduction losses can be traded such that efficiency is optimized. This advantage becomes increasingly important as performance is increased.
- With induction, as machine size grows, losses do not necessarily grow. Thus, induction drives may be the favored approach where high-performance is desired; peak efficiency will be a little less than with DC brushless, but average efficiency may actually be better.
Limitations of Induction motor
- While 3-phase induction motors have great utility, they also have some severe limitations.
- They cannot operate from DC; AC is a must. Shaft speed is proportionate to line frequency.
Hence, when used with utility power, they are constant speed machines. - Induction machines are more difficult to control. The control laws are more complex and difficult to understand. Achieving stability over the entire torque-speed range and over temperature is more difficult with induction than with DC brushless. This means added development costs, but likely little or no recurring costs
- Finally, when operated from utility power, they have limited starting torque and somewhat limited running peak torque capabilities, when compared to DC type machines.
Add an inverter (without any feedback control) and it becomes possible to power an induction machine from a battery or other DC source; variable speed also becomes possible simply by adjusting the inverter frequency.
Still, torque performance is low compared with DC machines.Add some feedback loops such that the inverter produces the exact frequency that the motor “desires,” and the induction motor is now capable of competing with DC and DC brushless for vehicle applications.
Conclusion:
The author concludes that DC brushless drives will likely continue to dominate in the hybrid and coming plug-in hybrid markets, and that induction drives will likely maintain dominance for the high-performance pure electrics.He also emphasis the fact that so much of the hardware is common for both drives could mean that we will see induction and DC brushless live and work side by side during the coming golden era of hybrid and electric vehicles.
Result:
1.Power converters used in EV and HEV vehicles are studied and presented.
2.The EV steady state speed is calculated at duty cycle is 70%
3. A mathematical model of a DC Motor is developed for the below equation using Simulink.
ω= V/Kϕ -Ra/Kϕ^2 .T
4.In author’s perspective the blog titled "Induction Versus DC Brushless Motors"by Wally Rippel is explained.