Week-4 Challenge WOT Condition Part-2
AIM:- To analyse basic functionality of the powertrain blockset
OBJECTIVE:- This project is developed to grasp the concepts of control model. In order to achieve the same, we will be analysing the powertrain blockset.
There are more major objectives of this project, which are as follows:-
(i) Study the differences between mapped and dynamic models of engine generator and motor
(ii) find the mehod of calculation of fuel consumption in the given model. Factors affecting the behaviour of fuel consumption
(iii) to perform a comparaitive analysis of various environmental factors on EV reference model of powertrain blockset.
(iv) Comparative study of EV and HEV powertrain model
THEORY & PROCEDURE:-
1. Mapped models are basically those type of models in which parameters are assigned on thebasis of a look table. in simpler words we have pre-manifested conditions or state points on which the models stimulate.
It is used for quasi-state model simulations.
On other hand dynamic models as the name suggests run on dynamic modelling in which the models feedback the data and on which the system performs.
When we aspire to have a component level informations then we prefer the dynamic models. It gives the invidual impact of each and every block on system performance.
2. Fuel consumption algorithms are residing inside the visualisation subsystem.
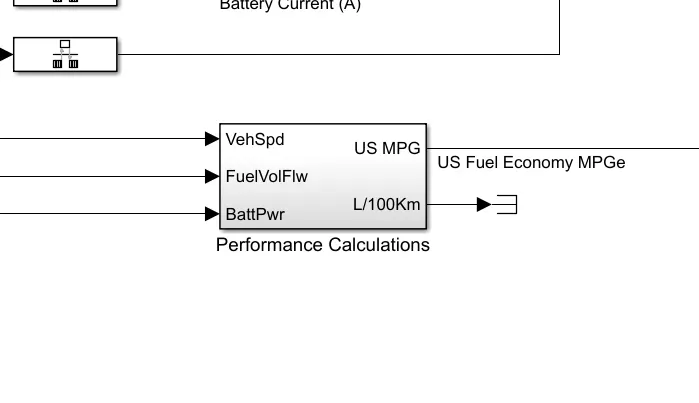
To compute the fuel flow three parameters are considered which are;- vehicle speed, fuel flow velocity and battery power.
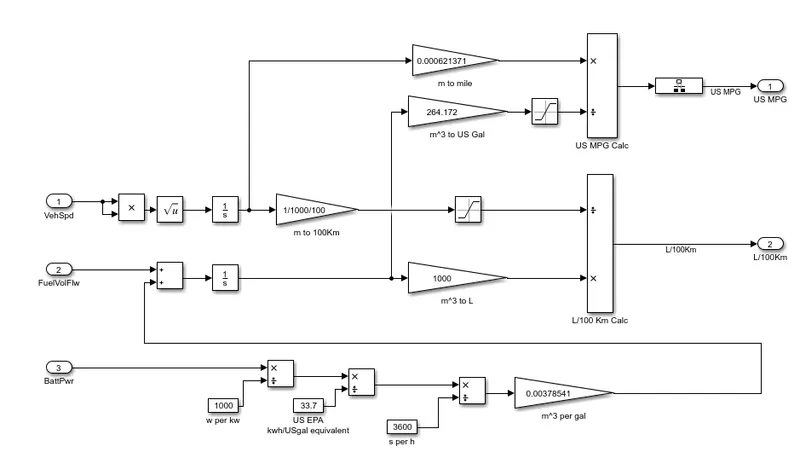
To run the vehicle the vehicle has two power source first one is the engine and the other one is motor. Hence two energy is consumed battery powe and fuel.
For fuel consumpion both fuel and battery power is considered in the selected algorithm. The mathematical fuel consumption model is described below sequentially:-
1. first the diatance covered is calculated with integration within spesified time limits
2. battery power consumption is computed and converted in the units of per gallon by using proper calculations.
3. fuel flow rate is observed and sum up with battery power
4. now total distance is divided with total fuel consumption
In this way fuel consumption is measured.
3.
The powertrain blockset is a collection of reference models provided by matworks in order to develop the control strategy development of different types of vehicles.
On a prior basis it includes pre-designed models of electric vehicle, hybrid electric vehicle and many more whicj can be explored to grasp the skills.
We will be using " autoblkHevStart " as the command to run the HEV reference application.
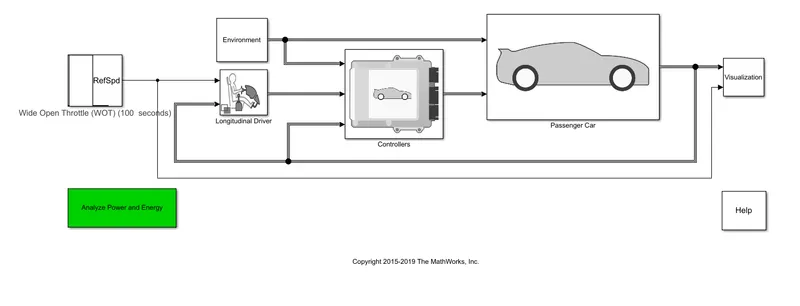
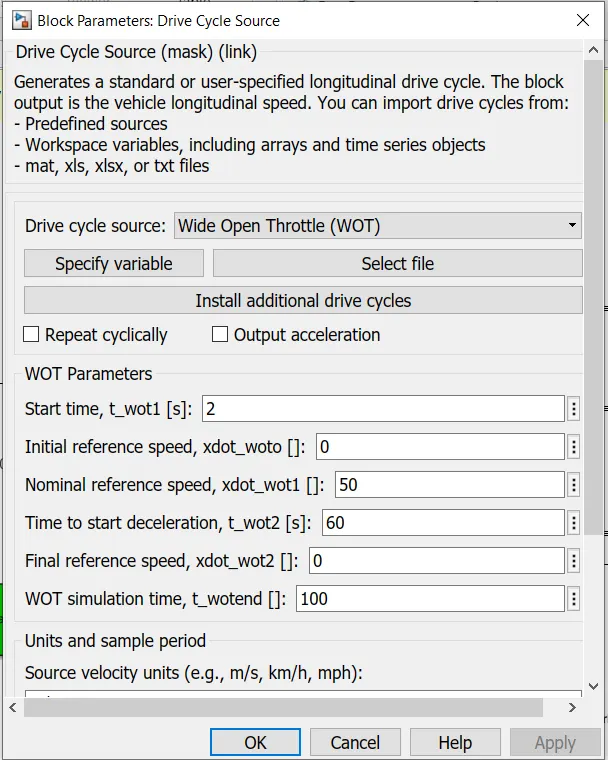
To run the vehicle wide open throttle condition we define the drive cycle as WOT and then select the various parameters as shown below.
We have run the simulation in three different environmental conditons which are as follows:-
1. Grade-- 0 , Wind speed -- 0
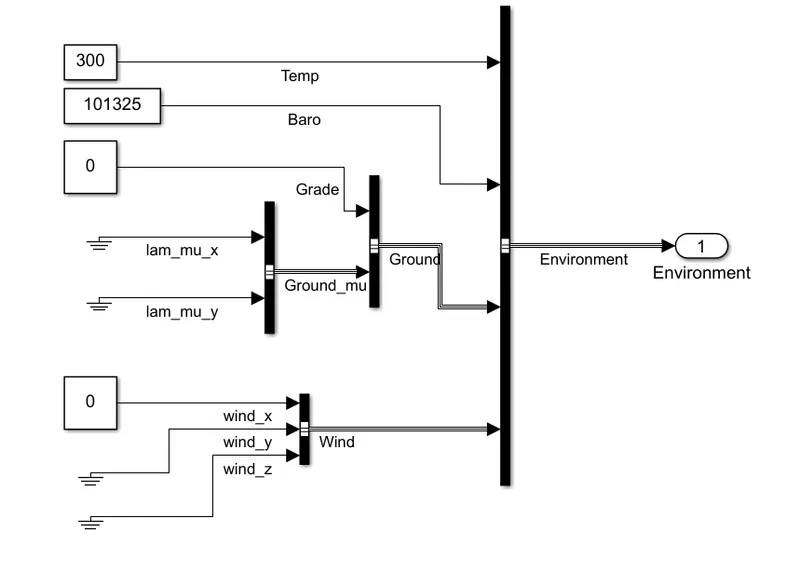
By running the simulation in this conditions we got the following scope view--
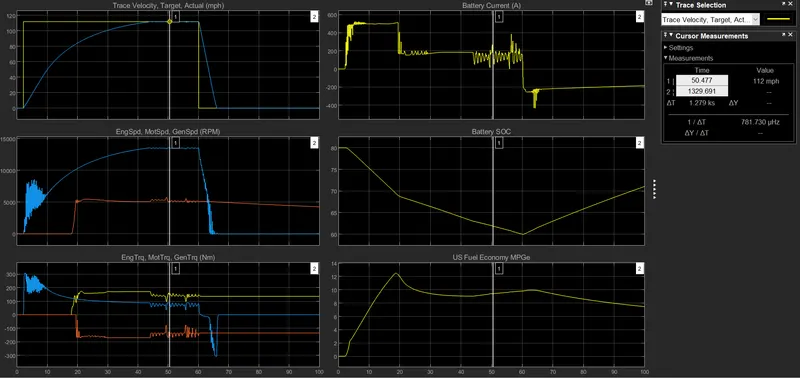
The required speed of 50 m/s is achieved in 43.7 seconds and took a decceleration time 5.9 seconds.
2. Grade-- 6% , wind speed-- 0
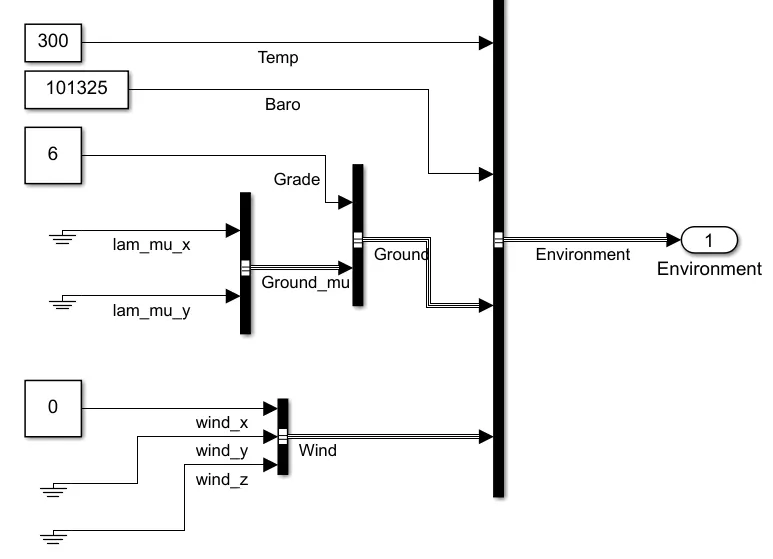
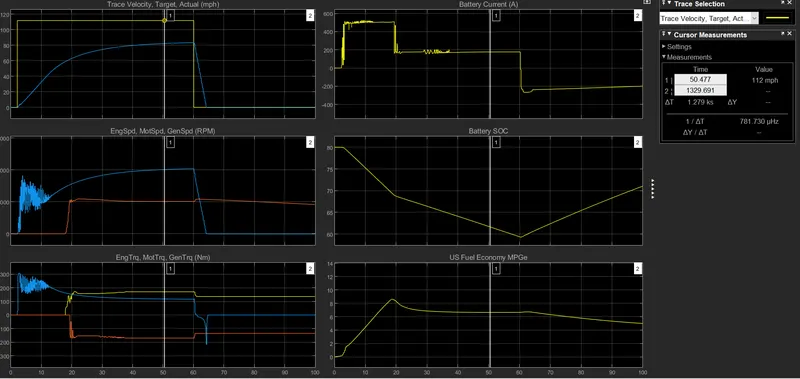
In this condition the model is reach its assigned maximum speed. it has reached a mx speed of 83.4 mph whereas our required was 112 mph. it takes 60.1 sec to achieve this. Deccelerartion time has been reduced to 4.2 sec.
3. Grade--0 , wind speed--20 mph
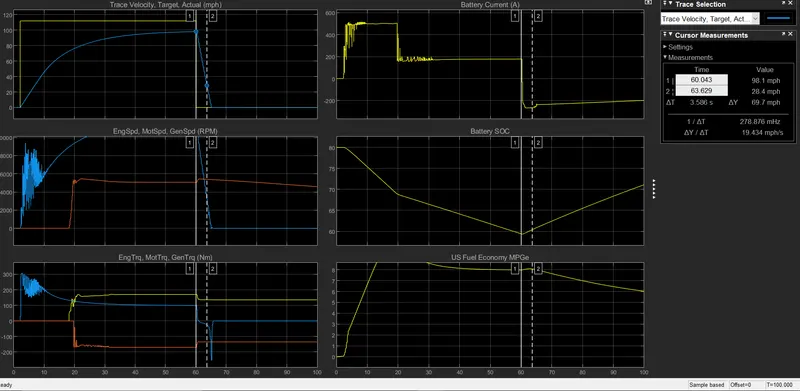
Maximum achieved is 98.1 mph and in 60 sec. decceleration time 5 sec
4. Grade-- 6 % , wind speed-- 20 mph
The environmental parameters have been changed accordingly.
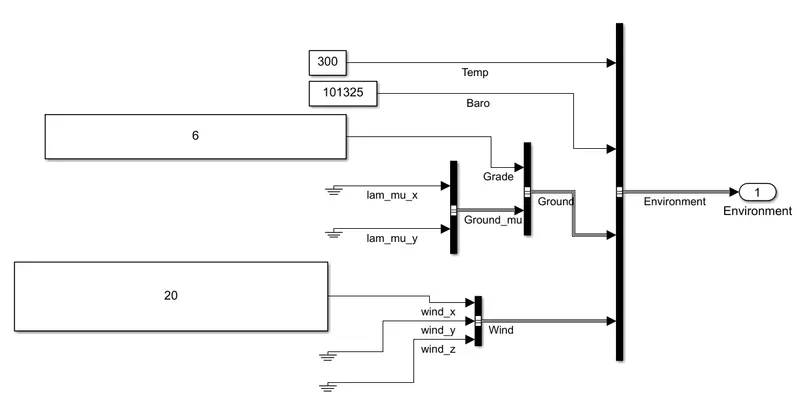
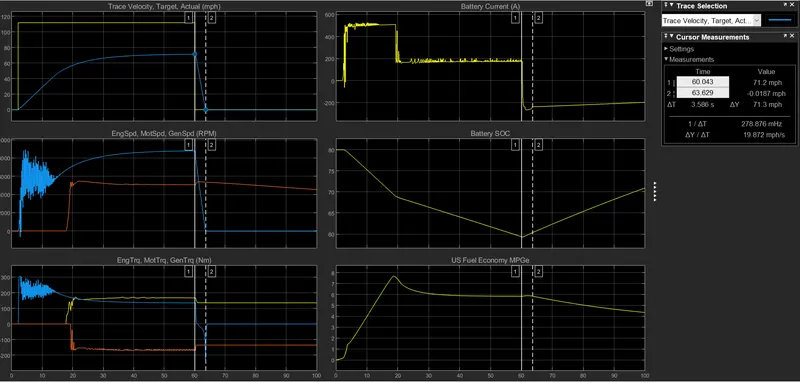
The models capability of maximum speed has been significantly reduced and reached to 71.2 mph with the time taken to be 60 sec. Deacceleration time has been reduced to 3.5 sec. .
4. To perform a compararive study on EV and HEV reference model we will proceed by assigning all the required parameters same for both the models.
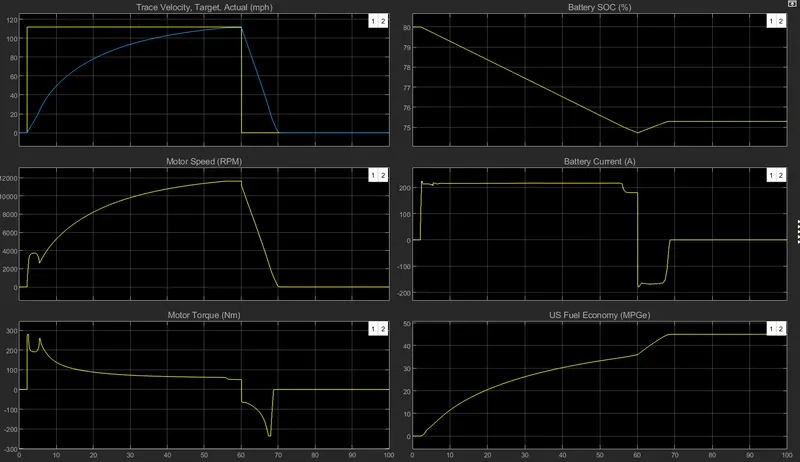
The simulation is run for 100 seconds and the obtained results for both the models are as follows:-
HEV
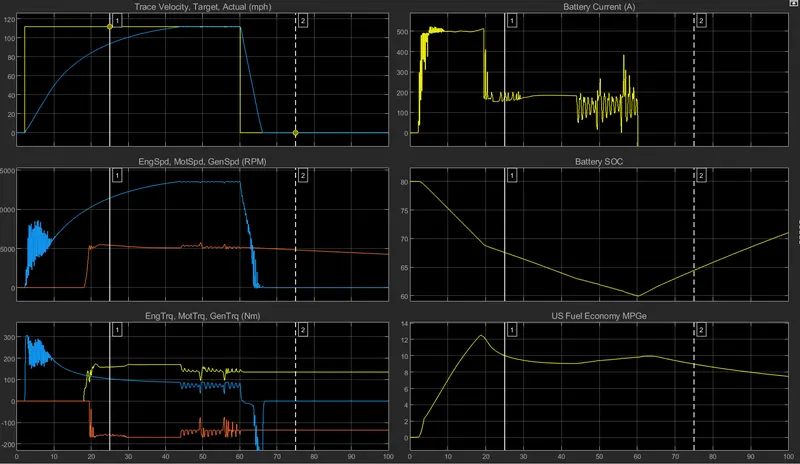
EV
Result Concluded
1> the max speed is achieved in hev in shorter duration as compared to ev
2> max speed of motor is very high in ev as compared to hev
3> there is more current fluctuations in hev
4> max battery current is very high in hev
5> battery SOC's min value is lower in hev
6> in hev torque is provided with engine and motor both whereas in ev motor alone is providing torque.
CONCLUSION
By this project we got the basic ideas to model a powertrain of any simple vehicle on primitive basis.
By using the pre-designed models of poertrain blockset on matlab we got familiar with control model designing of such a huge systems.
It stretched our vision of vehicle designing that how various environmental conditions can be imposed along with different drive cycles on vehicle models.
REFERENCES
1. https://in.mathworks.com/help/autoblks/ug/internal-combustion-mapped-and-core-engine-models.html