Week-4 Challenge WOT Condition Part-2
1. What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Solution: Powertrain blockset consists two types of combution engine models. They are Mapped and Dynamic model.
Mapped Model Engine: These are used to represent macro engine behaviour and measures the performance of vehicle as a set of steady state look up tables. This tables provides overall engine, motor and Generator characteerstics like Brake torque, fuel flow, exhaust temperature, efficiency and emissions. Static model is used for quasi steady state engine simulations. The following figure shows the mapped model engine using Lookup table.
Dynamic model Engine: These are used to decompose the engine behaviour into smaller individual component models that account for engine dynamics, intake airflow and turbo charger dynamics. They utilize the given data from all the subsystems or components to characterize the performance of engine in real time.Dynamic engines are used when we have component level data.This block calculates the fuel flow, air mass flow, air fuel ratio, exhaust mass flow rate. They are mainly used to study the impact of individual engine components on the overall performance. The following figure shows the Dynamic engine model configuration.
Mapped Model Motor: This model of motor runs in Torque control mode. This model specifies the elcttrical losses as a single operating unit that measures losses across the operating range, Maximum efficiency and speed.We use mapped motors when details of the motor are unknown and when quick simulation is required. Motor specifications are entered using the lookup tables before simulating the result. The following figure shows the Mapped motor and drive elctronics operating in torque control mode simulink.
Dynamic Model Motor: This model is used when all the parameters are known. So here the actual specifications of the motor is considered and result is simulated. This motor uses a torque based field controller for an internal permanent magnet synchronous machine with an optional output loop speed controller. These are more accurate when compared to the Mapped motors. The following figure shows the Dynamic model of integrated motor-transmission powertrain system.
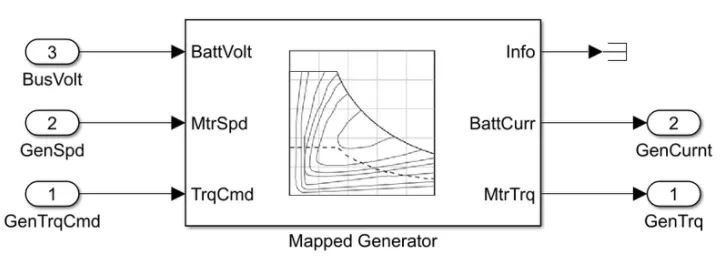
Mapped model Generator: In this model we have to give the specifications of Battery torque, battery current and others in the lookup table before simulating the result. Results are given on the basis of the data interpreted. The following figure shows the mapped model of generator.
Dynamic model Generator: Same as like Dynamic engine and motor, here also the actual details are taken into consideration and simulate the result. It performs real time simulation of components that actually takes place in real system. In model simulation gives detailed analysis. The following figure shows the dynamic model of the wind turbine generator.
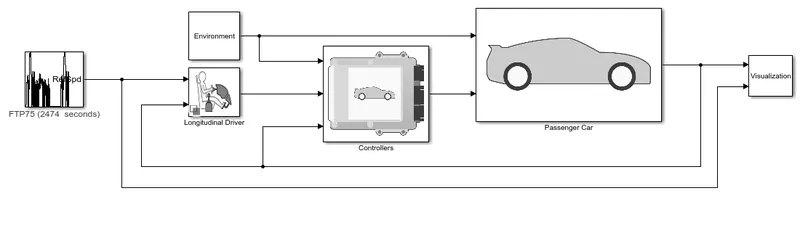
Steps to change the model type: Firstly we have to select the EV reference application model in simulink from the powertrain blockset. Which is shown in the following figure. Where click on the passenger car and open the electric plant.
After opening the electric plant block a window will appears which consists of Generator and motor model blocks. By right clicking on required block to change the model from one to another . After right clicking on that the following options wil appear from the choose the variennt option and change model from that.
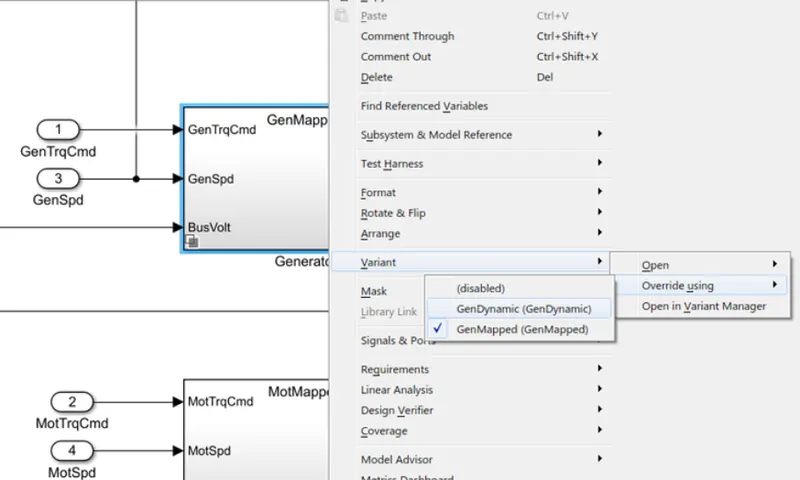
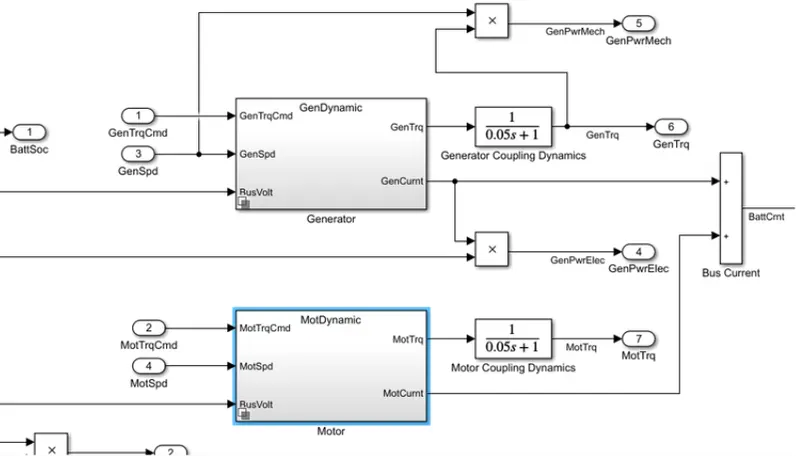
In the above figure we have changed the block model so now the changed blocks shown in the following figure.
2. How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Solution: Miles per gallon (mpg) are most commonly used in the United States, United Kingdom. When miles per gallons unit is used, it is necessary to identify the type of gallon used. The amount of fuel energy required to move an engine power car through a distance is determined and then it is compared to the equivalent amount of electrical energy required to move the car through the same distance and it is expressed as the miles per gallon. The powertrain blockset model calculates the miles per gallon for all kinds of vehicle. The following diagram shows the figure of HEv reference application block.
In the above figure there is a block name of visualization click on it to view the performance calculations. After open click on that a window will appears where there is a small block which represents the performanc calculations block which is shown below. Open the block.
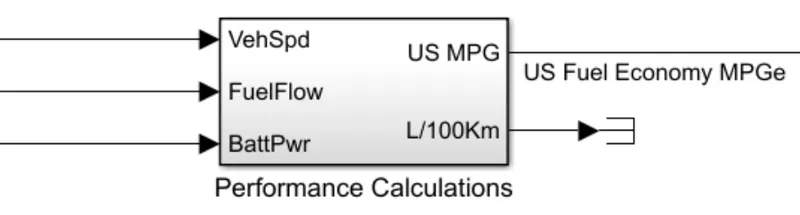
- After opening the above block we can see the following figure where all the calculation part takes place. Where we can see that Vehicle speed, Fuel consumption flow and Battery are taken as inputs. Where the vehile speed is an important factor while considering the fuel consumption at theat particular time. To convert the speed into distance we can integrate the speed with time and here also same procedure applied i.e. converting the velocity to get the distance by taking the integration block.
- Where the battery power is converted to Kw by dividing it by 1000. Battery power is then converted into energy KWH by multiplying it with the time. Then converting it from Kwh to euivaent energy in gallons we are diving it by 33.7. since we get the energy in kwh, to get it as gallons per second i.e. to convert from hour to sec we are dividing by 3600. Then US gallon per secong is multiplied by 0.0037841 to get the volume of fuel flow in m^3/g and also get multiplied with 739(density of gasoline) to get the mass flow rate in kg/s.
- Then the fuel is expressed as the mass flow rate that is the amount of fuel is in kg/sec. Now integrating this will results in the mass of fuel, and by dividing the mass with the fuel density we can convert it to the volume. By multiplying with 1000 we can get it in liters. By comparing the results will get to know the amount of consumed fuel to run for 100km.
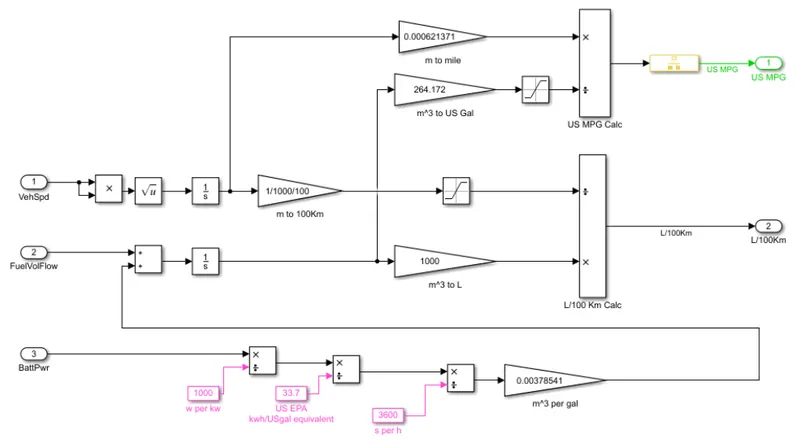
Now coming to major calculation part here we are taking the inputs from the above calculation. The vehicle distance is taken and it is converted to the miles by multiplying with 0.000621371. Then the inputs from fuel flow i.e. both Battery energy and Fuel energy which is in m^3 are converted into equivalent US gallons by multiplying with 264.172. Then two inputs Miles covered and equivalent US Gallon are further divided and the final result is achieved in MILES PER GALLON.
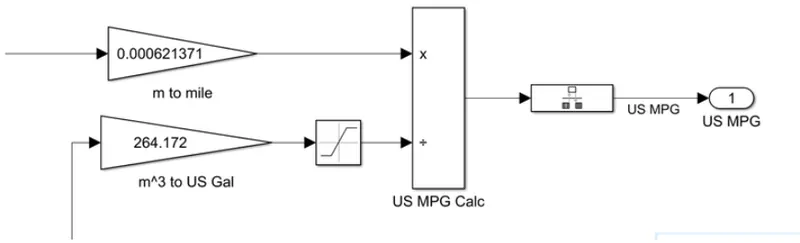
Factors are considered to model fuel flow: The factors which are considered to model fuel flow are Fuel economy and Fuel consumption.
Fuel economy: The fuel economy of an automobiles relatable to the distance covered by a vehicle and the amount of fuel consumed. Consumptions can be expresses as volume of fuel to Distance or the ditance traveled per unit volume consumed. The energy in the fuel is required to overcome various losses encountered while propelling the vehicle, and in providing power to vehile systems such as ignition or air conditioning. Drivers driving can also effect the fuel economy such as sudden accelaration and heavy braking will leads to waste of energy. The major facors in fuel economy are Vehicle speed, Engine speed and Motor torque.
Fuel Consumption: Fuel consumption is inverse of fuel economy. It is the amount of fuel which is consumed during the driving with a given distance or in a particular time.
3.Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
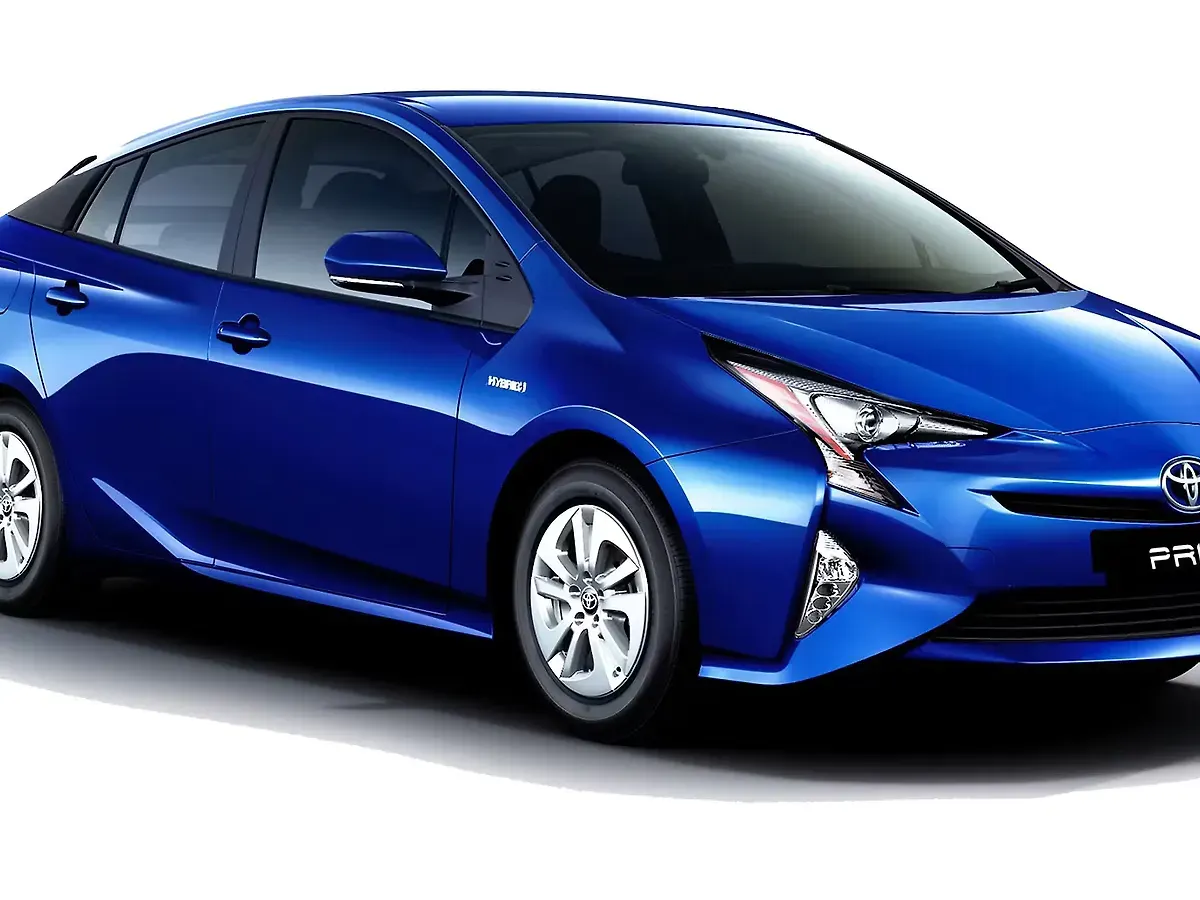
Solution: Hybrid Electric Vehicle(HEV) is a type of Hybrid vehicle that combines a conventional internal combustion engine (ICE) system with an electric propulsion system. The presence of the electric powertrain is intended to achieve either better fuel economy than a conventional vehicle or better performance. There is a variety of HEV types and the degree to which each function as an electric vehicle also varies. The most common form of HEV is the hybrid electric car, although hybrid electric trucks, buses, boats and aircraft also exist. Modern HEVs make use of efficiency improving technologies such as regenerative brakes which convert the vehicles kinetic energy to electric energy, which is stored in a battery or supercapacitor. Some varieties of HEV use an internal combution engine to turn on electrical generator, which either recharges the vehicles batteries or directly power its electric drive motors, this combination is known as a motor-generator. Many HEVs reduce idle emissions by shutting down the engine at idle and restarting it when needed, this is known as a start-stop system. If the engine is not used to drive the car directly, it can be geared to run at maximum efficiency, further improving fuel economy. The following figure shows HEV model of Toyota Pirus.
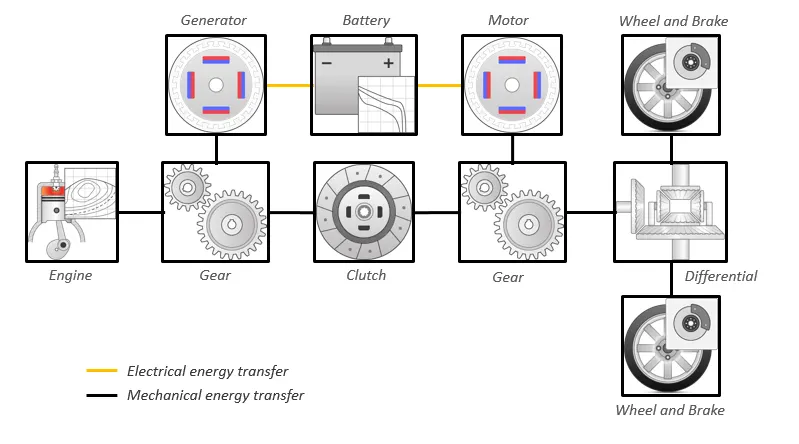
The following diagram shows the HEV architecture of Powertrain configuration.
From the powertrain blockset we have selected the Hybrid Electric vehicle (HEV) reference model. The following figure shows the simulink model of HEV.
First we have to change the drive cycle source mode to Wide Open Throttle(WOT). For this we have to double click on the drive cycle block and then the following windown will appears from there we have to change the mode of source.
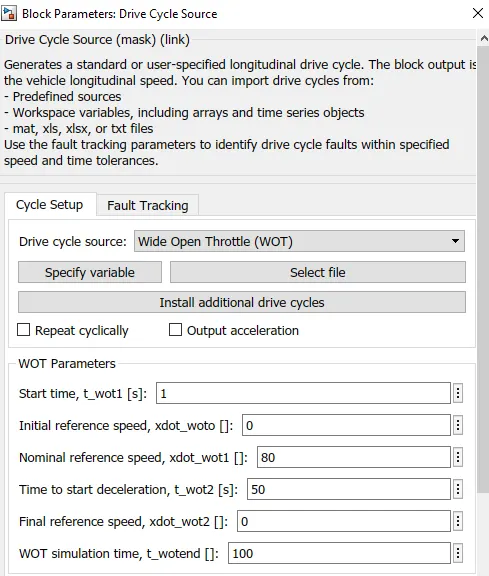
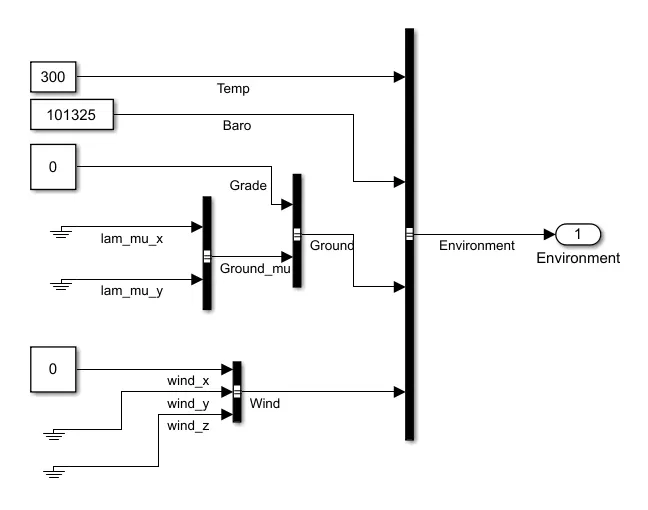
Where we are changing the values to as per our assumption here we are taking grade angle value as 0 degrees and wind velocity is 0 m/s.
The folllowing figure shows the simulation results of HEV. There are total 6 plots has been observed. Each plots represents different parameters. We can observe the every point by using cursor measurement. The cursor enables us to study the characterstics of other parameters corresponsing to the accelaration of the vehicle.
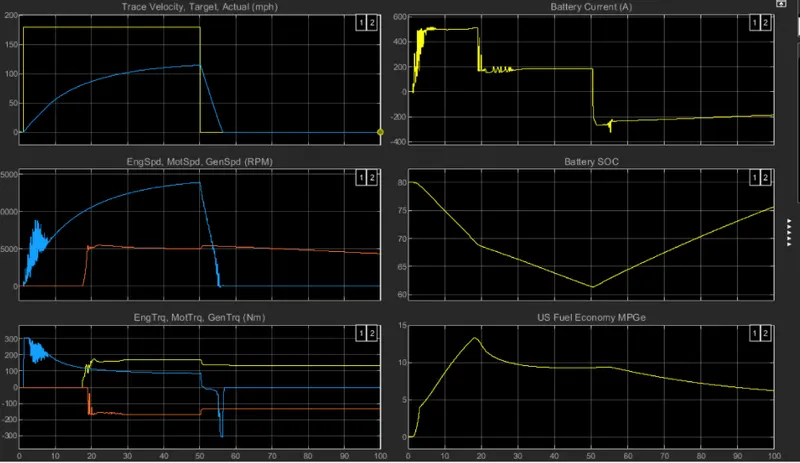
PLOT 1: Trace velocity , Target actual(mph)
This plot shows the velocity of the vehicle with respect to the driving cycle. The time value is taken on X axis. The accelaration time to reach 80mph is 16.6sec but the top speed is achieved at 115mph and taking to reach this peak is 48.71sec. The decelaration takes place from 115mph and this action takes 6.3sec.
PLOT 2: Engine speed, Motor speed, Generator speed
This plot shows the changes in speed of engine, motor and generator in terms of RPM through out the driving cycle. The supply power from the battery is observed and distributed by control system that power is generated to motor. Here the peak engine and generator speed is 5437, generator speed is 13872RPM.
PLOT 3: Engine torque, Motor torque, Generator torque
This plot shows the torque characterstics and its change in Engine, Motor and generator. The raise of velocity in vehicle at intial stage is driven by the supply of torque. The peak engine torque is 174Nm and Motor is 302Nm. Generator has no torque.
PLOT 4: Battery Current (A)
This plot shows the Battery current values in amperes and its change for various accelaration inputs as per the given drive cycle. Peak current discharge from battery s 502A and peak current charge the battery is -150.8A.
PLOT 5: Battery SOC
This plot shows the Battery State Of charge(SOC) in % and its changes corresponding to the given inputs. The SOC is decreased from 80% to 61.2% of charge in 44.3sec. The SOC refers to the recharging condition of battery during the decelaration process.
PLOT 6: US Fuel economy MPGs
This plot shows the Fuel economy in US miles per Gallons. This calculates the milage of vehicle during the accelaration of vehicle. The maximum miles that car can run per Gallon of fuel is 13.45mpg.
Case 2
In this case we are changing the values of grade angle to 8° and wind velocity to 10 m/s. Then the plot results are as shown in the following figure.
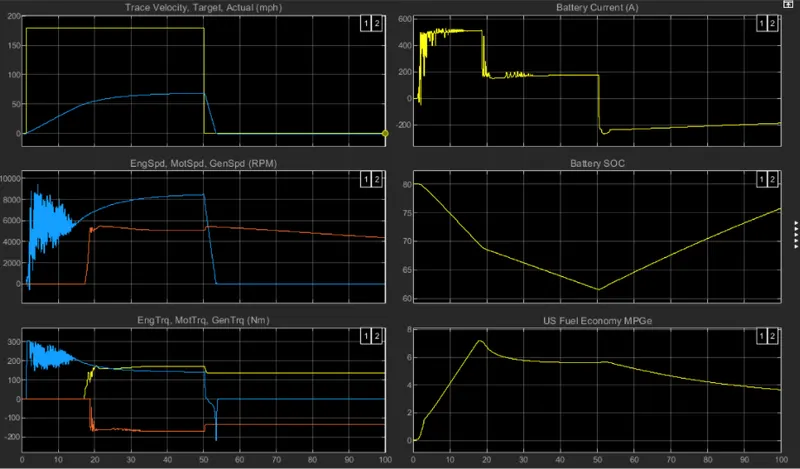
PLOT 1: Trace velocity, Target Actual (mph)
This plot shows the velocity of the vehicle with respect to the driving cycle. The top speed can not be achieved as we have some additional forces acting and so car can only run upto 67.3mph. The accelaration time to reach this value is 44.5sec and from here decelarate it takes 5.04sec. The torque of vehicle to obtain the velocity is low when compared to the previous model.
PLOT 2: Engine speed, Motor speed, Generator speed
This plot shows the changes in speed of engine, motor and generator in terms of RPM through out the driving cycle. Here the peak engine and generator speed is 5620RPm, generator speed is 9460RPM. Due to change in the gradeability these values are different from the default one.
PLOT 3: Engine torque, Motor torque, Generator torque
This plot shows the torque characterstics and its change in Engine, Motor and generator.The peak engine torque is 178Nm and Motor is 304Nm. Generator has no torque. The torque values are raised due to presence of wind velocity.
PLOT 4: Battery Current (A)
This plot shows the Battery current values in amperes and its change for various accelaration inputs as per the given drive cycle. Peak current discharge from battery s 510A and peak current charge the battery is -152.4A. Battery supply is also high. Sometimes generator is acting as recharge system.
PLOT 5: Battery SOC
This plot shows the Battery State Of charge(SOC) in % and its changes corresponding to the given inputs. The SOC is decreased from 80% to 62.2% of charge in 49.23sec. SOC is not acting at the same point when the slope portion is obtained and torque will reduced.
PLOT 6: US Fue economy MPGs
This plot shows the Fuel economy in US miles per Gallons. The maximum miles that car can run per Gallon of fuel is 17.93mpg. Fuel economy is high due to wing and grade angle.
Conclusion:
The top speed reached by the vehicle is less in case 2 compared to case 1 due to presnce of grade angle and wind force.The SOC is also shows that the discharge is high compared to default model. Fuel economy is also down in case2. So we can say that the efficiency of no load vehicle is high compared to the vehicle with additional loads and force acting on them.
4. Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
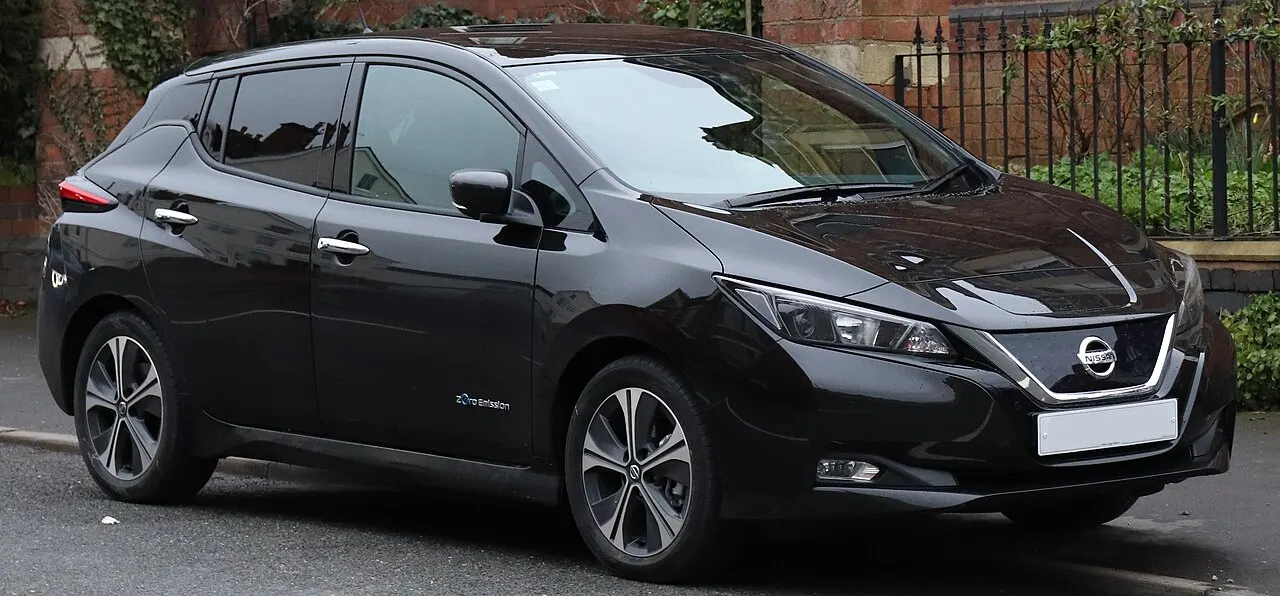
Solution: An electric car, battery electric car, or all electric car is an automobile that is propelled by one more electric motors, using only energy stored in batteries. Compared to the Internal combution engine (ICE) vehicles, electric cars are quiter, have no exhaust emissions, ad=nd lower emissions overall. In the US and European Uninion, as of 2020, the total cost of ownership of recent electric vehicles is cheaper than the equivalent ICE cars, due to lower fuelling and maintainance costs. Charging an electric car can be done at a variety of charging stations. These charging stations can be installed in both houses and public areas. Many countries have established governament incentieves for plug in electric vehicles, tax credits, subslides, and other non-monetary incentives while several countries have legislated to phase out sales of fosill fuel cars to reduce air pollution and limit climate change. The following image shows the pure electric car model of Nissan Leaf.
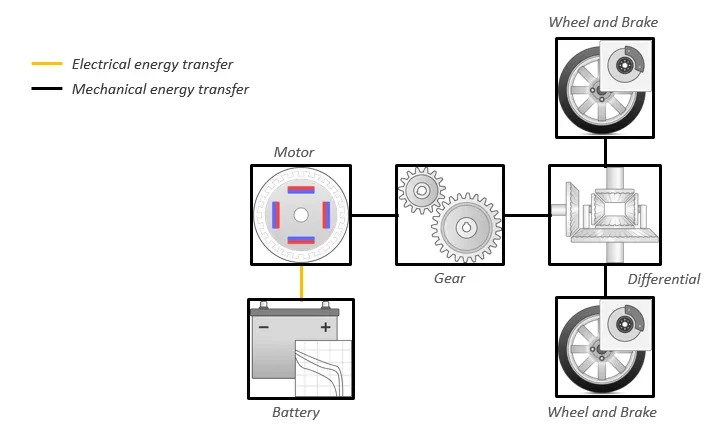
The following diagram shows the Architecture of Electric Vehicle.
As per the previous here also we are taking the Drive cycle source as WOT (Wide Open Throttle) and same parameter values are taking to compare the both Models. Taking grade angle is 0° and wind vlocity as 0 m/s.
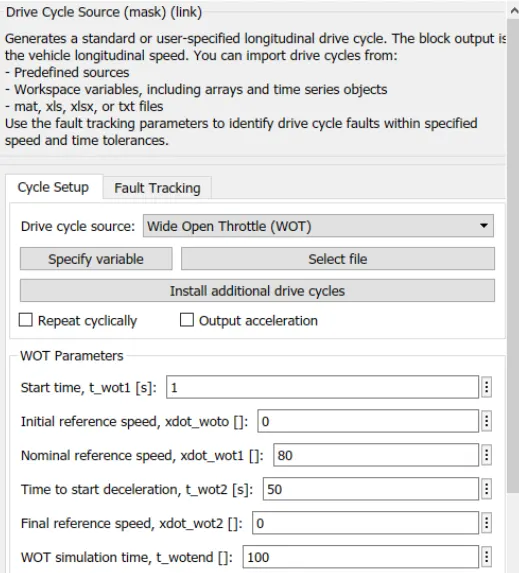
With the above values the simulation results are generated as shown in the following figure.
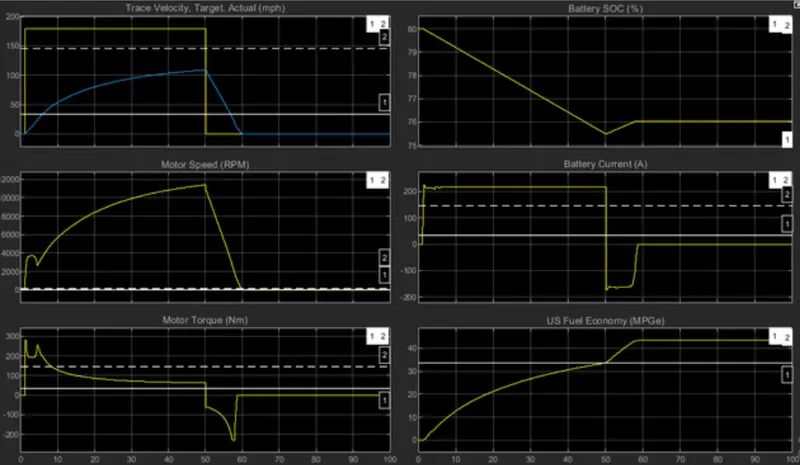
Same like the previous model here also showing 6 plots of different parameters.
PLOT 1: Trace velocity, Target Actual (mph)
This plot shows the velocity of the vehicle for the drive cycle data with the Time on X axis. The top speed is obtained here at 109.2mph. The acceleration time to reach 109.2mph is 48.9sec. And the decelaration time from this point to minimum point is 10.51sec.
PLOT 2: Engine speed, Motor speed, Generator speed
This plot shows the speed variations of Engine, Motor and Generator throughout the drive cycle. In this model the maximum speed is 11410.01RPM.
PLOT 3: Engine torque, Motor torque, Generator torque
The plot shows the Torque values of Engine, Motor and Generator with respect to the given inputs. Maximum Motor toque is acieved at 280.763 Nm.
PLOT 4: Battery Current (A)
This plot shows the Battery current values in amperes and its variations corresponding to the accelaration inputs. The peak current discharge from battery is 224.691A and the peak current charging the battery is -170.75A.
PLOT 5: Battery SOC
This plot shows the SOC values in terms of %. The SOC decreased from 80% to 75.48% of charge in 49.21sec for the specified driving conditions.
PLOT 6: US Fue economy MPGs
The plot shows the Fuel economy as Miles per Gallons for the inputs through the driving cycle. The highest Miles per Gallon is 43.81mpg.
Conclusion:
Here we are comparing the default models of the both models i.e. HEV and EV. The Electric vehicle when compared to HEV with same environmental drive cyclle conditions results in less top speed achievement. As the pure electric car here uses Lithium-ion battery compared to the Nickel metal hydride battery, the discharging capacity and the rate of charging is higher in pure electric car. The HEV allows the battery to compensate the required power by the vehicle and generator helps charge the battery at faster rate which allows to travel the vehicle over long distances. The SOCshows the battery efficiency of the pure EV is higher than the HEV. Electric vehicle produces 0 emissions whereas HEV produces waste gas emission.