Week-4 Challenge WOT Condition Part-2
AIM 1: What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Solution : A powertrain blockset constitutes of 2 types of combustion engine models , namely ; Mapped and Dynamic .
Mapped engines models are used to represent macro engine behavior and measure performance of the vehicle system as a set of steady state lookup tables (brake torque, fuel flow, exhaust temperature, air mass flow, efficiency, and emissions) as functions of commanded load and measured engine speed.Results are obtained from all these inputs. Static model is used for quasi steady-state engine simulations
Dynamic engine models are used todecompose the engine behavior into smaller individual component models that account for engine dynamics, intake airflow and turbocharger dynamics. They utilize the data received from all the sub systems or sub components to characterize the performance of engine in real time .Dynamic model engines are used when we have component-level data . They are mainly used to study the impact of individual engine components on the overall performance.Using this model we get to know about all the dynamic effects of the vehicle.
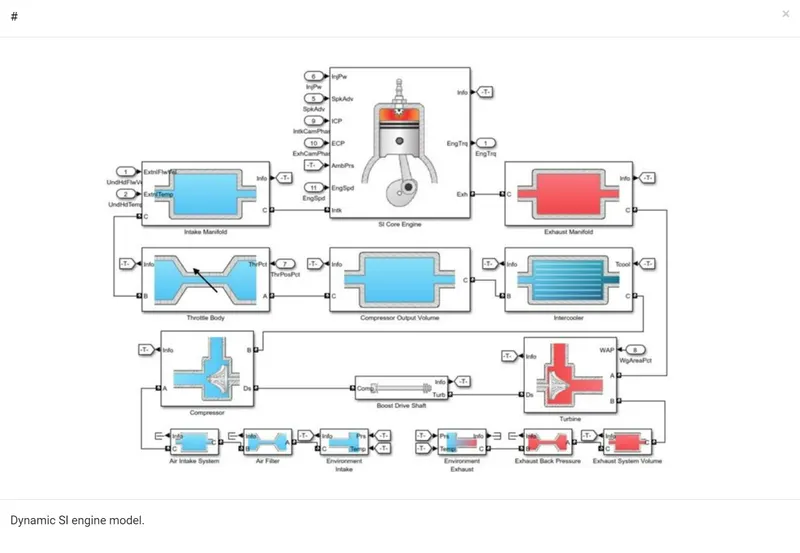
Mapped Motor : This model of motor runs in Torque control mode. We use mapped motors when details of the components of the motor are not known to us and also if we require quick simulation of the system
Dynamic Motor : This model is used when all the parameters are known to the user. Dynamic models are much more accurate than the Mapped motors.
Similar conditions apply for the Dynamic and Mapped Generators too.
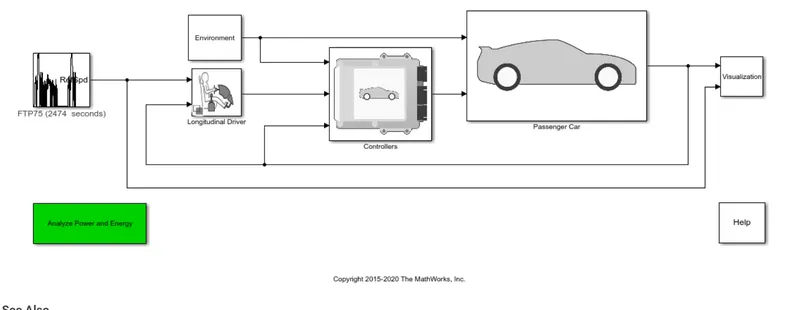
We open the EVreference application . From the Passenger car block
To change the model type , we should go to the MODELLING and From there Select Variant Manager
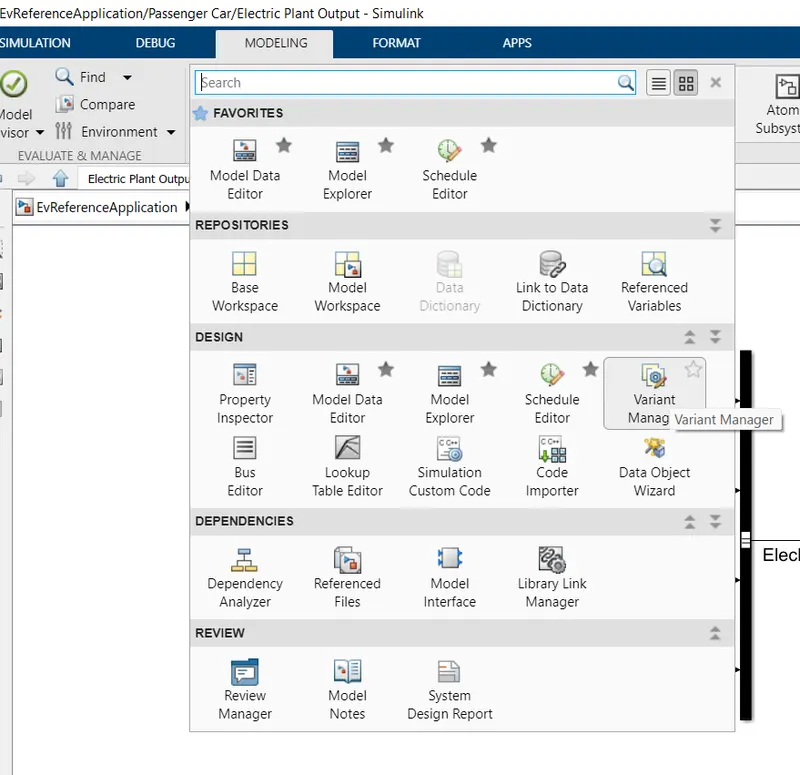
And then choosing the model and using the Label mode active choice , choose Dynamic or Mapped or weswitch from Mapped to Dynamic model . 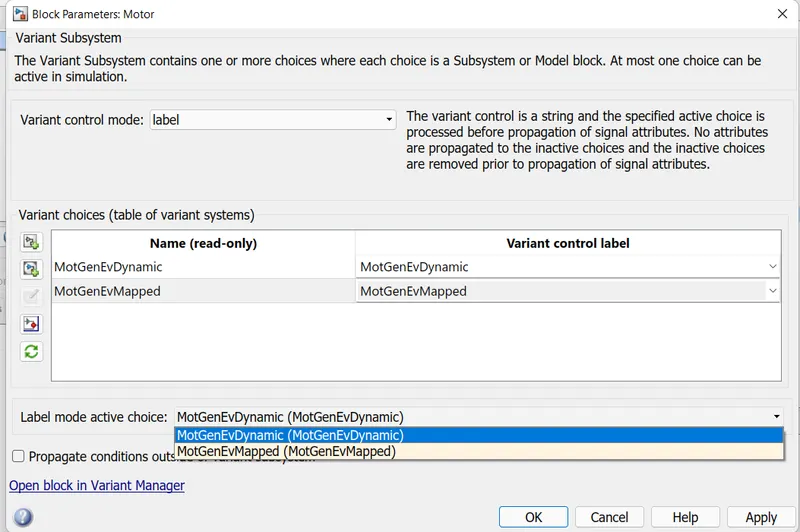
Similarly using the same method we can change from Dynamic to Mapped or vice versa for Generator,Motor and engine model .
AIM 2 : How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Solution : We use the example used in the previous situation as the EVReferenceApplication.
Then EVReferenceApplication > Visualization > Performance Calculation
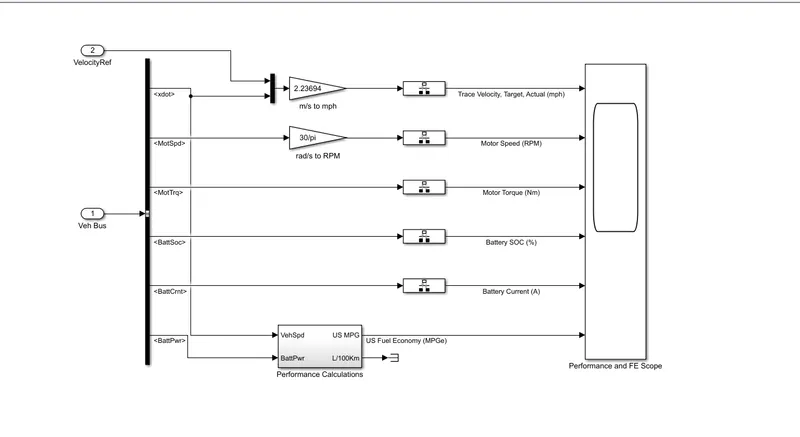
The inputs which can be used as fuels are Electricity from the Battery and also the normal fuel . 1 kwH ( OR 1 Unit ) battery can run the vehicle for 3.125 miles . 1 gallon of fuel can be assumed as 33.7 kWh of electricity which leads to 105 miles.
On opening the Performance calculator block we get :
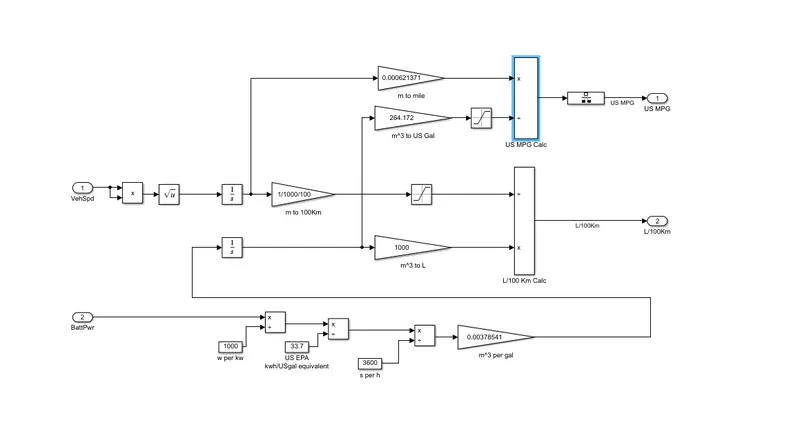
Using the following calculations we can calculate the Miles per gallon .
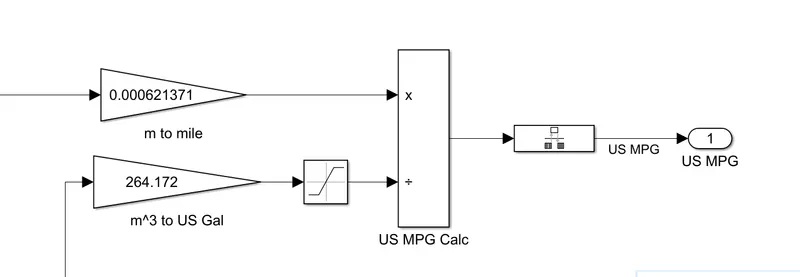
fig1.
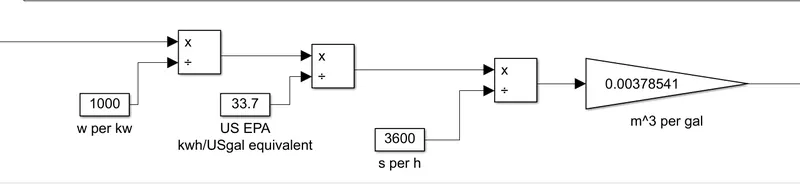
fig2.
IN Calculating the Fuel flow for the model ,the inputs used are vehicle input , Battery power and also Fuel Volume flow .
Since 1 gallon is equivalent to 33.7 kWh ( or units ). So the batter power capacity is divided by this constant 33,7 and then after getting converted into the gallon equivalent , this battery equivalent gallons is added to the normal fuel flow. Total distance can be calculated with the speed and time . The distance will be then converted into Miles. SO using all these above data the fuel efficiency can be easily calculated .
AIM 3 : Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
Solution : In the command window on typing "autoblkHevStart" we get the required HEV model
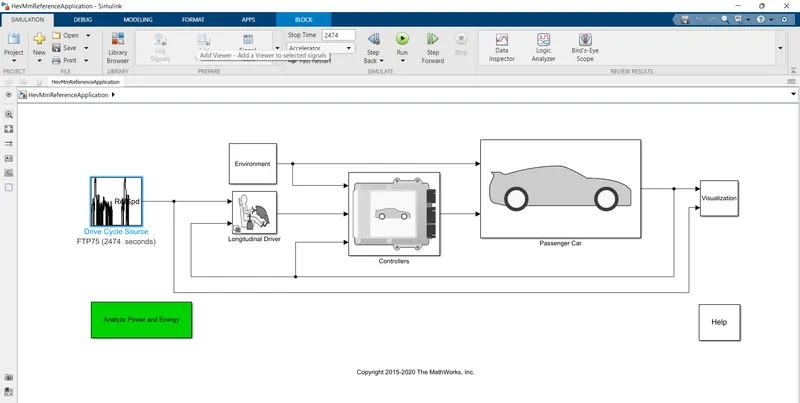 .
We are running this in WOT driving cycle. So from the Drive cycle block we change the Driving cycle to Wide Open Throttle ( WOT ).
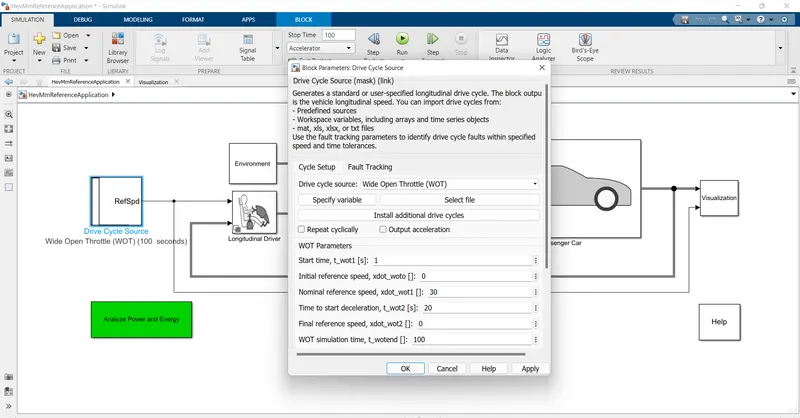
On running the simulation with original parameters. we get the following result as the output :
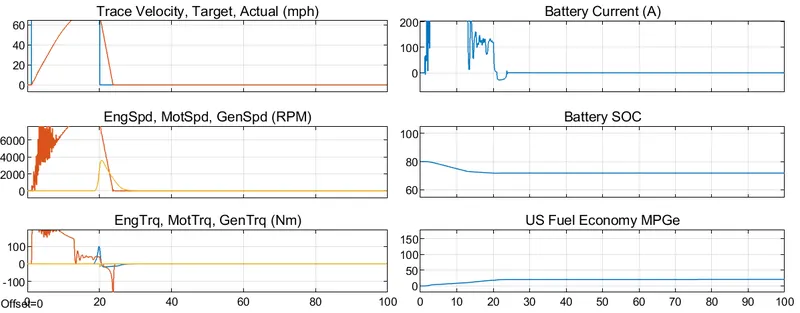
In the first graph Trace velocity we compare Trace velocity of the ideal WOT Cycle to the Actual WOT Cycle for the given parameters .
The second graph shows the speeds of the motor and generator. We can see a rapid increase in the motor speed after a constant run. Finally it decelerates and becomes zero .
The third graph compares the torque of the motor and generator .Initially motor torque is very high ( full throttle ) for few seconds and gradually it reduces and both the machines have the same torque .
In the 4th graph we can see Battery current , initially there is a heavy usage of the battery until the engine is ON and the vehicle runs completely on the support of battery . Once the engine is ON, then it is seen that the battery current is reduced gradually due to shared usage of fuel .
In the fifth graph SOC is shown , which gradually decreases with the running of the vehicle .
Now we change the parameters like Grade and Wind velocity :
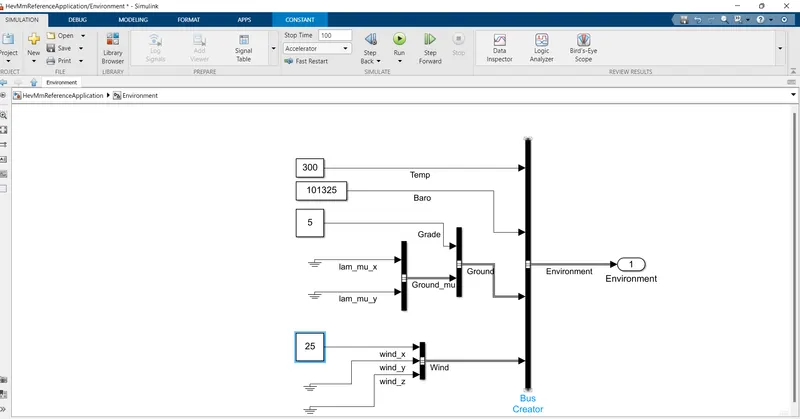
Output of the Simulation :
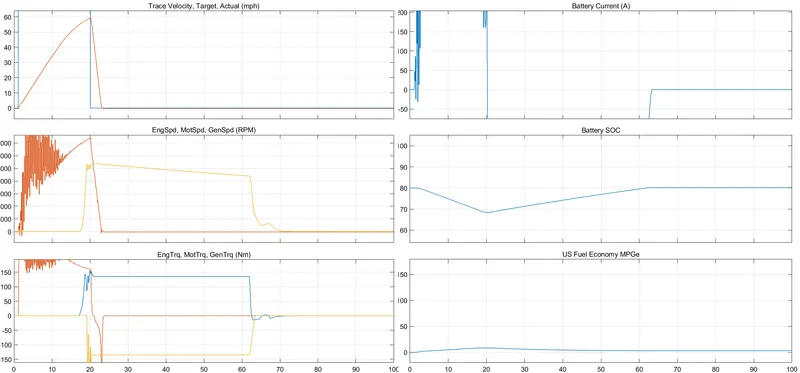
Grade is changed to 5 degrees and The wind velocity is now 25 m/s.
In the first graph Trace velocity we compare Trace velocity of the ideal WOT Cycle to the Actual WOT Cycle for the new changed parameters.
The second graph shows the speeds of the motor and generator. We can see a rapid increase in the motor speed after a constant run. Finally it decelerates and becomes zero . It is also seen that in the fourth graph battery current increases when there is increase in the speed .
Now there as a change in SOC , from the earlier simulation . Here we can see that initially SOC decreases , but then it gradually increases with the time . This is because of the regenerative braking .
Torque charactersistics also show that generator has a negative slope graph . But motor initially has a very high torque and then gradually decreases .
There is no much improvement in the efficiency of the engine though .
AIM 4 : Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
Solution : For running this simulation we change the drive cycle to WOT . With Grade 5 degrees and Wind speed as 25 m/s .
RUN HEV Model by typing autoblkHevStart in the Command Window :
Drive cycle used here is WOT .
OUTPUT SIMULATION :
Now we run the EV reference Application by typing autoblkEvStart in the Command Window :
We run this model also in the same WOT Drive Cycle :
OUTPUT SIMULATION :
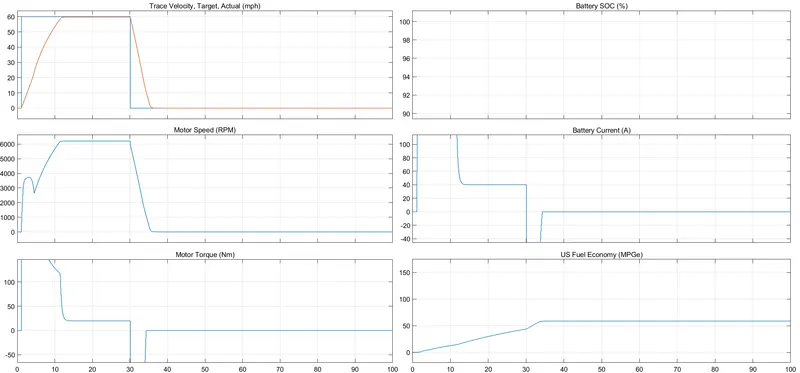
So we have obtained the OUTPUT Of both the EV and HEV reference applications.
On comparing the result and analysing we can see that all the graphs of EV Reference Application are very much stable while comparing to the HEV model .
1. In the first graph we see the Trace velocity , which are similar in both the Systems .
2. In the second graph we can see the Speed . Speed in EV is only the Motor Speed which is very neat and stable with less distortions, while in the HEV model there is a generator speed also which is very much distorted .
3. The third graph shows the torque , which is also similar to the Speed. HEV model has so many distortions but the EV Model gives a stable result .It is evident that the Peak RPM in HEV Model is high compared to the EV Model .
4. Battery current in HEV is very high initiallly and then slowly it decreases. This happens because initially the Vehicle runs only on the battery and only after the engine starts it helps the motor to run and thus battery current decreases.
5 . Efficiency of the HEV is less compared to the EV because the engine is always less efficient because of the Heat losses . .
6 . SOC of the EV model is improved by a value of 2% during deceleration, but HEV has something like 15% because of regenerative braking durng deceleration . So HEV has a better SOC than EV .