Week 2- 2R Robotic Arm Challenge
2R robotic arm
Aim- To write a programin matlab to simulate the forward kinematics of a 2R Robotic arm.
Code-
clear all
close all
clc
%inputs
l1= 1;
l2= 0.5;
theta1= linspace(0,90,10);
theta2= linspace(0,90,10);
ct= 1;
for i= 1:length(theta1)
THETA1= theta1(i);
for j=1:length(theta2)
THETA2= theta2(j);
x0= 0;
y0= 0;
x1= l1*cosd(THETA1);
y1= l1*sind(THETA1);
x2= x1+l2*cosd(THETA2);
y2= y1+l2*sind(THETA2);
%plotting
figure(1)
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis([0 2 0 2])
pause(0.1)
M(ct)=getframe(gcf);
ct= ct+1;
end
end
movie(M)
videofile=VideoWriter('forwrad_kinematic.avi','Uncompressed AVI')
open(videofile)
writeVideo(videofile,M)
close(videofile)
Animation-
Explaination of codes-
clear all - This command is used to clear all the data stored in the workspace
close all- This command is used to close all the fig and plots
clc- This command is used to clear the command window
Important note- To move the robotic arm continously we are using for loop
for i= 1:length(theta1)
THETA1= theta1(i);
for j=1:length(theta2)
THETA2= theta2(j);
Error-
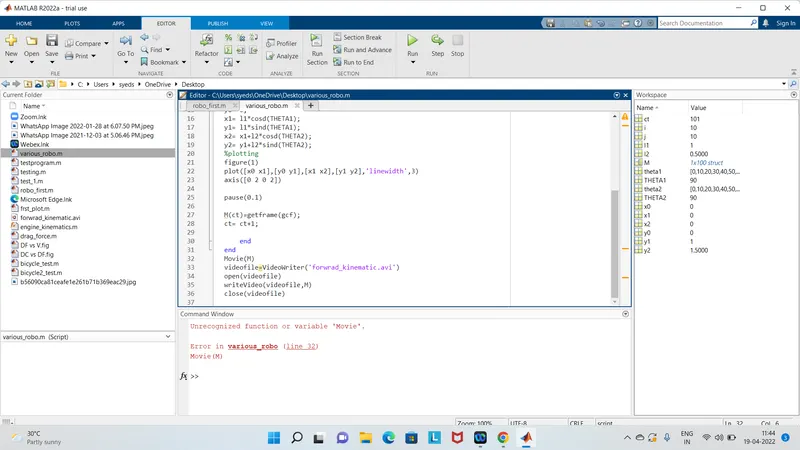
Chnages- Replaced Movie to movie