Week-11 Challenge: Braking
1. Energy required for braking calculation by drive cycle:
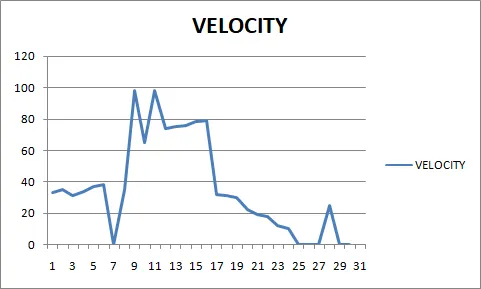
Drive cycle has been created in xcell file
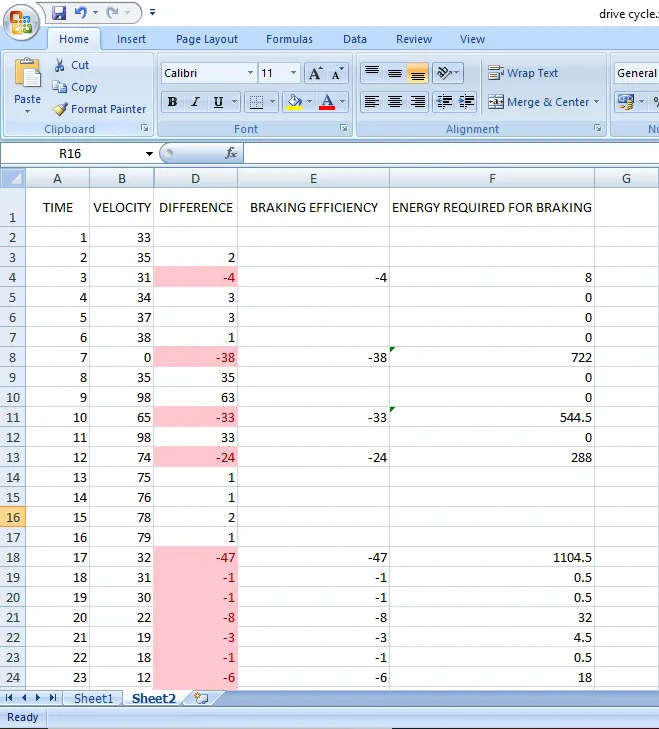
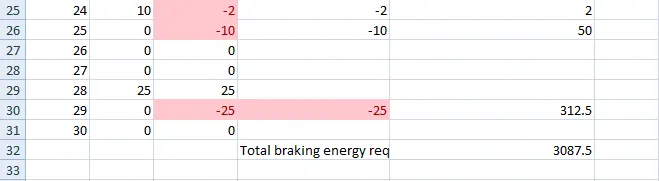
Mass is assumed as 1000kg
formula of energy is = 0.5*M*V^2
Graph of energy required for breaking:
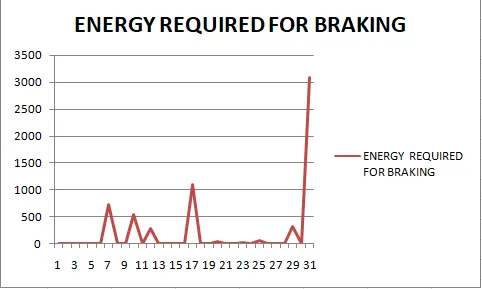
This graph is based by the drive cycle.
x-axis is time and y-axis is energy.
Drive cycle:
2.Brake torque at high speed:
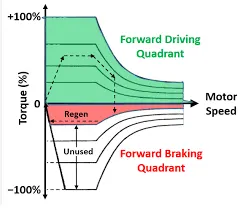
- Here it is clearly shown in the first graph that till the motor reaches the critical speed it has constant torque and once it reaches the critical speed, the curve is having a down slope which is a constant power region.
- And this graph denotes the accelerating operation of the motor. For the deceleration or braking operation of the motor, this graph is mirrored down which will be having the speed (+ve) and torque (-ve).
- we can say that an EV can achieve 0-100 kmph in 10sec.
- Acceleration operation goes this way, with low speed and high torque Constant torque region is achieved which has accelerating power and by reaching the critical speed it shifts to constant power region and thus it easy for an EV to reach 0-100 kmph.
- As said the breaking operation graph will be th mirrored image of above plot.
- So we cannot say that the motor producing 7Nm torque for acceleration can also produce -7Nm for breaking.
- Because we are operating in the field weakening region, and operating above the base speed.
- Thus Peak Acceleration torque is greater than the Peak Deceleraion torque.
- Thus for acceleration it has high torque with low speed and for deceleration it has low torque for high speed.
B.How electric and mechanical brakes are coordinated?
- Electric drive intelligent brake (EDIB) IS THE COORDINATION OF THE BRAKES.
- There are 2 combinations one is series and other is parallel.
- Series : both mechanical and electrical are opperated at one after another, so they are connected in series.
- Parallel : both mechanical and electrical are opperated ata same point and time.
- Low speed of the motor requires high regenerative breaking force.
- High speed of the motor requires both combined of mechanical and regenerative braking force.
- Combined of control of mechanical and regenerative braking is sensed by the position of braking pedal.
- So the power controller diverts the signal to the hydraulic or regenerative breaking.
- And again regenerative brake signal goes to the power converter.
- At low speed we get high braking torque.
3. Motor speed, torque and efficiency values.
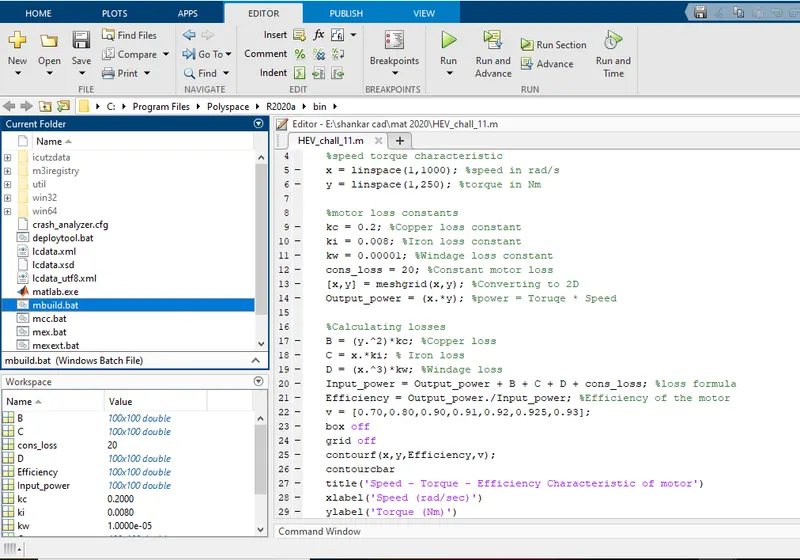
Script:
Program Description:
- Here in this program first two inputs were given. They are Speed & Torque using linspace command.
- Then the motor constant values are assigned namely Copper loss, Iron loss, Windage loss and Constant motor.
- Then meshgrid is used to evaluate functions of two variables and three-dimensional mesh/surface plots.
- Output Power is calculated by multiplying speed and torque.
- Then all the loss were calculated and the input powers were also calculated.
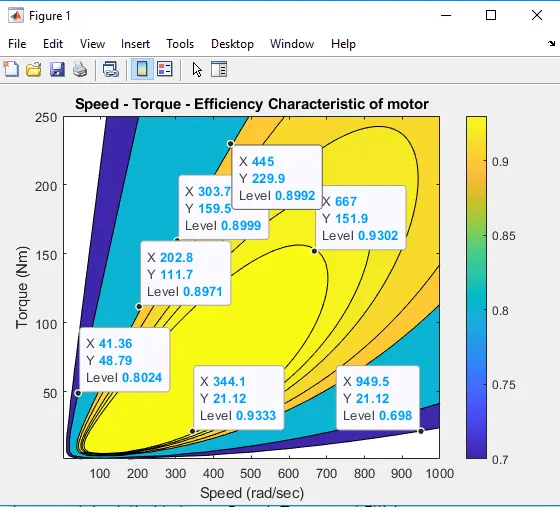
- Then comes the efficiency were calculated. And Contour graph is plotted between Speed, Torque and Efficiency.
- Title were given and labels were given.
Graph: