Week-11 Challenge: Braking
1. For a defined driving cycle, calculate the energy required for braking.
The energy required for acceleration or deceleration is nothing but the kinetic energy required by the vehicles.
The energy required for acceleration is equal to the energy required to decelerate. In both cases, external energy is given to accelerate and decelerate respectively.
Which is equal to `E = 1/2*m*v^2`
To calculate braking energy of a vehicle we have to consider the initial speed and the final speed of the vehicle to determine the kinetic energy required.
Braking Energy (BE) = `1/2*m*(u^2-v^2)`
Where,
m = mass of vehicle (Kg)
u = initial velocity (m/s)
v = final velocity (m/s)
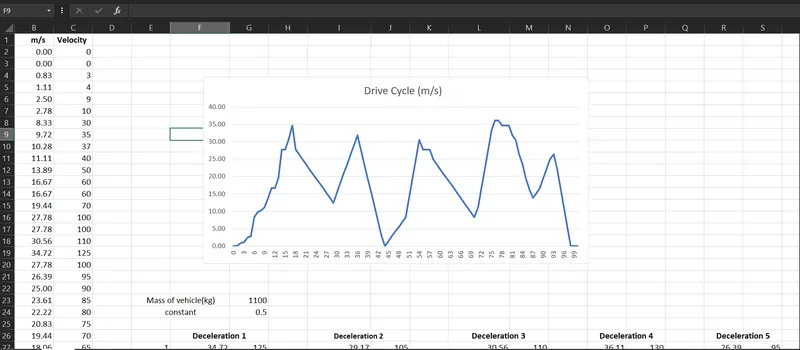
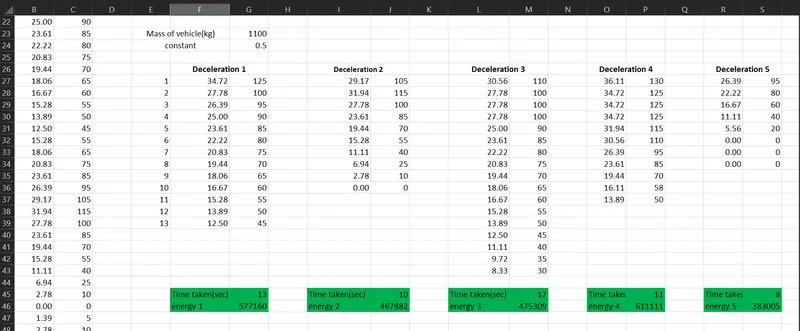
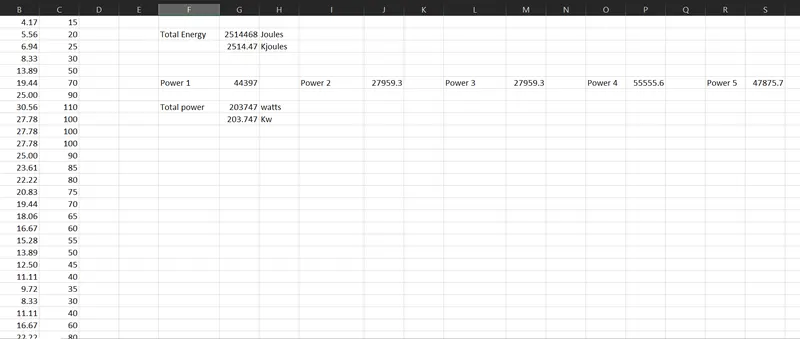
We calculated the brake energy and power using an excel calculator.
The snaps of the excel is given below.
The total energy for braking is = 2514.47 kJ
The total power for braking is = 203.7469 kw
2. Why electric motor can’t develop braking torque at a high speed similar to starting? How electric and mechanical brakes are coordinated?
The above figure represents the two quadrants of the motor operation where in the first quadrant both torque and speed are positive (Forward Motoring) and in the fourth quadrant the speed is positive and the torque is negative (Braking).
At high speed, the torque will be less and operates at a constant power region hence it is difficult to bring the vehicle to rest or decelerate immediately. The peak acceleration torque is greater than the peak deceleration torque. Hence braking torque of the EV motor is not as high as acceleration torque.
The term braking comes from the term brake. We know that brake is equipment to reduce the speed of any moving or rotating equipment, like vehicles, locomotives. The process of applying brakes can be termed braking. Now coming to the term Braking. We can classify the term in two parts -
- Mechanical Braking- It is mostly used in scooters, motor vehicles, and motorcycles where small power is required. It is essential in manufacturing power transmission applications, material handling, etc. It delivers forces to the axle or a wheel to stop motion. It helps reduce the speed of the system slowly by the mechanical process compared to electrical braking. The working of a mechanical break depends on the pedal. When the pedal is pressed, the brake shoes are pushed outwards and rotates against the drum which is connected to the wheels. Hence the machine or vehicle gets slow down and stopped. And when the pedal is released, it goes to normal position due to the pullback action of spring shoes. Ex- Drum Brake, Band Brake, Hydraulic Disc Brake
- Electrical Braking- It is used to reduce the speed of the machine depending on flux and torque. This type of braking is mainly used for functional braking to control the speed of the machine. It is easy to handle and comfortable. But it cannot be used for emergency braking and parking braking. Ex- Eddy current braking, Dynamic resistor type braking, Regenerative braking, Sharing DC bus type braking.
Both mechanical and electrical braking system can be used as desired by making control strategy in two ways
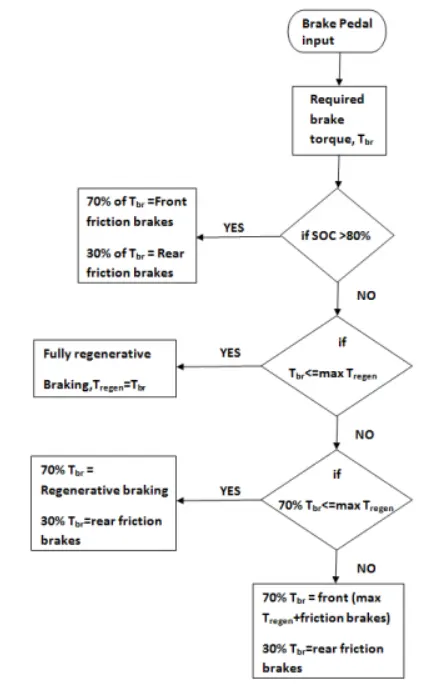
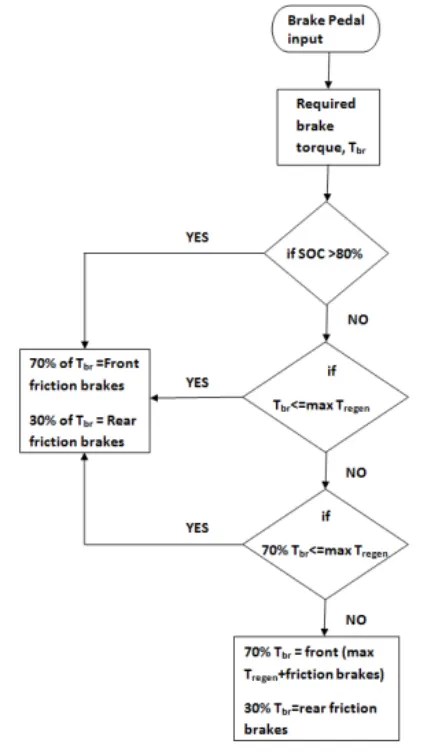
- Series Braking Strategy- Once the brake pedal is pressed and depending on the level of depression, a brake torque is sent. Now, this break torque passed into the brake control strategy block. Firstly, it is checked if the battery state of charge is below 80%, which is set as the maximum permissible level of charge. If that condition is satisfied then the battery is recharged. The brake torque requested is compared to the maximum regenerative torque limit of the motor-generator. If the overall brake torque requested is less than or equal to the maximum regenerative torque, then the vehicle brakes purely on regenerative torque, and the battery is charged. The amount of charge ultimately put in depends also on the motor-generator operation efficiency and the battery charging efficiency. If the overall brake torque requested is greater than what the motor-generator, then the friction brakes kick in. Now since the vehicle is front-driven, it is checked if the total brake torque requested from the front is less than or equal to the maximum regenerative torque capability of the motor-generator. If yes, then front braking is provided purely by regeneration and real by friction. Once the total brake torque request increases further, then front friction brakes come into play in combination with real friction brakes and front regenerative braking, to satisfy the overall brake torque demand. This has been represented in a flow chart manner.
- Parallel braking strategy- Once the brake pedal is applied and desired overall brake torque request is sent from the driver block. This braking torque on passing through the brake control strategy gets divided between regeneration and friction braking at all times. The strategy is so modeled with the comfort and brake pedal feel in mind. As parallel regenerative braking is an add-on to conventional systems, it is devoid of any integrated control. So to make the transition and performance of regenerative braking with friction smooth, it is assigned in such a way that, there is a clear division between the amount of brake torque that will be achieved from regeneration and friction braking. On application of brakes and in keeping with the design of the motor-generator it is designed to operate generator is a constant generator torque region. Motor generators can provide a maximum of 322 Nm of generator torque at or under the base speed. The generator is scaled such that the base speed of the generator corresponds to a velocity of 124 kmph, which is the maximum speed limit on most highways. Hence regeneration works, as long as the vehicle is braking from a speed of under 124 kmph and the requested brake torque on the front-driven wheels, after the front-rear brake split is greater than or equal to maximum generator torque. If that condition is satisfied, then regenerative and friction braking operates in tandem else it's just the friction brakes at the driven and non-driven axle. This has been represented below.
3. Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
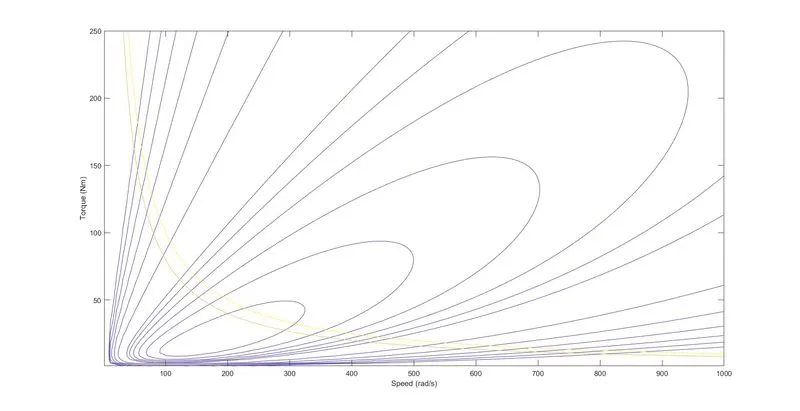
The contour plot for the motor speed, torque and efficiency are given below.
Matlab code-
clear all
close all
clc

% Determining the Speed domain (rad/s)
x = linspace(1,1000);

% Determining the Torque range (Nm)
y = linspace(1,250);

%% Defining the motor loss constants

% For Copper loss
Kc = 0.2;

% For Iron loss
Ki = 0.008;

% For Windage losses
Kw = 0.00001;

% For Constant motor losses
ConL = 20;

%% Power Calculations

% Meshing speed and tprque in space to create a 2D array
[X,Y]= meshgrid(x,y);

% Output Power
Po= (X.*Y);

% Copper Losses
L1 = Kc.*(Y.^2);

% Iron losses
L2 = Ki.*(X);

% Windage losses
L3 = Kw.*(X.^3);

% Input Power
Pi = Po + L1 + L2 + L3 + ConL;

% Efficiency
n = Po./Pi;

% The efficiency's that we have to include
V = [0.60,0.65,0.70,0.75,0.80,0.85,0.90,0.91,0.92,0.93,0.94,0.95,];

%% Plots
grid on
contour(X,Y,n,V)
xlabel('Speed (rad/s)')
ylabel('Torque (Nm)')
hold on

% Plotting contours of Output Power at 8kw and 10kw
V = [8000,10000];
contour(X,Y,Po,V)
Cotour Plot
P.S: The required files are attached below.