Week-11 Challenge: Braking
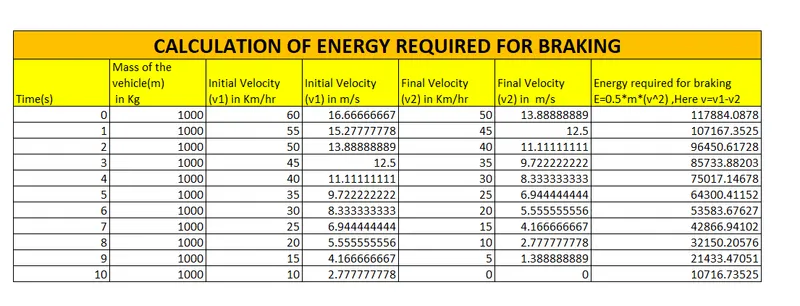
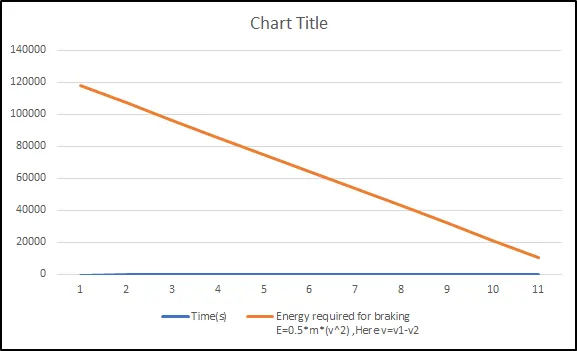
- For a defined driving cycle, calculate the energy required for braking.
Braking is the process of controlling the velocity of an object by inhibiting its motion.
An object in motion possesses kinetic energy and to bring the object to a stop this kinetic energy must be removed. Removing the kinetic energy can be accomplished by dissipating the energy to the atmosphere through friction or by converting it into another form of energy. The most common type of braking is a mechanical brake which inhibits motion through friction brake pads. A mechanical brake applies a friction force to convert the kinetic energy of the vehicle into thermal energy which then dissipates into the atmosphere.
Braking systems which don't use friction are referred to as Regenerative Braking System (RBS). In RBS,
the kinetic energy is converted into other forms of useful energy, which can be stored for later use, increasing fuel efficiency.
As with any system, the process of braking must follow the principal of conservation of energy. Energy cannot be created or destroyed but only
converted from one form to another,
The BE(braking energy )depends on initial and final velocity of the vehicle.
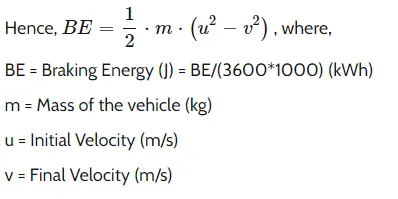
Excel calculator for calculating BRAKING ENERGY:
- Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
When the motor is at rest and it has to operate from standstill position to the reach the moderate speed the higher torque is required to bring the motor in operation. Whereas when the vehicle is already at high speed the capping or the limit is reached by the motor operation and thus any further higher torque could not be obtained while braking. The braking operation happens in the motion which is been distributed as per proportion in the BRAKE ENERGY and the REGENERATIVE BRAKING.
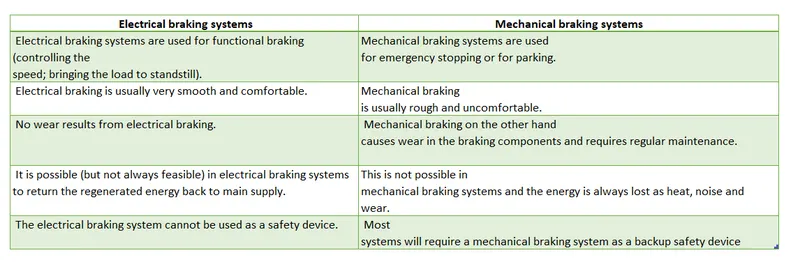
Braking systems are necessary for the correct and safe operation of mechatronic systems. Most functional braking is achieved using electrical braking, which is made possible by the addition of a variable speed drive system (e.g., variable frequency drive system). Electrical braking is efficient and ensures smooth operation and allows the designer to recover the mechanical energy. However electrical braking
cannot be used as a safety braking system for the cases of emergency braking and parking braking.
It is for these reasons that mechanical braking systems are still employed today, in order to act as emergency and parking brakes
Two types of braking systems are employed in most drive systems: electrical and mechanical. In this note a general overview is presented of the two types of braking systems, and it concludes with a comparison of the two types.
Types of Electrical Braking Systems
There are six methods of electrical braking in drive systems, listed below:
1. Plugging: The three phase voltage sequence is reversed at the stator
terminals of the induction motor. The equivalent form of plugging in dc drive
systems is the reversal of the polarity of the armature voltage of a dc motor.
2. DC Injection Braking: A d.c. voltage is applied to any two of the three
terminals of the induction motor.
3. Eddy Current Braking: A separate eddy current braking device is coupled to
the shaft of the motor. Eddy current braking results when electromagnets are
activated and they induce eddy currents in the rotating metallic disk. The eddy
currents produce magnetic fluxes that oppose the flux produced by the
electromagnets and thus result in a braking torque on the motor. The energy
is dissipated as heat in the rotating metallic disk.
4. Dynamic Resistor Braking: In variable frequency drive systems, when the
motor is braking and acting as an induction generator, it returns power back to
the d.c. link capacitor and the voltage of the d.c. link increases. A resistor can
thus be used to dissipate the excessive charge on the capacitor, whereby an
IGBT is controlled to proportionately switch the resistor in parallel with the
capacitor (using pulse width modulation switching). The excessive energy is
thus dissipated in the resistor.
5. Regenerative Braking: Rather than dissipating the excessive charge in the
resistor, it is possible to return the excessive energy back to the three phase
supply by using a dedicated inverter, placed in parallel with the uncontrolled
rectifier that is used in the variable frequency drive system.
6. Sharing the DC Bus: Another possible method of removing the excessive
charge on the capacitor is to share the d.c. between a number of different
variable frequency drive systems. The drive that is braking can supply energy
to the drive that is motoring. In such a case, there is no need to dissipate the
excessive energy into a resistor or to return it to the three phase power
source.
In the first two methods, the excessive energy is dissipated as heat in the motor itself. In the Eddy current method, the excessive energy is dissipated as heat in the
metallic disk. In the fourth method, the excessive energy is dissipated as heat in the resistor. In the fifth method the energy is returned to the ac suppy. In the sixth method, the energy circulates between the different motors (from the one that is
acting as a generator to the one that is acting as a motor).
In cases where it is possible to recover the energy, the following can be done:
1. It can be stored in batteries.
2. It can be stored in a flywheel (a flywheel that has an integrated permanent
magnet dc alternator).
3. It can be returned to the ac supply using a regenerative drive.
Mechanical Braking Systems
There are four types of mechanical brakes used in drive systems:
1. Drum brakes.
2. Disk brakes.
3. Band brakes.
4. Pawl and Ratchet brakes:
The ratchet is linked to a spring loaded friction plate. The ratchet is lifted using a solenoid.
The drum and disk brakes are either electromagnetically lifted or hydraulically lifted,
but always spring applied. They must be spring applied for safety reasons, so that when the power supply is lost, the brake will apply and safely bring the load to a
standstill
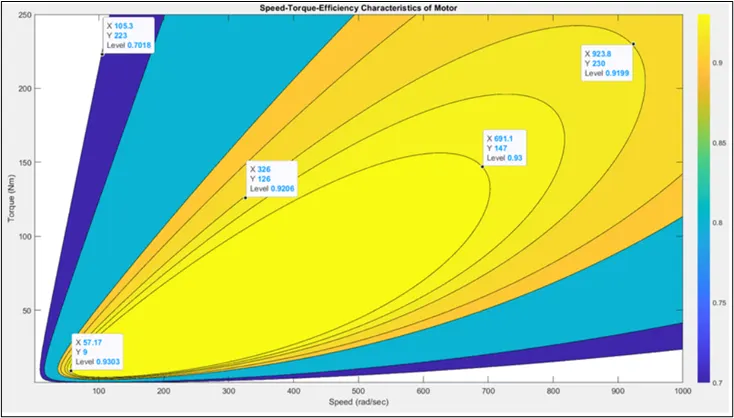
- Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
clear all
close all
clc

x=linspace(1,1000,250);   %Speed in rad/sec

y=linspace(1,250,250);    %Torque in Nm


%Motor loss constants

kc=0.2;     %Copper loss constant

ki=0.008;   %Iron loss constant

kw=0.00001; %Windage loss constant

Const_Loss=20;    %Constant motor loss


[X,Y]=meshgrid(x,y);       %Converting to 2D

Output_power=(X*Y);    %Power = Torque x Speed

B= (Y.^2)*kc;  %Copper loss

C= X.*ki;      %Iron loss

D= (X.^3)*kw; %Windage loss


Input_power = Output_power + B + C + D + Const_Loss;

Efficiency= Output_power./Input_power;   %Eff of the motor

V = [0.70,0.80,0.90,0.91, 0.92,0.925,0.93];  %Efficiencies to be plotted

box off

grid off

contourf(X,Y, Efficiency,V);

contourcbar
title('Speed-Torque-Efficiency Characteristics of Motor');
xlabel('Speed (rad/sec)');
ylabel('Torque (Nm)');
Plot:
RESULTS:
- For a defined driving cycle, calculation of the energy required for braking is done.
- Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated-explanation given.
- Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.-task completed.