Solving Differential equation using ode45 inbuilt function
Aim : Solving ordinary Differential equation using ode45 inbuilt function.
Objective : Algorithm to solve ordinary differential equation using ode45.
Basic knowledge of Damping.
Theory :
Genrally we neglect the losses due to drag while solving the problems.But practically
we cannot ignore them .
Let's consider simple pendulum..,
If losses are neglected then the amplitude remains constant , even with no apply
of force periodically , called natural vibrations or oscillations.
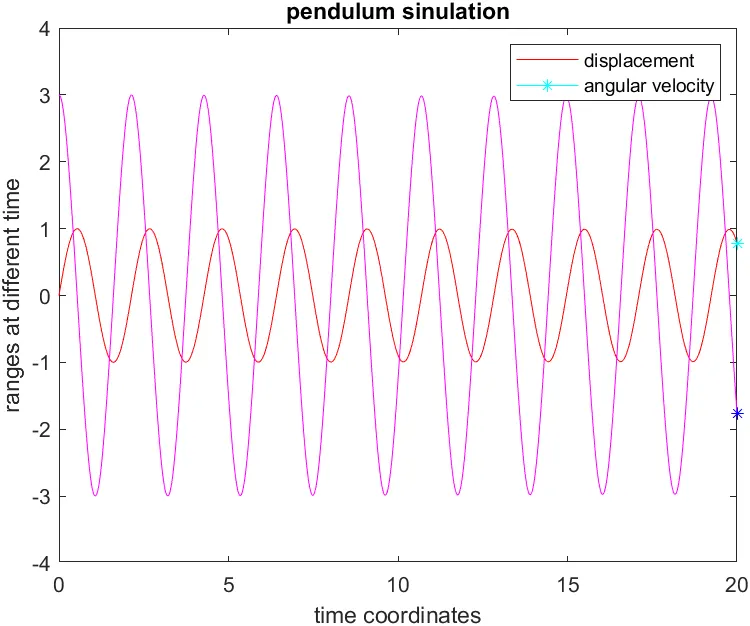
You can observe the no variation of amplitude over of cycles - if damping neglected.
In practical this is not the case , decrease in amplitude obsorved , that phenomenon
called damping.
Energy dissipates due to drag or frictional forces.
Important term in damping to differ types of damping - Damping ratio
Damping Ratio(`xi`) = `frac{Damping Coefficient}{Critical Damping coefficient (C_c)}`
Critical Damping coefficient(`C_c`) = `2sqrt(m*k)`.
Different types of Damping :
- Underdamped - `xi``lt 1`.
- Overdamped - `xi gt 1`.
- Criticaldamped - `xi = 1`.
- Undamped - `xi = 0`.
Observe the plots of types of damping
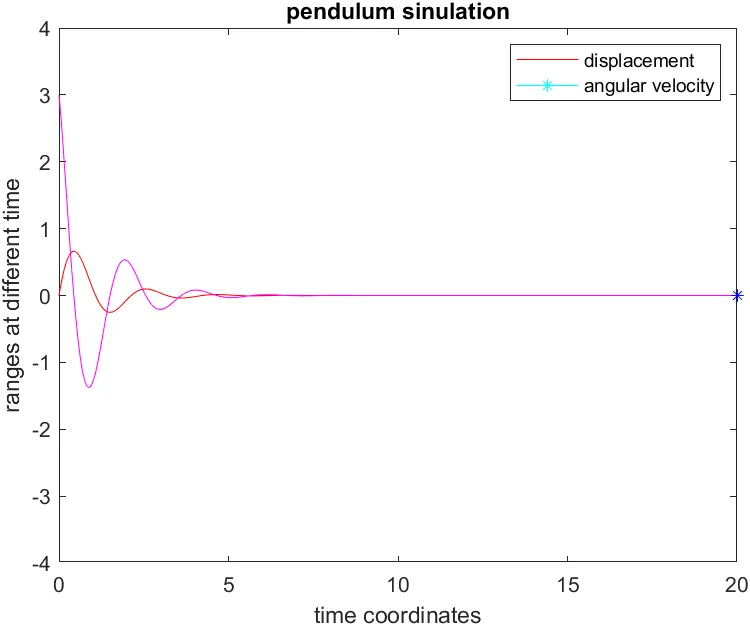
fig : Overdamping
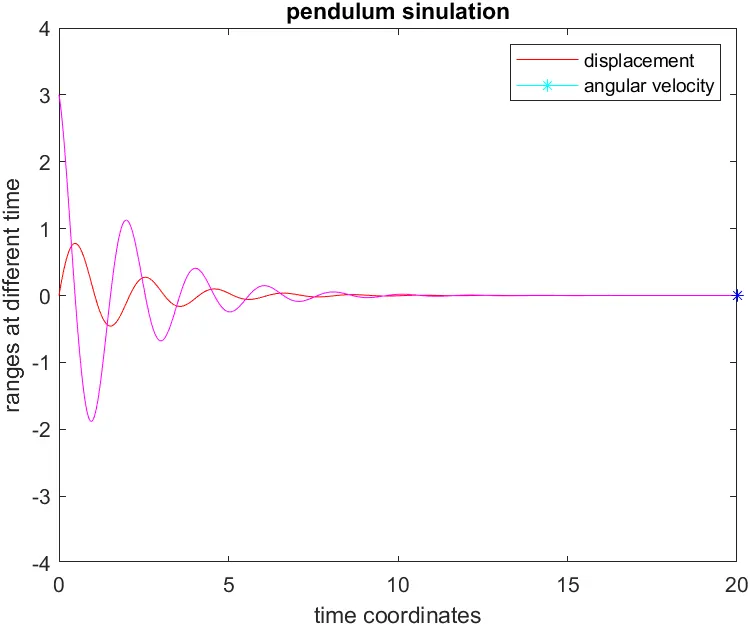
fig :Criticaldamping
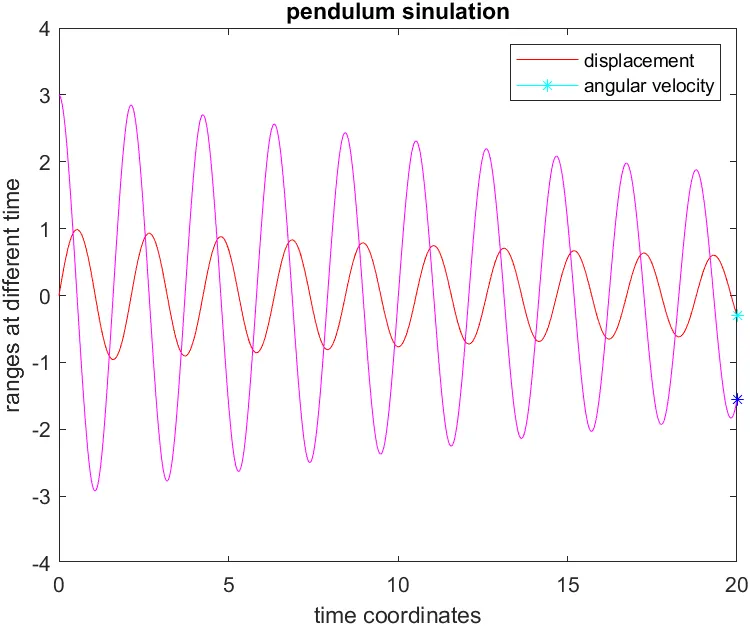
fig : underdamped
ode45 inbuilt function :
Syntax : ode45(fname , tspan , IVC , options).
fname - ode function solves the differential equation algorithm.
tspan - Interval range to integrate.
actually , t_co dimentions same as tspan , but if required for accuracy matlab can manipulate for required dimentions, change step-size.
IVC - Space coordinates , initial conditions.
In matlab , genrally ode45 use the runge-kutta (`4^(th)` order) - Numerical analysis.
Method as results are more accurate than other methods. (Rate of convergence - 2).
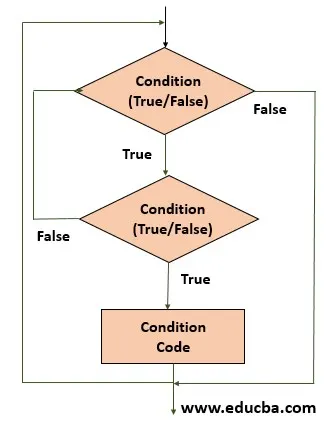
Workflow of for loop:
Description of simple pendulum under viscous damping:
Governing equation :
`frac{d^2theta}{dt^2}`+ `frac{b}{m} (frac{d theta}{dt}) + frac{g}{l}sintheta = 0`
b - Damping co-efficient.
`theta - ` angular displacement of the pendulum bob`
g - acceleration due to gravity.
l - lenght of the pendulum wire.
here , considered the viscous damping (drag due to the fluids like air,water...).
viscous damping - force is directly proportional to velocity.
`F_d = b*dotx`
b - damping coefficient.
If we neglected the term 'b' = 0 , the governing equation becomes
`frac{d^2theta}{dt} + frac{g}{l}sintheta = 0`.
This discribes the natura free vibrations without daping.
Simple pendulum figure output:
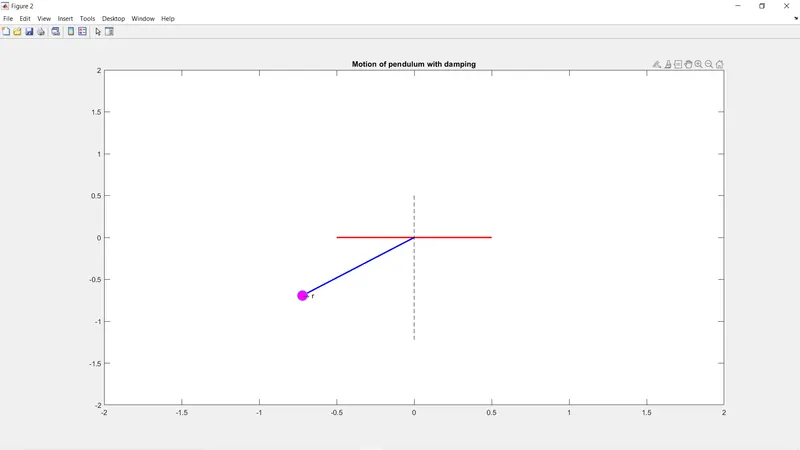
This figure shows the output plot animation of simple pendulum
Code :
%% Program for pendulum simulation
close all;clear all;clc;
l = 1;
tspan = linspace(0,20,800);  %time interval (integration range)
s1 = [0;3]; % space coordinates
[t_co,re] = ode45(@pendulum_function , tspan , s1);
c =1;
figure(1)
for i =1:length(re(:,1))
%plot command for to plot the displacement of pendulum over time.
    plot(t_co(1:i,1),re(1:i,1),'color','r')
    hold on
%plot command to show the marker represents displacement at the particular time.
    plot(t_co(i,1),re(i,1),'color','c','marker','*')
%plot command to plot the velocity variation of pendulum over time.
    plot(t_co(1:i,1),re(1:i,2),'color','m')
%plot command to show the marker represents velocity at the particular time.
    plot(t_co(i,1),re(i,2),'color','b','marker','*')
%setting axis extent limits.
    axis([0 20 -4 4]);
    xlabel('time coordinates');
    ylabel('ranges at different time');
    title('pendulum sinulation');
    legend('displacement','angular velocity')
    drawnow
    if i~=length(re(:,1))
        clf
    end
end

This figure represents the animation of pendulum with damping.

figure(2)
for j = 1:(length(re(:,1)))
%plot command to draw horizontal line
   plot([-0.5,0.5],[0,0],'color','r','LineWidth',2)
   hold on
%x1,y1 - defining the co-ordinates of pendulum.
   x1 = sin(re(j,1));
   y1 = cos(re(j,1));
%plot command for to plot the pendulum wire.
   plot([0,0+x1],[0,0-y1],'color','b','LineWidth',2)
   hold on
%plot command for to to show the pendulum in figure.
   plot(x1,y1,'marker','o','markersize',15,'markerfacecolor','m','markeredgecolor','c')
   %plot(x1,-y1,'marker','.','color','k')
%plot command to show the mean position , used diiferent linestyle.
   plot([0,0],[0.5,-l-0.25],'color','black','linestyle','--')
   axis([-2 2 -2 2]);
% if loop used to show the direction of pendulum
   if j ~= length(re(:,1))
      if re(j+1,1) > re(j,1)
        text(x1,-y1,'\rightarrow r')
       else
       text(x1,-y1,'\leftarrow r')
      end
   end
   title('Motion of pendulum with damping');
   drawnow
%getframe(gcf) - Copying the data drames of present figure properties into array 'fr'.
   fr(c) = getframe(gcf);
   c = c+1;
   %if j ~= length(re(:,1))
    %  clf
   %end
end

%VideoWriter used to create the videofile.
video_file = VideoWriter('fra');

%open the videofile.
open(video_file)

%writeVideo to create the video using the data stored in 'fr'.
writeVideo(video_file,fr)

%close the videofile.
close(video_file)
Explanation of code step-wise :
1.At first , used genral commands ,
close all - to clear all existing figures and plots.
clear all - to remove all data in workspace.
clc - to clear the command prompt.
2.Defined length of pendulum wire , assigned to variable 'l'.
3.tspan - time interval range over integration ocuurs.
4.S0 - Defining Space coordinates.
5.Use ode45 inbulit function to solve the ordinary differential equation , syntax explained above.
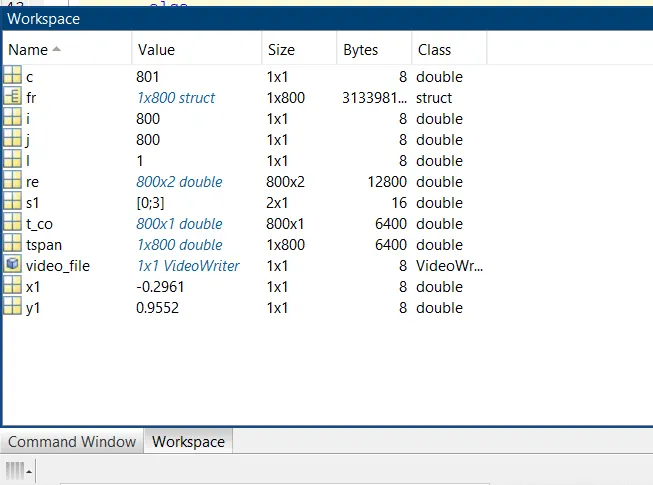
6.Results stored in t_co - time coordinates , re - dispacement and velocity of oscillations values along columns.
7.used first for loop to plot the displacement and velocity variations over cycles with time(x-axis).
8.used the second for loop to show the animation of simaple pendulum with taken underdamped condition.
9.hold on - add the present axes properties to the current figure.
10.drawnow - hold the execution of code temporarly and plot the present figure , as matlab gives prference to the execution of code.
11.plot command to plot the figure.
12. use xlabel , ylabel ,for to label the axis.
13.legend to define the different plots.
14.title - title of the plot.
15.ax([xmin xmax ymin ymax]) - Defning the extents of axis limits.
16.Explained the required things as comments in code.
17.'getframe' - getframe command stores the information of present data frame of the plot , and that data stored in 'fr'.
18.'videoCreator - crates videofile but it won't write anything .
19.'open' - command to open the video file.
20.'writeVideo' - write a video by using the data stored in 'fr'.
21.'close' - command used for closing the video file.
video file created only after the animation completed in the output . Can observe that in command history. By default matlab creates '.avi' files . we can convert that into '.mp4'file . use VideoWriter('name','MPEG-4');
Function snippet for to define the required ordinary Differential equation.
%function to define ordinary the differential equations.

function sdot = pendulum_function(t,s)
g = 9.8;
l = 1;
b = 0.05;
m = 1;
sdot = zeros(2,1);
sdot(1) = s(2);
sdot(2) =-(b/m)*s(2) - (g/l)*sin(s(1));
end
1.g - acceleration due to gravity(9.8 m/`s^2`).
2.length of the pendulum wire.
3.damping coefficient.
4.m - mass of the pendulum.
5.sdot(1) - for dispacement simulation.
6.sdot(2) - for velocity simulation.
outputs :
1.
as , you can observe from the figure exponential decay of amplitude.
2. Simulation video of simple pendulum with underdamped condition:
https://www.youtube.com/watch?v=eFqM_9N51rA
Conclusion :
1. Plotted the velocity and displacement variations of simple pendulum with
underdamped condition.
2. Learned about damping.