Project 2 - Modeling of 3 phase Induction Motor Drive
Aim:
- To model 3 Phase Inverter using Simulink (model the parasitic as well) with a switching frequency of 10Khz using 3 phase Squirrel Cage Induction motor, using V/F method, open loop.
- Use the 3 phase inductor motor theory to derive the transfer function of 3 phase Induction Motor
- To model 3 phase induction motor with a 3 phase inverter using Direct Torque control using an Average Model, Implement both torque and flux control to achieve desired power.
1.
Design Parameters:
- Power = 100 HP
- DC Voltage = 800 V
- Output Voltage = 460 VRMS – line to line
- Initial Speed = 1500 RPM
- Final Speed = 1000 RPM
- Initial Load Torque = 10 Nm
- Final Torque=20 Nm
- Torque Step Time = 0.1 secs
Simulink Model:
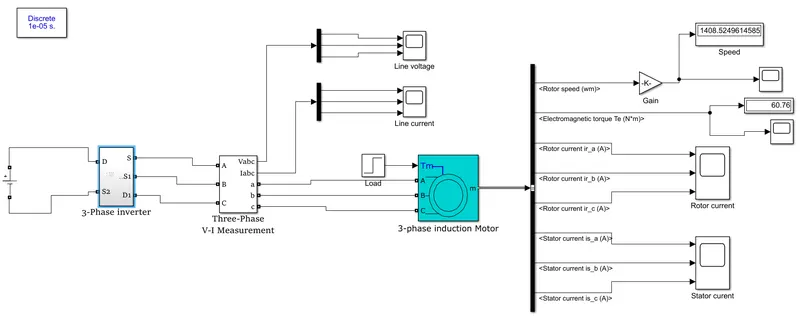
V/f control is a method to control a ratio between primary voltage (V) to be applied to the induction motor and
inverter output frequency (f) to be constant. This control enables to obtain satisfactory torque characteristics in a wide
frequency range by maintaining the magnitude of the rotating magnetic field vector independently from the inverter
output frequency when voltage drop due to a primary winding resistance is ignored.
However, as the frequency declines, the voltage drop due to the primary winding resistance becoming too large to be
ignored, and consequently, it becomes impossible to obtain sufficient torque. In such a case, applying a higher voltage
than the voltage calculated from the V/f ratio which was used for a high frequency makes it possible to secure enough
torque even at a low frequency.
Whenever three phase supply is given to three phases induction motor rotating magnetic field is produced which rotates at a synchronous speed given by

In three phase induction motor emf is induced by induction similar to that of a transformer which is given by
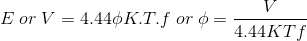
Where,
K is the winding constant
T is the number of turns per phase
f is frequency.
Now, synchronous speed varies as frequency is changed, but when frequency is decreased, flux increases. This change in flux value results in saturation of the rotor and stator cores, which further raises the motor's no-load current. Hence, maintaining flux at a consistent value is crucial, and doing so requires changing the voltage. In other words, if we lower the frequency, the flux will increase, but if we lower the voltage, the flux will drop as well, creating no change in flux and keeping it constant. Hence, we are maintaining a constant V/f ratio here. As a result, it is called the V/f approach.
Simulation Results:
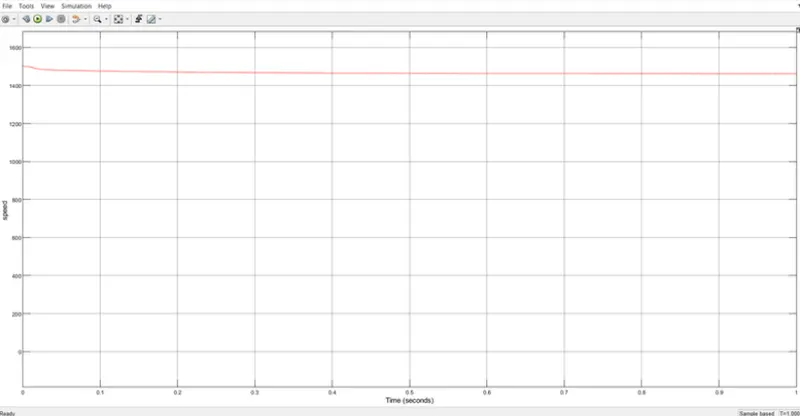
Rotor speed
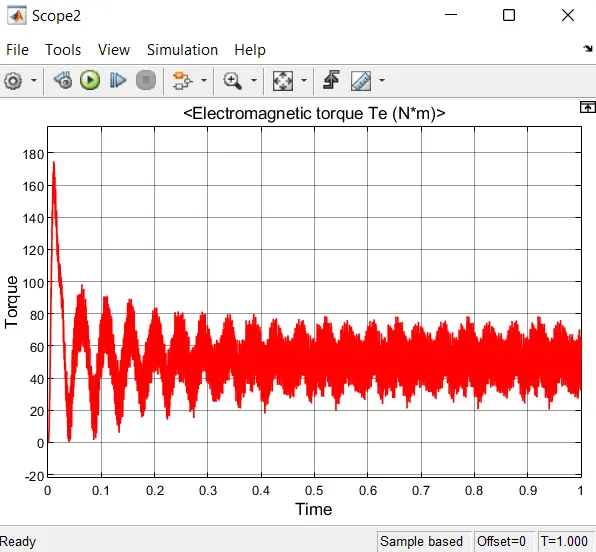
Electromagnetic Torque
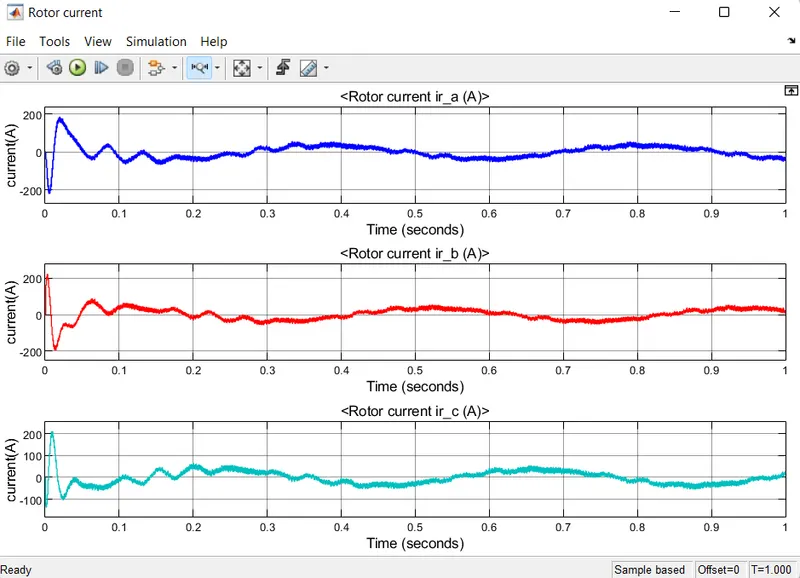
Rotor currents
Stator currents
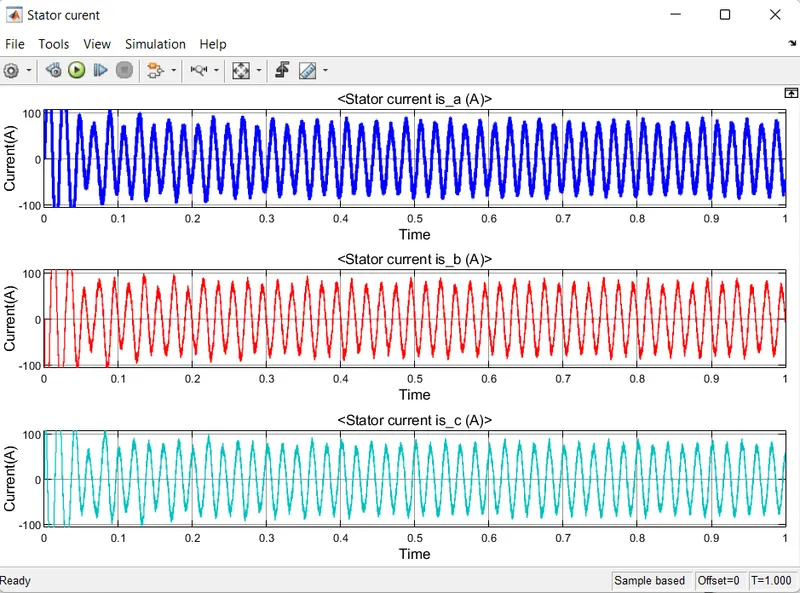
- When we alter the V/f ratio from one value to another, using a multilayer inverter for speed control of the induction motor will be smooth, flexible, and also significantly minimize transients.
- The fundamental disadvantage of multilayer inverters is the enormous quantity of flying capacitors and clamping diodes needed for high-speed switching power electronics.
2. Transfer function of 3 phase Induction Motor:
The transfer function of an Induction motor will be determined as follows:
Mathematical modeling of induction motor can be obtained by taking all the basic equations.
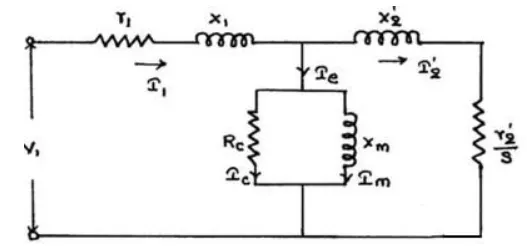
r1 = Stator resistance
X1 is the stagger leakage reactance
I1 equals stator current
Shunt branch resistance is Rc.
Magnetizing reactance: Xm
Ie is the unitary no-load current.
Rotor current = I2.
I2'= Rotor Current Per Phase As Shown By Stator
X2'= stator-referenced stationary rotor reactance
r2' is the stator's rotor resistance.
Stator Voltage, V1,
E1 = emf caused by a stator
s= slip
The machine's electrical equation is
Va=IaRa+JXsIa+Eb
in which Ebddt
Laplace transformations are used,
Va(s)=Ia(s)(Ra+jXs)+Eb(s)
we know that
Eb=Ktsθ(s)
replacing, we obtain
Va(s)=Ia(s)Z(s)+Ktsθ(s)
⇒Va(s)−Kt(s)sθ(s)Z(s)=Ia(s)
The source of electrical torque is
Te=E2sinθ
The source of mechanical torque is
Tm=J..θ+Bθ
Laplace Transforms are used,
Tm(s)=(Js2+Bs)θ(s)
Tm=Te⇒E2θ(s)=Js2+Bs(θ(s))
⇒(Js2+Bs−E2)θ(s)=Tm
⇒Js2+Bs−E2=Tmθ(s)
⇒θ(s)Tm(s)=1Js2+Bs−E2
We are aware that TIacos (take = 0)
T=KϕIa
⇒T=Kϕ(s)Ia(s)
From above, we may determine Ka[Va(s)Kts(s)].
Z(s)=(Js2+Bs−E2)θ(s)
⇒KaVa(s)=(Js2+Bs−E2)θ(s)Z(s)+Ktsθ(s)
⇒Va(s)θ(s)=(Js2+Bs−E2)Z(s)+KaKtsKa
⇒θ(s)Va(s)=Ka(Js2+Bs−E2)Z(s)+KaKts
⇒θ(s)Va(s)=Ka(Js2+Bs−E2)(Ra+Las)+KaKts
The induction motor's transfer function is provided as
⇒θ(s)Va(s)=Ka*J*La*s^3+(RaJ+BLa)s^2+(BRa+KaKt)s
3.
Design Parameters:
- Initial Speed = 0 RPM
- Flux Target = 2.5 webers
- DC Voltage = 500 V;
- Fundamental Frequency = 60 Hz
- Speed Step Time = 0.01 secs
- Determine fundamental speed based upon fundamental frequency
- Determine the switching sequence for direct torque control
- Moment of Inertia = 0.1 Kgm^2
- Load Torque Initial = 0 Nm
- Final Load Torque = 50 Nm
- Torque Step Time = 0.03 secs
Motor Parameters:
- Stator Resistance = 0.5 Ohms
- Rotor Resistance = 0.2 Ohms
- Stator Leakage Inductance = 20 mH
- Rotor Leakage Inductance = 10 mH
- Magnetizing Inductance = 200 mH
- Number of Poles = 4
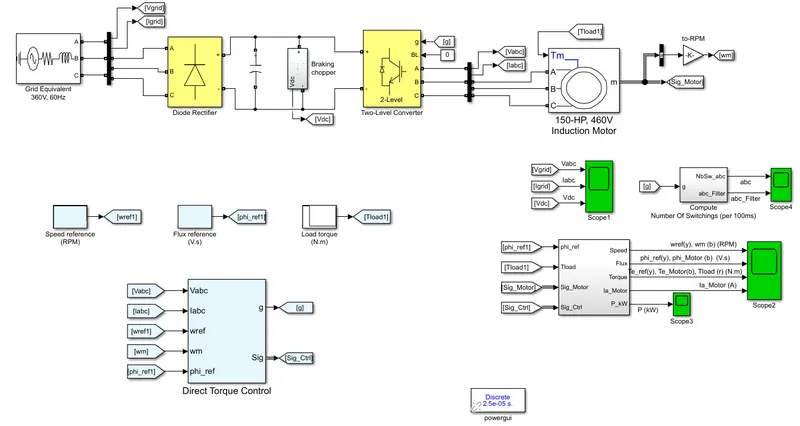
- The three-phase voltage source is fed to the diode rectifier to convert 3 phase to a DC Voltage Source.
- Three-phase two-level inverter is connected to the dc voltage source and then connected to the induction motor.
- The DC source is charged from the grid equivalent and then discharged by the 3 phase inverter.
- To achieve this, a breaking chopper is added.
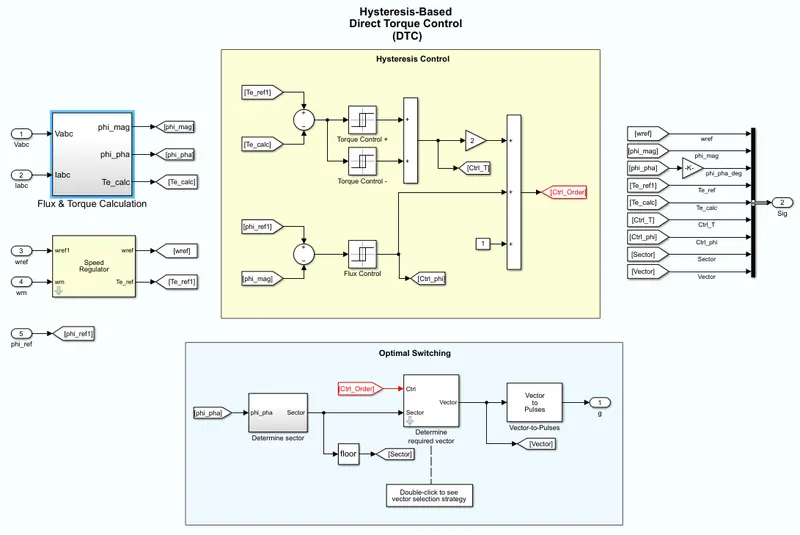
- The hysteresis-based torque controller uses reference speed, reference angle, and reference torque, which are converted into ABC and then to magnitude and angle so that we can use inverse park transformation to convert them to sectors.
- Next, logic is applied so that it can create the vectors, which are then converted to pulses.
- The inverter needs the produced pulses to change the DC voltage into the necessary/desired three-phase voltage so that the three-phase induction motor may be powered.
Flux and Torque Calculation-
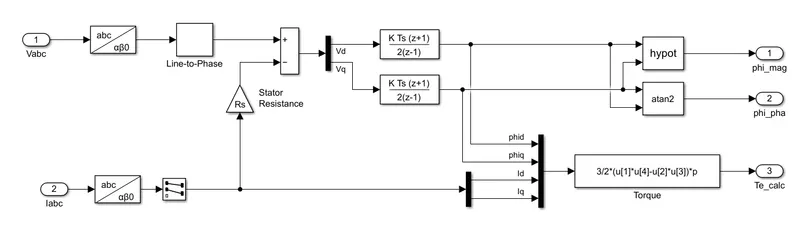
- The necessary equations are used to determine the flux and the torque as indicated above.
- After utilizing Clark's transformation to translate ABC into alpha-beta, the necessary computations are performed to provide the flux control and torque control outputs.
Simulation Results:
Vabc, Iabc and Vdc plot:
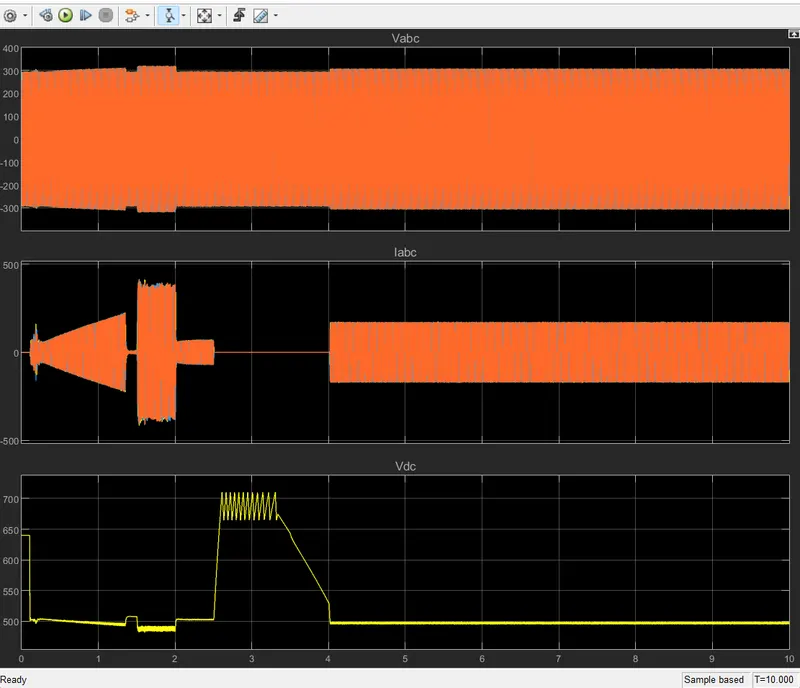
- Vabc is ranged at approximately -320 to 320V.
- Iabc is approximately -200 to 200 A.
- Vdc is set at 500V.
Motor Parameters:
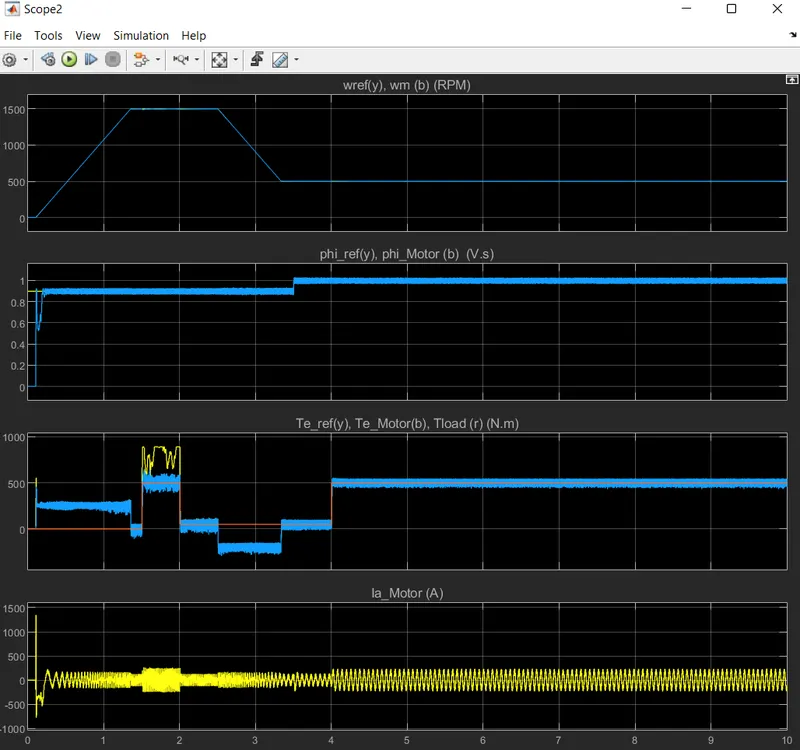
- Above plots represents speed, torque, Phi value and Current in the Motor respectively.
- From the plot, we can observe the flux and torque and the speed of the induction motor is controlled.
Conclusion:
- The Three Phase induction motor Drive is modeled and controlled using both the V/F control method and the Direct Torque Control Method and also the Transfer Function of the Induction motor based on the Equivalent Circuit is determined.