Project
Aim:
To prepare a detailed technical report for a BAJA ATV using a CVT with the model provided and study the effect of input parameters like throttle, speed and brake on the output parameters like vehicle speed, distance etc.
Theory:
All Terrain Vehicle
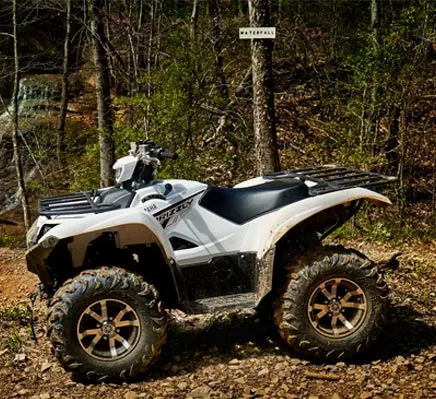
An all-terrain vehicle (ATV) is defined as a motorized off-highway vehicle designed to travel on four low-pressure or non-pneumatic tires, having a seat designed to be straddled by the operator and handlebars for steering control. ATVs are subdivided into two types as designated by the manufacturer. Type I ATVs are intended by the manufacturer for use by a single operator and no passenger. Type II ATVs are intended by the manufacturer for use by an operator and a passenger, and are equipped with a designated seating position behind the operator. Similarly, riders must also consider the various ATV sizes.
SAE BAJA
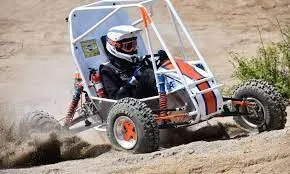
Baja SAE is a Collegiate Design Series competition run by the Society of Automotive Engineers International (SAE International). Teams of students from universities all over the world design and build small off-road cars. The goal in Baja SAE is to design, build and race off-road vehicles that can withstand the harshest elements of rough terrain. The vehicles used in Baja SAE racing are often similar in appearance to dune buggies.
The primary objective of BAJA SAEINDIA has always been to develop an understanding in the fresh and curious minds about entering the industrial reign. The purpose is to help the undergraduates enlarge their spectrum in technical and practical approaches, to trigger the prefrontal cortex and increase problem-solving and planning skills, enhance the managing capability, along with core technical knowledge.
Simulink Block Explanation:
1. Generic Engine
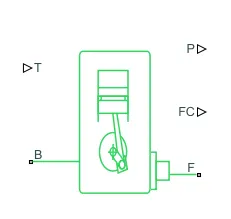
This block represents a IC engine with only basic parameters available. Engine type can be selected as spark ignition and diesel engine. The max power , rated speed, maximum speed and idle speed can be mentioned. There is option to consider the inertia effects and also to calculate the fuel consumption values
2. Ideal Rotational Motion Sensor
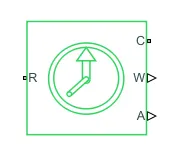
This block measures angular velocity or angle in a mechanical rotational network. The sensor is ideal since it does not account for inertia, friction, delays, energy consumption, and so on.
The physical signal ports W and A report the angular velocity and angle, respectively, of port R relative to port C. The measured angular velocity is positive when the angular velocity at port R is greater than the angular velocity at port C.
This is used to measure the engine rpm
3. Inertia
The block represents an ideal mechanical rotational inertia.The block has one or two mechanical rotational conserving ports. The block positive direction is from its port to the reference point. This means that the inertia torque is positive if the inertia is accelerated in the positive direction.
4.Variable Ratio Transmission
Represents a variable ratio gearbox such as implemented by mechanical belt CVT, electric, or hydraulic transmissions. The physical signal input r defines the ratio of input to output angular shaft velocities. Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter.
5. Simple Gear
Represents a fixed-ratio gear or gear box. No inertia or compliance is modeled in this block. Connections B (base) and F (follower) are mechanical rotational conserving ports. Gear ratio between the follower and base gear to be mentioned
6. Double Shoe brake
Represents a brake arranged as two pivoted rigid shoes symmetrically installed inside or outside a drum and operated by one actuator. The actuator force causes the shoes to exert a friction torque on a shaft connected to the drum. Connection S is a conserving rotational terminal associated with the drum shaft. Connection F is a physical signal port representing the force input to the actuator. Positive force creates friction torque that resists shaft rotation.
7. Tire
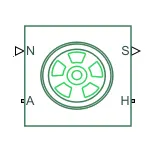
Represents the longitudinal behavior of a highway tire characterized by the tire Magic Formula. The block is built from Tire-Road Interaction (Magic Formula) and Simscape Foundation Library Wheel and Axle blocks. Optionally, the effects of tire inertia, stiffness, and damping can be included. Connection A is the mechanical rotational conserving port for the wheel axle. Connection H is the mechanical translational conserving port for the wheel hub through which the thrust developed by the tire is applied to the vehicle. Connection N is a physical signal input port that applies the normal force acting on the tire. The force is considered positive if it acts downwards. Connection S is a physical signal output port that reports the tire slip.
8. Vehicle Body
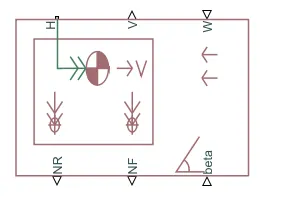
Represents a two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. The vehicle can have the same or a different number of wheels on each axle. The vehicle does not move vertically relative to the ground. Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body. The resulting traction motion developed by tires should be connected to this port. Connections V, NF, and NR are physical signal output ports for vehicle velocity and front and rear normal wheel forces, respectively. Wheel forces are considered positive if acting downwards. Connections W and beta are physical signal input ports corresponding to headwind speed and road inclination angle, respectively. CG accepts a two- element vector representing the x and y distance offsets from vehicle CG to additional load mass CG. M represents the additional mass. If both variable mass and pitch dynamics are included, the physical signal port J accepts the inertia of the additional mass about its own CG.
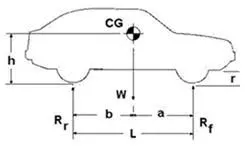
Here b is given as 1.6m, a as 1.4m and h as 0.5m default. gavitational acceleration is 9.8m/s^2.
9. Integrator
This block will do continous-time integration of the input signal. If velocity is integrated over time, distance can be calculated
10. PS Terminator
Use this block to terminate physical signal outputs.
Results:
1. CVT Model
various studies conducted on the CVT model
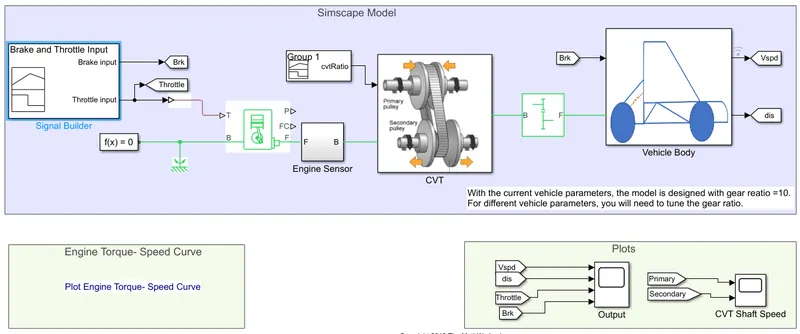
a. With constant throttle input of 0.5% and brake input at 0
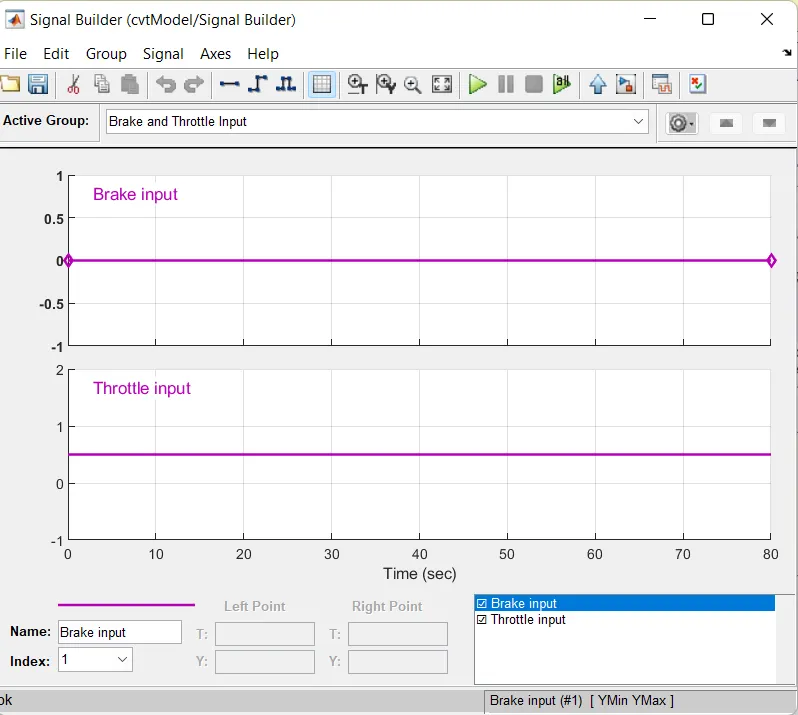
The input signal created in the signal builder is as follows
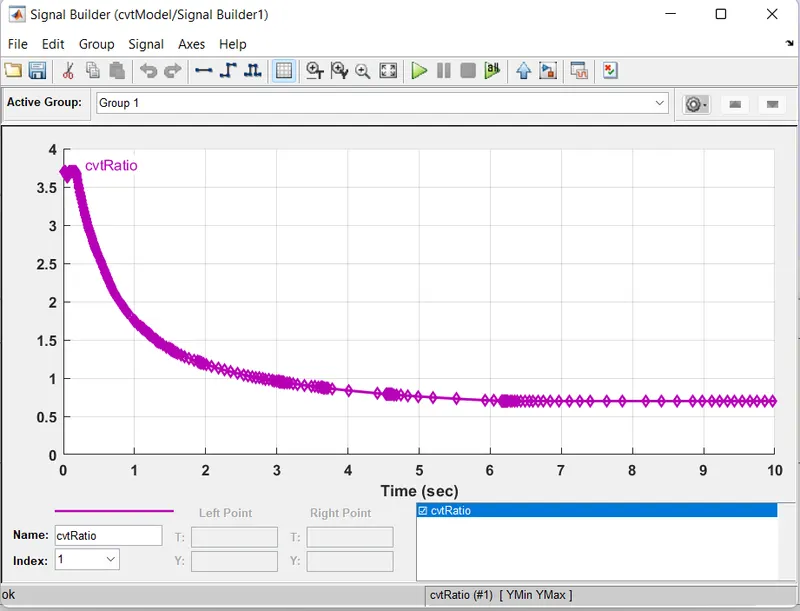
The CVT ratio is as follows and CVT ratio is kept the same for all trials
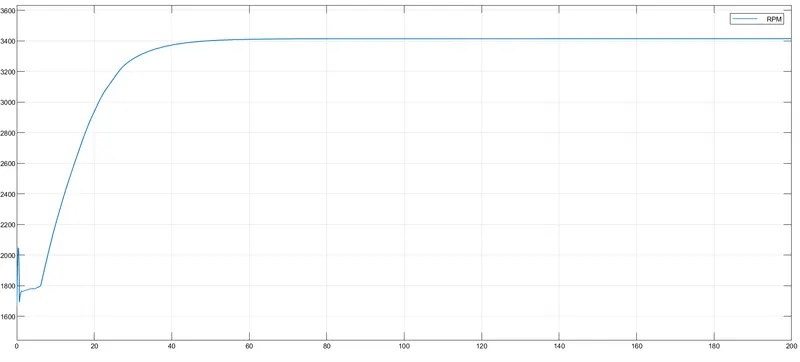
The plot for the engine rpm is as follows and a steady increase in engine rpm is observed since the throttle input is kept constant.
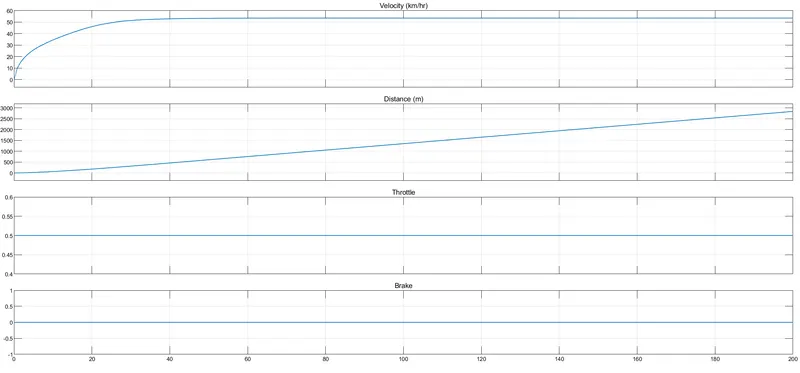
The plots for the vehicle parameters like velocity, distance, throttle and brake are as given below
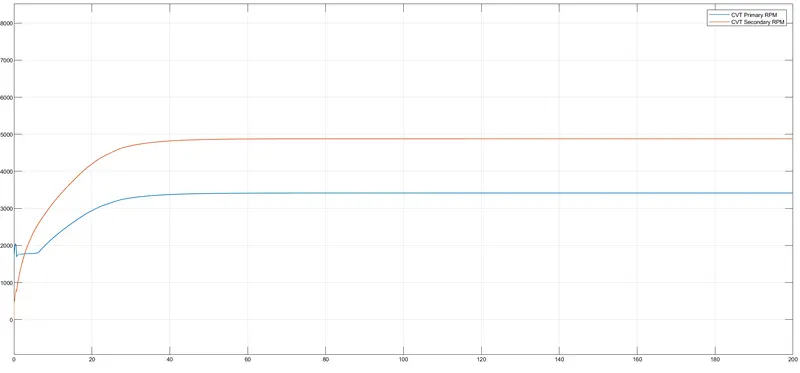
The primary and secondary speed of the CVT is plotted below
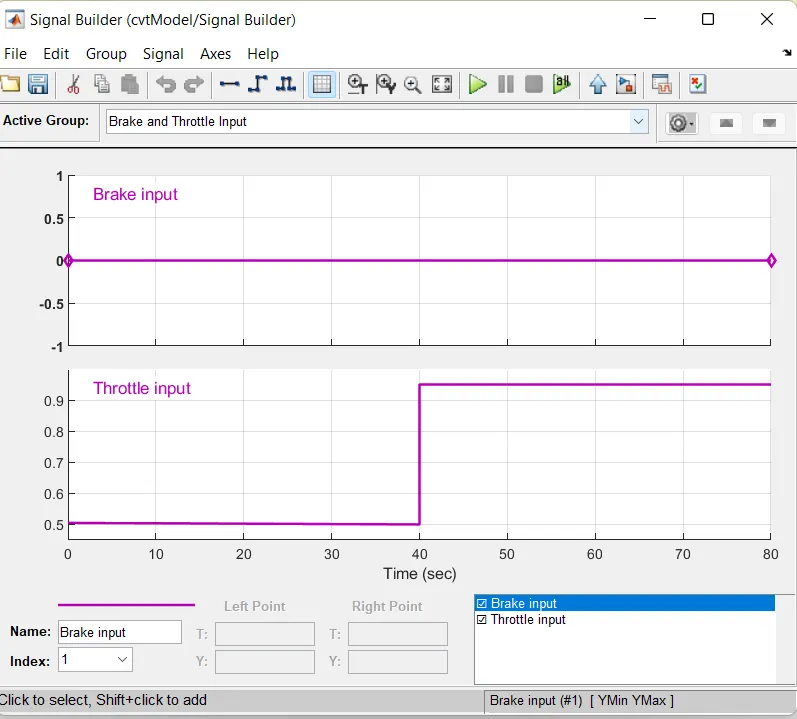
b. With throttle input of 0.5% for the first 40s and 1 for the next 40s and brake input at 0
The input signal created in the signal builder is as follows
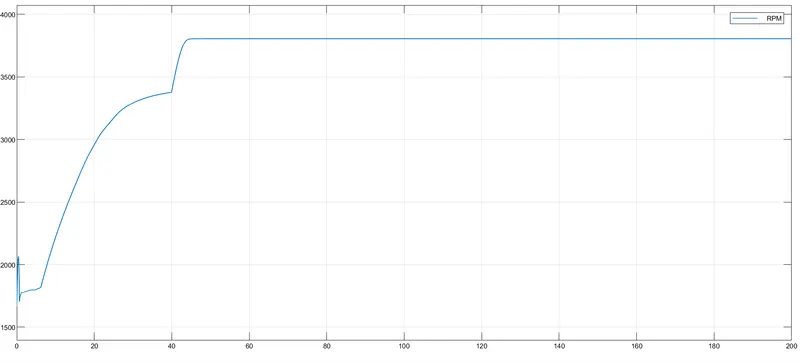
The plot for the engine rpm is as follows and two different slopes for engine rpm is observed since the throttle input is varied after 40s.
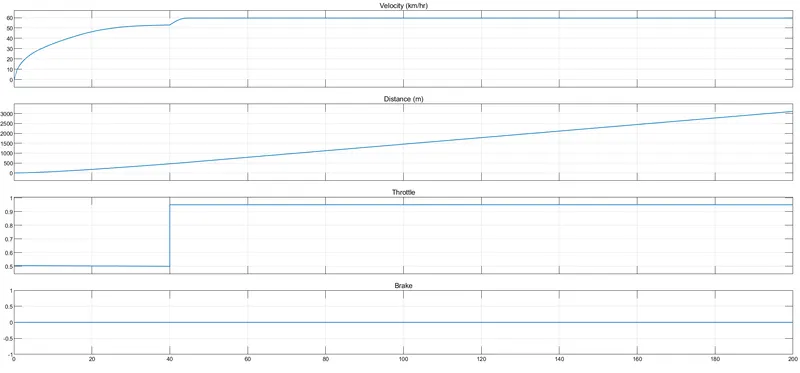
The plots for the vehicle parameters like velocity, distance, throttle and brake are as given below
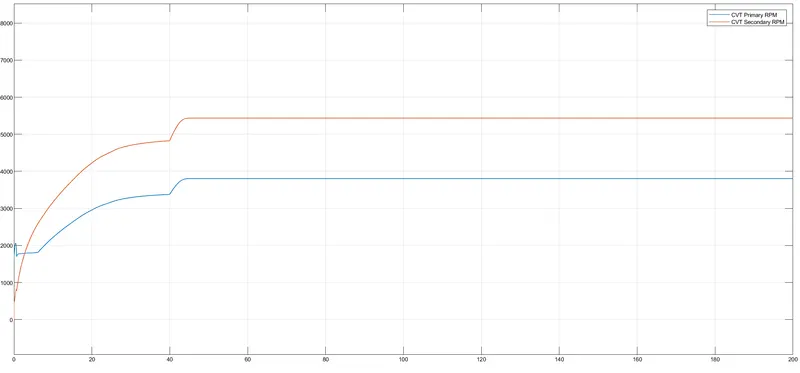
The primary and secondary speed of the CVT is plotted below
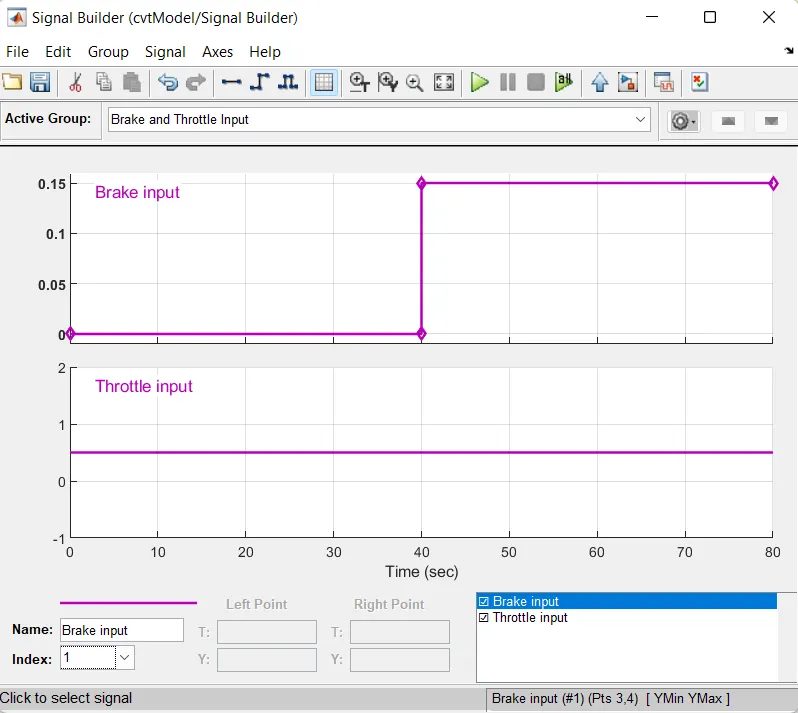
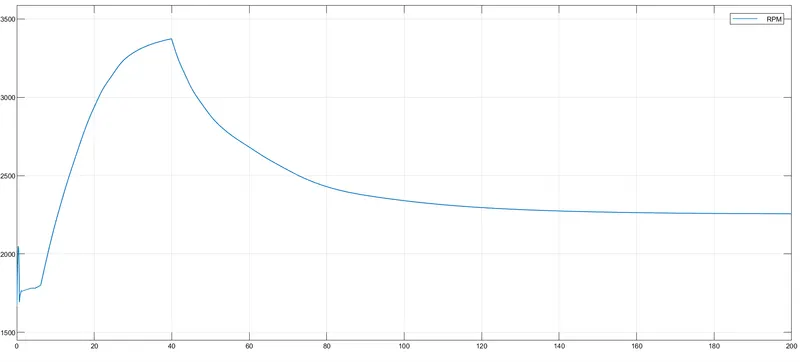
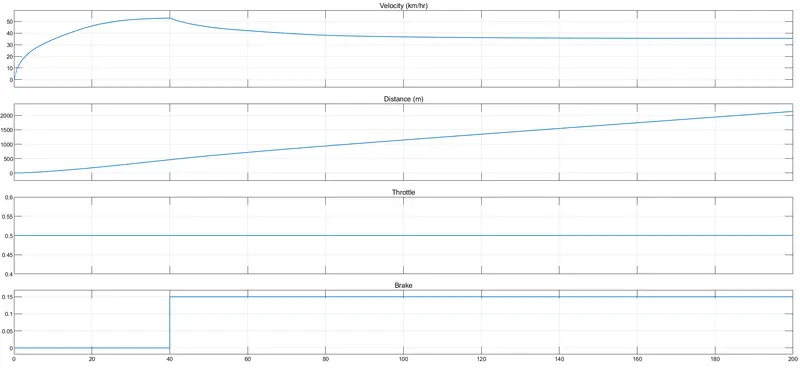
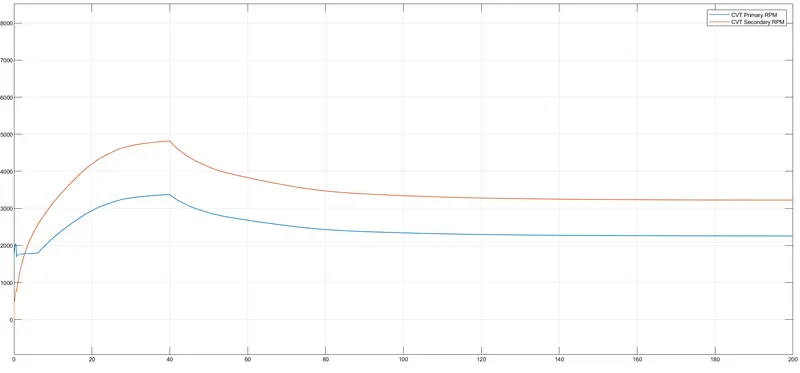
c. With a constant throttle input of 0.5% and brake input at 0 for the first 40s and 0.15 for the next 40s
The input signal created in the signal builder is as follows
The plots for the engine rpm is given below. We can see that once the brake is applied, engine rpm is dropping down
The plots for the vehicle parameters like velocity, distance, throttle and brake are as given below
The primary and secondary speed of the CVT is plotted below
2. CVT with dashboard
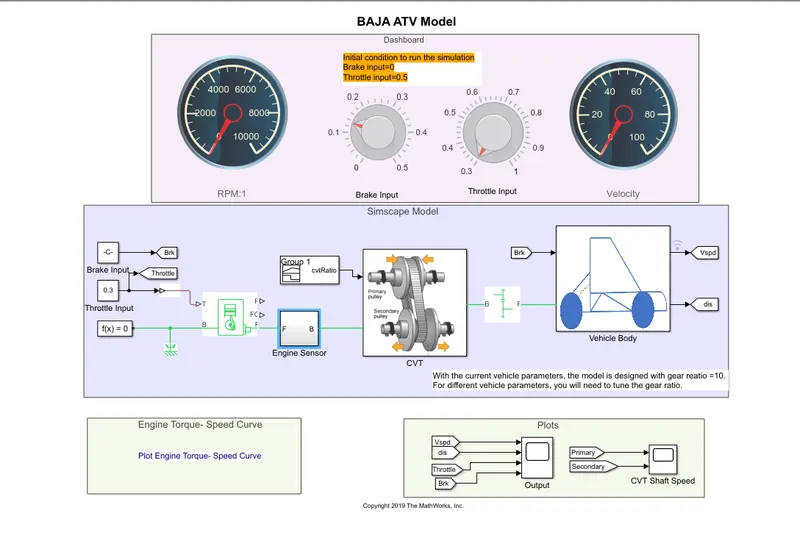
in this, the inputs for throttle and brake are varied manually and the change in engine rpm and velocity is observed on the dial when the simulation time is kept infinity
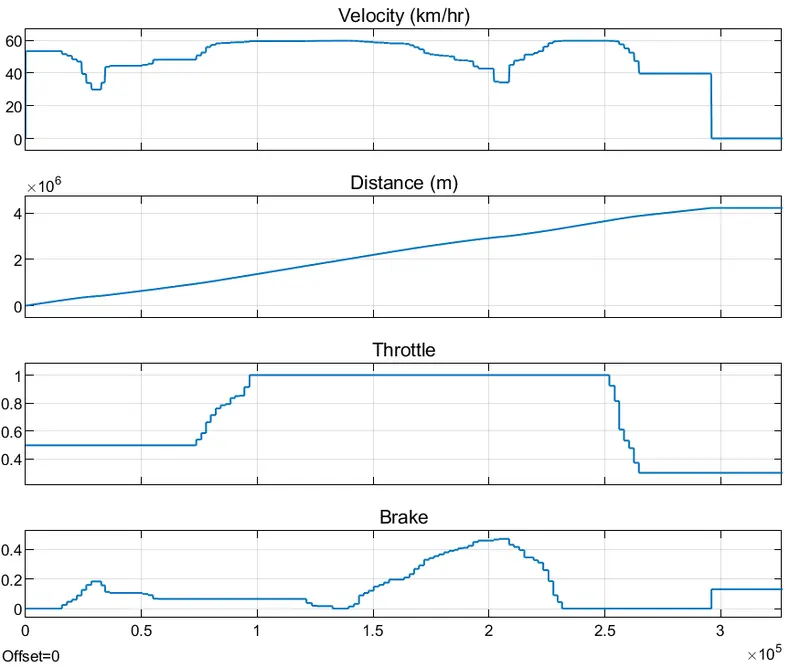
The plots for the CVT primary and secondary speeds are plotted below
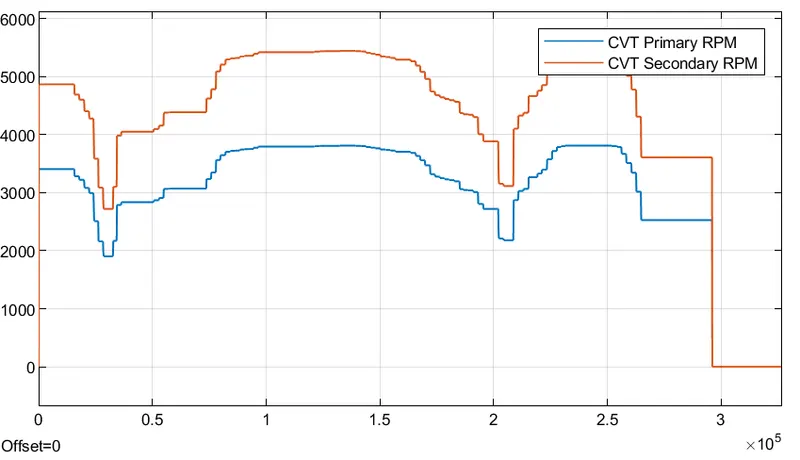
Conclusion:
- The technical study is done with a fixed CVT ratio and simple gear ratio
- The engine will stall and speed and torque will decrease to 0 once the engine speed goes below stall speed
- A constant acceleration is observed when a constant throttle input was given
- The maximum rpm for the engine is taken from the speed vector array
- Once the brake is applied, engine rpm will start to decrease