SYSTEM LEVEL SIMULATION OF A BAJA ATV
AIM :
To carry out a system-level simulation of an all-terrain vehicle.
OBJECTIVE :
To prepare a technical report explaining the model properties & comments on the results.
ALL-TERRAIN VEHICLE (ATV) :
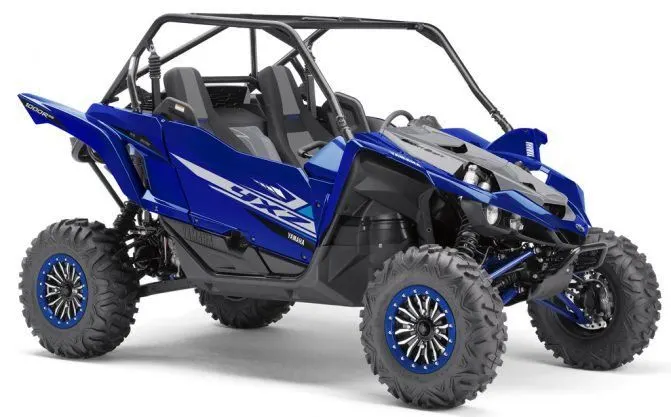
An all-terrain vehicle (ATV), also known as a light utility vehicle (LUV), a quad bike, or simply a quad, as defined by the American National Standards Institute (ANSI); is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name implies, it is designed to handle a wider variety of terrain than most other vehicles. Although it is a street-legal vehicle in some countries, it is not street-legal within most states, territories, and provinces of Australia, the United States or Canada.
By the current ANSI definition, ATVs are intended for use by a single operator, although some companies have developed ATVs intended for use by the operator and one passenger. These ATVs are referred to as tandem ATVs.
The rider sits on and operates these vehicles like a motorcycle, but the extra wheels give more stability at slower speeds. Although most are equipped with three or four wheels, six-wheel models exist for specialized applications. Multiple-user analogues with side-by-side seating are called utility terrain vehicles (UTVs) or side-by-sides to distinguish the classes of vehicle. Both classes tend to have similar powertrain parts. Engine sizes of ATVs currently for sale in the United States (as of 2008 products) range from 49 to 1,000 cc (3.0 to 61 ci in).
CONTINUOUSLY VARIABLE TRANSMISSION :
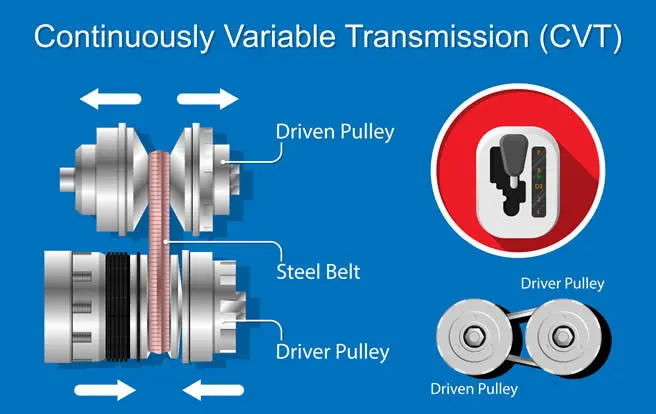
A continuously variable transmission (CVT) is an automatic transmission that can change seamlessly through a continuous range of gear ratios. This contrasts with other transmissions that provide a limited number of gear ratios in fixed steps. The flexibility of a CVT with suitable control may allow the engine to operate at a constant RPM while the vehicle moves at varying speeds.
CVTs are used in automobiles, tractors, motor scooters, snowmobiles, and earthmoving.
The most common type of CVT uses two pulleys connected by a belt or chain, however, several other designs have also been used at times.
SIMULINK MODEL
Model Without Dashboard :
The Simulation of a BAJA ATV model with CVT was attached below.
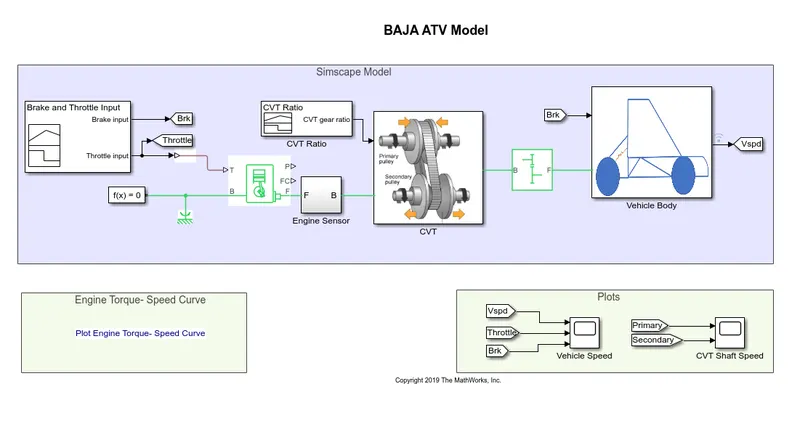
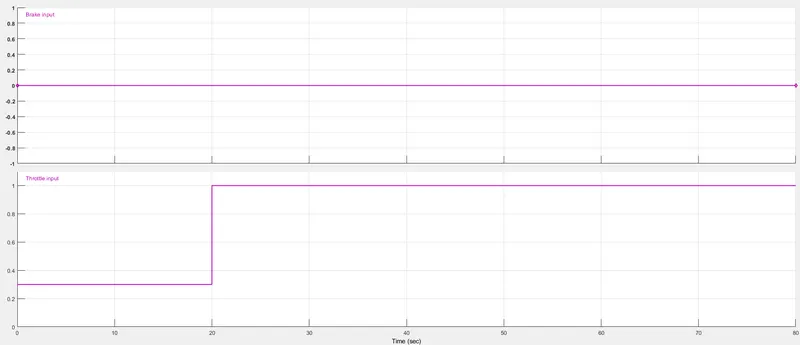
Initially a Signal builder block was used to generate the input signals.
These two signals include Brake and Throttle inputs.
The Siginal builder briefing was attached below,
Then the inputs from the signal builder were connected to a Genetic Engine block qhich represents a simple IC Engine.
The Throttle input was connected to the T port of the engine which represents the throttle port of the engine.
This engine block was connected to a Mechanical Rotational Reference and a solver configuration block.
The output of the engigine block was the F port , it represents the crankshaft of the engine.
This output of the Genetic engine was further connected to an Engine sensor block which was a sub-system.
Engine Sensor sub-system was attached below,
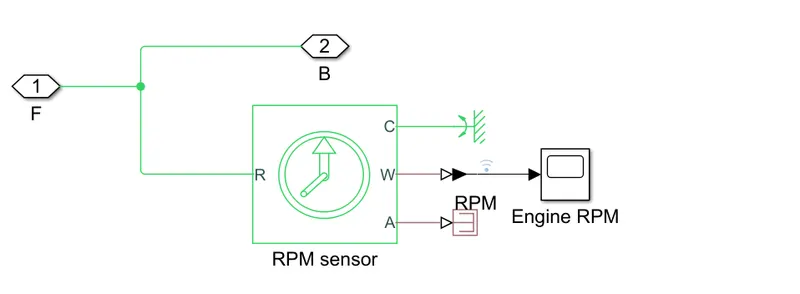
This sub-system consist of an Ideal Rotational Motion Sensor block , which receives the input from the crank shaft port.
This block was used to measure the angular velocity of the engine.
The port W representing angular velocity was connected to a scope block using a PS-Simulink converter.
The port A representing displacement was terminated.
Necessary references were connected and the angular velocity in RPM was obtained.
The output of this sub-system was connected to another sub-system named CVT.
CVT sub-system was attached below,
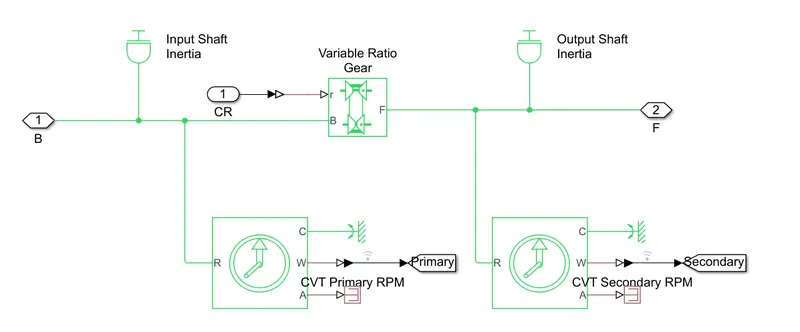
This sub-system consist of a variable gear system.
The input ton the sub-system was initially connected to an Input Inertia Shaft block which indicated that the torque is positive when the inertia is accelerated in positive direction.
It was futher connected to a Variable Ratio Gear block which represents the gear block used in CVTs. The port r receives the ratio of input to output angular velocities of the shatft.
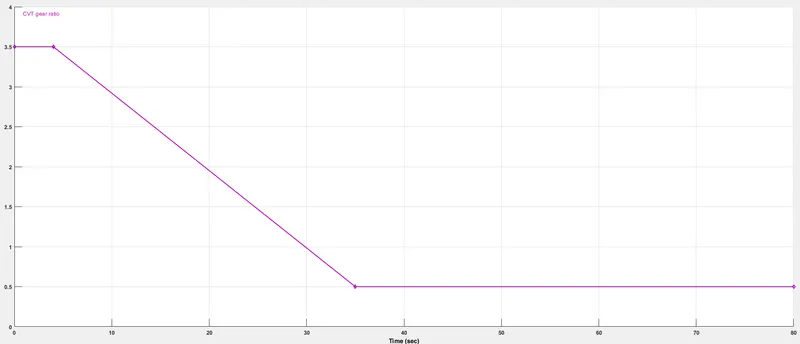
A Signal builder block was used to transfer the inputs to the r port , which defines the variable gear ratio input.
The Signal builder briefing was attached below,
Then the output port of the variable ratio gear was connected to an Output Shaft Inertia bloc and eventually it turns out to be the output of the sub-system.
Inside the sub-system there were two Ideal Rotational Motion Sensor blocks were connected at the either side of the Variable ratio gear block.
These sensors were used to obtain the primary and secondary angular velocities of the shaft, the necessary references were attached and the angular displacement port was teminated.
The output of thus sub-system was connected to a Simple Gear block which represents one gear system of a CVT.
This Simple gear block was further connecte to another sub-system named Vehicle Body.
Vehicle Body sub-system was attached below,
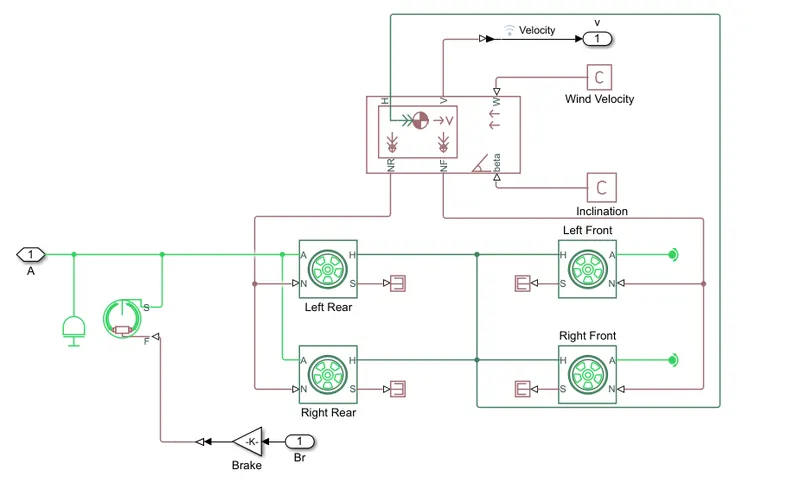
In this sub-system the input was connected to a Tire block.
Port A is the mchanical rotational conservation port for the axle.
Port H is the mechanical translational conservation port for the hub.
The thrust developed by the tire was applied to the vehicle through these bports.
It was initially connected to two tire blocks which represent the rear wheels that drive the vehicle.
These blocks were connceted an Inertia block and a Double shoe brake block .
The input for this brake block was given through the signal builder block which was created at the start that contains brake and throttle signals.
Then these two rear tyres are connected to two other tire blocks representing the front wheels.
All these four wheels were then connected to Vehicle Body block which represents a two axle vehicle body in longitudinal motion.
This block accounts for body mass,aerodynamic drag,road incline and weight distribution between axles due to acceleration and road profile.
It also includes pitch and suspension dynamics which were optional.
Ports NR and NF were normal forces acting on rear and front tires.
Port beta represents the inclination on the road , connected to a constant block of physical signal.
Port H was a mechanical translational motion port connected to the tires for translational motion.
Port W represents headwind speed which was alsoe connected to a PS constant block.
Port V represents the velocity of the vehicle which was also the output of this sub-system.
Then this output of the Velocity Body block was connected to a Goto block.
Then the From block of the whole model were now connected to scope blocks inorder to observe the results of the system.
Velocity from Velocity Body block , Brake and Throttle signals from the signal builder block were connected to one scope block and the output of two gears in the CVT sub-system were connected to another scope block representing their RPM.
RESULTS & OBSERVATION :
The Simulation had a runtime of 200 s.
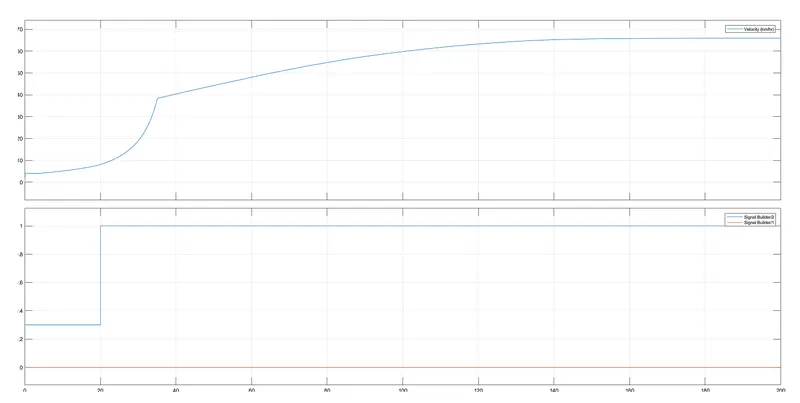
The plot obtained from the primary scope block containing velocity , brake and throttle inputs was attached below.
This plot clearly depicts that the vehicle speed increases as the throttle increases. Initially when the throttle was constant , the speed was rising slowly and once the throttle attains the maximum value , the speed was alsoe increased and then continued at constant speed.
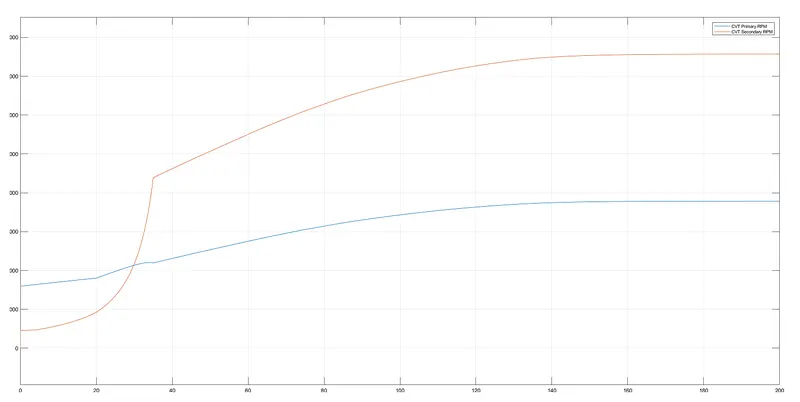
The plot obtained from the secondary scope block containing primary and secondat RPM inputs was attached below.
This plot was actually obtained from the RPM results from the CVT sub-system.
The blue curve represents the Primary RPM and the red curve represents the Secondary RPM.
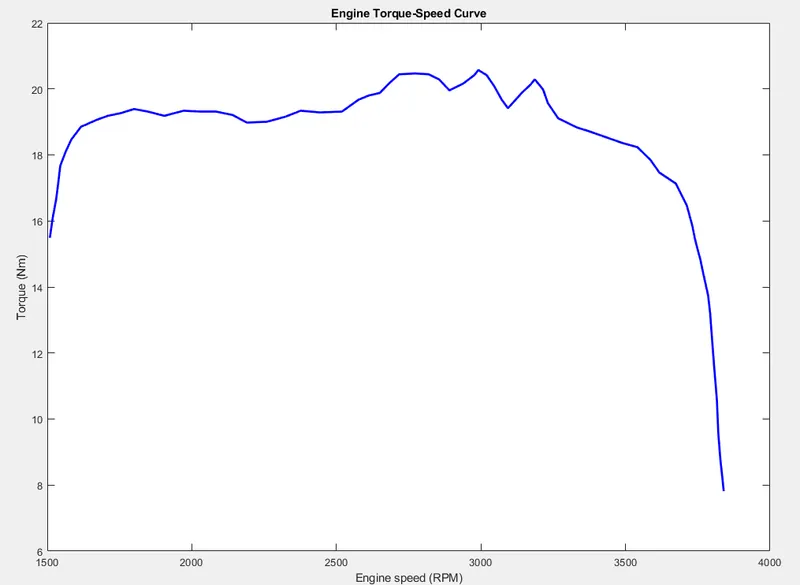
This plot below was obtained by clicking on the plot link in the model.
It depicts the relation between the Torque and Speed of the engine.
It was observed that at initial speeds , the torque was more. As the speed increases ,the torque also increases upto certain spped.
Torque is inversely propotional to the speed and thus at high speeds the torque was very less.
At high speeds there is no need for torque to move the vehicle.
Model With Dashboard :
The Simulation of a BAJA ATV model with CVT along with a Dashboard was attached below.
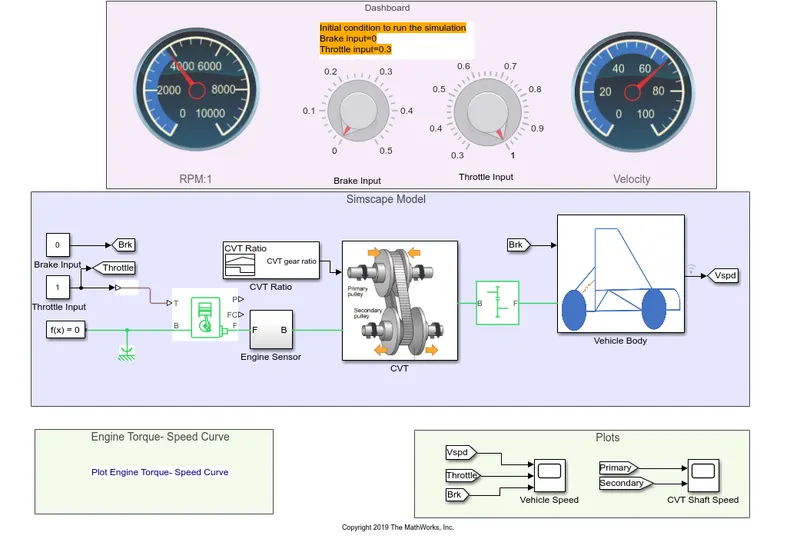
All the parts and sub-systems were common for both the models except the Dashboard.
A Dashboard is generally a control pannel usually located directly infront of the Vehicle's driver.
The Dashboard of this model was attached below,
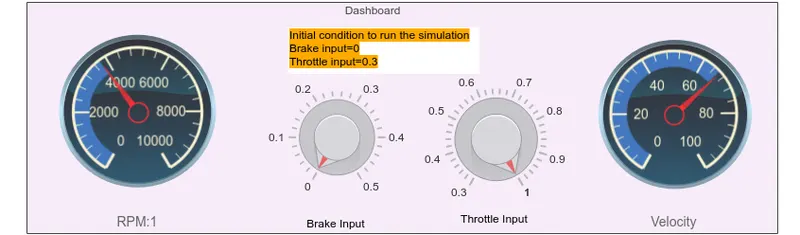
In this model the dashboard was used to control the Throttle and Brake inputs with knobs.
The above stated model with the dashboard has some minor differences and better representation then the first model.
After the simulation was run , it was observed that a Custom Gauge block displays the values of the RPM and speed in a speedometer like blocks.
The values of throttler and braking can be changed manually during the simulation using the provided knobs.
To assign thses types of inputs first a Constant block was used to give input to Throttle and Brake , then these blocks were linked with the Knob block seperately.
The minimum and maximum values were set in the knob blocks.
Likewise, the RPM from the scope block named as CVT shaft speed was linked with the first Custom Gauge Block named as RPM:1, it displays the RPM values.
The speed values from the scope block named as Vehicle speed was linked to the second Custom Gauge block named as Velocity, it displays the vehicle speed values.
Thus the change in results can be observed by varying the input values manually accoding to the requirements.
CONCLUSION :
The system level simulation for the BAJA ATV vehicle with CVT was performed successfully.
From the above study we can infer that ,
- Velocity, Shaft speed and Engine speed are directly proptional to the Throttle input and inversely propotional to the Brake input.
- The Primary CVT speed was greater than the Secondary CVT speed as they are directly propotional to the shaft diameter.
- With increase in the throttle value, the vehicle velocity increases on the other hand with the increase in the braking the vehicle slows down and stops.
Similar approach can be used to understand various other vehicle models.
REFERENCE :