Project 1 (Mini Project on Vehicle Direction Detection
General Overview:
Identifying the direction of the vehicle is one of the important & diverse features in Autonomous driving & Advanced Driver Assistance Features. This particular sub-feature of identifying the direction of vehicle is basically identifying the direction the vehicle is taking based on the camera input.
Camera reads the road signs & stores into its memory with unique values for left turn, right turn & straight drive. Depending on the direction it is taking, final indication is given to the driver – as an indication if he is driving in the recommended direction or not.
Vehicle Direction Determination can also be coupled along - side features like GPS systems to identify whether the vehicle is reaching its destination in an optimized manner. This sub feature can also be used along with Lane Detection, Highway Warning, Ramp Entry / Exit in Wrong Way Detection etc.
Objective of Project:
- Development of MATLAB Simulink model as per requirement.
- Tag the requirements to the simulink model; tagging requirement 1 & requirement 2 to their corresponding subsystems is fine.
- MBD compliant changes, Data Dictionary creation & code generation is added advantage, and that is not scope of this project.
- If choosing code generation, Storage class for Input signals: ImportedExtern; Storage class for Output signal: Export to File; Storage class for local signals: localizable; Storage class for calibration signals: Const.
- Choose sample time for all signals as 0.01s
Signals & Calibration Data List:
|
Signal / Calibration Name |
Signal Type |
Data Type |
Sample Time |
Dimension |
Min |
Max |
Initial Value |
Units |
|
SteeringWheel_YawDegreeInput |
Input |
Int16 |
0.01 |
1 |
-180 |
180 |
- |
Deg |
|
CameraInput_RoadSign |
Input |
Boolean |
0.01 |
1 |
0 |
1 |
- |
- |
|
Vehicle_Turn_Status |
Local |
Int16 |
0.01 |
1 |
-180 |
180 |
- |
Deg |
|
Right_Turn_AngularLimit |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
30 |
Deg |
|
|
Left_Turn_AngularLimit |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
-120 |
Deg |
|
|
Straight_Drive_Steering_Angle |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
0 |
Deg |
|
|
RightTurn_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
30 |
||
|
LeftTurn_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
-120 |
||
|
Straight_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
0 |
||
|
Vehicle_Direction_Indicator |
Output |
Boolean |
0.01 |
1 |
0 |
1 |
- |
- |
Simulink Model:-
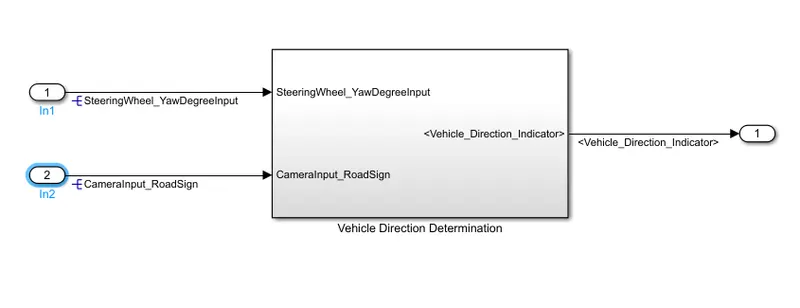
Vehicle Direction Determination Subsystem:-
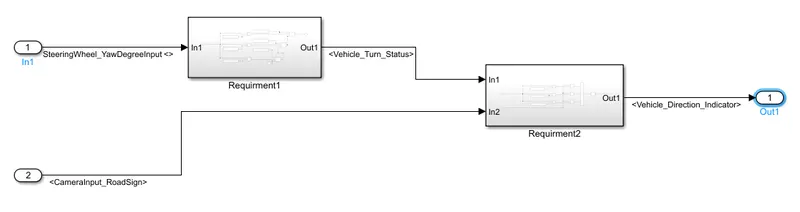
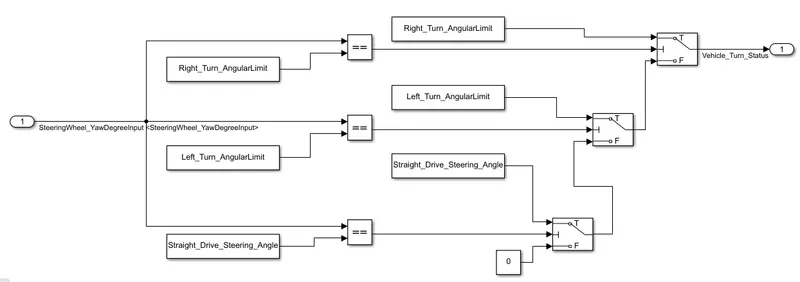
Requirement - 1:
- Steering wheel input as yaw rate (Signal name: SteeringWheel_YawDegreeInput) is the input for this system.
- This is compared against 3 angular values, one each for left turn, right turn & straight drive (Calibration Values: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle) to say which specific direction the steering wheel is turning towards.
- Use switch blocks to compare & develop this requirement. Keep this requirement in a subsystem & output of this requirement is a local signal (Signal Name: Vehicle_Turn_Status).
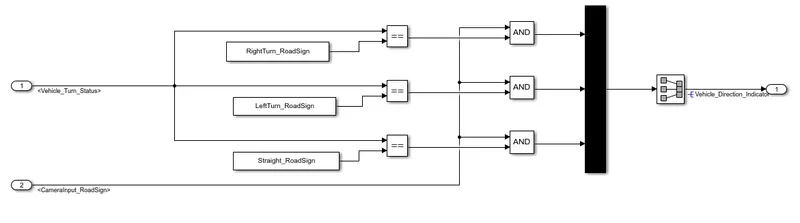
Requirement – 2:
- Keep this requirement as a separate subsystem. Inputs to this requirement are local signal from requirement 1 (Signal Name: Vehicle_Turn_Status) & an input signal from camera (Signal Name: CameraInput_RoadSign), which confirms the occurrence of a road sign.
- Signal Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign), if each of them is found equal, then each of the three corresponding output is compared against the camera input signal,
- Using a logical operator block, only one among them is finally given as output signal (Signal Name: Vehicle_Direction_Indicator).
Procedure to create SLDD :-
- Go to SIMULINK blank model click on model setting from modeling option.
- Click on the model properties
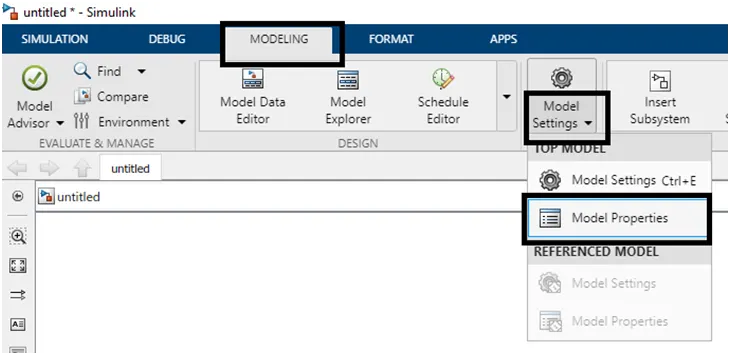
- In Model properties click on external data. and then to create SLDD file click on New.
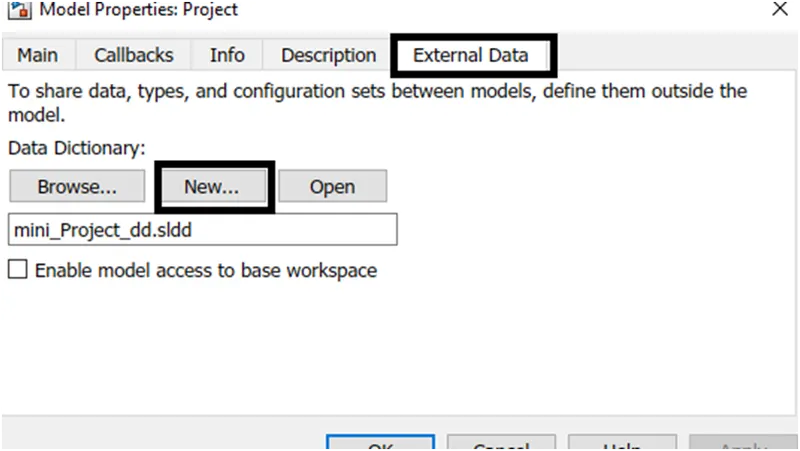
- By clicking on New bellow window appeares and then give the filename and save the file. The file wii be saved with extention .sldd
- After that back to simulink blank model and click on the left bottom corner newly appered icon and it takes us to the editing window.
- In that window click on the .sldd file and then Design Data.
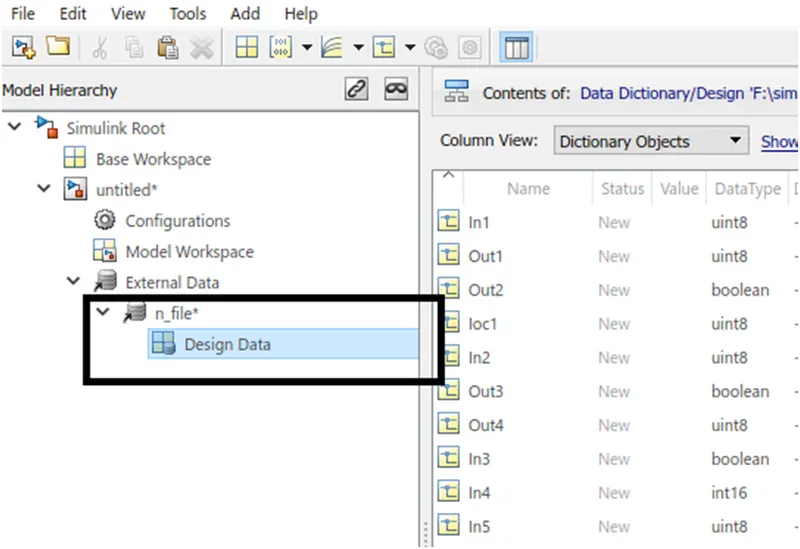
- After this we can create the data as per our requirment. We can add constunt, signals and many more.
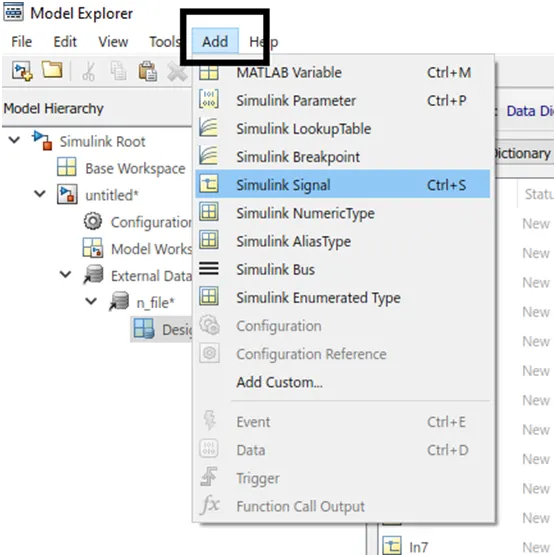
Data Dictionary:-
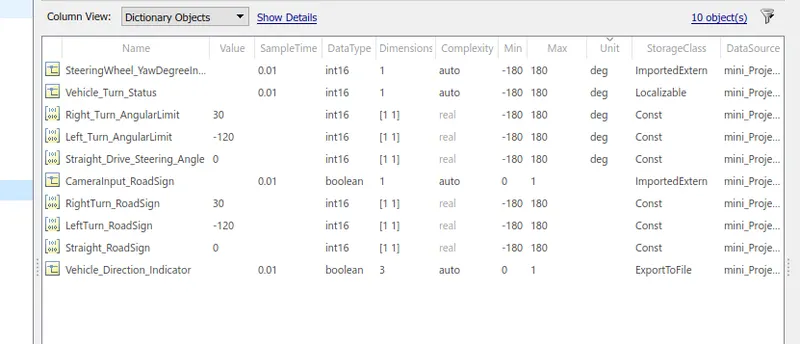
Tagging of Requirement1 And Requirement2:-
- Copy the data in Microsoft Word for Requirment 1 and Requirment 2
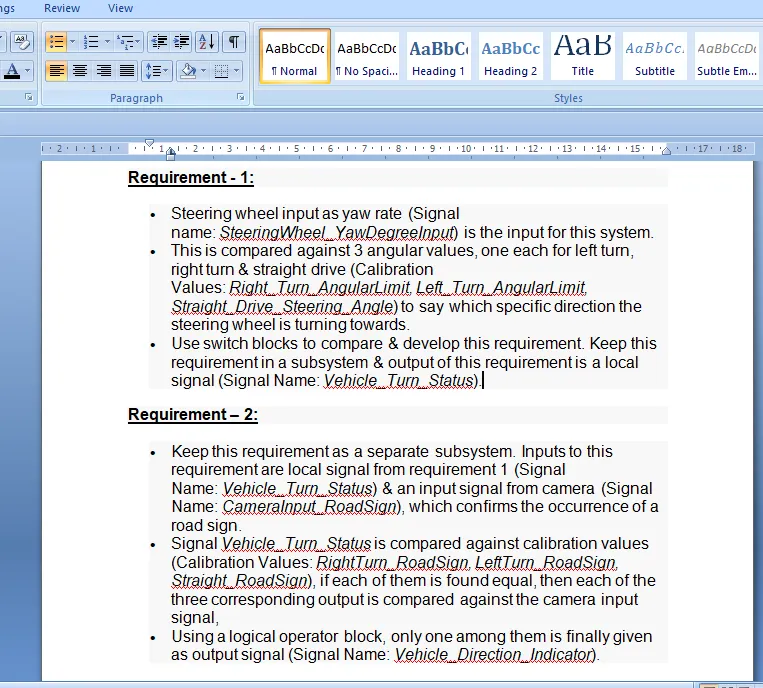
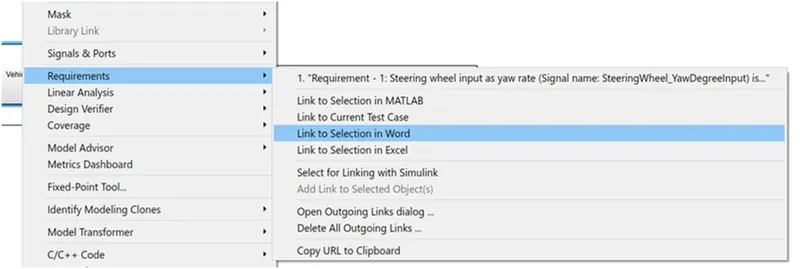
- Right click on requirement 1 and the following option shows select requirement further is given below.
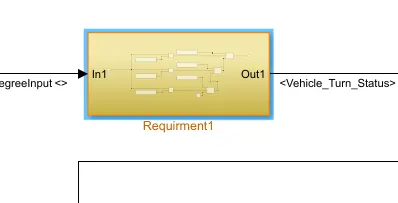
- Same procedure is to be done for requirment 2
Code Generation for model:-
Project.c
/*

 * File: Project.c

 *

 * Code generated for Simulink model 'Project'.

 *

 * Model version                  : 1.8

 * Simulink Coder version         : 9.5 (R2021a) 14-Nov-2020

 * C/C++ source code generated on : Sat Jan 15 22:25:20 2022

 *

 * Target selection: ert.tlc

 * Embedded hardware selection: Intel->x86-64 (Windows64)

 * Code generation objectives: Unspecified

 * Validation result: Not run

 */


#include "Project.h"

#include "Project_private.h"


/* Exported data definition */


/* Definition for custom storage class: ExportToFile */

boolean_T Vehicle_Direction_Indicator[3];/* '<S3>/Signal Conversion' */


/* Const memory section */

/* Definition for custom storage class: Const */

const int16_T LeftTurn_RoadSign = -120;/* Referenced by: '<S3>/Constant1' */

const int16_T Left_Turn_AngularLimit = -120;/* Referenced by:

                                             * '<S2>/Constant3'

                                             * '<S2>/Constant4'

                                             */

const int16_T RightTurn_RoadSign = 30; /* Referenced by: '<S3>/Constant' */

const int16_T Right_Turn_AngularLimit = 30;/* Referenced by:

                                            * '<S2>/Constant'

                                            * '<S2>/Constant1'

                                            */

const int16_T Straight_Drive_Steering_Angle = 0;/* Referenced by:

                                                 * '<S2>/Constant2'

                                                 * '<S2>/Constant5'

                                                 */

const int16_T Straight_RoadSign = 0;   /* Referenced by: '<S3>/Constant2' */


/* Real-time model */

static RT_MODEL_Project_T Project_M_;

RT_MODEL_Project_T *const Project_M = &Project_M_;


/* Model step function */

void Project_step(void)

{

  int32_T rtb_Vehicle_Turn_Status;


  /* Switch: '<S2>/Switch' incorporates:

   *  Constant: '<S2>/Constant'

   *  Constant: '<S2>/Constant1'

   *  Constant: '<S2>/Constant2'

   *  Constant: '<S2>/Constant3'

   *  Inport: '<Root>/In1'

   *  RelationalOperator: '<S2>/Relational Operator'

   *  RelationalOperator: '<S2>/Relational Operator1'

   *  RelationalOperator: '<S2>/Relational Operator2'

   *  Switch: '<S2>/Switch1'

   *  Switch: '<S2>/Switch2'

   */

  if (SteeringWheel_YawDegreeInput == Right_Turn_AngularLimit) {

    rtb_Vehicle_Turn_Status = Right_Turn_AngularLimit;

  } else if (SteeringWheel_YawDegreeInput == Left_Turn_AngularLimit) {

    /* Switch: '<S2>/Switch1' incorporates:

     *  Constant: '<S2>/Constant4'

     */

    rtb_Vehicle_Turn_Status = Left_Turn_AngularLimit;

  } else if (SteeringWheel_YawDegreeInput == Straight_Drive_Steering_Angle) {

    /* Switch: '<S2>/Switch2' incorporates:

     *  Constant: '<S2>/Constant5'

     *  Switch: '<S2>/Switch1'

     */

    rtb_Vehicle_Turn_Status = Straight_Drive_Steering_Angle;

  } else {

    /* Switch: '<S2>/Switch1' incorporates:

     *  Constant: '<S2>/Constant6'

     *  Switch: '<S2>/Switch2'

     */

    rtb_Vehicle_Turn_Status = 0;

  }


  /* End of Switch: '<S2>/Switch' */


  /* SignalConversion: '<S3>/Signal Conversion' incorporates:

   *  Constant: '<S3>/Constant'

   *  Constant: '<S3>/Constant1'

   *  Constant: '<S3>/Constant2'

   *  Inport: '<Root>/In2'

   *  Logic: '<S3>/AND'

   *  Logic: '<S3>/AND1'

   *  Logic: '<S3>/AND2'

   *  RelationalOperator: '<S3>/Relational Operator'

   *  RelationalOperator: '<S3>/Relational Operator1'

   *  RelationalOperator: '<S3>/Relational Operator2'

   */

  Vehicle_Direction_Indicator[0] = (CameraInput_RoadSign &&

    (rtb_Vehicle_Turn_Status == RightTurn_RoadSign));

  Vehicle_Direction_Indicator[1] = (CameraInput_RoadSign &&

    (rtb_Vehicle_Turn_Status == LeftTurn_RoadSign));

  Vehicle_Direction_Indicator[2] = (CameraInput_RoadSign &&

    (rtb_Vehicle_Turn_Status == Straight_RoadSign));

}


/* Model initialize function */

void Project_initialize(void)

{

  /* (no initialization code required) */

}


/* Model terminate function */

void Project_terminate(void)

{

  /* (no terminate code required) */

}


/*

 * File trailer for generated code.

 *

 * [EOF]

 */
Result:
- Model Created as per Requirement subsystem also created as per model requirement.
- Subsystem are attached with requirement word document tagging .
- SLDD file also Created as per Requirement.
- C code generated and given in the report as shown above.