Planetary Gear
Aim
To Create a 3D Model of Planetary Gear and perform motion analysis.
Introduction
Planetary Gear System
A Planetary Gear System (also known as an epicyclic Gear System), consists of two gears mounted so that the center of one gear revolves around the center of the other. A carrier connects the centers of the two gears and rotates to carry one gear, called the planet gear or planet pinion, around the other, called the sun gear or sun wheel. The planet and sun gears mesh so that their pitch circles roll without slip.
An epicyclic gear system can be assembled so the planet gear rolls on the inside of the pitch circle of a fixed, outer gear ring, or ring gear sometimes called an annular gear.
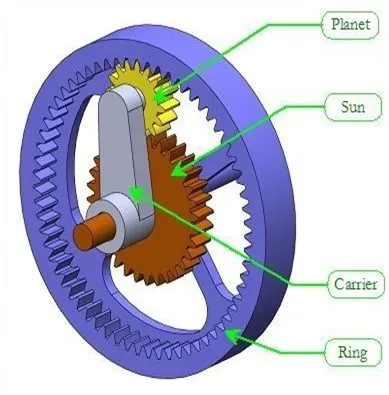
Objectives: -
- Create 3D models for Planetary Gear System
- Obtain a plot of Angular Velocity for each case:
- Fixed = Ring Gear, Input = Sun Gear, Output = Carrier
- Fixed = Sun Gear, Input = Ring Gear, Output = Carrier
- Fixed = Carrier, Input = Sun Gear, Output = Ring Gear
- Calculate the Pitch Diameter and Number of Teeth of Planet Gear
Setup: -
- Geometry Of Various Gears
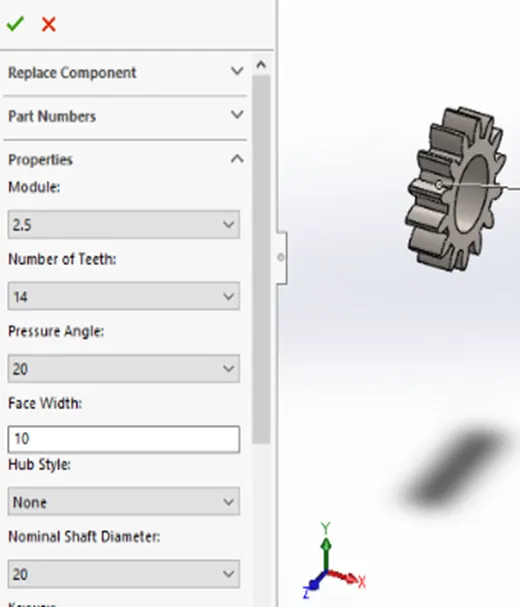
- Sun Gear
Module = 2.5
Number of Teeth = 14
Pitch Diameter
= Module X No. of Teeth
= 2.5 X 14 = 35mm
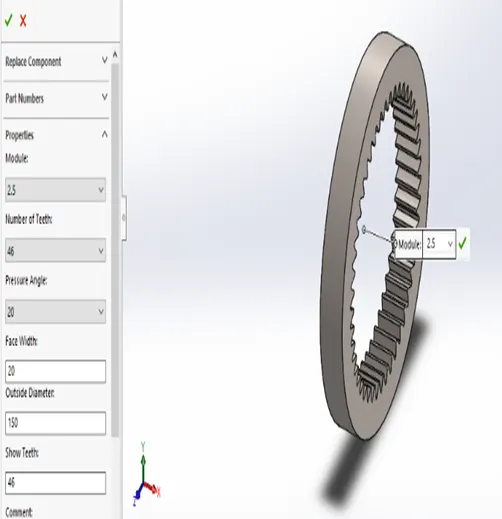
- Ring Gear
Module = 2.5
Number of Teeth = 46
Pitch Diameter
= Module X No. of Teeth
= 2.5 X 46 = 115mm
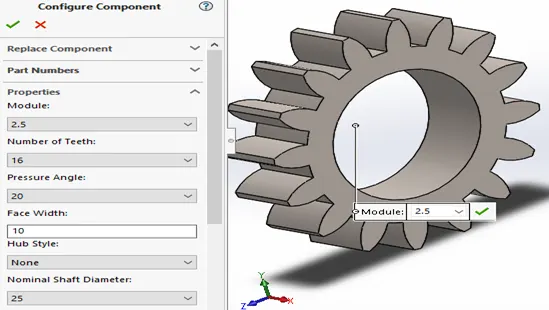
- Planet Gear x4
Module = 2.5
Pitch Diameter
= Pitch Diameter of Ring Gear – Pitch Diameter of Sun Gear
= 115mm – 35mm = 40mm
Number of teeth
= Pitch Diameter / Module
= 40 / 2.5 = 16
- Carrier
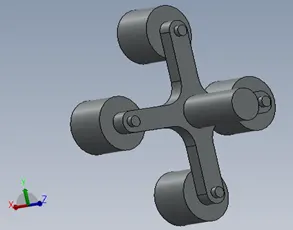
- Sun Gear
- Assembly
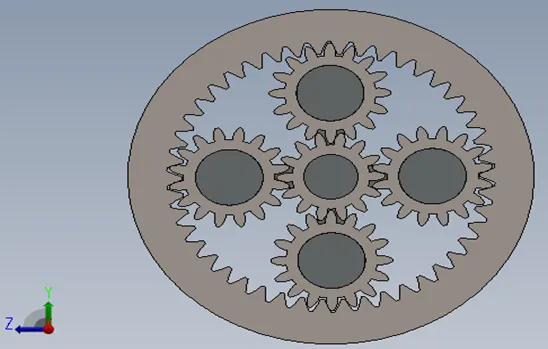
- Mates
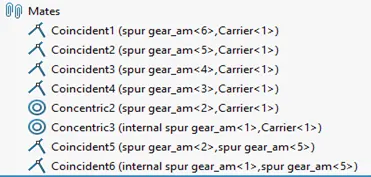
Study: - (200rpm)
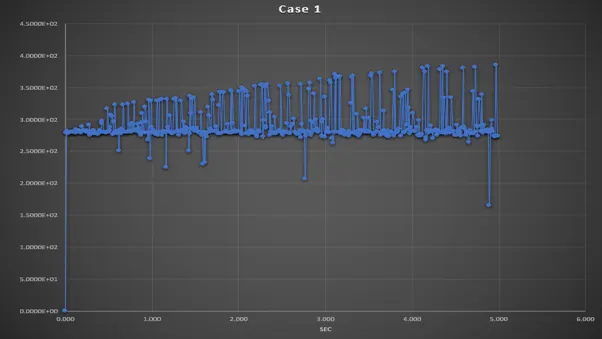
- Case 1
Fixed = Ring Gear
Input = Sun Gear
Output = Carrier
Angular Velocity at Carrier
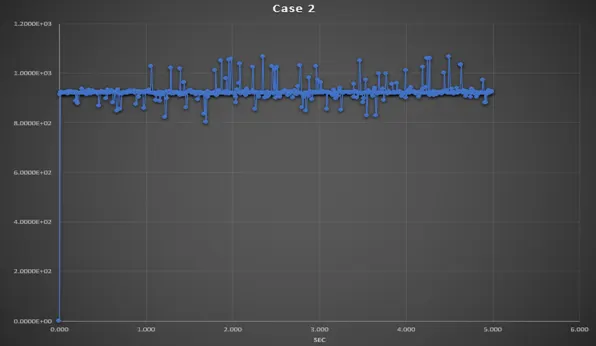
- Case 2
Fixed = Sun Gear
Input = Ring Gear
Output = Carrier
Angular Velocity at Carrier
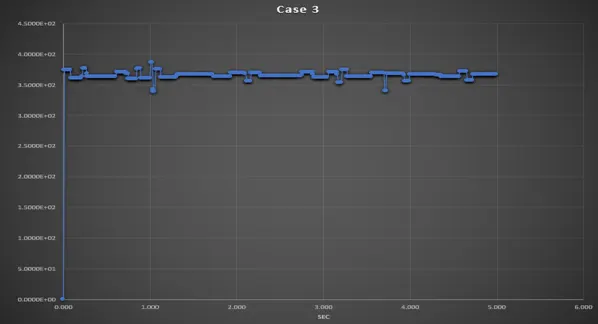
- Case 3
Fixed = Carrier
Input = Sun Gear
Output = Ring Gear
Angular Velocity at Ring Gear
Observation and Conclusion: -
- We have finally able to get the plot for all the case.
- The big deviation in Angular Velocity is because due to fact that during entering the slot for the first time it enters very gently in order to adjust any misalignment and as soon as alignment is set it gets steadied from there.
- All the animations are attached