Final Project: Design of an Electric Vehicle
AIM :
Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following
OBJECTIVES - To Prepare a report about
1. System level configurations
2. Model parameters
3. Results
4. Conclusion
CONCEPT OF BATTERY ELECTRIC VEHICLE (BEV):
➡ An electric car is a vehicle that is propelled buy one or more electric motors using energy stored in rechargeable battery packs.
➡ These are eco-friendly and has higher efficiency compare to IC cars. An electric vehicle is 69 to 70% efficient when counted against stored chemical energy and around 60% efficient when counted against required energy to recharge. They use electric motors for propulsion.
➡ The most common type of motor is used for permanent magnet synchronous motor(PMSM) at three phase induction motor.
➡ Electric vehicle use electricity for power instead of fossil fuels like conventional vehicles. So they do not produce any exhaust gases and pollution. The power did in the electric vehicle come from battery generator or any collector system. Batteries fitted in the electric vehicle are of high energy density in order to make the power requirement and range.
There are two main types of battery electric vehicles (BEV) i.e fully electric and plug in hybrid(PHEV)
BATTERY ELECTRIC VEHICLES
- Can be charged at home overnight, providing enough range for average journeys.
- Butlong journeys or those that require a lot of hill climbs may mean that the fuel cells require charging before you reach your destination.
- Although regenerative braking can help mitigate against this by charging the battery packs.
- Charging ranges from 30 minutes and upto more then 12 hours. This all depends on the speed of charging station and size of battery.
Advantages of Fully electric or Battery Electric vehicle(BEV) :
1 . Creates no noise next to negligible
2. No spark plugs,geatrs or clutch.
3. Doesnt burn fossil fuels, instead uses rechargable batteries.
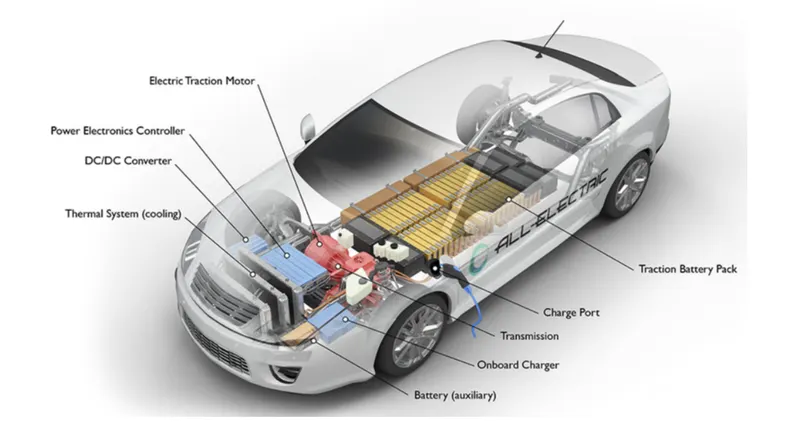
Plug-in Hybrid vehicles :
- Hybrid electric vehicles offer a mixture of battery and petrol our diesel power.
- This makes them better for travelling long distances as you can switch to traditional fuels rather then to find a stop to charge the battery.
- The same disadvantages that apply to IC engine will also apply to PHEVs.
- Need more maintenance, engine noise, emission and cost of petrol.
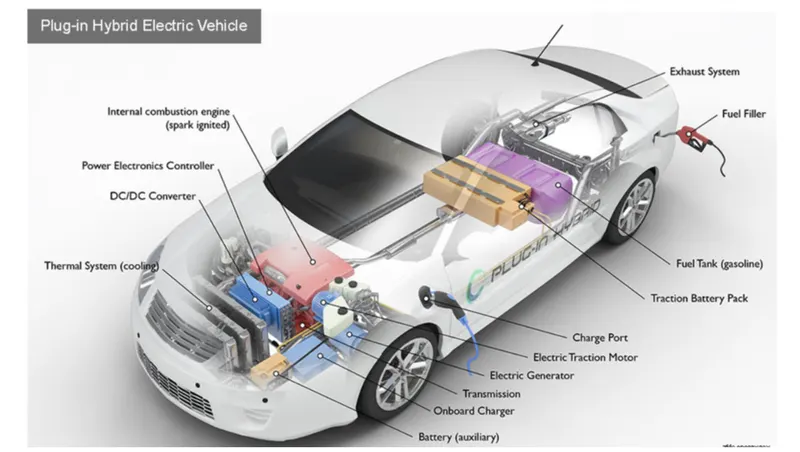
Components :
The main components of the electric vehicle are :
- Wheels/tires
- Battery
- Motor/Generator
- Power Converters
- Transmission system
- Motor controllers
BLOCK DIAGRAM :
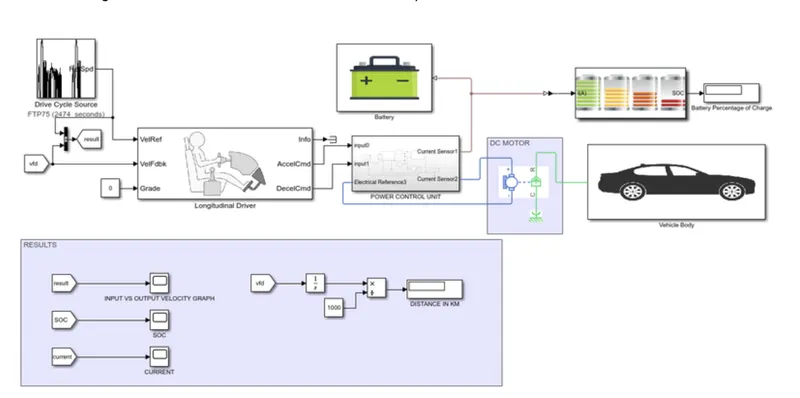
Block diagram for electric vehicle while using a battery and a DC motor.
Drive Cycle data :
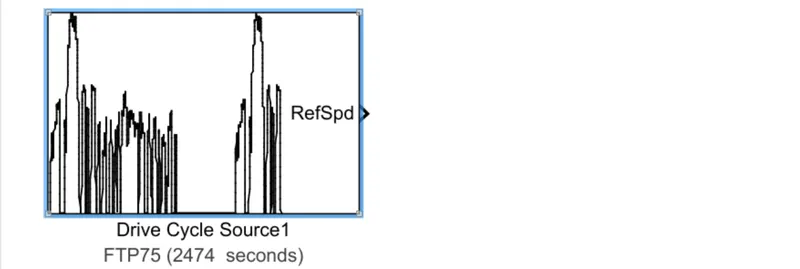
The block parameters for this block are
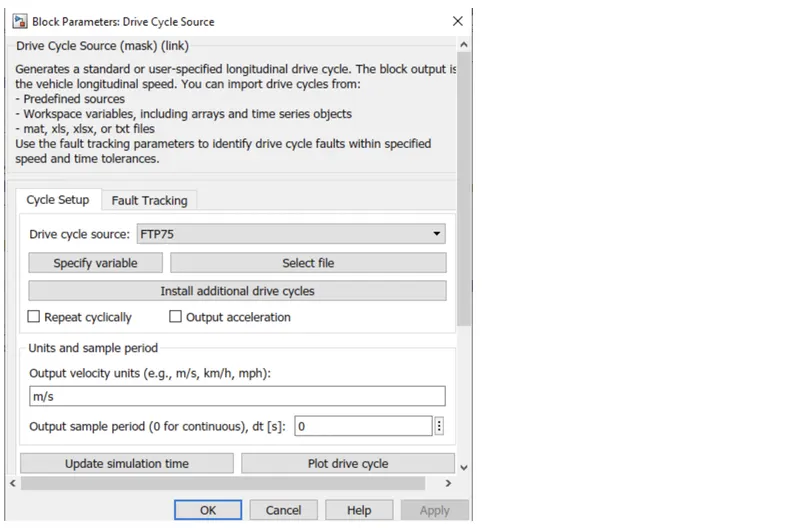
This block will help us in in putting the drive cycle data, whether it is built in or custom made by the user. That is we can use the custom made drive cycle data in excel sheet using this block.
For this model we have used FTP 75 drive cycle, which is inbuilt in this block.
Longitudinal Driver :
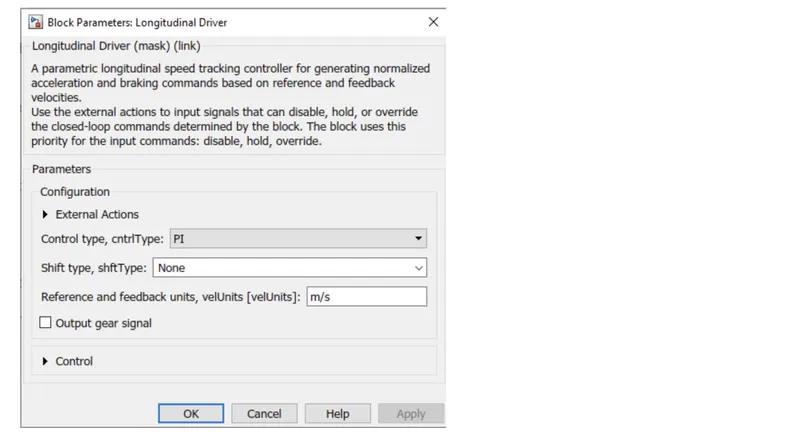
This block is used to create a longitudinal speed tracking controller and it is based on the reference and feedback velocity, the block generates normalise acceleration and breaking commands that can vary from 0 to 1. We can use this block to model the dynamic response of a driver or to generate the commands necessary to track and longitudinal drive cycle
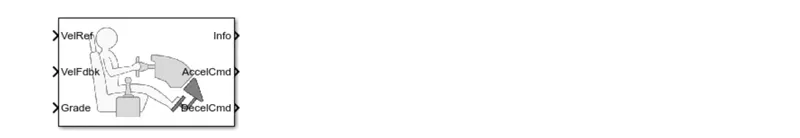
The block parameters are shown below
Power unit control Subsystem :
• Disturb system has the blocks which are used to create the voltage signals to control the motor speed as per the input drive cycle data.
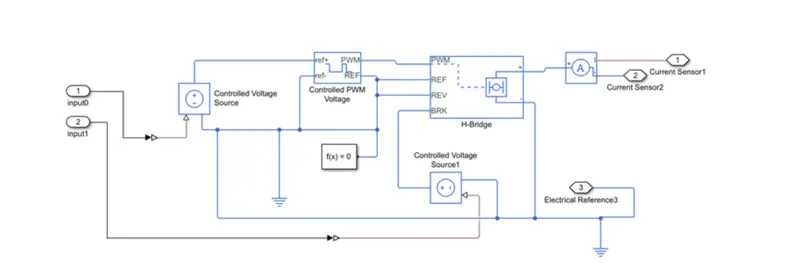
• Subsystem is connected to the longitudinal driver Block output ports namely acceleration command deceleration command.
• Disturb system will convert this acceleration and deceleration command into what is signal using 2 control voltage source Block control PWM voltage block , a H bridge and a current sensor.
Controlled voltage sensor block :
The block parameter is shown below
• This lock is used to maintain the specified voltage at its output regardless of the current flowing through the source.
Controlled PWM voltage block :
The block and its parameters are shown below
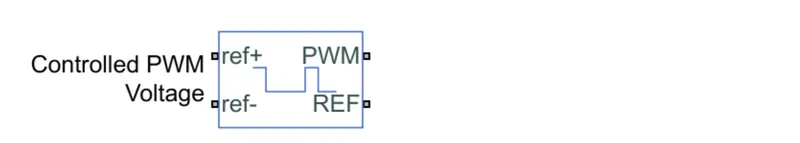
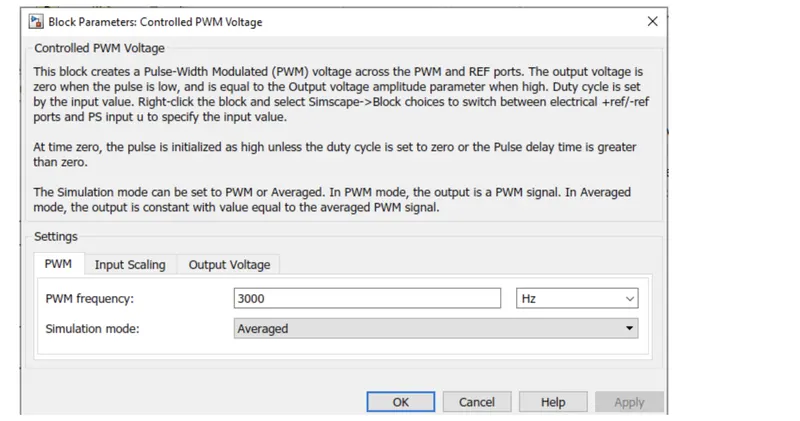
• This block is used to create the pulse width modulated(PWM) voltage.
• Electrical input ports :- the block calculate the duty cycle based on the reference voltage across its reference+ and reference- ports. This Modelling variant is the default.
• The value of the output voltage amplitude parameter determines amplitude of the output voltage
H-Bridge Block :
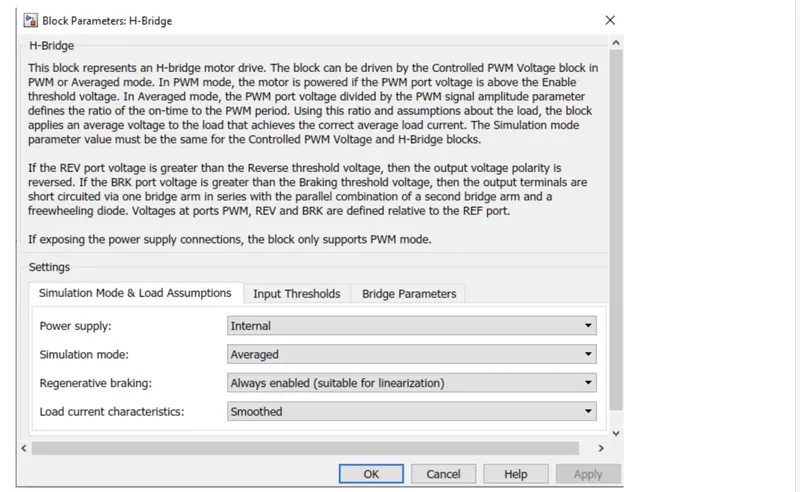
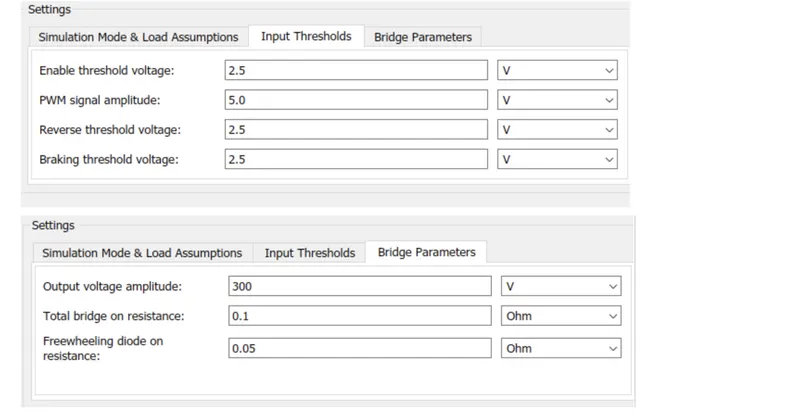
• This block is used to change the polarity of the voltage applied across the DC motor so as to run the motor in forward and reverse direction as per the input command.
Block and its parameters are shown below,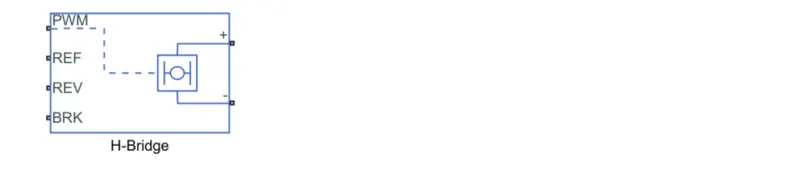
Current Sensor Block :
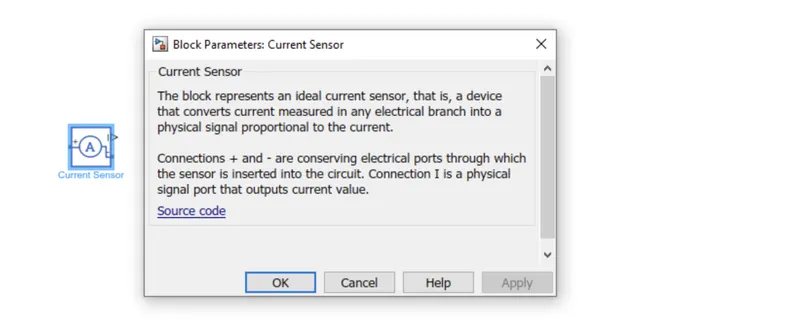
• This block is used to measure the current flowing through the H bridge.
The block and its perimeters are shown below
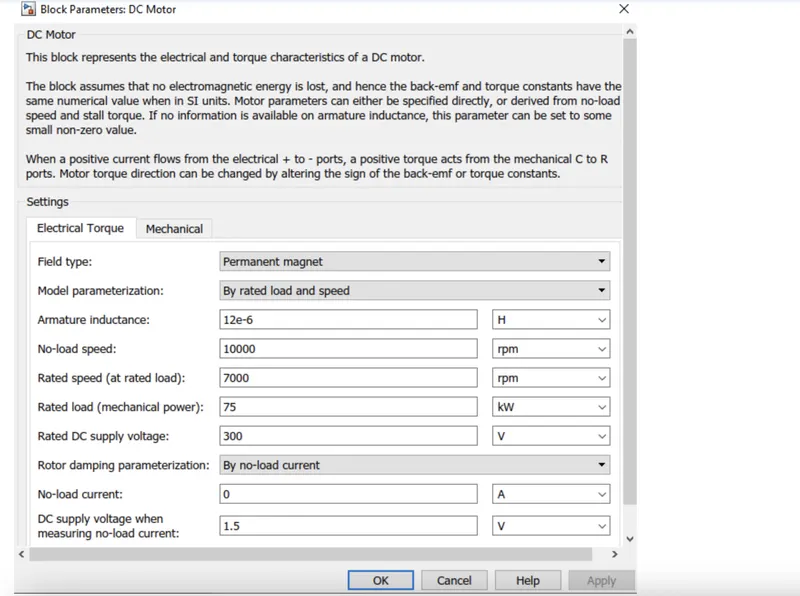
DC Motor :
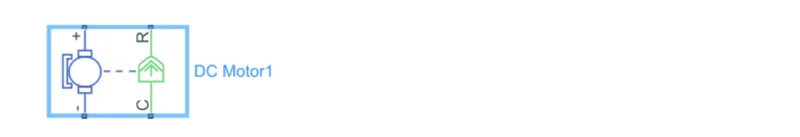
• This block is used to convert the electrical energy to mechanical energy. In this electric vehicle model we have used DC motor.
• This motor can act as a generator in case of regenerative braking.
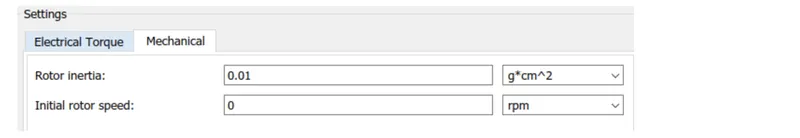
• The motor Block and its perimeter are shown below
Battery Subsystem :
• In this subsystem we have a battery block a controlled current source block and a goto Block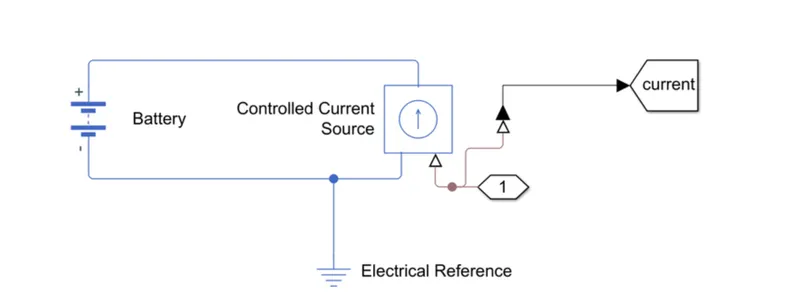
Battery Block :
• This battery Block represents a simple battery model.
• The Block model is the battery as a series internal resistance and a constant voltage source.
• The block and its perimeters are shown below
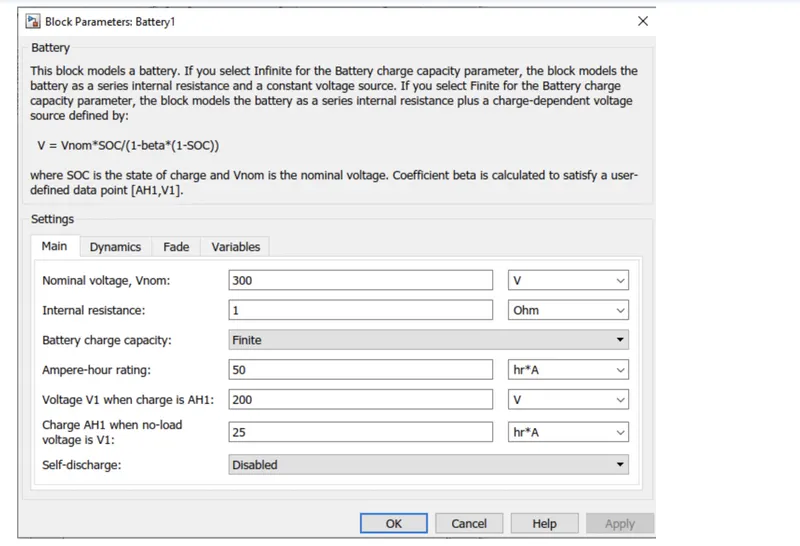
All other parameters section are kept at default value.
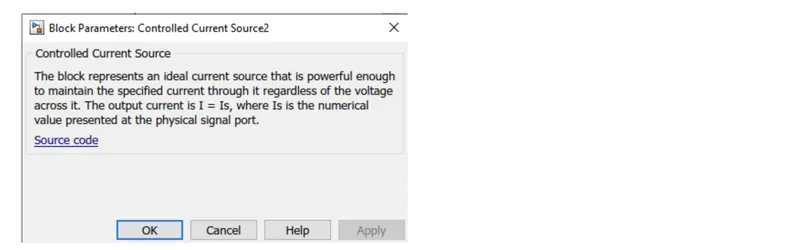
Controlled Current Source Block:
• This block gives a constant current output regardless of the voltage across it.
• TheBlock and it's parameters are shown below
Goto Block :
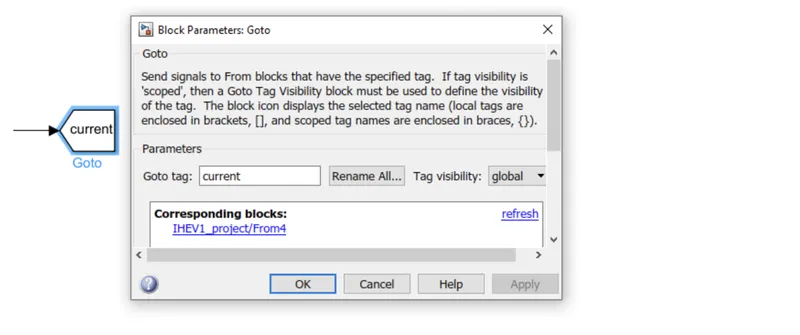
• It is used to pass values to the’From Block’ so that this value can be accessed from anywhere in the simulink diagram.
• This input can be a real or complex valued signal or vector of any data type.
• This’From Block’ and ‘Goto block’ allows us to pass a single from one group to another without actually connecting them.
State Of Charge (SOC) calculation subsystem :
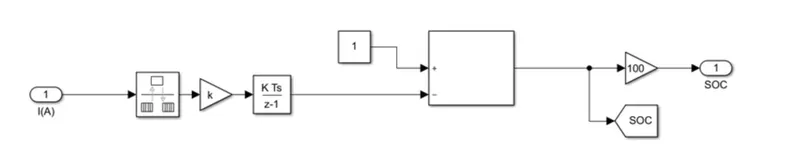
• The input for this is from the current sensor.
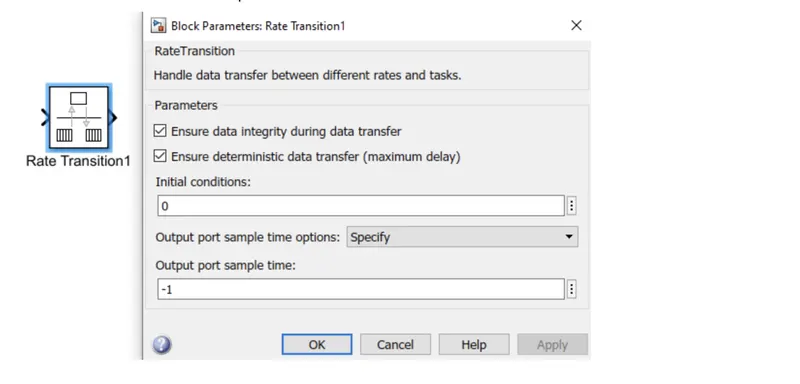
• Now this is connected to the rate transition Block. This sentence the transfer of data between blocks operating at different rates.
• The Block and its parameters are shown below,
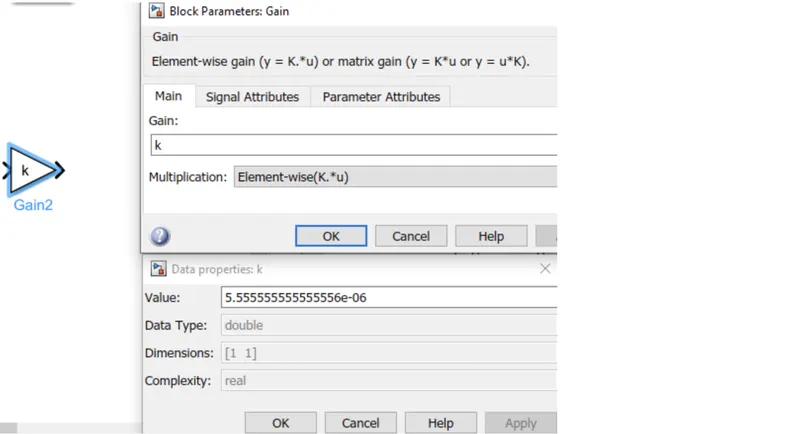
• Then a gain block is connected to it. This gain will multiply the value of k = 1/ A*sec,
Where A* sec is ampere second value of battery
In this case the battery capacity is in A*hr , which is ampere hour
To convert,
A*sec = A*hr * (3600)
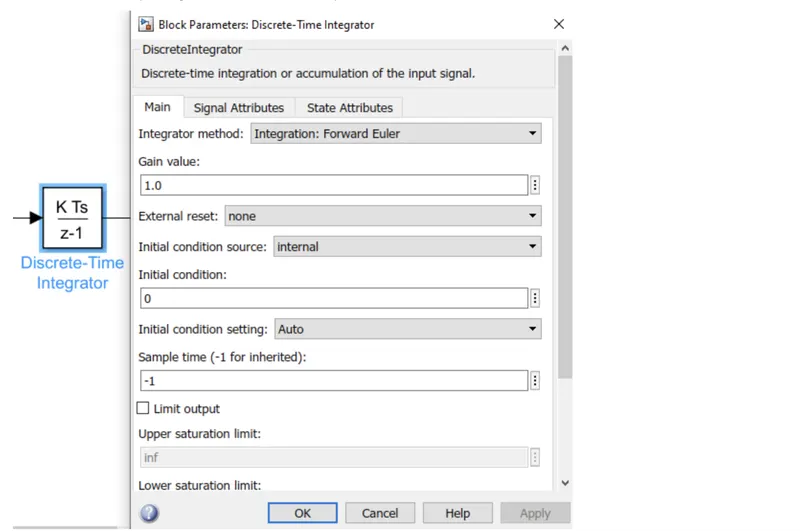
• Then to add all these values with respect to time we have used a Discrete-time-integrator. This block will accumulate the input signal.
• The block and it's parameters are shown below
• Now this added value is subtracted from 1, which will give us the remaining SOC. To convert this to percentage we have multiplied by 100 using another gain block.
• Also a goto block is used here to get a SOC values.
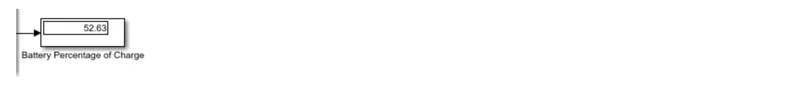
• The output from the subsystem is connected to a display block which will display the battery percentage as shown below
Vehicle-Body Subsystem :
• This Subsystem represents the body of the vehicle. The block diagram for this subsystem is shown below
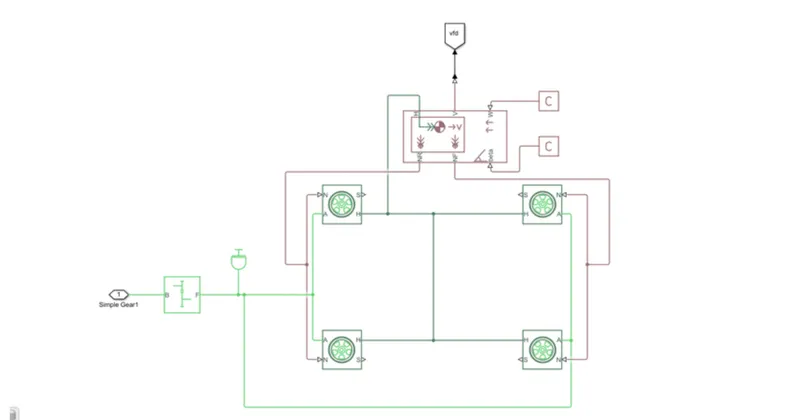
• The input to this subsystem is the mechanical rotational conserving port of the DC motor block.
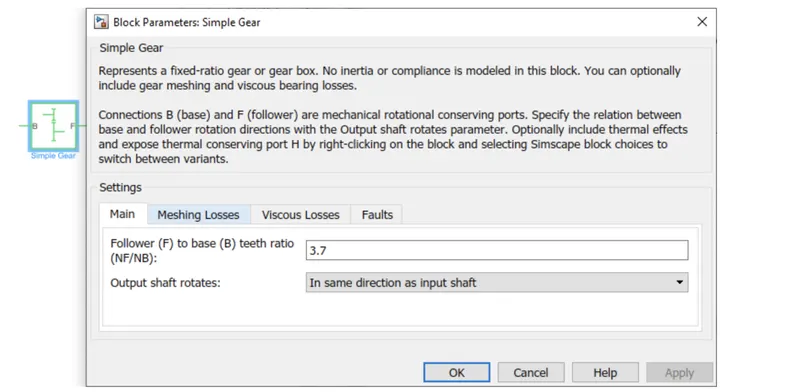
• This is connected to the single speed gear box of gear ration 3.7
• The block and its parameters are shown below,
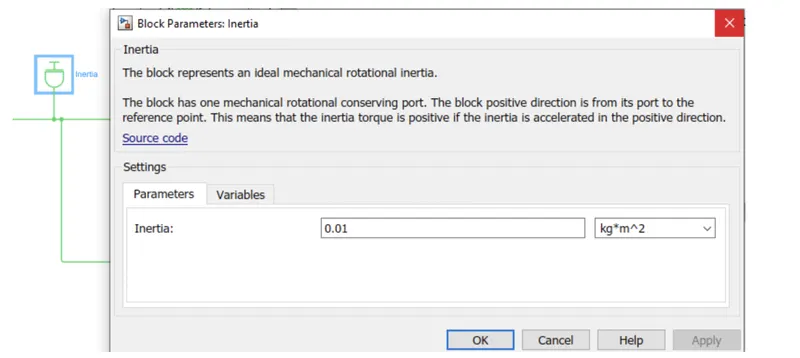
• The inertia acting on the shafts is given using a inertia block. This block and its parameters are shown below
• Now the simple gear is connected to all four wheels, representing an all wheel drive vehicle.
• The tires are represented using tire block.
• The block and its parameters are shown below,
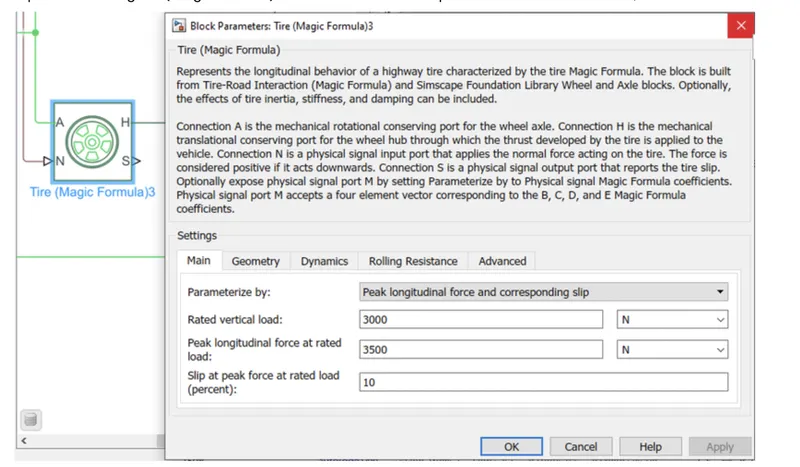
• The simple gear is connected to the axle port of tire block.
• Now to represent the vehicle body we have used the vehicle body block.
• This block and its parameters are shown below,
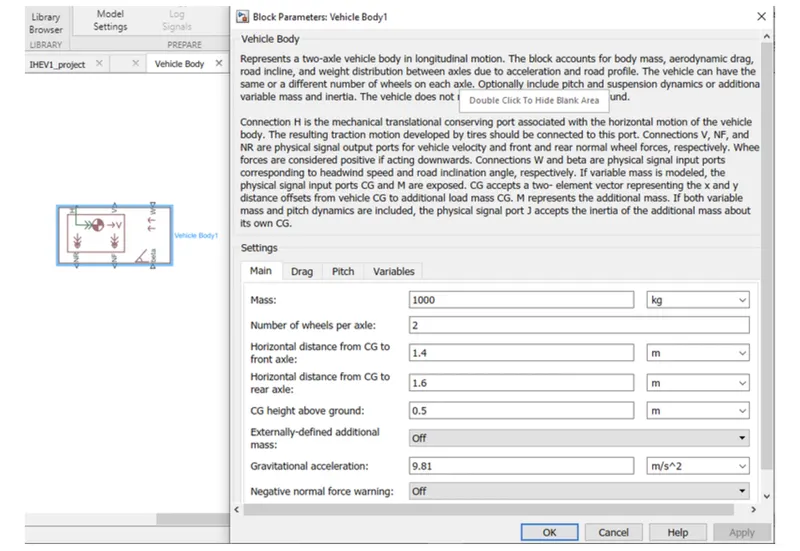
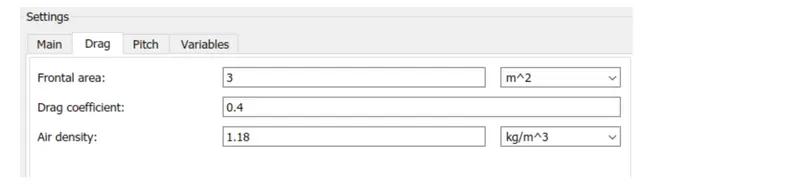
•The input to this subsystem is the mechanical rotational conserving port of the DC motor block.
•This is connected to the single speed gear box of gear ration 3.7
•The block and its parameters are shown below,
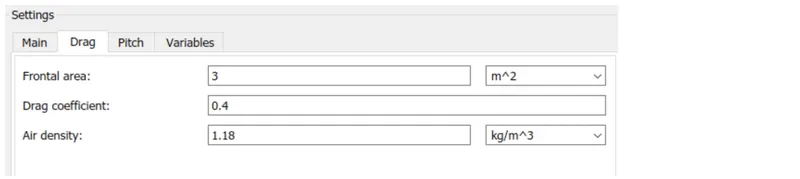
• Now to the front and rear normal forces ports represented by NF & NR respectively of the vehicle body we have connected the 4 tyre. 2 at NF port and 2 at NR ports. This represents the front 2 tyres and the rear 2 tyres.
• Also the mechanical translational conserving port for the wheel hub represented by H in tyre block is connected to the port H in the vehicle body block which represents the mechanical translational conserving port associated with the horizontal motion of the vehicle body.
• To the gradient and wind speed ports of the vehicle body block, we have connected physical signal constant block.
• The output from the vehicle body is the velocity of the vehicle. This output is connected to got block with tag ‘vid’.
• Now coming back to to longitudinal driver block, the velFbdk input to this block is given using the ‘From Block’ with tag’vfd’. This is the output from vehicle body block.
RESULTS :
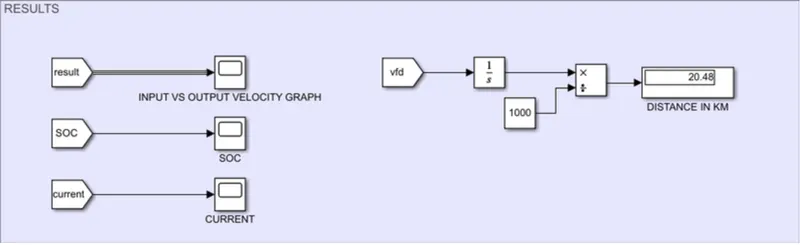
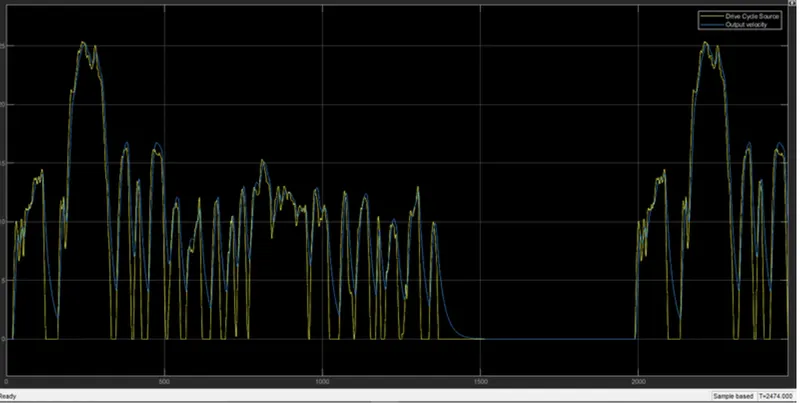
➡ Here the first scope is input vs output velocity graph.
➡ This scope has 2 inputs, one is FTP 75 drive cycle and the other one is velocity feedback. This two is combined using a bus and connected to a goto block with tag result and the corresponding ‘FromBlock’ is connected to the scope to get this graph.
➡ The result of graph is shown below,
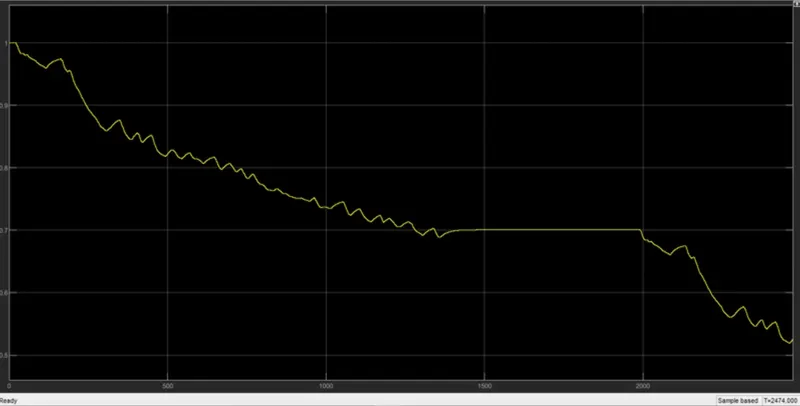
➡ The next step is used to get the change in SOC value wrt time.
➡ The input for this scope is ‘From Block’ with tag ‘SOC’.
The result of graph is shown below,
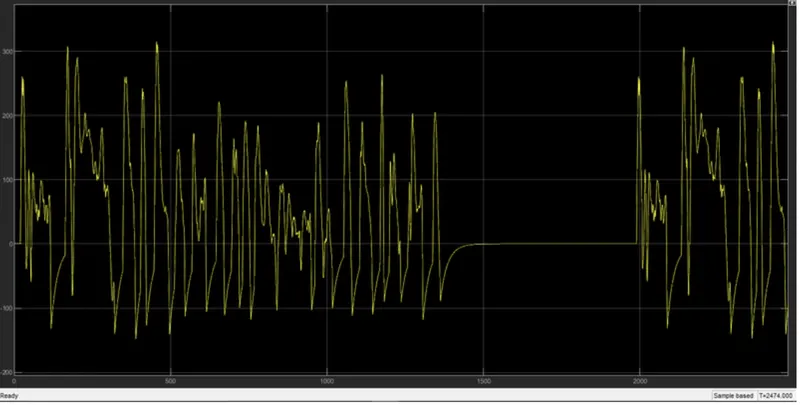
➡ The third score is used to get the current value with respect to time.
➡ Its input is ‘from block’ with tag ‘current’.
The result of graph is shown below,
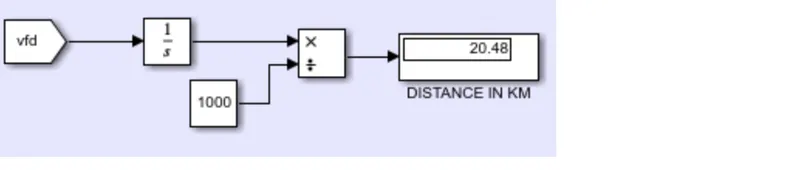
➡ The last result displays the distance travelled by the vehicle in kilometres.
➡ It is calculated by integrating the velocity feedback value and dividing it by 1000 to convert it into kilometres.
CONCLUSION :
➡ The Matlab model of an electric car which uses a battery and a DC motor has been successfully made by choosing suitable blocks from powertrain blockset and conclusions has been drawn from the results.
➡ From the input versus output velocity graph we can see that the electrical model that we design has traced the FTP 75 Drive cycle very closely.
➡ Only when the speed suddenly drops to 0 in the FTP 75 drive cycle, the model takes time to catch up. On all other locations the model trace the drive cycle closely.
➡ Looking at the SOC group we can see that almost 50% of the battery capacity is used for completing this drive cycle. And also we can see sudden spikes in that group the spikes are the regenerative braking region, During which the SOC value increases.
➡ And from the current variation graph we can see that the maximum current value during normal driving is around 300A enduring regenerative breaking the maximum current value reaches to150A. distance covered is20.48kms which Is higher than the drive cycle data. For FTP 75 the total distance is 17.77 km. But still the value is closer to that FTP 75 value showing that the model is quite accurate in following the drive cycle data.