Braking energy in EV and contour plot of motor speed, torque and efficiency values using MATLAB
Objective
> For a defined driving cycle, calculate the energy required for braking.
> Explain why electric motor can’t develop braking torque at high speed similar to starting
> Explain electric and mechanical brakes are coordinated
> A MATLAB program which plots contour of given motor speed, torque and efficiency values.
To calculate the braking energy required for a defined drive cycle.
At first the drive cycle is defined in an excel sheet and a plot is made. Using the plot, the values from the braking regions of the vehicle are taken. The plot of the drive cycle is given below.
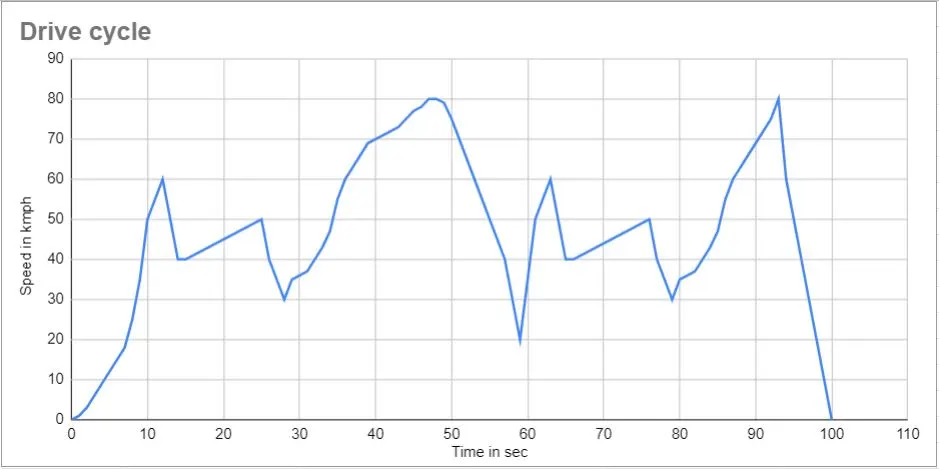
From the plot it is seen that, it consist of 6 braking regions. The initial and final values of the velocities are as given below.
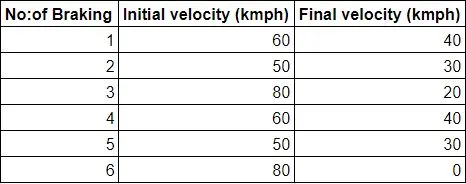
The above values are used to calculate the energy required using the formula
E = 0.5*m*(vi^2 - vf^2)
where, m = Mass of the vehicle in (Kg) = 1000 kgs
vi = Initial velocity of vehicle in (m/s)
vf = Final velocity of the vehicle in (m/s)
With the above values the deceleration values and total braking energy requiment of the vehicle are calculated using the excel calculator. The calculations are as given below given below.
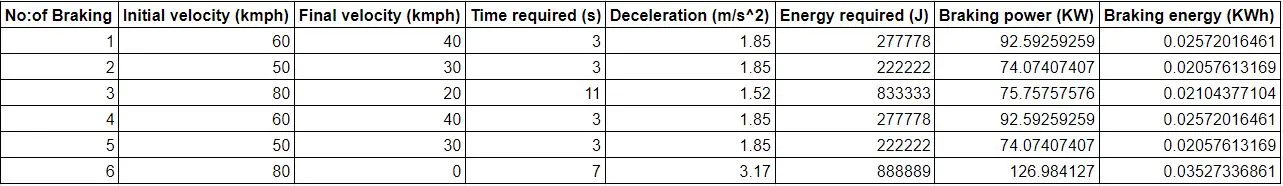
The total braking energy required = 0.148 KWh
Link to the excel sheet is given below:
(https://docs.google.com/spreadsheets/d/131ymoymhXR0awO7M9kxnflqpd5kqsVk0aoQ6sWm4-QA/edit?usp=sharing)
Electric motor can’t develop braking torque at high speed similar to starting
This situation occurs only when the vehicle is at high speeds because the motor will be running at the constant power region. In the constant power region the torque of the motor reduces and so the motor cannot develop the braking torque which is equal to the torque occured during low speed at the constant torque region.
The torque vs speed plot of a vector control induction motor is given below.
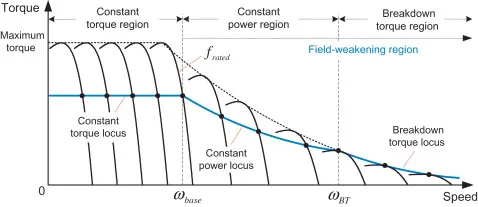
From the above characteristic curves of the motor it is seen that, the torque of the motor remains high at low speeds and reduces as the speed increases.
Therefore electric motor cannot develop braking torque at high speed similar to starting.
Electrical brake and mechanical brake.
Electrical braking
Electrical braking can be done by many methods such as,
> Unblancing the input phases of current to the motor.
> Using transistors in H-bridge configuration to reverse the motor direction in order to reduce speed.
> Implimenting regenerative braking system by using bi-directional power converters.
> Regenerative braking converts much of the energy to electrical energy, which may be stored for later use.
Mechanical braking
Mechanical brakes commonly use friction between two surfaces pressed together to convert the kinetic energy of the moving object into heat, though other methods of energy conversion may be employed. The friction between the surfaces are produced using pressurized air or pressurized oil which are commonly known as air brake and hydraulic brake respectively.
Coordination of electrical and mechanical braking in EV
Two types of brake control strategies are used to coordinate the electrical brake and mechanical brake they are,
> Series control strategy
> Parallel control strategy
The comparison of the control strategies are shown in the below figure.
In the figure it is seen that, according to the amount of brake pedal travel of the vehicle, the mechanical brakes and regenerative brake are applied.
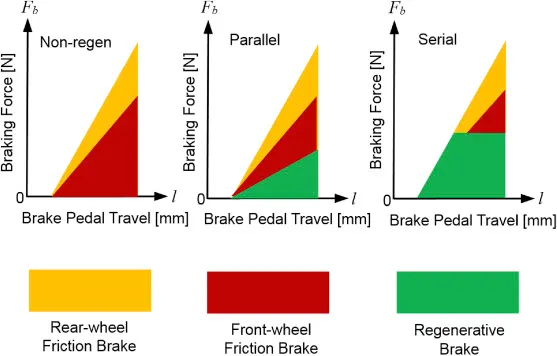
Parallel control strategy
When the brake is applied according to the brake pedal travel the front wheel friction brake, the rear wheel friction brakes and the regenerative brakes are applied simultameously. The higher the travel of the brake pedal the higher the amount of braking will be done.
The braking energy is distributed in the following manner,
Rear wheel friction brake > Front wheel friction brake > Regenerative brake
Series control strategy
When the brake is applied according to the brake pedal travel the front wheel friction brake, the rear wheel friction brakes and the regenerative brakes are applied one after another. As the braking requirement increases the frictional brakes are used accordingly.
For low speeds of the vehicle, regenerative braking is used but it may be limited according to the SOC (state of charge) of the battery.
As the speed of the vehicle increases the rear wheel frictional brake will be applied, if the braking requirement in not satisfied yet then the front wheel frictional brake is also used.
The coordination of the series control braking can be done with preference to comfort of braking (or) energy storage.
Electric driven intelligent brake (EDIB)
EDIB is a brake control strategy which is developed by NISSAN. It is a type of parralle braking which can be seen in the below image.
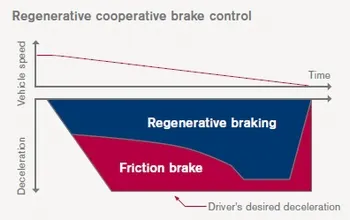
From the above image, it shows that the frictional brake and the regenerative brake are used simulatneously at higher speeds of the vehicle. At low speed the torque of the motor is high and so the regenerative brake have higher braking percentage than the frictional brakes.
Brief working of EDIB
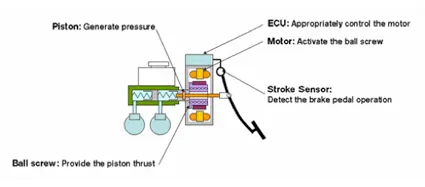
When the driver steps on the brake pedal, the stroke sensor detects operation of the brake. That information is communicated to the ECU and controls the motor. The motor engages the piston through ball screw and amplifies the friction brake's pressure (hydraulic pressure). Through optimum control of the friction brake's hydraulic pressure, the energy regeneration outcome is maximized.
MATLAB program which plots contour of given motor speed, torque and efficiency values
Inputs considered
Motor speed (W) = 1000 rad/s
Torque (T) = 250 m/s
Copper loss constant (Kc) = 0.2
Iron loss constant (Ki) = 0.008
Windage loss constant (Kw) = 0.00001
Constant loss = 20
Formule used
> Tl = CL+IL+WL+C
where, Tl = Total loss in motor
CL = Copper loss in motor
IL = Iron loss in motor
WL = Windage loss in motor
C = Constant loss of the motor
> CL = Kc*(T^2)
> IL = Ki*(W)
> WL = Kw*(W^3)
where, W = speed of the motor in rad/s
T = Torque of the motor in N-m
> Output power = W*T
> Input power = output power + Tl
> Efficiency = Output power/Input power
MATLAB code
clear all
close all
clc

% Speed and torque inputs
W = linspace(1,1000);
T = linspace(1,250);
[W,T]=meshgrid(W,T);

% Constants
Kc = 0.2;
Ki = 0.008;
Kw = 0.00001;
C = 20;

% Calculating losses in a motor
CL = Kc*(T.^2);
IL = Ki*(W);
WL = Kw*(W.^3);

% Total loss in the motor
Tl = CL+IL+WL+C;

% Power calculations
P_out = W.*T;
P_in = P_out+Tl;

% Efficiency
Z = P_out./P_in;
V = [0.70,0.75,0.80,0.85,0.90,0.91,0.92,0.93];

% Contour plot
contourf(W,T,Z,V)
colorbar
box off
grid off
title ('Contour plot motor speed, torque and efficiency values');
xlabel ('Speed in (rad/s)');
ylabel ('Torque in (N-m)');
Result of the MATLAB code
The pot obtained from the code is shown below
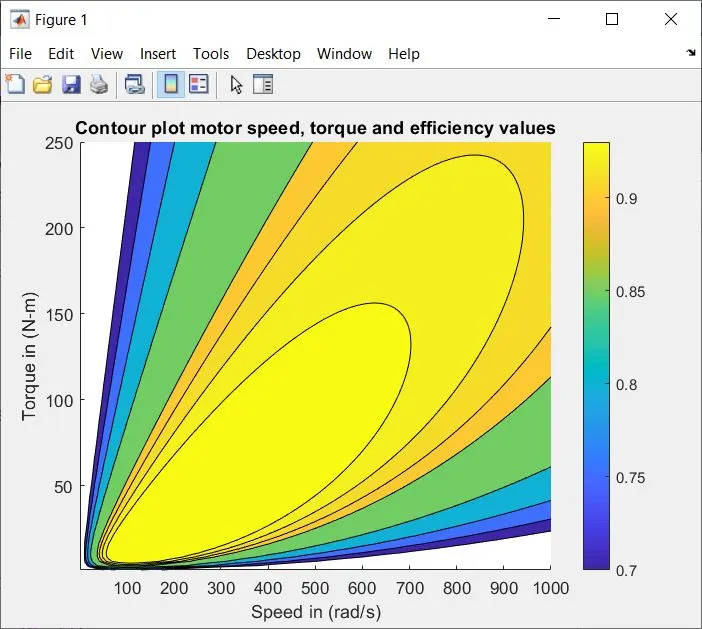
From the plot it is seen that, as the speed and torque of the motor changes the efficiency changes accordingly.
The efficiency of the motor with the considered losses is greater when, speed(W) is between [90-700]appx and torque(T) is between [10-150]appx.