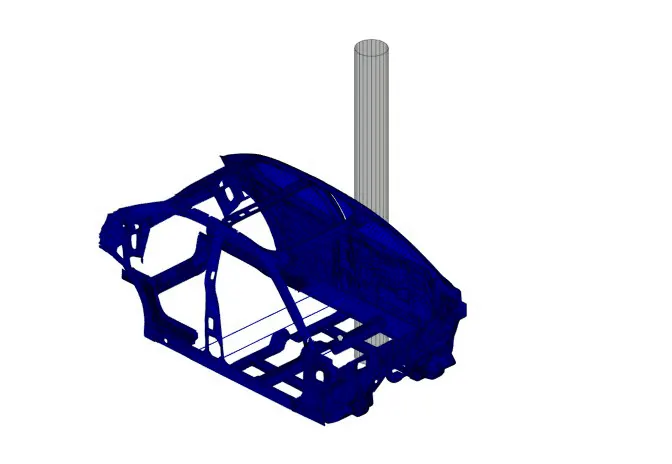
SIDE CRASH ANALYSIS OF NEON'S BIW USING HYPERCRASH AND RADIOSS
OBJECTIVE:
The main aim of this project is to perform a side crash of neon's BIW model using preprocessors like Hypermesh, Hypercrash, and Radioss solver.
PROCESS:
1. The consistent unit system in this project is Kg mm ms KN.
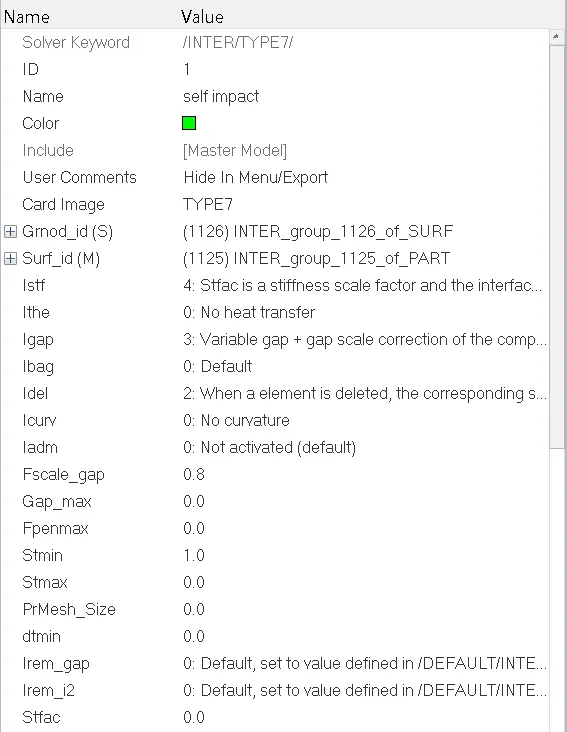
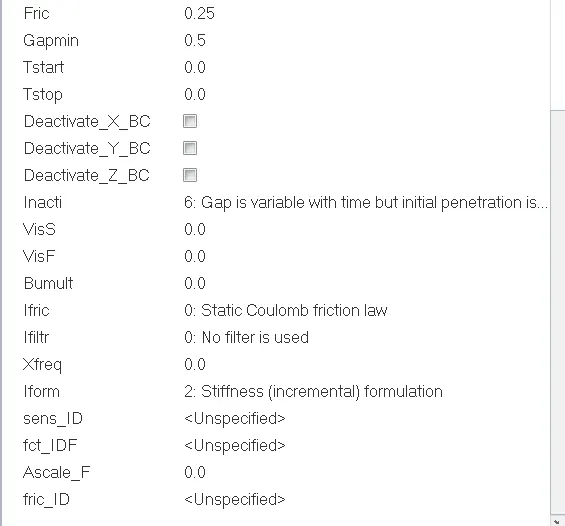
2. Created an appropriate contact interface type-7 self-impact with the recommended parameters on the model as shown below,
3. Checked for the penetrations and intersections in the model and cleared using the tools-->penetration checker option in Hypermesh.
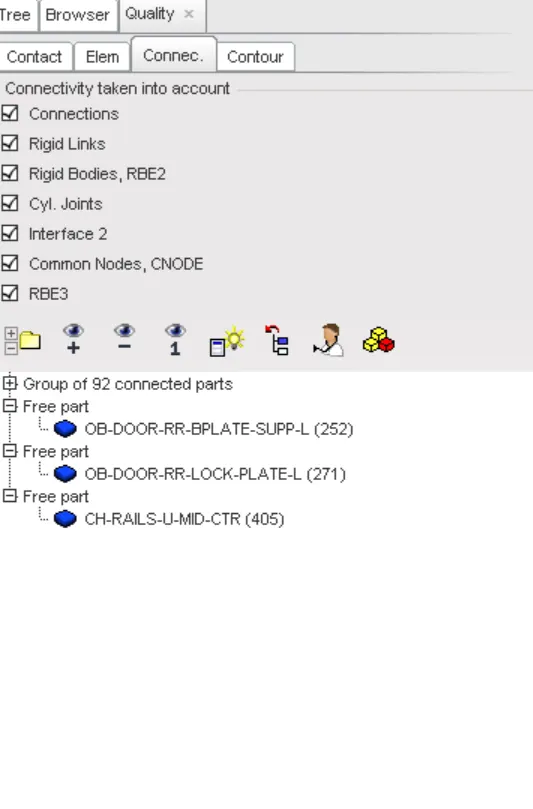
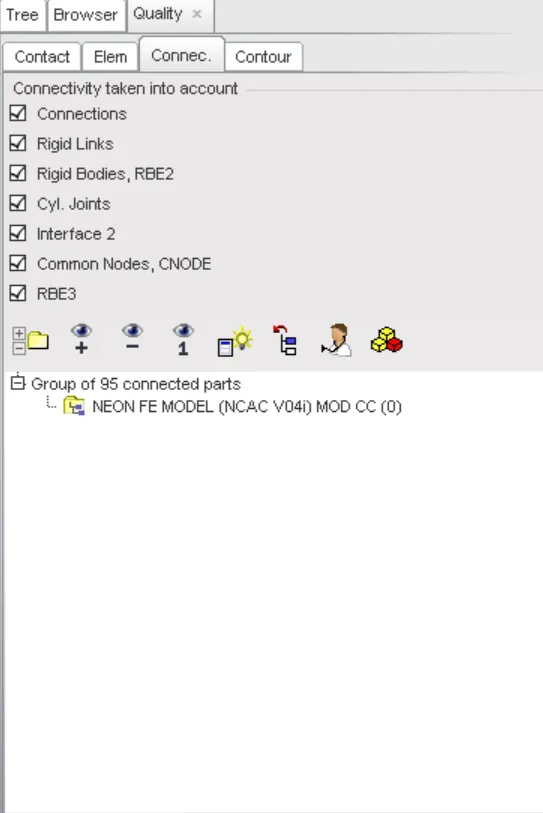
4. Checked for the presence of flying parts in the model using quality--> check the connectivity of tree selection option in Hypercrash as shown below and deleted the parts if any.
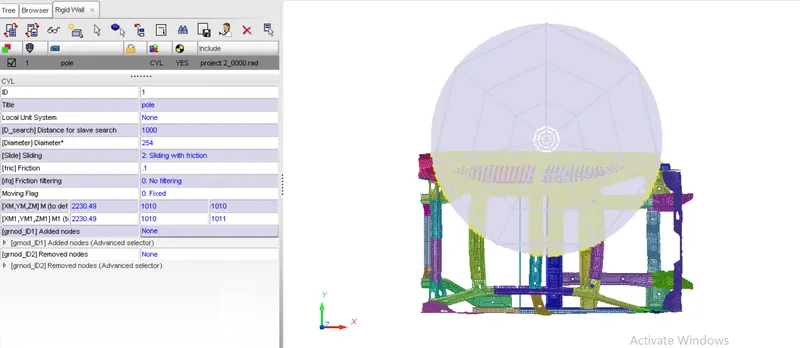
5. Created an infinite cylinder rigid wall in Hypercrash using Load case-->rigidwall option with a diameter of 254mm and search distance of 1000mm as shown below,
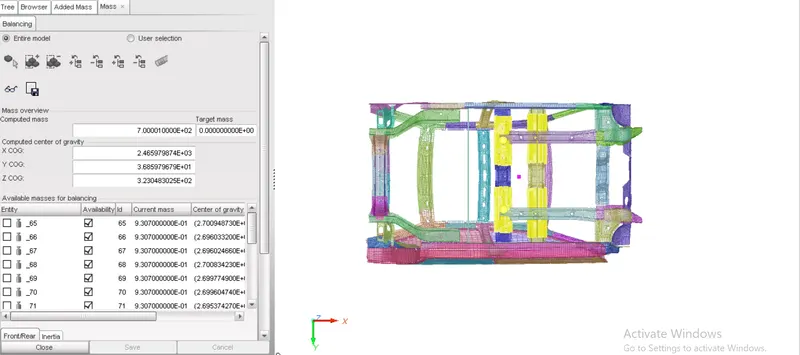
6. Added some mass to the cross members to reach 700kg while getting the center of gravity approximately below the driver seat, so the vehicle does not yaw or move forward when hitting the pole, using options like load case-->added mass and mass--> balancing in Hypercrash.
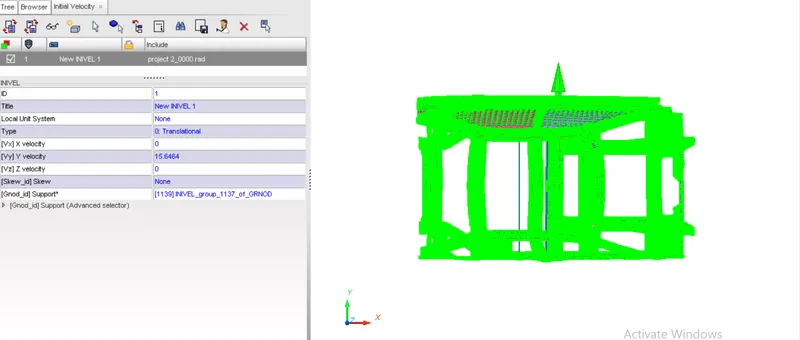
7. Applied translational initial velocity of 35 mph(15.6464 m/s) to the whole model in the positive Y direction using load case--> initial velocity in Hypercrash.
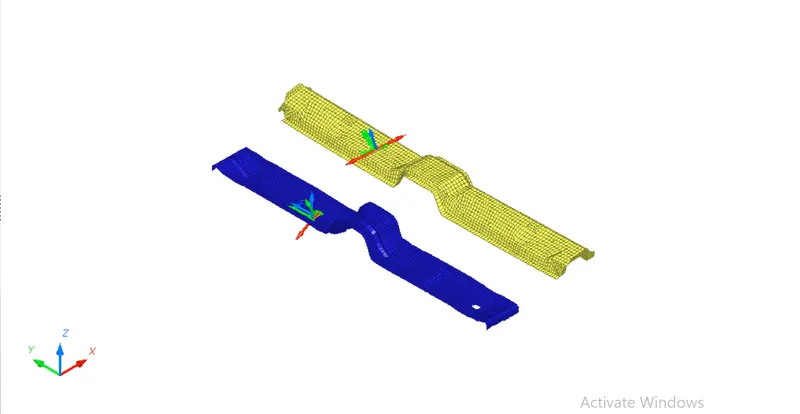
8. Created some cross-sections in the cross members using the local coordinate systems (i,.e frames), so that the sectional forces can be calculated at the part level.
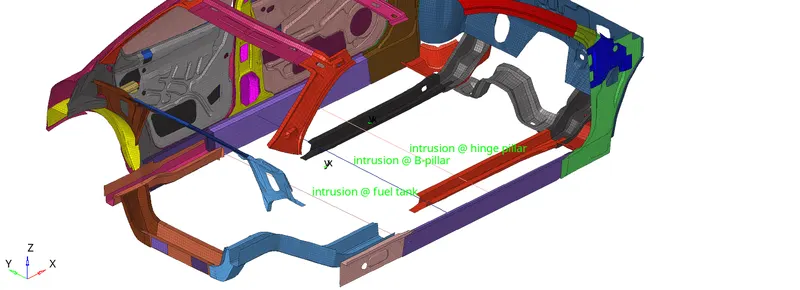
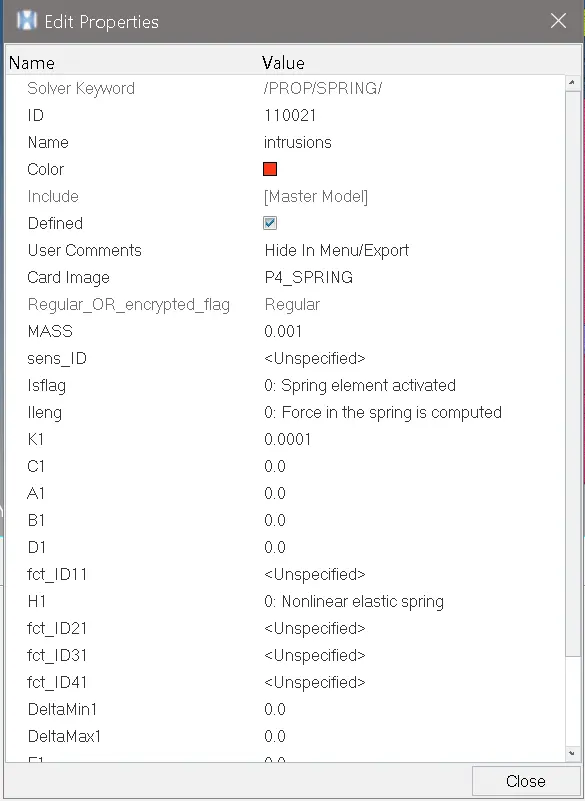
10. To calculate the hinge pillar, B-pillar and fuel tank region intrusions, created three springs of mass 0.001 kg and stiffness of 0.0001 KN/mm as shown below,
11. The velocity experienced by the driver during the impact can be measured by calculating the velocity of an inner node of the front door inner panel. To calculate the velocity a moving skew is created by using solver-->create-->skew--> move at the node, then time-history for the node is requested /TH/nodes to get the results.
12. Output requests such as time history for cross-sections, rigid wall, node, interface are created so that their results can be plotted in the Hypergraph.
13. control cards for the model.
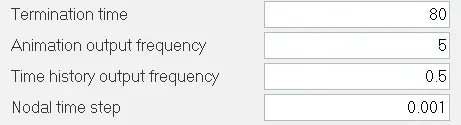
14. finally, checked for any errors in the model using quality-->model checker in Hypercrash and also tools-->model checker in Hypermesh and rectified them by using autocorrect option and some are rectified manually.
OUTPUT:
1. Sectional force in cross-member 1 (viewing from the front).
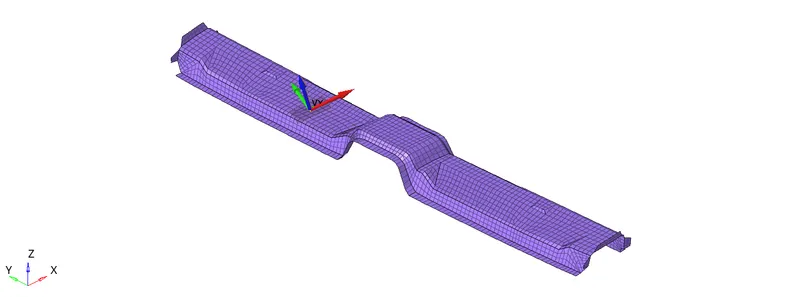
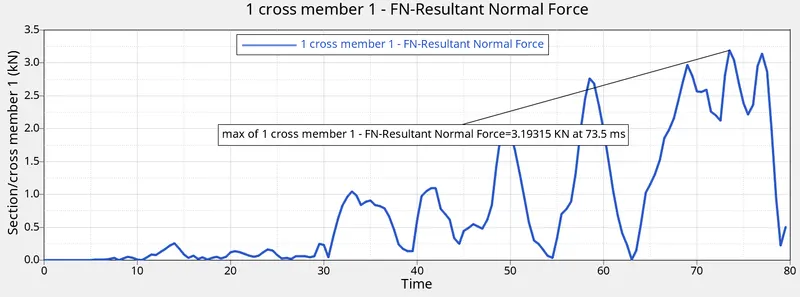
The maximum sectional force in cross-member 1 is 3.19315 KN at 73.5 ms.
2. Sectional force in cross-member 2.
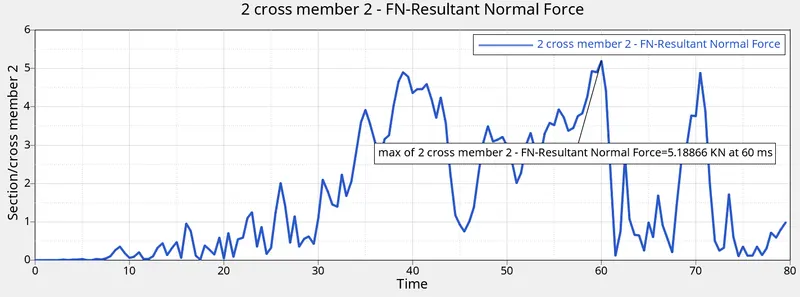
The maximum sectional force in cross-member 2 is 5.18866 KN at 60 ms.
when comparing the two sectional forces, the force in cross-member 2 reaches its maximum value at 60 ms but the cross-member 1 force reaches its maximum at 73.5 ms, it seems that cross-member 1 is stiffer than cross-member 2.
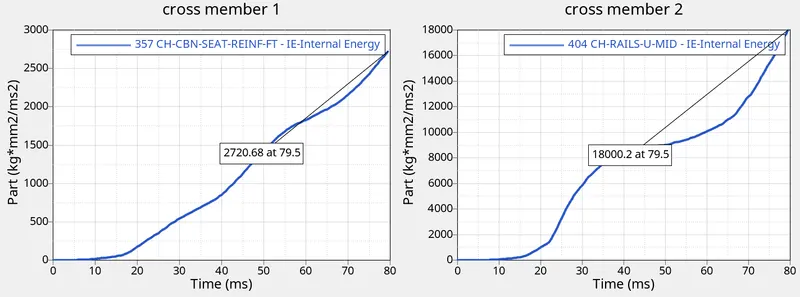
whenever a component deforms some energy(internal or strain energy) is absorbed in it, if the deformation is high the internal energy which is absorbed is also high.so, The internal energy stored by cross-member 1 is minimum that the I.E in cross-member 2.so, cross-member 2 is less stiff than cross-member 1.
3. Intrusion in the Hinge pillar region.
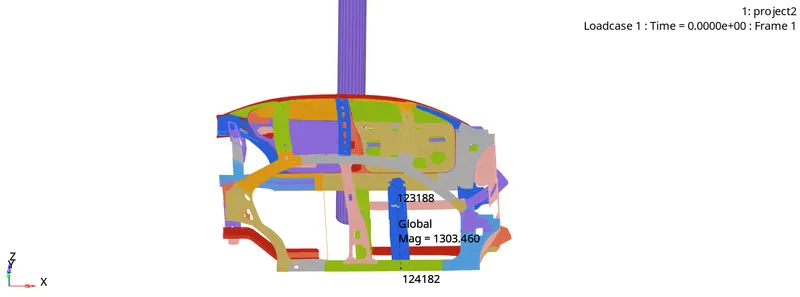
the distance of the spring between the nodes 123188 and 124182 before impact is 1303.460 mm
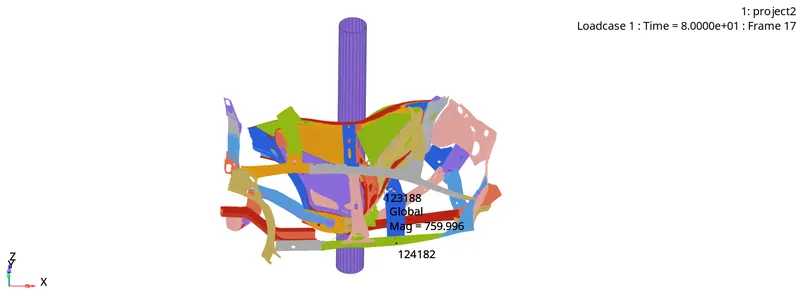
the distance of the spring between the nodes 123188 and 124182 after impact is 759.996 mm
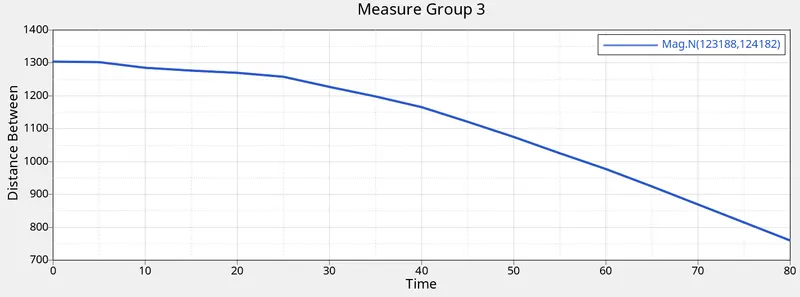
so, the intrusion between the nodes 123188 and 124182 is 543.464 mm.
4. Intrusion in the B-pillar region.
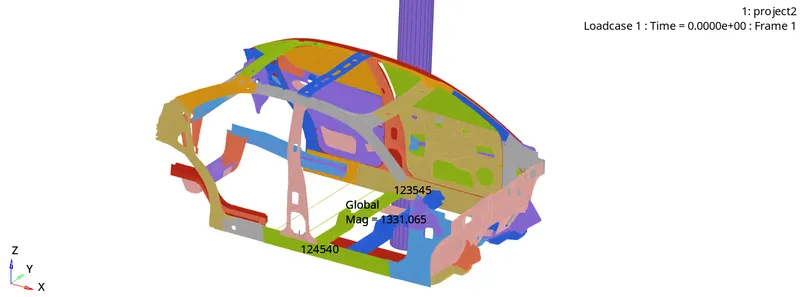
the distance of the spring between the nodes 123545 and 124540 before impact is 1331.065 mm
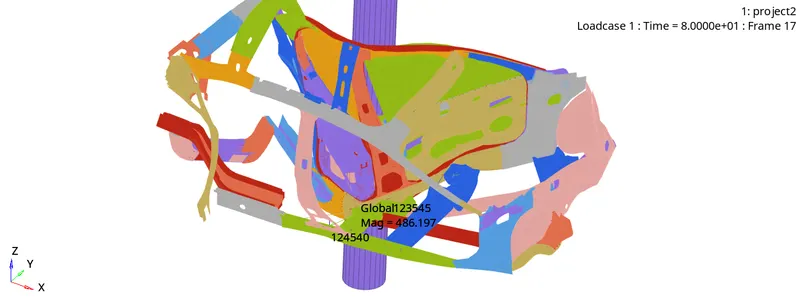
the distance of the spring between the nodes 123545 and 124540 after impact is 486.197 mm
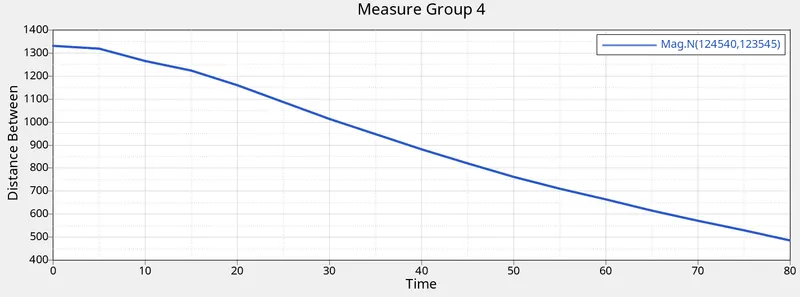
so, the intrusion between the nodes 123545 and 124540 is 844.868 mm.
5. Intrusion in the fuel tank region.
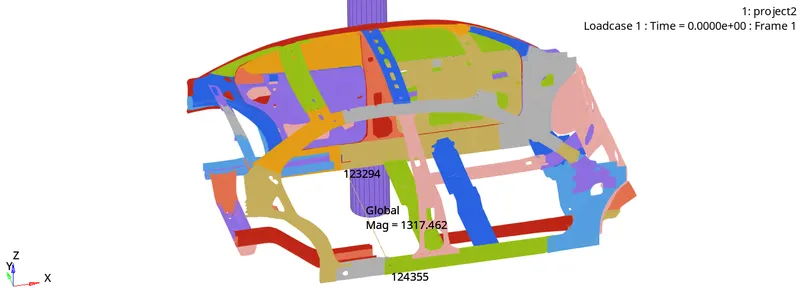
the distance of the spring between the nodes 123294 and 124355 before impact is 1317.462 mm
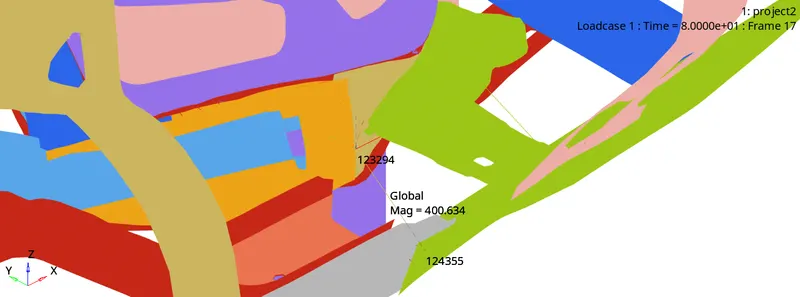
the distance of the spring between the nodes 123294 and 124355 after impact is 400.634 mm
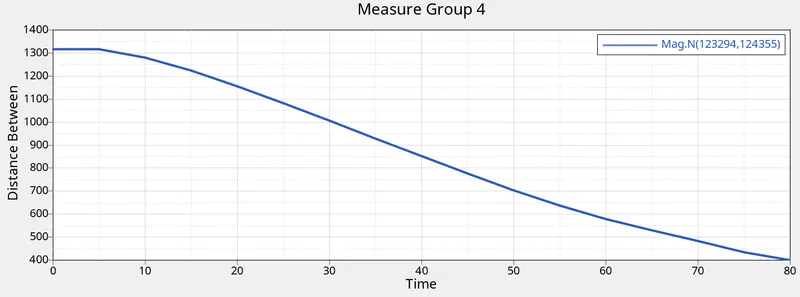
the intrusion between the nodes 123294 and 124355 is 916.828 mm
countermeasure:
- So, from the above results, the intrusion in the fuel tank region is high when compared with B-pillar and hinge pillar intrusions. This can be reduced by using the side impact bars as shown below,
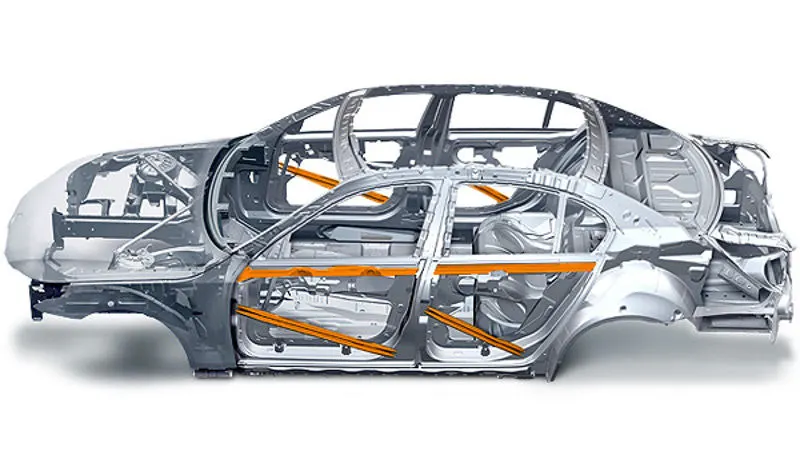
- The role of an anti-intrusion bar/side-impact bar is to absorb the kinetic energy of colliding vehicles that is partially converted into internal work of the members involved in the crash.
- The forces that occur in the event of a crash can therefore be better absorbed into the floor and the roof.
- Also, the usage of another cross member near the fuel tank region may reduce the intrusion.
6. Peak velocity of the inner node of the front door.
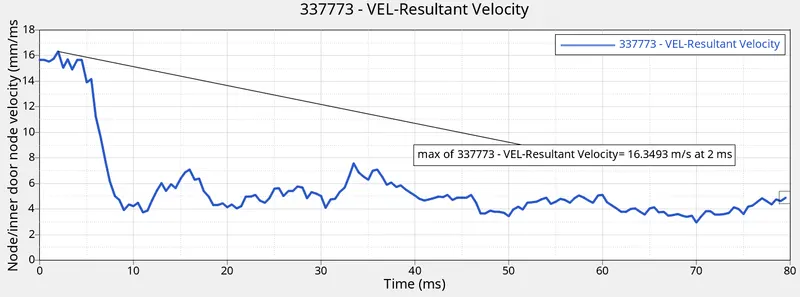
the maximum velocity at node 337773 is 16.3493 m/s at 2 ms
so, the peak velocity of the inner node of the front door
countermeasure:
- Side impacts are particularly dangerous because the location of impact is very close to the passenger, who can be immediately reached by the impacting pole or vehicle.
- Here, the peak velocity calculated at the inner node is the velocity experienced by the occupant in the front seat approximately.
- This can be reduced by using the Side-impact bars as mentioned above.
- Side impact bars increase the rigidity of the doors and distribute the energy in the event of a side-on crash.
ANIMATION OUTPUT:
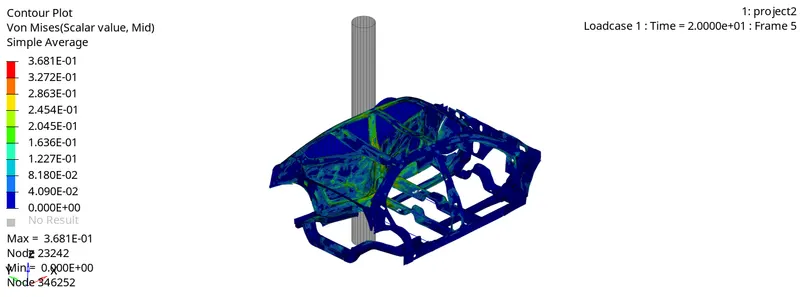
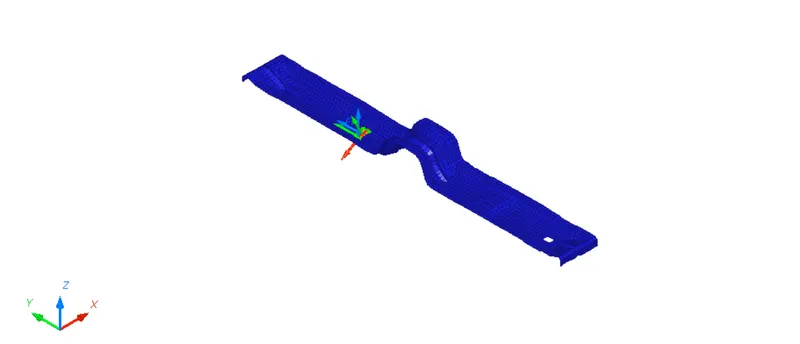
the maximum von-mises stress 0.3681 KN/mm occurs at node 23242 which is at the bottom of the B-pillar.
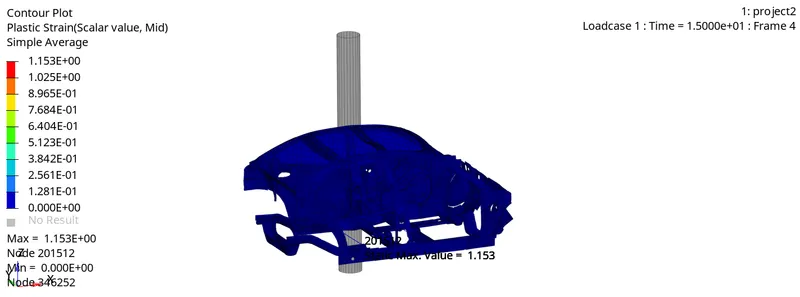
the maximum plastic strain 1.153 occurs at node 201512 which is at the cross-member 2.
ENERGY BALANCE:
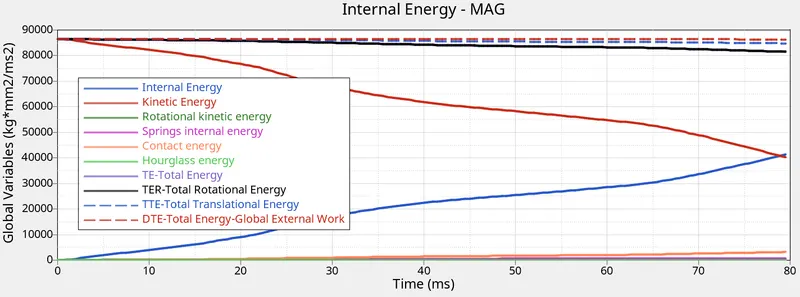
1. In the crash analysis, the ultimate target is energy absorption. when the BIW hits the rigid wall with the velocity of 35 mph, the kinetic energy starts with the maximum value and gradually decreasing as the velocity decreases. At the same time, The internal energy increases gradually as the deformation of the components increases. From the graph, it is obvious that all the kinetic energy gets transferred to internal energy.
2. The total translation energy is slightly decreasing due to loss of energy it ranges from 86482.8 J to 84797.5 J
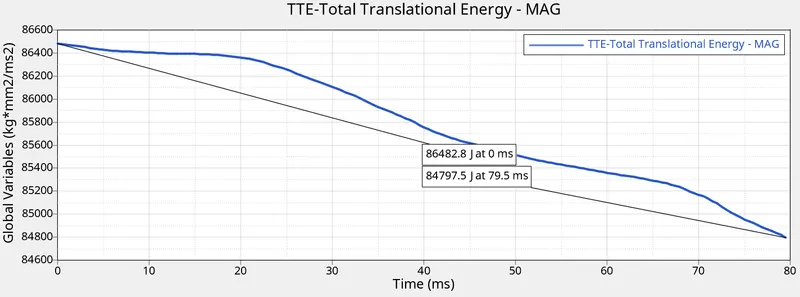
3. The equation TTE=IE+KE+RKE+CE+HE, is satisfied as the calculation shown below,
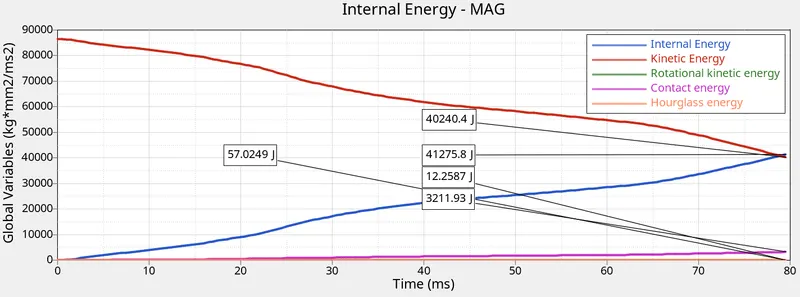
Energies are calculated at the end of the simulation,
TTE (TOTAL TRANSLATION ENERGY) = 84797.5 J
I.E (INTERNAL ENERGY) =41275.8 J
K.E (KINETIC ENERGY) = 40240.4 J
R.K.E (ROTATIONAL KINETIC ENERGY) = 12.2587 J
C.E (CONTACT ENERGY) = 3211.93 J
H.E (HOURGLASS ENERGY) = 57.0249 J
So, 41275.8+40240.4+12.2587 +3211.93 +57.0249 = 84797.4136 J
4. Also the condition, Hourglass energy + contact energy < 15% of total energy (IE+KE), is also satisfied as shown below,
57.0249+3211.93 = 3268.9549 < (15% * 41275.8 +40240.4 ) = 12227.43 J.
5. The energy error ranges from -0.0% to -4.0 % is acceptable.
TIMESTEP:
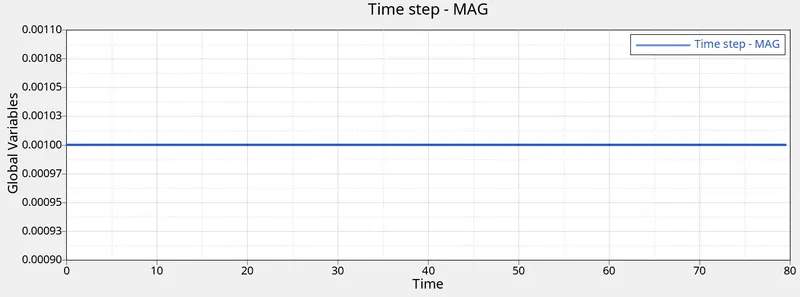
Here the timestep remains constant up to the end of the simulation.
MASS BALANCE:
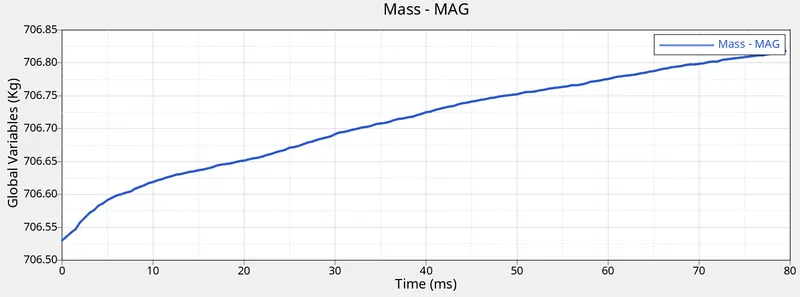
1. Here the addition of mass increases gradually due to the usage of CST, in order to maintain the timestep not decreasing less than the minimum value specified in the nodal and brick timestep formulation block.
2. the mass error ranges from 0.9327 % to 0.9741 %, is below the recommended value i.e, 1% to 3%.
3. the number of cycles is 79900.
RESULT:
Hence, the side crash of neon's BIW model is performed using the preprocessors such as Hypermesh, Hypercrash, and Radioss solver.