SIMULATION OF A FRONTAL CRUSH OF A DODGE NEON BIW USING RADIOSS AND HYPERCRUSH
TITLE : SIMULATION OF A FRONTAL CRUSH OF A DODGE NEON BIW
AIM : Simulate the frontal crush of the dodge neon on a rigid wall and to post proccess the forces generated or transfer through specific cross-sectional areas of the car using Hypermesh (Radioss) and Hypercrush.
INTRODUCTION
A crash test is a form of destructive testing usually performed in order to ensure safe design standards in crashworthiness and crash compatibility for various modes of transportation (see automobile safety) or related systems and components.
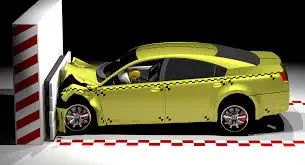
- Frontal-impact tests: which is what most people initially think of when asked about a crash test. Vehicles usually impact a solid concrete wall at a specified speed, but these can also be vehicle impacting vehicle tests. SUVs have been singled out in these tests for a while, due to the high ride-height that they often have.
- Moderate Overlap tests: in which only part of the front of the car impacts with a barrier (vehicle). These are important, as impact forces (approximately) remain the same as with a frontal impact test, but a smaller fraction of the car is required to absorb all of the force. These tests are often realized by cars turning into oncoming traffic. This type of testing is done by the U.S.A. Insurance Institute for Highway Safety (IIHS), EuroNCAP, Australasian New Car Assessment Program (ANCAP) and ASEAN NCAP.
Small Overlap tests: this is where only a small portion of the car's structure strikes an object such as a pole or a tree, or if a car were to clip another car. This is the most demanding test because it loads the most force onto the structure of the car at any given speed. These are usually conducted at 15-20% of the front vehicle structure.
- Side-impact tests: these forms of accidents have a very significant likelihood of fatality, as cars do not have a significant crumple zone to absorb the impact forces before an occupant is injured.
- Pole-impact tests: A difficult test which places a large amount of force on a small proportion on the side of the vehicle.
Roll-over tests: which tests a car's ability (specifically the pillars holding the roof) to support itself in a dynamic impact. More recently, dynamic rollover tests have been proposed in lieu of static crush testing (video).[1]
Roadside hardware crash tests: are used to ensure crash barriers and crash cushions will protect vehicle occupants from roadside hazards, and also to ensure that guard rails, sign posts, light poles and similar appurtenances do not pose an undue hazard to vehicle occupants.
- Old versus new: Often an old and big car against a small and new car,[2][3] or two different generations of the same car model. These tests are performed to show the advancements in crash-worthiness.[citation needed]
Computer model: Because of the cost of full-scale crash tests, engineers often run many simulated crash tests using computer models to refine their vehicle or barrier designs before conducting live tests.
- Sled testing: A cost-effective way of testing components such as airbags and seat belts is conducting sled crash testing. The two most common types of sled systems are reverse-firing sleds which are fired from a standstill, and decelerating sleds which are accelerated from a starting point and stopped in the crash area with a hydraulic ram. It can also be used to evaluate the whiplash protection of a vehicle's seat.
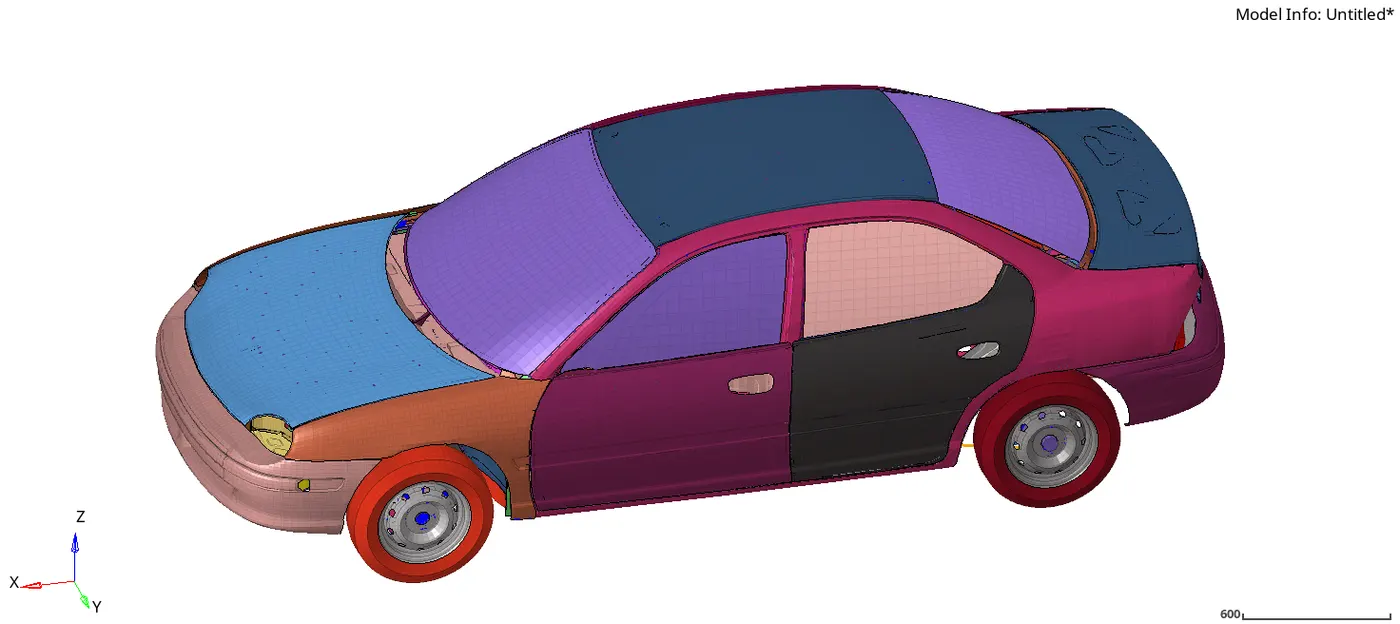
Full car model
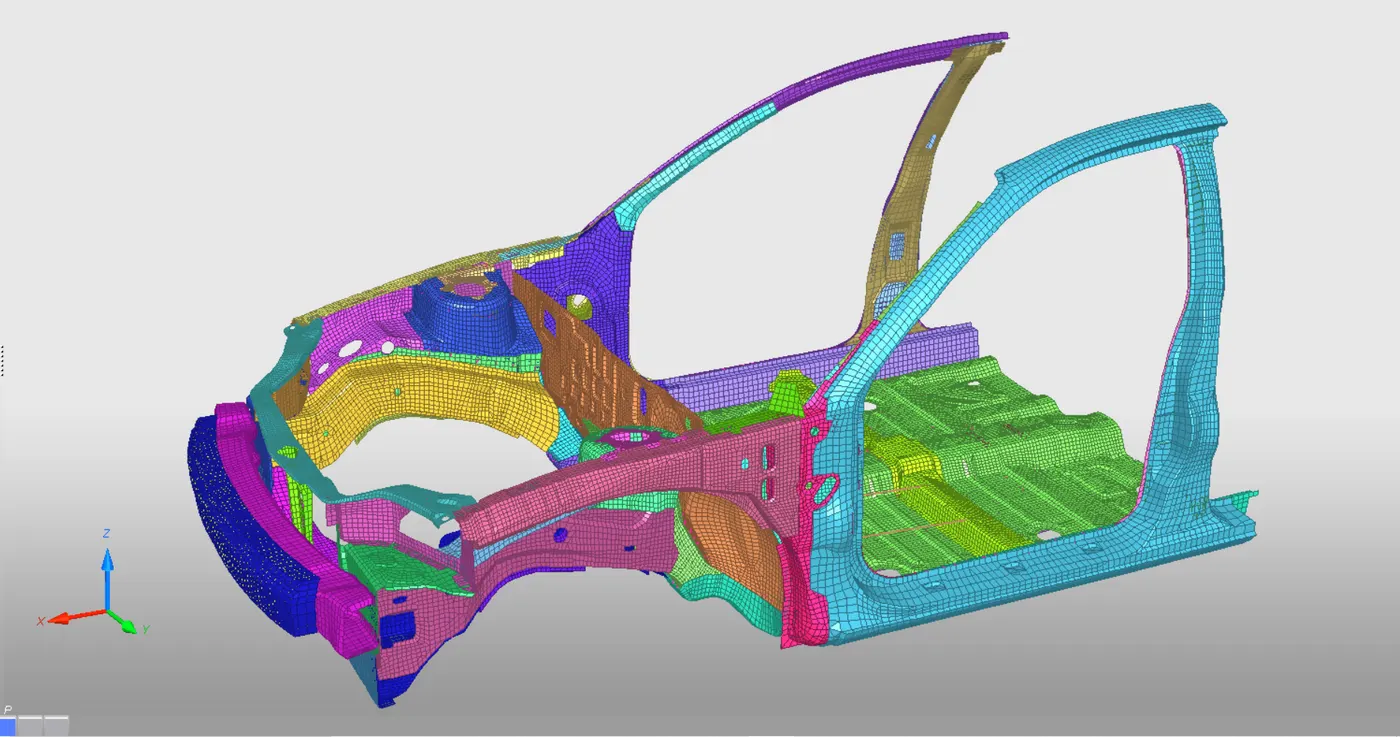
Reduced Frontal car
UNIT SYSTEM
The unit system which was used in this model was kg ms mm
PROCEDURE
- Create an a contact interface to model how the parts interact when they come into contact with each other
- Check for element penetrations
- Check for connectivity of all parts
- Creation of rigid wall
- Mass Balancing
- Applying initial velocity
- Creation of cross-section for force analysis
- Creating time history output request
- Creation of animation output request
- Using an accelerometer
- Applying custom time step
- Model Check Quality
- Post processing results of animation (Plastic strain , displacement, Vonmises stress)
- Time step, enegy error and mass error debugging
- Plotting time history data of sectional forces, accelerometer , specific energy and Intrusion displacement
- Conclusion
CONTACT INTERFACE
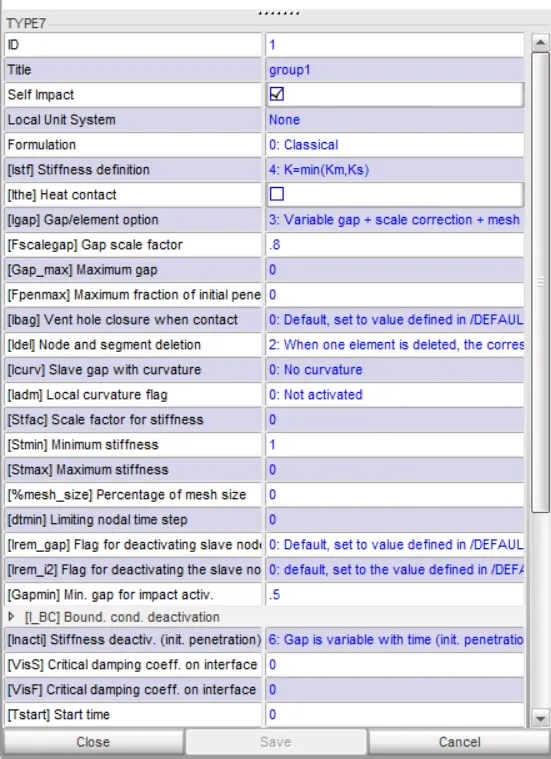
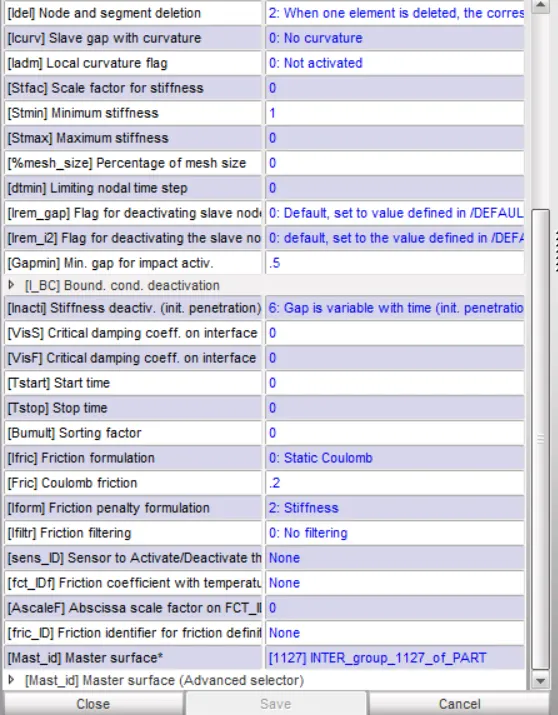
A self contact is created for the car using the Type 7. All parts are selected as its a self contact interface interaction Properties used can be seen below.
PENETRATION AND CONNECTIVITY CHECK
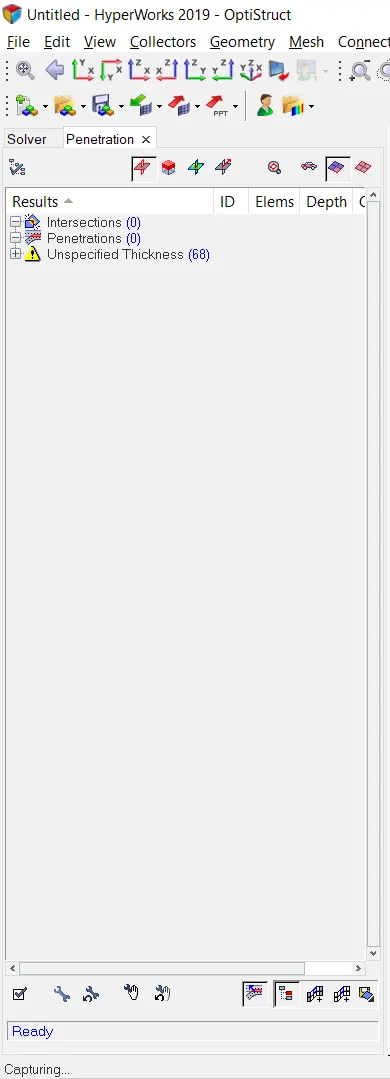
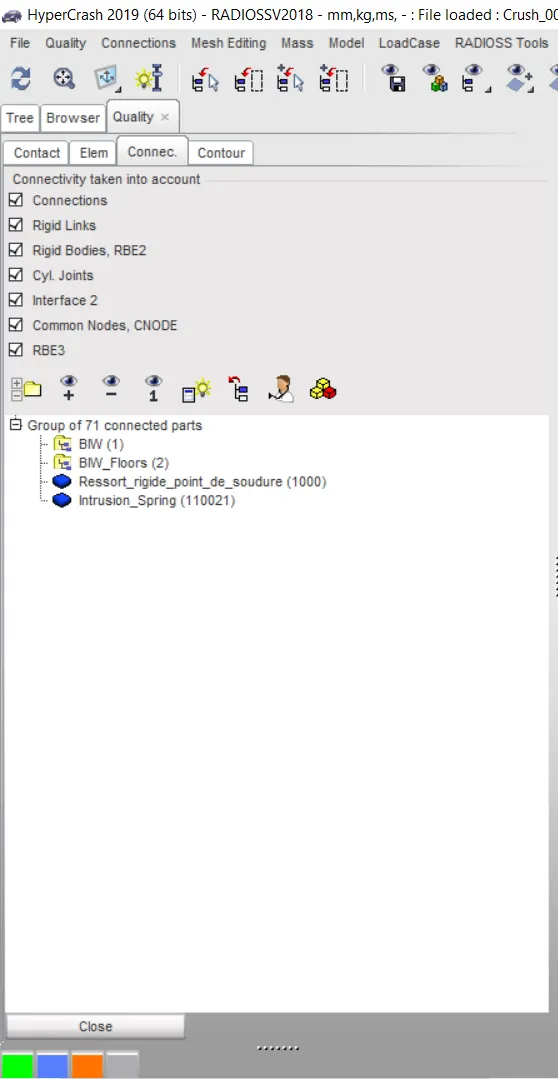
it is very important to check for element which have penetrated into the gap because this can affect the simulations results and drops to negative. The simulation becomes unstable. Below is an image of the penetration check in hypercrush. As it can be seen there where no penetration found in the model.Also checked below is the connectivity of all parts and ther was no unconnected parts
RIGID WALL CREATION
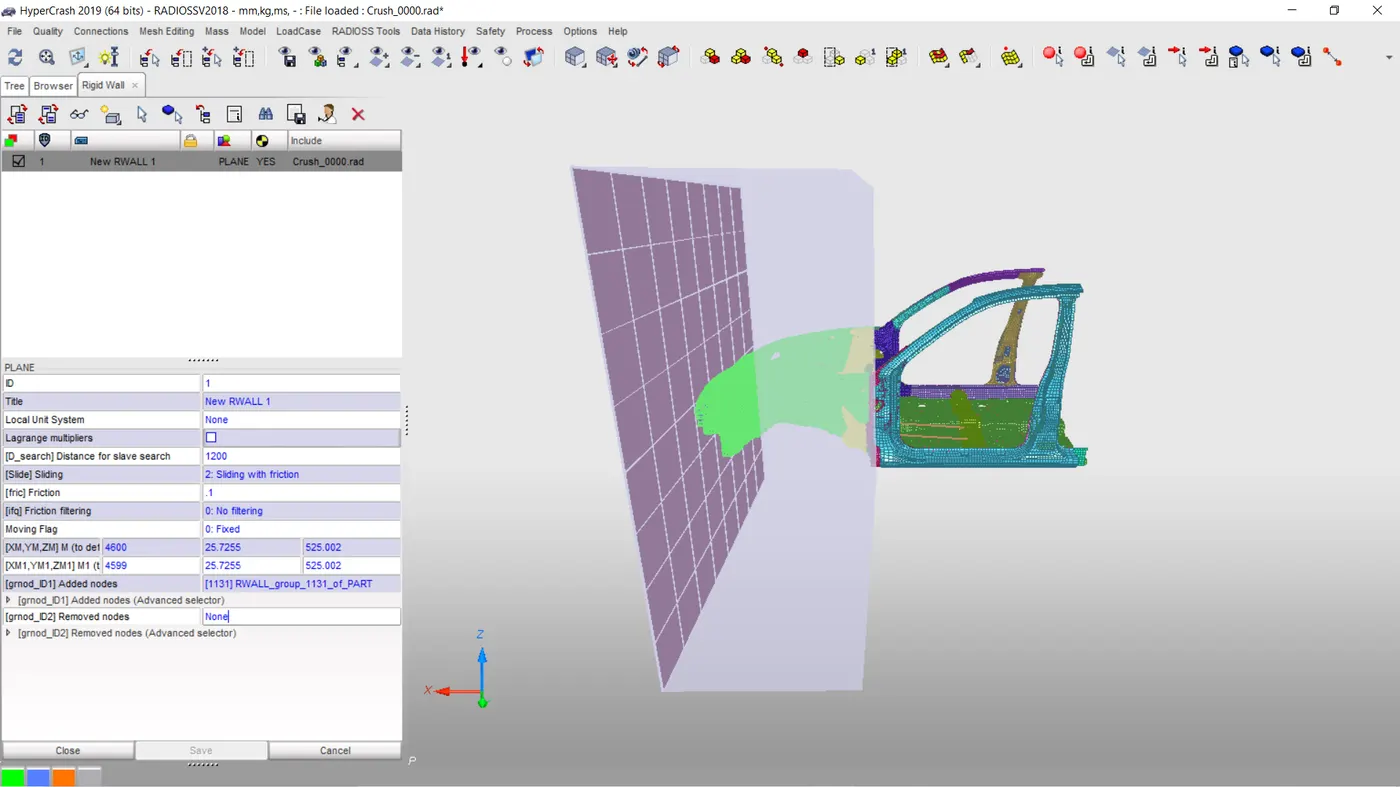
Rigid wall is a body with very high stiffness and is made to be static and to receive the frontl crush of the dodge. The cordinates of the rigid wall is defined first by picking a node on the bumper to specify the tail cordinates. The head cordinates is created by copying that of the tail and only giving a little gap to the normal direction. This gap is defined as small as possible in order to reduce CPU computing time during simulation.The search distance of possible slave nodes that could hit the rigis wall is be selected together with a search tolerance. 0.1 sliding frequency is selected for the wall.
MASS BALANCING
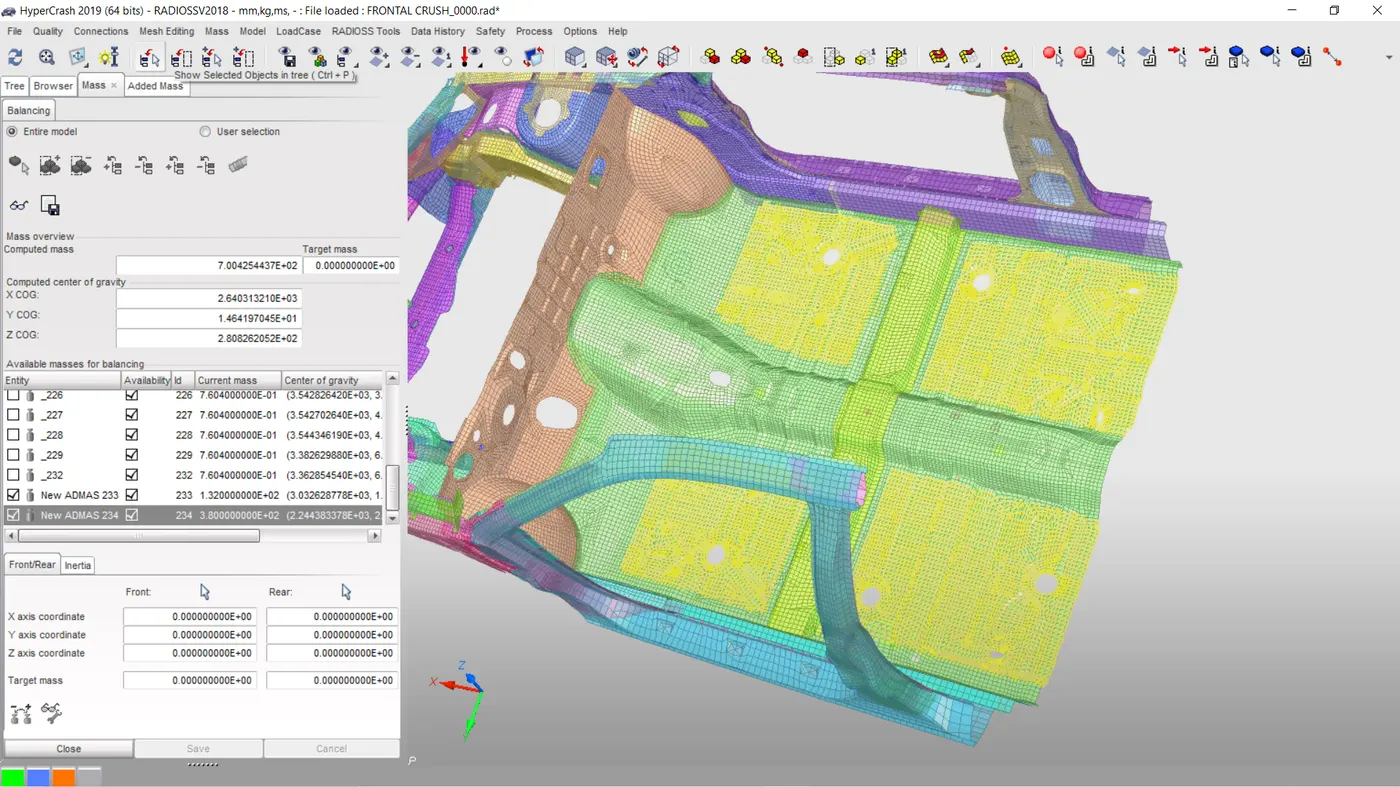
iT IS IMPORTANT TO CONTROL THE DISTRIBUTION OF MASS IN THE MODEL TO REFLECT THE ACTUAL POSITION OF THE C.O.G OF THE FULL MODEL OF THE CAR. The full model of the car has its centre of gravity somewhere closer to the front drivers seat. Masses are added at the front and back seats to push the COG to the middle part of the car.This masses must also be added to reach a desired weight of 700kg. The current weight before balancing was 187kg. 132kg was added too the frobt seats and 380kg is added to the back seats. The centre of gravity can be seen in place as a dot in the car model below.
INITIAL VELOCITY
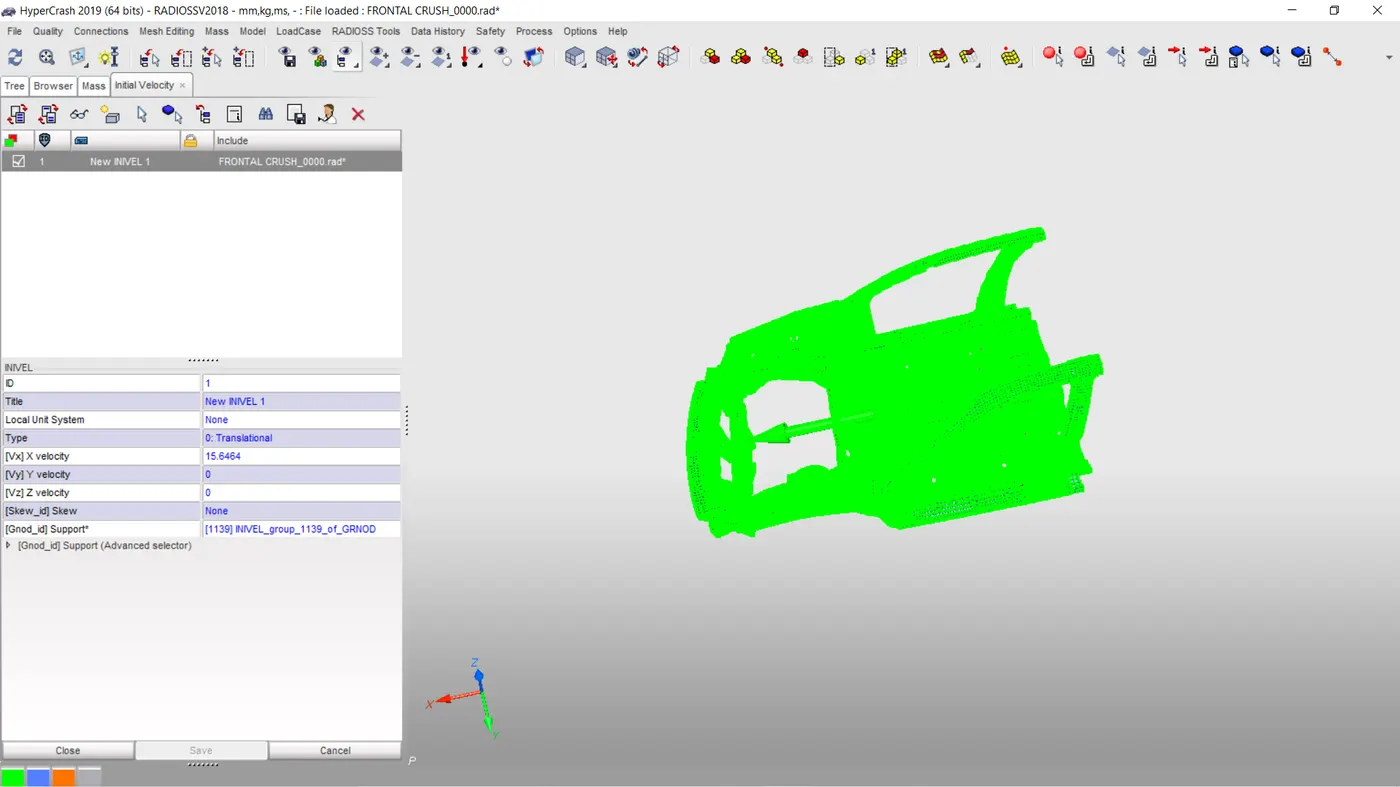
Intial velocity kinematic condition of 35mph is added to propel the model horixontally in the x direction to the rigid wall to simulate the crush , with a friction of 0.1
CREATION OF CROSS-SECTION
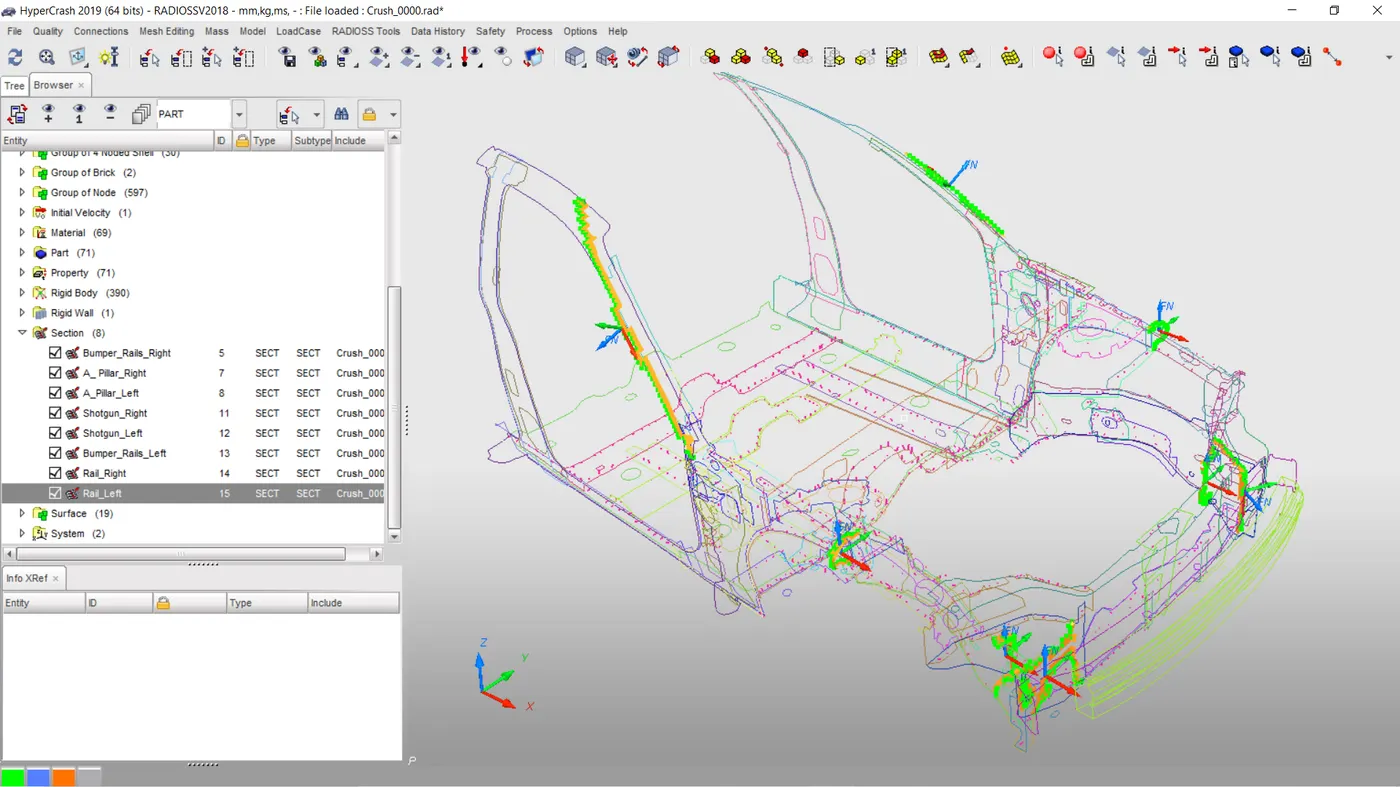
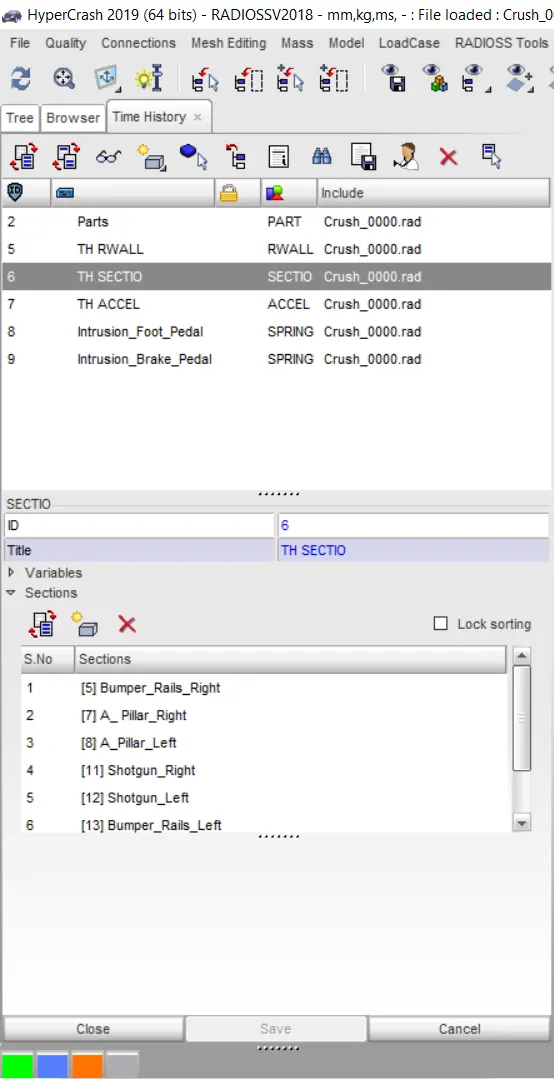
Cross-sections are created for specific parts in order to study the force distribution in these parts. Parts are listed below
- A pillar right and left
- Shotgun right and left
- Bumper rail right and left
- Rails right and left
TIME STEP
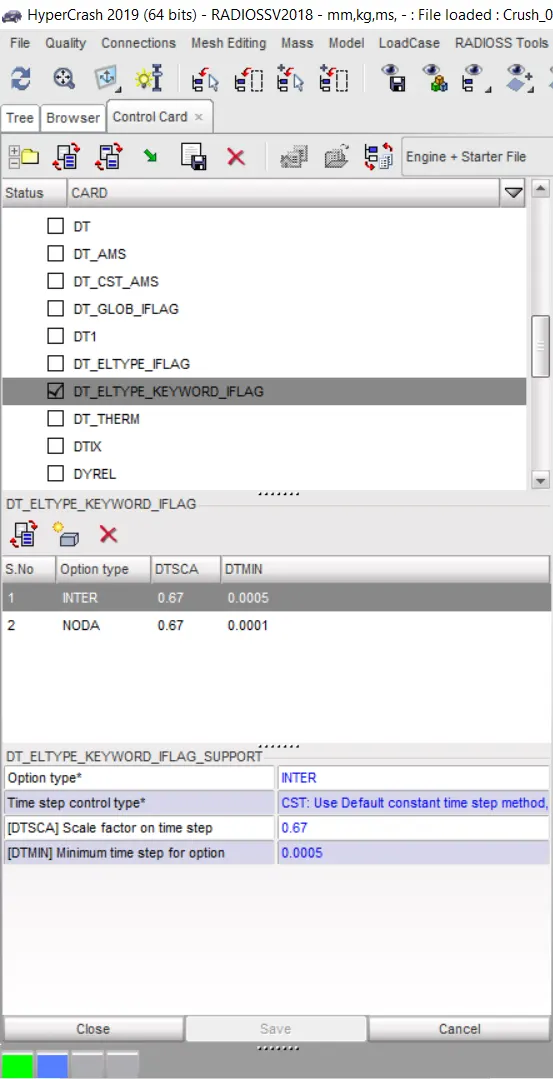
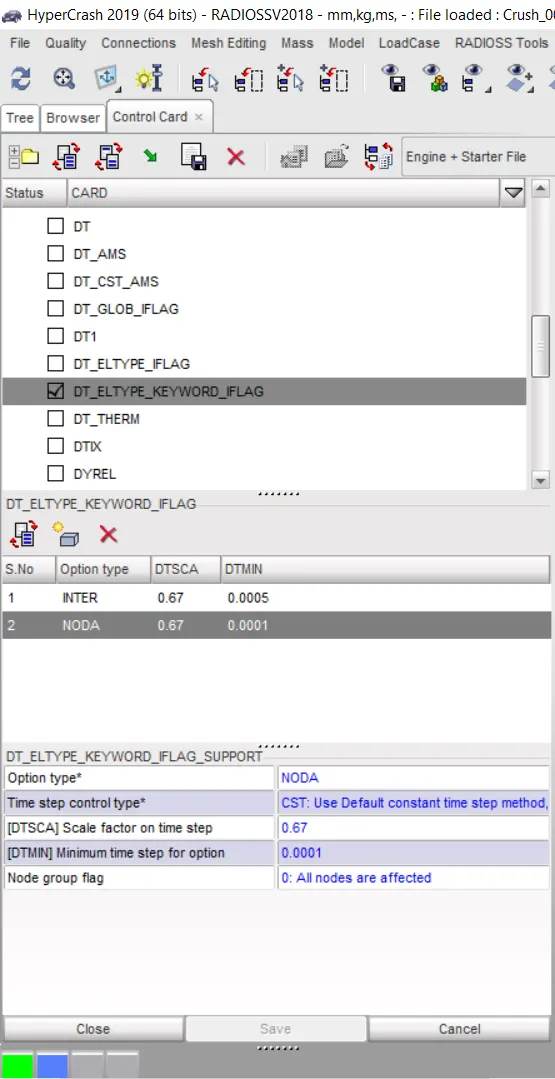
Custom time step is specified with the following parameter
- Constant element timestep is used with cst turned on to switch to small strain when large element deformation happens.
- A factor of 0.67 is specified NODA /CST with INTER/CST factor 0.67 and time step o.ooo1
- Addition of mass to elements which produces low timestep
- Simulation time of 80ms
- Time step of 0.0005ms
CREATING TH OUTPUT REQUEST
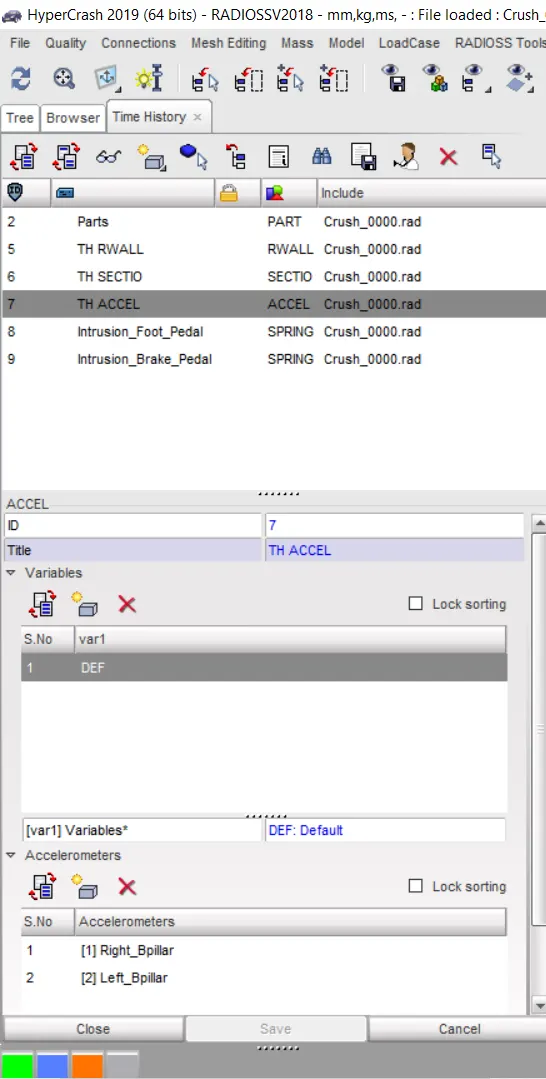
In order to post proccese the results of the simulation , the required data must be rquested. It can be seen below the requested uotput file ad the variables selcted is left at default (DEF). All the sections are requested together with an accelerometer, springs and rigid wall (was created automatically). AN OUTPUT IS REQUESTED FOR TWO SPRINGS WHICH ARE CREATED AT THE FOOT AND BRAKE PEDAL IN ORDER TO DETERMINE THE INTRUSIONS DEVELOPED DURING THE CRUSH.
CREATION OF ANIMATION OUTPUT REQUEST
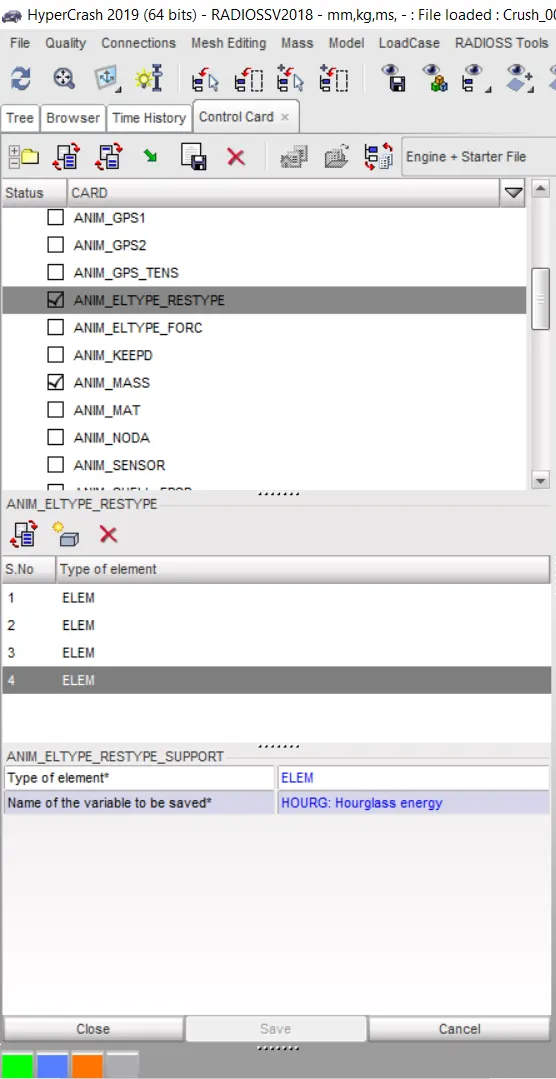
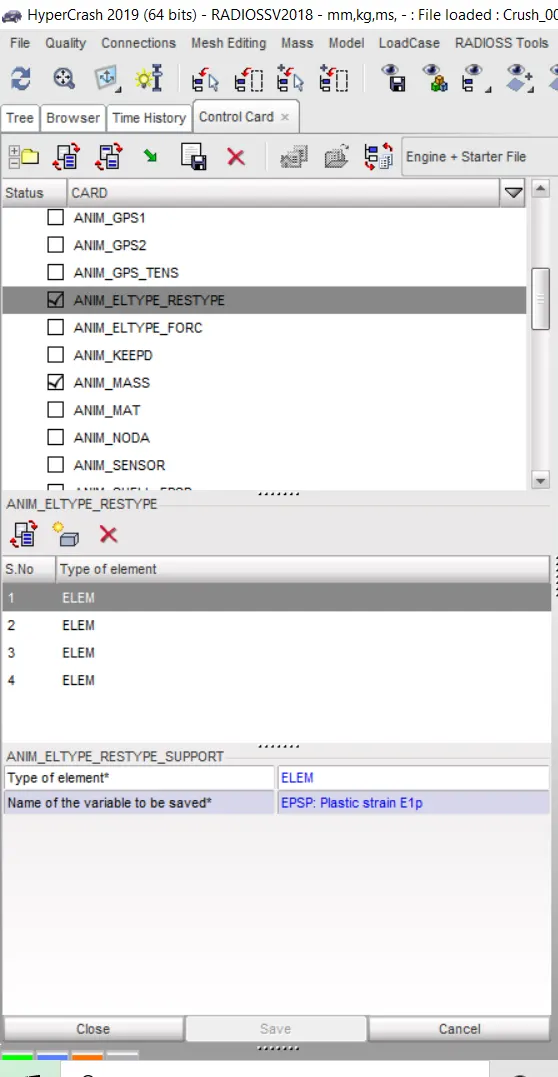
In order to post proccese the results of the simulation , the required data must be rquested. The animation of vonmisses ,hourglass and specific energy, Time step and Mass variation is request by creating with ANIM_ELTYPE_RESTYPE.
ACCELEROMETER
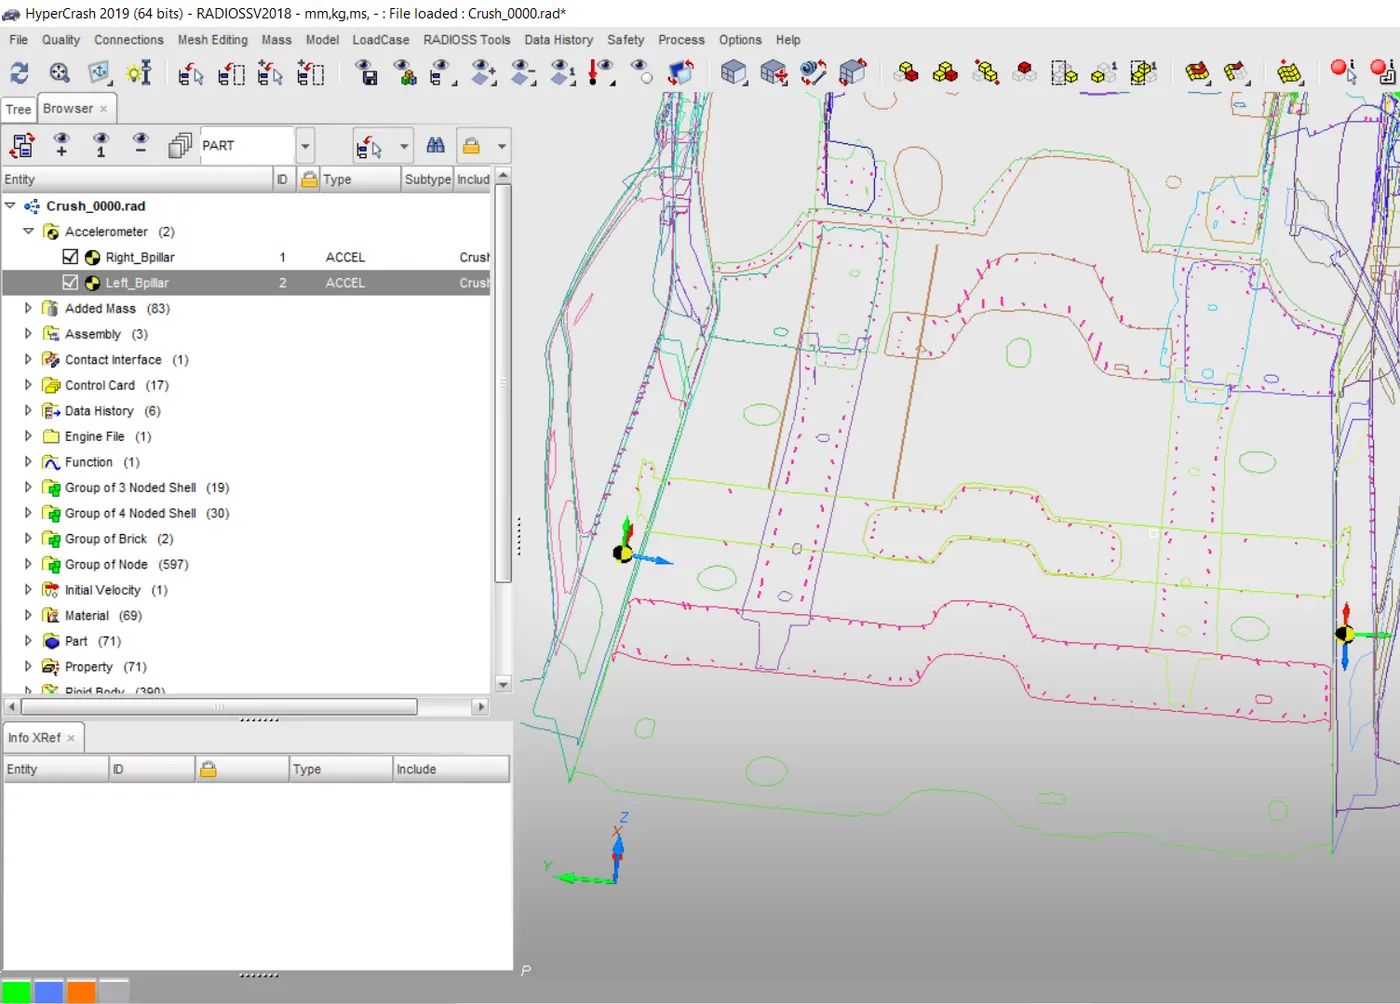
An accelerometer is placed at the b pillar to record the acceleration of that part. This is requested in the th output.
This is placed at both opposite sides and a skew is defined for the cordinates.
MODEL QUALITY CHECK
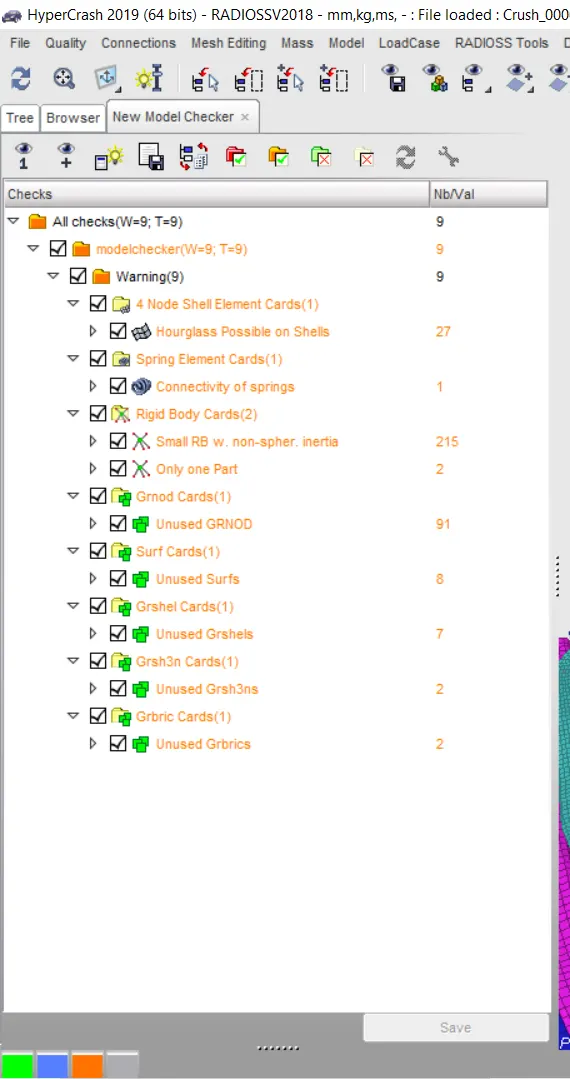
It is important to check for possible errors that may occur during simulation and model checker shows all the errors together with warnings. Below it can be seen that no errors was seen during this check
TIMESTEP AND ENERGY ERROR DEBUGGING
The time step through the simulation was as expected with the minimum time step not less than 0.0001ms and the energy error was well below 15%. No mass change occurred
POST PROCCESING ANIMATION OUTPUT
VON-MISSES
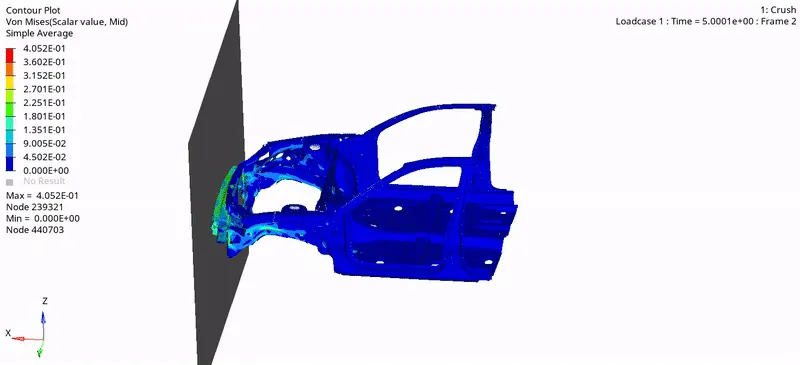
MAXIMUM VON MISSES STRESS=0.41GPa
DISPLACEMENT
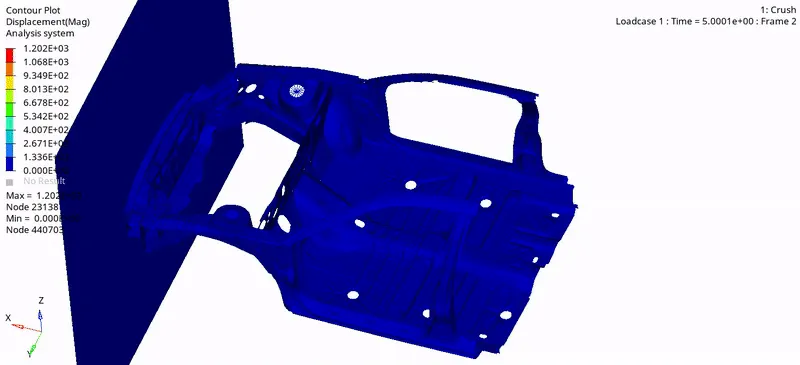 MAXIMUM DISPLACEMENT =1202mm
ENERGY TIME DATA
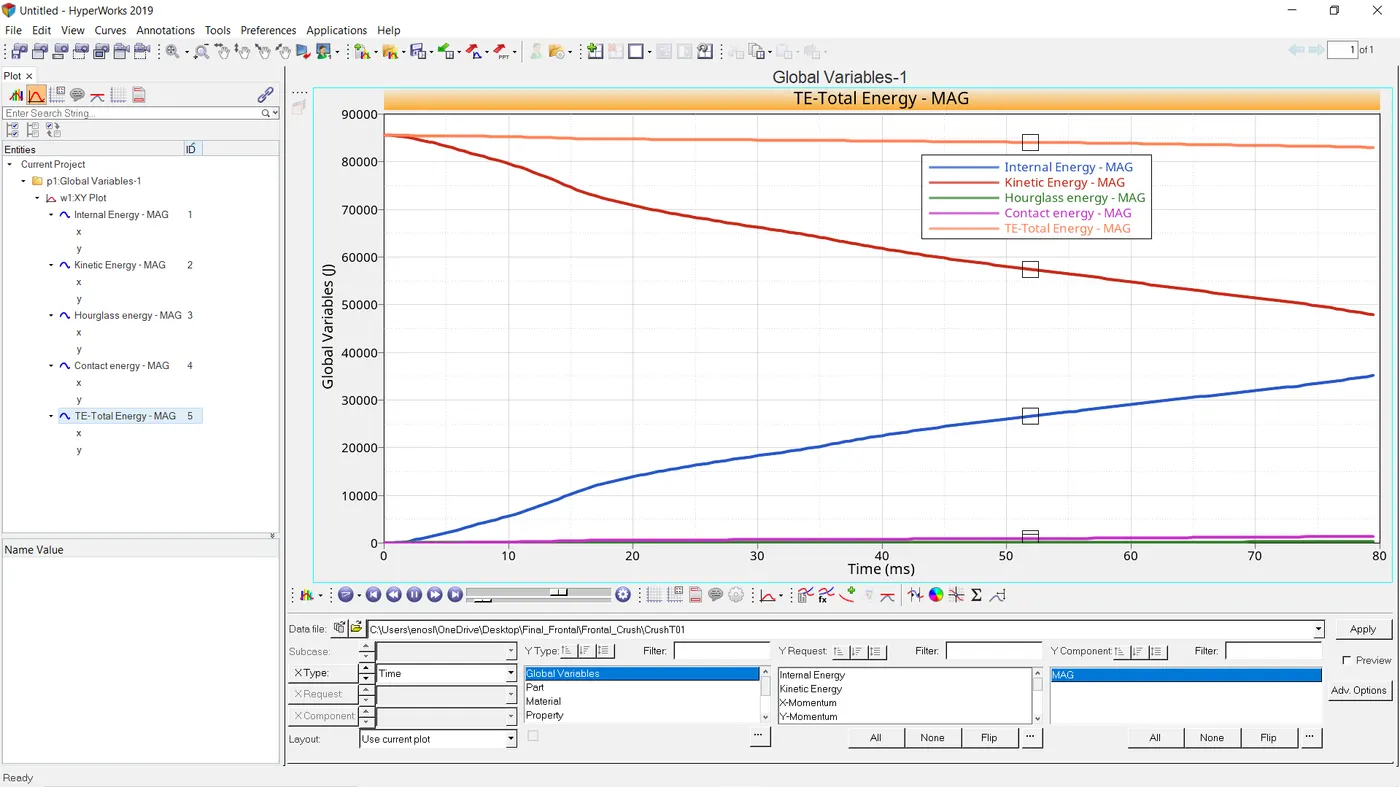
The flow of energy through the simulation was fairly as expected . The kinetic energy decreasing with significant increase in internal energy with time.Because energy absorption is the goal ,the whole of K.E which starts at the highest value should get dissipated and transferred to the internal energy. The more internal energy the more the deformation of the components. The copntact energy which is the energy spent in moving penetrations out of the gap zone is almost constant with a slight increase. This is good as its supposed to be less than 0 to 5% of the total energy. The total energy was slightly decreasing due to the loss of energy and this is expected from the negative energy error recorded. This is due to the timestep control of using CST applying small strain switching element deformation. Hourglass is well stabilized as its seen constant.
MASS PLOT
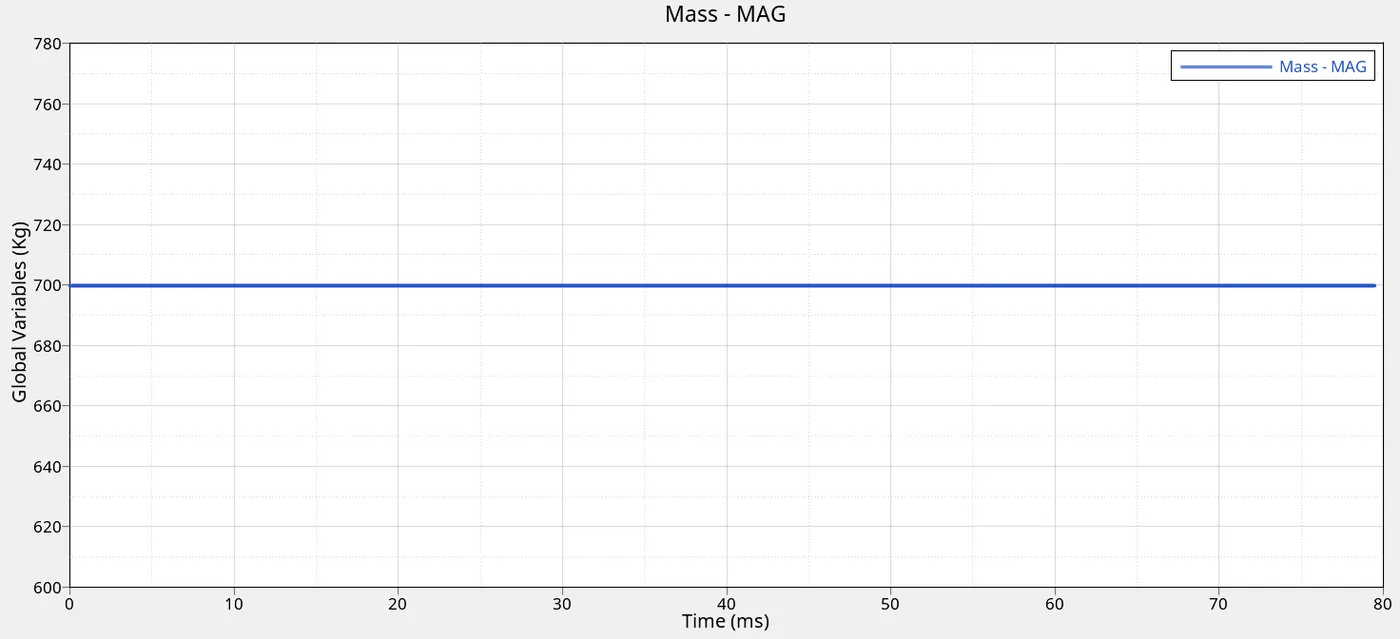
The mass is constant from beginning to end due to the fact that no mass error was detected during simulation .Mass addition was not needed for time step stabilization
TIME-STEP PLOT
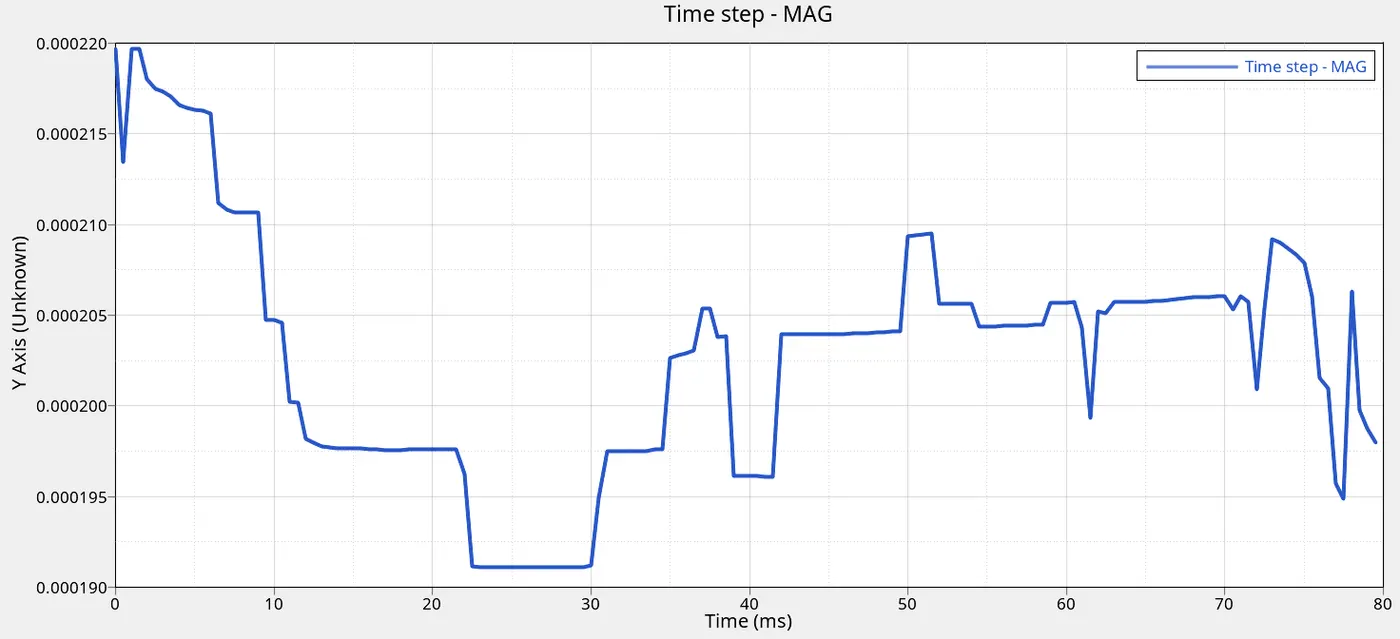
The time step was kept above the critcal value of 0.0001ms.
Energy error of -2.0 was recorded this indicates some energy being dissipated
Simulation Time = 11648.79 s
No of cycles = 395010
CROSS-SECTIONAL FORCES
Bumper -Forces
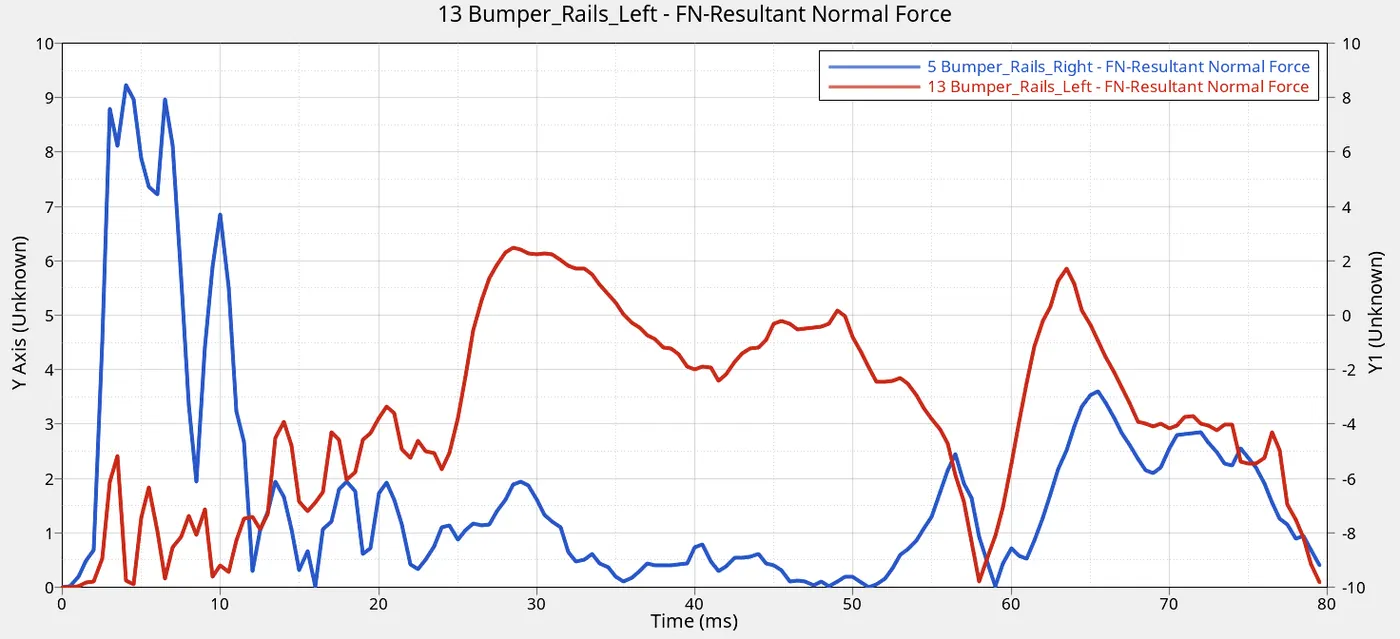
Forces shown in the graph above indicate that energy absorption began from the bumper because its the first contact of the crush. The rail and the shotgun starts to receive the energy from the bumper after peak force 9KN and after 10 ms the energy absorption in the bumper reduces significantly.
Rail_Forces
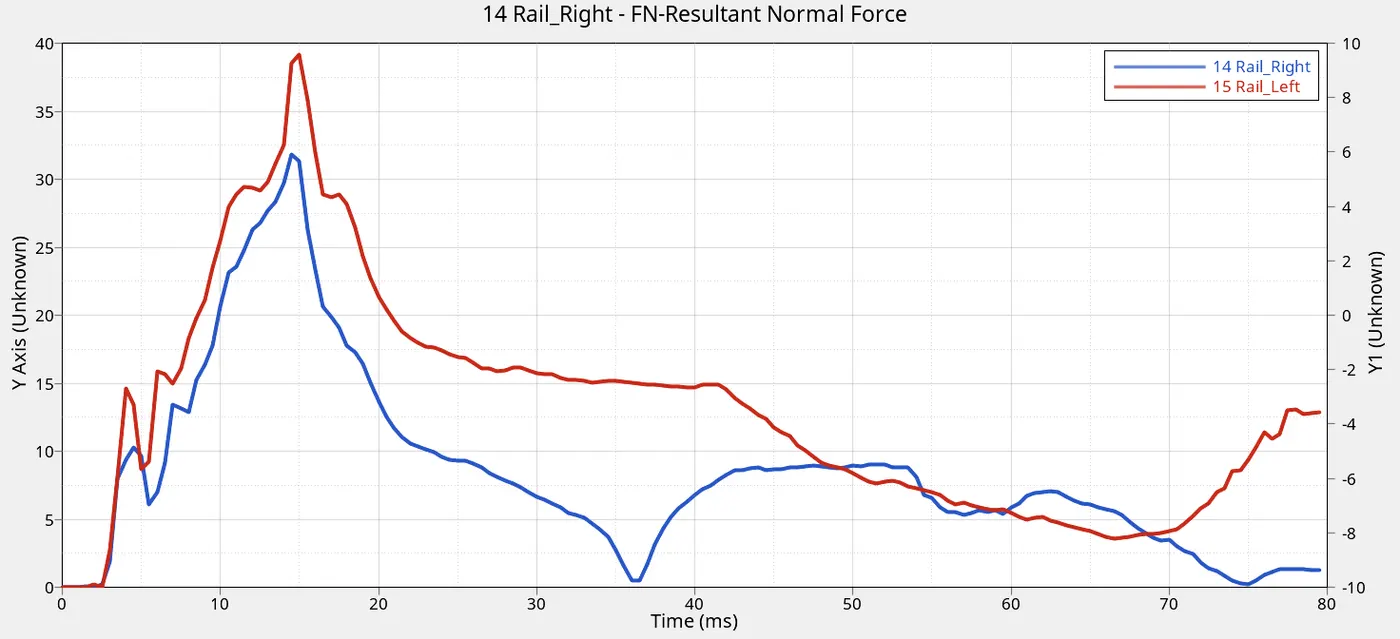
The front rail plays an inportant role in energy absorption. The energy absorbed is maximum compared with the other part of almost 40KN. iT can be observed that maximum absorption occured only after the 10ms. Before this time energy was being absorbed by the bumper to a certain limit then the rail also begun to receive energy. The energy which starts at the bumper is transfered gradually through to the rail ,shotgun and A pillar which receives the least energy.
Shotgun_Forces
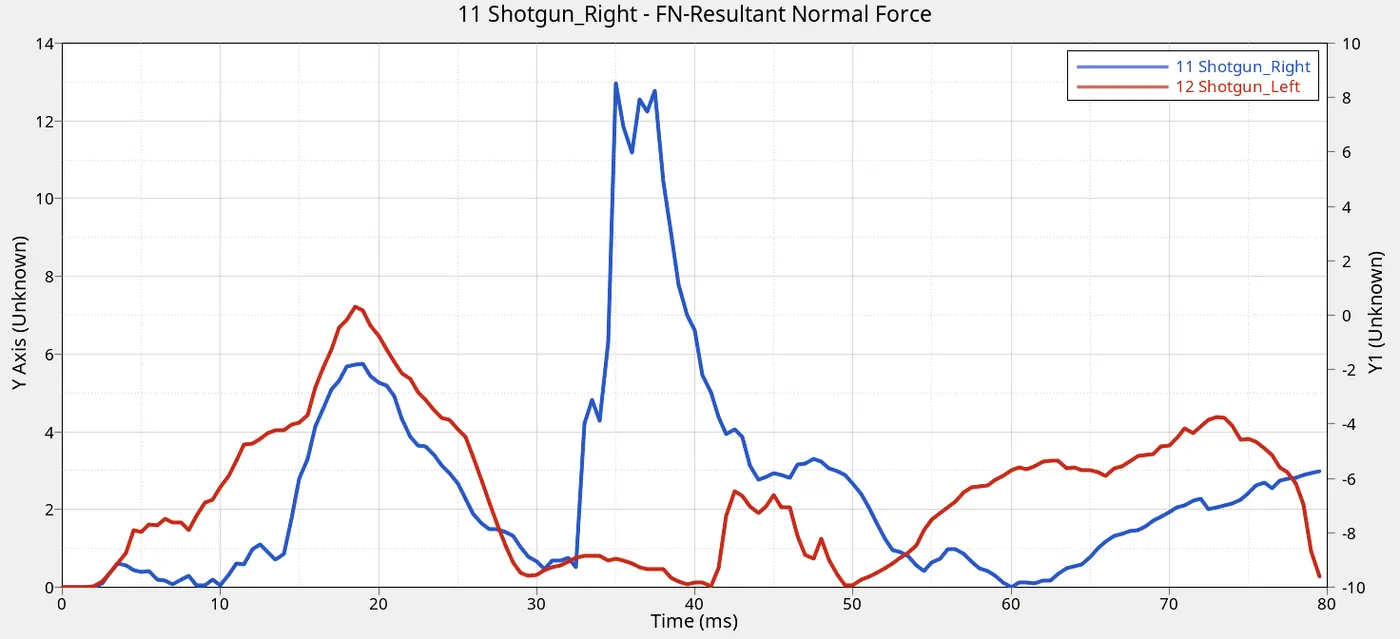
The energy which was not absorbed by the rail is transferred to the shotgun a which peaked 12KN at 40ms. More energy is absorbed here compared to the bumper but way lesser than the rails
A_Pillar Forces
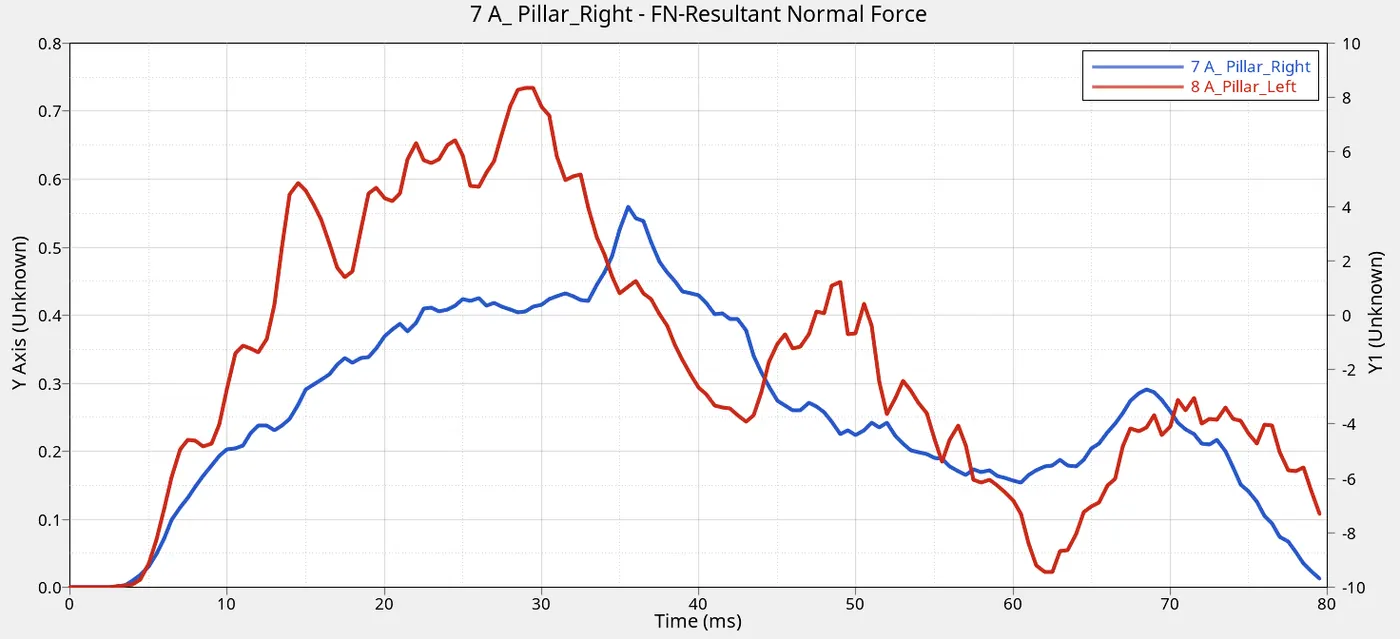
The A pillar receives the least energy as expected because its always required that less energy reaches the passenger seat area. The amount of energy is reduced significantly to only 700N.
INTRUSIONS ON THE DASH WALL
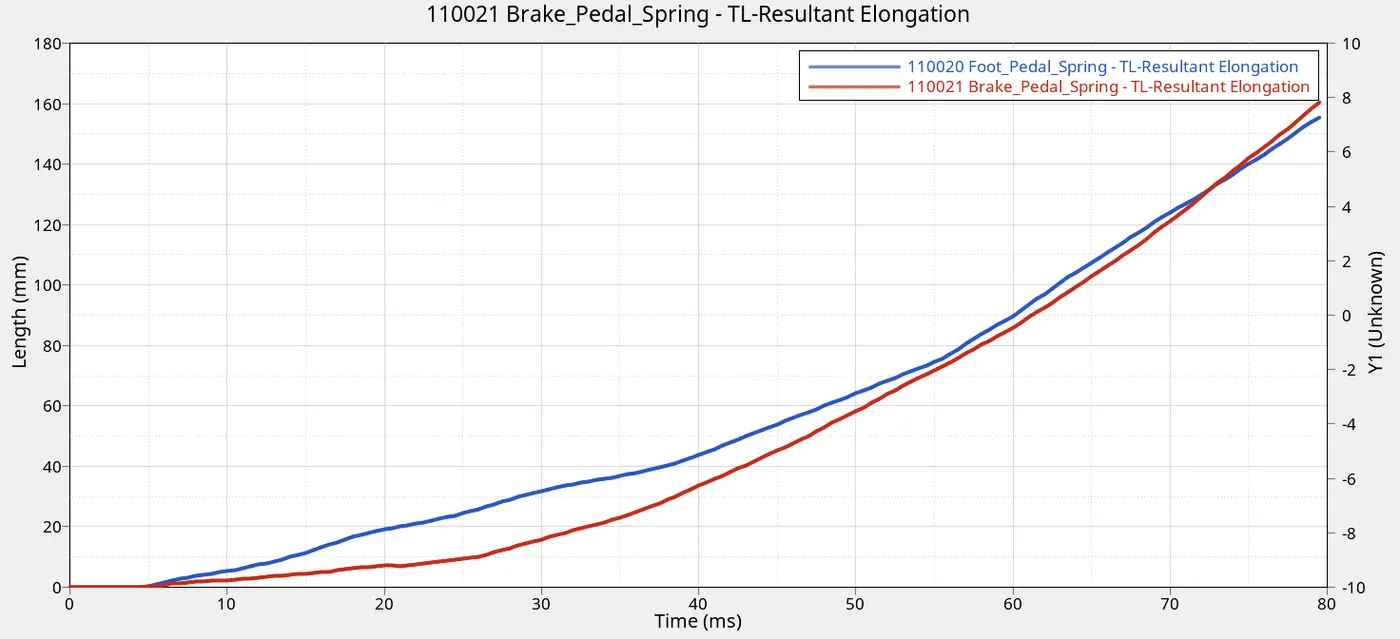
The intrusion on the dashwall is calculated by creating springs at both foot and brake pedals to determine the distance moved by those springs. It can be seen that the spring moved a distance of 170mm after the impact. Placing more components such as the engine would absorb more energy to reduce this intrusion to the dashboard.
ACCELERATION ON THE B_PILLAR
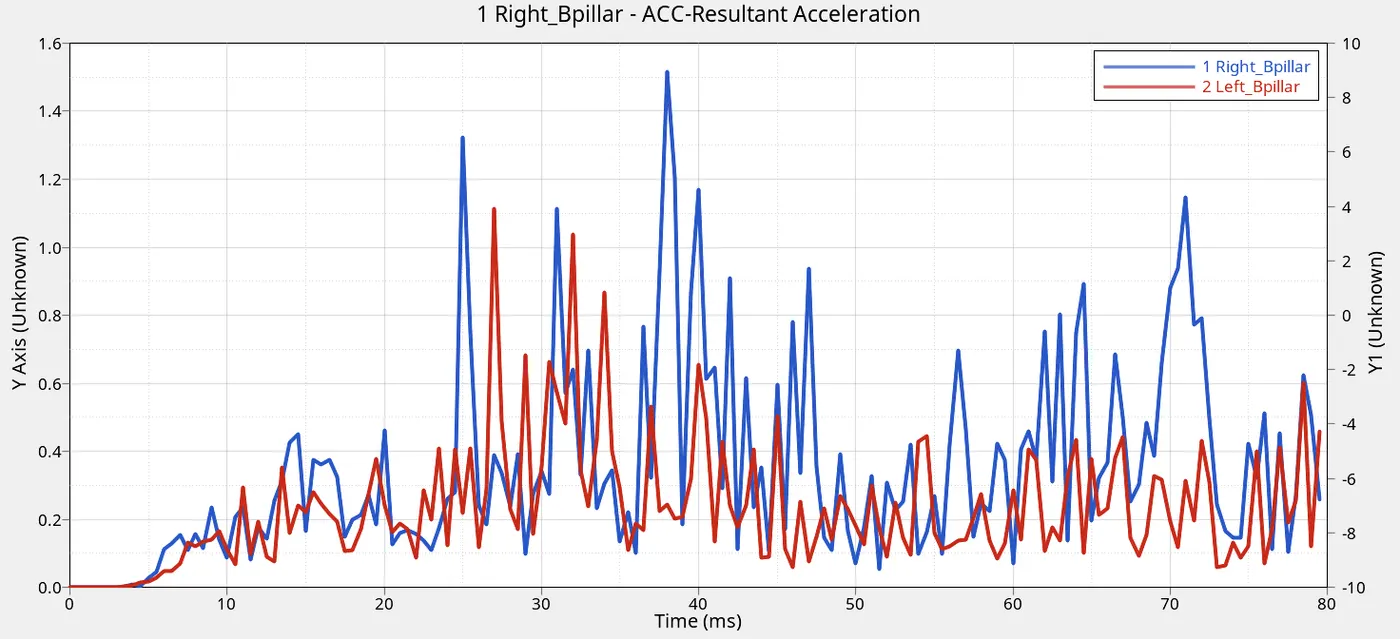
The acceleration of the car where the occupants are located is 1.45mm/ms^2 on the right and 1mm/ms^s. This is optained by placing of the accelerometers
CONCLUSION
- The simulation objectives was obtained and successfull as the timestep mass error and energy error were all withen tolerable values.
- The more internal energy the more the deformation of the components. The contact energy which is the energy spent in moving penetrations out of the gap zone is almost constant with a slight increase. This is good as its supposed to be less than 0 to 5% of the total energy. The total energy was slightly decreasing due to the loss of energy and this is expected from the negative energy error recorded. This is due to the timestep control of using CST applying small strain switching element deformation. Hourglass is well stabilized as its seen constant.
- Energy error of -2.0 was recorded this indicates some energy being dissipated
- The energy absorbed is maximum compared with the other part of almost 40KN. iT can be observed that maximum absorption occured only after the 10ms. Before this time energy was being absorbed by the bumper to a certain limit then the rail also begun to receive energy. The energy which starts at the bumper is transfered gradually through to the rail ,shotgun and A pillar which receives the least energy.
- The A pillar receives the least energy as expected because its always required that less energy reaches the passenger seat area. The amount of energy is reduced significantly to only 700N.
- It can be seen that the spring moved a distance of 170mm after the impact on the dashwall. Placing more components such as the engine would absorb more energy to reduce this intrusion to the dashboard.
- The acceleration of the car where the occupants are located is 1.45mm/ms^2 on the right and 1mm/ms^s.