Week 9 - FVM Literature Review
1.What is Finite Volume Method(FVM), write down the major differences between FDM and FVM. Also, describe the need for interpolation schemes and flux limiters in FVM.
You can use the 1D linear heat conduction equation as an example.
Explanation :
In computational fluid dynamics(CFD) there are three commonly used numerical methods based solvers to solve the governing equations i.e Navier Stokes Equations.
These three methods are
Finite Difference Method :
Finite Difference methods(FDM) ae discritizations used for solving differential equations by approximating with them difference equations that finite differences approximate the derivatives.
FDMs convert a linear ordinary differential equation (ODE) or non-linear partial differential equation(PDE) into a system of equations that can be solved by matrix algebra techniques for FDMs.
The grid is linear and should be aligned in such a way that all grid points lie in a straight line. The properties and governing equations are considered to be concentrated at a single point.
Finite Volume Method :
This method is applied over a volume so that the governing equation is valid over the entire volume. The properties are assumed to be concentrated at the center area. The volume integrals in a partial differential equation containing a divergence term are converted into surface integrals, using the divergence theorem. The obtained terms are considered as fluxes at the surface of each finite volume because when we look through these discretised equations the flux entering a given volume is identical to that leaving the adjacent volume, which is known as conservative. FVM is widely used as it can be applied for complex geometry and moving parts.
Finite Element method :
The FEM is a particular numerical method for solving PDEs in two or three space variables. For solving a problem the FEM subdivides a large system into smaller, simpler parts that are called finite elements. This method approximates the unknown function over the domain. The simple equation the model these finite elements are then assembled into a large system of equations that models the entire problem.
Drawbacks of finite difference method :
- We cannot use FDM directly to a body whose grid points are not aligned correctly along the x,y or z directions. These situations may occure due to complex designs, folds and cuts in an geometry.
- Since it is not aligned we cannot calculate the properties at the next adjacent point exactly, but we can use some corrections in order to approximate the difference with the adjacent point. This method is known as variable transformation method. This approach seeks to creat a grid using other space variables such as eta and epsilon. These space grids looks similar to a cartesian grid. A suitable mapping function is defined and this function can be easily transformed through cartesian to new space variables and viceversa.
- The variables transformation method gives an approximation solution of the property and also time consuming and complex.
- For complex profiles and moving parts the above method is less preffered.
Due to this Finite Volume Method (FVM) is used.
Finite Volume Method :
The finite volume method is a method for representing and evaluating the partial differencing equation PDEs in the form of algebraic equation. In the finite volume method, volume integrals in a partial differential equation that contain a divergence term are converted surface integrals, using the divergence theorem. These terms are then evaluated as fluxes at the surface of each finite volume.
Because the flux entering a given volume is identical to that leaving adjacent volume is identical to that leaving adjacent volume, these methods are conservative. Another advantage of the finite volume method is that it is easily formulates to allow for unstructured meshes. The methos is used in many computational fluid dynamics packages. Finite volume refers to the small volume surrounded each node point on a mesh.
In finite instead of writing equation for a single point, we write equations for an entire volume. Also for a considered volume no assumptions are made over the shape of the volume. Inside this particular volume the flow is conserved flow quantities are conserved, energy, mass, momentum is conserved and so on. This is called as Finite Volume Representation. The starting point of FVM is with ‘integral form of governing equations’.
Steps for FVM discretization :
- We will write the required governing equation in its integral form.
- Apply Gauss Divergence theorem.
- We obtained discretised form which can be solved using a computer(‘Flux Terms’)
Consider a steady state heat conduction equation with a source term
`partial/(partialx)(alpha.(partialT)/(partialx))+S = 0`
Where,
`S`= is the source term
`alpha` = is the thermal diffusivity term
`(partialT)/(partialx)` = is the temperature gradient along x direction.
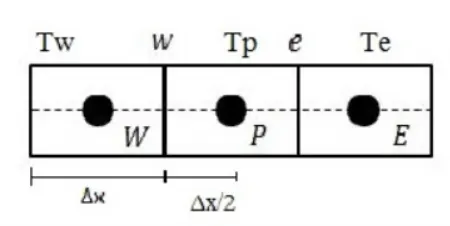
The above governing equation is valid at every point in the domain, meaning it is valid for the entire control volume.
If we consider a small control volume (dv) and it is multiplied with the governing equation and integtated for entire volume then that should be equal to zero i.e the integral form of governing equation.
Taking the conservation equation validated at single point and if it is validated at single point then it is validated at entire volume and in this entire volume the properties are conserved.
Multiplying the equation by ‘dv’ and integrating it, we obtain
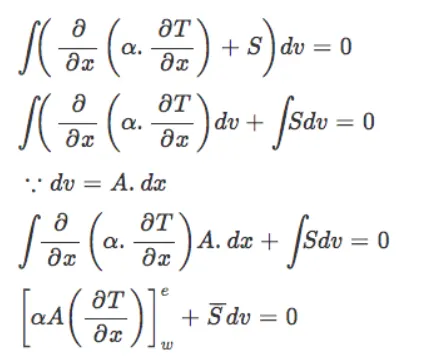
`bar a`is the average value of source term (s) which when multiplied by `dv` will be equal to `intSdv.`
`alpha_eA(partialT)/(partialx_e)-alpha_omegaA(partialT)/(partialx_omega)+barSdv=0`
If we assume `alpha`as a constant term and not as a function of temperature,
The source term which is to be added in the cell, if it is a function of temperature we have to lineraize it. If we consider `alpha` as a function of temperature we have to linearize it as well.
(`barS` linearization `rarr`
`S_u+S_pT_p`).
`alphaA[(T_e-T_p)/(Deltax)]-alphaA[(T_p-T_omega)/(Deltax)]+barSdv=0`
`[Heatflux]_o-[Heatflux]_i+Sourceterm=0`
The amount of heat that is removed from a particular box is conserved.
Different schemes are used to solve the equation.
GRADIENT SCHEME :
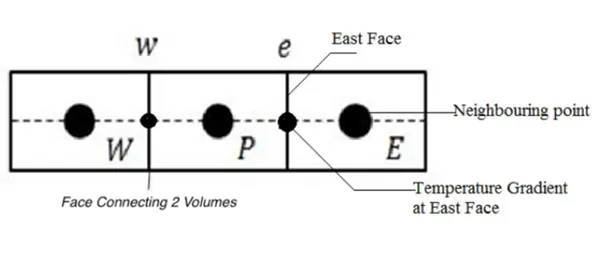
From the above figure when we calculate temperature gradient on the east face, we basically use temperature from neighbouring points trying to evaluate or numerically represent gradient of temperature which is also called as gradient scheme.
INTERPOLATION SCHEME :
In the finite volume formulation, evaluation of surface and volume integrals sometimes requires the values of unknown variables at locations other than the computational nodes of the control volume.
These values are obtained by employing certain interpolation schemes.
As an example let us consider the simple case of steady one dimensional convection and diffusion.
`d/(dx)(rhouphi)=d/(dx)(r(dphi)/(dx))`
where,
`phi`= is our solution variable (scalar)
`rho` = is the density
`u` = is the velocity
`r` = is the coefficient.
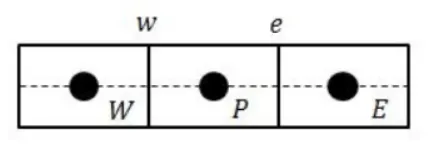
The above figure represents the three neighbouring control volumes, which we are going to use for deriving the discretization equation.
Integer of the governing differential equation over the control volume around grid points p yields.
`(rhouphi)_e-(rhouphi)_omega=(r(dphi)/(dx))_e-(r(dphi)/(dx))_omega`
Evaluation of LHS of the above equation requires value of `phi`over the `e` and `omega`. These values are estimated by employing certain interpolation schemes.
Some interpolation schemes used in CFD are as follows :
- Upwind interpolation scheme.
- Linear interpolation scheme.
- Quadratic upwind interpolation for convective kinematics (QUICK) scheme.
- Hybrid scheme.
- Total variation Diminishing (TVD) scheme.
UPWARD INTERPOLATION SCHEME :
This scheme takes into account the direction of fluid flow and based on it the value of solution variable at the faces is approximately by its value at the upstream computational nodes.
LINEAR INTERPOLATION SCHEME :
In order to approximately the values of variable at the control volume face center by two nearest computational nodes location. This is equivalent to a central difference scheme of first order derivative. It is second order inaccurate and produce oscillatory solutions. The relation for linear for linear interpolation is given below :
`f_e=f_elambda_e+f_p(1-lambda_e)`
where,
`lambda_e=(x_e-x_p)/(x_E-x_p`
A part from Gradient scheme and interpolation scheme there are something called Flux Limiters.
FLUX LIMITERS :
While calculating the variable gradients they tend to toggle and are not bounded to a particular value and keep jumping. This occurs due to discontinuity, having a flux limiter will help to bound the gradient value giving a stable solution.
Numerical approximation using higher order spatial discretization schemes results in better accurate but exhibits sourious oscillations near discontinuities such as shocks. On the other hand lower order spatical discretization schemes remain stable near discontinuities but dampen out the distributions due to their dissipative nature.
Hence to capture discontinuities, high resolution schemes are required which are highly accurated and stable throughout the domain.
Flux limiters operate functionally as a switch and tune numerical fluxes obtaines from a lower order scheme and higher order scheme such that near the discontinuity lower order scheme and away from the higher order scheme is employes.
Flux limiter function depends upon the smoothness parameters which is defined as
`r_p=(phiP-phiW)/(phiE-phiP)`
The flux linear conservation is constraines to be greater than or equal to zero. It assumes a value of 0 near discontinuities and a value of 1 away from them. Hence it switches between higher order scheme and lower order scheme for numerical representation of flux, thereby keeping the scheme stable and accurate throughout.
The flux limiters are also reffered to as slop limiters because they both have the same mathematical foam, and both have the effects of limiting solution gradient near stacks for discontinuities. In general, the term flux limiters is used when the limiter acts on system fluxes ans slope limiters is used when the limiter acts on system states.
Consider 1D-Semi discrete scheme,
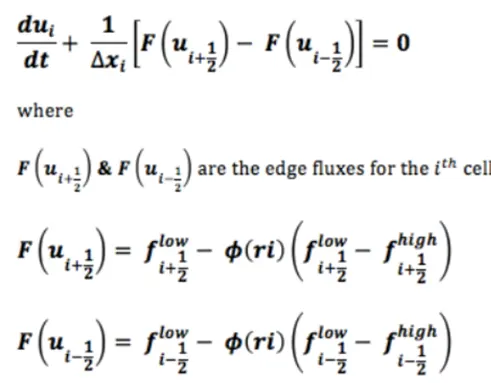
f_high = lower precision, high resolution flux
f_low = high precision, low resolution flux
phi(r) = flux limiter function.
`r_i=(u_i-u_(i-1))/(u_(i+1)-u_i`
'r' represents the ratio of successive gradients on the solution mesh,
phi(r)>=0.
This is the limiter function case
If limiter function = 0, then there will be a low resolution and sharp gradient.
If limiter function > 0, then there will be a high resolution and positive gradient.