Week 7 State of charge estimation
1.Simulate the 3 test cases from harness dashboard and write a detailed report on the results
The example helps to get started with designing Lithium Ion Battery Management System (BMS) with MATLAB and Simulink.
This Project includes Simulink models for BMS Algorithms such as: State of Charge estimation using Extended Kalman Filter, Unscented Kalman Filter, Passive Battery Cell Balancing, State Machine for Pre-charging and Contactor Management, Fault Management - Over/Under Voltage, Over Current, Over Temperature etc and Charge and Discharge Current Limit Calculations.
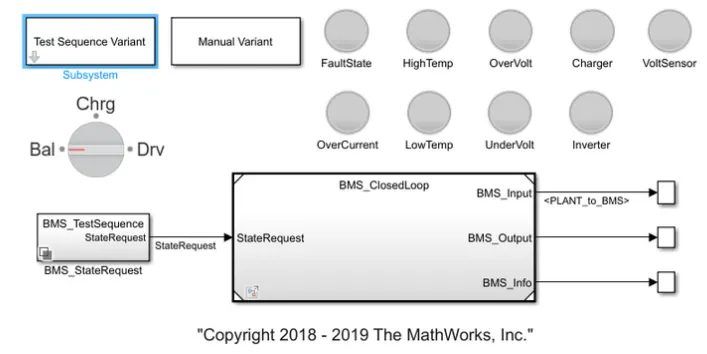
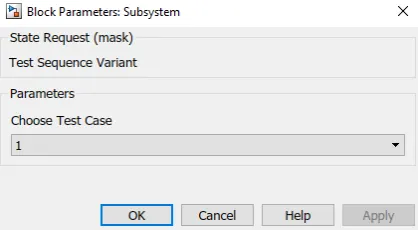
As it has been asked for three test cases, now click on the Test Sequence Variant and under the parameters choose test case-1.
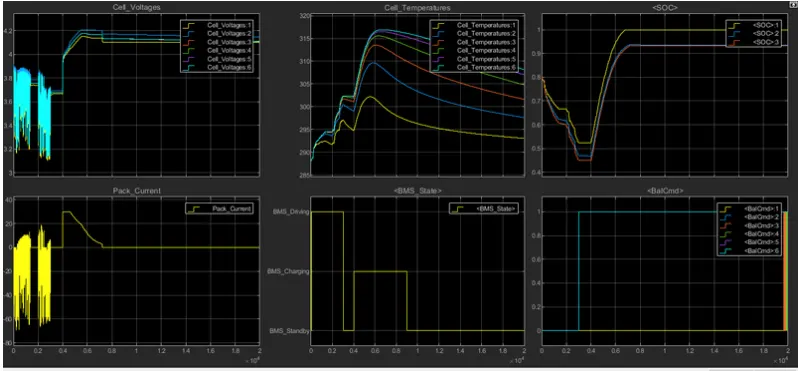
As the simulation ends we got 6 result graph considering the BMS is an operation for electrical vehicle.The first graph indicates the cell voltage of all the cells involved in the battery pack we first observed that cell voltages changing as the current flowing in and out. at the beginning of the simulation, the voltages are slightly different because we initialize the model with a slight associate of imbalance the voltages are deflecting from the range of 3.1 V to 3.9 V for the time period of 0.3*10^4 sec, and then there is balances state of all voltage of their respective cells and then there is a sudden hike in cell voltage till they reach 4.2 V and at the end of the simulation, the values converge towards one another and trying to balance the voltages till the end still there is a small difference in their voltages and the voltage line flows between 4 V to 4.2 V. because the system goes on standby mode.In charging state during the constant current phase current is debated because the maximum cell voltage is high, enough compared to prescribe 4.4 V limit that an excessively high current control the voltage beyond the threshold significantly limiting the life of the battery.The temperature traces show the significant discrepancy between the hoter and least hot cell the reason is mainly because of symmetry in the merger layer in terms of thermal behavior. the cell-6 is significantly hotter the cell-1 because it is thermally insulated on one side. even if the maximum temperature reached during the simulation is not concerned in terms of safety. the temperature difference at cell no 6 at its higher temperature will eventually cost much faster degradation of cell-6 compared to cell-1 leading to undesirable and uneveness in cell condition. therefore need an active thermal management system to keep thermal differences within a few degree celcius.The graph no 3 show the soc of three different battery cell each performed with different matter yellow corresponds to coulomb counting, blue corresponds to ukf and orange to ekf, the initial SoC is 75%, however, the simulation so estimates need to initialize it to 80% to set their capability to recover.It is apparent that coulomb counting never does because it has no way to realize it is wrong due to the absence of voltage information. both common filter algorithms on the other hand recover from the initial error within the first hour of simulated time. with the ekf slightly outperforming then ukf.
Now click on the Test Sequence Variant and under the parameters choose test case-2.
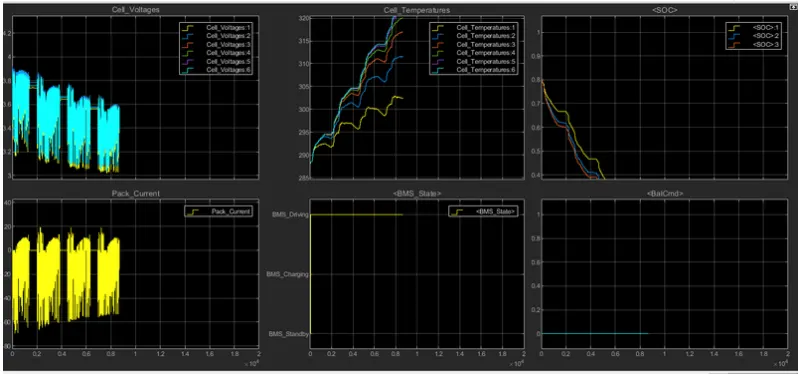
At the initial state the voltage of all the cells are deflecting in the same manner and dropping slightly in the range of 3 V to 3.9 V it has 4 fluctuation zones and in between each of these fluctuating zone, they are stable for while and this phase lasts for 0.85*10^4 sec.On the other hand the current graph has exactly flowed in the same manner but in the opposite direction when voltage is getting drop current required is high and current flows in the range of -70 A to 20 A.The temperature of all the cells initiating from 288-degree Celcius and they get scattered all the cells have a different temperature traces show the significant discrepancy between the hottest and coldest cell the reason is mainly because of symmetry in the merger layer in terms of thermal behavior. cell-6 is significantly hotter the cell-1 because it is thermally insulated on one side. even if the maximum temperature reached during the simulation is not concerned in terms of safety.The cells are initially at 80% of SoC and then they're falling at different time periods. to set their capability to recover.It is apparent that coulomb counting never does because it has no way to realize it is wrong due to the absence of voltage information. Both common filter algorithms on the other hand recover from the initial error within the first hour of simulated time. with the ekf lightly out performing then ukf then is apparent that coulomb counting never does because it has no way to realize it is wrong due to the absence of voltage information. Both common filter algorithms on the other hand recover from initial error within the first hour of simulated time. with the elf slightly outperforming the ukf. The other scopes indicate the bms state at each of the balance command signals respectively. where it's on driving mode and command signals on zero lines.
Now click on the Test Sequence Variant and under the parameters choose test case-3.
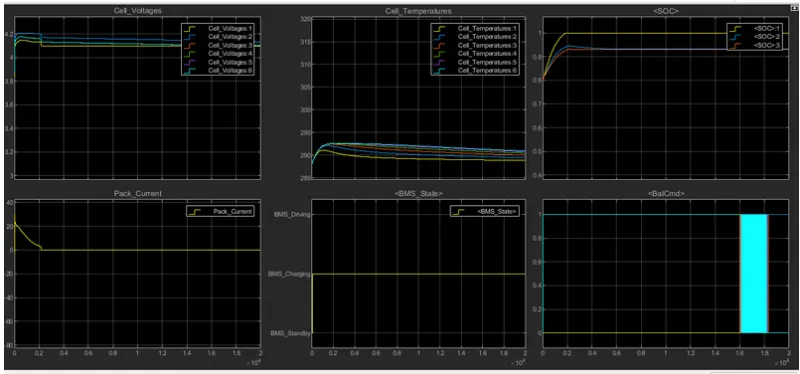
All the cells are initiated with at different voltages the where the 6 the one having the higher voltage of 4.2 V and the 1st one having near about 4.1 V and remaining falling under this range BMS on charging state throughout the simulation. so the voltage graph move along in a straight line because the voltage supply continues .there have some deflection of voltage lines of different cells but that is a very less amount of change in voltage .at the end of the simulation BMS trying to balance the voltage very much.The battery pack current is initiated with 20 A and then it falls to zero current till its complete simulation time of 0.2*10^4 sec and then it maintains the constant current because it is put on charging state and it remains constant throughout the simulation.All the cells initiate with 287-degree celcius and then all the cells maintaining the straight line but with different temperatures range. The SoC is initial soc of three different cells is at 80% as the. as the system is put on charging state the soc hikes up to 100% for the yellow cell,ukf and ekf initially having different charging rates but after 0.4*10^4 sec they having equal state of charge of 91% and it maintains throughout the simulation.It is apparent that coulomb counting never does because it has no way to realize it is wrong due to the absence of voltage information. both common filter algorithms on the other hand recover from the initial error,ekf and urf slightly under performing then coulomb counting.The other scopes indicate the bms state at each of the balance command signals respectively. bms on charging state and battery command passing signal between 0 to 1.
2.What is coulomb counting? Refer to the above model and explain how BMS implements coulomb counting for SOC estimation ?
Coulomb counting is a technique used to track the SoC of a battery pack. It works by integrating the active flowing current (measured in amps) over time to derive the total sum of energy entering or leaving the battery pack. This produces a capacity that is typically measured in amp-hours.The Coulomb counting method measures the discharging current of a battery and integrates the discharging current over time in order to estimate SOC. Coulomb counting method is done to estimate the SoC(t), which is estimated from the discharging current I(t), and previously estimated SOC values,SoC(t-1).SOC is calculated by the following equation
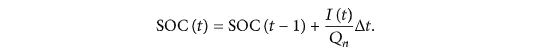
But there are several factors that affect the accuracy of Coulomb counting method including temperature, battery history, discharge current, and cycle life.
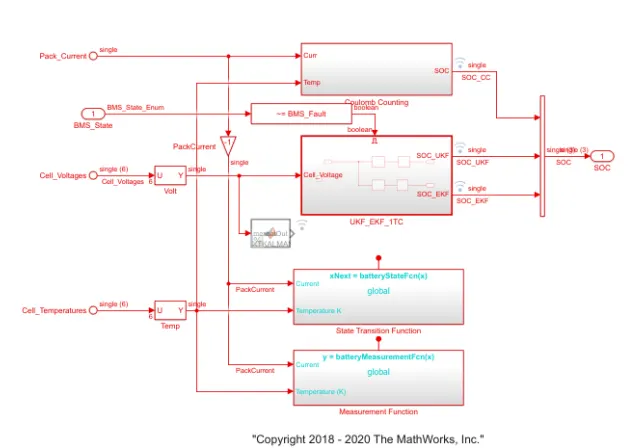
SoC estimation block we can see three different techniques for the state of charge estimation. all three techniques have their own merits and limitations. the first method is coulomb counting and the other two are unscented(ukf) and extended Kalman filter(ekf).here we are concern with the coulomb counting method.
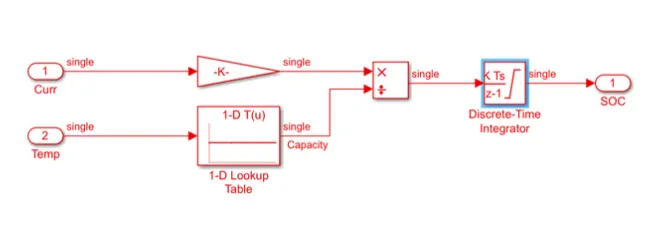
In coulomb counting method block,it takes two input signals such as current and temp and the current signal goes to gain block and the temp signal goes to lookup tables of battery time and current and both the blocks are connected to the divided block and these signals are connected to the discrete-time integrator to track the charge and which finally helps to calculate the state of charge.Which consist of integrating a current and doesn't leave the cell for that here we using discrete-time integrator to give the track of the cell charge of the time the benefits of this method is that its simplicity and its low cost and the drawbacks are an accumulation of current sensor error and its inability to recover from the wrong initial condition. from the lack of feedback from voltage measurements.