Week-4 Challenge WOT Condition Part-2
1. What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Mapped Model of Engine: Here the model of the engine is modelled with the help of lookup tables to characterize the engine or the motor performance.The table provides the overall engine characteristics.Here the components are modelled by steady state maps and charts in backward facing direction.Therefore energy consumed and performance of different components during transient period are not calculated properly.It is suitable for analysis and design activities that do not require engine sub systems dynamic characteristics.
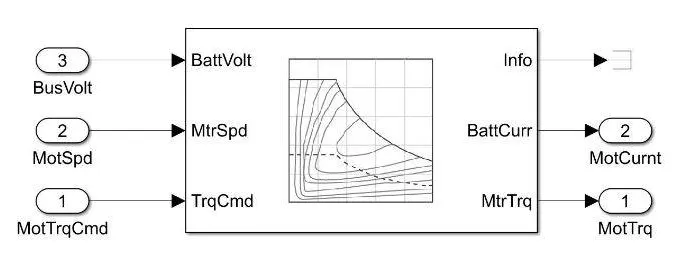
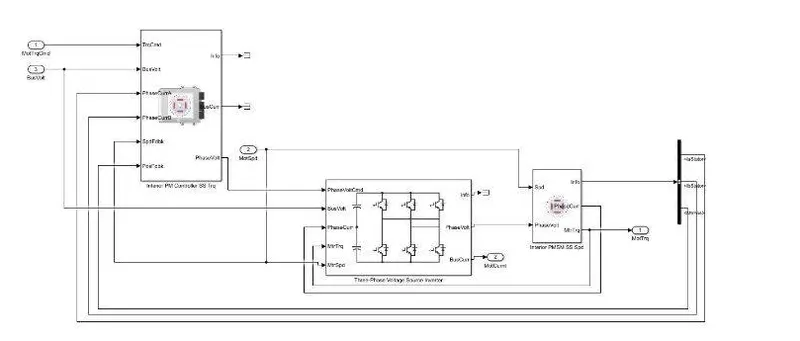
Dynamic Model of Engine: Here the model is developed by considering the both transient or dynamic behavior and the steady state characteristics of the motor or the engine.Therefore this model is suitable for disigning the control ,estimator and diagnostic algorithms that depend on dynamic sub system.It is a forward facing approach model.perfomance is good compared to the mapped model of the engine.
2.How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
kwh (kilo watt hour) is the standard energy unit in the electricity.Miles per gallon is a measure of the average distance travelled per unit energy consumed.MPGe is used by US Environment protection Agency to compare energy consumption of greeen technology vehicle applications.
Calculation of MPGe: It is determined by converting the vehicle consumption per unit distance, as determined through computer modeling from its native units into gasoline energy equivalent.
MPGe= ((Total Miles Driven)*(Energy of one gallon of gasoline))/(Total energy of all fuels consumed)
Factors Considered for Model Fuel Flow:
1. The cost of aquiring and using the fuel for each specific situation.
2. The energy content of the fuel type.
3. The availability of the type of fuel the source needs.
4. How safe it will be to use the fuel under consideration.
3. Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
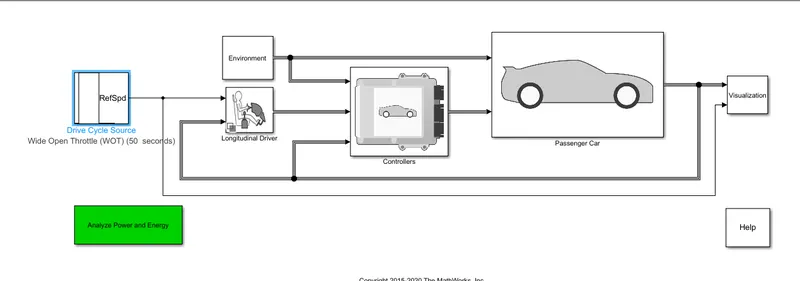
Now the drive cycle is chosen to be WoT
with the following modifications as shown below
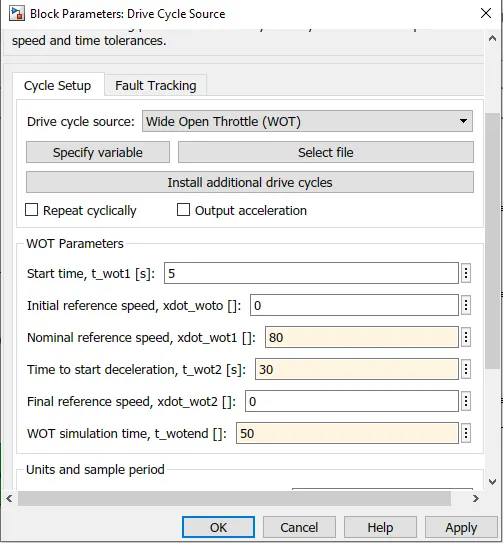
Now click apply and OK
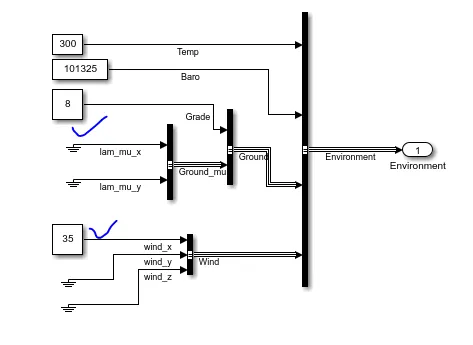
Now following changes are made to the environment block with gradeability 8% and the wind velocity to be 35.
following results are obtained
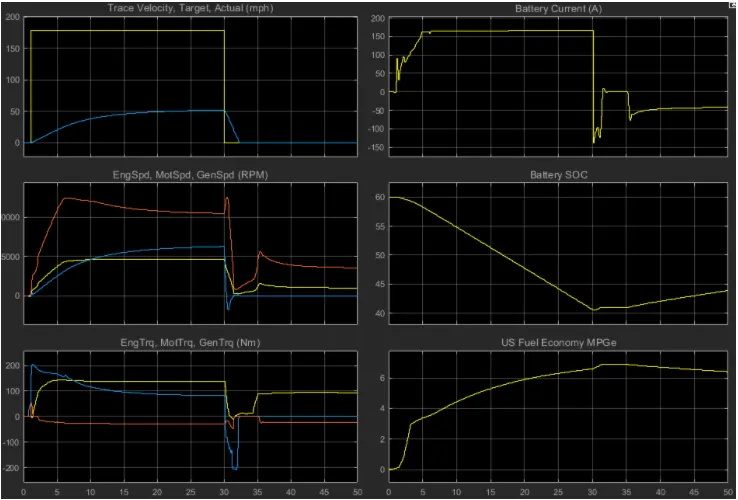
The vehicle velocity is less than the reference velocity as the grade and wind velocity have the effect. The maximum velocity obtained is 50mph.The engine/motor/generator speed is around 13000rpm which comes to zero during the braking operation.The max torque produced is 200Nm.The SoC falls to 42% in the initial 30 seconds and the battery current is about 160A during this duration.
4.Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
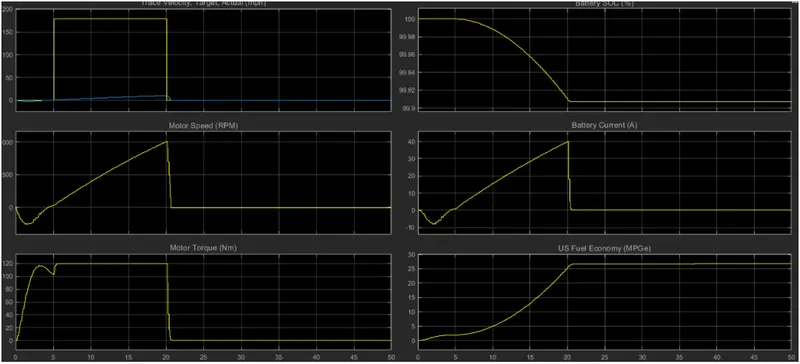
Waveforms for the pure EV
We can Conclude that the maximum obtained speed is Hybrid Electric Vehicle is more than the Electric Vehicle,The battery current is higher in the HEV which is 160A and in case of EV it is 40A.Similarly Torque is more in case of HEV rather than the EV. With regards to the fuel economy the EV is 27MPGe where as HEV it is 7MPGe which is advantage.
We can Conclude that:
EV are better compared to the HEV in terms of Battery discharge condition,Less emission and fuel consumption and more efficient.