Week-7 Challenge: DC Motor Control
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
A.
Speed control of a DC motor using BJT H-bridge
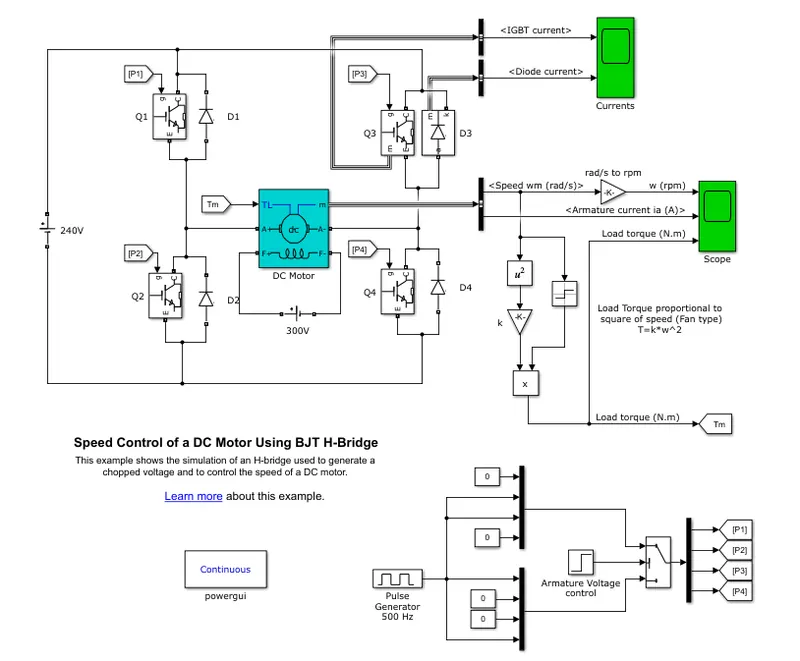
Here is the MATLAB demo model for 'Speed Control Of A DC Motor Using BJT H-Bridge'. This model consist of a H-Bridge with 4 pairs of BJT diode.
H-Bridge
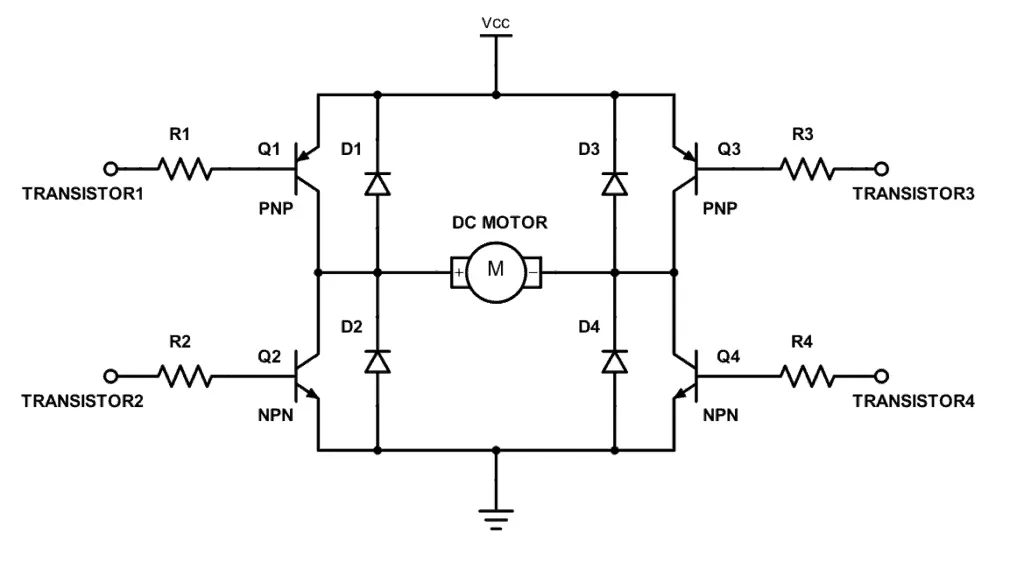
A H-bridge is an electronic circuit that switches the polarity of a voltage applied to a load. These circuits are often used in robotics and other applications to allow DC motors to run forwards or backwards. The name is derived from its common schematic diagram representation, with four switching elements configured as the branches of a letter "H" and the load connected as the cross-bar.
This H-Bridge is made with 4 switches Q1,Q2,Q3,Q4 and 4 diodes D1,D2,D3,D4. The basic operating mode of an H - bridge is fairly simple : if QI and Q4 are turned on , the left lead of the motor will be connected to the power supply , while the right lead is connected to ground. Current starts flowing through the motor which energizes the motor in the forward direction and the motor shaft starts spinning. If Q2 and Q3 are turned on the reverse will happen , the motor gets energized in the reverse direction , and the shaft will start spinning backwards. In a bridge , you should never ever close both QI and Q2 ( or Q3 and Q4 ) at the same time . If you did that , you just have created a really low - resistance path between power and GND , effectively short - circuiting your power supply . This condition is called ' shoot - through and is an almost guaranteed way to quickly destroy your bridge , or something else in your circuit.
Working of model
- This model consists of a H bridge with 4 BJT - Diode Pair. The inputs such as duty cycle and step time are given from 'Pluse Generator Block' , ' Armature Voltage Control Block'.
- DC motor used in the model is preset model ( 5 HP 24V 1750 rpm ) It simulates a fan type load ( where Load torque is proportional to square of speed ) . The armature mean voltage can be varied from 0 to 240 V when the duty cycle ( specified in the Pulse Generator block ) is varied from 0 to 100 %.
- The H - bridge consists of four BJT / Diode pairs ( BJT simulated by IGBT models ).
- Two transistors are switched simultaneously : QI and Q4 or Q2 and Q3 . When QI and Q4 are fired , a positive voltage is applied to the motor and diodes D2 - D3 operate as free wheeling diodes when QI and Q4 are switched off.
- When Q2 and Q3 are fired , a negative voltage is applied to the motor and diodes DI - D4 operate as free wheeling diodes when Q2 and Q3 are switched off.
B.
SIMULATION RESULTS
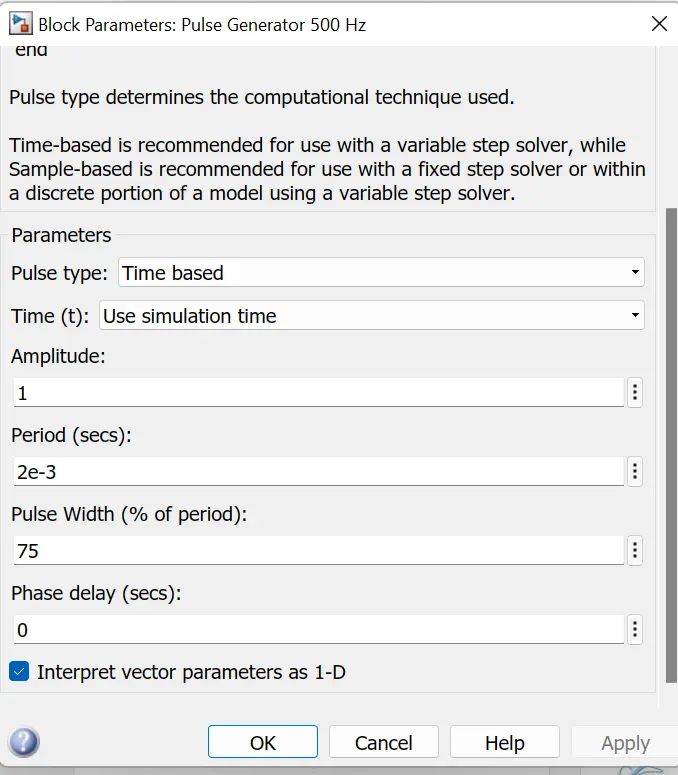
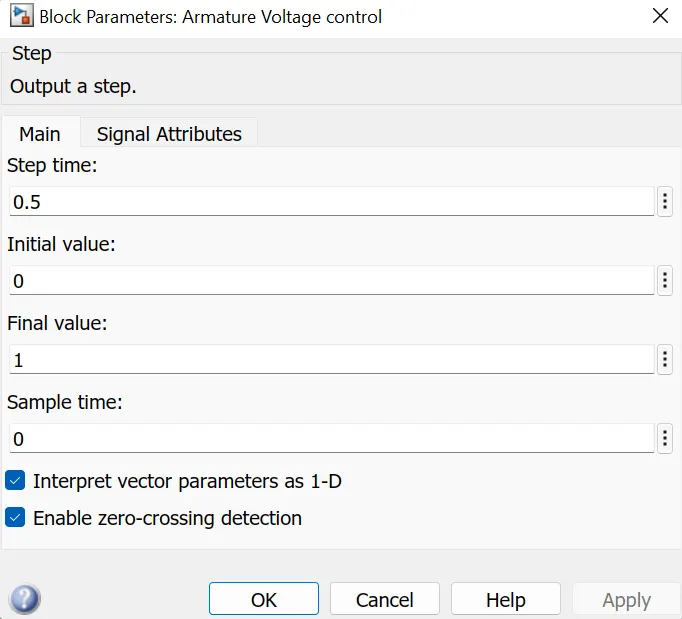
The Pulse Generator with Amplitude 1 , Peiod 2e-3 and pulse width of 75% isgiven as the input. And the Armature voltage control with 0.5 step time is used.
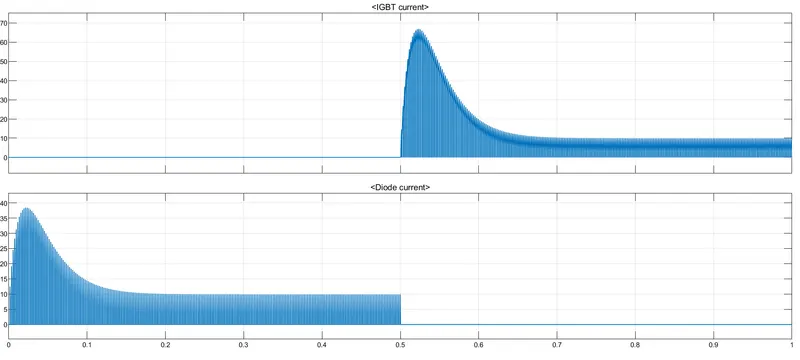
The graph shows IGBT Current and Diode Current with respect to the time after 1 second simulation. From the graph we can see that, fo 0 to 0.5 seconds, the current flows through diode D3 and from 0.5 to 1 second, the current flows through Q3.
The motor starts in the positive direction with aduty cycle of 75% (mean DC voltage of 180V ). At t = 0.5s , the armature voltage is suddenly reversed and the motor runs in the negetive direction.
RPM, Armature Current and Torque Plots
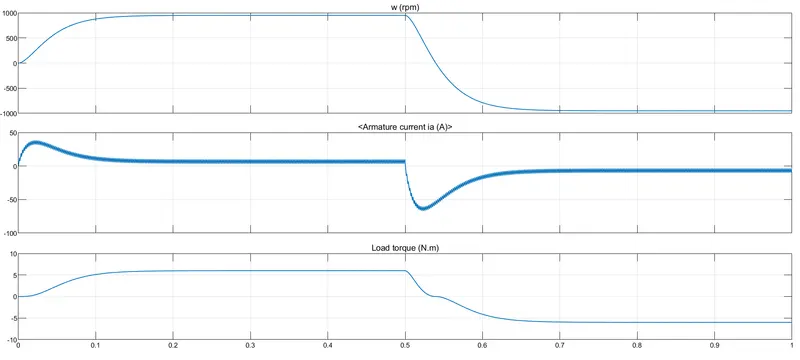
' Scope ' shows motor speed , armature current and load torque and ' Currents ' shows currents flowing in BJT Q3 and diode D3 . The waveform for speed , armature current and load torque is shown in above graphs . from armature current graph , we can see that at starting there is sudden spike increase in current at 0 sec also and at 0.5 sec also. We can see that , as the voltage gets changed in the circuit , the speed of motor also changes ) In this transition of positive to negative direction of rotation we observe a high surge in current , this is due to the transient switching occurring in the circuit. As there is already current flowing in the circuit & on changing of switches after 0.5 sec , the current in the circuit adds to the changed direction of current and we observe a surge. The surge in the current can be reduced by reducing duty cycle. In this case the duty cycle is 75%, if we reducing it to 50% we can observe a tremendous dcrease in surge current.
C.
Four Quadrant Chopper
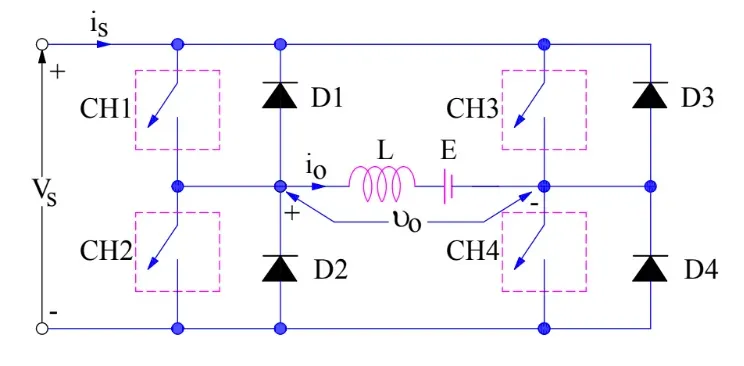
The circuit of a four quadrant chopper or class-E chopper basically consists of four semiconductor switches CH1 to CH4 and four diodes D1 to D4. The four diodes are connected in anti-parallel. For first quadrant operation CH1 is made ON, for second quadrant operation CH2 is made ON and so on.
- First Quadrant Operation:
For first quadrant operation, CH4 is kept ON, CH3 is kept OFF and CH1 is operated. When both CH1 & CH4 are ON simultaneously, the load gets directly connected to the source and hence the output voltage becomes equal to the source voltage. This essentially means that vo = vs. It may be noted that the load current flows from source to load as shown by the direction of io.
When CH1 is switched OFF, the load current free wheels through CH4 and D2. During this period, the load voltage and current remains positive. Thus, both the output voltage vs and load current io are positive and hence, the operation of chopper is in first quadrant. And motor rotates in forward direction, called Forward Motoring.
- Second Quadrant Operation:
To obtain second quadrant operation, CH2 is operated while keeping the CH1, CH3 & CH4 OFF. When CH2 is ON, the DC source in the load drives current through CH2, D4, E and L. Inductor L stores energy during the On period of CH2.
When CH2 is switched OFF diode D4 and diode DI conducts , output voltage v , becomes positive and the output current i , is negative , inductor release energy using diodes D4 and D1 power flows from load to source and hence called as Forward braking . This is also konw as Regenerative braking.
- Third Quadrant Operation:
To obtain second quadrant operation, switch CH3 turned on. The polarity of back emf Eb must be reversed . Here switch CH3 operated , Switches CH3 and CH2 conducts , output voltage vo and the output current i , both are negatives , power flows from source to load and inductor stores energy , the motor rotates in the reverse direction hence it is called as reverse motoring.
When switch CH3 turned off. Switch CH3 turned off but switch CH2 and diode D4 conducts , output current i , is negative and the output voltage v , becomes zero , inductor release energy and freewheeling action using diode D4 takes place , the motor rotates in the reverse direction , So the polarity of back emf is reversed , hence called as Reverse motoring.
- Fourth Quadrant Operation:
Switch CH4 turned on, The polarity of back emf must be reversed . If that the motor is running in the reverse direction . Here switch CH4 operated , Switch CH4 and diode D2 conducts , output voltage vo is zero and E , is responsible for the positive output current io . machine behave as generator and inductor stores energy.
Switch CH4 turned off , The polarity of back emf must be reversed . Switch CH4 turned off , diode D2 and diode D3 conducts , output voltage vo becomes negative and output current i , is positive , inductor release energy using diodes D2 and D3 . power flows from load to source and hence called as reverse braking.
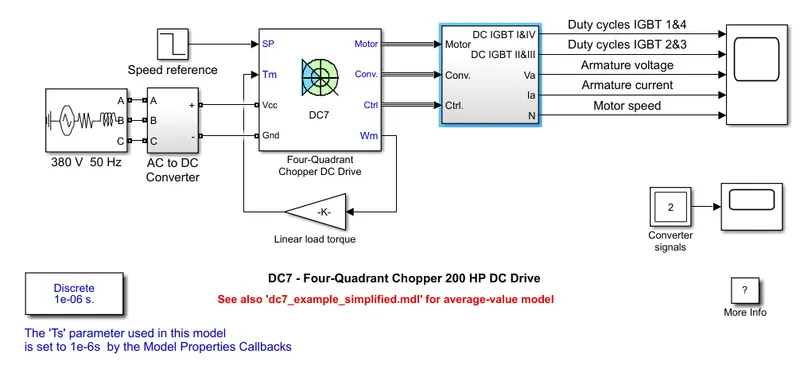
Simulink Model
H-Bridge:
- Works in Open Loop system ( Non - feedback mechanism ).
- The motor is not separately excited.
- It cannot work in regenerative mode.
- We need to change the polarity in order to make the motor move forward or backward.
- Simulation is continuous.
- The simulation takes more time and is less efficient.
Four Quadrant Chopper:
- Works in closed - loop system ( feedback mechanism ) . The armature voltage is controlled by PI regulators.
- The motor is separately excited with a constant 150 V DC field voltage source.
- It can work on all 4 quadrants.
- We need to interrupt the signals.
- Simulation is discrete.
- The simulation takes less time and its more efficient.
2. Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
2-Quadrant Chopper Using Simulink
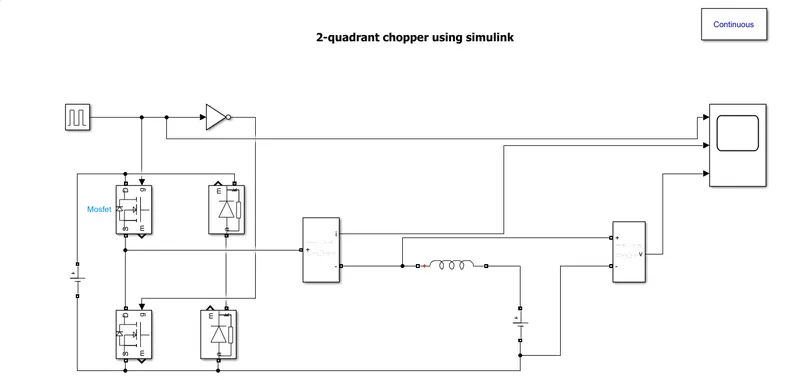
Let us take two mosfet blocks and diodes blocks and connect it as shown in circuit diagram.
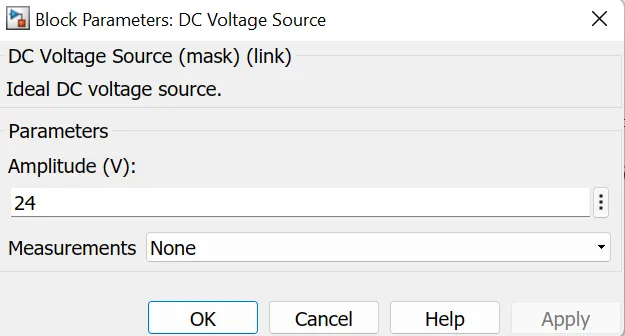
The dc voltage source is connected as shown.
Let the voltage of dc voltage source be 24 volts.
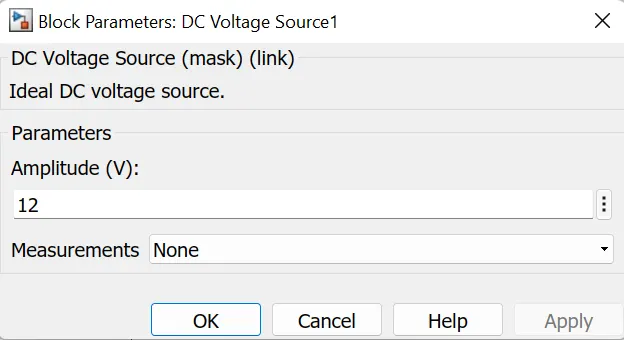
Let us consider an series RLC branch block and select inductor L, thus block works as a load.
To consider LE load ie motor load , and dc voltage source of 12 volt is also connected in series with inductor.
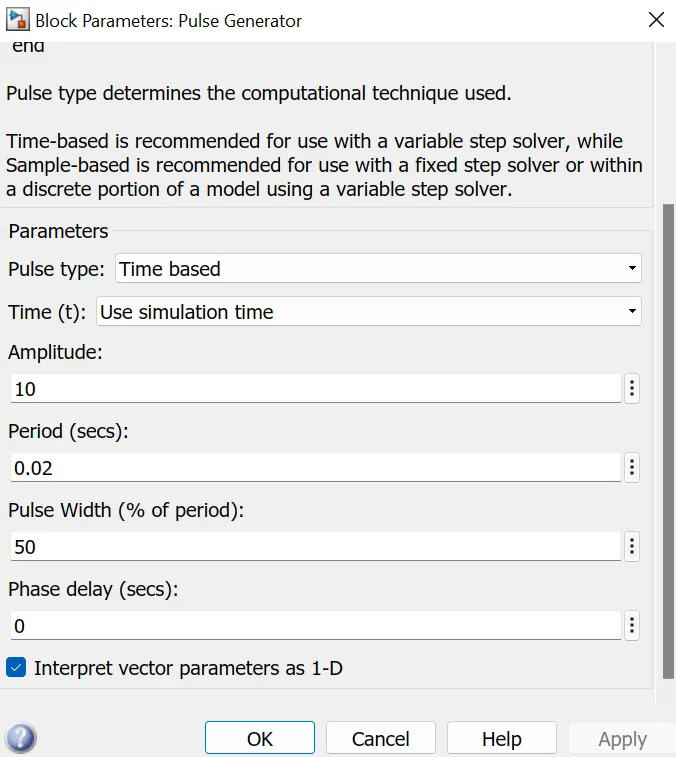
The pulse generator block is used to create gate pulse.
The not gate is used in the model so that the two mosfet will not get closed at the same time otherwise short circuit will occur due to use of not gate , when one mosfet is ON the other mosfet will get off and when other mosfet is ON the first mosfet will get off.
The amplitude of pulse generator is kept 10 so that we can clearly see the pulses at scope and let period be 0.02 seconds and let pulse width be 50%.
Result
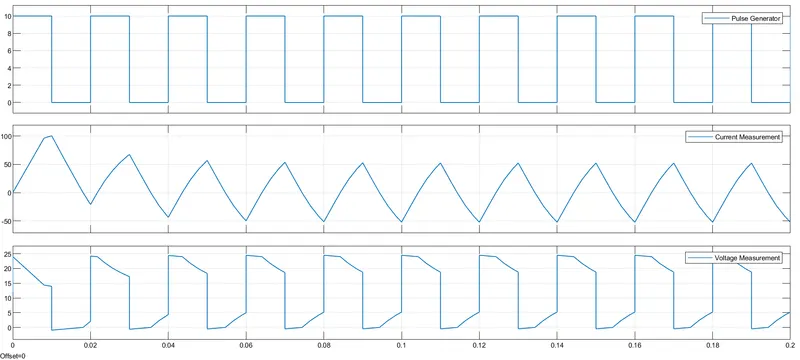
The voltage waveform is not going less than zero , the minimum value of voltage is zero and maximum value is always in the positive direction .However in current waveform, the current increases and decreases , the current may be positive as well as negative, and the pulse amplitude is 10 thus from pulse waveform we can see that the pulse amplitude is 10.
Simulink File:2 Quadrant Chopper Model
3. Explain in a brief about operation of BLDC motor.
Brushless DC motor
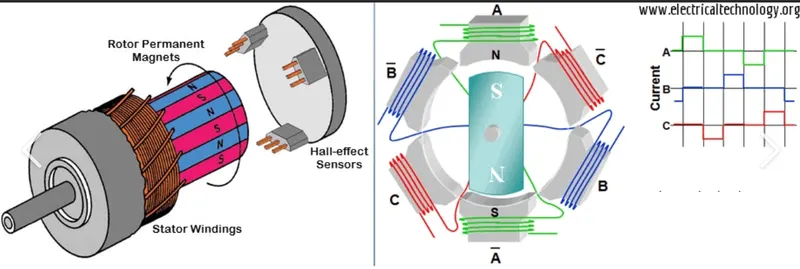
Brushless DC motors are common in industrial applications across the world. At the most basic level , there are brushed and brushless motors and there are DC and AC motors. Brushless DC motors , do not contain brushes and use a DC current. These types of motors are highly efficient in producing a large amount of torque over a vast speed range. In brushless motors , permanent magnets rotate around a fixed armature and overcome the problem of connecting current to the armature. Commutation with electronics has a large scope of capabilities and flexibility. They are known for smooth operation and holding torque when stationary. A Brushless DC motor has only two basic parts : the rotor and the stator. The rotor is the rotating part and has rotor magnets whereas the stator is the stationary part and contains stator windings. In BLDC permanent magnets are attached to the rotor and move the electromagnets to the stator. The high power transistors are used to activate electromagnets for the shaft turns. The controller performs power distribution by using a solid - state circuit.
Working Principle and Operation
BLDC motor works on a principle similar to that of a conventional DC motor , ie , the Faraday's law which states that whenever a current - carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force , the magnet will experience an equal and opposite force . In the case BLDC motor , the current - carrying conductor is stationary while the permanent magnet moves. When the stator coils are electrically switched by a supply source , it becomes an electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC , switching makes to generate an AC voltage waveform with a trapezoidal shape. Due to the force of interaction between the electromagnet stator and permanent magnet rotor , the rotor continues to rotate. Consider the figure below in which the motor stator is excited based on different switching states. With the switching of windings as High and low signals , corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles align with stator poles causing the motor to rotate. Observe that the motor produces torque because of the development of attraction forces ( when North - South or South - North alignment ) and repulsion forces ( when North - North or South - South alignment ) . In this way motor moves in a clockwise direction.
Advantages of Brushless DC Motor
The advantages of a BLDC motor are :
1. Brushless motors are more efficient as their velocity is determined by the frequency at which current is supplied , not the voltage .
2. As brushes are absent , the mechanical energy loss due to friction is less which enhanced efficiency .
3. BLDC motor can operate at high speed under any condition .
4. There is no sparking and much less noise during operation
5. More electromagnets could be used on the stator for more precise control .
6. BLDC motors accelerate and decelerate easily as they are having low rotor inertia .
7. It is a high - performance motor that provides large torque per cubic inch over a vast sped range .
8. BLDC motors do not have brushes which make them more reliable , high life expectancies , and maintenance free operation .
9. There are no ionizing sparks from the commutator , and electromagnetic interference is also get reduced .
10. Such motors cooled by conduction and no airflow are required for inside cooling .
Disadvantages of Brushless DC Motors
1. BLDC motor cost more than a brushed DC motor .
2. The limited high power could be supplied to the BLDC motor , otherwise , too much heat weakens the magnets and the insulation of winding may get damaged .