DC Motor Control by using transister simulink model.
Aim
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
2 Explain in a brief about the operation of Brushless D.C motor BLDC motor.
Objective-1
A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
A. Explanation of model 'Speed control of a DC motor using BJT H-bridge' with the details on armature current shoot-up.
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to square of speed). The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
The model below shows the simulation of an H-bridge used to generate a chopped voltage and to control the speed of a DC motor.
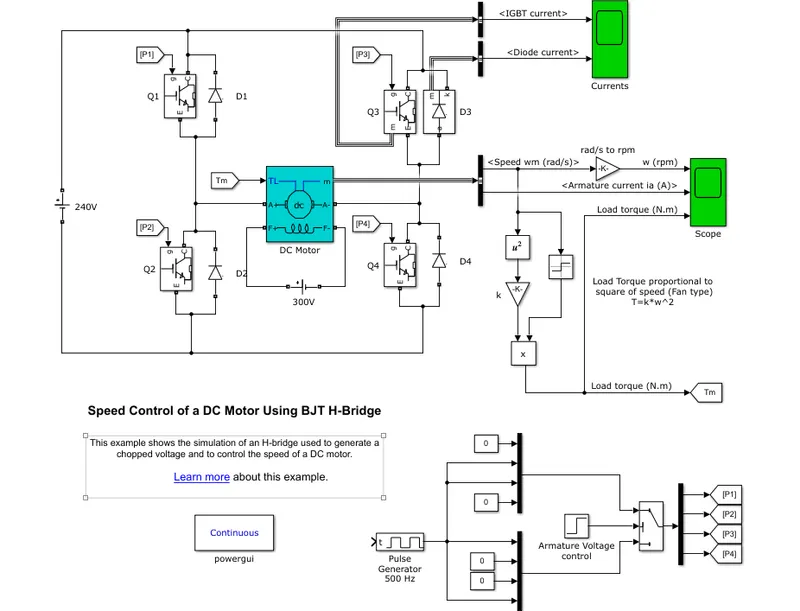
Here a block called pulse generator is used to generate pulses of certain magnitude which are fed to this system constituting of four IGBT to create pulse width modulation.
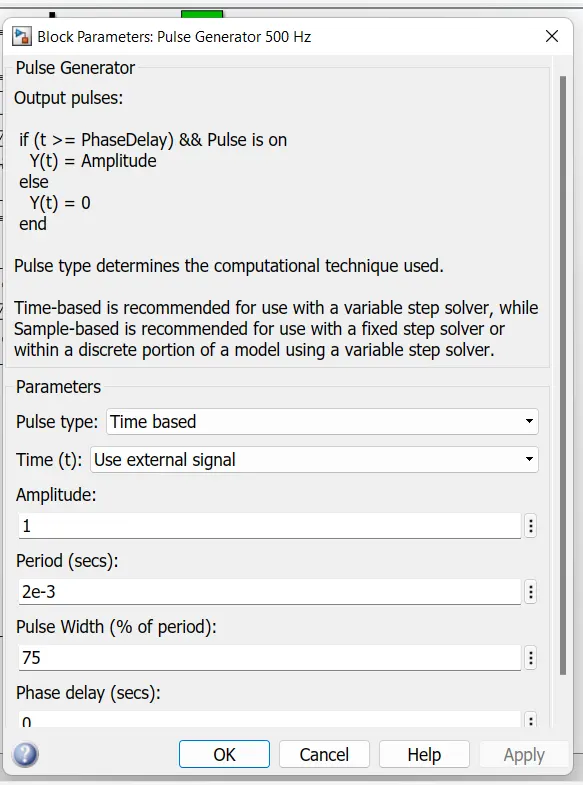
Case 1. In this case, we have taken the default parameters and the simulation is such that the motor starts rotating in a positive direction with the duty cycle of 75% with a mean voltage of 180V. The scope shows the motor speed, armature current, and load torque. Initially, the block parameters for the pulse generator are as follows
Result Explanation:
When we run the simulation for 1st case with keeping the parameters as default we get the following result in scope.
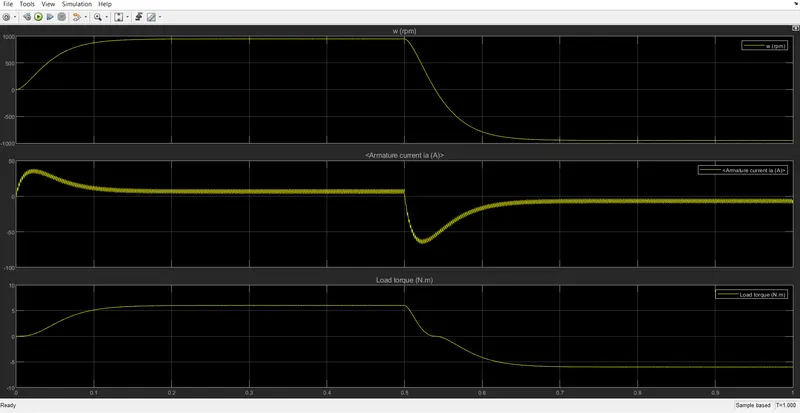
Here in the result above for the plot of current, we can observe that at 0.5 sec, the armature current is suddenly reversed and the motor runs in the negative direction. So, in the first half cycle, we can see that the motor attains a speed of 1000 RPM and a load torque of 6 Nm. Whereas, for the second half cycle the same values in the negative direction. Here we can see that the armature current of the DC motor does not shoot up.
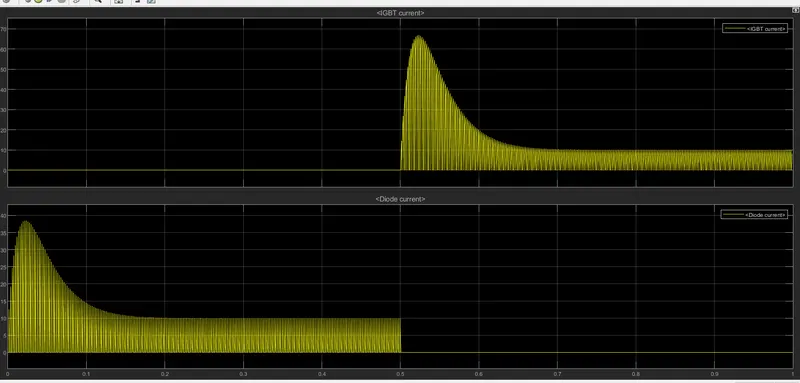
As per the frequency of the two transistors work on before and after 0.5 sec. During the initial stage, The anode diode current works after IGBT 0.5 sec, and vice versa current can work.
B. Comment on the armature current shoot-up from the scope results.
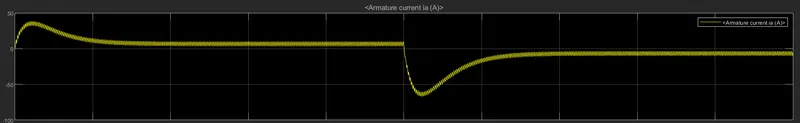
In that graph, it shows a sudden shoot-up when 0 sec the supply of electric current is started and after 0.5 sec suddenly it will fall down to -60 (negative energy ) because of the sudden breaking, and the motor will rotate in the reverse direction and produce some current through the regenerative braking. so that current values can be shown in this fig. after a sudden fall it comes to a constant 0.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
Description
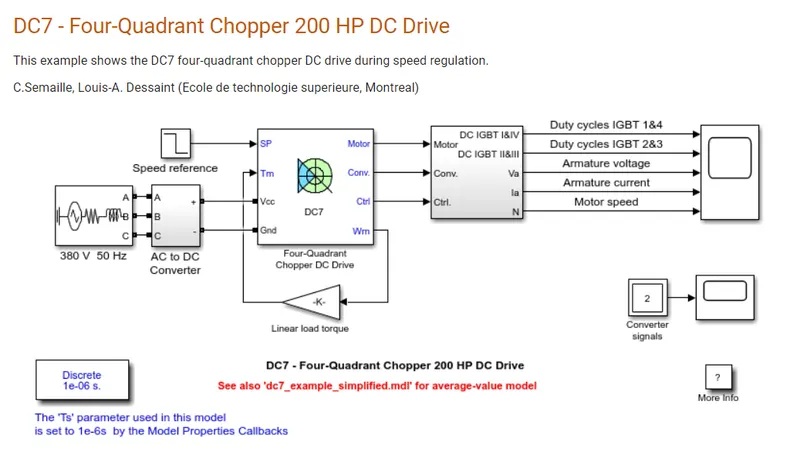
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system. The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
Simulation:
- Before starting the simulation, set the initial bus voltage to 515 V via the GUI block ('The Initial States Setting' button and 'Cbus' variable).
- Start the simulation. You can observe the motor armature voltage and current, the four IGBT pulses, and the motor speed on the scope. The current and speed references are also shown.
- The motor is coupled to a linear load, which means that the mechanical torque of the load is proportional to the speed.
- The speed reference is set at 500 rpm at t = 0 s. Observe that the motor speed follows the reference ramp accurately (+400 rpm/s) and reaches steady-state around t = 1.3 s.
- The armature current follows the current reference very well, with a fast response time and small ripples. Notice that the current ripple frequency is 5 kHz.
- At t = 2 s, the speed reference drops to -1184 rpm. The current reference decreases to reduce the electromagnetic torque and causes the motor to decelerate with the help of the load torque.
- At t = 2.2 s, the current reverses in order to produce a braking electromagnetic torque (dynamic braking mode). This causes the DC bus voltage to increase.
- At t = 3.25 s, the motor reaches 0 rpm and the load torque reverses and becomes negative. The negative current now produces an accelerating electromagnetic torque to allow the motor to follow the negative speed ramp (-400 rpm/s). At t = 6.3 s, the speed reaches -1184 rpm and stabilizes around its reference.
Comparison of Four Quadrant Chopper DC Drive(DC7) with BJT H bridge
- In the four-quadrant chopper DC drive model, the speed reference input is used to change the direction of the motor rotation whereas in the BJT H-bridge model, the polarity is reversed across the terminals of the motor with respect to the battery, to change the direction of the motor rotation.
- In a four-quadrant chopper, the speed reference values are changed to control the speed of the motor whereas, in BJT H-bridge the speed of the motor is controlled by varying the with of the pulse in the pulse generator.
- The four-quadrant chopper DC drive operates in four-mode i.e, forward motoring, forward regenerative braking, reverse motoring and reverse regenerative braking whereas, the BJT H- bridge only operates in two modes i.e, forward and reverse.
- PI (Proportional) controllers are used for speed and current control in DC7 and it is absent in BJT H- bridge.
- The four-quadrant chopper uses ramps to avoid current shoot up and smooth working and stability.
- The disturbances and current shoot-up is low in DC7 whereas for BJT the shoot-up is high because of switching losses.
- Due to the high switching frequency in the four-quadrant chopper (DC-DC converters), a low armature current is obtained.
- This why the overall performance and stability is good in Four Quadrant Chopper DC Drive as compared to BJT H- bridge model.
- The only disadvantage is due to its complexity as it consists of four switching devices.
2. Explain in a brief about operation of BLDC motor.
A BLDC or Brushless DC motor is a permanent magnet sychronous electric motor which is driven by direct current and it comprises of electronically controlled commutation system (commutation is the process of producing rotational torque in the motor by changing the phase current through it at appropriate synch time) instead of mechanical commutation system. BLDC motors are also referred as trapezoidal magnet motors.
Unlike convetional brushed type DC motor, where in the brushes makes the mechanical contact with commutator on the rotor so to form an electrical path between a DC electric source and rotor armature winding, BLDC employs electrical commutation with permanent magnet rotor and a stator with sequence of coils. In this motor, generally permanent magnet (or field poles) rotates and current carrying coil (conductors) are fixed. So, BLDCM are superior to brushed DC motor as it has the ability to operate at high speed, high efficiency and better dissipation.
Thy are an indispendable part of modern drive technology, most commonly employed for actuating drives, machine tools, electric propulsion system, robotics, computer peripherals and also for electrical power generation.
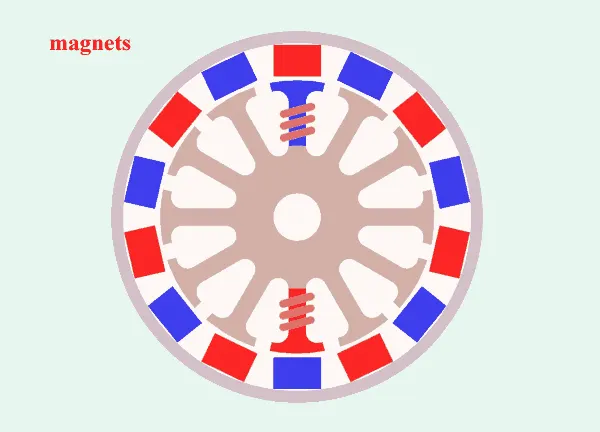
The layout of a DC brushless motor cn vary depending on wheather it is an 'Outrunner' or 'Inrunner' style.
- Outrunner- In outunner type BLDCM the field magnet is a drum rotor which rotates around the stator. This style is preferred for applications that requires high torque and where high speed of motor is not required.
- Inrunner- In inrunner type BLDCM the stator is a fixed drum in which the field magnet rotates inside, inside the rotor. This style is usually preferred for applications that requires less torque and is capable of spinning at high speed.
But the basic fundamental principle for both type of BLDC motor is same. The images for inrunner and outrunner type BLDC motor is given below.
BLDC motor works on the principle similar to that of a brushed DC motor which is based on the Lorentz force law which states that whenever a current carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In the BLDC motor, the current carrying conductor is stationary and the permanent magnet is moving.
Construction of BLDC
BLDC motors can be constructed in different physical configurations. Depending on the stator windings, these can be configured as single-phase, two-phase, or three-phase motors. However, three-phase BLDC motors with permanent magnet rotor are most commonly used. The construction of this motor has many similarities of three phase induction motor as well as conventional DC motor. This motor has stator and rotor parts as like all other motors.
1. Stator- Stator of a BLDC motor made up of stacked steel laminations to carry the windings. These windings are placed in slots which are axially cut along the inner periphery of the stator. These windings can be arranged in either star or delta. However, most BLDC motors have three phase star connected stator.
Similar to an Induction AC motor, the BLDC motor stator is made out of laminated steel stacked up to carry the windings. Windings in a stator can be arranged in two patterns; i.e. a star pattern (Y) or delta pattern (∆). The major difference between the two patterns is that the Y pattern gives high torque at low RPM and the ∆ pattern gives low torque at low RPM. This is because in the ∆ configuration, half of the voltage is applied across the winding that is not driven, thus increasing losses and, in turn, efficiency and torque.
Each winding is constructed with numerous interconnected coils, where one or more coils are placed in each slot. In order to form an even number of poles, each of these windings is distributed over the stator periphery. The stator must be chosen with the correct rating of the voltage depending on the power supply capability. For robotics, automotive and small actuating applications, 48 V or less voltage BLDC motors are preferred. For industrial applications and automation systems, 100 V or higher rating motors are used.Steel laminations in the stator can be slotted or slotless as shown in Figure 2. A slotless core has lower inductance, thus it can run at very high speeds. Because of the absence of teeth in the lamination stack, requirements for the cogging torque also go down, thus making them an ideal fit for low speeds too (when permanent magnets on rotor and tooth on the stator align with each other then, because of the interaction between the two, an undesirable cogging torque develops and causes ripples in speed). The main disadvantage of a slotless core is higher cost because it requires more winding to compensate for the larger air gap.
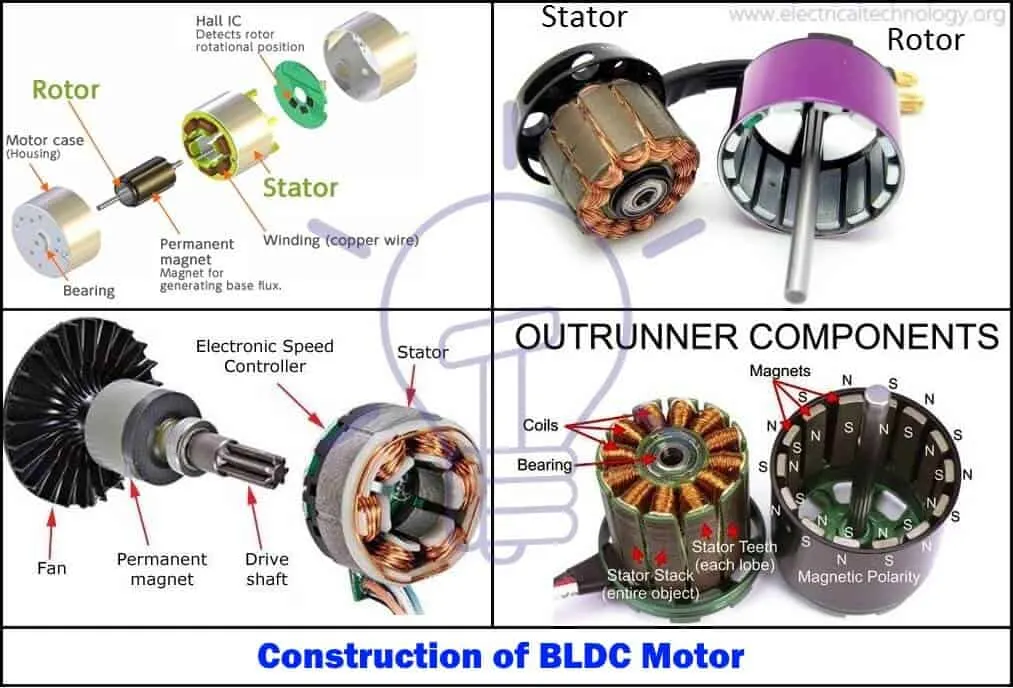
2. Rotor- BLDC motor incorporates a permanent magnet in the rotor. The number of poles in the rotor can vary from 2 to 8 pole pairs with alternate south and north poles depending on the application requirement. In order to achieve maximum torque in the motor, the flux density of the material should be high. A proper magnetic material for the rotor is needed to produce required magnetic field density. The rotor of a typical BLDC motor is made out of permanent magnets. Depending upon the application requirements, the number of poles in the rotor may vary. Increasing the number of poles does give better torque but at the cost of reducing the maximum possible speed. Another rotor parameter that impacts the maximum torque is the material used for the construction of permanent magnet; the higher the flux density of the material, the higher the torque.Ferrite magnets are inexpensive, however they have a low flux density for a given volume. Rare earth alloy magnets are commonly used for new designs. Some of these alloys are Samarium Cobalt (SmCo), Neodymium (Nd), and Ferrite and Boron (NdFeB). The rotor can be constructed with different core configurations such as the circular core with permanent magnet on the periphery, circular core with rectangular magnets, etc.
3. Hall Sensors- Hall sensor provides the information to synchronize stator armature excitation with rotor position. Since the commutation of BLDC motor is controlled electronically, the stator windings should be energized in sequence in order to rotate the motor. Before energizing a particular stator winding, acknowledgment of rotor position is necessary. So the Hall Effect sensor embedded in stator senses the rotor position.Most BLDC motors incorporate three Hall sensors which are embedded into the stator. Each sensor generates Low and High signals whenever the rotor poles pass near to it. The exact commutation sequence to the stator winding can be determined based on the combination of these three sensor’s response.
Working Principles and Operation of BLDC:
BLDC motor works on the principle similar to that of a conventional DC motor, i.e., the Lorentz force law which states that whenever a current carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In case BLDC motor, the current carrying conductor is stationary while the permanent magnet moves.
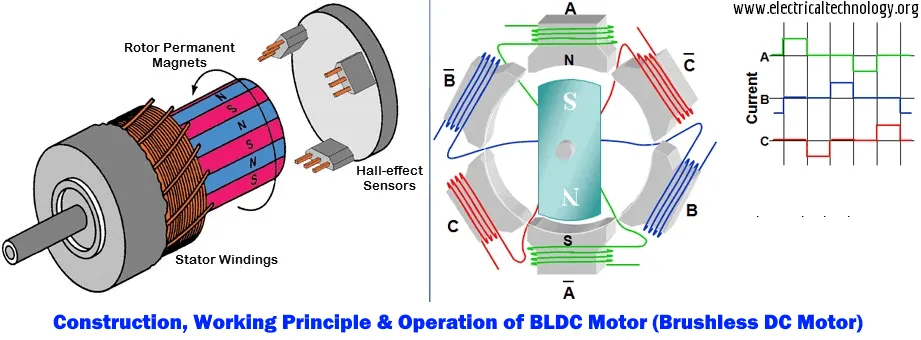
When the stator coils are electrically switched by a supply source, it becomes electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC, switching makes to generate an AC voltage waveform with trapezoidal shape. Due to the force of interaction between electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
Consider the figure below in which motor stator is excited based on different switching states. With the switching of windings as High and Low signals, corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles align with stator poles causing motor to rotate.
Observe that motor produces torque because of the development of attraction forces (when North-South or South-North alignment) and repulsion forces (when North-North or South-South alignment). By this way motor moves in a clockwise direction.
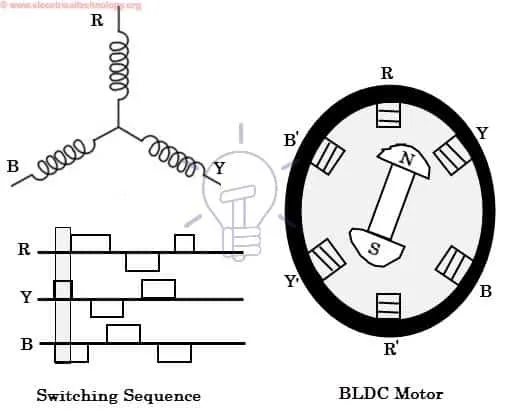
Here, one might get a question that how we know which stator coil should be energized and when to do. This is because; the motor continuous rotation depends on the switching sequence around the coils. As discussed above that Hall sensors give shaft position feedback to the electronic controller unit.
Based on this signal from sensor, the controller decides particular coils to energize. Hall-effect sensors generate Low and High level signals whenever rotor poles pass near to it. These signals determine the position of the shaft.
Advantages of BLDC Motor
BLDC motor has several advantages over conventional DC motors and some of these are
- It has no mechanical commutator and associated problems
- High efficiency due to the use of permanent magnet rotor
- High speed of operation even in loaded and unloaded conditions due to the absence of brushes that limits the speed
- Smaller motor geometry and lighter in weight than both brushed type DC and induction AC motors
- Long life as no inspection and maintenance is required for commutator system
- Higher dynamic response due to low inertia and carrying windings in the stator
- Less electromagnetic interference
- Quite operation (or low noise) due to absence of brushes
Disadvantages of Brushless Motor
- These motors are costly
- Electronic controller required control this motor is expensive
- Not much availability of many integrated electronic control solutions, especially for tiny BLDC motors
- Requires complex drive circuitry
- Need of additional sensors