Week-7 Challenge: DC Motor Control
Aim:
- Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor changes direction from forward to reverse.
- Compare the 'Four-Quadrant Chopper DC Drive (DC7) block' with H-bridge model.
- Make a suitable EV model using DC7 block and make result report.
Software used:
- MATLAB R2020a
1. Speed control of a DC motor using BJT H-bridge:
Inputs:
- Total cycle time: 1 sec
- Forward Motering time: 0.5 sec
- Reverse Motering time: 0.5 sec
- Battery Voltage: 240 V
- Duty cycle: 75%
- Moter supply voltage = Duty cycle * Battery Voltage = 180 V
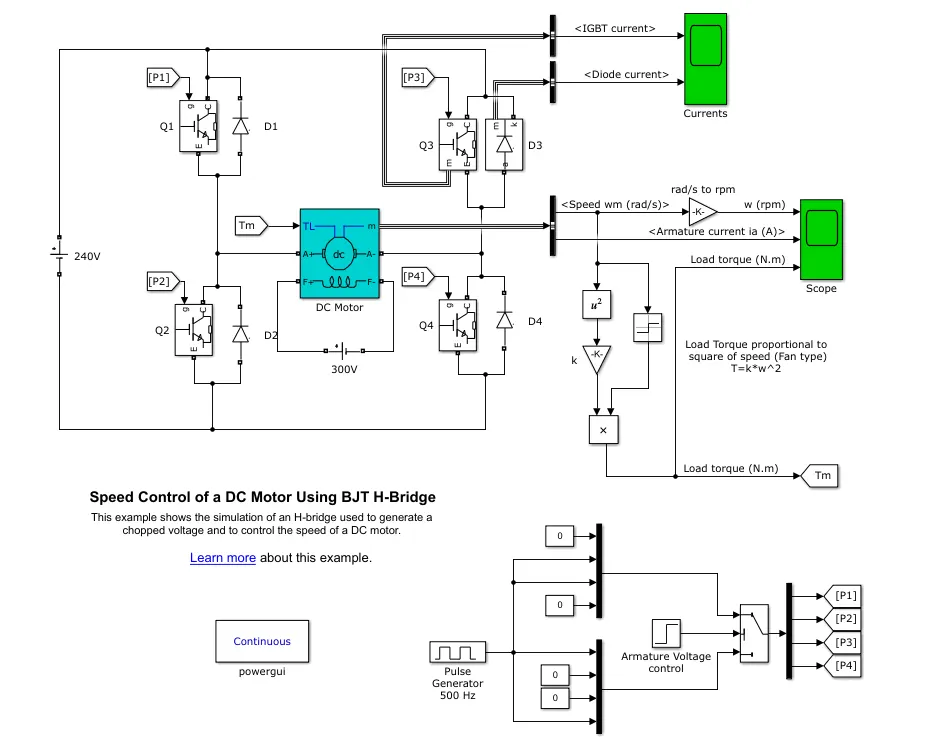
Description:
- The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
- The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to square of speed). The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
- The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
Simulation:
- The motor starts in the positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t= 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction.
- 'Scope' shows motor speed, armature current and load torque and 'Currents' shows currents flowing in BJT Q3 and diode D3.
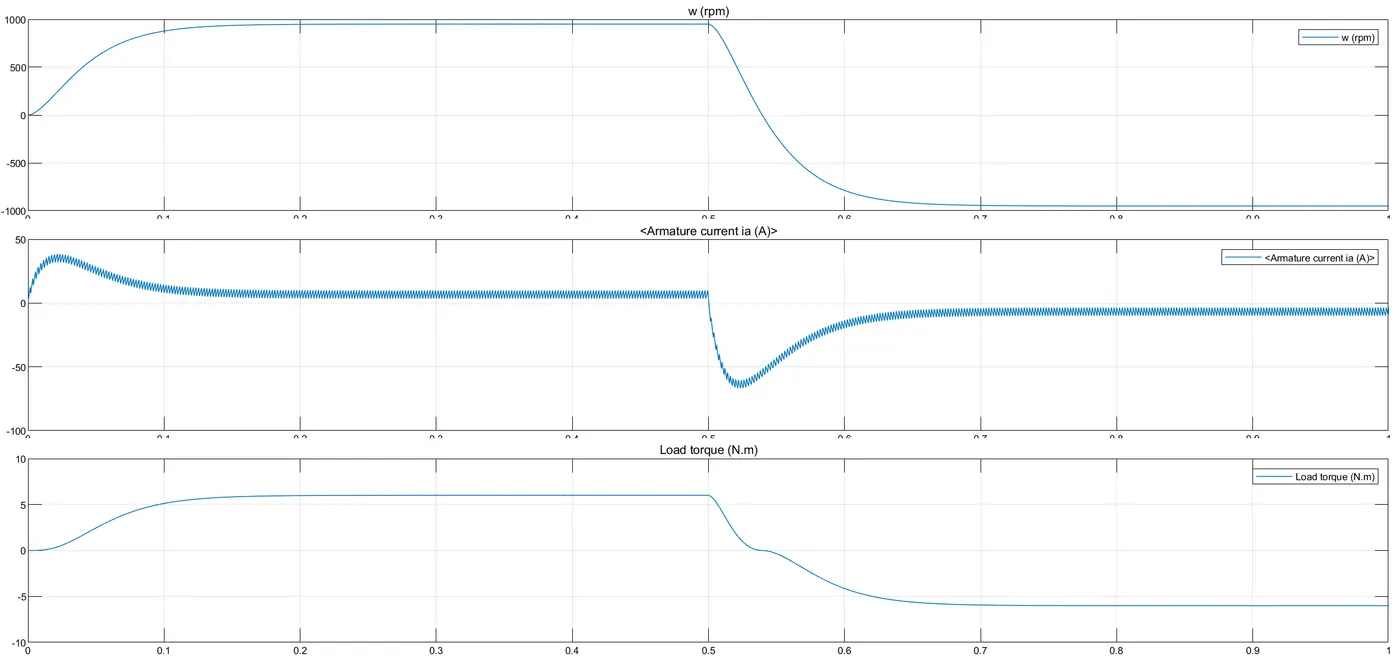
- Here we can see by running the simulation at 75% duty cycle, the Armature current is shooted up in both forward and reverse direction.
Simulation_2:
Modifying the armature current:
- Simulating with 40% Duty cycle.
- Moter supply voltage = Duty cycle * Battery Voltage = 96 V
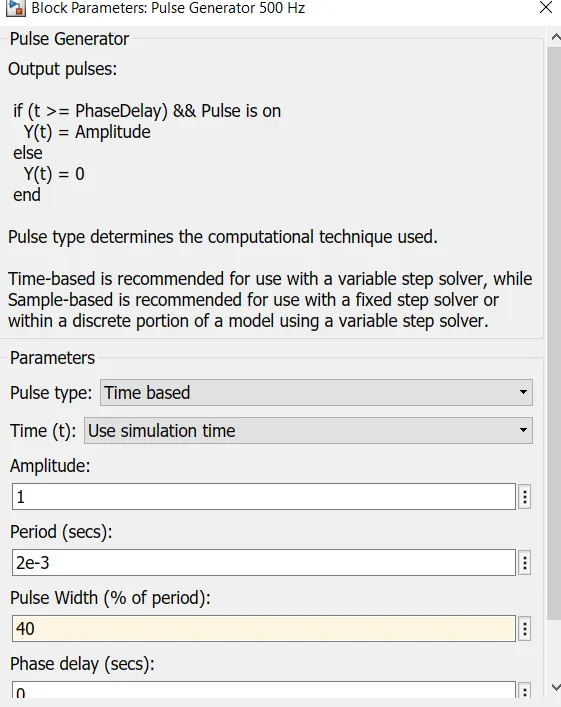
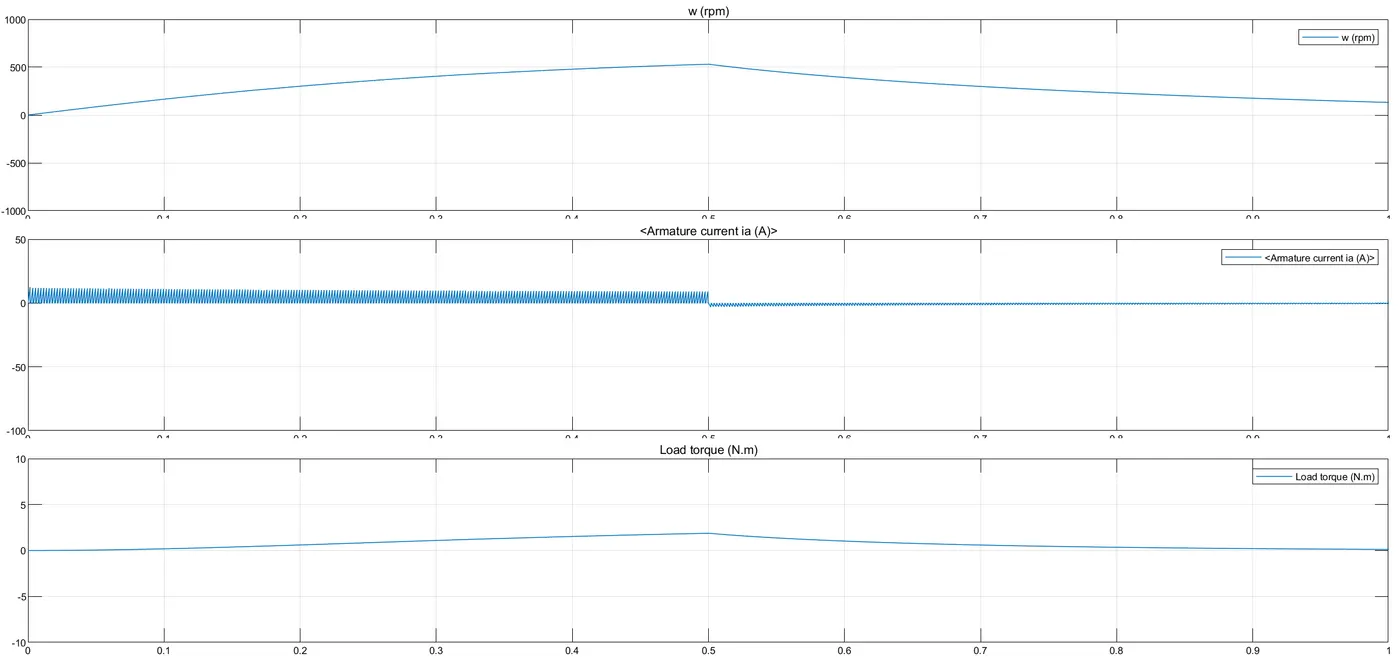
- By changing the duty cycle to 40% the Armature current is doesn’t shoot up when motor changes direction from forward to reverse.
2. The Four-Quadrant Chopper DC Drive (DC7) block:
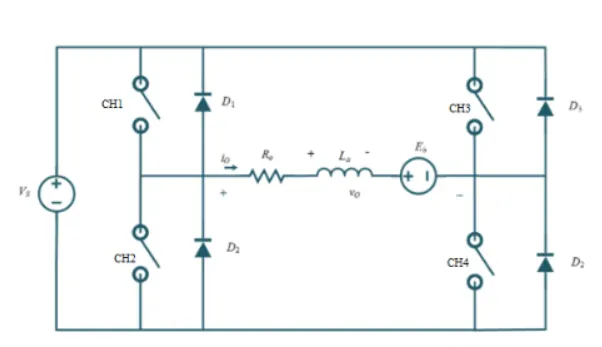
Fig: Type E class chopper
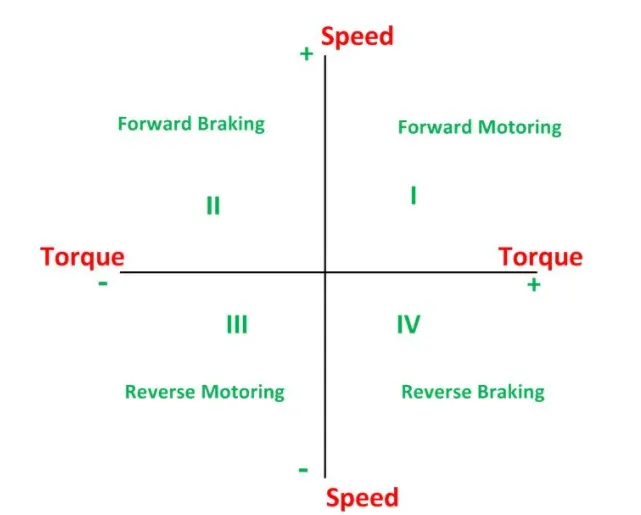
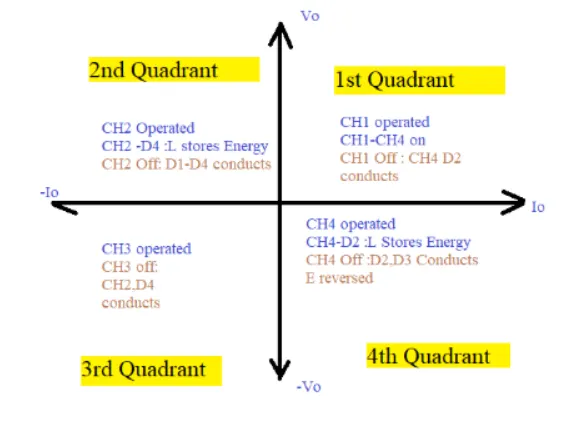
| Function | Quadrant | Speed | Torque | Power Output |
|---|---|---|---|---|
| Forward Motoring | I | + | + | + |
| Forward Braking | II | + | - | - |
| Reverse Motoring | III | - | - | + |
| Reverse Braking | IV | - | + | - |
Inputs:
- Phase to phase Voltage = 380 V
- Frequency = 50 Hz
- Phase angle of phase A (degrees) = 0
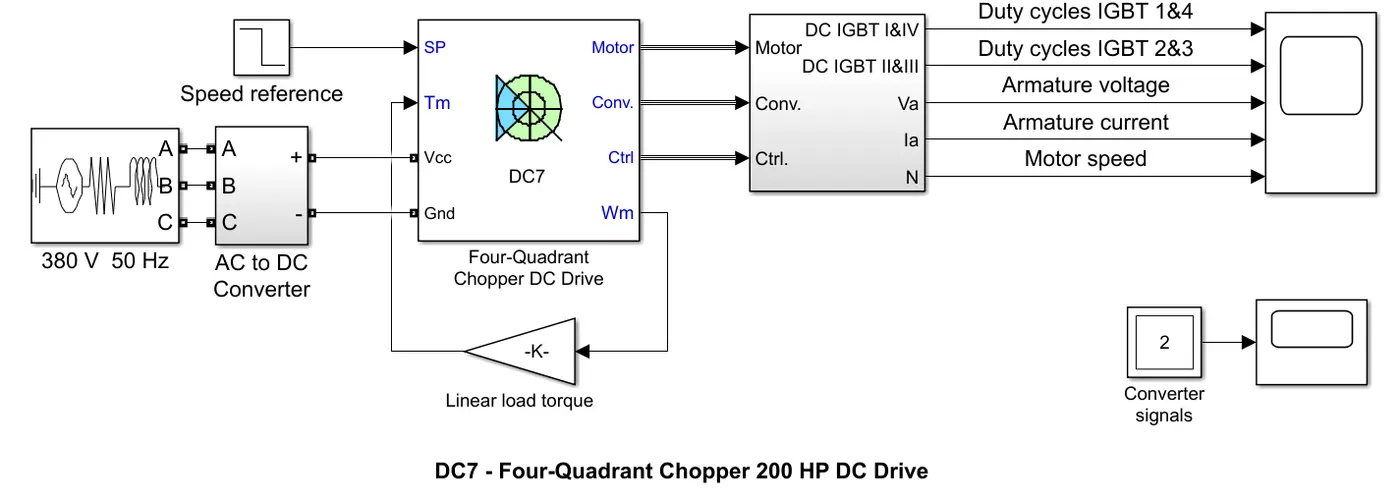
Description:
- The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
- The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system. The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
Simulation:
- Before starting the simulation, set the initial bus voltage to 515 V via the GUI block ('Initial States Setting' button and 'Cbus' variable).
- Start the simulation. You can observe the motor armature voltage and current, the four IGBT pulses and the motor speed on the scope. The current and speed references are also shown.
- The motor is coupled to a linear load, which means that the mechanical torque of the load is proportional to the speed.
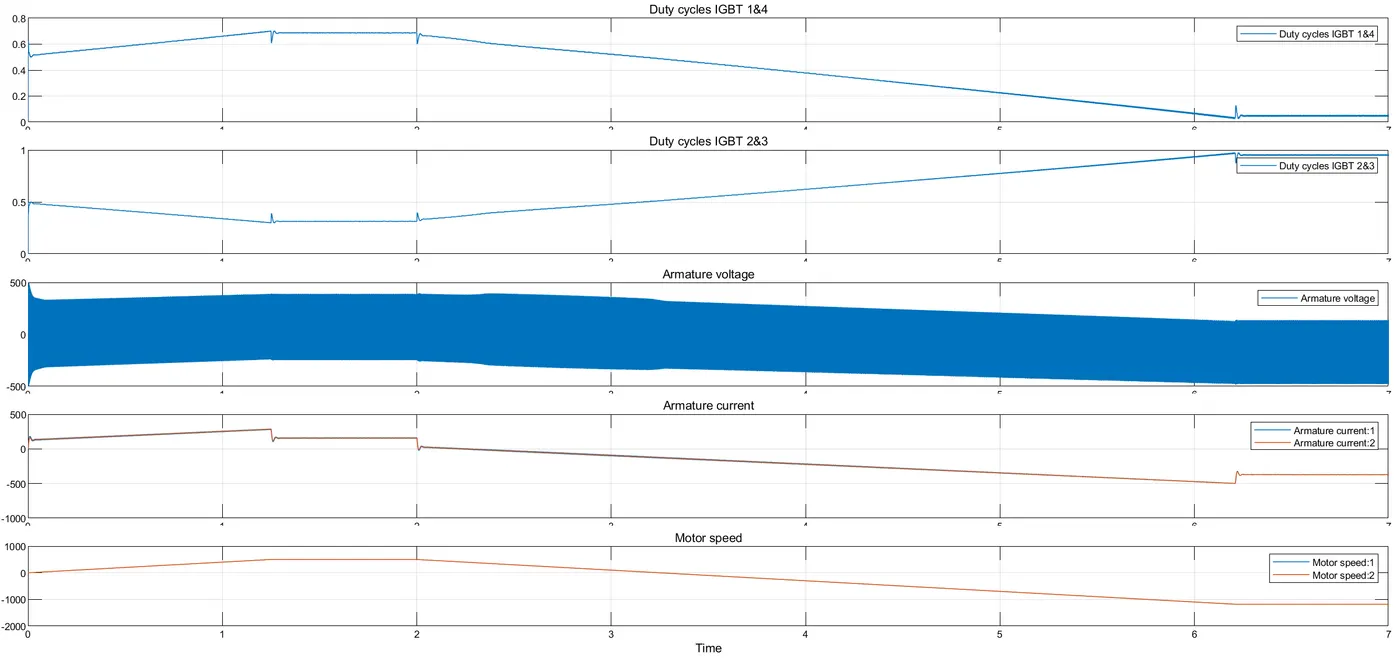
- At t = 2 s, speed reference drops to -1184 rpm. The current reference decreases to reduce the electromagnetic torque and causes the motor to decelerate with the help of the load torque.
- At t = 2.2 s, the current reverses in order to produce a braking electromagnetic torque (dynamic braking mode). This causes the DC bus voltage to increase.
- At t = 3.25 s, the motor reaches 0 rpm and the load torque reverses and becomes negative. The negative current now produces an accelerating electromagnetic torque to allow the motor to follow the negative speed ramp (-400 rpm/s). At t = 6.3 s, the speed reaches -1184 rpm and stabilizes around its reference.
Results:
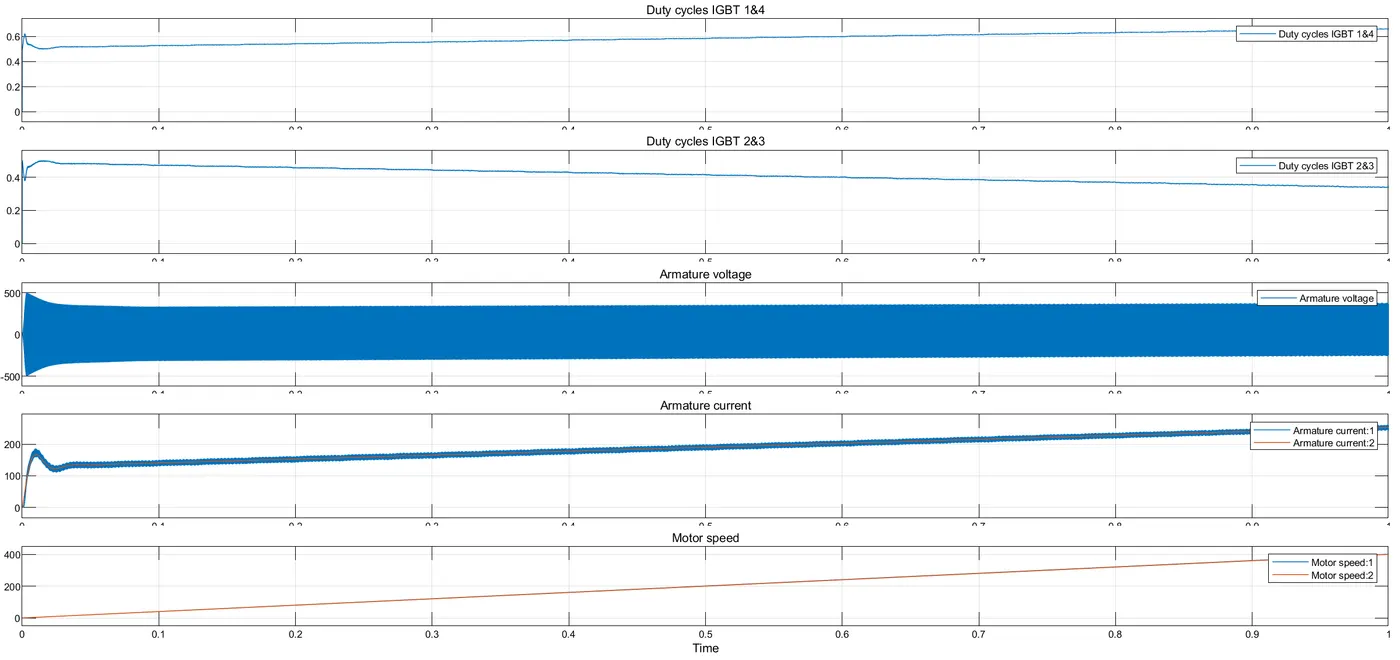
- When cycle run for 1 sec:
- When cycle run for 7 sec:
Comparsion of 'Four-Quadrant Chopper DC Drive (DC7) block' with H-bridge model:
- In H-Bridge we need to reverse the polarity to change the direction but in Four-Quadrant Chopper DC Drive it uses reference speed to change the direction of motor rotation.
- PI controller is used for speed and current control in Four-Quadrant Chopper DC Drive is absent.
- The current shoot-up and distribution is high in H-Bridge because of the switching looses.
- In the H-Bridge can perform only the Forward & Reverse motering. Where as in the Four-Quadrant Chopper DC Drive operates in 4 modes, Forward & Reverse Motering and Forward & Reverse Braking.
- Rgenerative braking is possible in Four-Quadrant Chopper DC Drive, where H-Bridge cannot.
3. EV model using DC7 block:
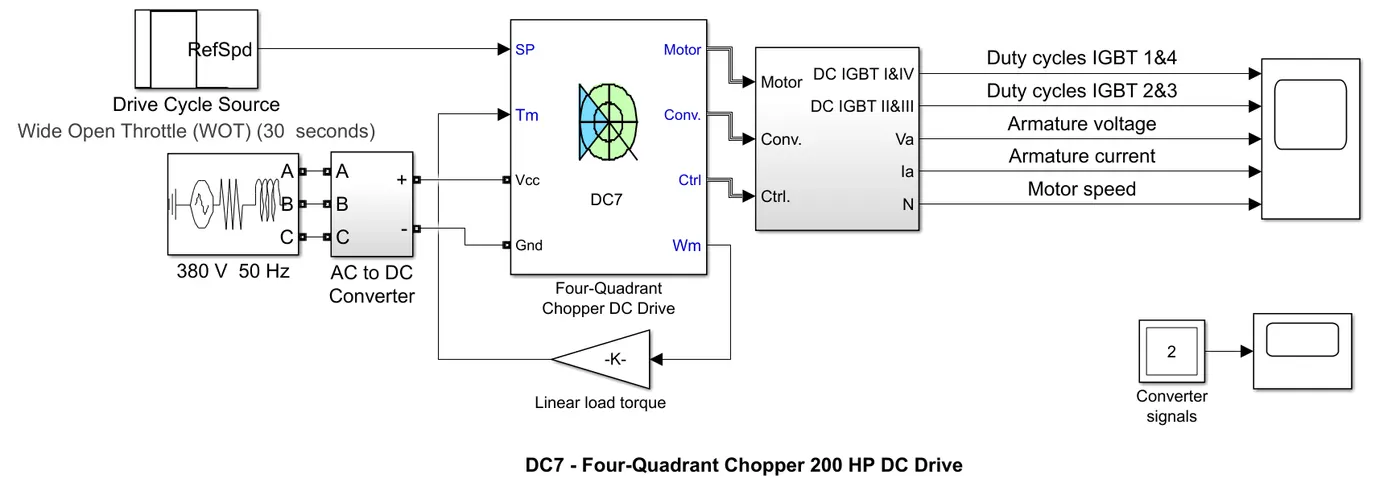
- Created a EV model with WOT Drive cycle
Inputs
- Battery Voltage = 380 V
- Frequency = 50 Hz
- Phase angle of phase A (degrees) = 0
- Drive Cycle = WOT
Results:
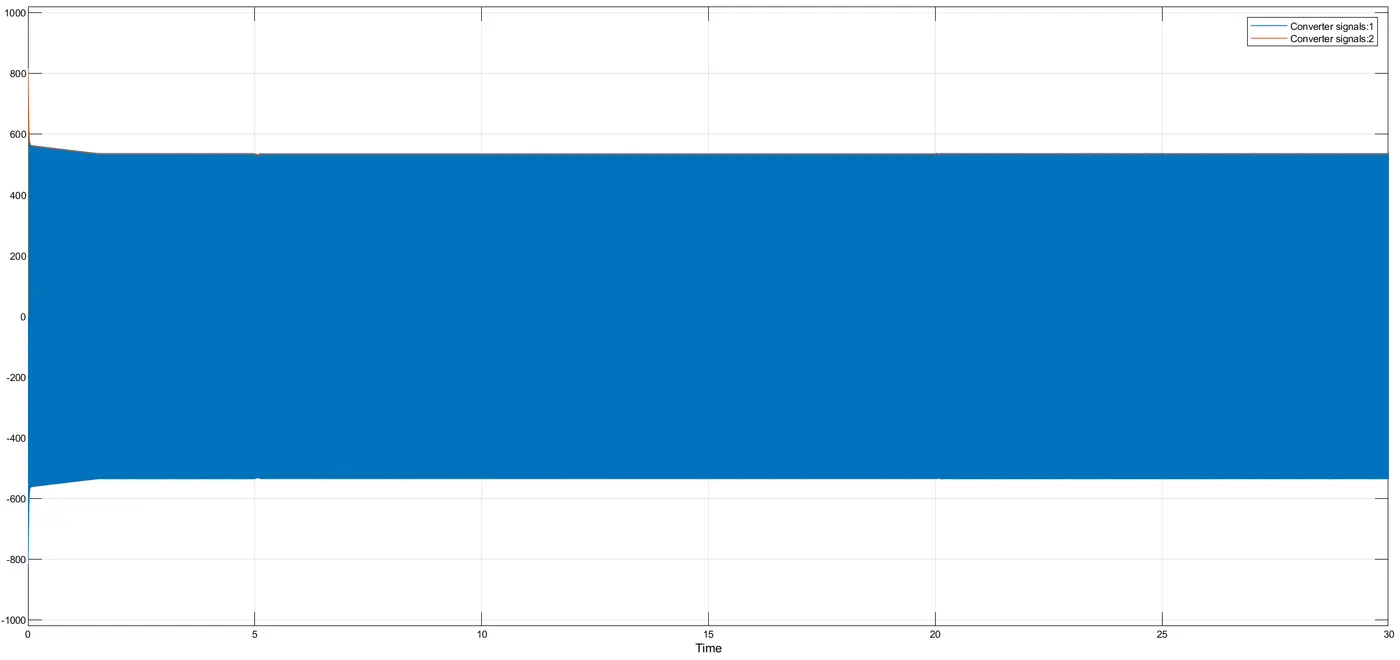
- After running the simulation to 30 sec the below graphs (Duty cycle IGBT 1&4, Duty cycle IGBT 2&3, Armature Voltage, Armature Current and Motor speed) are plotted.
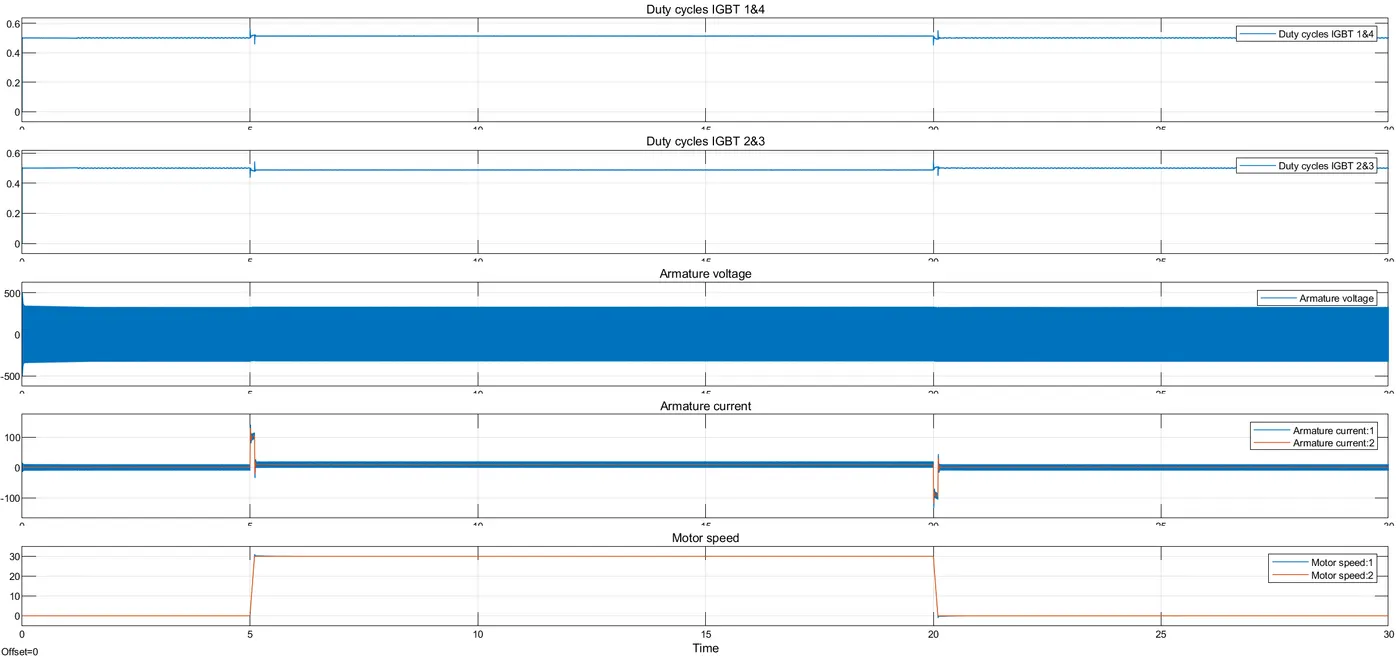
- Converter Signals
- Hence Created a EV model using DC7 block.