Week-7 Challenge: DC Motor Control
WEEK – 7
DC MOTOR CONTROL
QUESTIONS:
- A) Explain a MATLAB demo model named ‘Speed control of DC motor using BJT H- Bridge’.
Answer:
H-bridge:
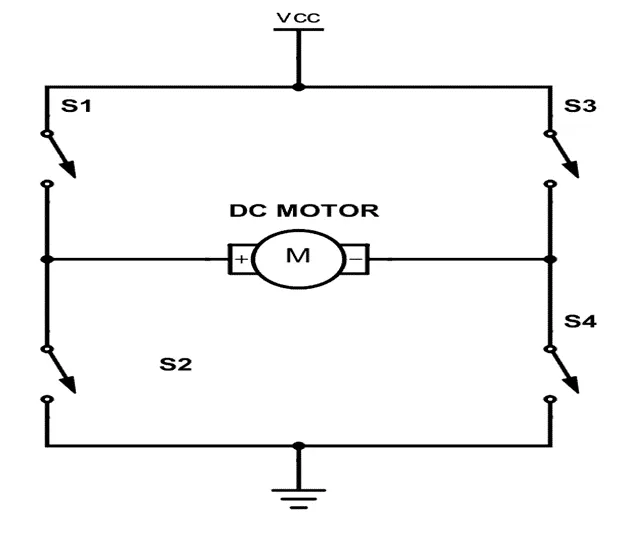
An H-bridge is a simple circuit that lets you control a DC motor to go backward or forward. You normally use it with a microcontroller, such as an Arduino, to control motors.
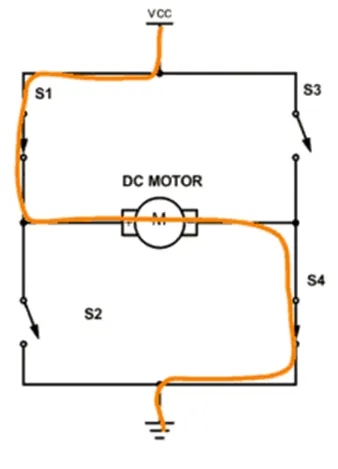
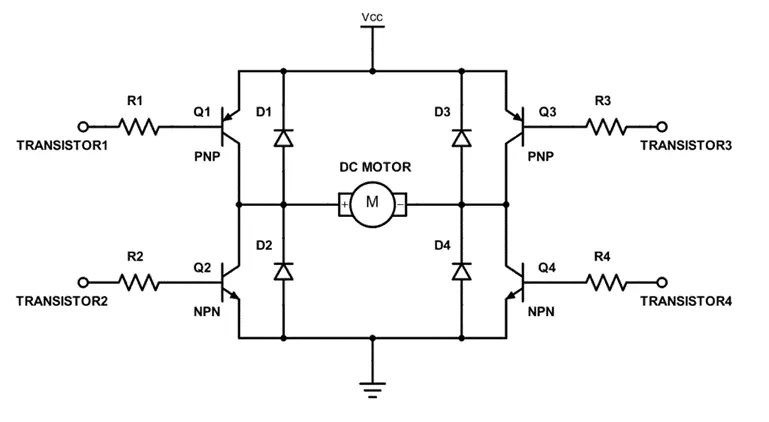
A DC motor spins either backward or forward, depending on how you connect the plus and the minus. If you close switch 1 and 4, you have plus connected to the left side of the motor and minus to the other side. And the motor will start spinning in one direction.
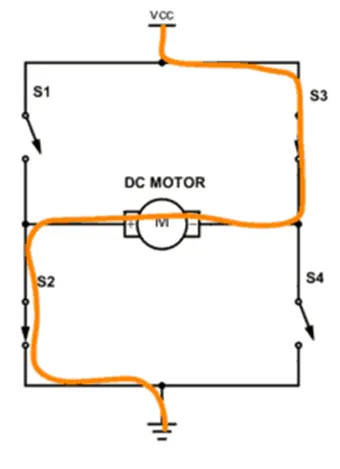
If you instead close switch 2 and 3, you have plus connected to the right side and minus to the left side. And the motor spins in the opposite direction.
The H-Bridge circuit
You can build an H-bridge with four transistors. The transistor can work as a switch that you can open and close with the voltage on the base.
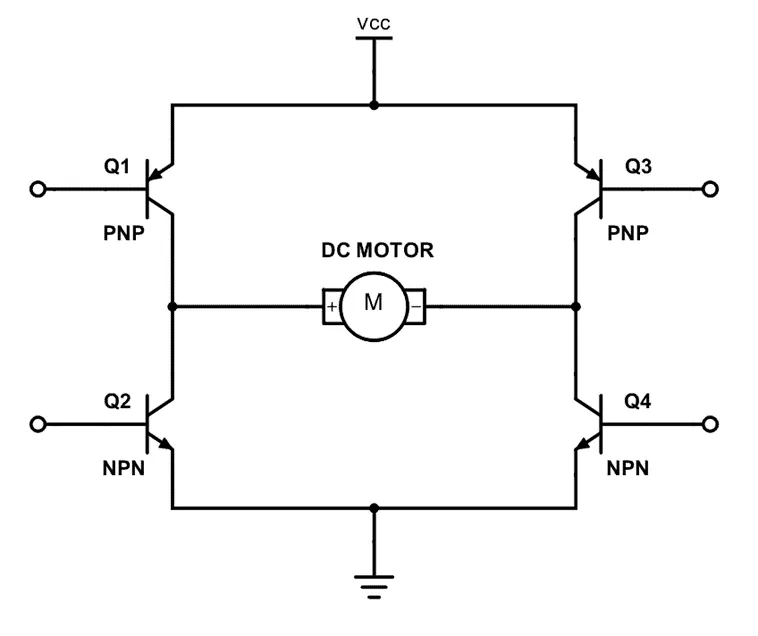
Since the transistor can be a switch, you’ll be able to make the motor spin in either direction by turning on and off the four transistors in the circuit above. A side-effect of how a motor works is that the motor will also generate electrical energy. When you disable the transistors to stop running the motor, this energy needs to be released on some way. If you add diodes in the reverse direction for the transistors, you give a path for the current to take to release this energy. Without them, you risk that the voltage rises and damages your transistors.
Matlab model:
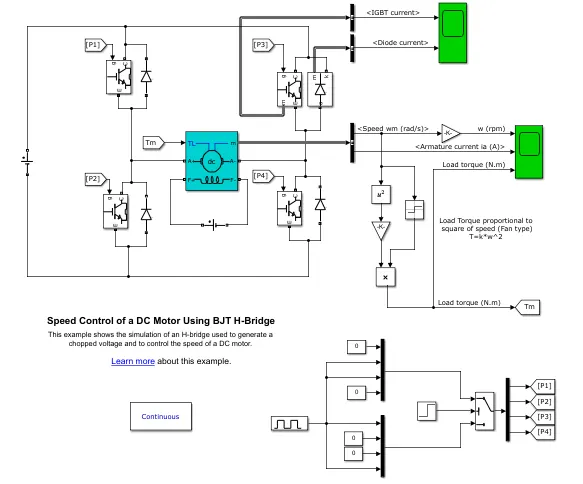
Above figure is consist of dc motor, igbt and diodes. The PWM signal generate to the igbt. The igbt connected to Motor Armature. The switches (igbt) operate to the PWM signal. The PWM signal control, then Motor change in direction forward and Reverse.
Results:
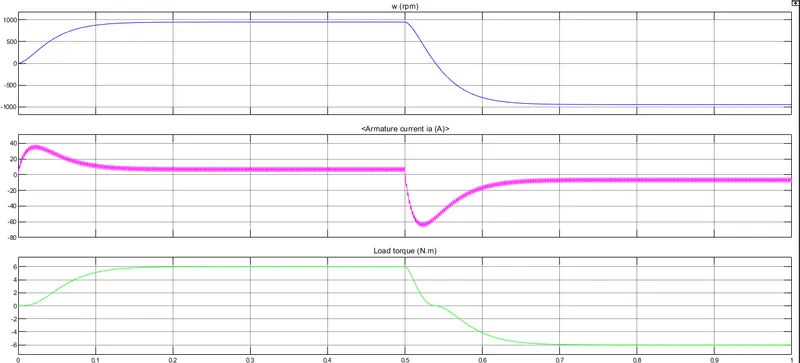
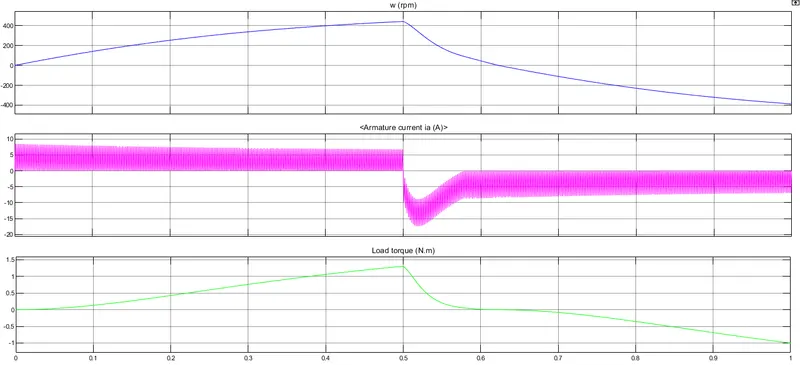
The PWM signal change the pulse width and also changes the motor direction. The change of PWM signal are 75%, 99%, and 50% below the figure. The change pulse width Below 70% motor operate the reverse Directions and above 70% motor operate Forward direction. The PWM signal changes corresponding to the Motor output are speed and torque also changes.
- B) Comment on the armature current shoot-up from the scope results.
The armature current doesn’t shoot-up when motor changes direction from forward and reverse. The motor forward and reverse achieved by a pulse generator. Thus pluse generator width changes then motor will change to Forward and reverse condition. Example of pulse width less than 99% the motor running to forward and pulse width greater than 60 motor run to the reverse directions.
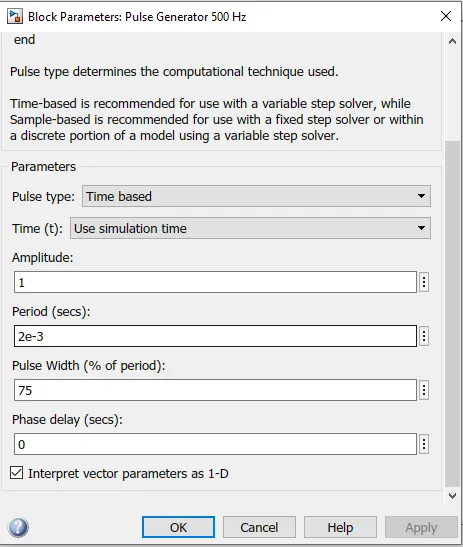
Figure shows the pulse generator.
- C) Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
Answer:
Four-Quadrant Chopper:
Four Quadrant Operation of any drives or DC Motor means that the machine operates in four quadrants. They are Forward Braking, Forward motoring, Reverse motoring and Reverse braking.
A motor operates in two modes – Motoring and Braking. A motor drive capable of operating in both directions of rotation and of producing both motoring and regeneration is called a Four Quadrant variable speed drive.
In motoring mode, the machine works as a motor and converts the electrical energy into mechanical energy, supporting its motion. In braking mode, the machine works as a generator and converts mechanical energy into electrical energy and as a result, it opposes the motion. The Motor can work in both, forward and reverse directions, i.e., in motoring and braking operations.
The product of angular speed and torque is equal to the power developed by a motor. For the multi-quadrant operation of drives, the following conventions about the signs of torque and speed are used. When the motor is rotated in the forward direction the speed of the motor is considered positive. The drives which operate only in one direction, forward speed will be their normal speed.
In loads involving up and down motions, the speed of the motor which causes upward motion is considered to be in forward motion. For reversible drives, forward speed is chosen arbitrarily. The rotation in the opposite direction gives reverse speed which is denoted by a negative sign.
The rate of change of speed positively in the forward direction or the torque which provides acceleration is known as Positive motor torque. In the case of retardation, the motor torque is considered negative. Load torque is opposite to the positive motor torque in the direction.
Operation:
The figure below shows the four-quadrant operation of drives:
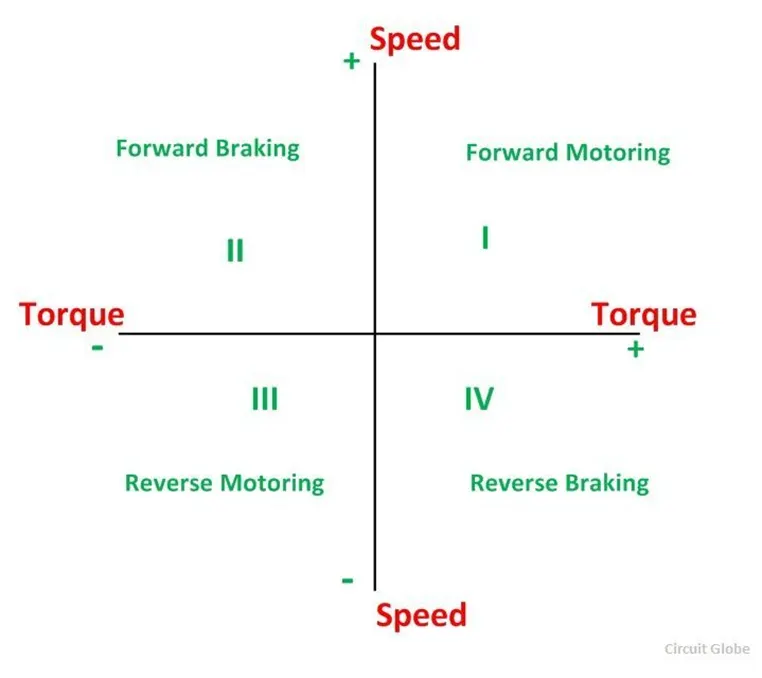
In the I quadrant power developed is positive and the machine is working as a motor supplying mechanical energy. The I (first) quadrant operation is called Forward Motoring. II (second) quadrant operation is known as Braking. In this quadrant, the direction of rotation is positive, and the torque is negative, and thus, the machine operates as a generator developing a negative torque, which opposes the motion.
The kinetic energy of the rotating parts is available as electrical energy which may be supplied back to the mains. In dynamic braking, the energy is dissipated in the resistance. The III (third) quadrant operation is known as the reverse motoring. The motor works, in the reverse direction. Both the speed and the torque have negative values while the power is positive.
In the IV (fourth) quadrant, the torque is positive, and the speed is negative. This quadrant corresponds to the braking in the reverse motoring mode.
The four-quadrant operation and its relationship to speed, torque and power output are summarized below in the table:
|
Function |
Quadrant |
Speed |
Torque |
Power Output |
|
Forward Motoring |
I |
+ |
+ |
+ |
|
Forward Braking |
II |
+ |
- |
- |
|
Reverse Motoring |
III |
- |
- |
+ |
|
Reverse Braking |
IV |
- |
+ |
- |
This is all about Four-Quadrant operation of DC Motor.
Example of Matlab model:
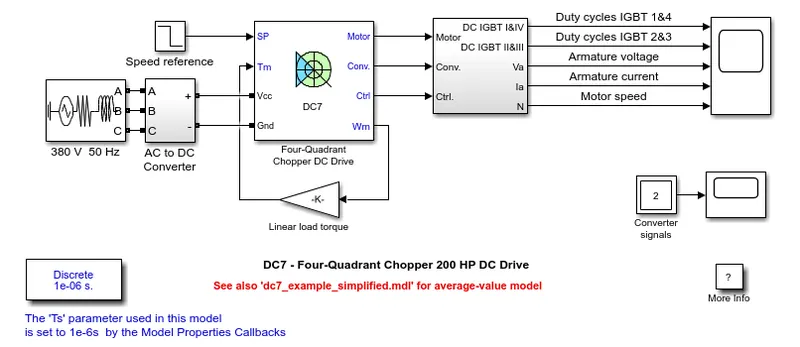
Compare:
|
H-bridge model |
Dc7 model |
|
The machine is separately excited with a constant voltage source. |
The machine tab is one of the port of the this model |
|
This block additional to need field voltage |
No field voltage control |
|
The converter is fed by constant DC voltage source. |
The armature voltage provided by in igbt converter by two PI regulators. |
|
No External inductor |
The external inductor add on armature circuit provided by reduce current oscillation. |
|
Simulation results obtained by a 1sec |
Good simulation results obtained with a 1us. |
|
The converter consists semiconductor devices with a motor. |
The converter consists of power semiconductor devices. |
|
The motor control by a PWM signal |
The controlling tab provided by a this model |
- Develop a 2-Quadrant chopper using Simulink & explain the working of the same with the relevant results.
Answer:
Two-Quadrant Chopper:
Type C chopper is obtained by connecting type –A and type –B choppers in parallel. We will always get a positive output voltage V0 as the freewheeling diode FD is present across the load. When the chopper is on the freewheeling diode starts conducting and the output voltage v0 will be equal to Vs . The direction of the load current i0 will be reversed. The current i0 will be flowing towards the source and it will be positive regardless the chopper is on or the FD conducts. The load current will be negative if the chopper is or the diode D2 conducts. We can say the chopper and FD operate together as type-A chopper in first quadrant. In the second quadrant, the chopper and D2 will operate together as type –B chopper.
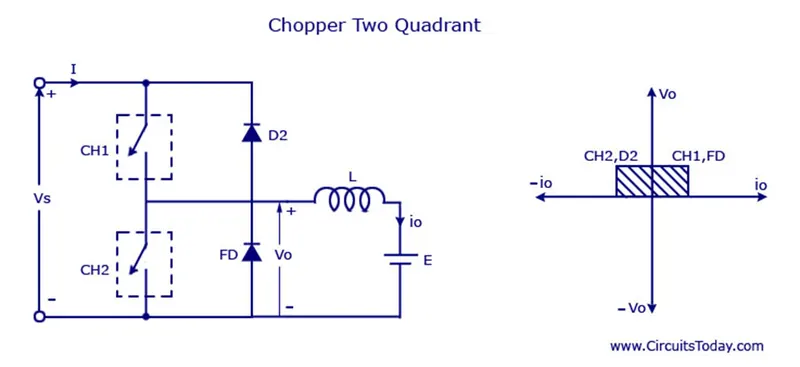
Chopper Two Quadrant
The average voltage will be always positive but the average load current might be positive or negative. The power flow may be life the first quadrant operation ie from source to load or from load to source like the second quadrant operation. The two choppers should not be turned on simultaneously as the combined action my cause a short circuit in supply lines. For regenerative braking and motoring these type of chopper configuration is used.
Type D Chopper or Two-Quadrant Type –B Chopper
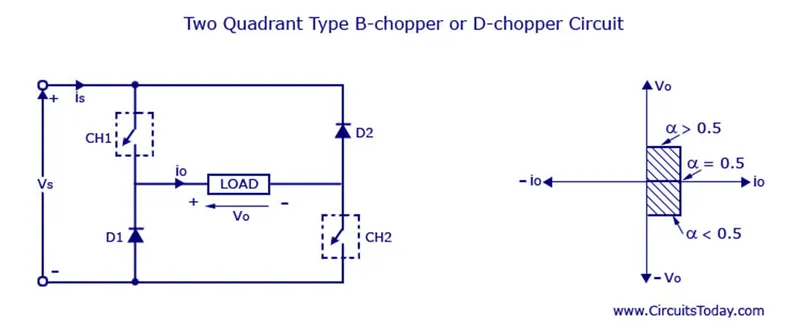
Two Quadrant Type B chopper or D Chopper Circuit
The circuit diagram of the type D chopper is shown in the above figure. When the two choppers are on the output voltage v0 will be equal to Vs . When v0 = – Vs the two choppers will be off but both the diodes D1 and D2 will start conducting. V0 the average output voltage will be positive when the choppers turn-on the time Ton will be more than the turn off time Toff its shown in the wave form below. As the diodes and choppers conduct current only in one direction the direction of load current will be always positive.
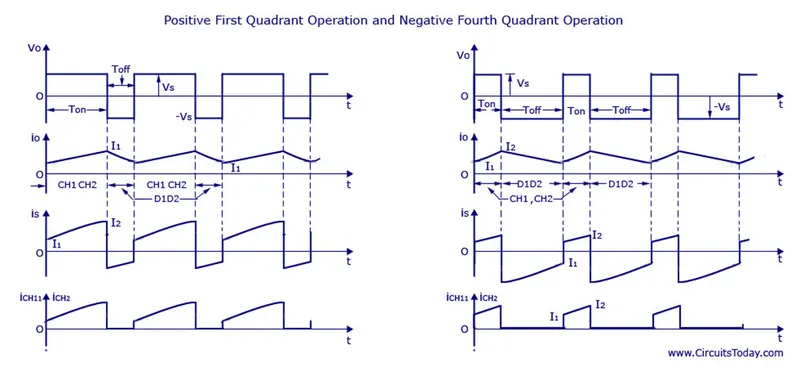
Positive First Quadrant Operation and Negative Fourth Quadrant Operation
The power flows from source to load as the average values of both v0 and i0 is positive. From the wave form it is seen that the average value of V0 is positive thus the forth quadrant operation of type D chopper is obtained.
From the wave forms the Average value of output voltage is given by
V0= (Vs Ton-VsToff)/T = Vs.(Ton-Toff)/T
Matlab model:
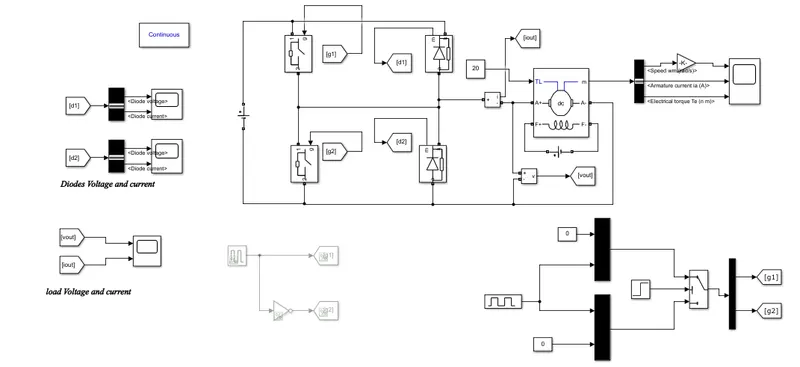
Results:
Motor outputs:
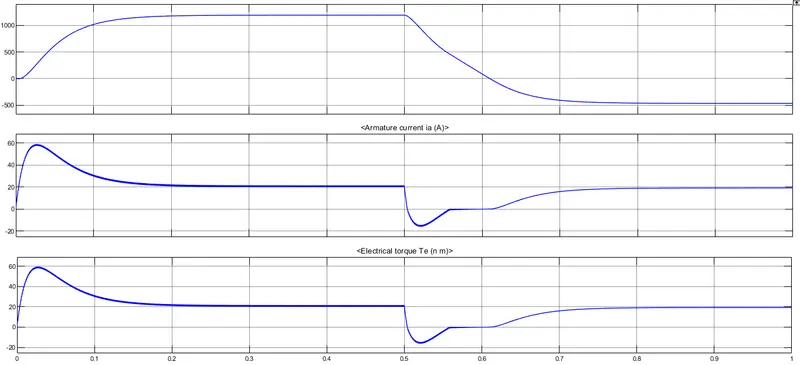
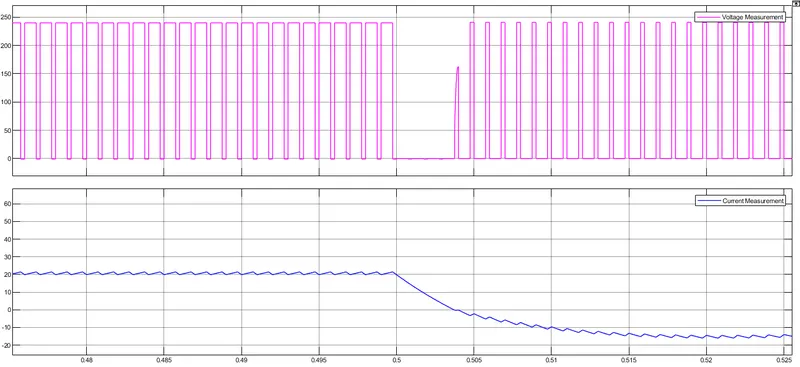
Load voltage and current:
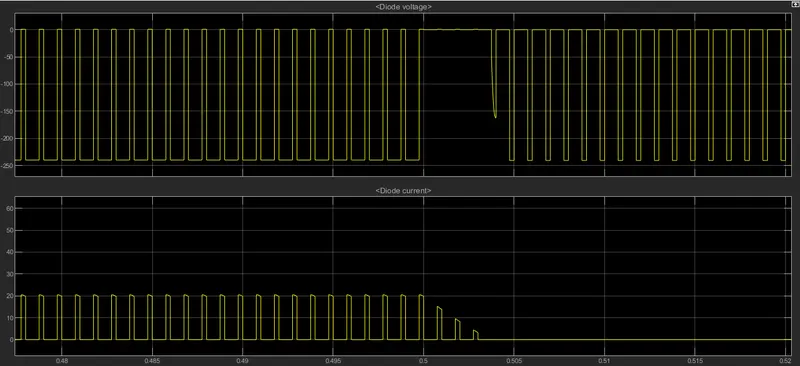
Diode d2 voltage and current
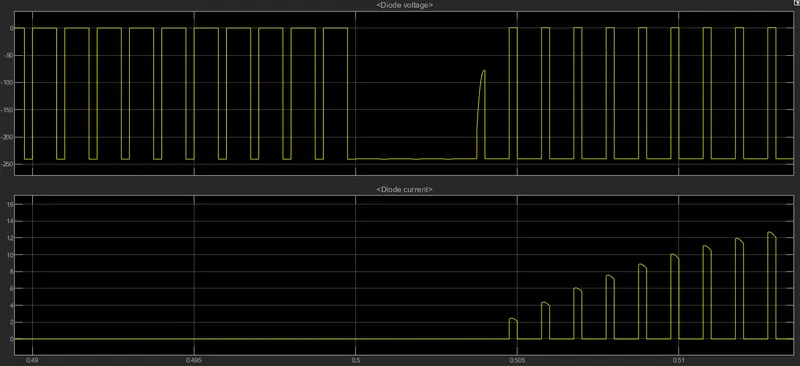
Diode d1 voltage and current
Mathematical model of two quadrant chopper:
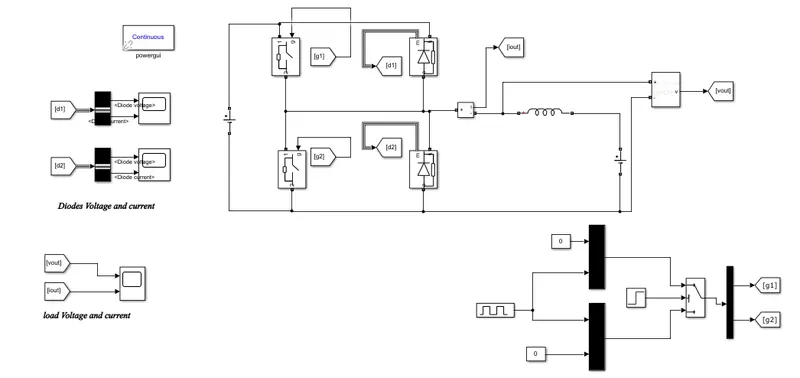
Combination of class A & B choppers. In this type of choppers no speed reversal. For forward motoring Q1- CH1 and D2 (class A) and Forward braking Q2-CH2 and D1 (class B).
In this Model do not fire both switches then is to short circuit of the supply. both CH1 and CH2 are controlled simultaneously.
CH1 is ON and CH2 is OFF between time. therefore flow of current to Vs-CH1-L- -Vs. then, CH1 is OFF so the inductor discharge to the oppsite. (L-D2-L). so current flows from supply to load. Both are positive the Quadrant is 1.
CH2 is ON and CH1 is OFF between time. Therefore flow of current to L-D2-Vs-D1-L.
Load output voltage and current:
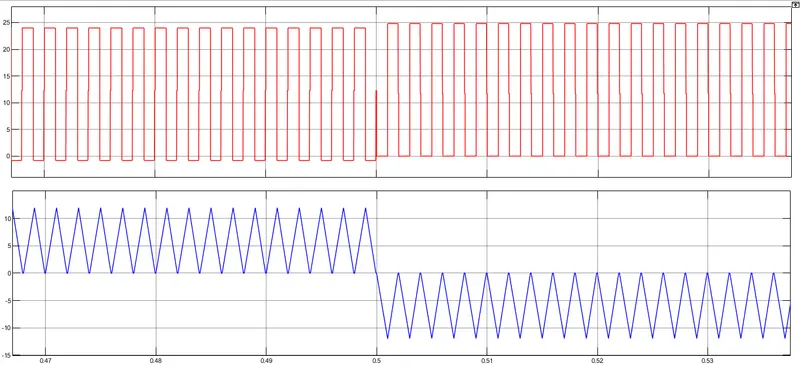
Diode d1 voltage and current:
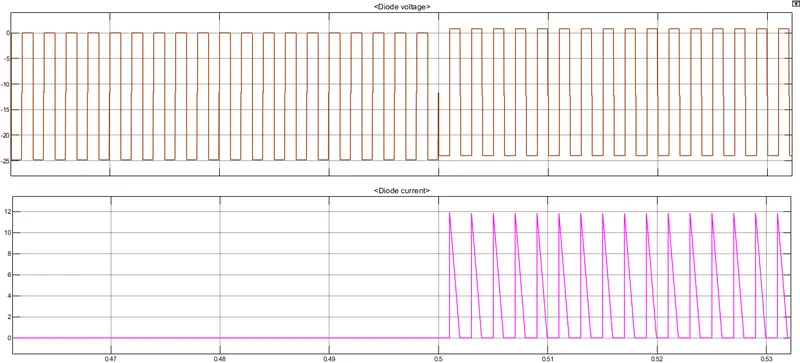
Diode d2 voltage and current:
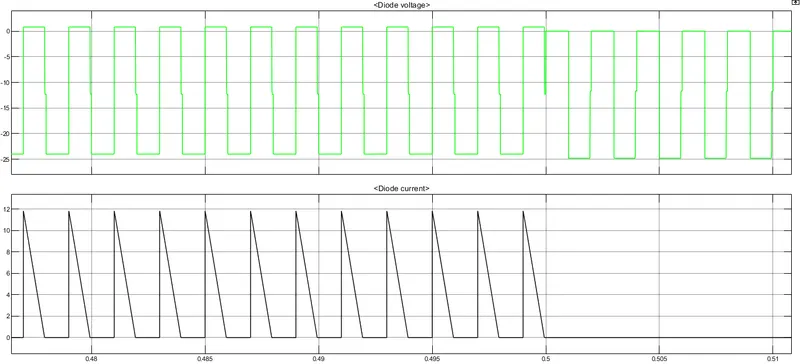
- Explain in a brief about operation of BLDC motor.
ANSWER:
A motor converts supplied electrical energy into mechanical energy. Various types of motors are in common use. Among these, brushless DC motors (BLDC) feature high efficiency and excellent controllability, and are widely used in many applications. The BLDC motor has power-saving advantages relative to other motor types.
Motors are Power Delivery Machines
When engineers are faced with the challenge of designing electrical equipment to perform mechanical tasks, they might think about how electrical signals get converted to energy. So actuators and motors are among the devices that convert electrical signals into motion. Motors exchange electrical energy to mechanical energy.
The simplest type of motor is the brushed DC motor. In this type of motor, electrical current is passed through coils that are arranged within a fixed magnetic field. The current generates magnetic fields in the coils; this causes the coil assembly to rotate, as each coil is pushed away from the like pole and pulled toward the unlike pole of the fixed field. To maintain rotation, it is necessary to continually reverse the current—so that coil polarities will continually flip, causing the coils to continue “chasing” the unlike fixed poles. Power to the coils is supplied through fixed conductive brushes that make contact with a rotating commutator; it is the rotation of the commutator that causes the reversal of the current through the coils. The commutator and brushes are the key components distinguishing the brushed DC motor from other motor types. Figure 1 illustrates the general principle of the brushed motor.
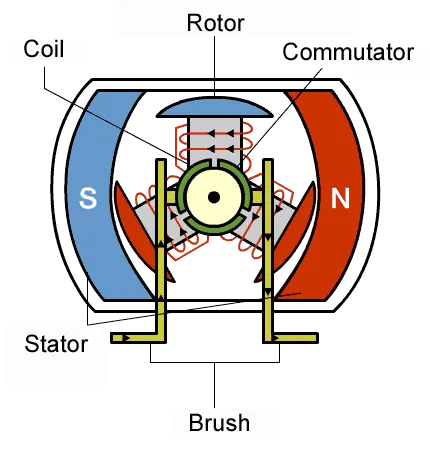
Figure 1: Operation of the Brushed DC Motor.
Fixed brushes supply electric energy to the rotating commutator. As the commutator rotates, it continually flips the direction of the current into the coils, reversing the coil polarities so that the coils maintain rightward rotation. The commutator rotates because it is attached to the rotor on which the coils are mounted.
Common Motor Types
Motors differ according to their power type (AC or DC) and their method for generating rotation (Figure 2). Below, we look briefly at the features and uses of each type.
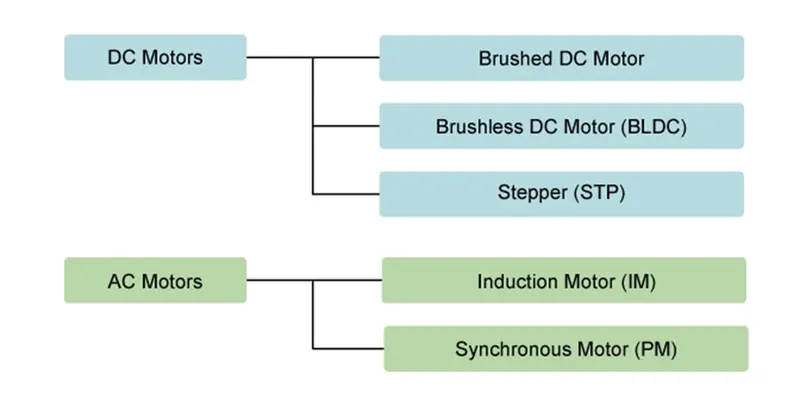
Figure 2: Different Types of Motors
Brushed DC motors, featuring simple design and easy control, are widely used to open and close disk trays. In cars, they are often used for retracting, extending, and positioning electrically-powered side windows. The low cost of these motors makes them suitable for many uses. One drawback, however, is that brushes and commutators tend to wear relatively quickly as a result of their continued contact, requiring frequent replacement and periodic maintenance.
A stepper motor is driven by pulses; it rotates through a specific angle (step) with each pulse. Because the rotation is precisely controlled by the number of pulses received, these motors are widely used to implement positional adjustments. They are often used, for example, to control paper feed in fax machines and printers—since these devices feed paper in fixed steps, which are easily correlated with pulse count. Pausing can also be easily controlled, as motor rotation stops instantly when the pulse signal is interrupted.
With synchronous motors, rotation is synchronous with the frequency of the supply current. These motors are often used to drive the rotating trays in microwave ovens; reduction gears in the motor unit can be used to obtain the appropriate rotational speeds to heat food. With induction motors, too, the rotation speed varies with frequency; but the movement is not synchronous. In the past, these motors were often used in electric fans and washing machines.
There are various types of motor in common use. In this session, we look at the advantages and applications of brushless DC motors.
Why Do BLDC Motors Turn?
As their name implies, brushless DC motors do not use brushes. With brushed motors, the brushes deliver current through the commutator into the coils on the rotor. So how does a brushless motor pass current to the rotor coils? It doesn’t—because the coils are not located on the rotor. Instead, the rotor is a permanent magnet; the coils do not rotate, but are instead fixed in place on the stator. Because the coils do not move, there is no need for brushes and a commutator. (See Figure. 3.)
With the brushed motor, rotation is achieved by controlling the magnetic fields generated by the coils on the rotor, while the magnetic field generated by the stationary magnets remains fixed. To change the rotation speed, you change the voltage for the coils. With a BLDC motor, it is the permanent magnet that rotates; rotation is achieved by changing the direction of the magnetic fields generated by the surrounding stationary coils. To control the rotation, you adjust the magnitude and direction of the current into these coils.
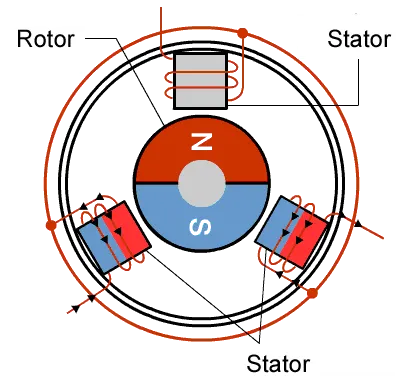
Figure 3: A BLDC Motor.
Since the rotor is a permanent magnet, it needs no current, eliminating the need for brushes and commutator. Current to the fixed coils is controlled from the outside.
Advantages of BLDC Motors
A BLDC motor with three coils on the stator will have six electrical wires (two to each coil) extending from these coils. In most implementations three of these wires will be connected internally, with the three remaining wires extending from the motor body (in contrast to the two wires extending from the brushed motor described earlier). Wiring in the BLDC motor case is more complicated than simply connecting the power cell’s positive and negative terminals; we will look more closely at how these motors work in the second session of this series. Below, we conclude by looking at the advantages of by BLDC motors.
One big advantage is efficiency, as these motors can control continuously at maximum rotational force (torque). Brushed motors, in contrast, reach maximum torque at only certain points in the rotation. For a brushed motor to deliver the same torque as a brushless model, it would need to use larger magnets. This is why even small BLDC motors can deliver considerable power.
The second big advantage—related to the first—is controllability. BLDC motors can be controlled, using feedback mechanisms, to delivery precisely the desired torque and rotation speed. Precision control in turn reduces energy consumption and heat generation, and—in cases where motors are battery powered—lengthens the battery life.
BLDC motors also offer high durability and low electric noise generation, thanks to the lack of brushes. With brushed motors, the brushes and commutator wear down as a result of continuous moving contact, and also produce sparks where contact is made. Electrical noise, in particular, is the result of the strong sparks that tend to occur at the areas where the brushes pass over the gaps in the commutator. This is why BLDC motors are often considered preferable in applications where it is important to avoid electrical noise.
Ideal Applications for BLDC Motors
We’ve seen that BLDC motors offer high efficiency and controllability, and that they have a long operating life. So what are they good for? Because of their efficiency and longevity, they are widely used in devices that run continuously. They have long been used in washing machines, air conditioners, and other consumer electronics; and more recently, they are appearing in fans, where their high efficiency has contributed to a significant reduction in power consumption.
They are also being used to drive vacuum machines. In one case, a change in the control program resulted in a large jump in rotational speed—an example of the superlative controllability offered by these motors.
BLDC motors are also being used to spin hard disc drives, where their durability keeps the drives operating dependably over the long term, while their power efficiency contributes to energy reduction in an area where this is becoming increasingly important.
Toward Wider Usage in the Future
We can expect to see BLDC motors used in a wider range of applications in the future. For example, they will probably be widely used to drive service robots—small robots that deliver services in fields other than manufacturing. One might think that stepper motors would be more suitable in this type of application, where pulses could be used to precisely control positioning. But BLDC motors are better suited to controlling the force. And with a stepper motor, holding the position of a structure such as a robot arm would require a relatively large and continuous current. With a BLDC motor, all that would be required is a current proportionate to the external force—allowing for more power-efficient control. BLDC motors may also be replacing simple brushed dc motors in golf carts and mobility carts. In addition to their better efficiency, BLDC motors can also deliver more precise control—which in turn can further extend battery life.
BLDC motors are also ideal for drones. Their ability to deliver precision control makes them especially suited for multirotor drones, where the drone’s attitude is controlled by precisely controlling the rotational speed of each rotor.
In this session, we have seen how BLDC motors offer excellent efficiency, controllability, and longevity. But careful and proper control is essential to taking full advantage of these motors’ potential. In our next session, we will look at how these motors work.
Controlling BLDC Motors
Understanding the principle and application of high efficiency motors: 2 of 3
BLDC motors have gained considerable attention for the ability to deliver high efficiency in a small package, and for their long service life and excellent controllability. In this session, we look at how we can control them to make effective use of their potential capabilities.
Connections are More Complicated
Figure 1 shows the appearance and inner structure of a typical type of BLDC motor—the inner rotor type. Note that this motor’s permanent magnet is attached to its rotor, and the coils are placed outside. This is quite different from a typical brushed DC motor, where the coils are on the rotor and the permanent magnet is outside. Since the BLDC motor’s rotor does not use coils, there is no need to supply it with current. That’s why there are no brushes.
But BLDC motors are more difficult to drive than brushed motors. With a brushed motor, all you need to do is to connect the power source to the positive and negative leads from the motor. The BLDC motor has a different from brushed dc motor to number of leads, and the connection is more complicated.
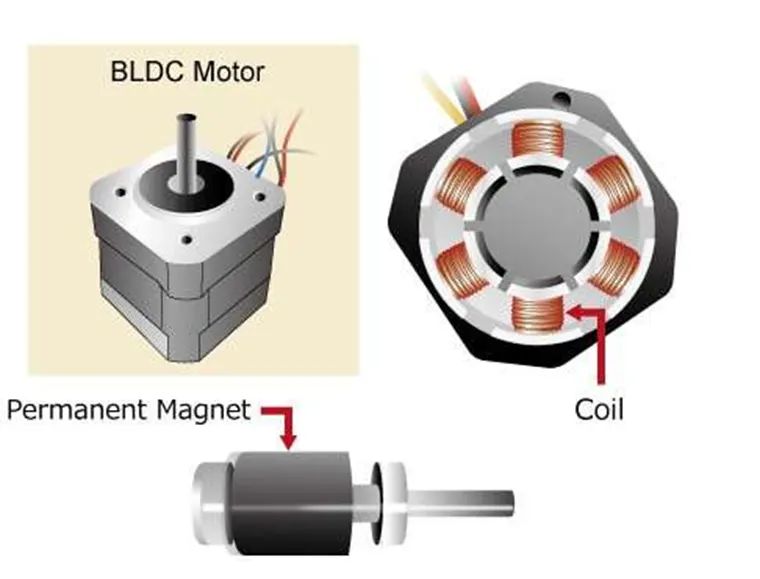
Figure 1: The Inside and Outside of a BLDC Motor.
The rotor is a permanent magnet, and does not pass current. Brushes and commutator are eliminated, allowing for longer service life.
Controlling the Magnetic Field
To rotate a BLDC motor, one needs to control the direction and timing of the current into the coils. Figure 2(a) illustrates a BLDC motor’s stator (coils) and rotor (permanent magnets). Let’s use this illustration to see how the rotor is made to turn. In this example we are using three coils, whereas in practice it is more common to use six or more. But here we look at just three coils, spaced at 120º. A motor, as we noted in our last session, performs the task of converting electrical energy into mechanical energy. So how does the motor in our illustration do this? Let’s look at what goes on inside.
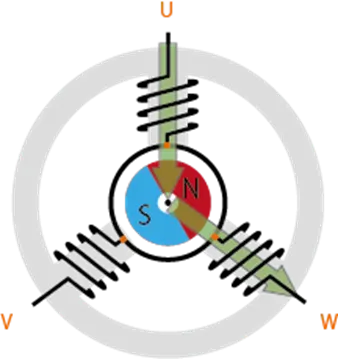
Figure 2(a): BLDC Motor’s Principle of Rotation.
Typical configuration: three coils with 120º spacing. Driven by controlling the phases and coil currents.
For our example, we show a 3-coil motor. Let’s label the coils U, V, and W. Remember that the passing of a current through a coil generates a magnetic field. Since there are three coils, there are three paths through which we can pass current; we can call these phase U (current into coil U), phase V (into coil V), and phase W. Let’s look first at phase U. If current moves through U only, magnetic flux is generated as shown by the arrow in Fig. 2(b). In actuality, all three coils are interconnected, through a single lead wire from each—and it is not possible to generate phase U in isolation. Figure 2(c) shows what happens when current moves through coils U and W (phase “UàW”), with the arrows again showing the flux generated at each coil. The wide arrow in Figure 2(d) is the resultant flux—the result of the combined magnetic fields from U and W. This large flux will cause the inner rotor to turn until the S and N poles of the rotor permanent magnet are aligned on this arrow (with the N pole closest to the arrow tip).
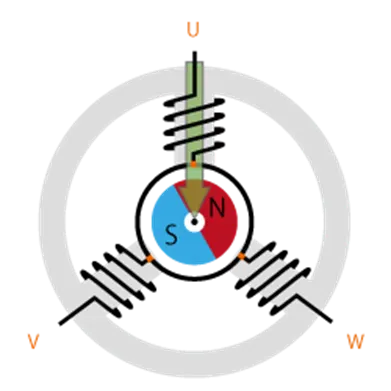
Figure 2(b): BLDC Motor Principle of Rotation.
Current flows through U and then W. The arrow shows flux generated by coil U.
Figure 2(c): BLDC Motor Principle of Rotation.
Current flows through U and W. The two arrows show flux generated by coils U and W, respectively.
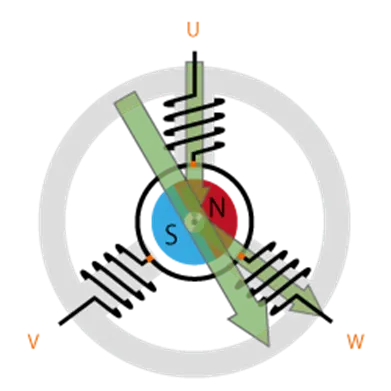
Figure 2(d): BLDC Motor Principle of Rotation.
The wide arrow shows the resultant flux—the sum of the flux produced by U and W.
Rotation is maintained by continually switching the flux so that the permanent magnet is constantly chasing the rotating magnetic field induced by the coils. In other words, energizing of U, V, and W must be continually switched so that the resultant flux keeps moving, producing a rotating field that continually pulls on the rotor magnet.
Figure 3 shows the relationship between energized phases and flux. As you can see, switching sequentially through modes 1 through 6 will cause the rotor to turn clockwise through one rotation. The speed of rotation can be controlled by controlling the rate at which the phases change. We use the name “120-degree conducting control” to the 6-mode control method described here.
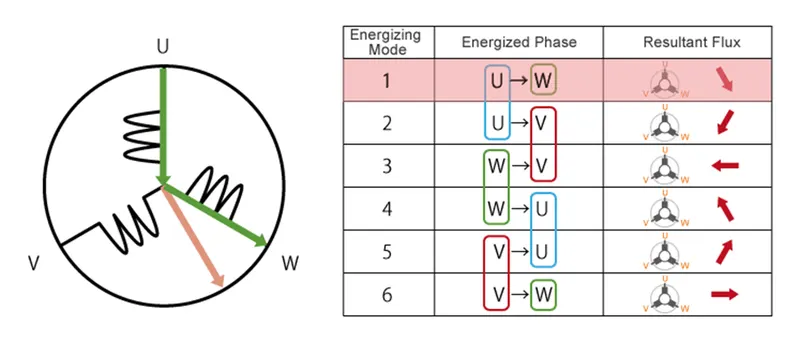
Figure 3: The changing resultant flux continually pulls the rotor magnet, causing the rotor to turn.
Sinusoidal Control Delivers Smooth Rotation
With 120-degree conducting control, there are only six resultant flux directions for driving the motor. For example, switching from Mode 1 to 2 (see Fig. 3) moves the resultant flux direction by 60º, pulling the rotor along accordingly. Switching from Mode 2 to 3 shifts the flux direction another 60º, again pulling the rotor. Repeating this process generates a continuous rotation, but it is a somewhat jerky rotation. In some cases, this jerkiness will create unwanted vibrations and mechanical noise.
As an alternative to 120-degree conducting control, we can use sinusoidal control to achieve smoother and quieter operation. With 120-degree conducting control, the motor is controlled by continually cycling through six fixed resultant fluxes. And as you can see in Figure 2(c), U and V both generate fluxes of equal magnitude. By more carefully controlling the current into U, V, and W, however, we can generate differing flux magnitudes at each coil, allowing us to more precisely vary the resultant flux. (See Fig. 4.)
By carefully adjusting the current flow into each of the three phases, then, we can achieve a more continuous change in resultant flux, resulting in smoother motor rotation.
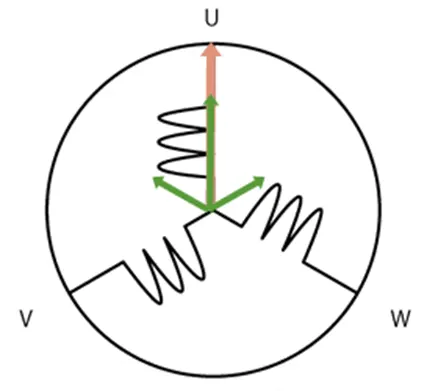
Figure 4: Sinusoidal Control.
By controlling the current into all three phases, resultant flux magnitude and direction can be controlled more precisely that with 120-degree conducting control, so as to achieve smoother rotation. Resultant flux is no longer limited to six discrete directions.
Control by Inverter
Let’s look again at the nature of the current into U, V, and W. For simplicity, let’s see how this works with 120-degree conducting control. Looking back to Figure 3, we see that in Mode 1 the current flows from U to W; in Mode 2, from U to V. As the arrows in the figure show, each change in the energized coil combination causes a corresponding change in the flux direction.
Now look at Mode 4. Here we have current moving from W to V; this is the just the reverse of Mode 1. With a brushed DC motor, this type of current reversal would be achieved using brushes and commutator. BLCD motors cannot by definition use brushes or other mechanical contact to achieve this reversal. Instead, they generally use inverter circuitry to implement this control.
And by using the inverter circuitry to also adjust the voltage into each coil, we can in addition control the magnitude of the current. A typical way to adjust the voltage is with pulse width modulation (PWM). In this approach, we alter the voltage by lengthening or reducing the pulse ON time (also referred to as the “duty cycle”: the ON time expressed as a ratio of the ON+OFF switching interval). Increasing the duty cycle has the same effect as raising the voltage; reducing the duty cycle has the same effect as lowering the current. (See Fig. 5.)
PWM can be implemented using MPUs equipped with dedicated PWM hardware. While 120-degree conductiong control only requires two-phase voltage control and be implemented relatively easily in software, sinusoidal control uses three-phase voltage control and is considerably more complicated. Appropriate inverter circuitry is therefore essential for driving BLDC motors. Note that inverters can also be used with AC motors. But when a term such as “inverter type” is used with reference to consumer electronics, it is usually referring to a BLDC motor.
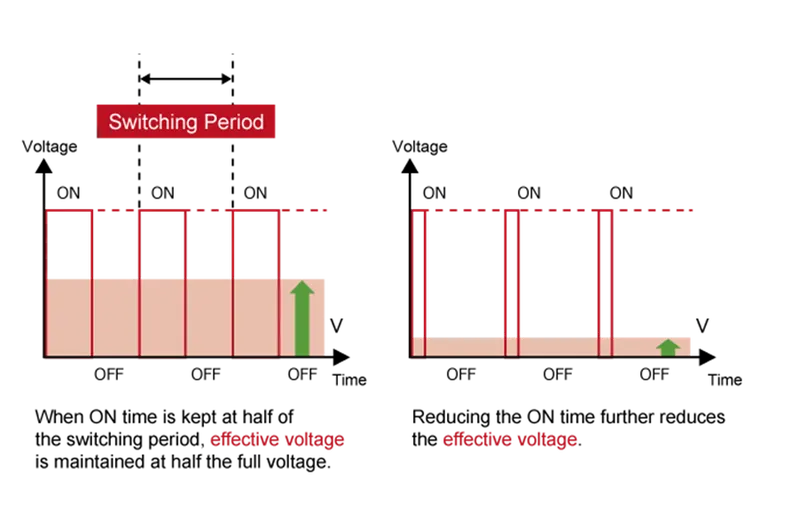
Figure 5: PWM Output vs. Output Voltage.
Varying the duty cycle (the ON time within each switching period) changes the effective voltage.
BLDC Motors and Positional Sensors
As we have seen, we drive BLDC motors by continually changing the directionality of the flux produced by the coils. The permanent magnets on the rotor continually chase the shifting rotating magnetic field, causing the rotor to turn.
So far, however, we have not looked at another important feature of these motors: their positional sensors. Because BLDC motor control must be coordinated with the rotor (magnet) position, these motors typically also include sensors to detect this position. Applying current when the rotor position is unknown may cause the rotor to turn in the wrong direction. The use of sensors prevents this problem.
Table 1 lists the typical types of sensors used in these motors. Different type’s sensors are used for different methods of control. Hall elements, with signal inputs spaced at 60º, are best for motors that use 120-degree conducting control—where all that is necessary is to determine which phase to energize. More precise sensors—such as resolvers and optical encoders—are more appropriate with motors that use vector control (see below), where flux is more finely controlled.
While sensors offer obvious advantages, they come with disadvantages as well. Some sensors have low tolerance to dust, and require regular maintenance. Others operate properly over only a limited range of temperatures. The use of sensors, and the implementation of all the attendant circuitry, increases manufacturing costs; and highly precise sensors are of course the most expensive. “Sensorless BLDC motors” currently on the market eliminate the use of sensor entirely, as a way of reducing the costs of parts and maintenance. But this session, where we are explaining the principles of operation, we have assumes that sensors are being use to track the rotor position.
|
Sensor Type |
Typical Applications |
Features |
|
Hall Element |
120-deg. conducting control |
Gets signal every 60 degrees. Relatively inexpensive. Poor tolerance to heat. |
|
Optical Encoder |
Sine-wave control, vector control |
Two types: Incremental (detects displacement from origin) and absolute (detects current position). High resolution. Poor tolerance to dust. |
|
Resolver |
Sine-wave control, vector control |
High resolution. Sturdy. Can be used in rough environments. |
Table 1: Positional Sensor Types and Features
Vector Control Maintains High Efficiency
As we have seen, sinusoidal control delivers smooth rotation by utilizing 3-phase current to smoothly control the flux. Where 120-degree conducting control energizes only two of the three (U, V, and W) phases at any one time, sinusoidal control is considerably more complicated—as it must accurately deliver differing amounts of current to all three phases.
One way of reducing this complication is with vector control, where calculations are used to convert the coordinate space, allowing 3-phase AC values to be handled as 2-phase DC values. This approach can only work, however, if high-resolution positional information is available for use in these calculations. One way of getting this information is through the use of high-precision sensors (optical encoders, resolvers, etc.). Another, “sensorless” way is estimate the position based on the magnitude of the current into each phase. In either case, the conversion of the coordinate space allows for direct control of torque-related electric current—allowing for highly efficient operation with little wasted current.
Implementation of vector control requires intensive mathematical processing, including the ability to rapidly solve the trigonometric functions needed to convert the coordinate space. The MCU used to control these motors will generally include an FPU (floating-point unit) and must be able to deliver considerable processing power.