Week-7 Challenge: DC Motor Control
AIM :
- Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor changes direction from forward to reverse.
- Refer to help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with H-bridge model.
- Make a suitable EV model using DC7 block and make result report.
- Explain in a brief about operation of BLDC motor.
1. Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor.
This given model shows the simulation of an H - bridge used to generate a chopped voltage and control the speed of DC motor. The given model consists of the Bipolar Junction Transistors (BJT) as the power switching applications operated as an IGBT.
The switch is controlled by a Simulink signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates fan type load, where load torque is proportional to the square of speed.
The armature voltage can be varied from 0 to 240V when the duty cycle can be varied from 0 to 100%.
Bipolar Junction Transistors (BJT)
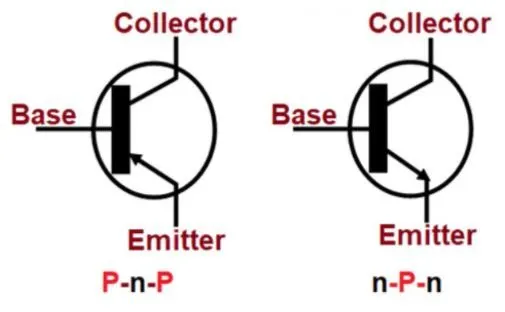
- A BJT is a three-terminal semiconductor device. The name 'bipolar' comes from the fact that this type of transistor contains two types of semiconductor material - one positive type (p-type) and one negative type (n-type) - through which a current flows.
- Bipolar junction transistors usually contain silicon. Moreover, impurities are commonly added to the silicon via doping to make the layers behave as desired.
- It's the p-type layers in a BJT's job to attract the electrons that enter the transistor through it's input circuit. The n - type layers, on the other hand should encourage electrons to flow out of the transistor. This push and pull effect between the layers enables the electrical current to be amplified and controlled.
- The configuration of the layers in a BJT determines the electrical current's flow and ensures that a charge can't return in the same direction as it came. This setup protects the system from overheating or becoming damaged.
BJT's are created by layering p-type and n-type silicon to form a three-layer 'sandwich':
- The Base, to which a small starting current is attached
- The Emitter, which emits electrons.
- The Collector, which collects the electrons that have been amplified. Electrons are passed between from the emitter to the base.
Bipolar Transistors have the ability to operate within three different regions:
- Active Region - The transistor operates as an amplifier and Ic = β x Ib
- Saturation - The transistors is 'Full-ON' operating as a switch and Ic = I (Saturation)
- Cut-off - The transistors is 'Fully-OFF' operating as a switch and Ic = 0.
There are two types of sandwiches : NPN (negative-positive-negative) and PNP (positive - negative - positive). The former switches on when the current flows through the base, while the latter switches on only when there is no current in the base.
BJT H - Bridge :
An H-Bridge is an arrangement of transistors that allows a circuit full control over a standard electric DC motor. That is an H-Bridge allows a microcontroller, logic chip or remote control to go forward, reverse, brake and coast.
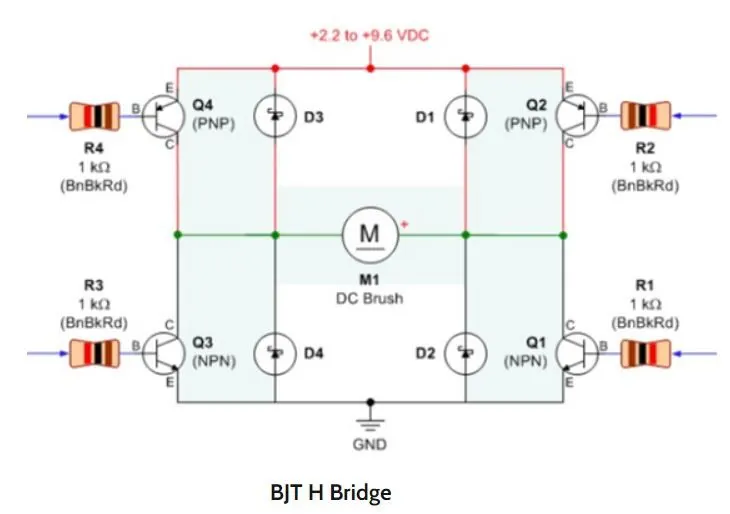
The H-bridge consists of BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultanously : Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2 - D3 operate as free - wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1 - D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
The Simulink model created in MATLAB Simulink is shown below :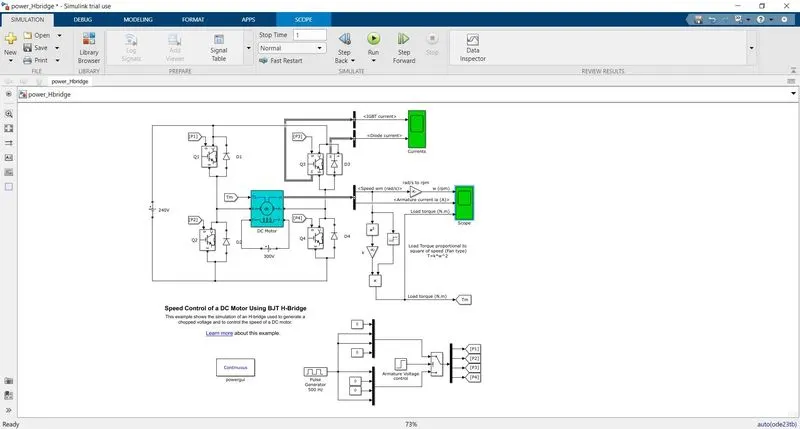
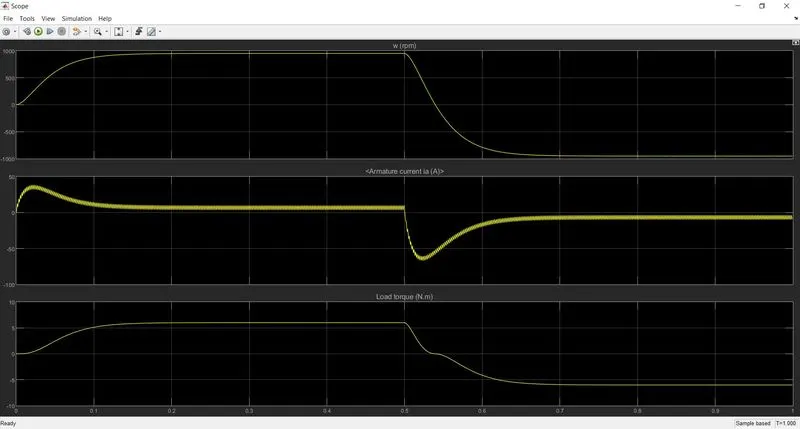
The motor starts in a positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t = 0.5 sec, the armature voltage is suddenly reversed and the motor runs in a negative direction.
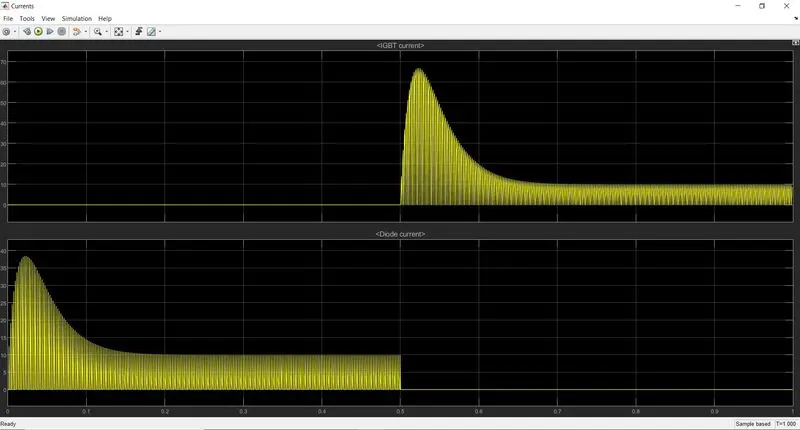
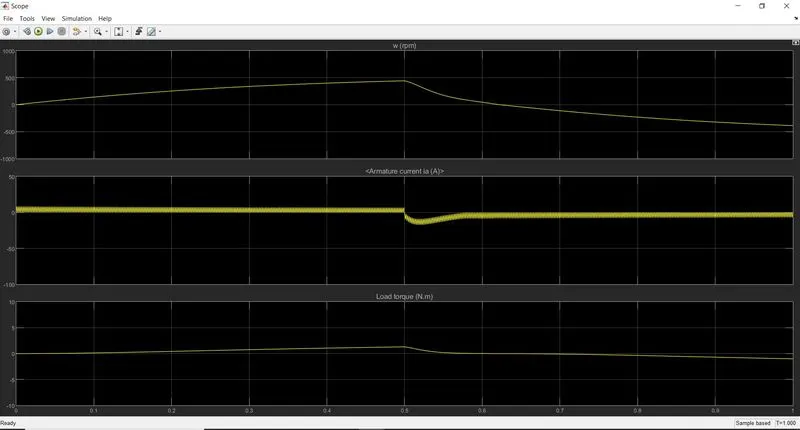
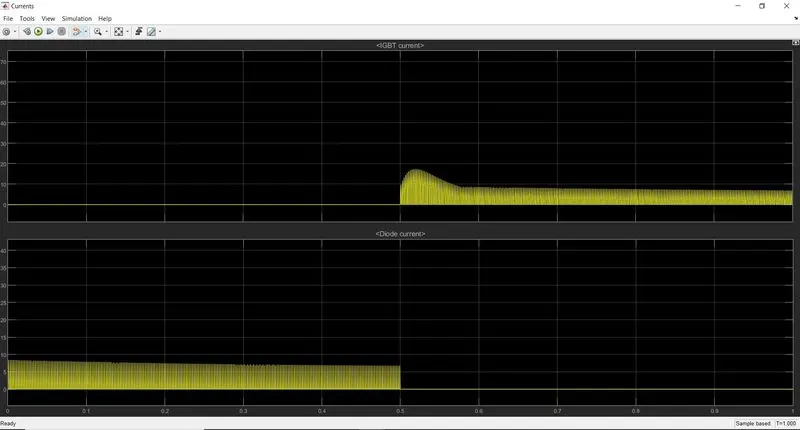
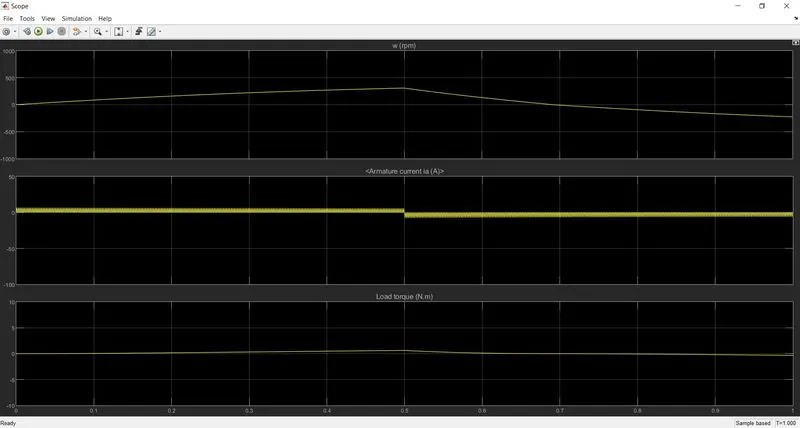
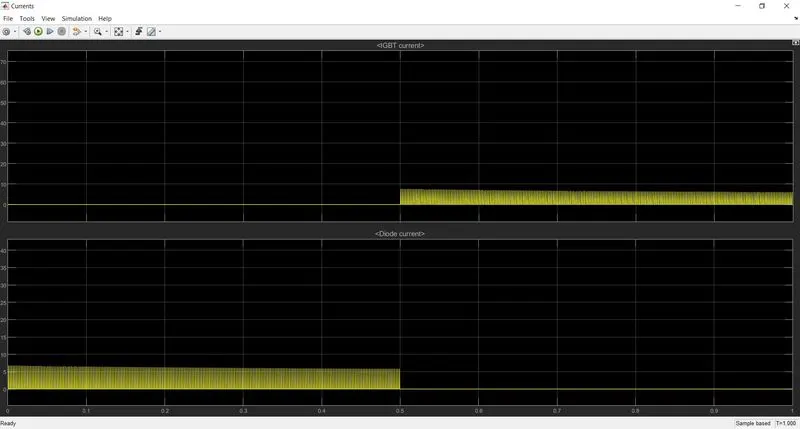
'Scope' shows motor speed, armature and load torque and 'current' shows current flowing through BJT Q3 and diode D3.
Plots -
1. 75 % duty cycle -
2. 50% Duty Cycle -
3. 40 % Duty Cycle -
Results -
- The given cycle runs for a 75% duty cycle, which means the program is ON for 75% of the time and off for 25% of cycle.
- For the given plot we can see that for Q3 and Q4 the input is provided after 0.5 sec,so IGBT signal is present after 0.5 sec to 1 sec.
- As for the first cycle we can see that the diode current passes, which indicates current passes through the circuit and after 0.5 sec there is no diode current which indicates there is no current passes through the circuit or the current passes in the reverse direction.
- From the given plot we can see that the motor took around 0.1 sec to reach the maximum rated speed it is because of the load applied.
- In Q3 mode the motor starts reducing speed or works in reverse mode and reaches a maximum speed of -1000 rpm.
- We can see the armature current overshoot when it changes direction, due to the load applied and again reaches its constant current supply because of constant speed.
- To reduce the overshoot we reduce the duty cycle to 50 %
- At 50% duty cycle it is can be observed that the overshoot is significantly reduced.
- In order to completely reduce the overshoot we further reduce the duty cycle to 40%.
2. Refer to help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with H-bridge model.
The Four-Quadrant Single-Phase Rectifier DC Drive (DC2) block represents a four-quadrant, single-phase, thyristor-based (or phase controlled) drive for DC motors. This drive features closed-loop speed control with two anti-paralleled single-phase thyristor rectifiers. The anti-parallel rectifiers operate in circulating current mode with the help of circulating current inductors. The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the thyristor firing angles (for the two rectifiers) corresponding to the commanded armature current are derived. These firing angles are then used to obtain the required gate signals for the rectifiers through a thyristor bridge firing unit.
Comparison between H bridge and 4 quadrant chopper
- To control the motor : In H bridge we need to change the polarity to make the motor move forward or backward. In $ Quadrant chopper, we need to interrupt signals to another.
- Reqenerative Braking : In H bridge it is not possible while it is possible in 4 quadrant chopper
- Simulation : In H Bridge simulation is continous while in a 4 Quadrant chopper it is discrete. Hence the H bridge takes more time. Overall a 4 Quadrant or E type chopper has more efficiency than H bridge.
3. Make a suitable EV model using DC7 block and make result report.
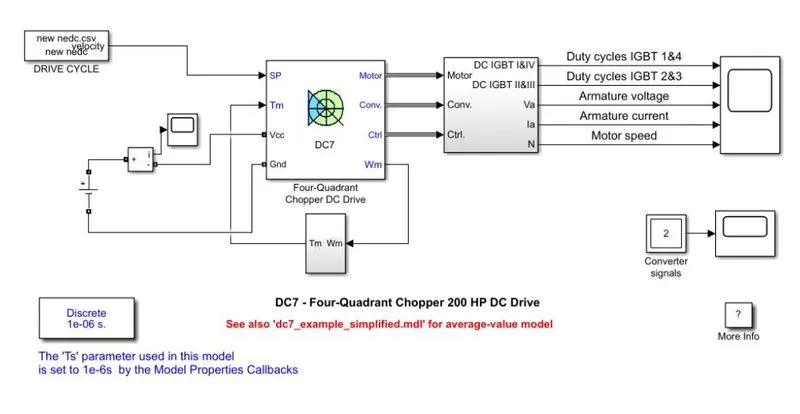
To incorperate the characteristics of an EV following changes were made to DC7 :
- The AC supply and ADC converter was replaced by a DC source of 400V.
- The SP input is replaced by the drive cycle block
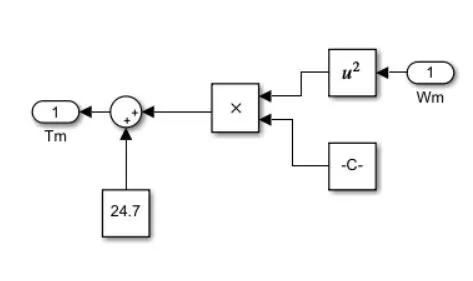
- The motor characteristics is made by using basic operations.
T = 24.7 + 0.00051*w_m
Subsystem,
DC7 EV simulation model :
Result -
For a fixed sampling time the following result was obtained
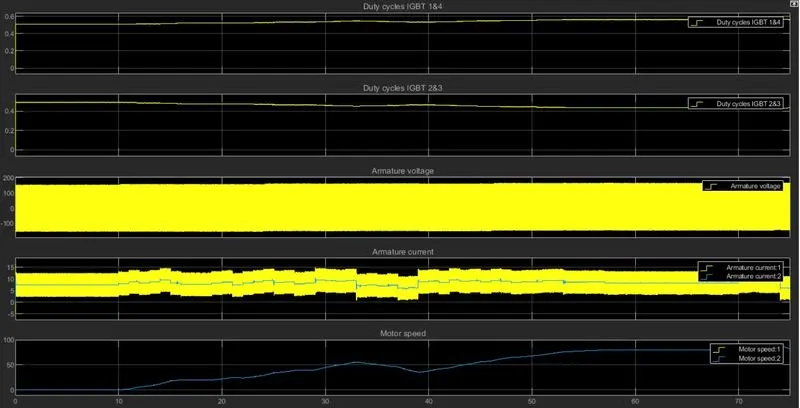
It is evident that motor speed tries to match the target speed.
4. Explain in a brief about operation of BLDC motor.
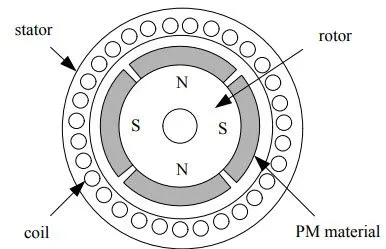
The main design difference between a brushed and brushless motors is the replacement of mechanical commutator with an electric switch circuit. Keeping that in mind, a BLDC Motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
Brushless Motors are available in three configurations: single phase, two phase and three phase. Out of these, the three phase BLDC is the most common one.
The following image shows the cross-section of a BLDC Motor.
Working Principle
Consider the following setup of three windings in the stator designated A, B and C. For the sake of understanding, let us replace the rotor with a single magnet.
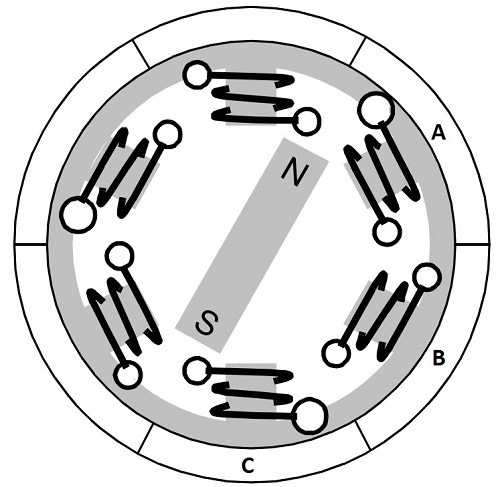
We know that when a current is applied through a coil, a magnetic field is generated and the orientation of the field lines i.e. the poles of the generated magnet will depend on the direction of the current flowing through the coil.
Using this principle, if we supply current to the coil A so that it will generate a magnetic field and attract the rotor magnet. The position of the rotor magnet will shift slightly clockwise and will align with A.
If we now pass current through coils B and C one after the other (in that order), the rotor magnet will rotate in clock wise direction.
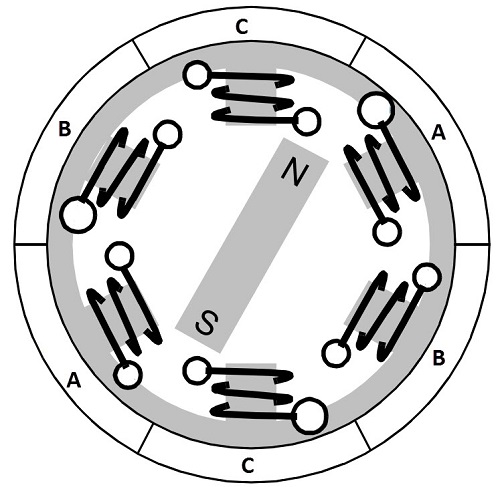
To increase efficiency, we can wind the opposite coils using a single coil so that we get double attraction. Further increasing the efficiency, we can energize two coils at the same time so that one coil will attract the magnet and the other coil will repel it. During this time, the third will be idle.
For a complete 3600 rotation of the rotor magnet, six possible combinations of the coils A, B and C are applicable and are shown in the following timing diagram.
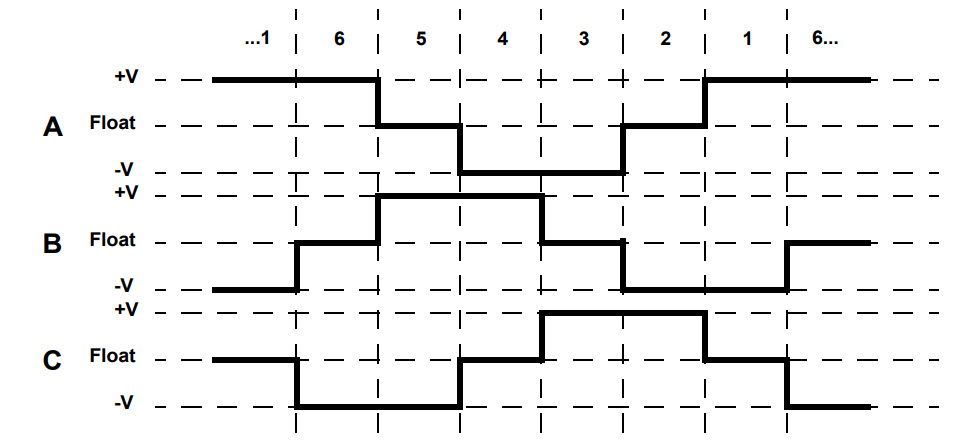
Base on the above diagram, we can confirm that at any time, one phase is positive, one phase is negative and the third phase is idle (or floating). So, based on the inputs from the Hall Sensors, we have two switch the phases as per the above diagram.