DC Motor Control Characteristics
AIM :
To perform the various operations corresponding to an Electric vehicle inorder to fulfill the required objectives that were provided.
OBJECTIVE :
- To run and analyse MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’.
- To compare the ‘The Four-Quadrant Chopper DC Drive (DC7) block’ with H-bridge model.
- To make a suitable EV model using DC7 block.
1. Analysis on ‘Speed control of a DC motor using BJT H-bridge’
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0). The DC motor uses the preset model . It simulates a fan type load (where Load torque is proportional to square of speed). The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
The simulink model of DC motor with BJT was attached below,
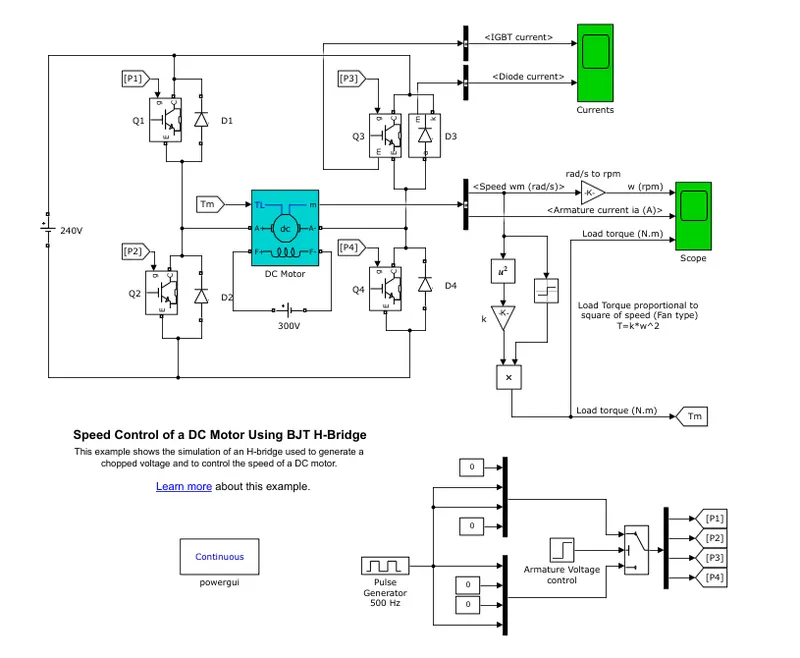
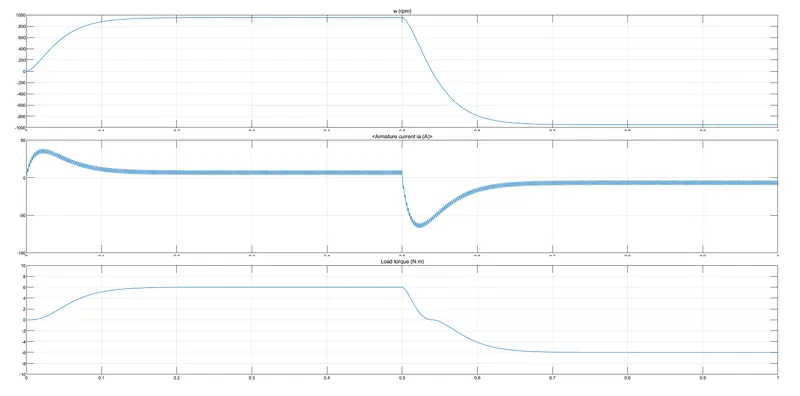
The motor starts in the positive direction with a duty cycle of 75% . At t= 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction.
Specifications :
- Power = 5 HP
- Rated voltage = 240 V
- Rated Speed = 1750 RPM
- Initial duty cycle = 75 %
- DC voltage = 180 V
The following scope shows motor speed, armature current and load torque and 'Currents' shows currents flowing in BJT Q3 and diode D3,
The duty cycle was then changed from 75 % to 45 %.
The resulting plot was attached below,
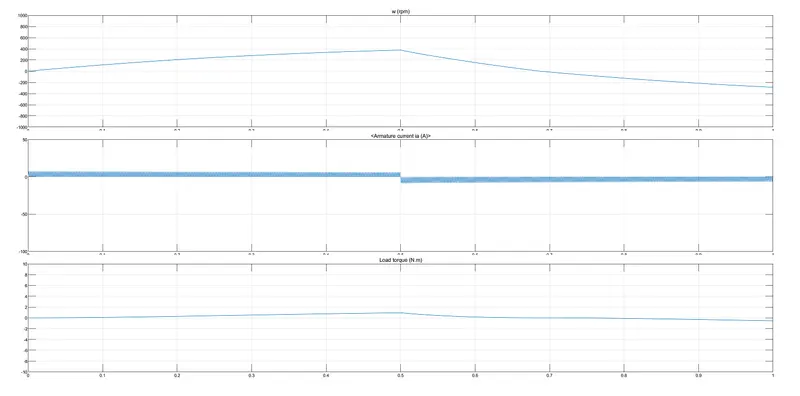
- This plot clearly depicts that by reducing the duty cycle ratio, the Armature current shoot-up can be optimized completely.
- The No load torque of the motor was reduced from 6 Nm to 2 Nm.
- There will be considerable fall in the Load torque and thereby reducing the speed.
- The No load speed was reduced from 900 rpm to 400 rpm.
Inference :
Reducing the Dury cycle ratio of the power modules ultimately reduces the effect of Armature current shoot-up but reduces the supply voltage to the motor and thus results in the reduction of Rated speed and torque of the motor.
2. Comparing the ‘The Four-Quadrant Chopper DC Drive (DC7) block’ with H-bridge model.
Four-Quadrant chopper model :
A Chopper is a DC-DC converter used to convert a fixed DC into variable DC.
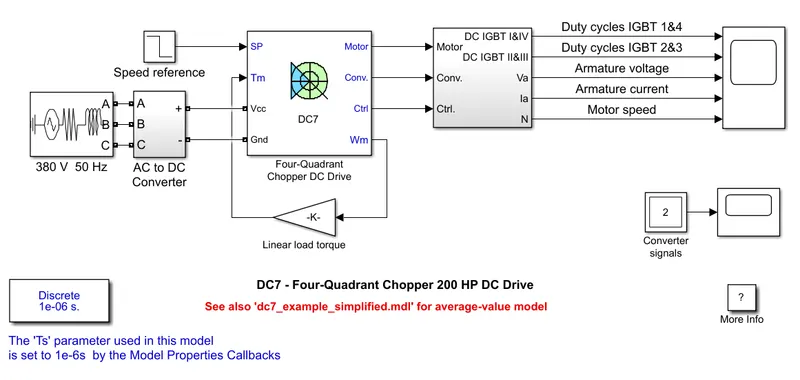
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system.
The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
The simulink model of the Four Quadrant chopper DC drive was attached below,
H-Bridge :
An H-bridge is an electronic circuit that switches the polarity of a voltage applied to a load. These circuits are often used in robotics and other applications to allow DC motors to run forwards or backwards.
Most DC-to-AC converters (power inverters), most AC/AC converters, the DC-to-DC push–pull converter, isolated DC-to-DC converter most motor controllers, and many other kinds of power electronics use H bridges. In particular, a bipolar stepper motor is almost invariably driven by a motor controller containing two H bridges.
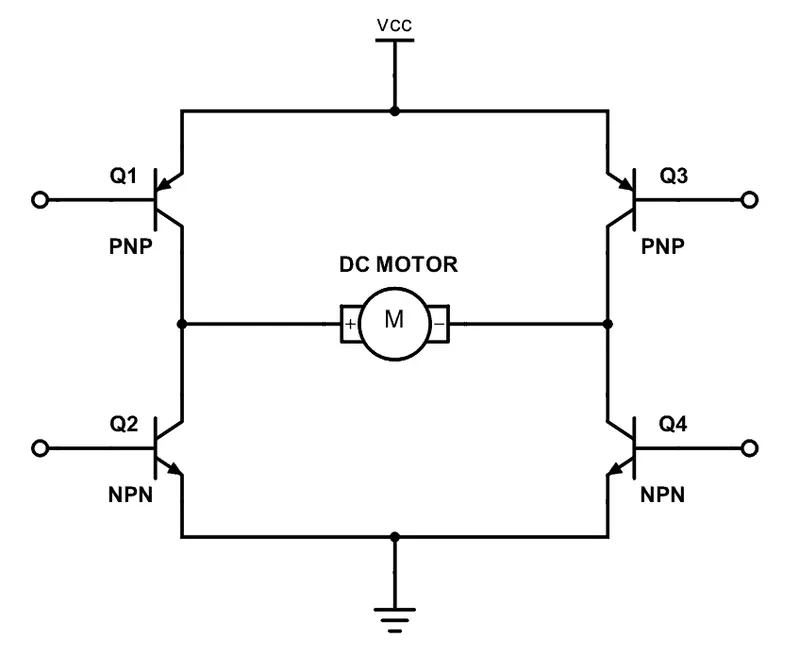
This circuit helps in the control of a DC motor to go backward or forward.
When 1 & 4 switches are cloed the motor spins in one direction and when 2 & 3 switches are closed the motor spins in the opposite direction.
Comparison :
- In H-Bridge the motor was coupled to a linear load which means the mechanical torque of the load is propotional to the speed.
- The Armature current follows the current reference very well , with fast response time and small ripples.
- 4-Quadrant DC drive uses the reference load and speed to match the motor characteristics obtained from supply current.
- The Armature current shoot-up was less compared to that of H-bridge model.
3. Constructing an EV model using DC7 block
The Four-Quadrant Chopper DC Drive (DC7) block was modified to obtain an EV.
The modified simulink modeal was attached below,
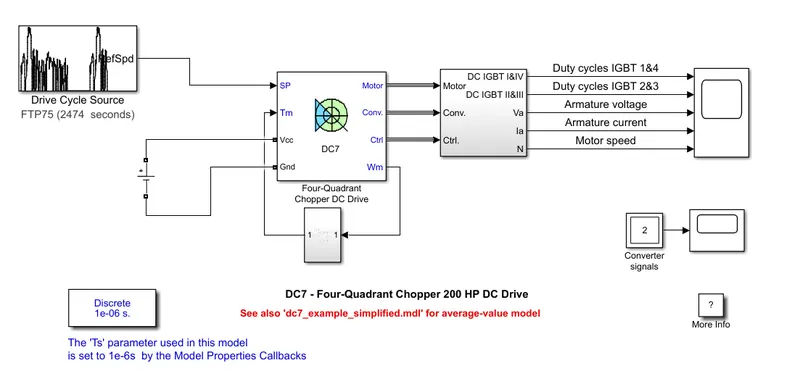
A DC Voltage source was attached to the DC7 block as the power source.
A Drive cycle data was also given as input to the motor block.
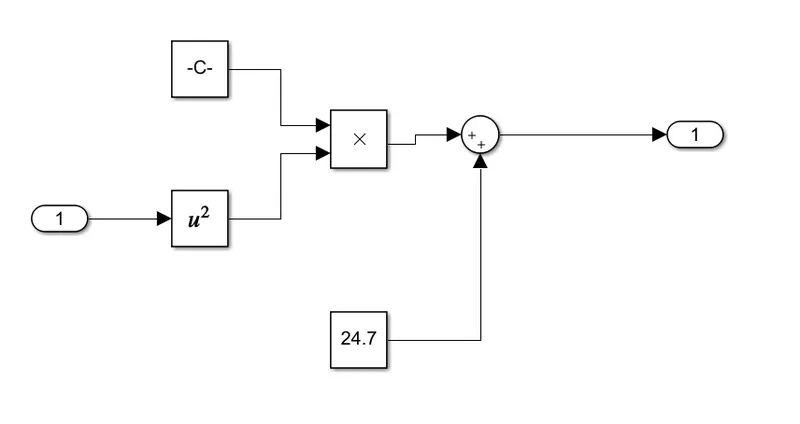
The load characteristics was given by the equation,
T = 24.7 + 0.0051ω2
This equation was converted into a block as a sub-system and was attached to the DC7 block.
The sub-system was mentioned below,
After all the modifications the simulation was ran for a runtime of 7s.
The output plot obatained was given below,
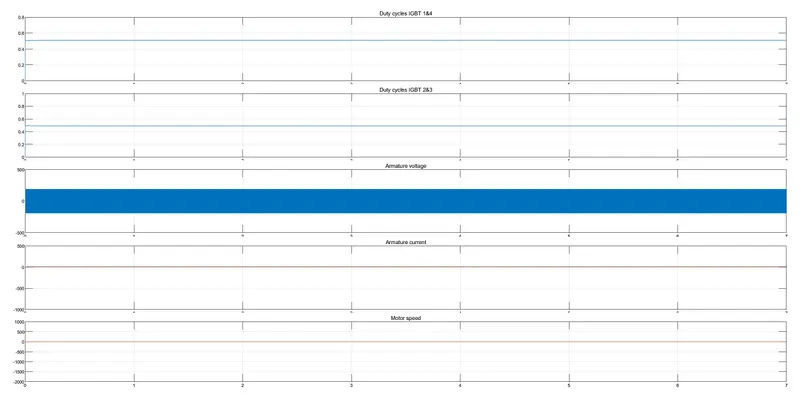
The Drive cycle used for simulation was FTP75.
This output plot provides the Duty cycles of the IGBT 1,4 and 2,3 seperately.
Further it depicts the Armature voltage, Armature current and the Motor speed.
CONCLUSION :
All the given objectives were satisfied with atmost perfection.
The calculations , images and files were attached wherever necessary.