Week-7 Challenge: DC Motor Control
1. Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor changes direction from forward to reverse.
Solution :
- The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT.
- When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V).
- Therefore, the IGBT block can be used to model the BJT device.
- The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink signal (1/0).
- The DC motor uses the preset model (5 HP 24V 1750 rpm).
- It simulates a fan type load (where Load torque is proportional to square of speed).
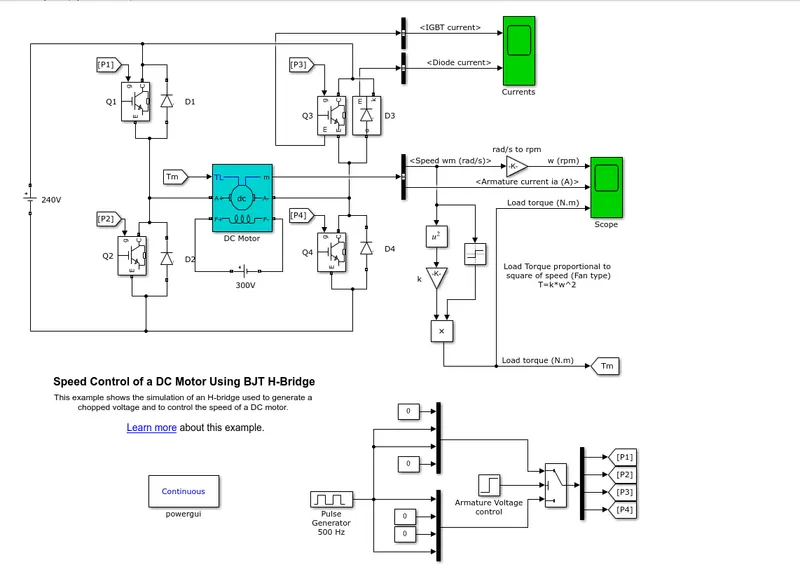
- The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
- The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models).
- Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off.
- When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
Armature Voltage Control :
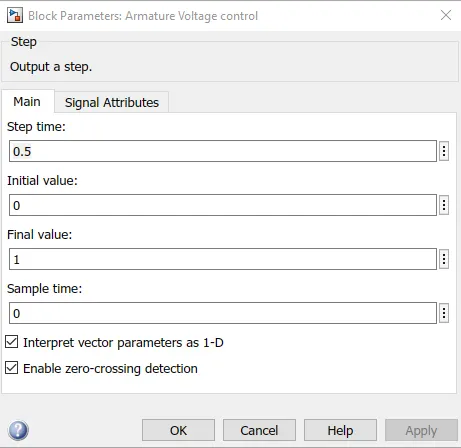
- The step-time for the simulation is taken as 0.5 seconds.
- That means each iteration will be performed for a time of 0.5 seconds.
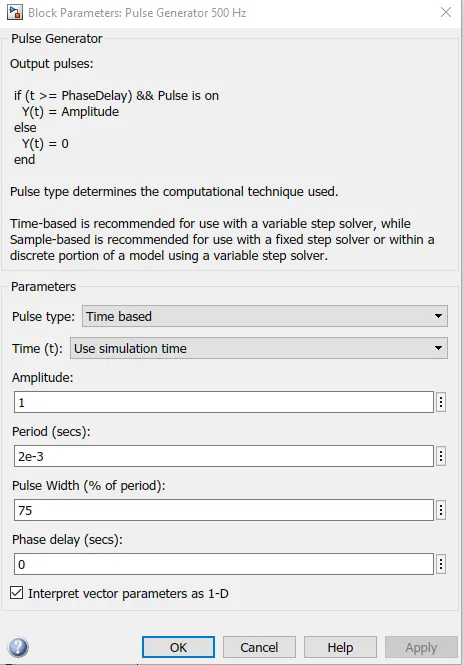
- The magnitude of the pulse generator is 500 Hz.
- The amplitude is taken as 1.
- No phase delay is given.
- The pulse width is 75%.
Result :
Plot 1 :
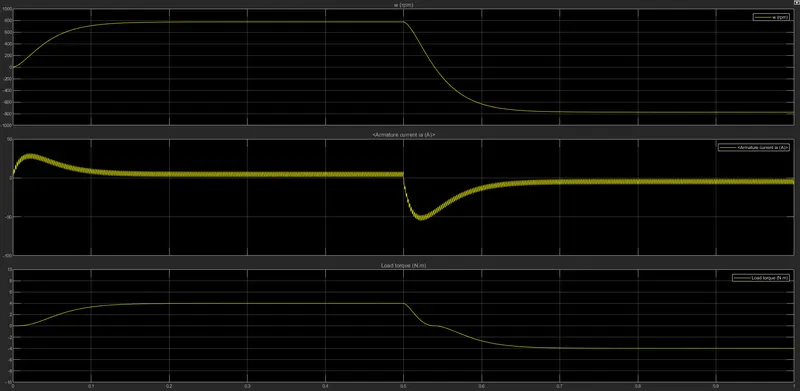
- At starting when the motor is starting the torque needed is more, hence revolution per minute of the motor is increasing as a result of which the plot starts from zero and shows an increase in variation.
- Then the motor runs for the required amount of time, and when the voltage is down the rpm falls down from around 900 rpm to a negative value.
- And then the plot gets constant.
Plot 2 :
- When the motor is starting the the current required is more as a result the graph shows a increase variation at the starting.
- When the time reaches 0.5 seconds, the armature current drops suddenly in a drastic way.
- And at the same time the armature current shoots up suddenly at 0.5 seconds, which is not desired.
- We have to make changes in such a way that the armature current does not shoots up and remains constant through out.
- The value of the current goes to a value of negative approximately -70 amperes.
Plot 3 :
- At the starting of the motor the load required increases gradually and as a result the graph shows a increase variation with respect to time.
- Then with the fall of current and torque the load also decreases.
- The load is directly proportional to the current and the armature revolution .
Modification :
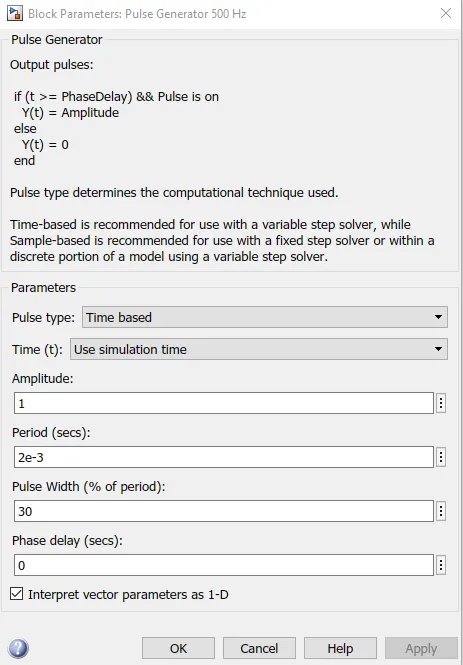
- In the block parameters the pulse generator is of 500 Hz.
- The amplitude is defined as 1
- The phase delay is given as Zero.
- The pulse width is taken as a value of 30.
Result :
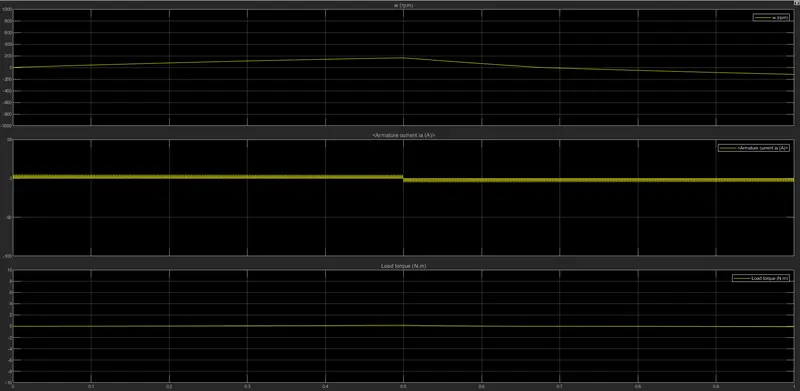
Explanation :
- When we decrease the time period of the signal or the pulse generator, we can see that the starting of the motor is smooth without any hindrance.
- The speed of the motor increases linearly with respect to time, then at time period of 0.5 seconds it a dips very negligibly as a result the armature revolution also drops and after that the rpm remains constant.
- Beacuse of the smooth revolution of the motor the current used by the motor is also less and and constant, as the speed is constant through out the armature current consumption is linear and constant.
- As a result of which the load required during the whole process of motor operation is constant through out.
2. Refer to help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with H-bridge model.
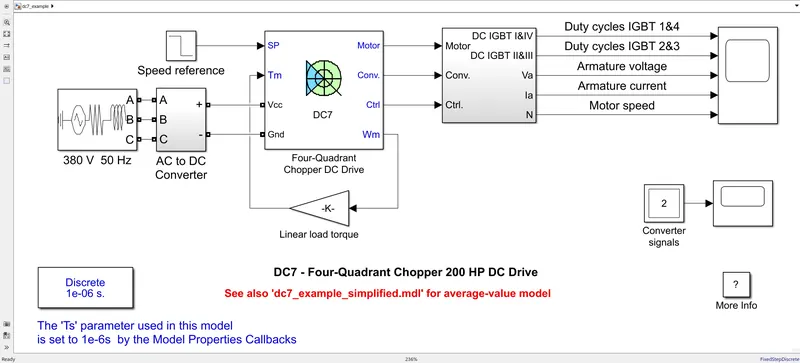
- The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source.
- The armature voltage is provided by an IGBT converter controlled by two PI regulators.
- The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source.
- In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
- The first regulator is a speed regulator, followed by a current regulator.
- The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed.
- The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system.
- The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation).
- For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3.
- This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
H-bridge vs DC7 :
- Four-Quadrant Chopper can operates in all four modes (Forward Motoring,Forward Braking, Reverse Motoring and Reverse Braking), but H-bridge can operate only in two modes (Forward and Reverse).
- In Four-Quadrant Chopper Regenerative Braking is possible, but H-bridge Regenerative Braking is not possible.
- In Four-Quadrant Chopper Two PI regulator (Speed Regulator and Current Regulator) is used to obtain electromagnetic torque needed to reach the desired speed and control the armature current and stabilize the system, but in H-bridge model PI regulator is not used.
- H-bridge is a electronic circuit that switches the polarity of voltage applied to the load and Four-quadrant Chopper is electronic switch that is used to interupt one signal under the control of another.
- H-bridge circuit are often used in Robotics and other applications to allow dc motor to run forward and backward.Four-Quadrant Chopper circuit is used to refer numerous type of electronic sitching devices and circuits used in power control and signal applications.
- Four-Quadrant Chopper model gives better efficiency and high energy(power) storage than H-bridge model.
3. Make a suitable EV model using DC7 block and make result report.
Solution :
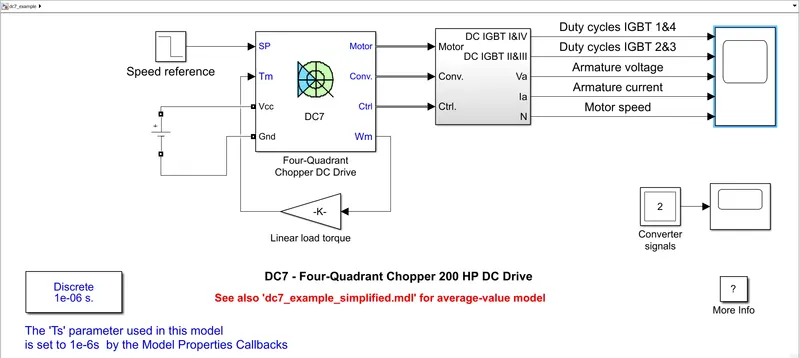
- The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source.
- In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
- The first regulator is a speed regulator, followed by a current regulator.
- The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed.
- The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system.
- The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation).
- For proper system behavior, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3.
- This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
The general Description for the model given in Mathworks help documents is as above.
How to model it for an Electric vehicle
- The energy source of an EV is a battery or fuel cell. Let’s take the case of a battery.
- So the model can be modified with an input of a battery from the Simulink Library Browser.
- You can take a generic battery model and configure it by referring to any datasheet sheet related to an EV vehicle battery model.
- Otherwise the easy option is to use a simple DC source as your energy source and give the appropriate voltage value for an EV. The scope results vary in both cases from each other
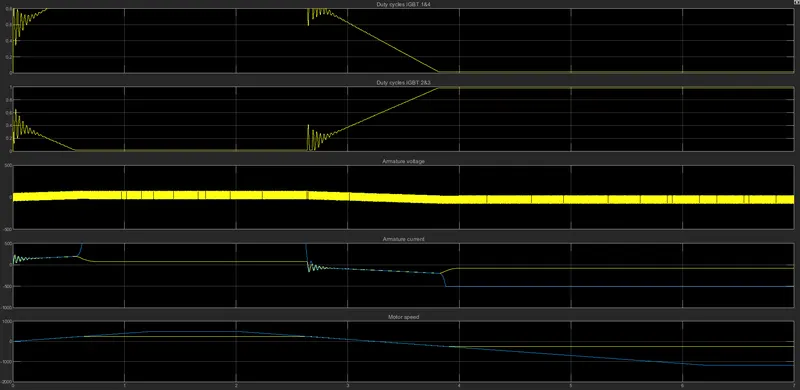
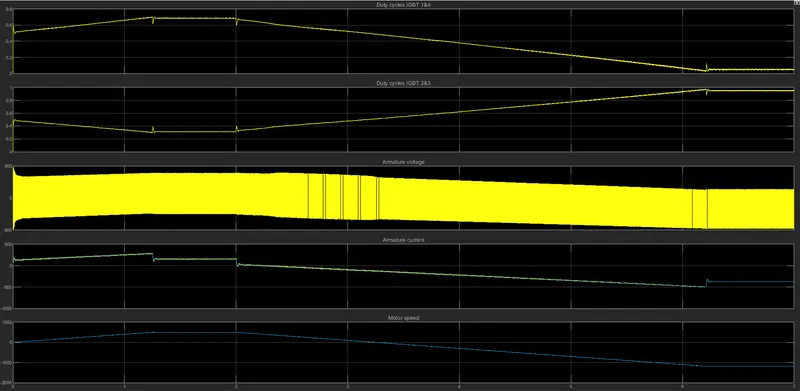
- From the above plot-1, observed that when the motor Speed increases, IGBT 1&4 duty cycle also increases.
- From the above plot-2, IGBT 2&3 is mirror image of IGBT 1&4. when the motor Speed increases, IGBT 2&3 of duty cycle decreases.
- In Plot-3, According to the motor speed Voltage level will be supplied from the DC Voltage Source. Whenever Speed increases more voltage will be required.
- In Plot-4, Observed that Voltage is proportional to Current. when Voltage increases Current increases and current in positive, when voltage decreases current also decreases and current goes in negative.
- In Plot-5, Motor Speed has shown, which was input reference speed is given in Drive Cycle Source. Motor Speed rises and reached maximum speed of 0-500 rpm approximately.