Week 7 Challenge - Assembly Workbench
Assembly Workbench
Objective
To create assemblies of Quick return mechanism and CV joint and to also create a 2D drawing of the given assemblies’ components.
Introduction
Assembly Workbench in CATIA is a tool used for creating and managing assemblies of 3D models. It allows users to assemble various parts and components into a single product and simulate the assembly to check for fit, interference, and other design considerations. Assembly Workbench provides tools for managing assembly constraints, such as mating and aligning components, as well as tools for analyzing the assembly and its components. In CATIA, Assembly Workbench is an essential tool for creating complex mechanical products or systems.
Procedure To Create These Bodies and Assemble Them Together
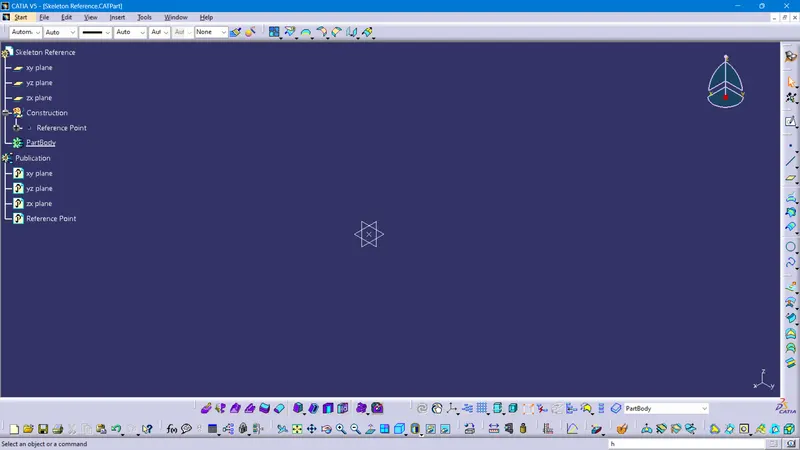
In order to create the Quick Return Mechanism & the CV Joint, we need to assemble their respective individual parts. The 2D drawings provided in the challenge can be used to create these parts. Once the parts are created, they can be assembled to form complete bodies. This process involves carefully following the assembly instructions and ensuring that each part is correctly positioned and secured. As a professional, it is important to communicate clearly and concisely to colleagues or team members about the steps involved in the assembly process and to ensure that everyone understands the requirements and expectations for the project but since currently I am doing this entire p In CATIA's Assembly Workbench, the creation of a reference point, known as the Skeleton Reference, is a crucial step in designing an assembly. This point serves as the origin for assembling the various parts in relation to it. To ensure the proper positioning of parts, a reference point must also be created for each individual component.
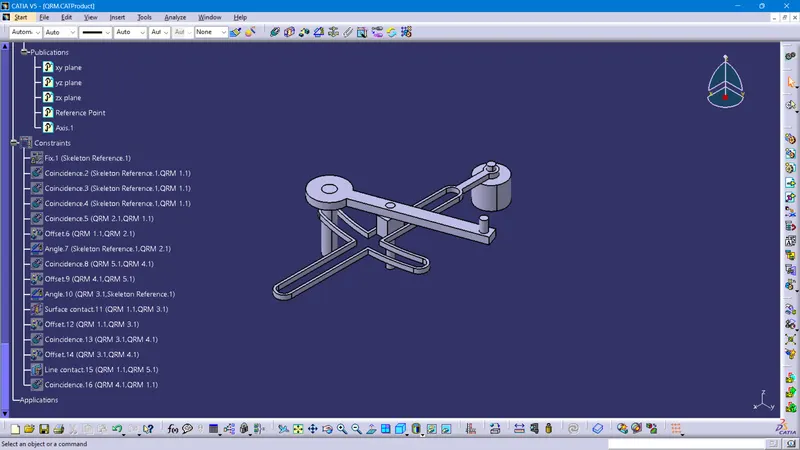
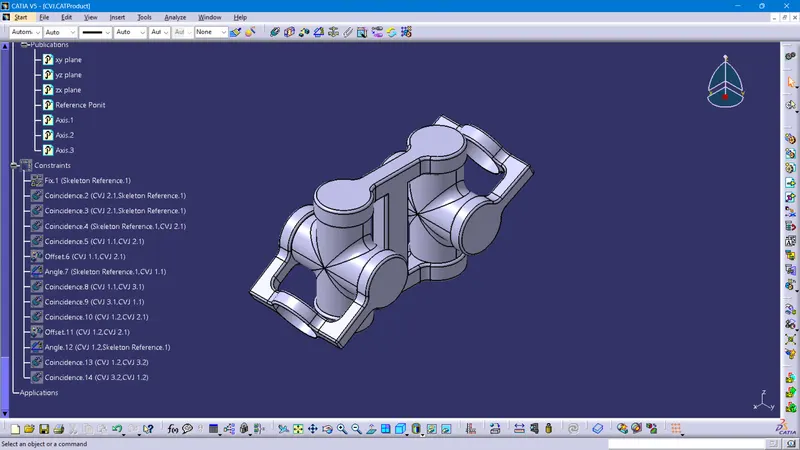
To establish the Skeleton Reference, the 'Fix Component' command in the Constraint Toolbar is employed. This command allows for the anchoring of the Skeleton Reference point to a specific location. Once established, the individual parts can be connected to the Skeleton Reference point using the 'Constraint Toolbar' in the Assembly Workbench.
The Coincidence Constraint tool is a commonly used command in the Constraint Toolbar, which is employed to link the reference points of each individual part to the Skeleton Reference point. This ensures that the parts are assembled together in the correct orientation and position as required by the design.
In summary, creating a Skeleton Reference point and employing the Coincidence Constraint tool to connect individual parts to it is a critical process in CATIA's Assembly Workbench. The proper use of these tools ensures the accurate modeling, testing, and analysis of assemblies, resulting in a final product that meets the desired specifications.
Various points and axes are made for each body so that it can be assembled with respect to the skeleton reference point process on my own hence I have to take all these things into consideration.
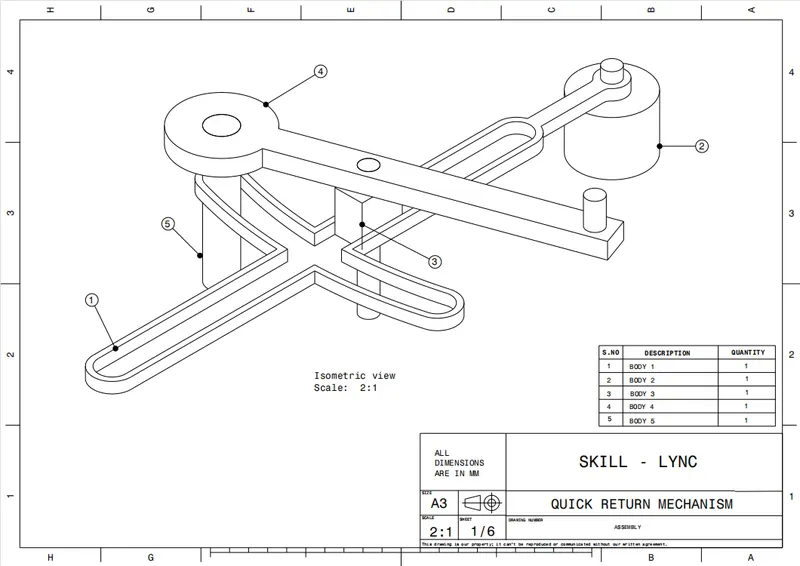
Assembly of Quick Return Mechanism
Quick Return Mechanism
A quick return mechanism is an apparatus that converts circular motion into reciprocating motion in presses and shaping machines, which are utilized to shape stocks of metal into flat surfaces. This mechanism is mostly used in shaping machines, slotting machines, and in rotary internal combustion engines. The word quick return indicates that the returning stoke is faster than the forward stroke which helps the tool to retrieve back faster after doing a particular job. Quick-return mechanisms feature different input durations for their working and return strokes. The time ratio of a Quick Return mechanism is the ratio of the change in input displacement during the working stroke to its change during the return stroke.
Let us create Assembly modeling which deals with multiple files that represent components within a product. The components within an assembly are represented as solid part bodies or surface models.
Quick Return Mechanism Part 1 (Oscillating Arm)
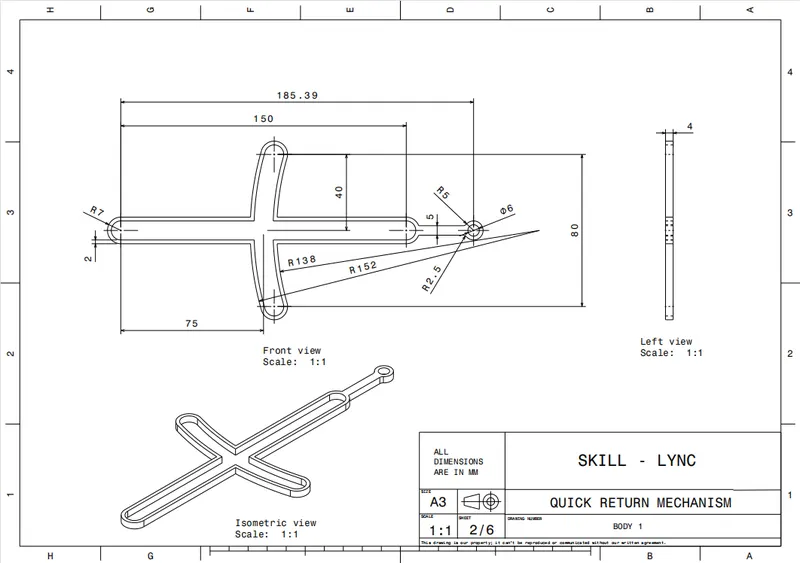
Views of the Oscillating Arm
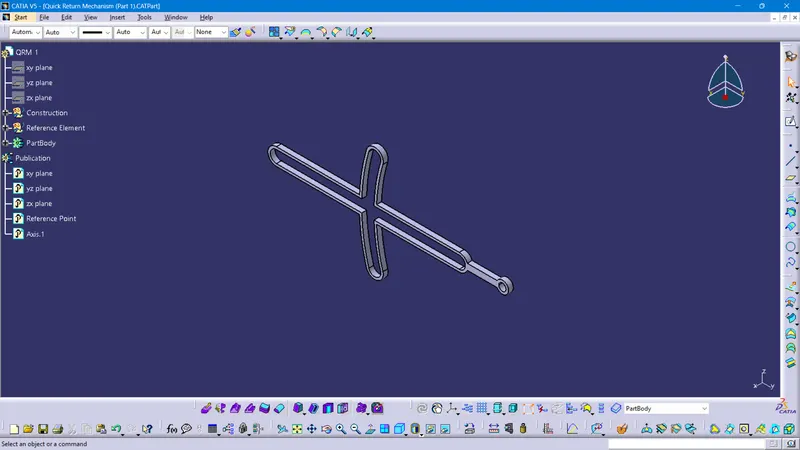
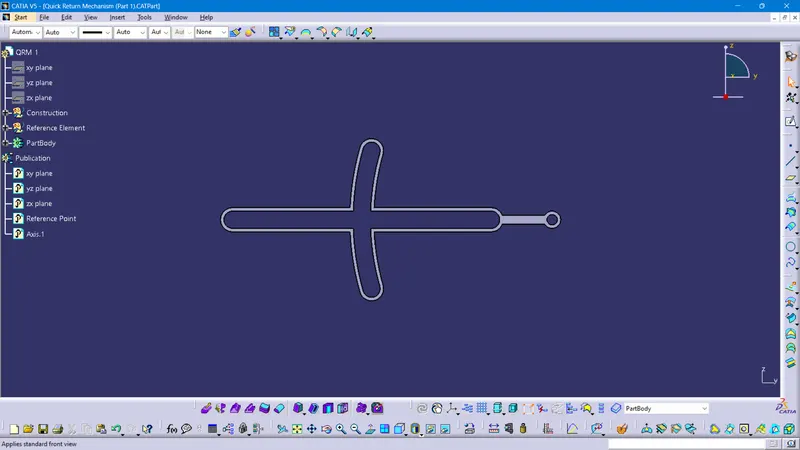
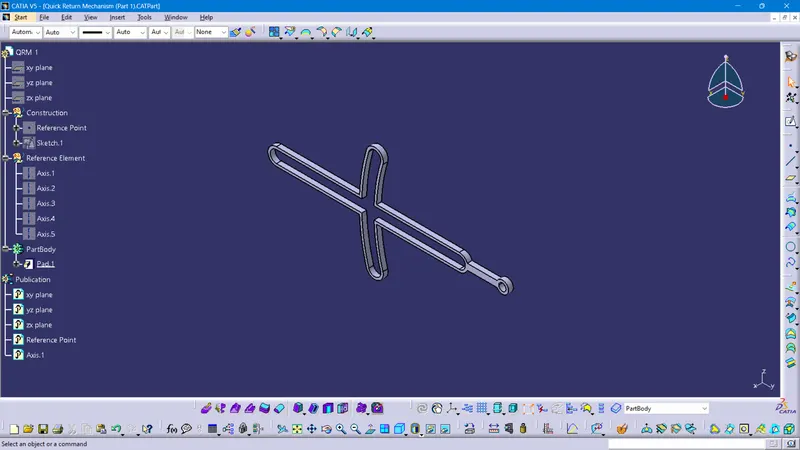
Feature Tree of the Oscillating Arm
Quick Return Mechanism Part 2 (Pivot)
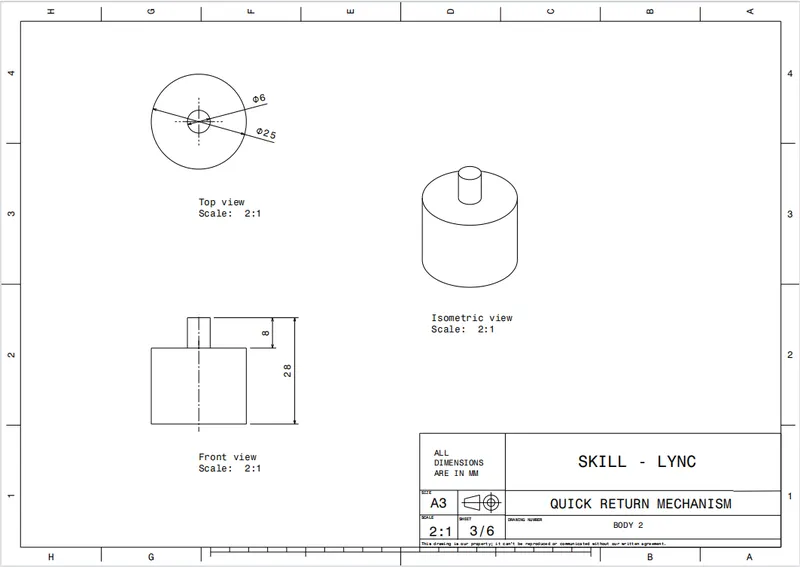
Views of the Pivot
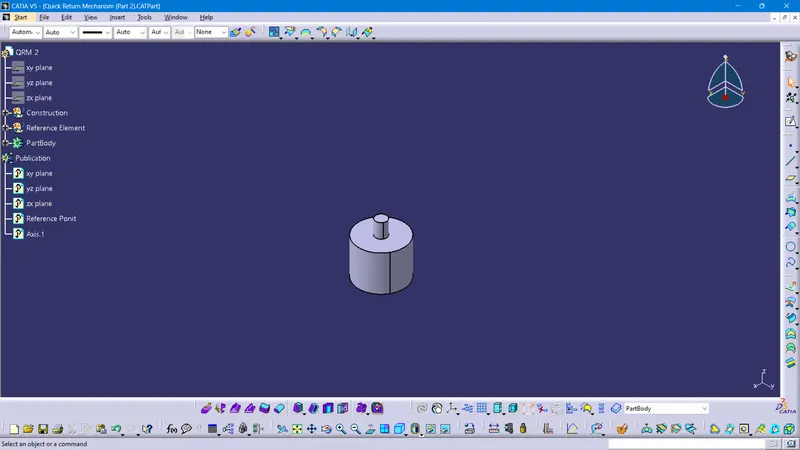
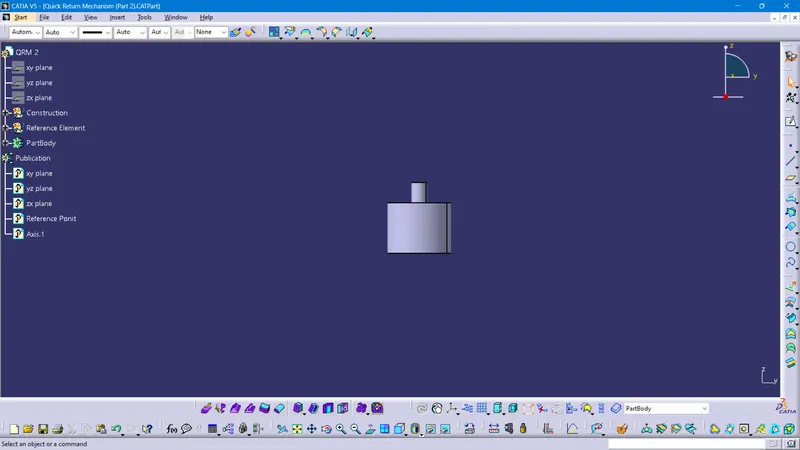
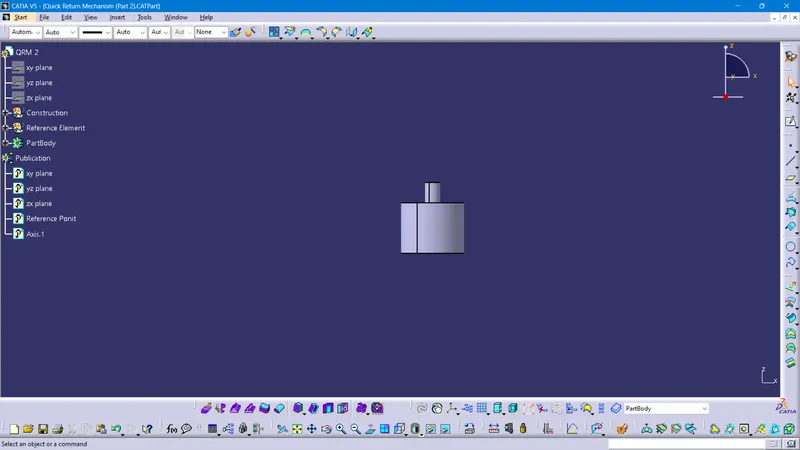
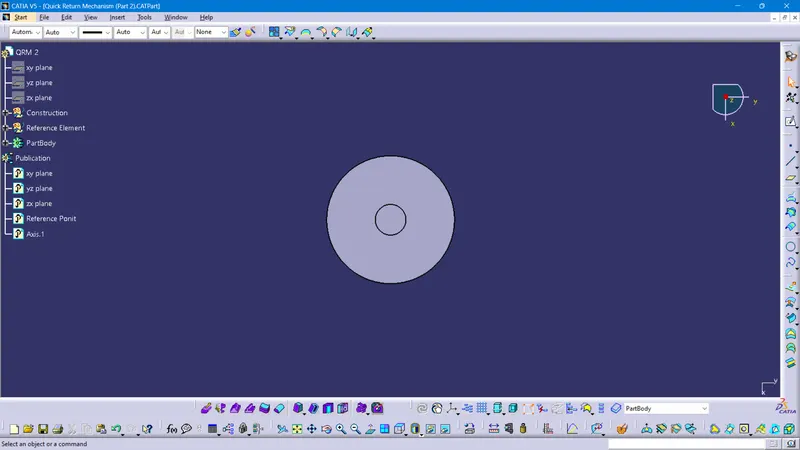
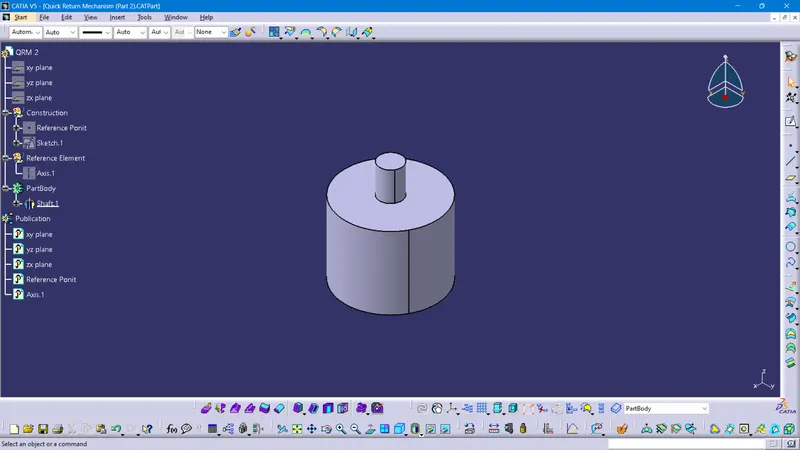
Feature Tree of the Pivot
Quick Return Mechanism Part 3 (Oscillating Pin)
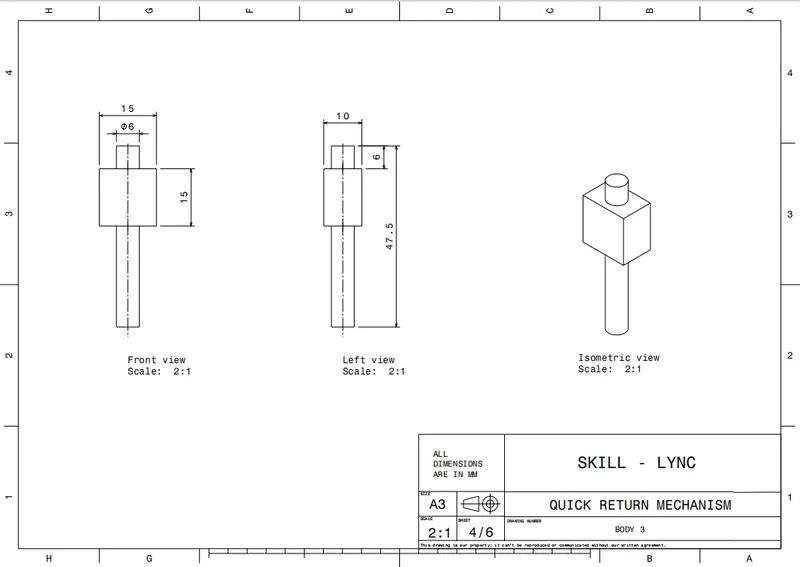
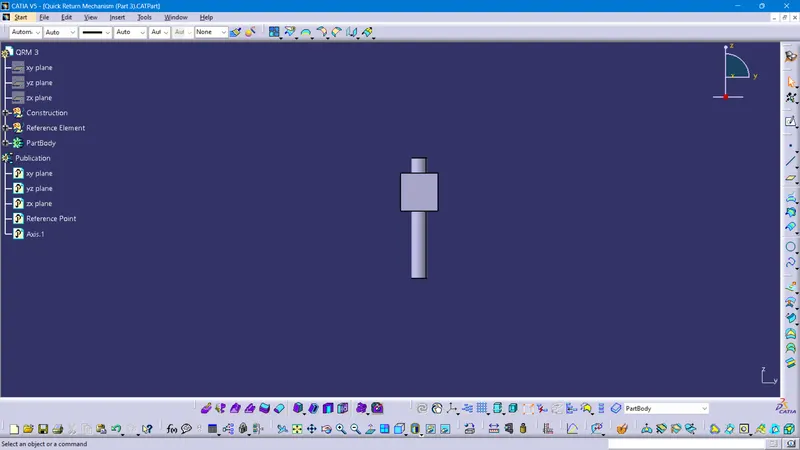
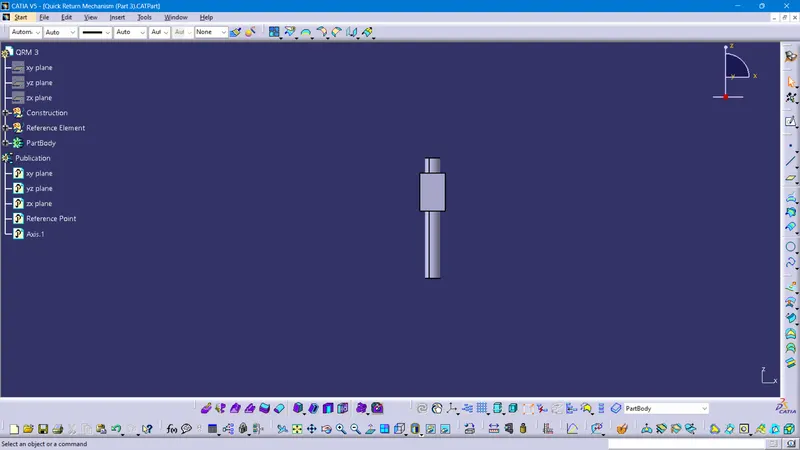
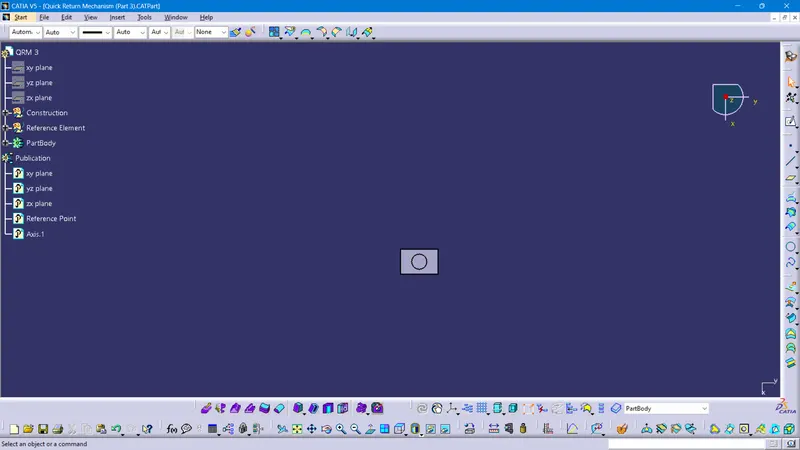
Views of the Oscillating Pin
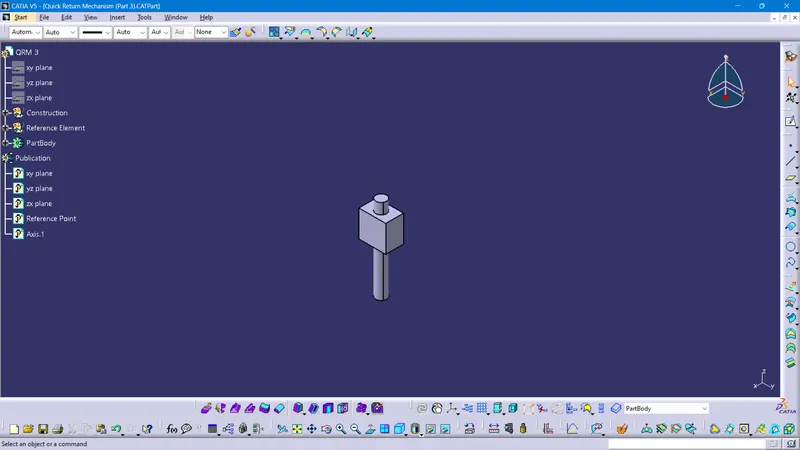
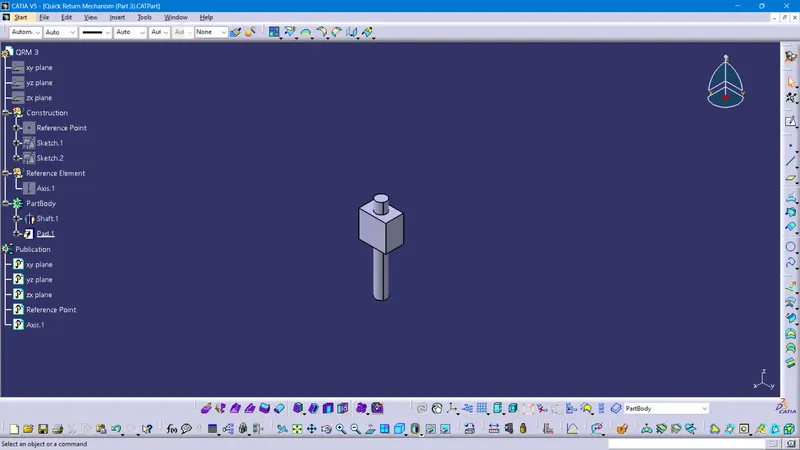
Feature Tree of the Oscillating Pin
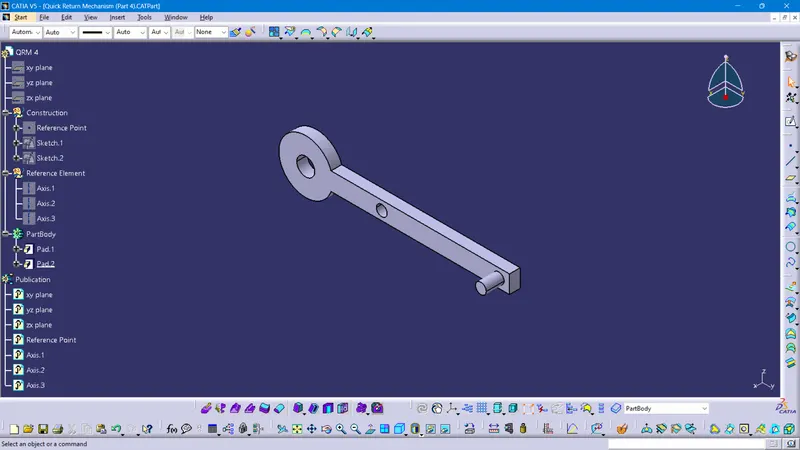
Quick Return Mechanism Part 4 (Rotating Arm)
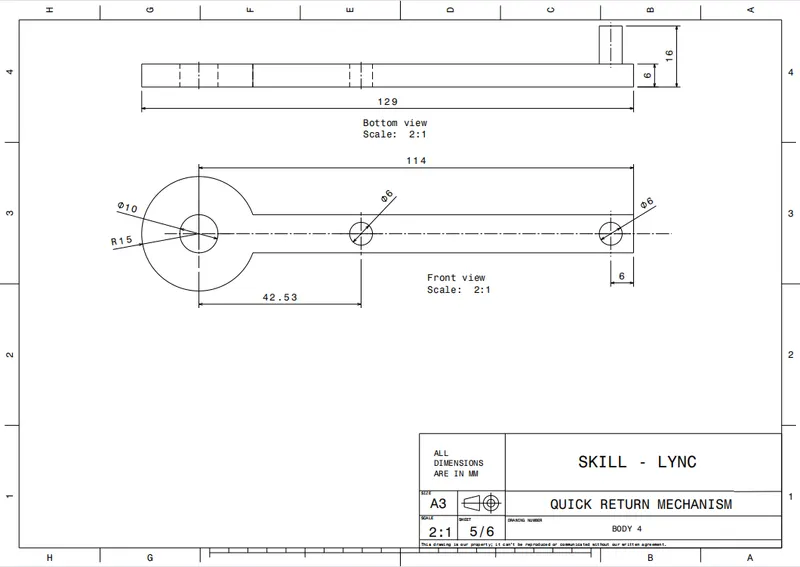
Views of the Rotating Arm
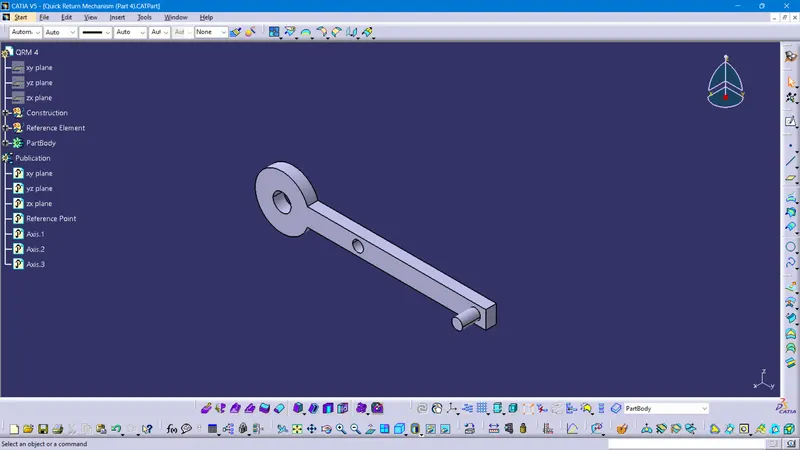
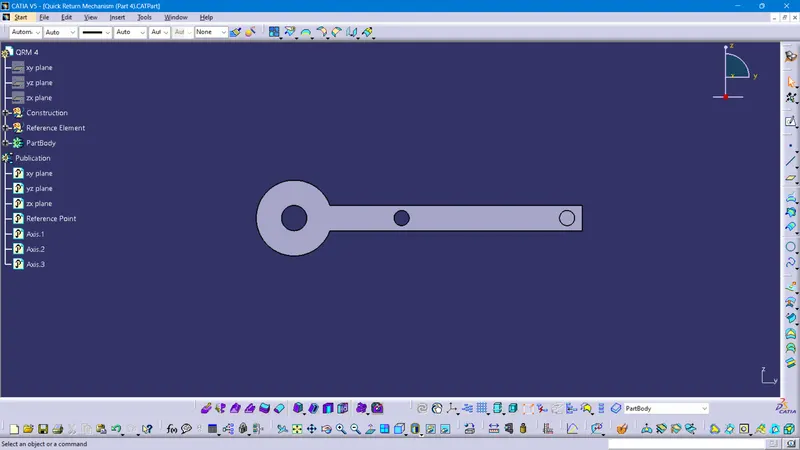
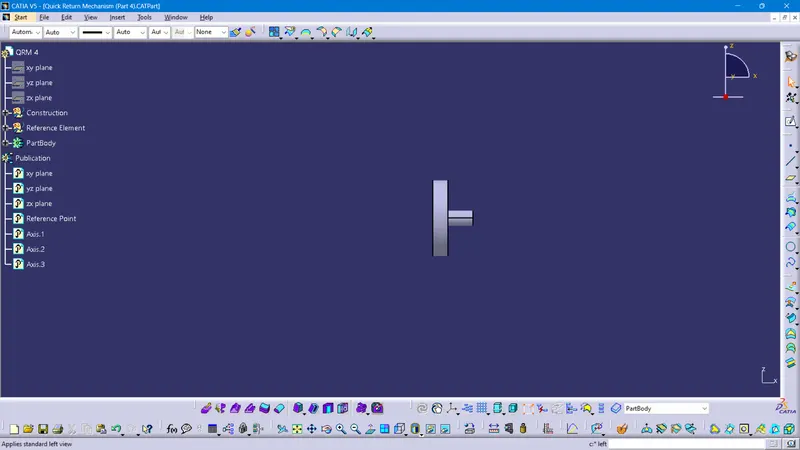
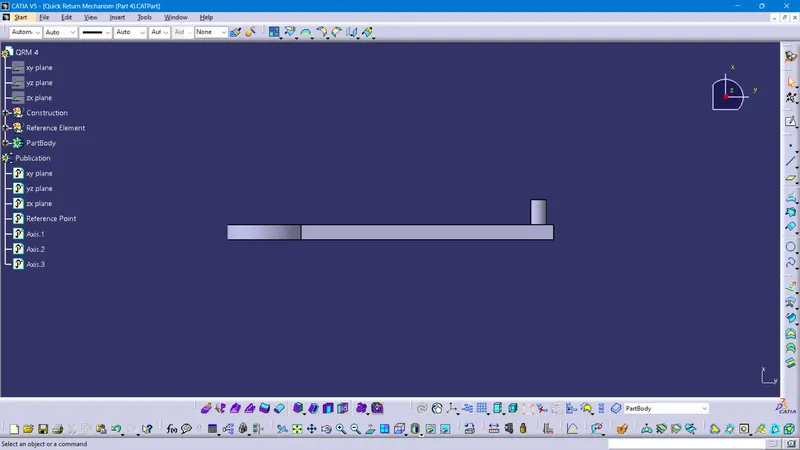
Feature Tree of the Rotating Arm
Quick Return Mechanism Part 5 (Pin)
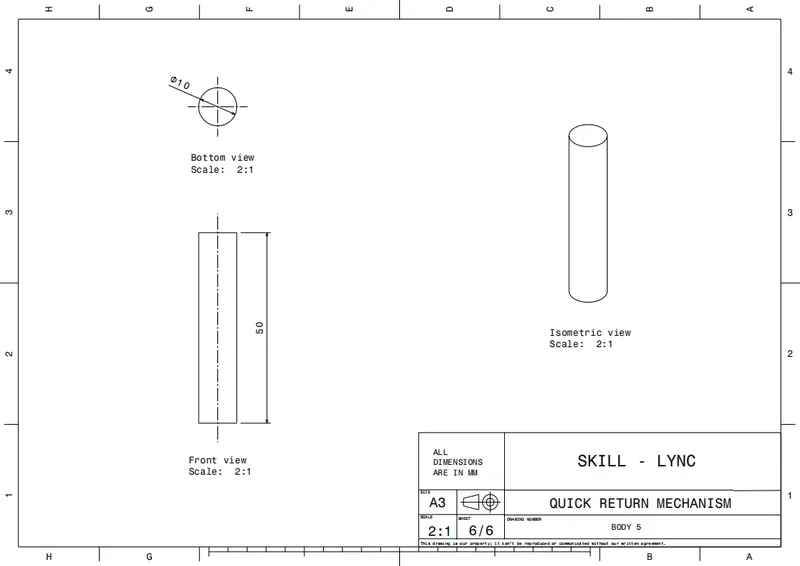
Views of the Pin
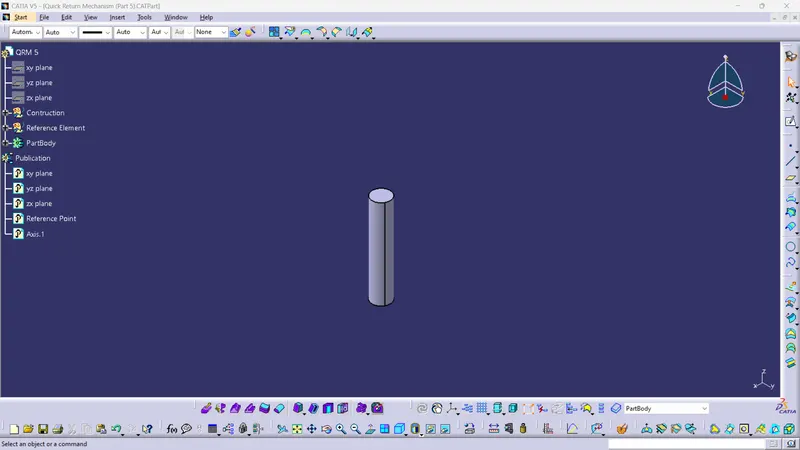
Feature Tree of the Pin
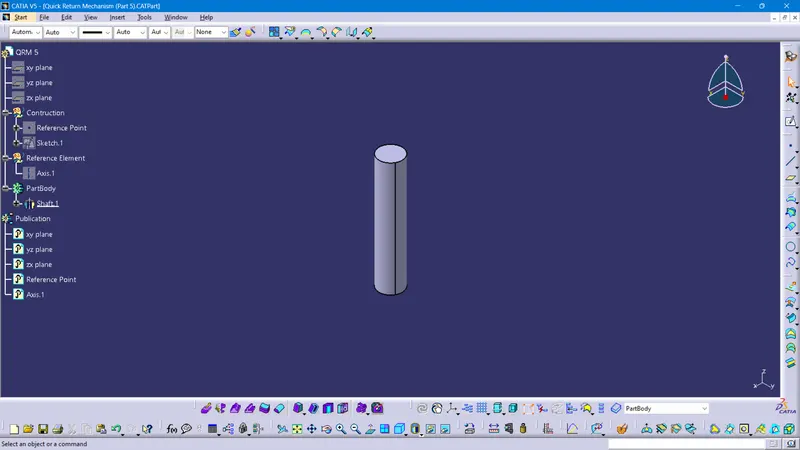
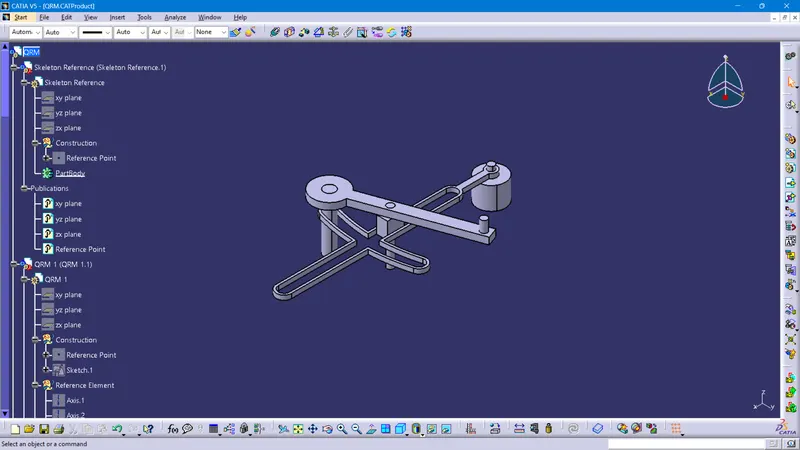
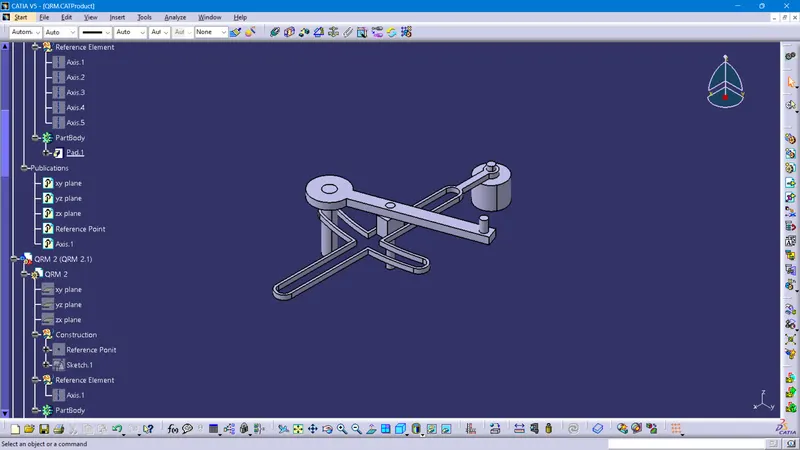
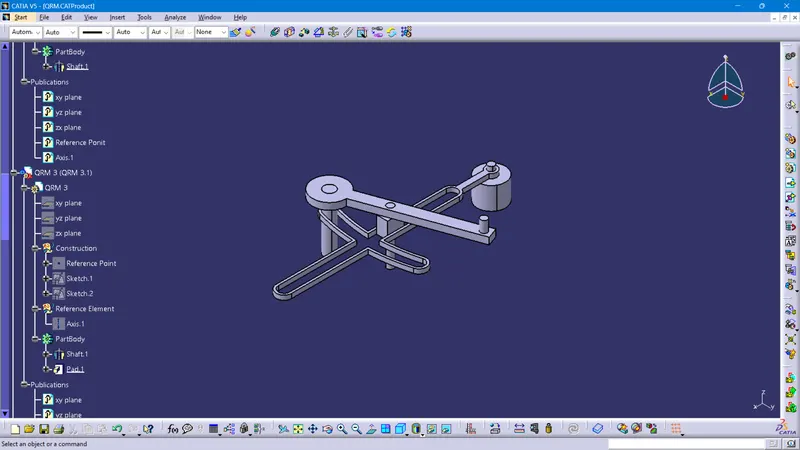
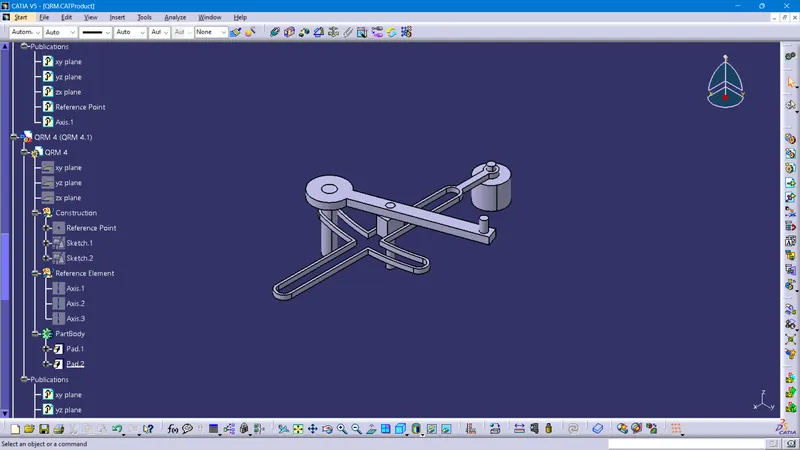
Views of the Assembly
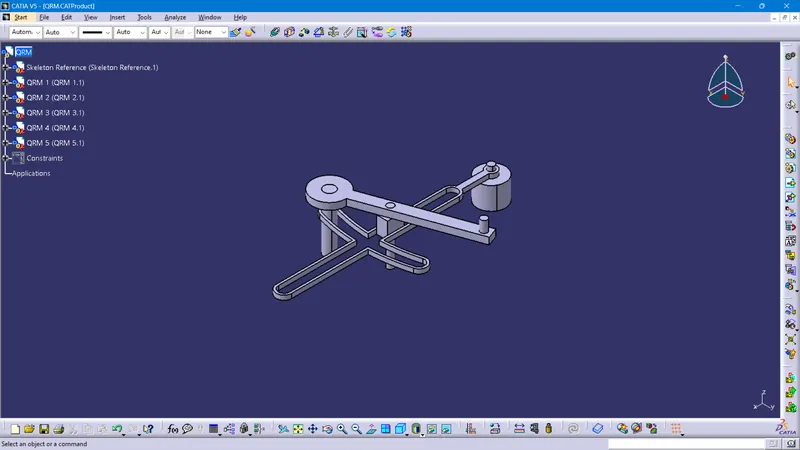
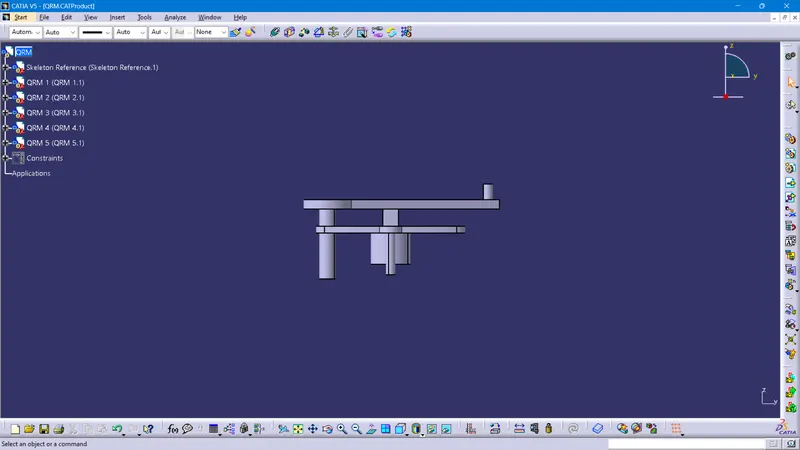
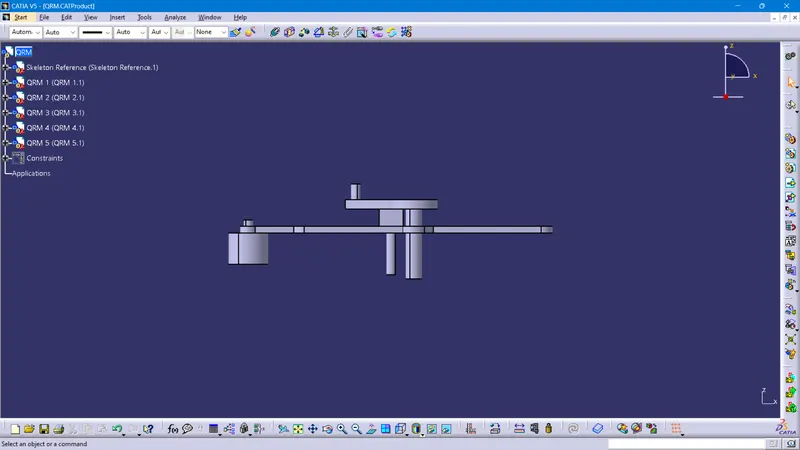
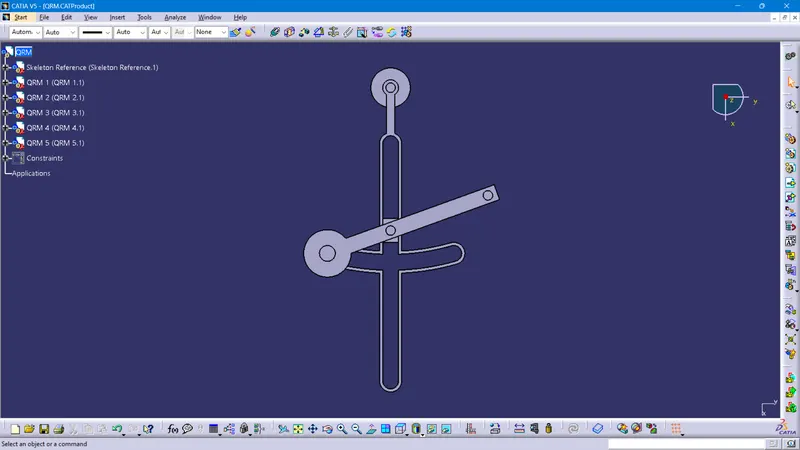
Feature Tree of the Assembly
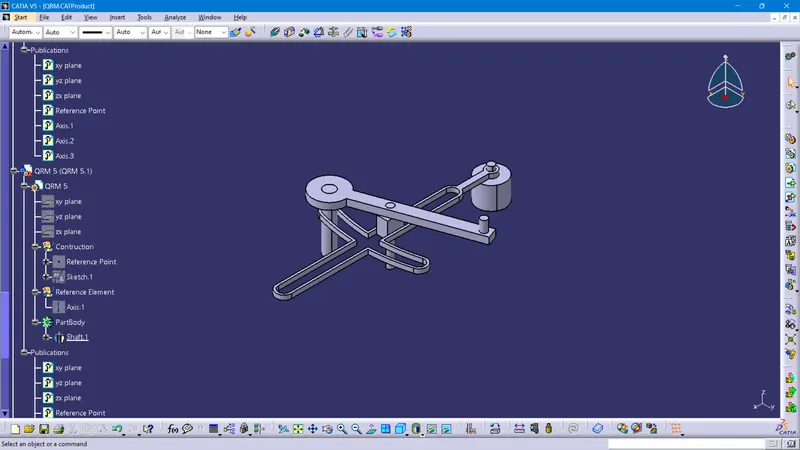
Assembly of Cv-Joint
Cv-Joint
CV joints are part of the driveshaft and are used primarily on front-wheel drive vehicles, but they are also used in the rear- and four-wheel drive vehicles. CV, joints are used to connect your vehicle's transmission to your wheels.
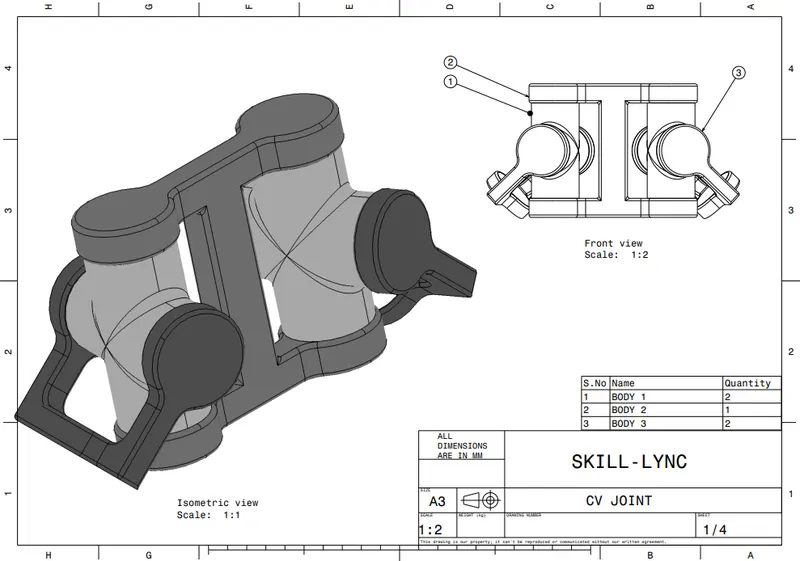
Cv-Joint Part 1 (Cross Journal)
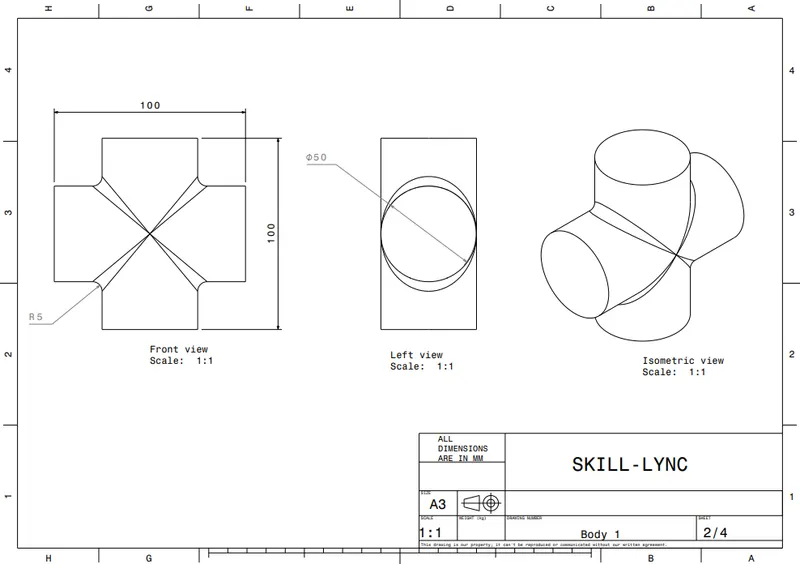
Views of the Cross Journal
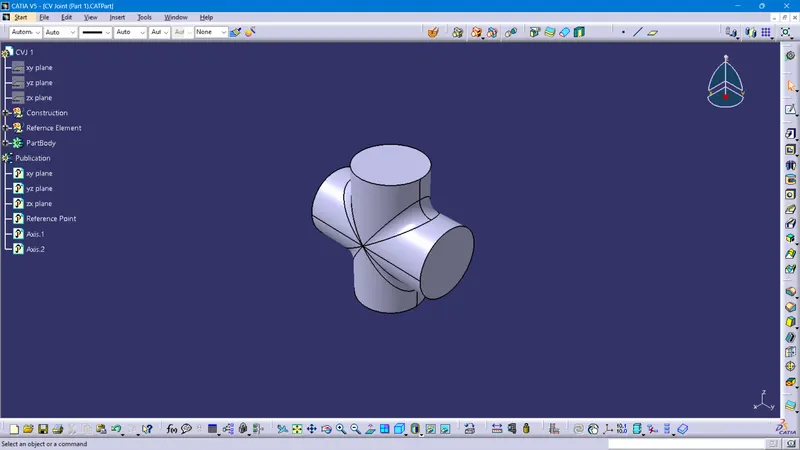
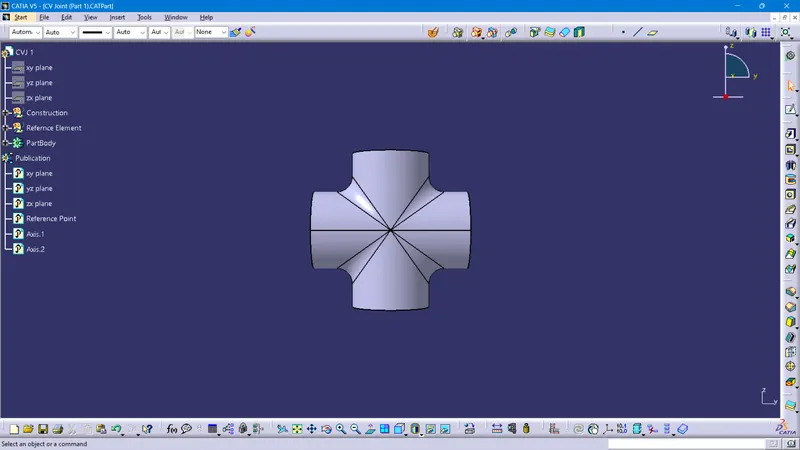
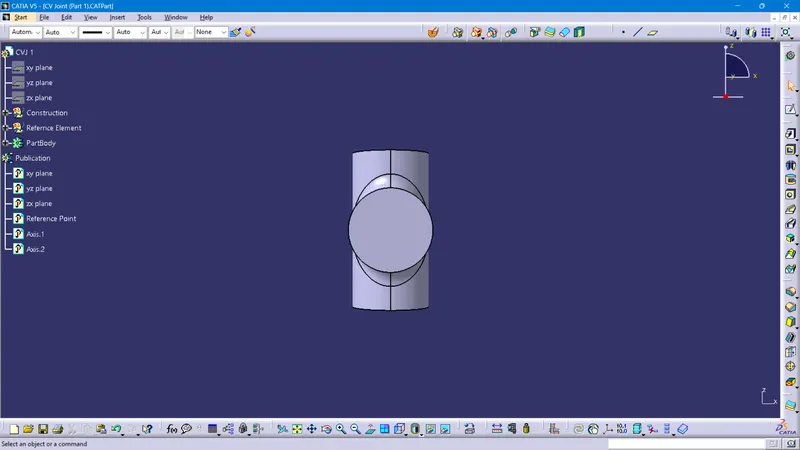
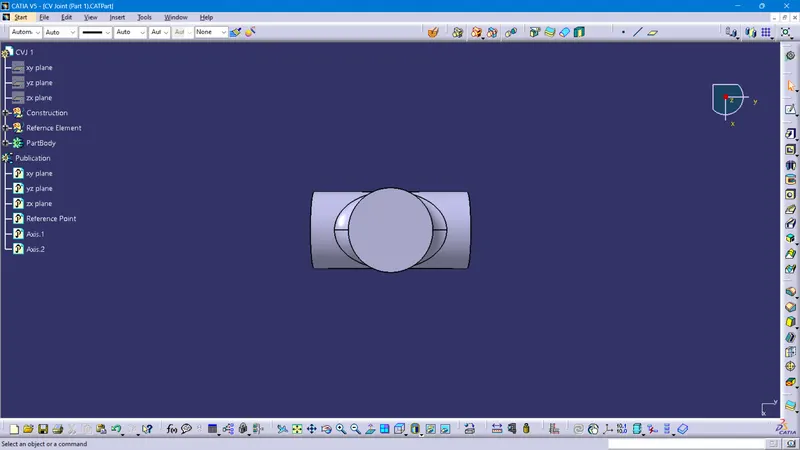
Feature Tree of the Cross Journal
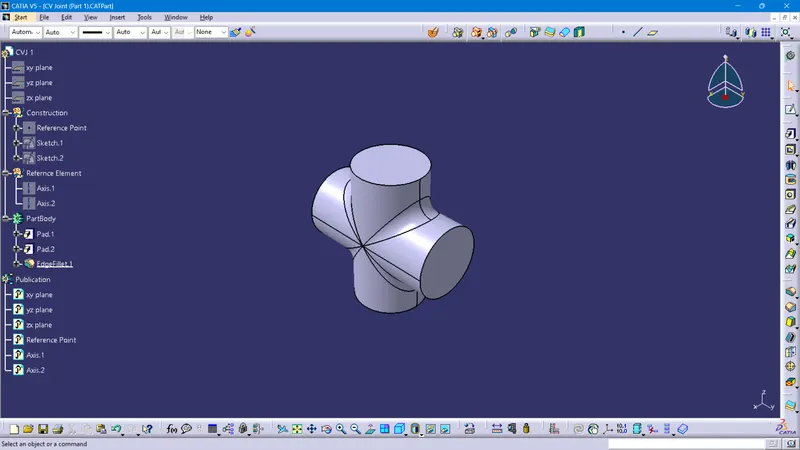
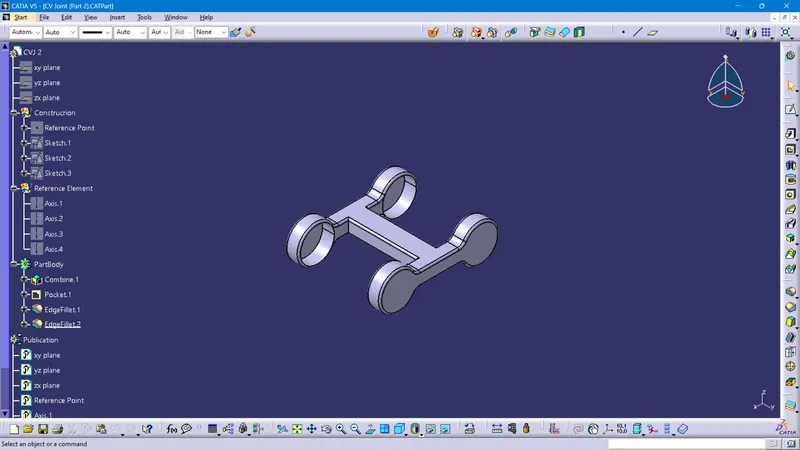
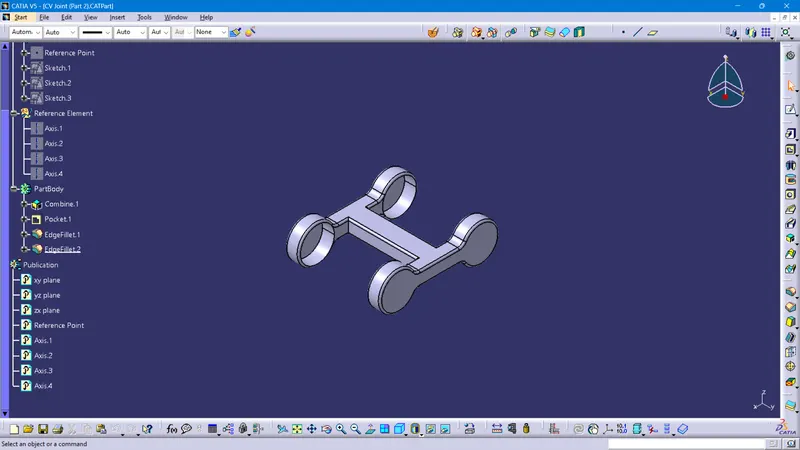
Cv-Joint Part 2 (Central H Yoke)
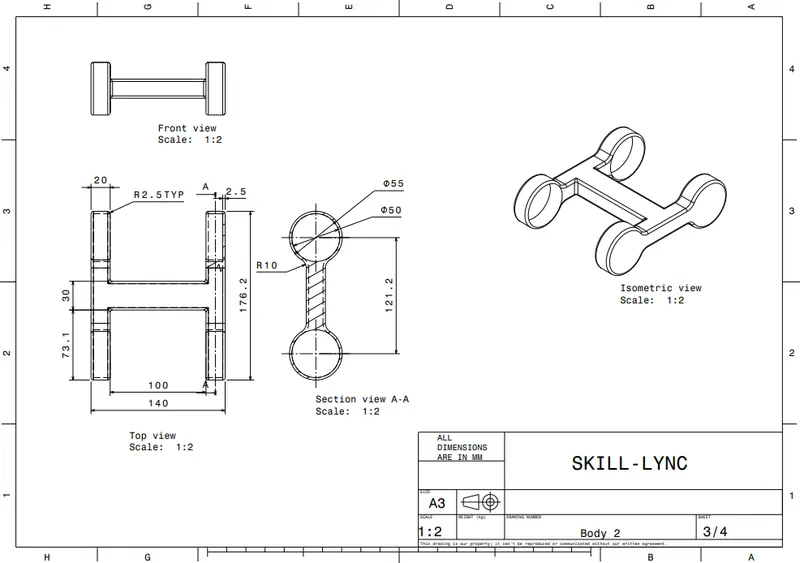
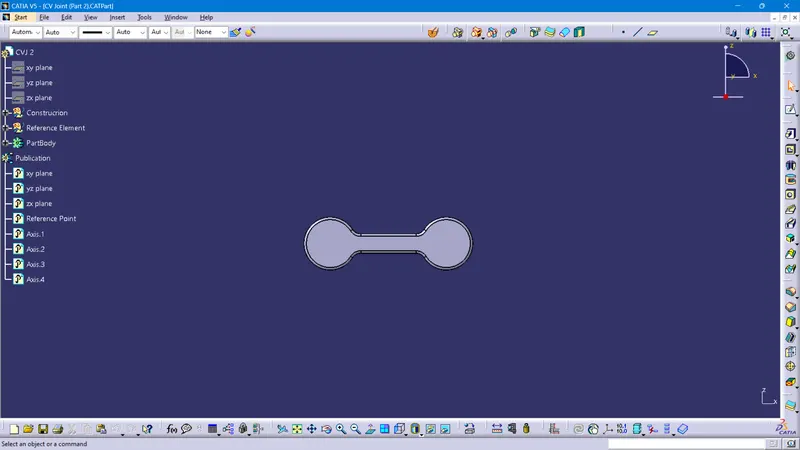
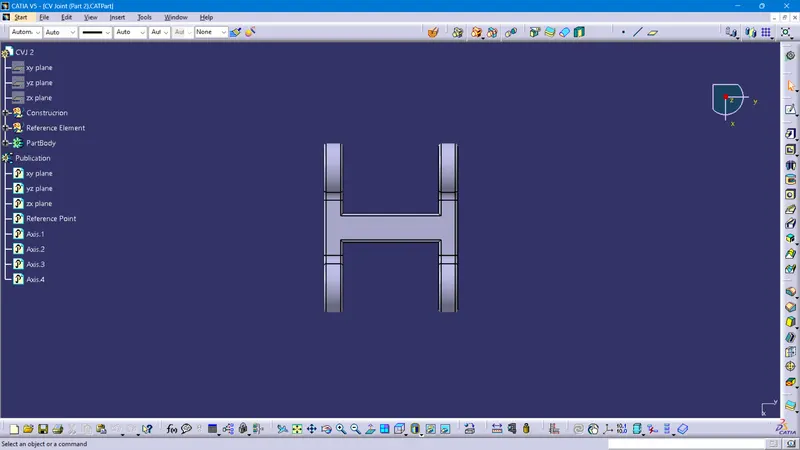
Views of the Central H Yoke
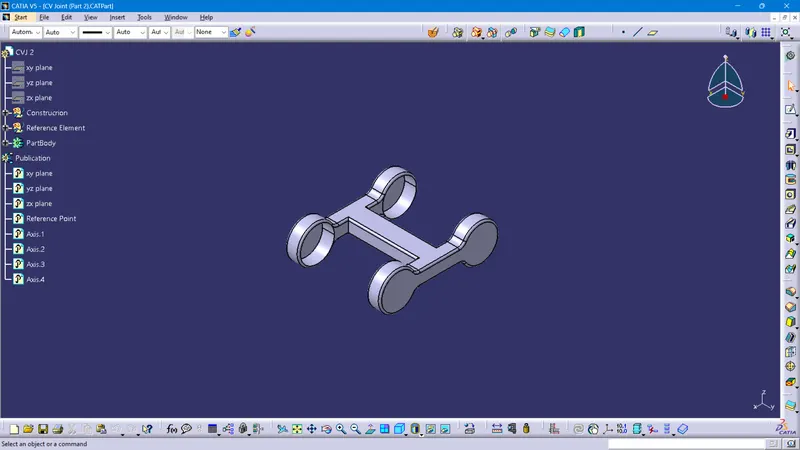
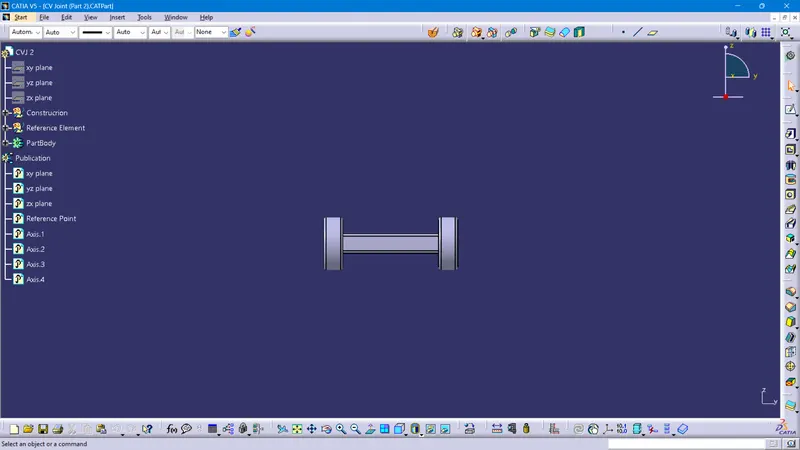
Feature Tree of the Central H Yoke
Cv-Joint Part 3 (Yoke)
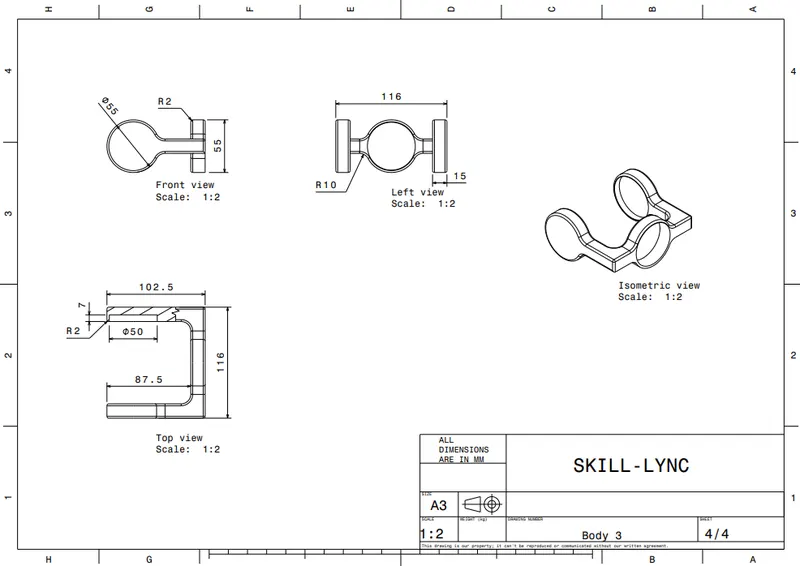
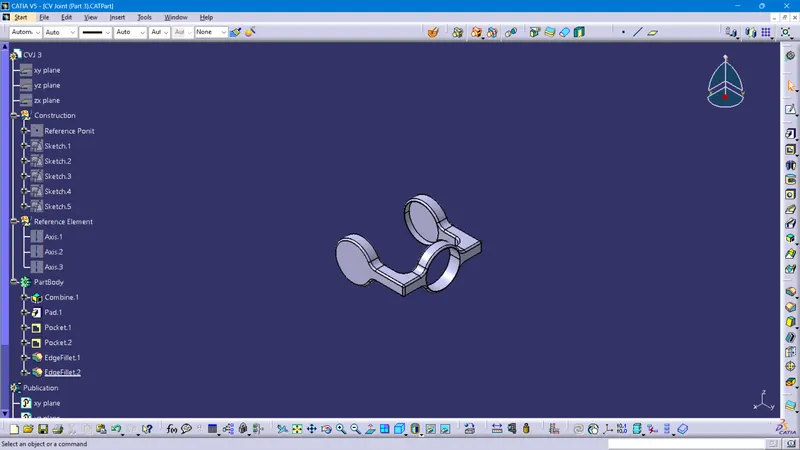
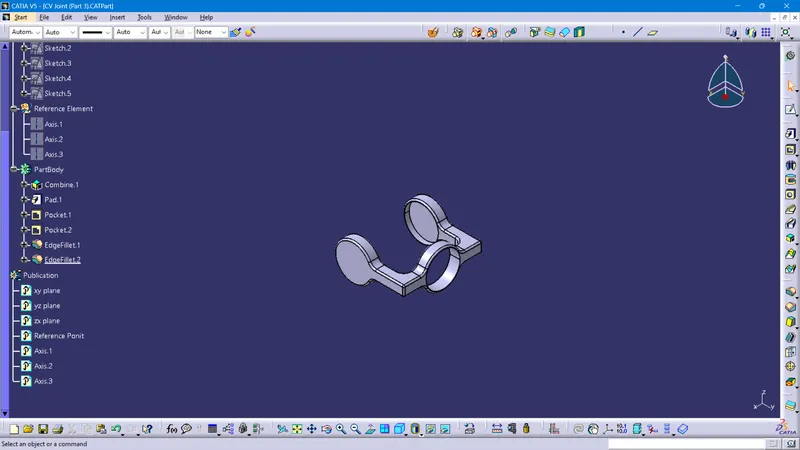
Views of the Yoke
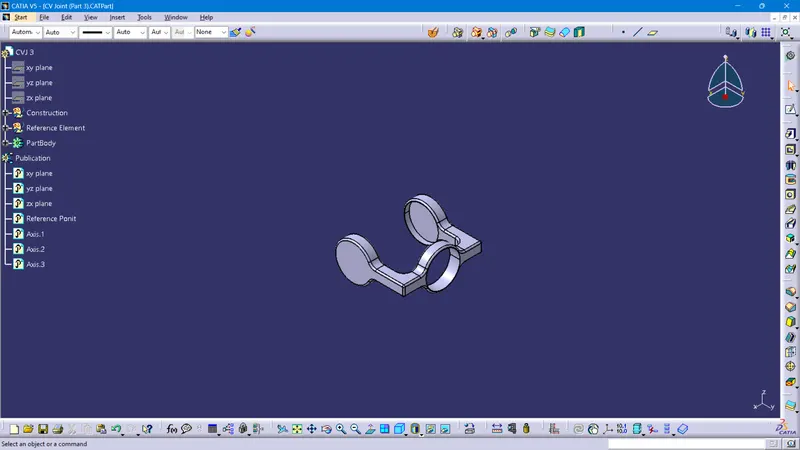
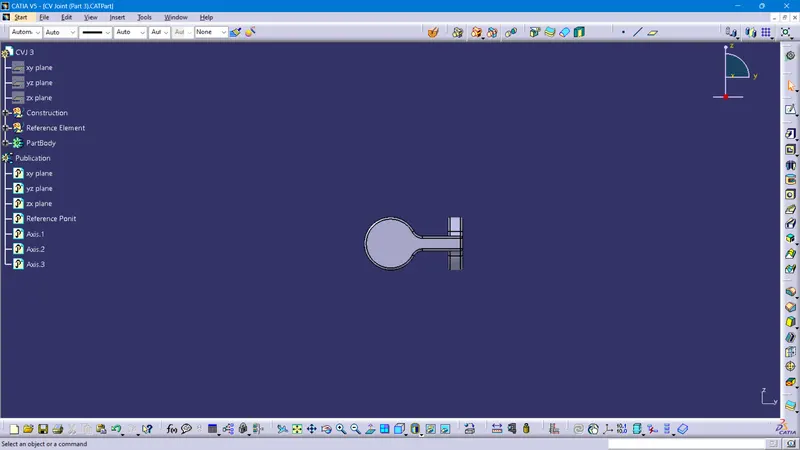
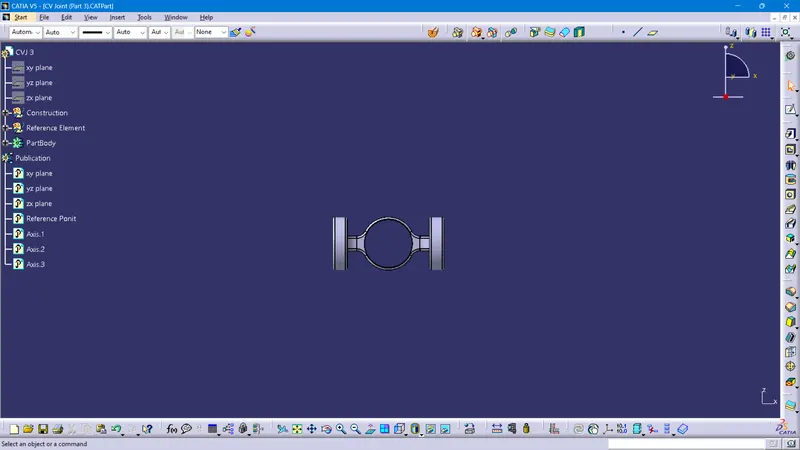
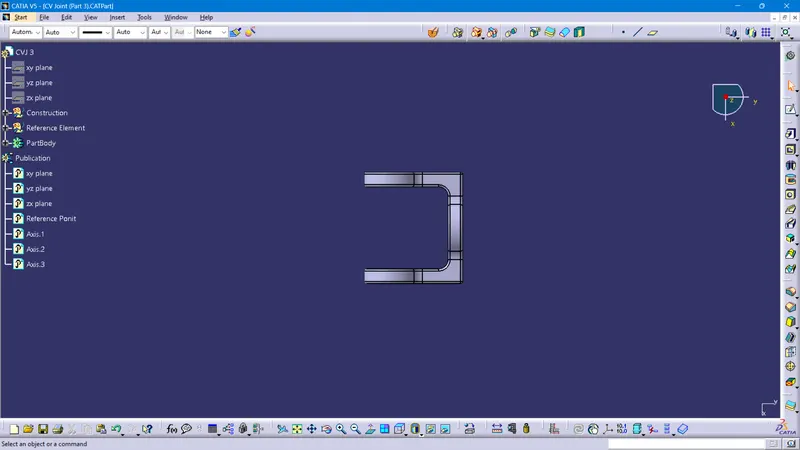
Feature Tree of the Yoke
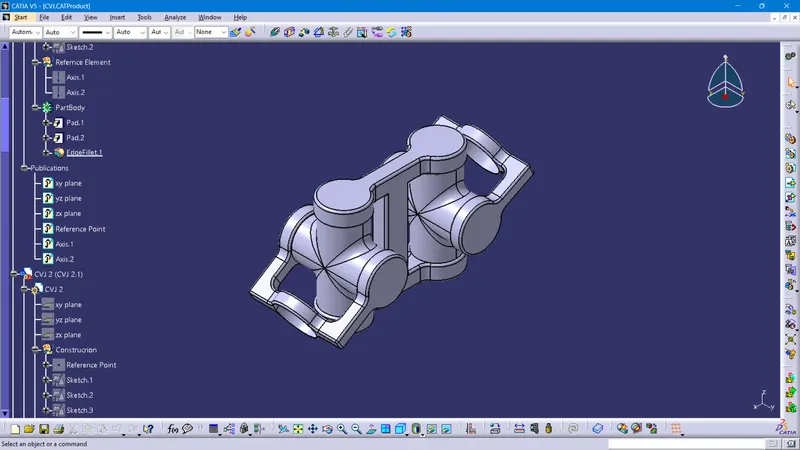
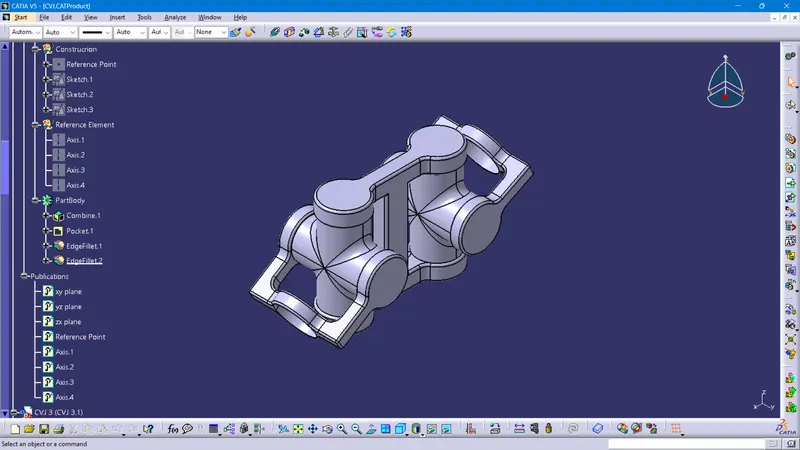
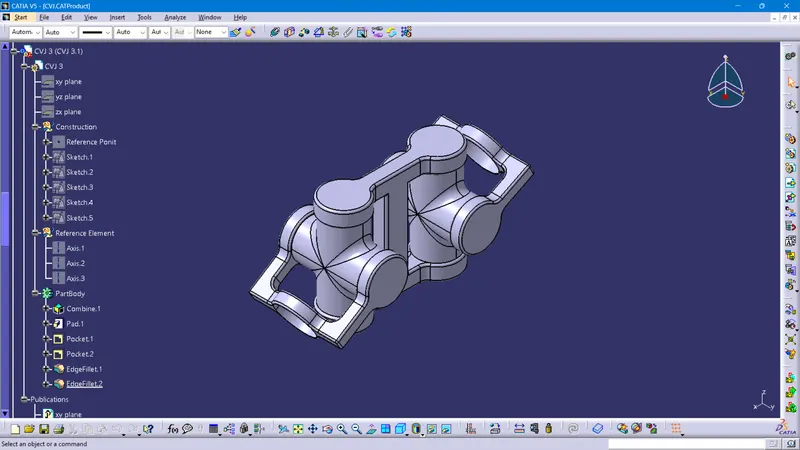
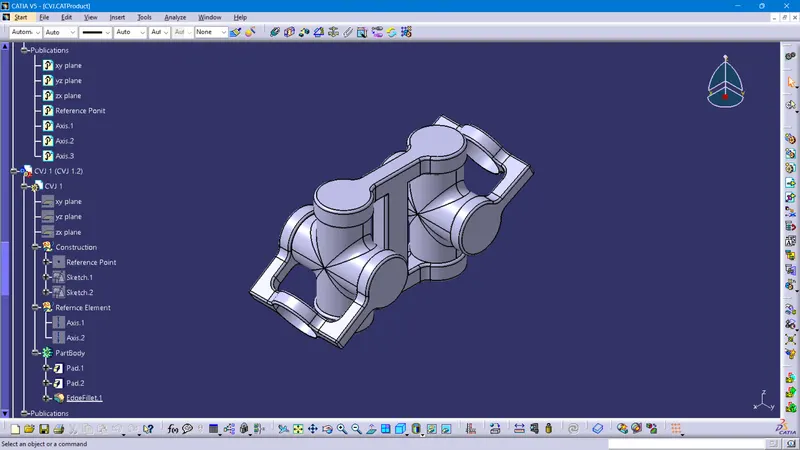
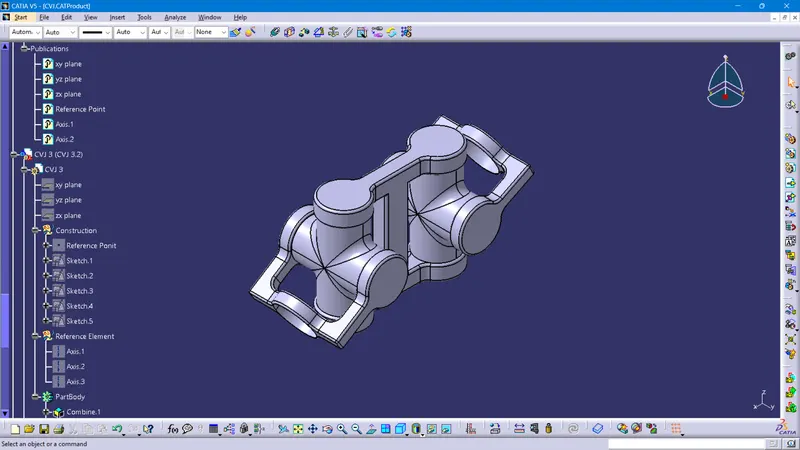
Views of the Assembly
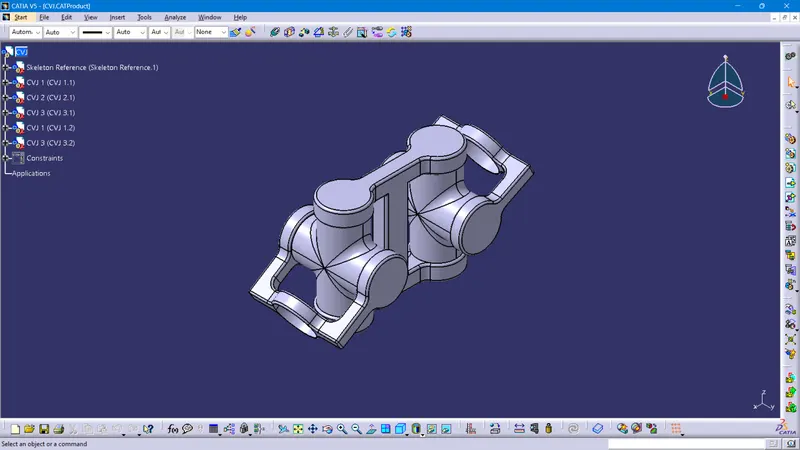
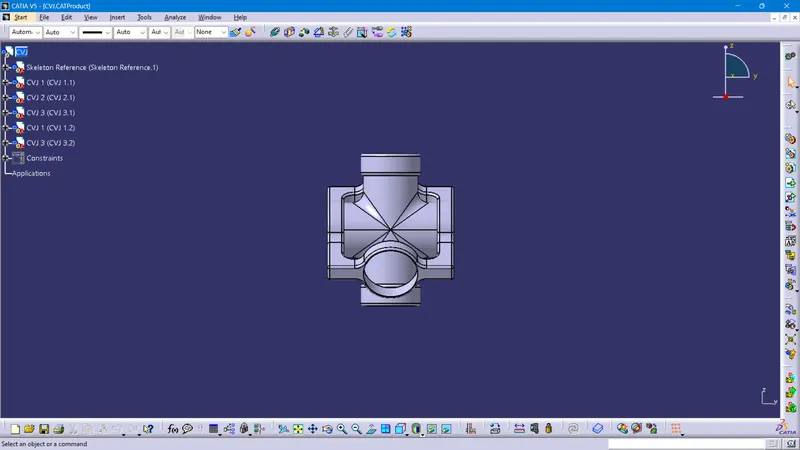
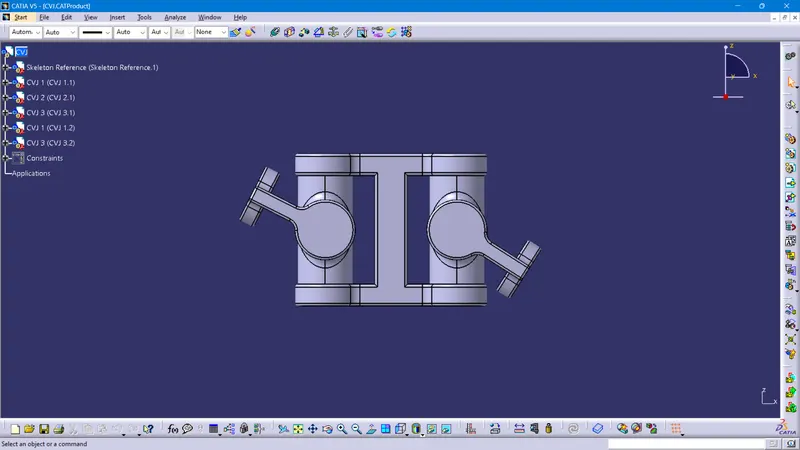
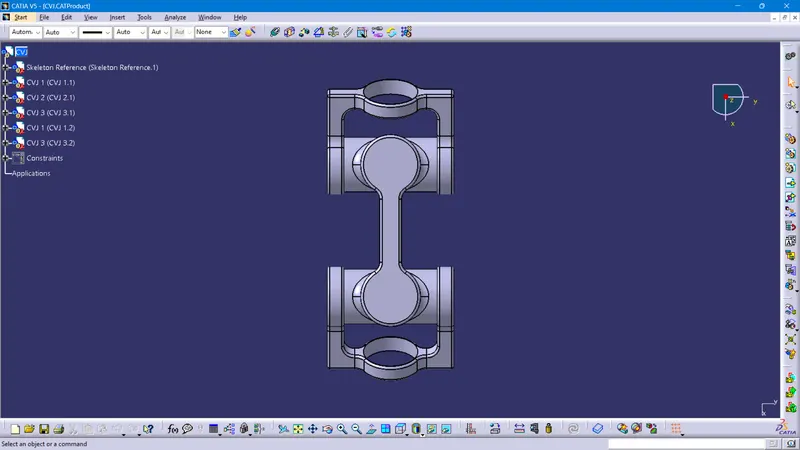
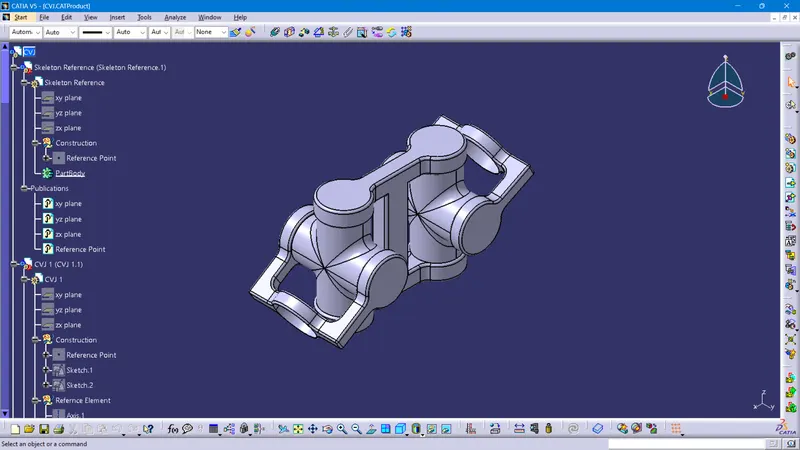
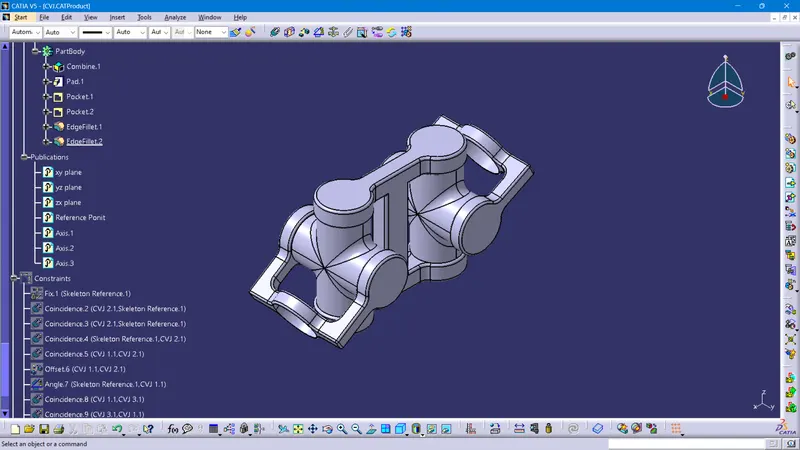
Feature Tree of the Assembly
Conclusion
The CATIA V5 software was used to design two products: a Quick Return Mechanism and a CV Joint. The design process involved creating 2D sketches in the Sketcher Workbench for individual bodies which were then converted into solid bodies using the Part Workbench. The Assembly Workbench was utilized to assemble these bodies with respect to a Skeleton Reference Point, resulting in the creation of the two products. The Drafting Workbench was then used to create detailed drawings for each part. These steps were documented in detail in the report and also the files in the .CATPart and .CATProduct is attached to this report.