Week-4 Challenge WOT Condition Part-2
Mapped model in matlab:
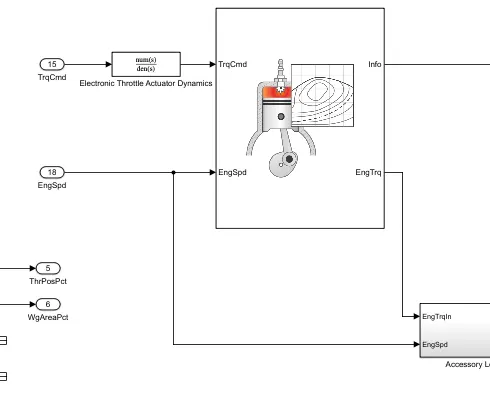
1) Model uses a set of steady-state lookup tables to characterize engine performance.
2) The Look up tables provide overall engine characteristics, including actual torque, fuel flow rate, BSFC, and engine-out exhaust emissions.
Dynamic model in matlab:
Model decomposes the engine behavior into engine characteristics that are separated into lower-level components. By combining components in this way, the models capture the dynamic effects.
Description of the Mapped and Dynamic Models :
Mapped Engine: Mapped Engine is the default settings in powertrain blockset. It is used to measure to measure performance parameters of the vehicle by using standard lookup tables which are prefed to the system. This type of modelling is less accurate. The lookup tables value are based on the values of brake torque, commanded torque and engine speed. If any other parameter like Input engine temperature is selected then lookup table values are also a function of the temperature parameter. The data extracted from lookup tables are: air mass flow, fuel flow, emission data, exhaust temperature and efficiency. This data is used to find out other parameters which are needed by the end user.
Dynamic Engine: This type of model uses real time data fed by the user at run time for modelling. This model is more accurate than mapped engine model. This type of model is used when the data of subsystems of a vehicle is required. We can calculate : Brake torque, fuel flow, port gas mass flow, exhaust temperature, exhaust mass flow rate and exhaust emissions.
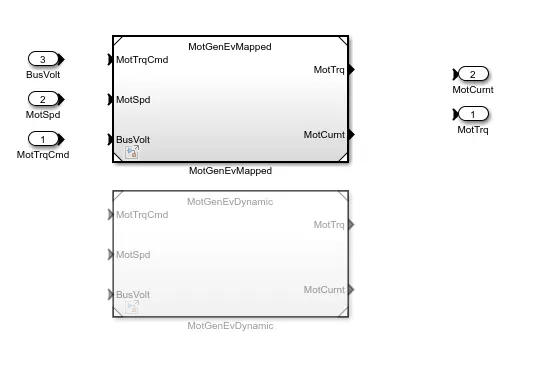
Mapped Motor: The mapped motor works in torque control mode. This type of motor is used when the user requires a faster simulation and doesn't have the knowledge of motor parameters. Input torque or speed can be specified, electrical losses and maximum motor power and torque can be defined.
Dynamic Motor: In the dynamic motor a three phase interior permanent magnet synchronous motor (PMSM) is used. The block uses three phase input voltages to regulate the individual phase currents, allowing control of the motor torque or speed. This block is used when the user knows what parameters are to be used in that particular simulation. This motor is more accurate.
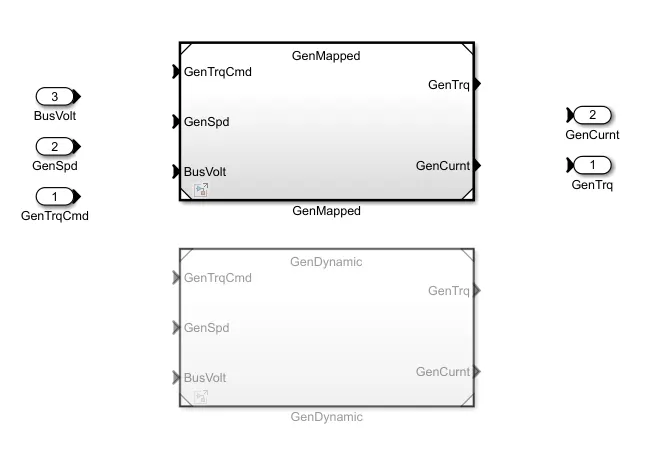
Mapped Generator: The mapped generator block is also similar like other blocks. Most of the data required is taken from the lookup tables corresponding to the given input parameters. Its simulation time is less.
Dynamic Generator: The dynamic generator involves user entering the parameters manually during the run time for their particular applications. The results take time and are more accurate.
How can you change model type?
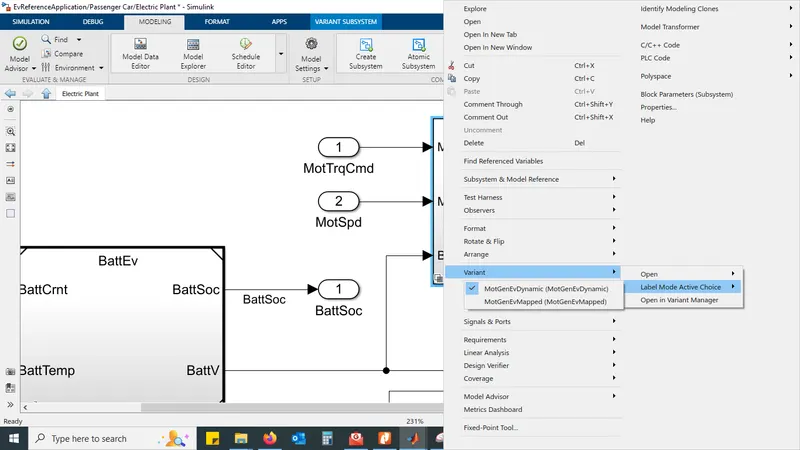
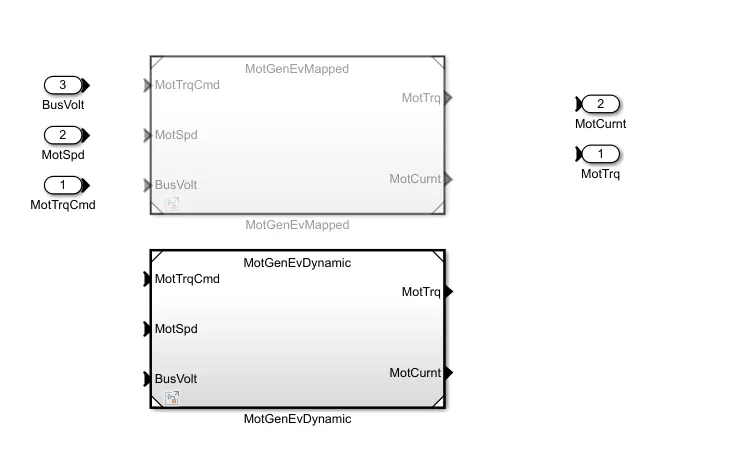
1) Open the EV Reference Application ==> Go to passenger car block ==> Go to electric plant block ==> In the motor block right click and select variant option ==> Select Model Active Choice and Select MotGenEvDynamic.
2) Dynamic model will be enabled as shown below.
2) calculate miles per gallon and factors to be consider:
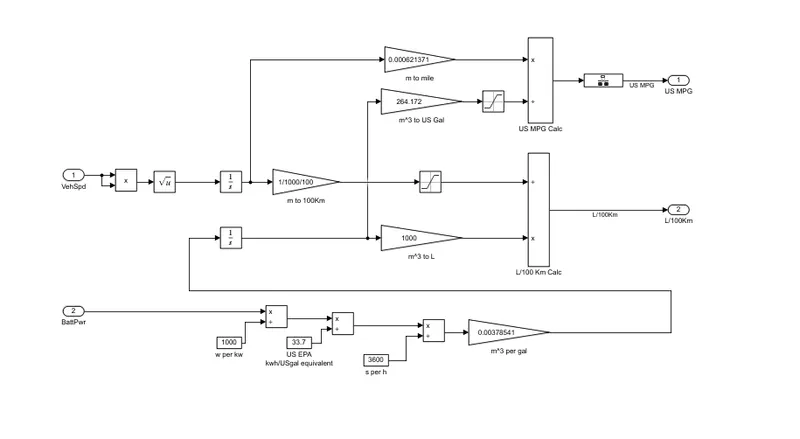
The following factors to be consider while calculate mpg are
1.vehicle speed.
2.fuel flow.
3.battery power.
The following block diagram shows the calculation of mpg using the vehicle parametrs.
3) HEV ReferenceApplication with WOT drive cycle:
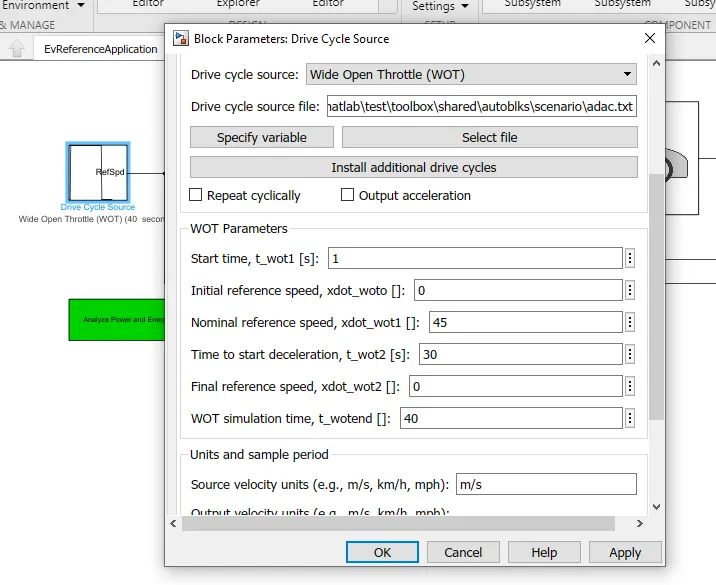
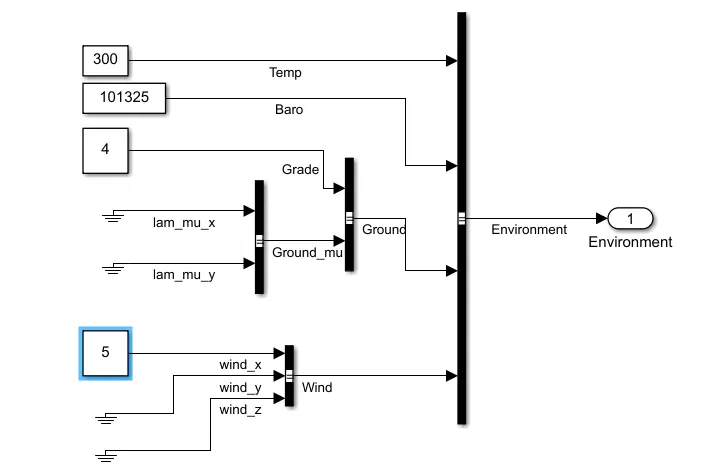
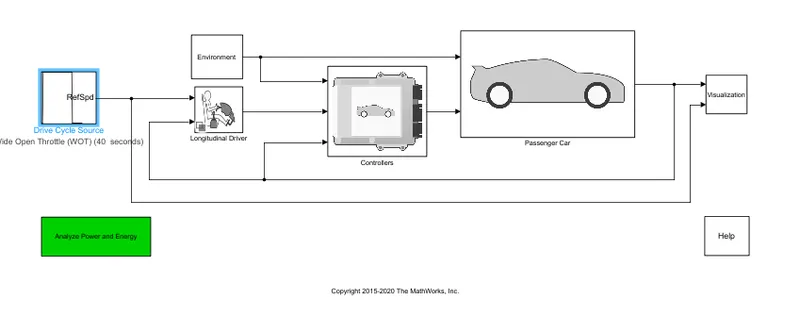
WOT drive dycle was siulated with reference speed =45, and time for 40 sec. Also added Grade = 4 and Wind paramer as 5. the Vehicle is simulated and results are discussed below.
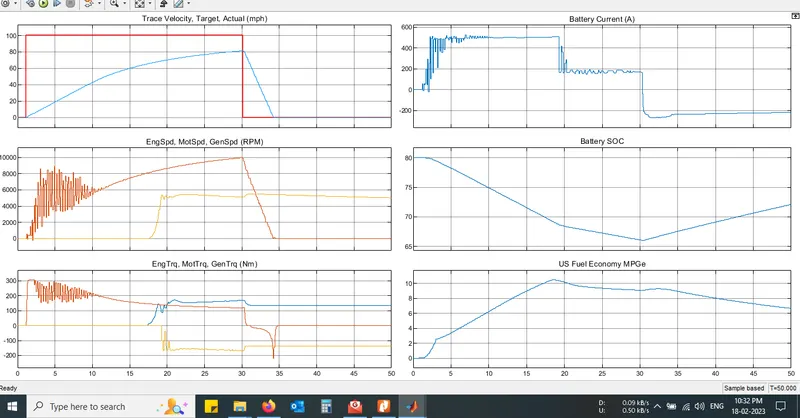
From the above simulation outcome, the following points to be concluded:
top Speed achieved =80 mph.
time taken to deaccelerate =3.5 sec.
Battery SoC: has decresed while accelerating : 80% to 65.5% and charged upto 72% while deacceleration.
Battery Maximum Ampere is limited to 500A.
4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
with the same WOT, with wind = 5 and Grade = 4, the results of Ev are shown below:
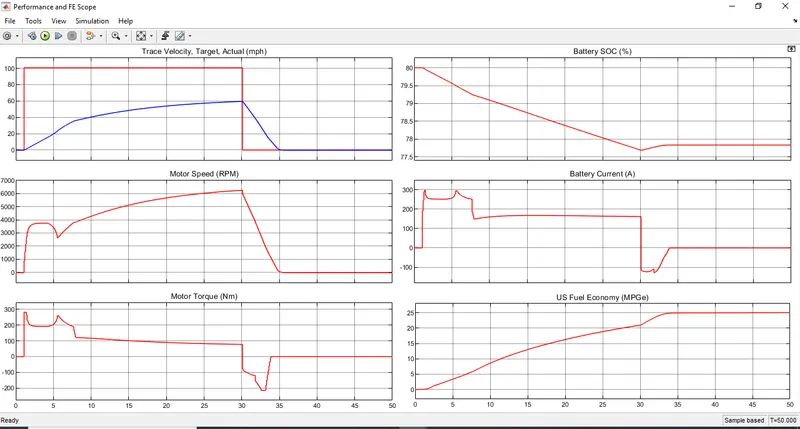
top Speed achieved =60 mph.
time taken to deaccelerate = 5 sec.
Battery SoC: has decresed while accelerating : 80% to 77.7% and charged upto 78% while deacceleration.
Battery Maximum Ampere is limited to 300A.
motor speed reaches maximum to 6200RPM.