Week-4 Challenge WOT Condition Part-2
- What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Mapped models:
Mapped models are used when the behaviour of a particular model is not of our interest and can be modeled with predefined values in the form of lookup tables
Example:EV mapped motor/generator
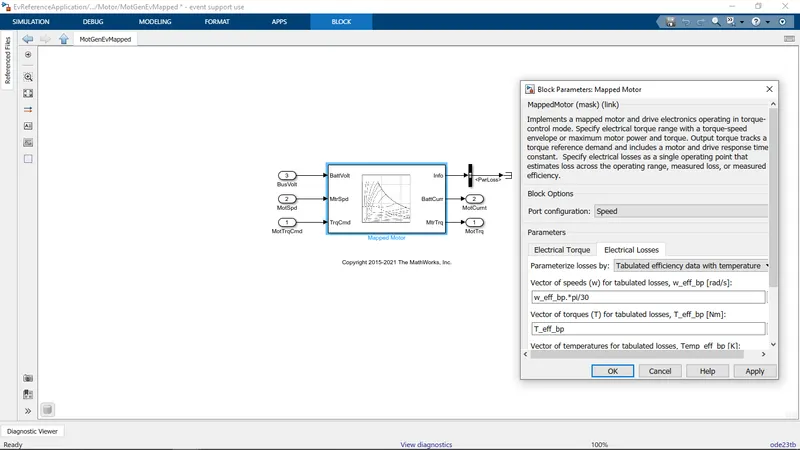
In above modle values are taken from experiments or lold data and Implements a mapped motor and drive electronics operating in torque control mode.
We have to specify electrical torque range with a torqu speed envelope or maximum motor power and torque.
Output torque tracks a torque reference demand and includes motor and drive responce time constant.
Dynamic model:
Dynamic modles are used when the internal responce to a model with respect to its component is needed
Example:EV dynamic motor generator
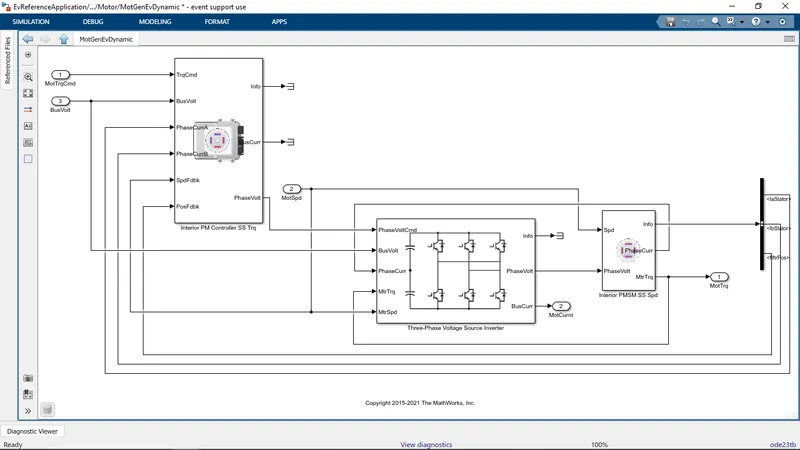
In the above model motor components such as inverter,phase controller,feedback circuits are also modelled
Changing the model type:
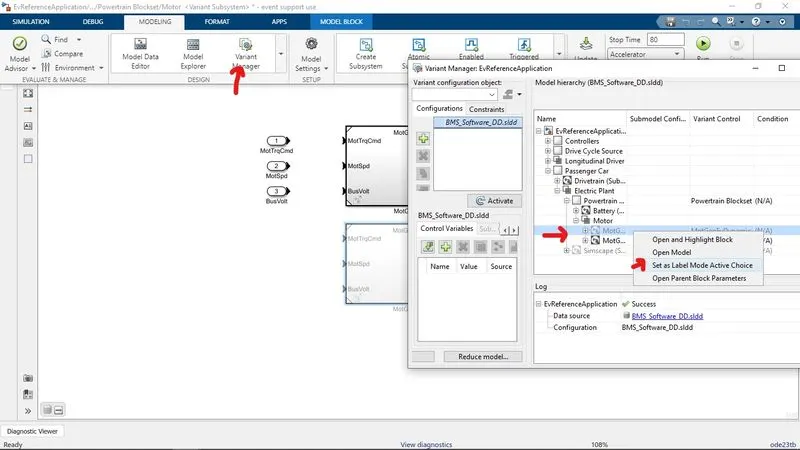
To change the model type -go to modeling block>choose variant manager>choose which type of model you want to operate & right click on it >and tap on set as label mode active choice
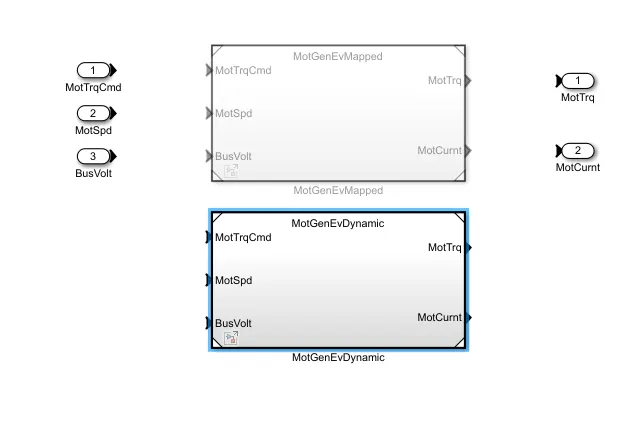
the model has changed drom mapped to dynamic model that is shown below
2.How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
The factors cosidered for indicating the fuel efficiency are
1.Vehicle speed
2.Battery power
3.fuel volume flow
The convertion of miles per gallon and fuel flow is shown below
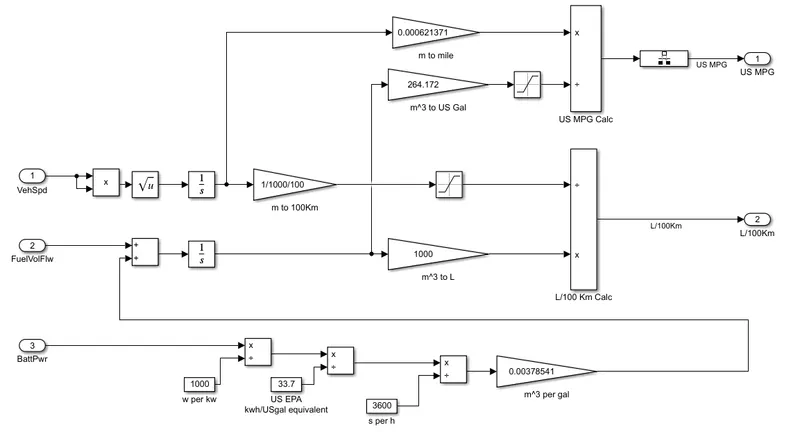
- As per the US environmental protection agency(EPA) 1 gallon of gasoline is equal to 33.7kWh
- So this measurement applies all the vehicles including pure EV
- In that above design Vehicle speed is integrated and the distance is measured km and later it is converted to miles
- And Battery power is used to find power used in kWh which nis then converted to gasoline equivalent by deviding 33.7
- for vehicles which are running using gasoline and battery for those 1gallon=gasoline+battery equivalent of 33.7kWh is cosidered
- So deviding distance in miles by total no.of gallons,we can fet MPGa
3.Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
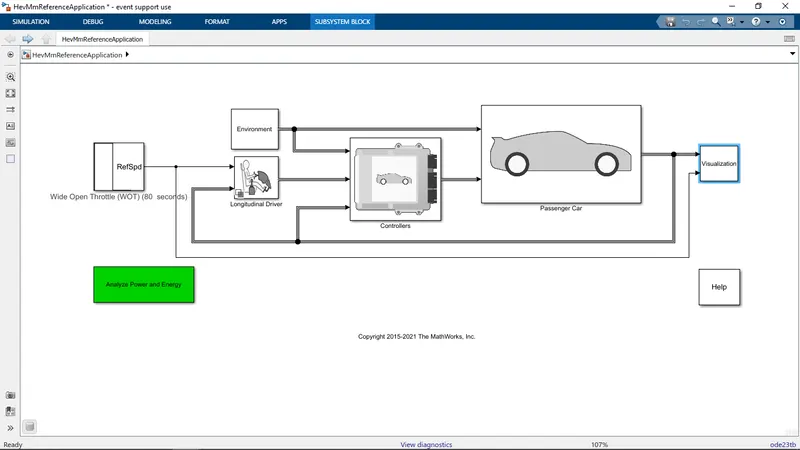
HEV reference application with WOT drive cycle is shown below
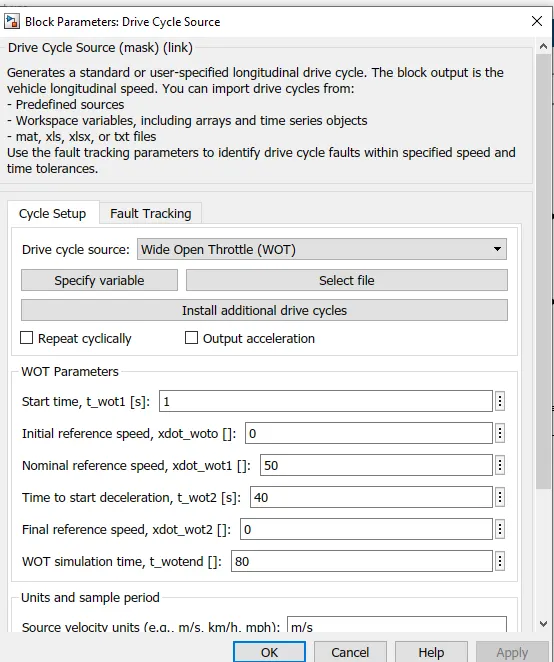
The WOT parameters shown below
This the WOT responces of the car is shown below with different grade and wind velocity
- grade =0 and wind velocity=0m/s
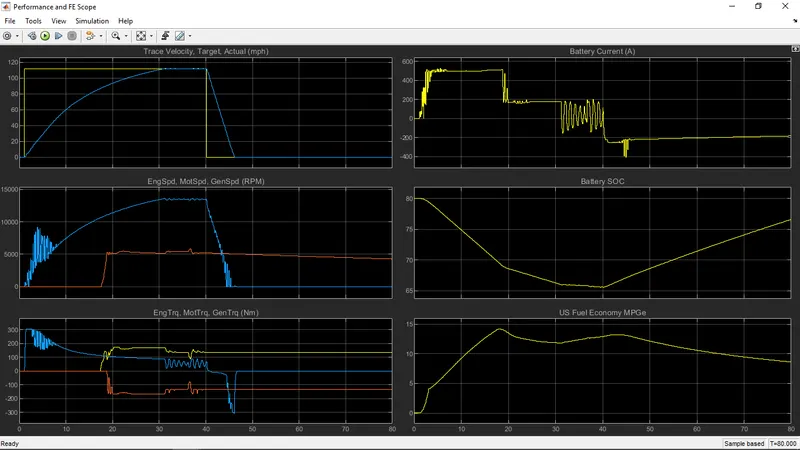
2.grade =10% and wind velocity=10m/s
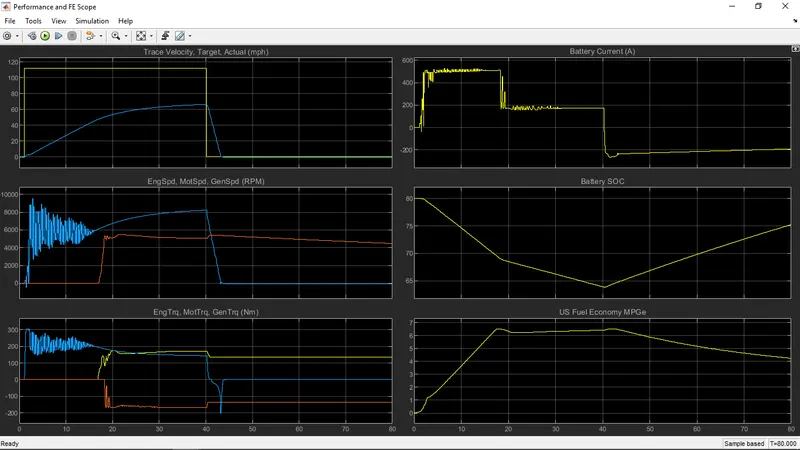
By comparing both the results with grade and wind velocity,
Peak velocity achieved is reduced as grade and wind velocity increases
so deceleration time got reduces and hence the battery SOC get reduces as grade and wind velocity increases
4.Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
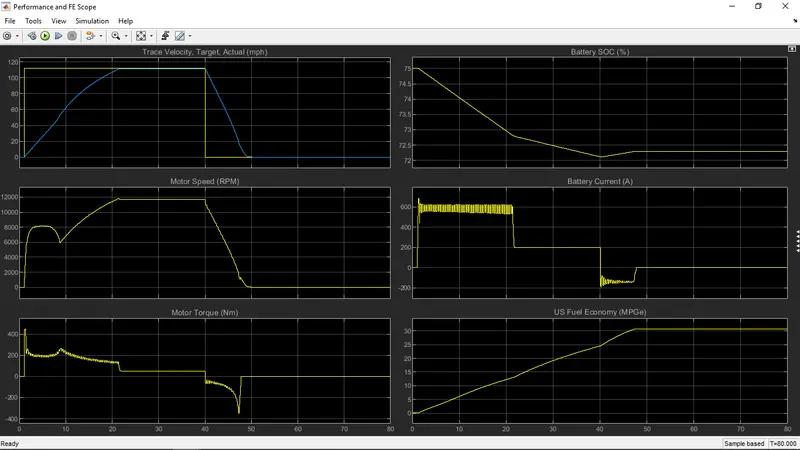
Appying same WOT responce conditions for both the vehilces and keeping all othe parameters we can see the resopnce of bothe vehicles
Responce of HEV
Responce of EV
Result:
Time taken to reach the same peak velocity is less for HEV as compared to EV
Deceleration time also low for HEV as compared to EV because it has more moving parts compared EV
Fuel economy also more for EV compared HEV